Topics / #simulation
Simulation projects on GitHub
Physics and fluid simulation engines for realistic motion and effects.
As of , the most-starred Simulation projects on GitHub are MiroFish (79.8K stars), gym (37.2K stars) and FreeCAD (34.4K stars). GitHub.Locker tracks 89 Simulation repositories with 710.4K stars combined. The fastest-growing on October 16 was text-to-cad, with +292 stars in a day.
Hot right now
Most stars gained in a day · Oct 16
 +292
text-to-cad
earthtojake/text-to-cad · ★ 21Ktext-to-cad is a library of agent skills for CAD, CAE and CAM: it gives coding agents focused workflows to generate, inspect, source, slice, and hand off CAD and robot-description artifacts from your local project files.
 +251
MiroFish
666ghj/MiroFish · ★ 79.8KMiroFish is an AI-powered multi-agent simulation engine that builds a high-fidelity digital parallel world from real-world seed data (breaking news, policy drafts, financial signals) and lets thousands of independent agents interact to forecast future outcomes.
 +66
founder-skill
Jakeschincariol/founder-skill · ★ 868Founder Skill is a set of eleven free Claude skills that let you stress-test a business idea before spending money on it: a board of directors modeled on Hormozi, Thiel and Jobs frameworks, a marketing director, a CFO, and a consumer panel of 100 simulated buyer agents.
 +43
FreeCAD
FreeCAD/FreeCAD · ★ 34.4KFreeCAD is a free, open-source 3D parametric modeler for designing real-life objects of any size, from mechanical parts to architecture.
The all-time top
89 projects · by stars
- 79.8K#1 · 666ghj/MiroFish
MiroFish
MiroFish is an AI-powered multi-agent simulation engine that builds a high-fidelity digital parallel world from real-world seed data (breaking news, policy drafts, financial signals) and lets thousands of independent agents interact to forecast future outcomes.
- 37.2K
 #2 · openai/gym
gym
Gym is an open source Python library for developing and comparing reinforcement learning algorithms. It provides a standard API for learning algorithms to talk to environments, plus a standard set of environments built on that API.
- 34.4K#3 · FreeCAD/FreeCAD
FreeCAD
FreeCAD is a free, open-source 3D parametric modeler for designing real-life objects of any size, from mechanical parts to architecture.
- 4
genesis-world
30.1KGenesis-Embodied-AI/genesis-world · PythonIt's a simulation platform for general-purpose robotics and embodied AI learning: a multi-physics engine, a photorealistic renderer (Nyx) and a cross-platform compiler (Quadrants) behind one Python API.
- 5
taichi
28.4Ktaichi-dev/taichi · C++Taichi Lang is an open-source language for high-performance GPU programming embedded in Python: you write Python-like code and its JIT compiler turns it into efficient parallel GPU or CPU machine code.
- 6
lerobot
28.2Khuggingface/lerobot · PythonLeRobot is Hugging Face's open-source project providing models, datasets, and tools for real-world robotics in PyTorch, aiming to lower the barrier to entry for building and deploying robot learning policies.
- 7

apollo
26.9KApolloAuto/apollo · C++An open autonomous driving platform from Baidu: a high-performance, flexible software stack covering perception, prediction, planning and control, for developing, testing and deploying self-driving vehicles.
- 8

backtrader
23.5Kmementum/backtrader · Pythonbacktrader is a Python library for backtesting trading strategies: you write a strategy as code, run it against historical market data and measure how it would have performed before risking real money.
- 9
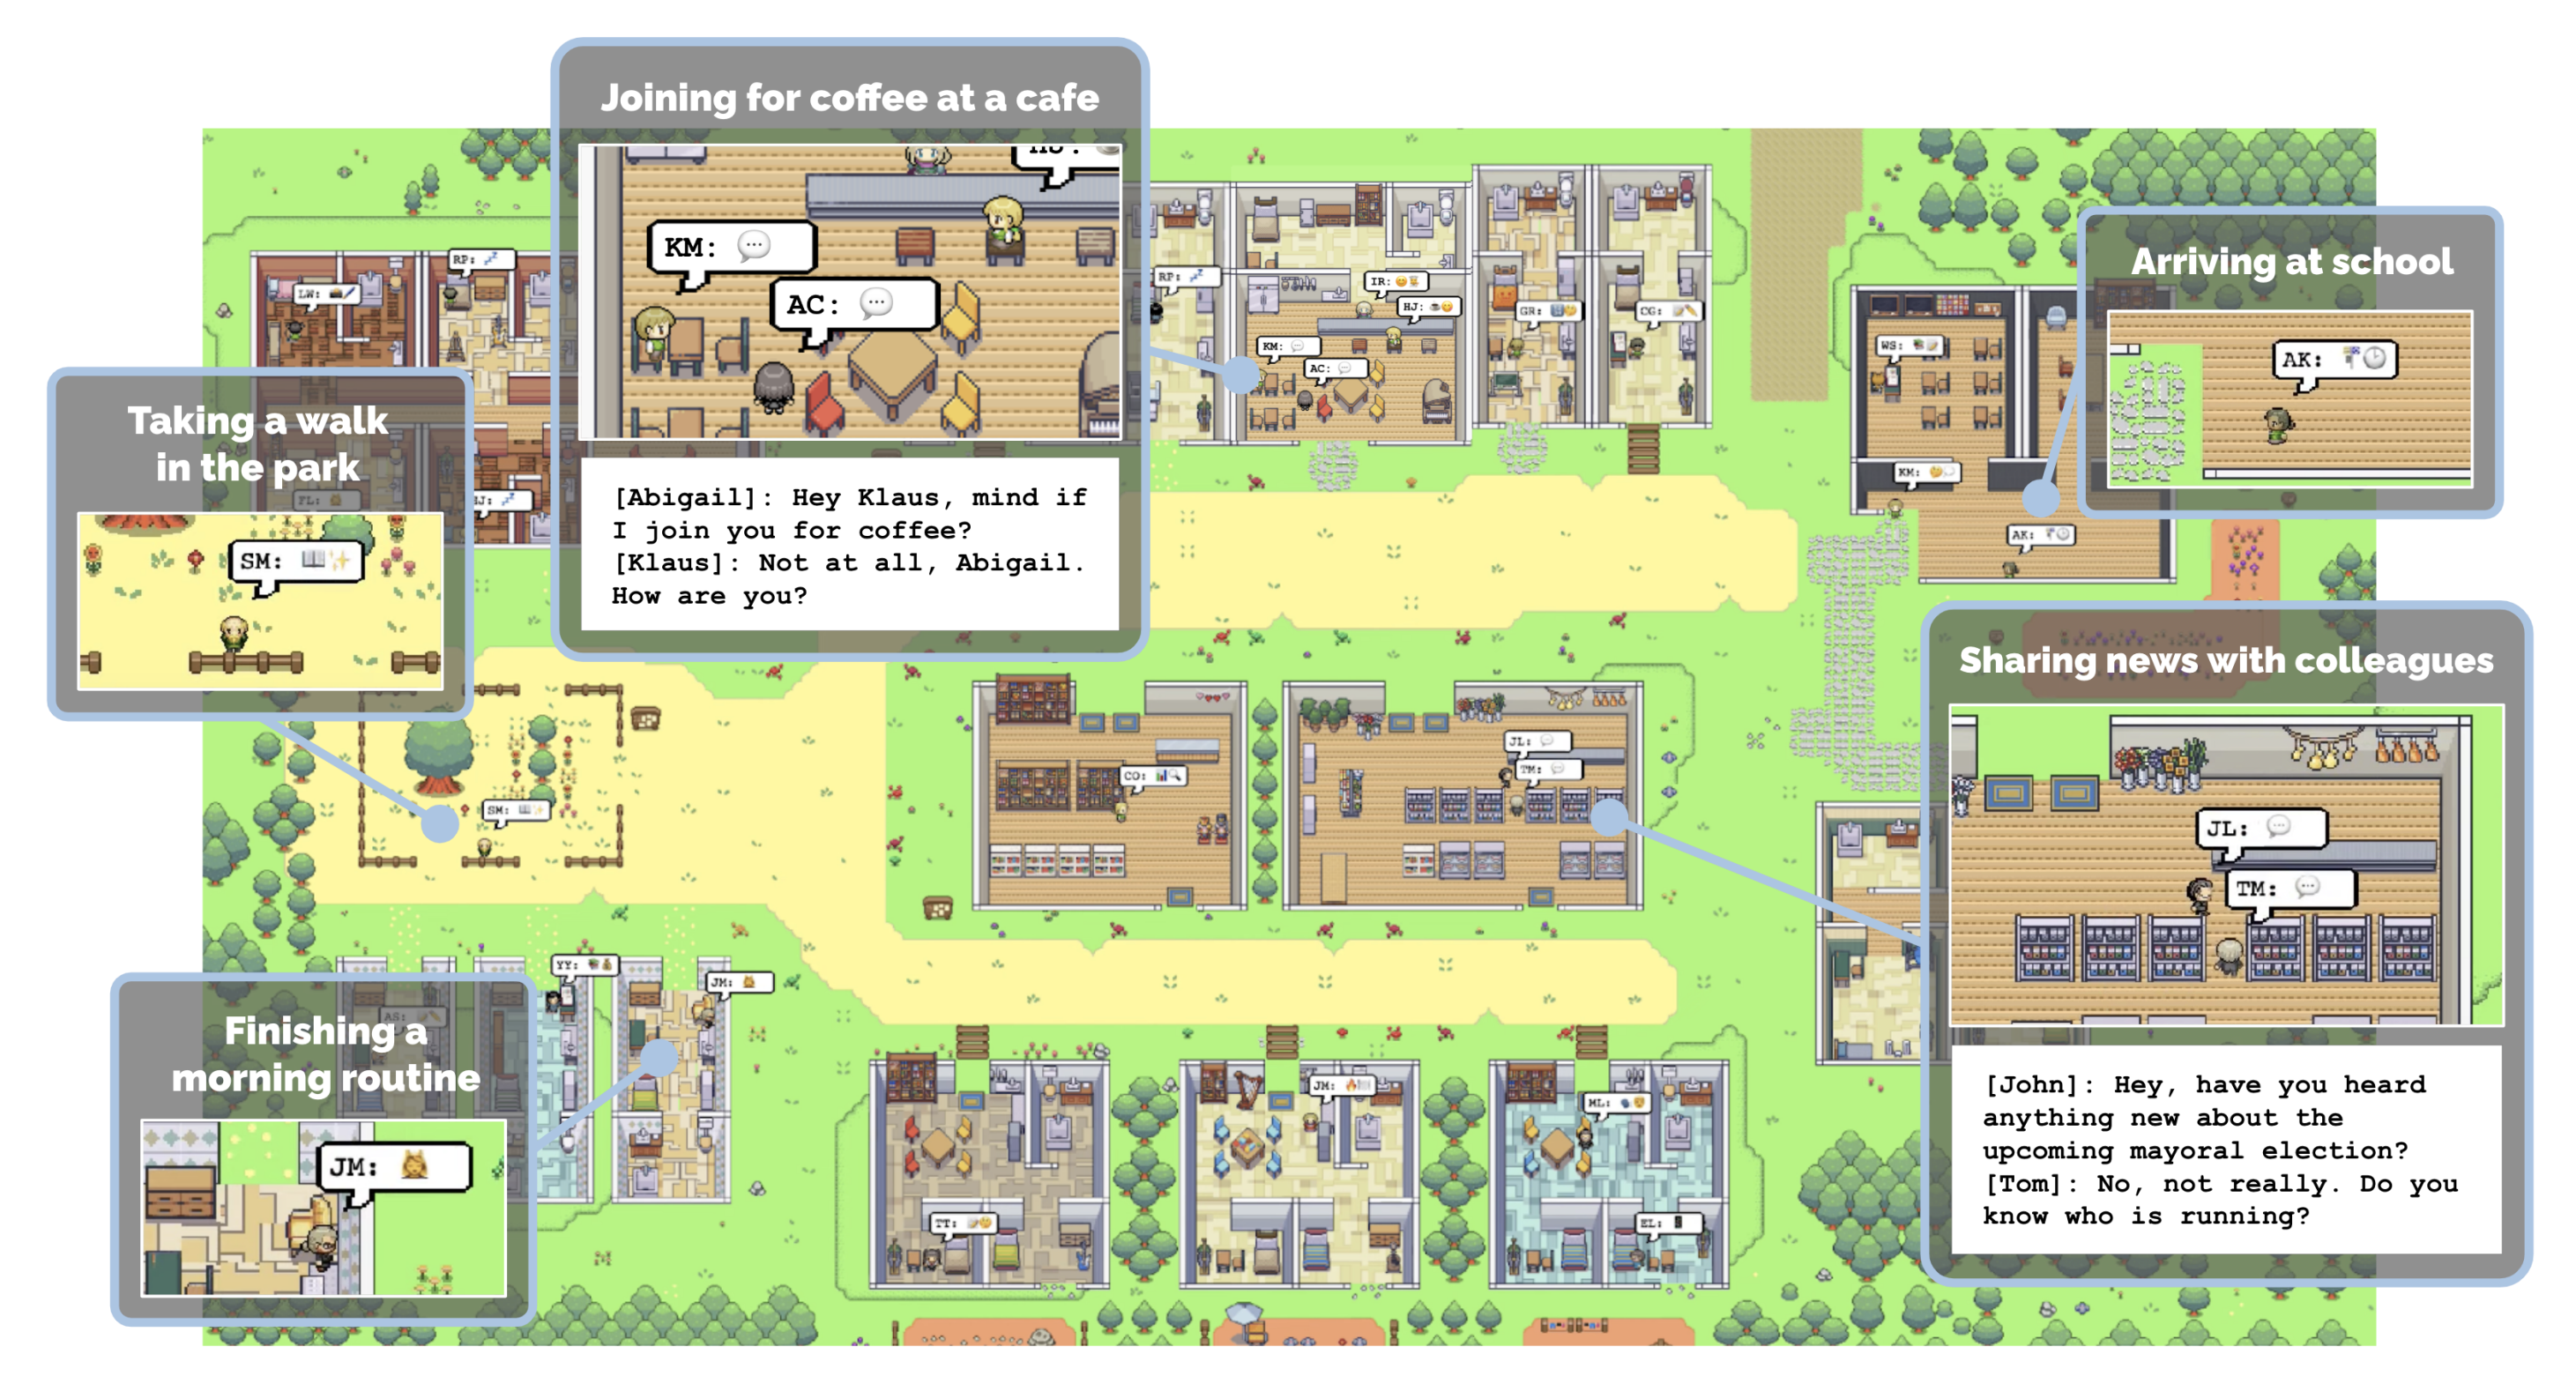
generative_agents
22.2Kjoonspk-research/generative_agentsThis is the official code release for the research paper 'Generative Agents: Interactive Simulacra of Human Behavior'. It contains the simulation module and game environment for computational agents that simulate believable human behavior in a sandbox town called Smallville.
- 10
text-to-cad
21Kearthtojake/text-to-cad · Pythontext-to-cad is a library of agent skills for CAD, CAE and CAM: it gives coding agents focused workflows to generate, inspect, source, slice, and hand off CAD and robot-description artifacts from your local project files.
- 11
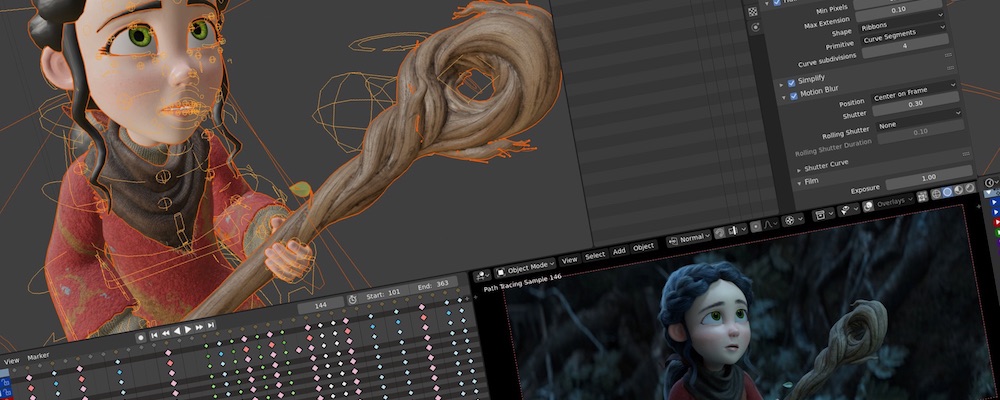
blender
21Kblender/blender · C++Blender is the free and open source 3D creation suite: one program covering modeling, rigging, animation, simulation, rendering, compositing, motion tracking and video editing. This GitHub repository is the official mirror of its source code.
- 12

ml-agents
19.8KUnity-Technologies/ml-agents · C#Unity ML-Agents Toolkit lets Unity games and simulations act as training environments for AI agents, using deep reinforcement learning and imitation learning. It pairs a Unity SDK with a Python API so game developers and researchers can train NPCs, test builds, or evaluate design decisions.
- 13
AirSim
18.6Kmicrosoft/AirSim · C++AirSim is an open-source simulator for drones, cars and more, built on Unreal Engine and created by Microsoft AI & Research. There is also an experimental Unity release.
- 14

matter-js
18.5Kliabru/matter-js · JavaScriptMatter.js is a JavaScript 2D rigid body physics engine for the web — a physics simulation you drop into web pages and Node.js apps.
- 15
camel
17.9Kcamel-ai/camel · PythonCAMEL is an open-source multi-agent framework for building, simulating and studying LLM-powered agents at scale, aimed at finding the 'scaling laws of agents'.
- 16
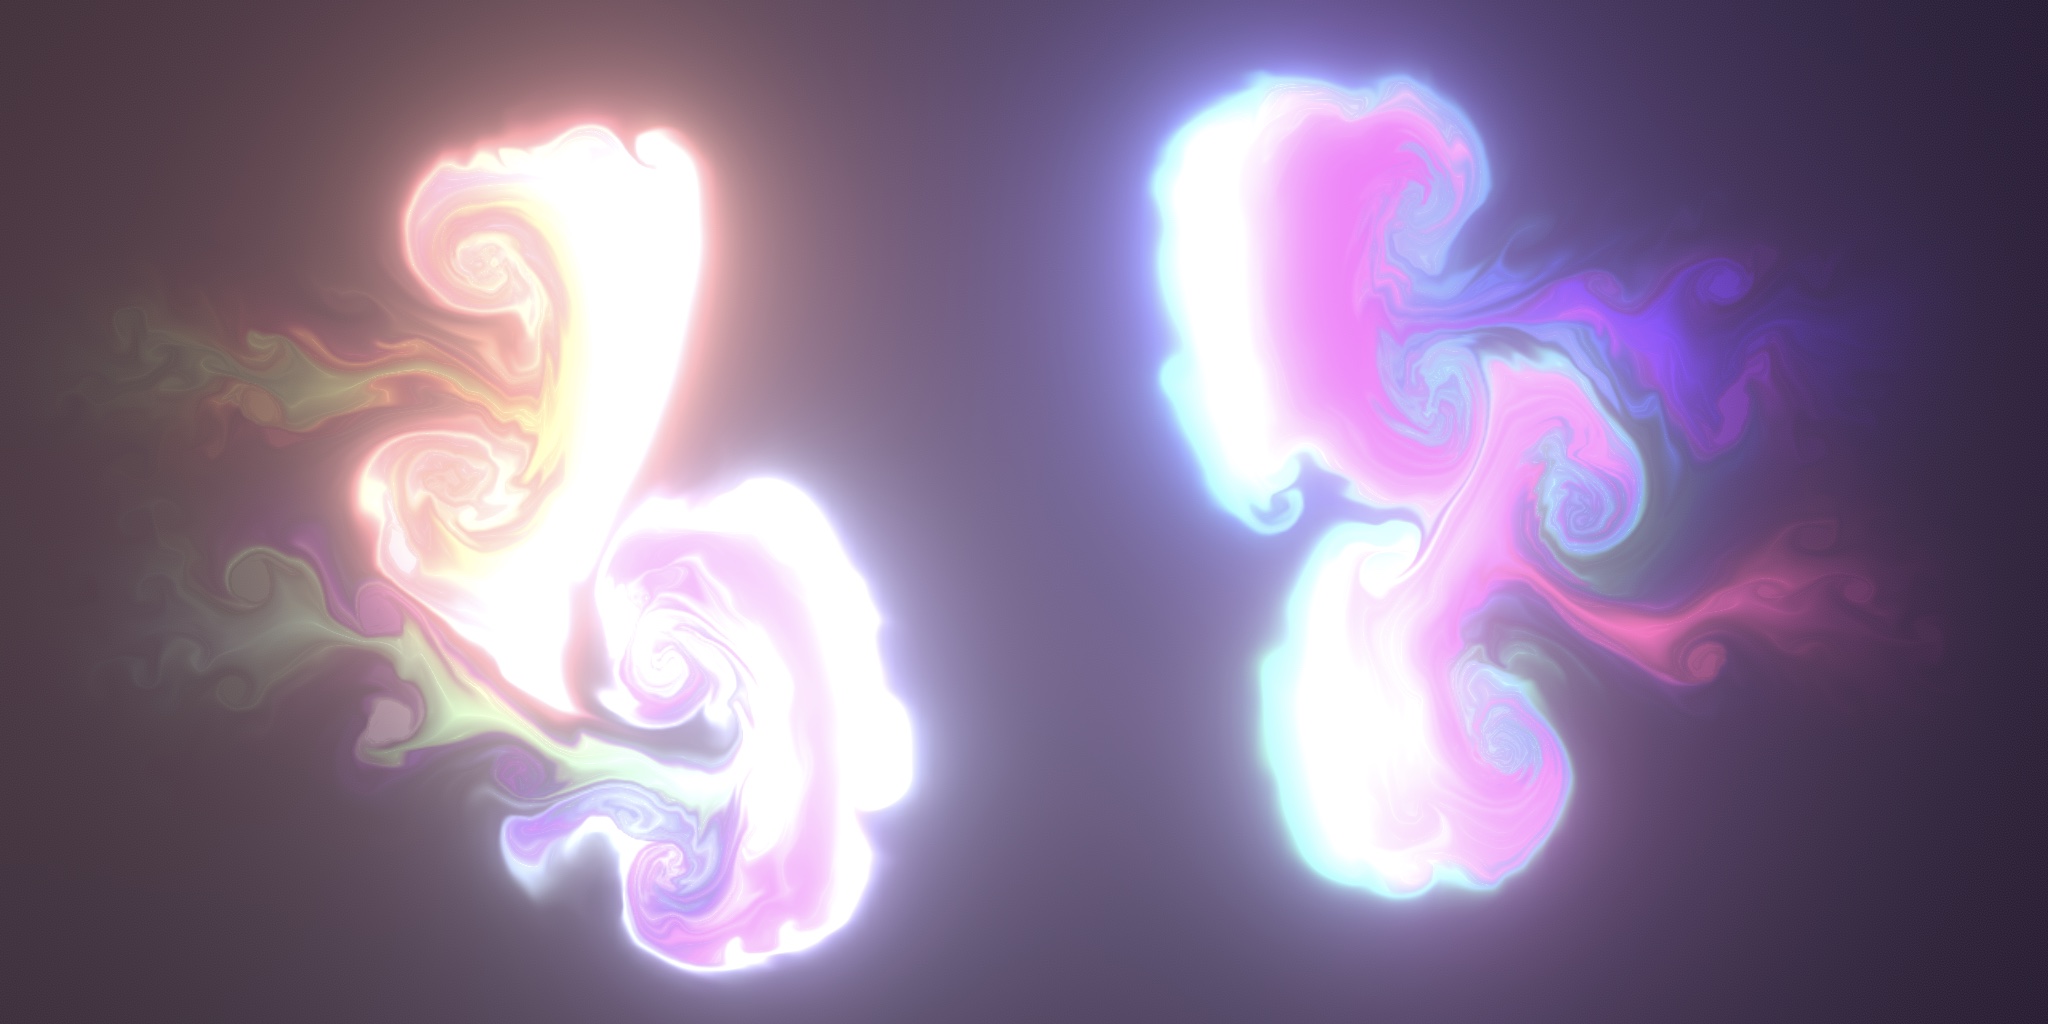
WebGL-Fluid-Simulation
16.7KPavelDoGreat/WebGL-Fluid-Simulation · JavaScriptIt is an interactive WebGL demo that simulates fluid dynamics in real time, letting you swirl colorful liquid-like effects with your mouse or finger directly in the browser.
- 17
Embodied-AI-Guide
16.5KTianxingChen/Embodied-AI-GuideA free, encyclopedia-style Chinese knowledge base and resource index for embodied AI — robots that perceive and act in the physical world — maintained by the Lumina Embodied AI community. It is one of the most popular embodied-AI guides in China, with over 16,000 GitHub stars.
- 18
OpenRCT2
16.4KOpenRCT2/OpenRCT2 · C++OpenRCT2 is an open-source re-implementation of RollerCoaster Tycoon 2, the classic construction and management sim where you build and run an amusement park and keep guests happy.
- 19
mujoco
15.7Kgoogle-deepmind/mujoco · C++MuJoCo is a general-purpose physics engine for simulating articulated structures interacting with their environment, maintained by Google DeepMind. It targets robotics, biomechanics, graphics/animation, and machine learning research.
- 20
bullet3
14.8Kbulletphysics/bullet3 · C++Bullet Physics SDK is the official C++ library for real-time collision detection and multi-physics simulation, used in VR, games, visual effects, robotics and machine learning.
- 21
QGIS
14.6Kqgis/QGIS · C++QGIS is a free, open-source, cross-platform desktop GIS (geographic information system) for viewing, editing, and analyzing spatial data like maps, satellite imagery, and geospatial databases.
- 22
carla
14.5Kcarla-simulator/carla · C++CARLA is an open-source simulator for autonomous driving research, built from the ground up to support development, training, and validation of self-driving systems, with open urban layouts, buildings, and vehicle assets.
- 23
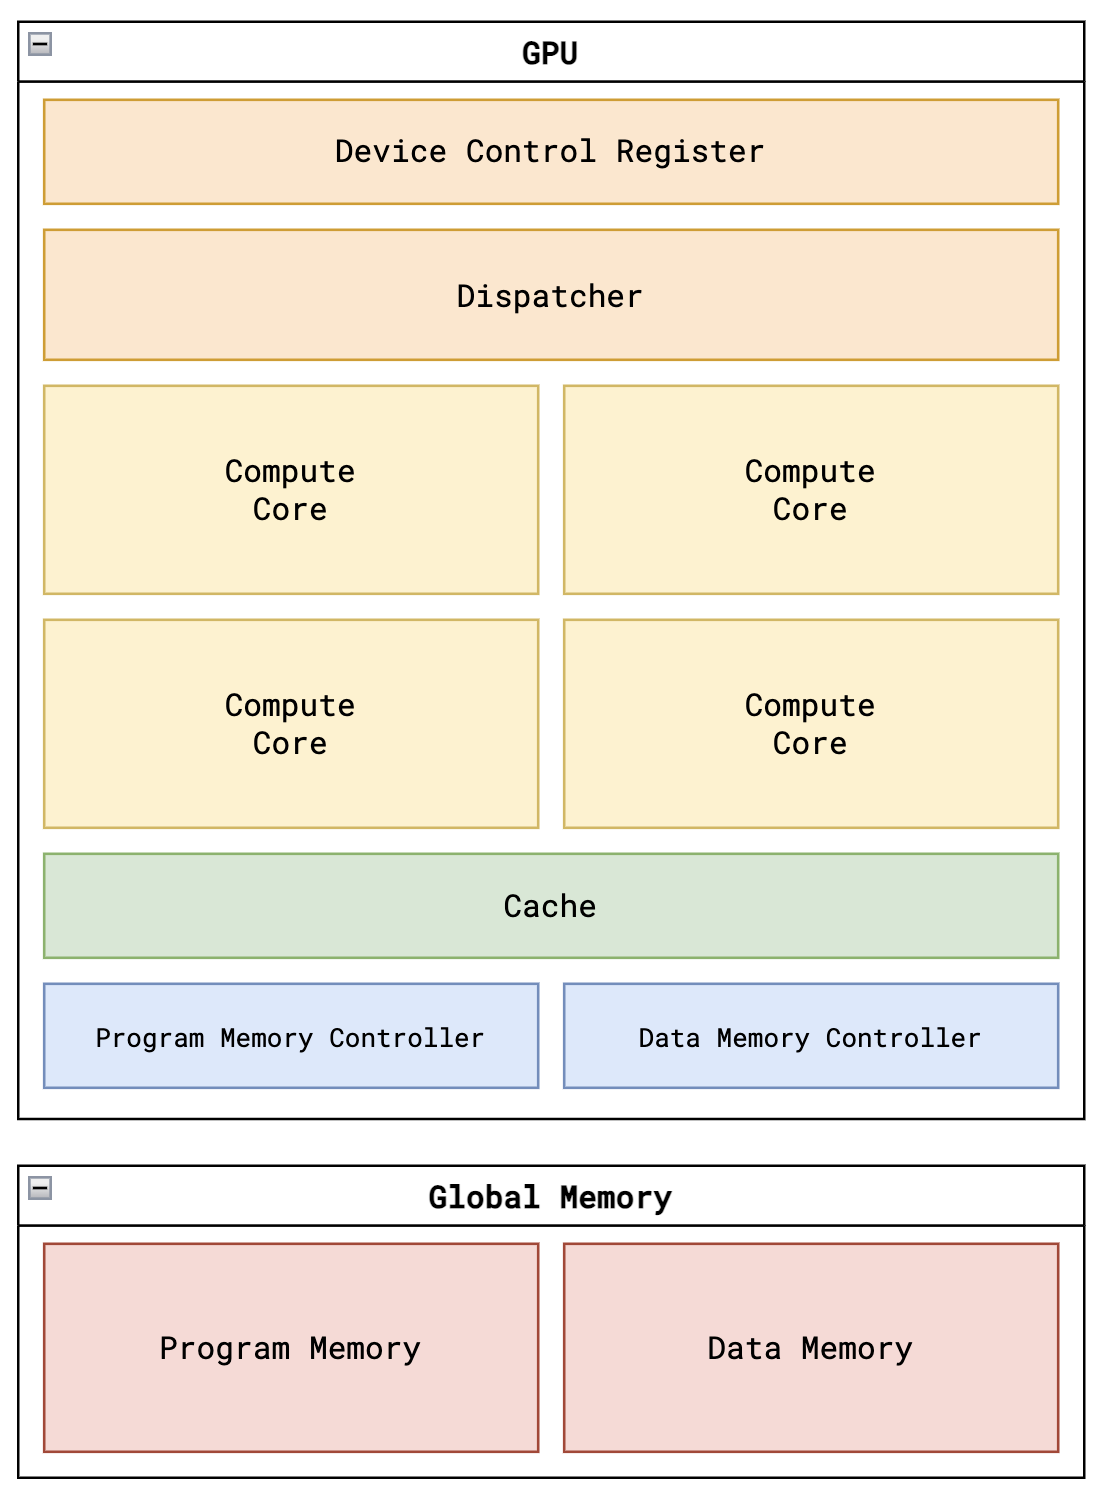
tiny-gpu
13.1Kadam-maj/tiny-gpu · SystemVerilogtiny-gpu is a minimal GPU design written in Verilog (SystemVerilog) built purely to teach how GPU architecture works from the ground up, covering core concepts like SIMD parallelization, memory bandwidth management, and instruction execution.
- 24

PX4-Autopilot
12.8KPX4/PX4-Autopilot · C++PX4 is an open-source autopilot stack for drones and unmanned vehicles — the flight software behind multirotors, fixed-wing planes, VTOLs, rovers and other unmanned platforms.
- 25
Gymnasium
12.7KFarama-Foundation/Gymnasium · PythonGymnasium is an open source Python library that provides a standard API for single-agent reinforcement learning environments, along with a set of popular reference environments. It is the maintained fork of OpenAI's Gym, continuing development after OpenAI handed it over.
- 26

autoware
12.2Kautowarefoundation/autoware · DockerfileAutoware is the world's leading open-source autonomous driving framework — a complete software stack for building self-driving vehicles.
- 27
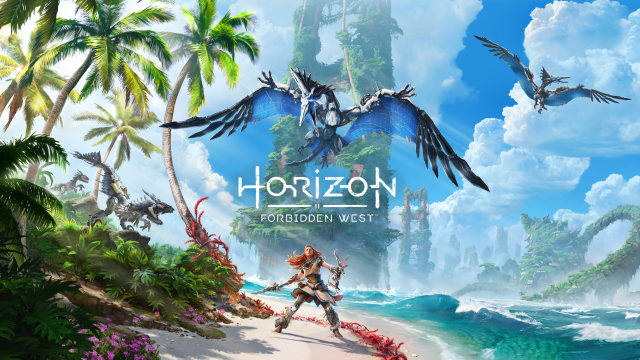
JoltPhysics
11.7Kjrouwe/JoltPhysics · C++Jolt Physics is a multi-core friendly rigid body physics and collision detection library written in C++, built for games and VR applications. It's the engine behind 'Horizon Forbidden West' and 'Death Stranding 2: On the Beach'.
- 28
dopamine
10.9Kgoogle/dopamine · Jupyter NotebookDopamine is a research framework for fast prototyping of reinforcement learning algorithms — a deliberately small, easily grokked codebase meant for trying out speculative research ideas.
- 29

ai-town
10.7Ka16z-infra/ai-town · TypeScriptAI Town is an MIT-licensed starter kit for building a virtual town where AI characters live, chat, and socialize with each other.
- 30
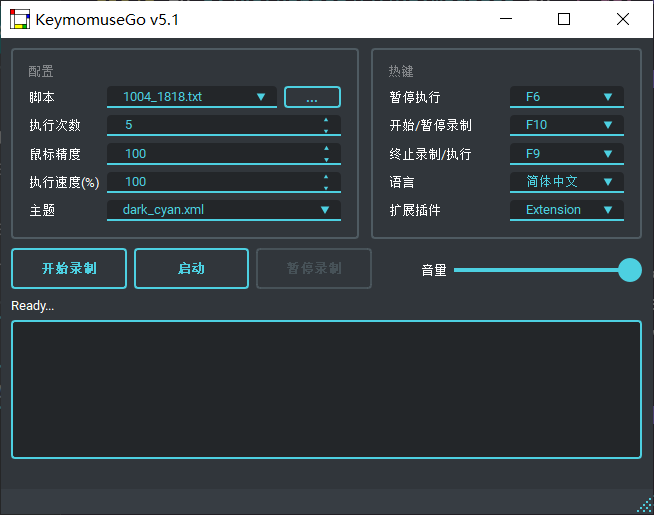
KeymouseGo
10.6Ktaojy123/KeymouseGo · PythonKeymouseGo is a free, open-source tool for Windows, macOS and Linux that records your mouse clicks and keyboard input and replays them automatically, as many times as you set. It is made for simple, repetitive work: you do the task once, then the computer repeats it.
- 31
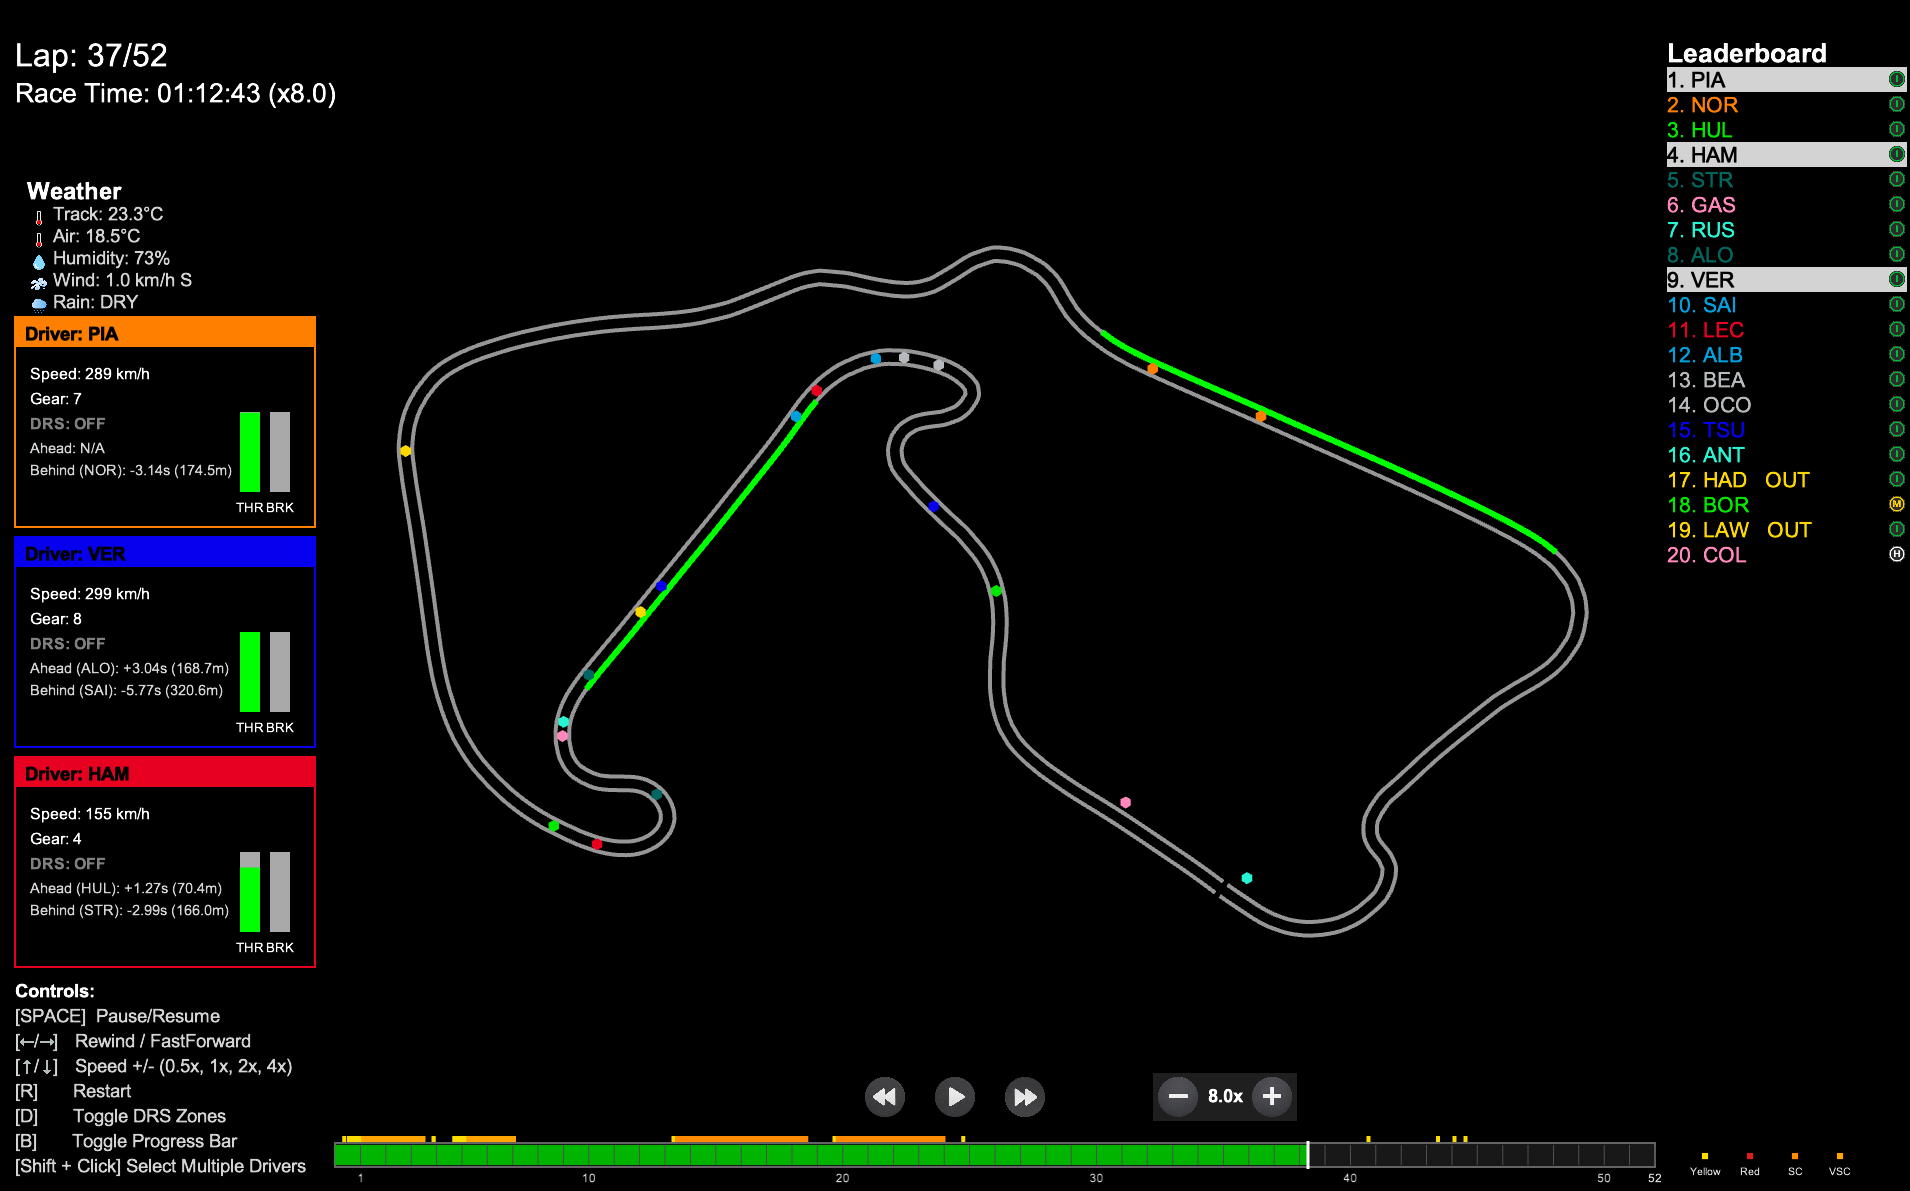
f1-race-replay
6.8KIAmTomShaw/f1-race-replay · PythonF1 Race Replay is a Python desktop app that visualizes real Formula 1 race telemetry and lets you replay race events with an interactive, animated track view.
- 32

box3d
6.6Kerincatto/box3d · CBox3D is a 3D physics engine for games, written by Erin Catto, the author of Box2D.
- 33
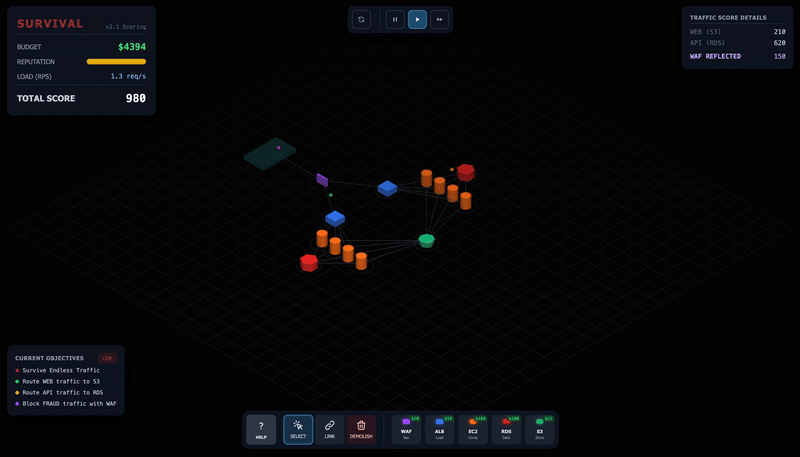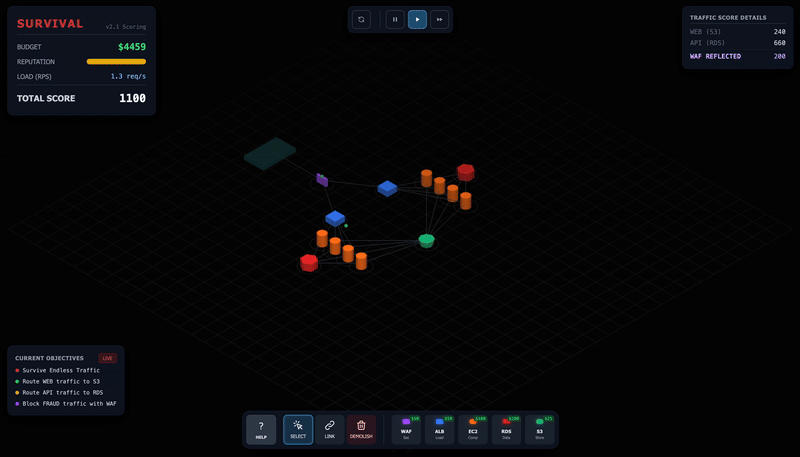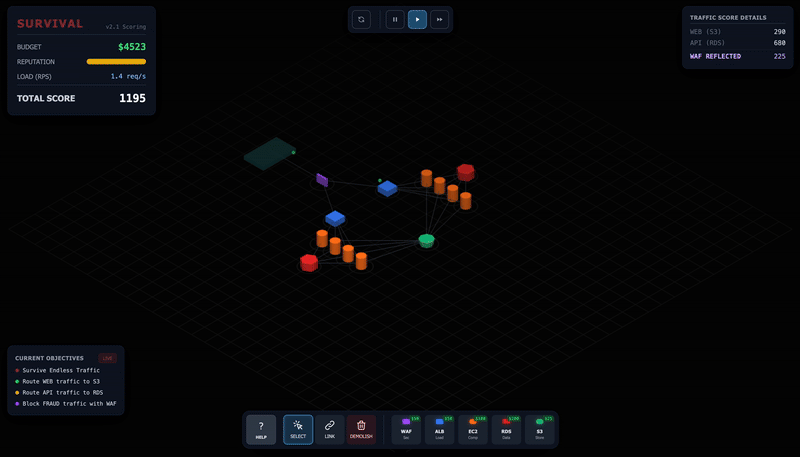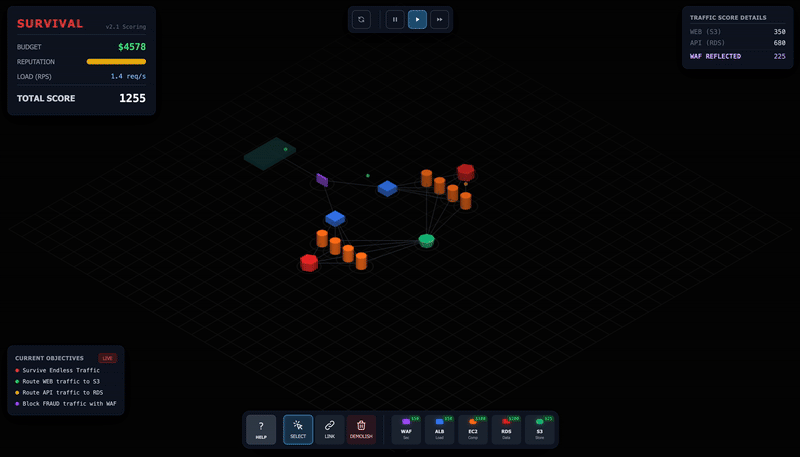
server-survival
6.4Kpshenok/server-survival · JavaScriptServer Survival is an interactive 3D tower-defense-style game where you play a Cloud Architect, building and scaling cloud infrastructure to survive growing traffic and DDoS attacks while learning real cloud architecture concepts.
- 34

xq-py
5.5KQuipNetwork/xq-pyxq-py is a Python implementation of the Quip Network's quantum virtual machine (QVM).
- 35
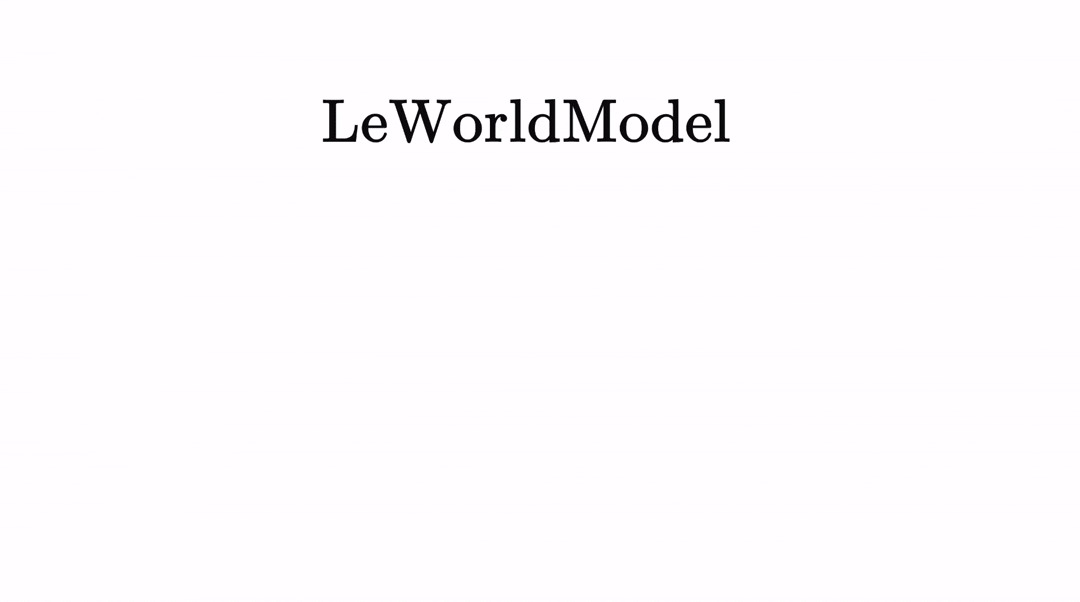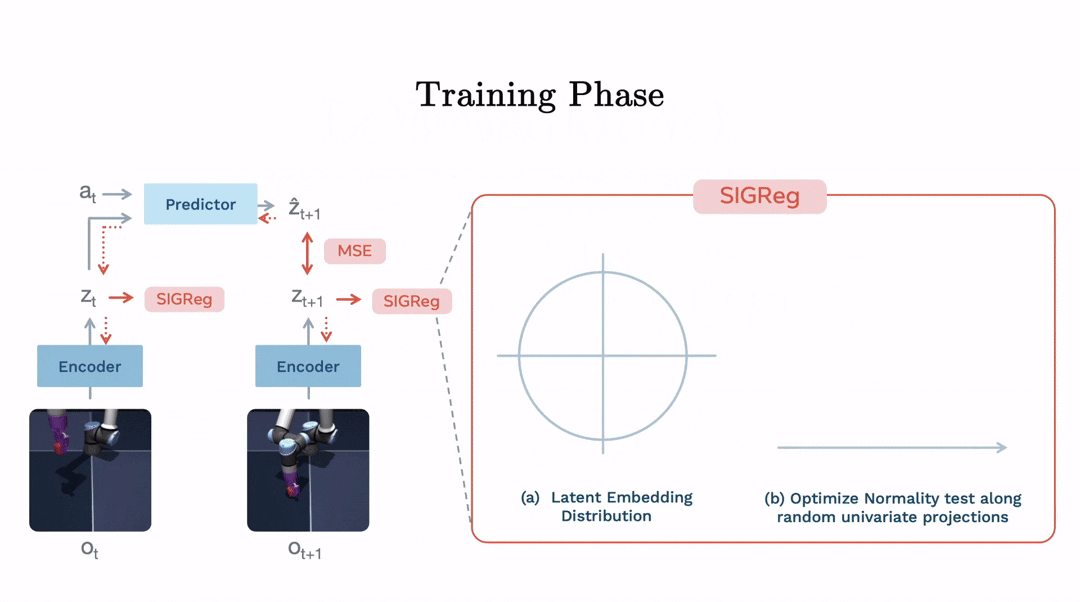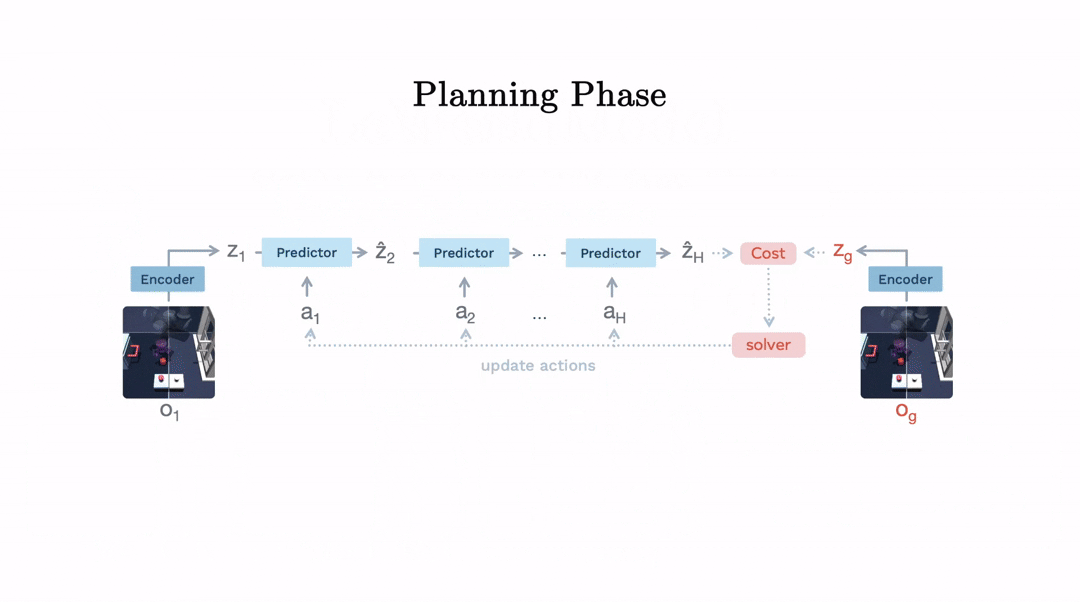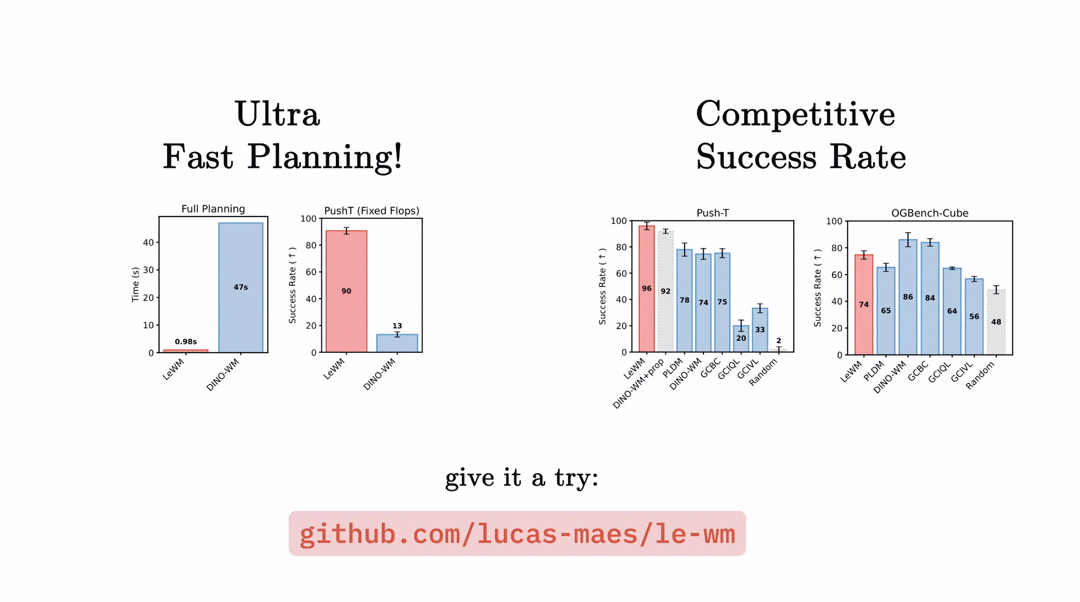
le-wm
4.5Klucas-maes/le-wm · PythonThis is the official codebase for LeWorldModel (LeWM), a Joint-Embedding Predictive Architecture (JEPA) that learns a world model directly from pixels using just two loss terms, avoiding the usual tricks like EMA, pretrained encoders, or auxiliary supervision.
- 36
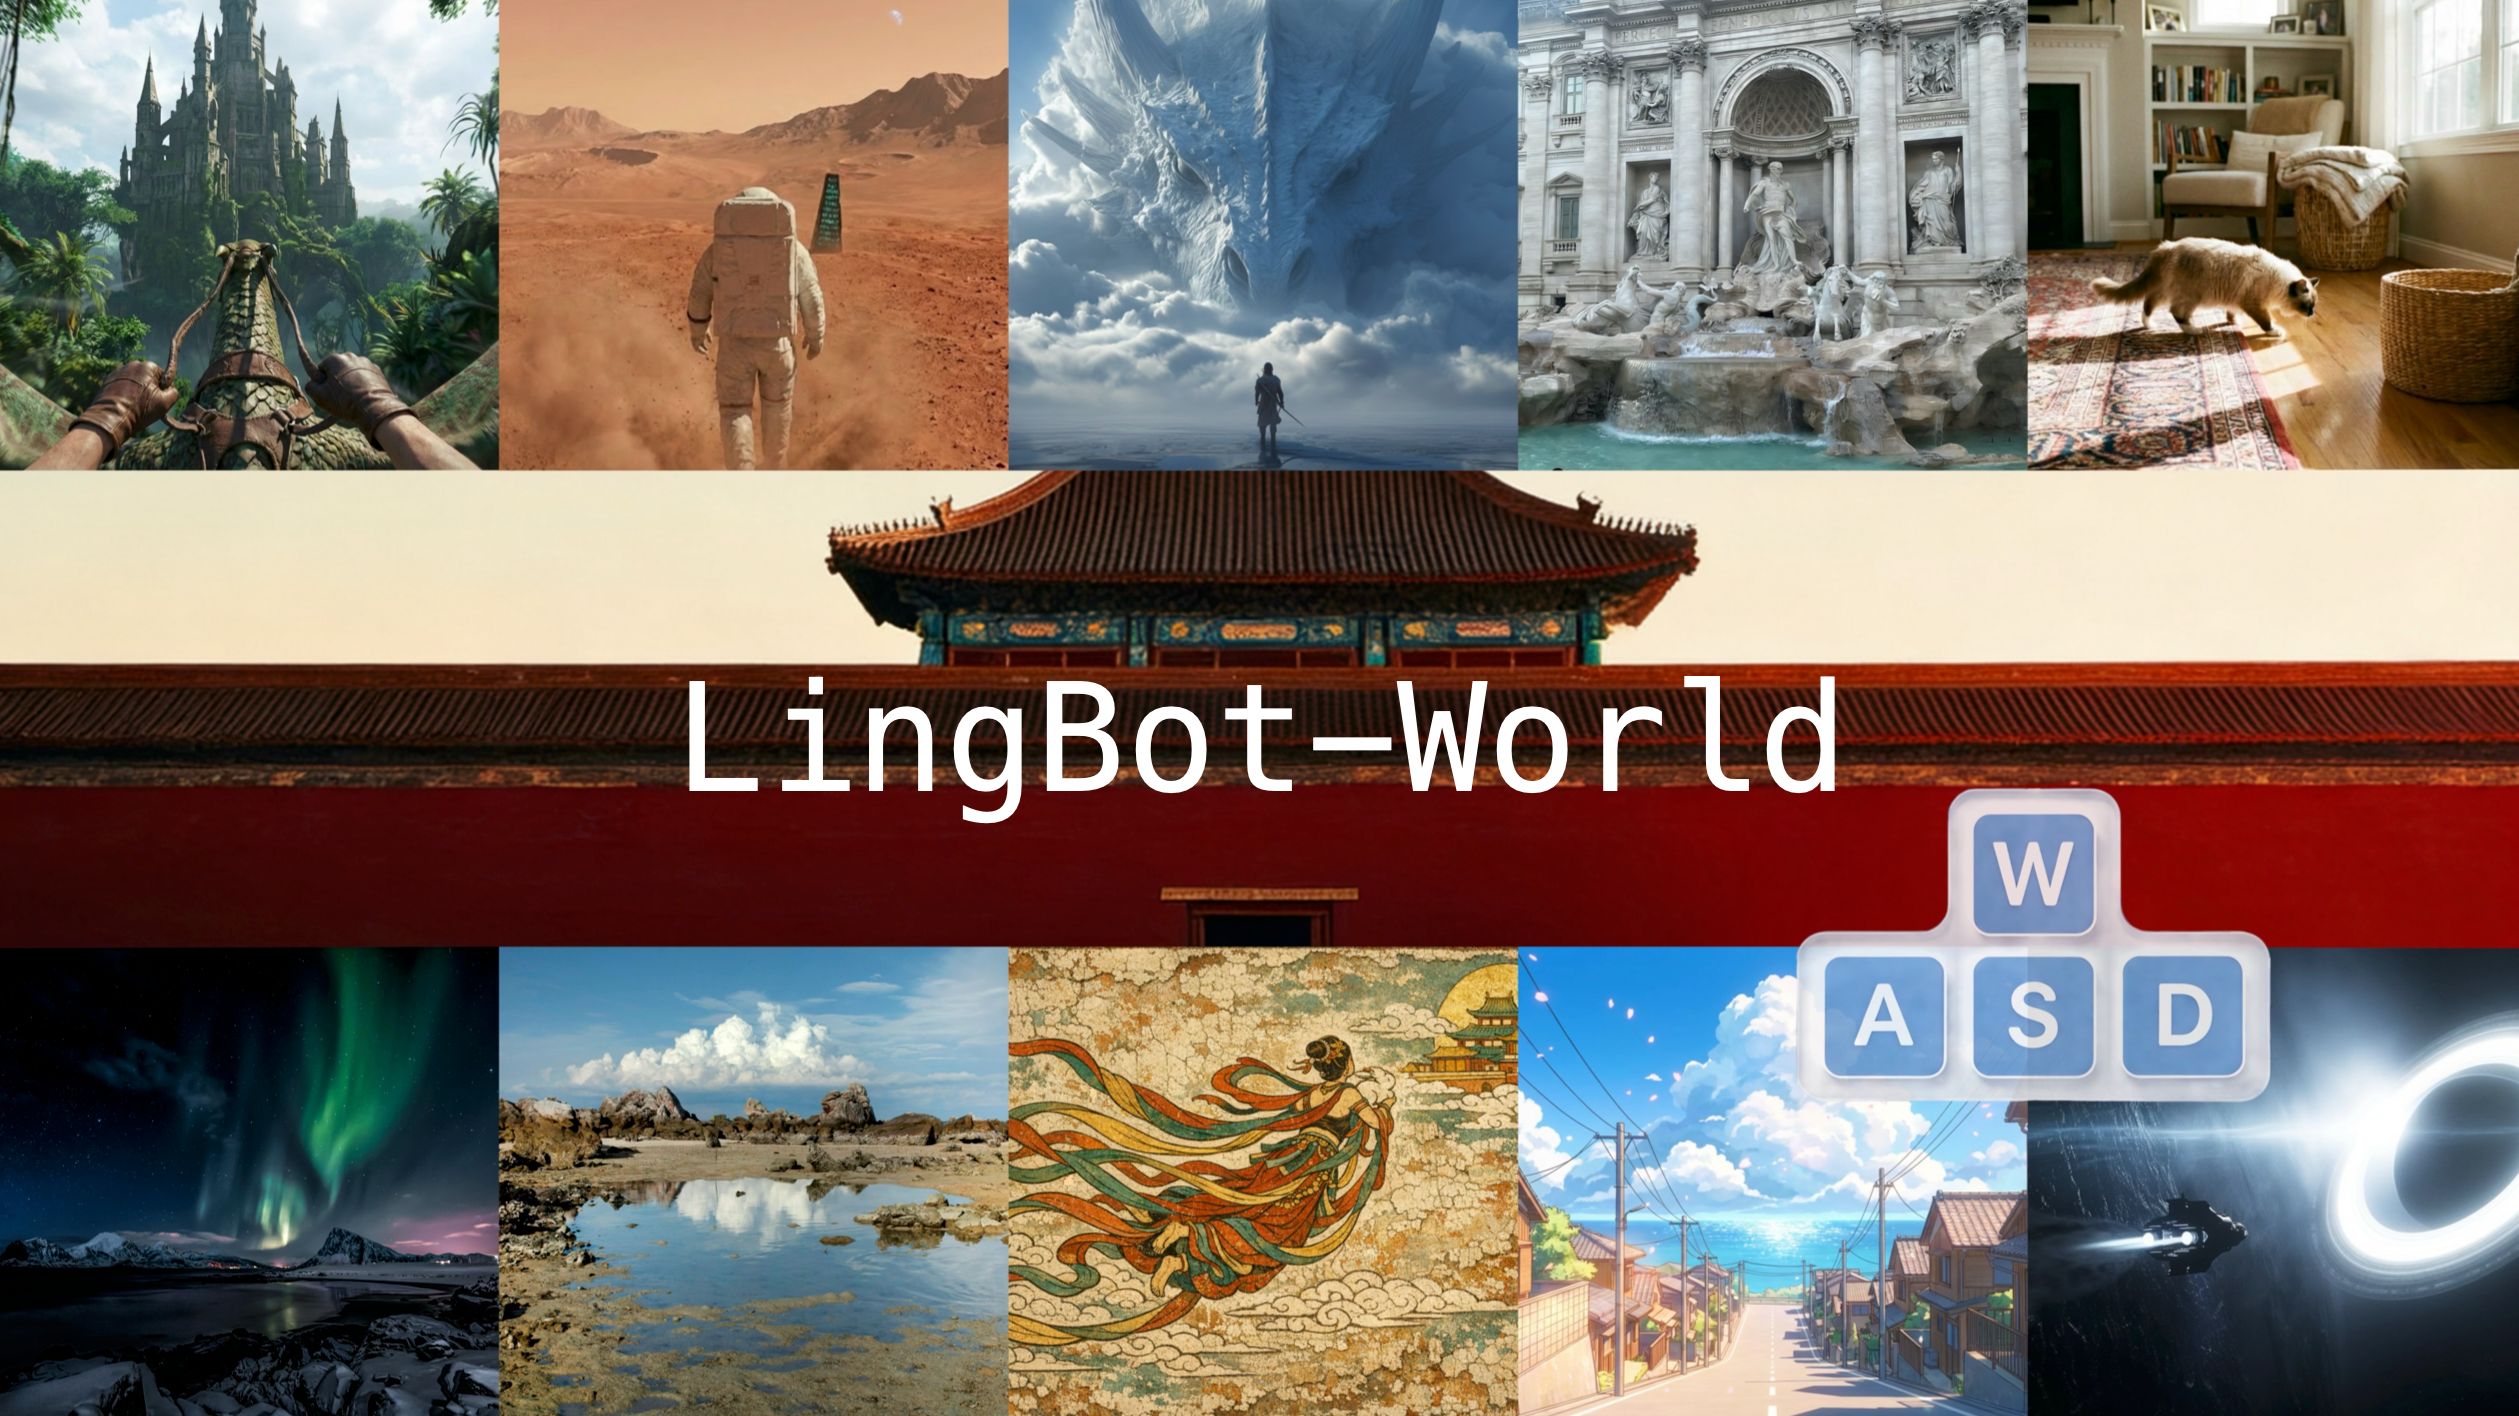
lingbot-world
4.5KRobbyant/lingbot-world · PythonLingBot-World is an open-source world model/simulator built from video generation: it turns an input image, text prompt, and optional control signals (camera poses or actions) into a long, controllable video that behaves like an interactive world.
- 37

AudioNoise
4.5Ktorvalds/AudioNoise · CAudioNoise is a small, playful collection of digital audio effect simulations (phaser-like all-pass filters, delay-based echoes, etc.) written in C by Linus Torvalds as a side project for learning digital signal processing basics, originally tied to his DIY guitar-pedal hardware.
- 38
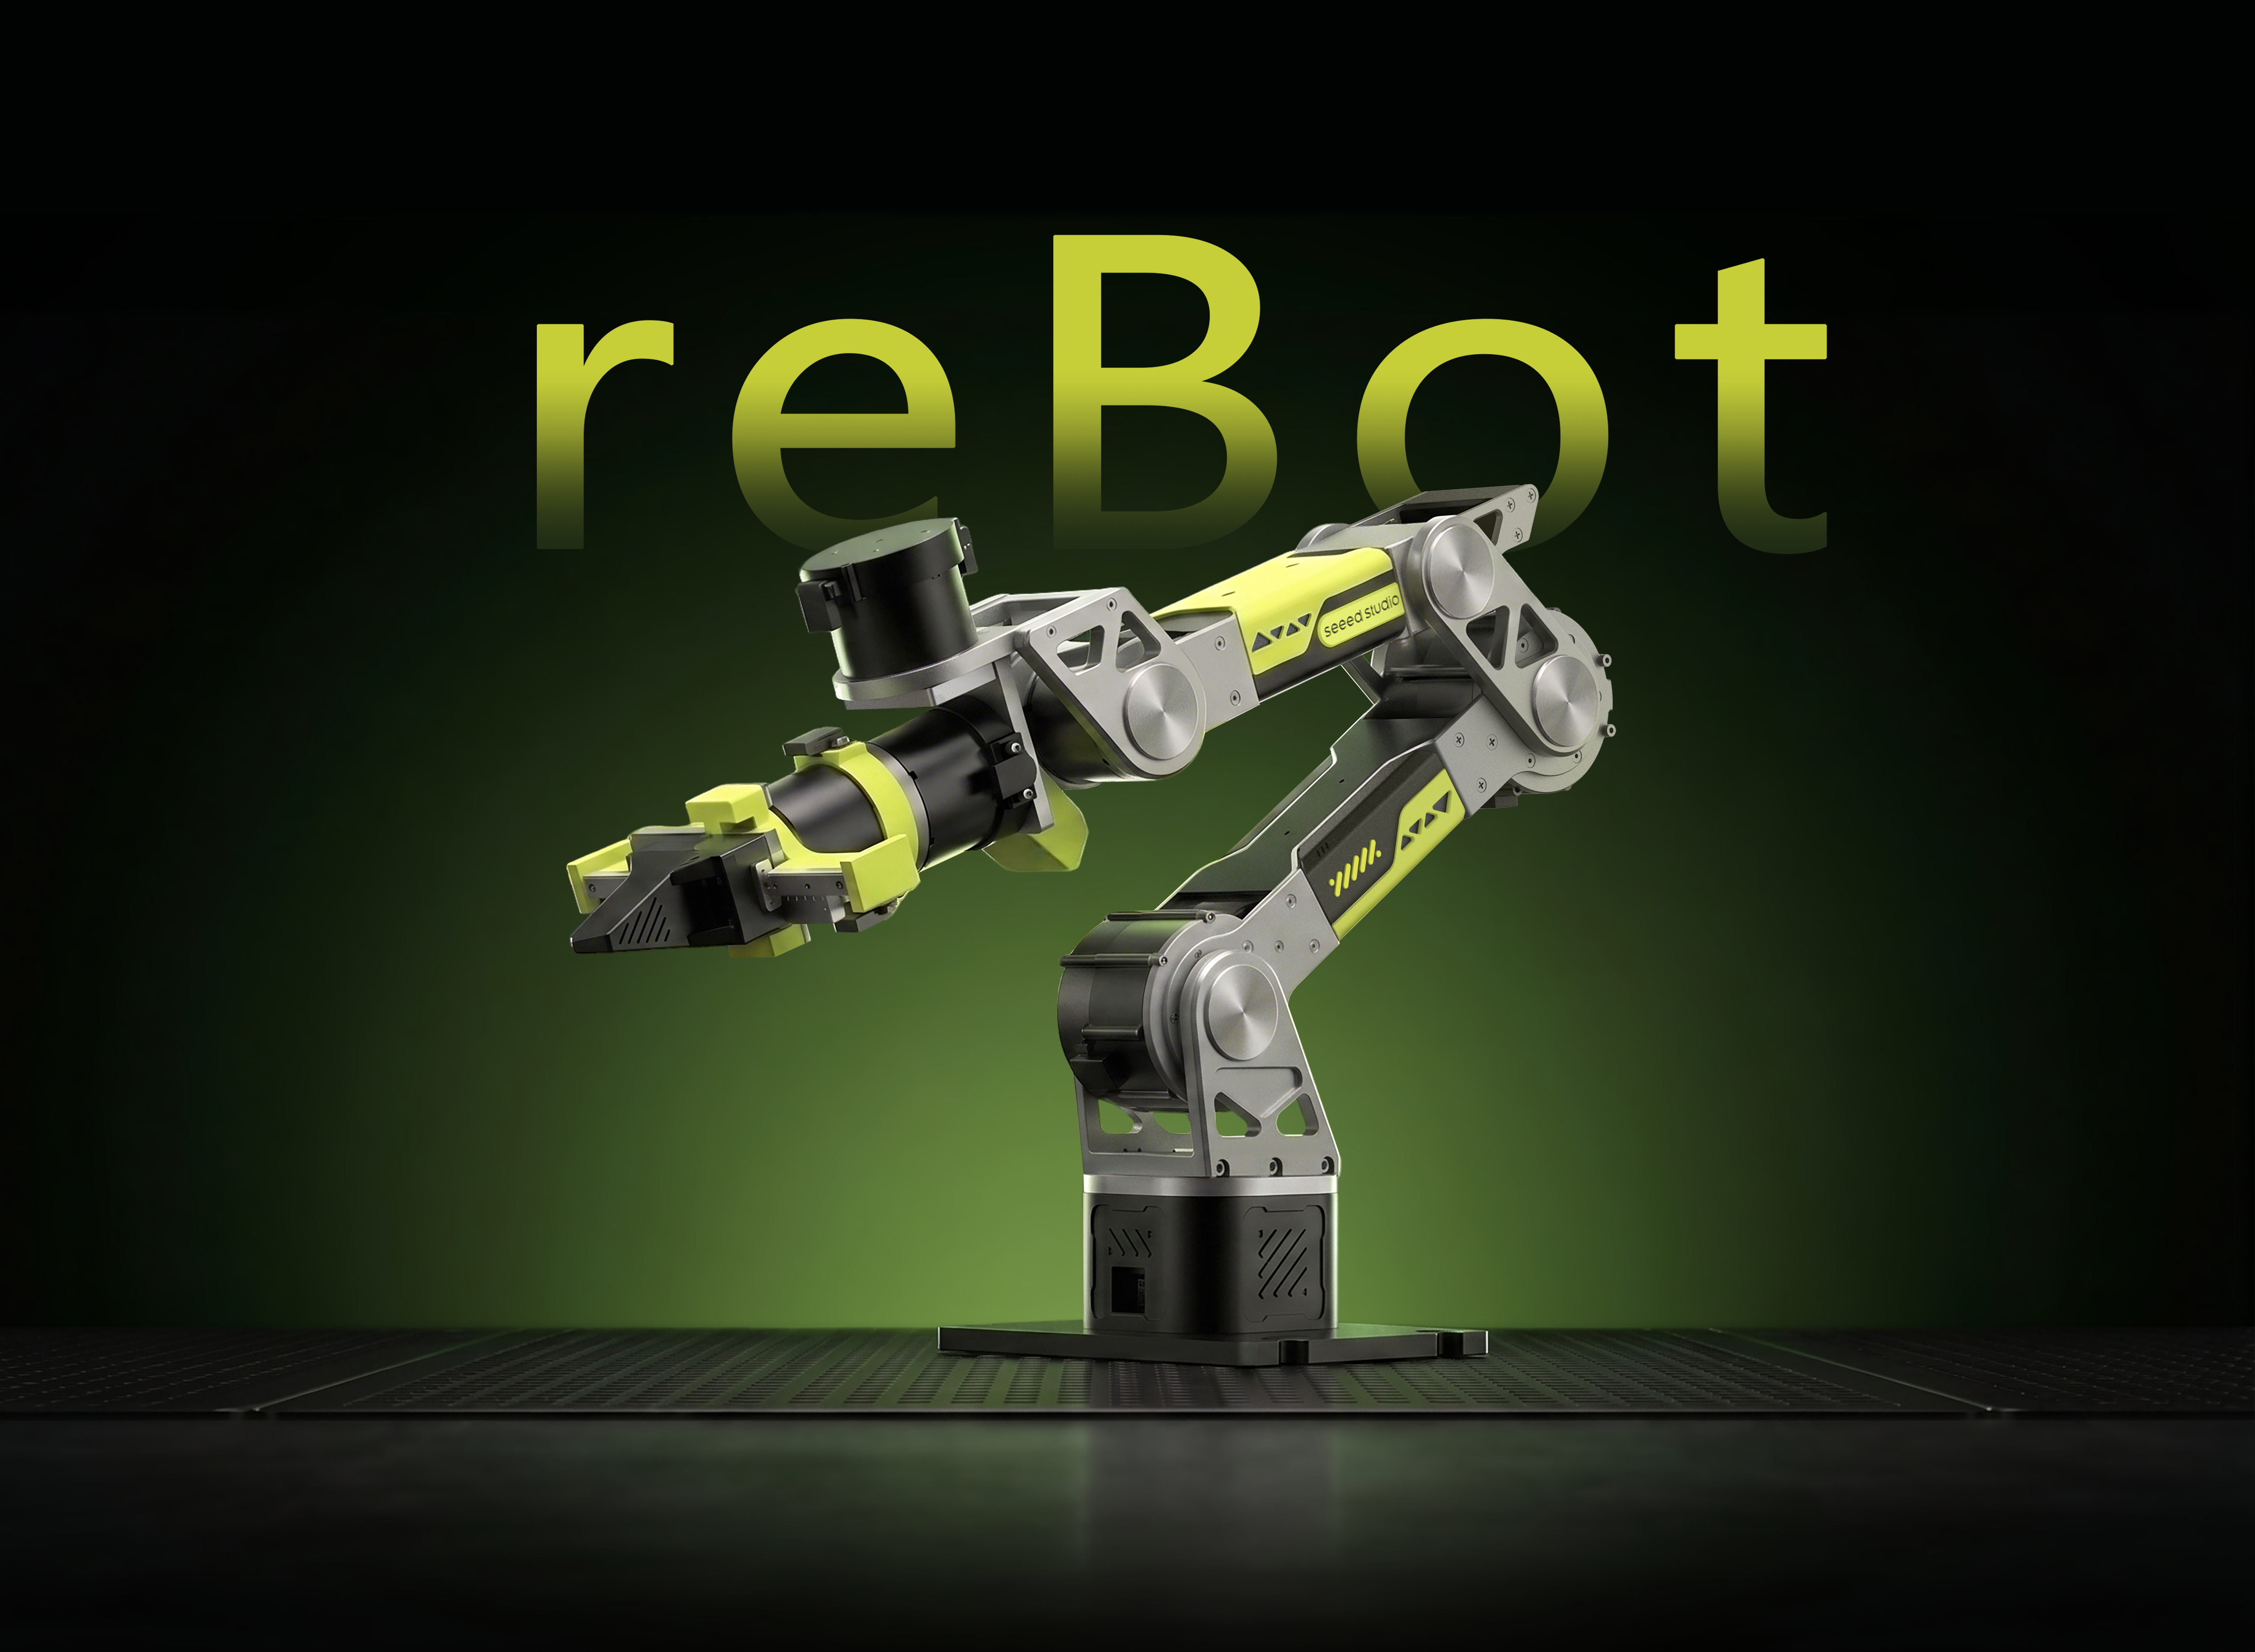
reBot-DevArm
4.4KSeeed-Projects/reBot-DevArm · PythonreBot-DevArm is a fully open-source robotic arm project (B601-DM and B601-RS models) aimed at lowering the barrier to learning Embodied AI, with all hardware files, BOM, and software openly released.
- 39
kimodo
3.8Knv-tlabs/kimodo · PythonKimodo is NVIDIA's kinematic motion diffusion model that generates high-quality 3D human and robot motion from text prompts and kinematic constraints like keyframes, end-effector positions, and 2D paths.
- 40

GR00T-WholeBodyControl
3.8KNVlabs/GR00T-WholeBodyControl · PythonNVIDIA GR00T Whole-Body Control — a codebase hosting pretrained checkpoints plus training, evaluation, and deployment code for advanced humanoid robot controllers: the Decoupled WBC used in GR00T N1.5/N1.6, the GEAR-SONIC series, and MotionBricks.
- 41
jumper
2.7KKingKongRobotics/jumper · PythonJumper is a 22-DoF crab robot, and this repository is its AI toolkit for creating appearances, training motions, and building scenes for it.
- 42

gpgpu-sim_distribution
1.8Kgpgpu-sim/gpgpu-sim_distribution · C++GPGPU-Sim is a cycle-level simulator that models contemporary NVIDIA GPUs running CUDA or OpenCL workloads, letting researchers study GPU microarchitecture without real hardware. It also bundles a visualization tool (AerialVision) and a power model (AccelWattch).
- 43

dqn-adaptive-cpu-scheduler
1.5Kaaawangyh/dqn-adaptive-cpu-scheduler · PythonThis is a research-grade repository that implements an adaptive CPU task scheduler trained with a Deep Q-Network (DQN). It includes a simulator of multi-core CPUs with DVFS and a thermal-aware reward, plus training, evaluation, and plotting pipelines.
- 44
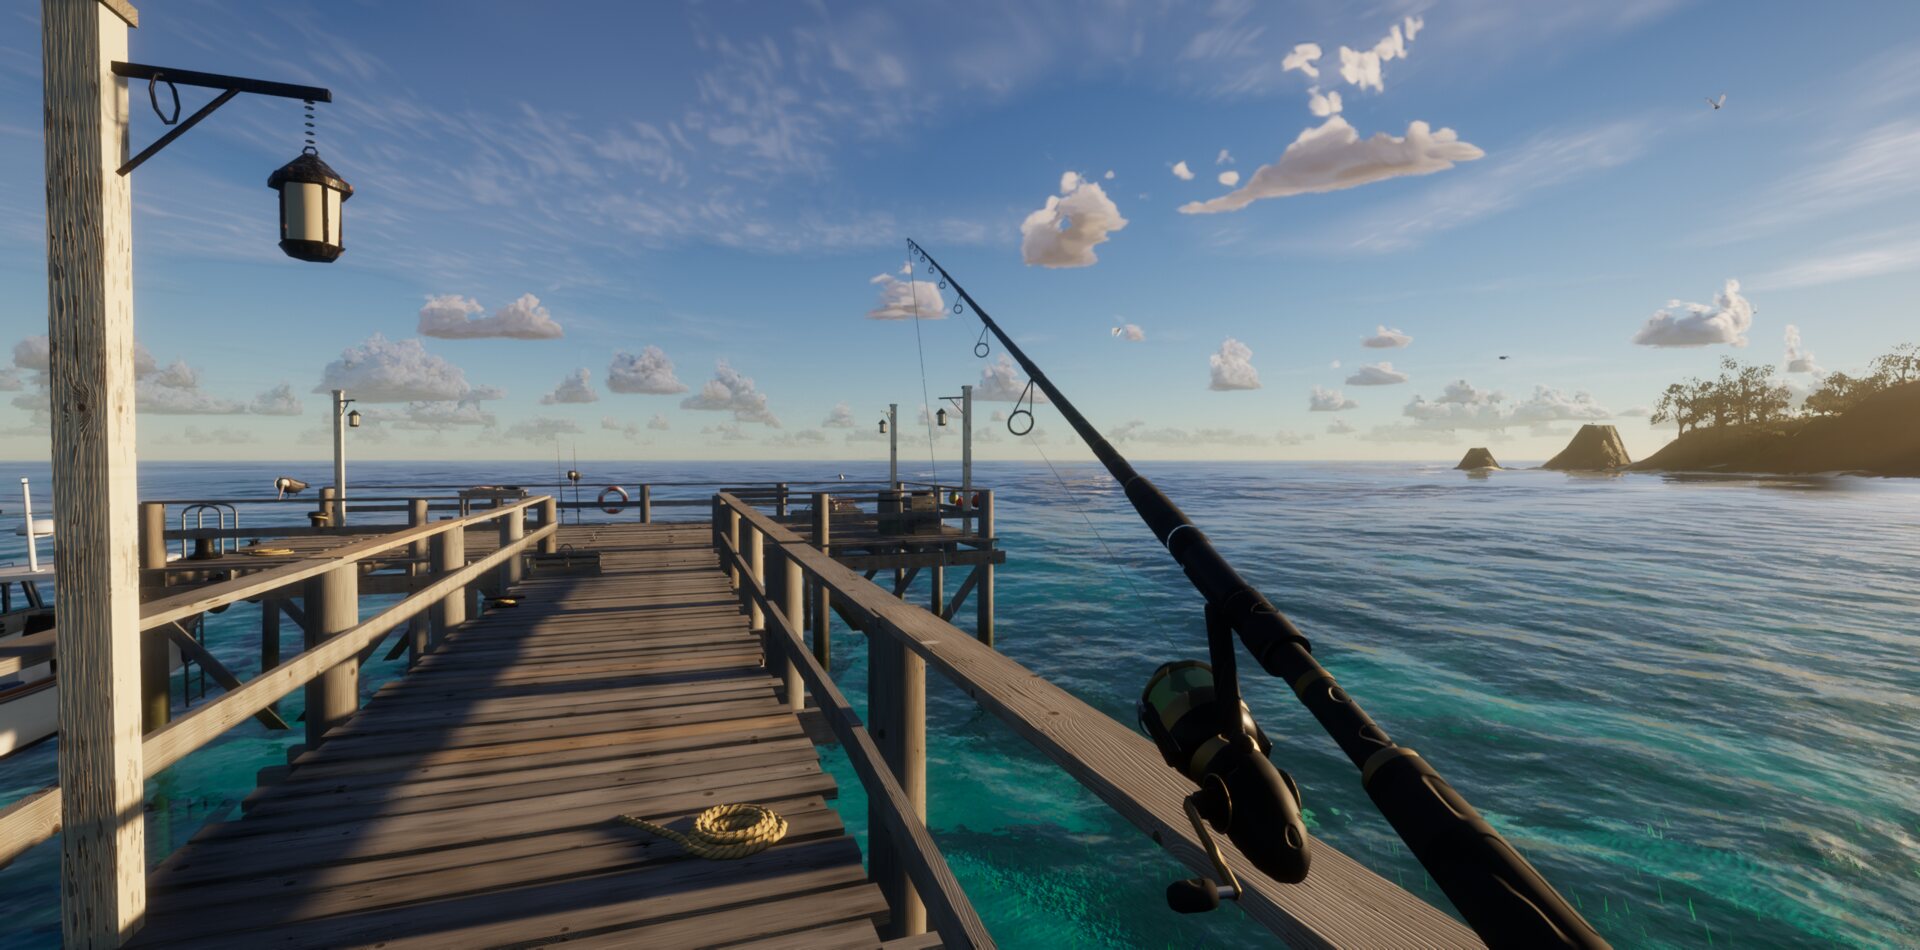
tidewater
1.3Kdgreenheck/tidewater · JavaScriptTidewater is an island fishing game that runs right in your browser: cast from the pier, the beach or your own boat, fight the fish, sell the catch to Joe, and spend it on better gear at Marta's chandlery.
- 45
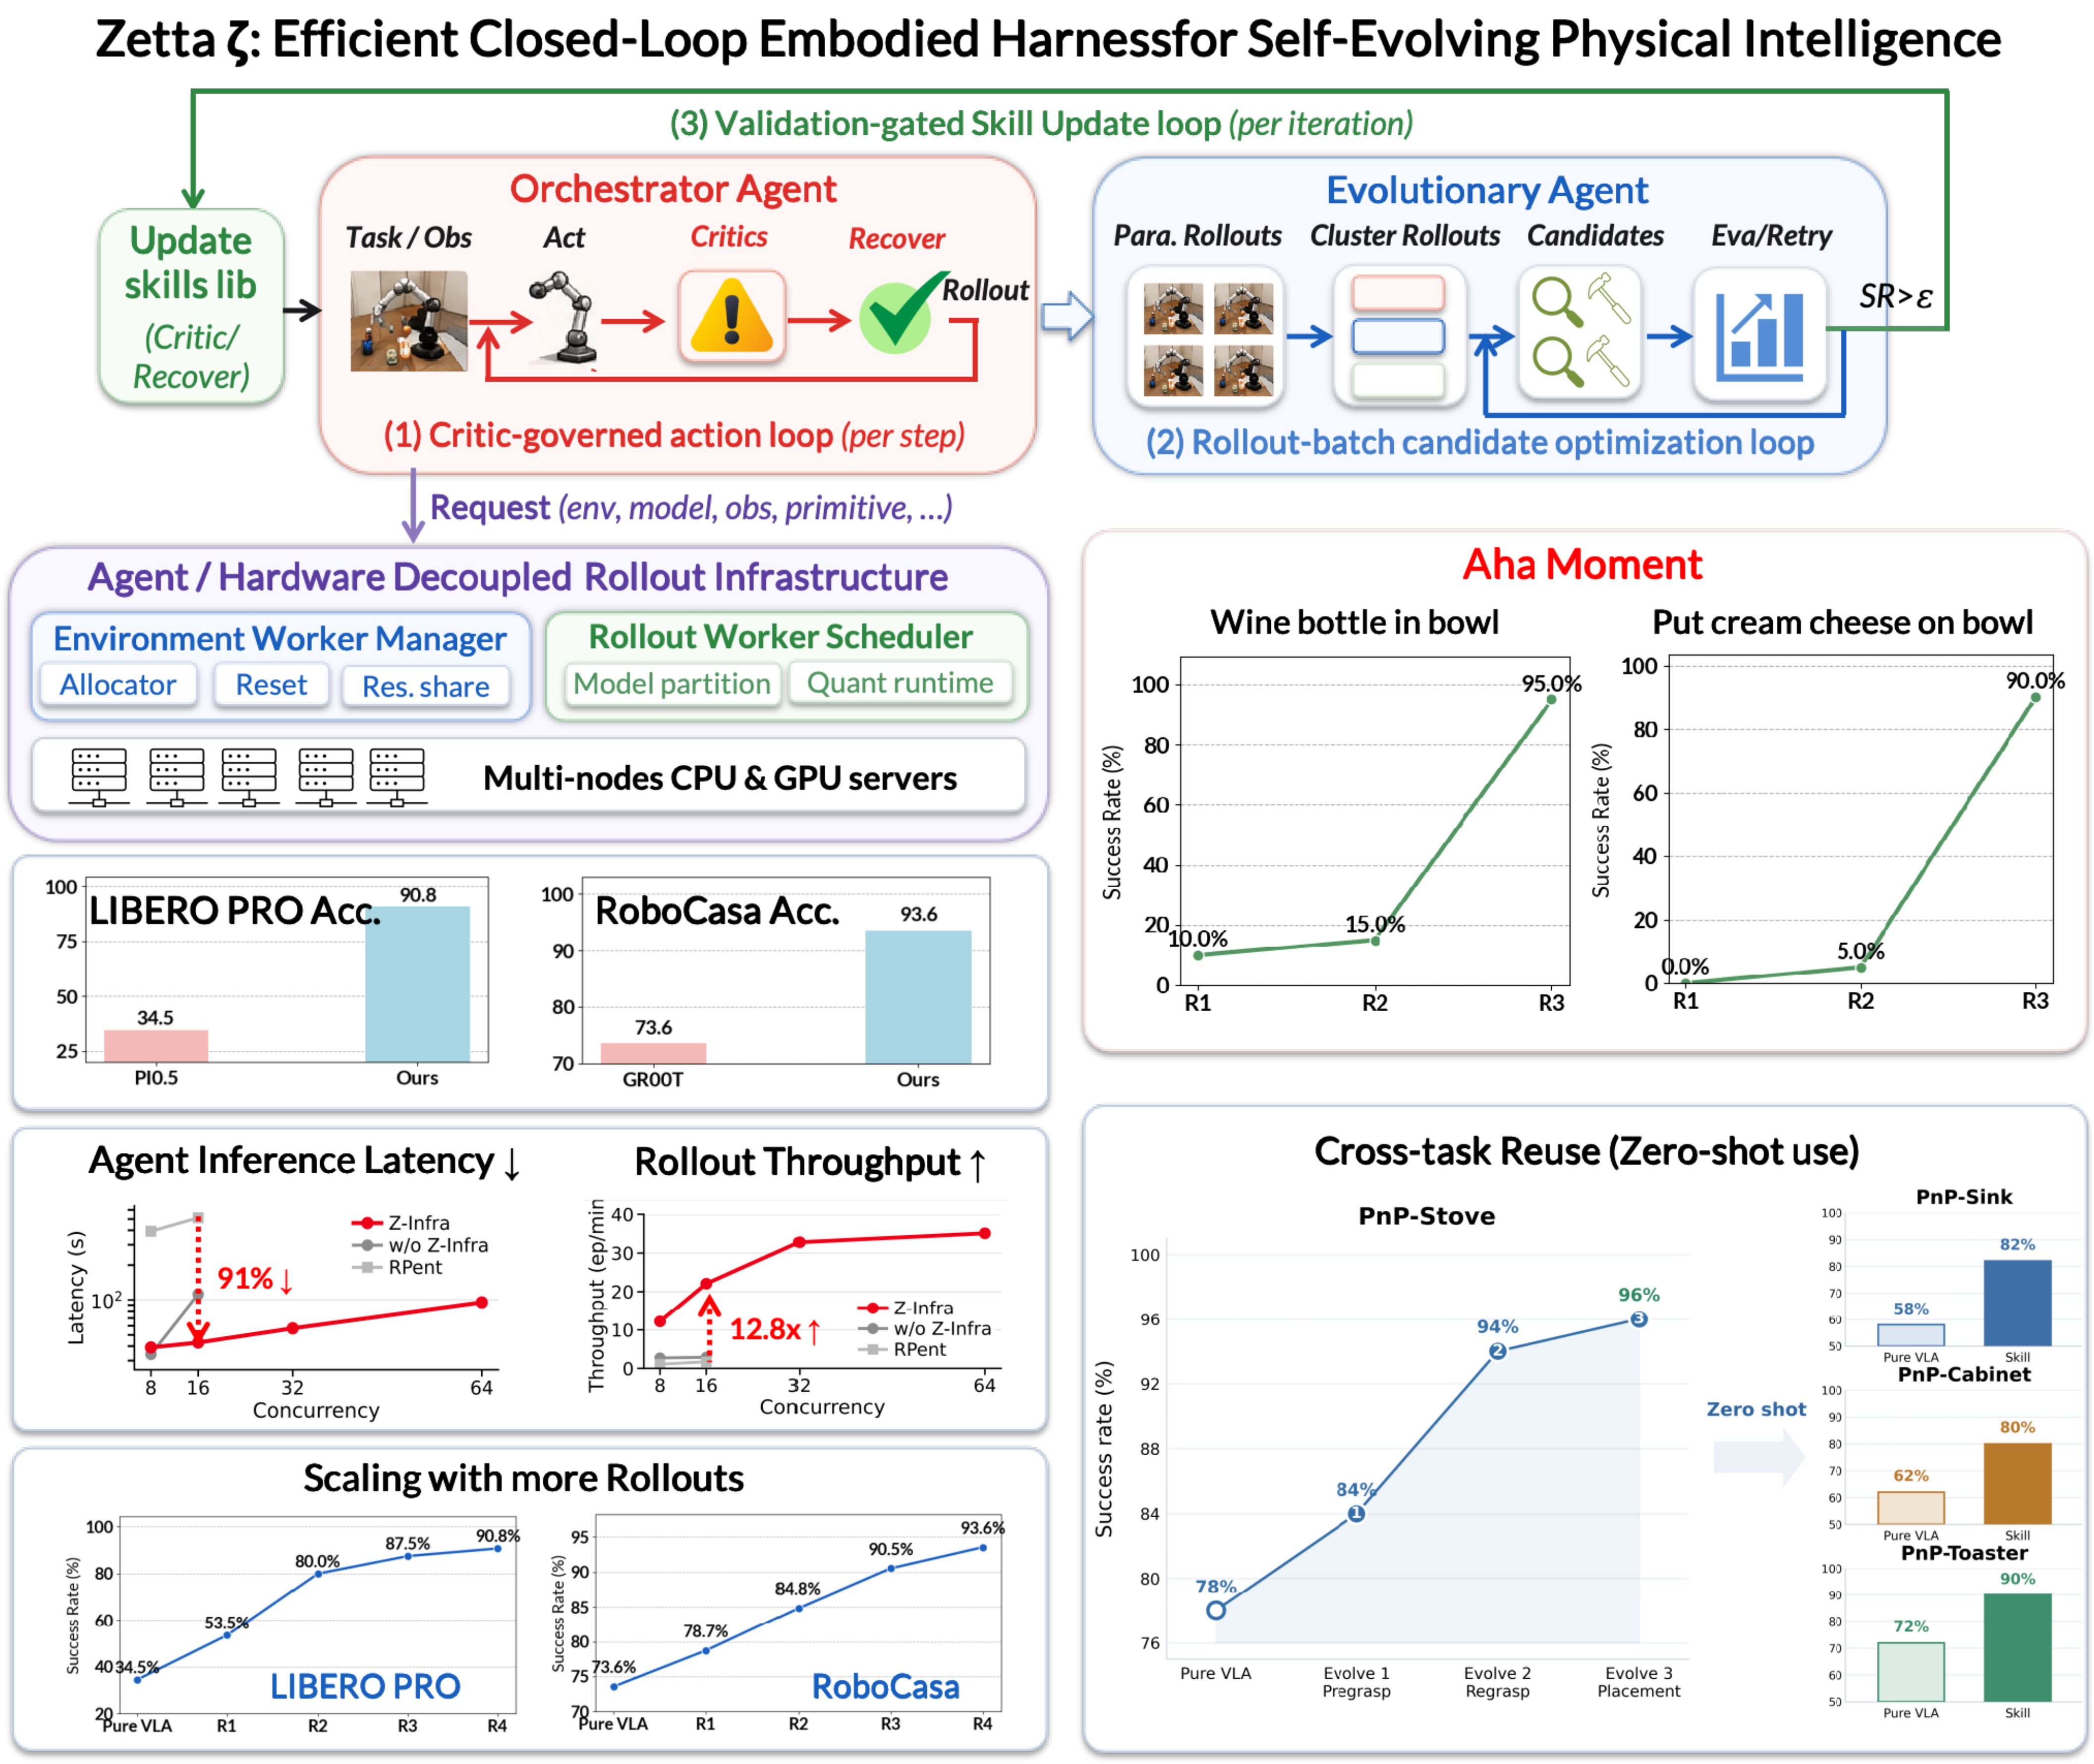
Zetta-Embodiment
1.3Kair-embodied-brain/Zetta-Embodiment · PythonZetta is a closed-loop embodied harness that evolves code-based runtime critics and recovery skills online while keeping the base robot policy frozen, reaching 90.8% success on LIBERO-Pro and 93.6% on RoboCasa with an 11.1x inference speedup.
- 46
Microduck-build-tutorial
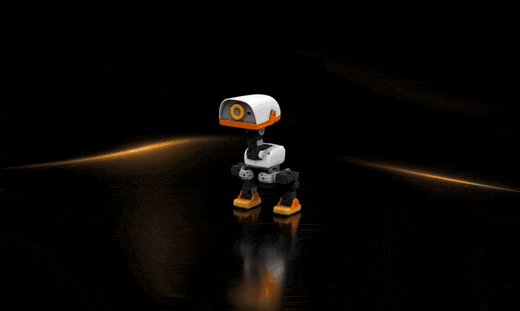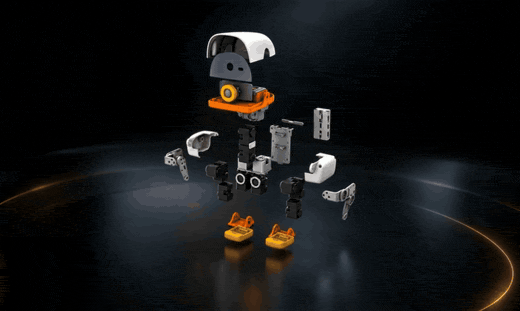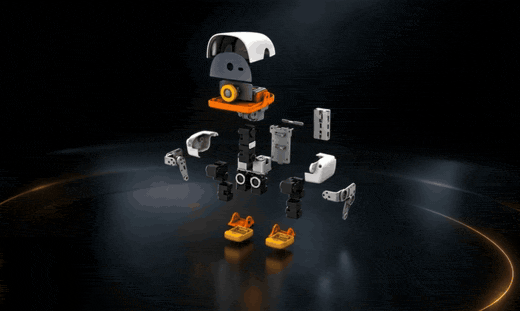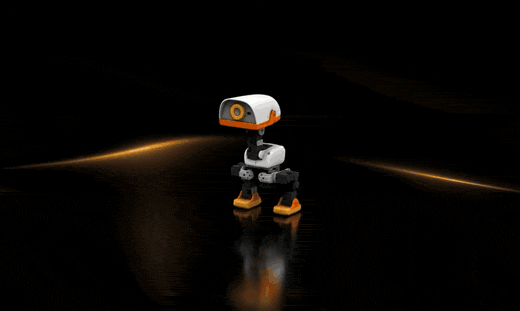
1.3KAI-FanGe/Microduck-build-tutorial · PythonMicroduck is a build tutorial and codebase for a compact biped (two-legged) robot: deployment code that runs on a Raspberry Pi Zero 2 W to drive Dynamixel servos using an ONNX reinforcement-learning walking policy, plus a MuJoCo/MjLab-based training environment to produce that policy.
- 47
desktop-fly
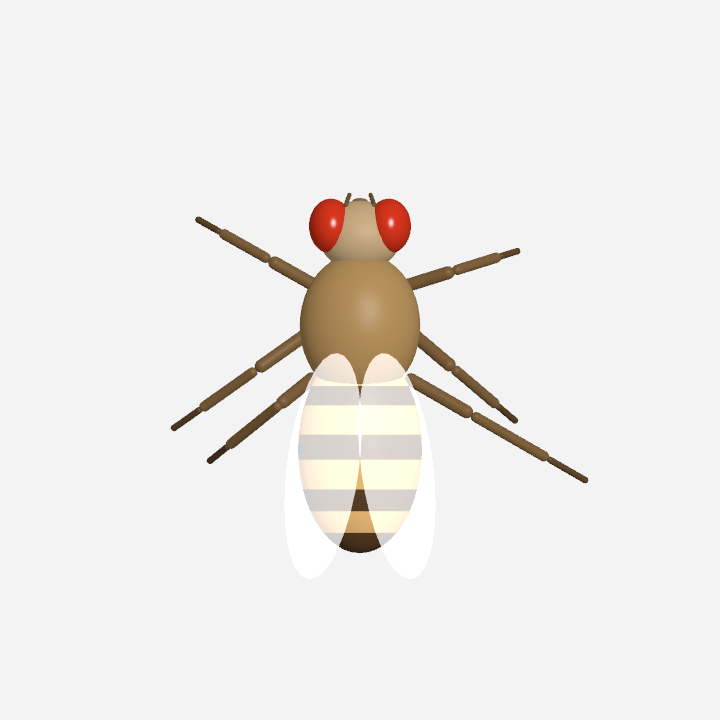
1.1KDenisSergeevitch/desktop-fly · SwiftDesktopFly is a 3D fruit fly that lives on your macOS desktop, animated by a live spiking simulation built from the real FlyWire fly-brain connectome (and a motor circuit from the MaleCNS dataset).
- 48
iw4L
1.1Kvladtrc/iw4L · RustIW4L is a Call of Duty runtime written from scratch in Rust on Bevy and wgpu. You point it at an existing Modern Warfare 2 install you already own, and it loads that game's data into its own independent engine using reverse-engineered on-disk layouts.
- 49
martypc
946dbalsom/martypc · RustMartyPC is a cycle-accurate emulator of early IBM PCs and compatibles, written in Rust. It recreates the original IBM PC, XT, PCjr and Tandy 1000 down to individual CPU cycles.
- 50
founder-skill
868Jakeschincariol/founder-skill · PythonFounder Skill is a set of eleven free Claude skills that let you stress-test a business idea before spending money on it: a board of directors modeled on Hormozi, Thiel and Jobs frameworks, a marketing director, a CFO, and a consumer panel of 100 simulated buyer agents.
- 51
SolarWM
777Junchao-cs/SolarWM · PythonSolarWM is a fully open foundation for building interactive video world models, covering data preparation, scalable multi-backbone training, and long-horizon inference.
- 52
FluxVLA
748FluxVLA/FluxVLA · PythonFluxVLA is a full-stack engineering platform for embodied AI covering the whole loop from data to real-robot deployment for vision-language-action (VLA) models, built to lower the engineering barrier for VLA research and development.
- 53
project_superdex
738facebookresearch/project_superdex · C++Project SuperDex is a unified simulation platform for dexterous manipulation research from Meta, combining a contact-first physics engine, robotics authoring tools, and a reinforcement learning interface, with VR-based teleoperation planned for Q4 2026.
- 54

pyraimd
714kpleo/pyraimd · PythonPyramid is an extensible Python framework for ab initio molecular dynamics: first-principles engines and machine-learned interatomic potentials (MLIPs) work together — reference calculations supply energies and forces while fast learned potentials propagate the atoms.
- 55
Motus2
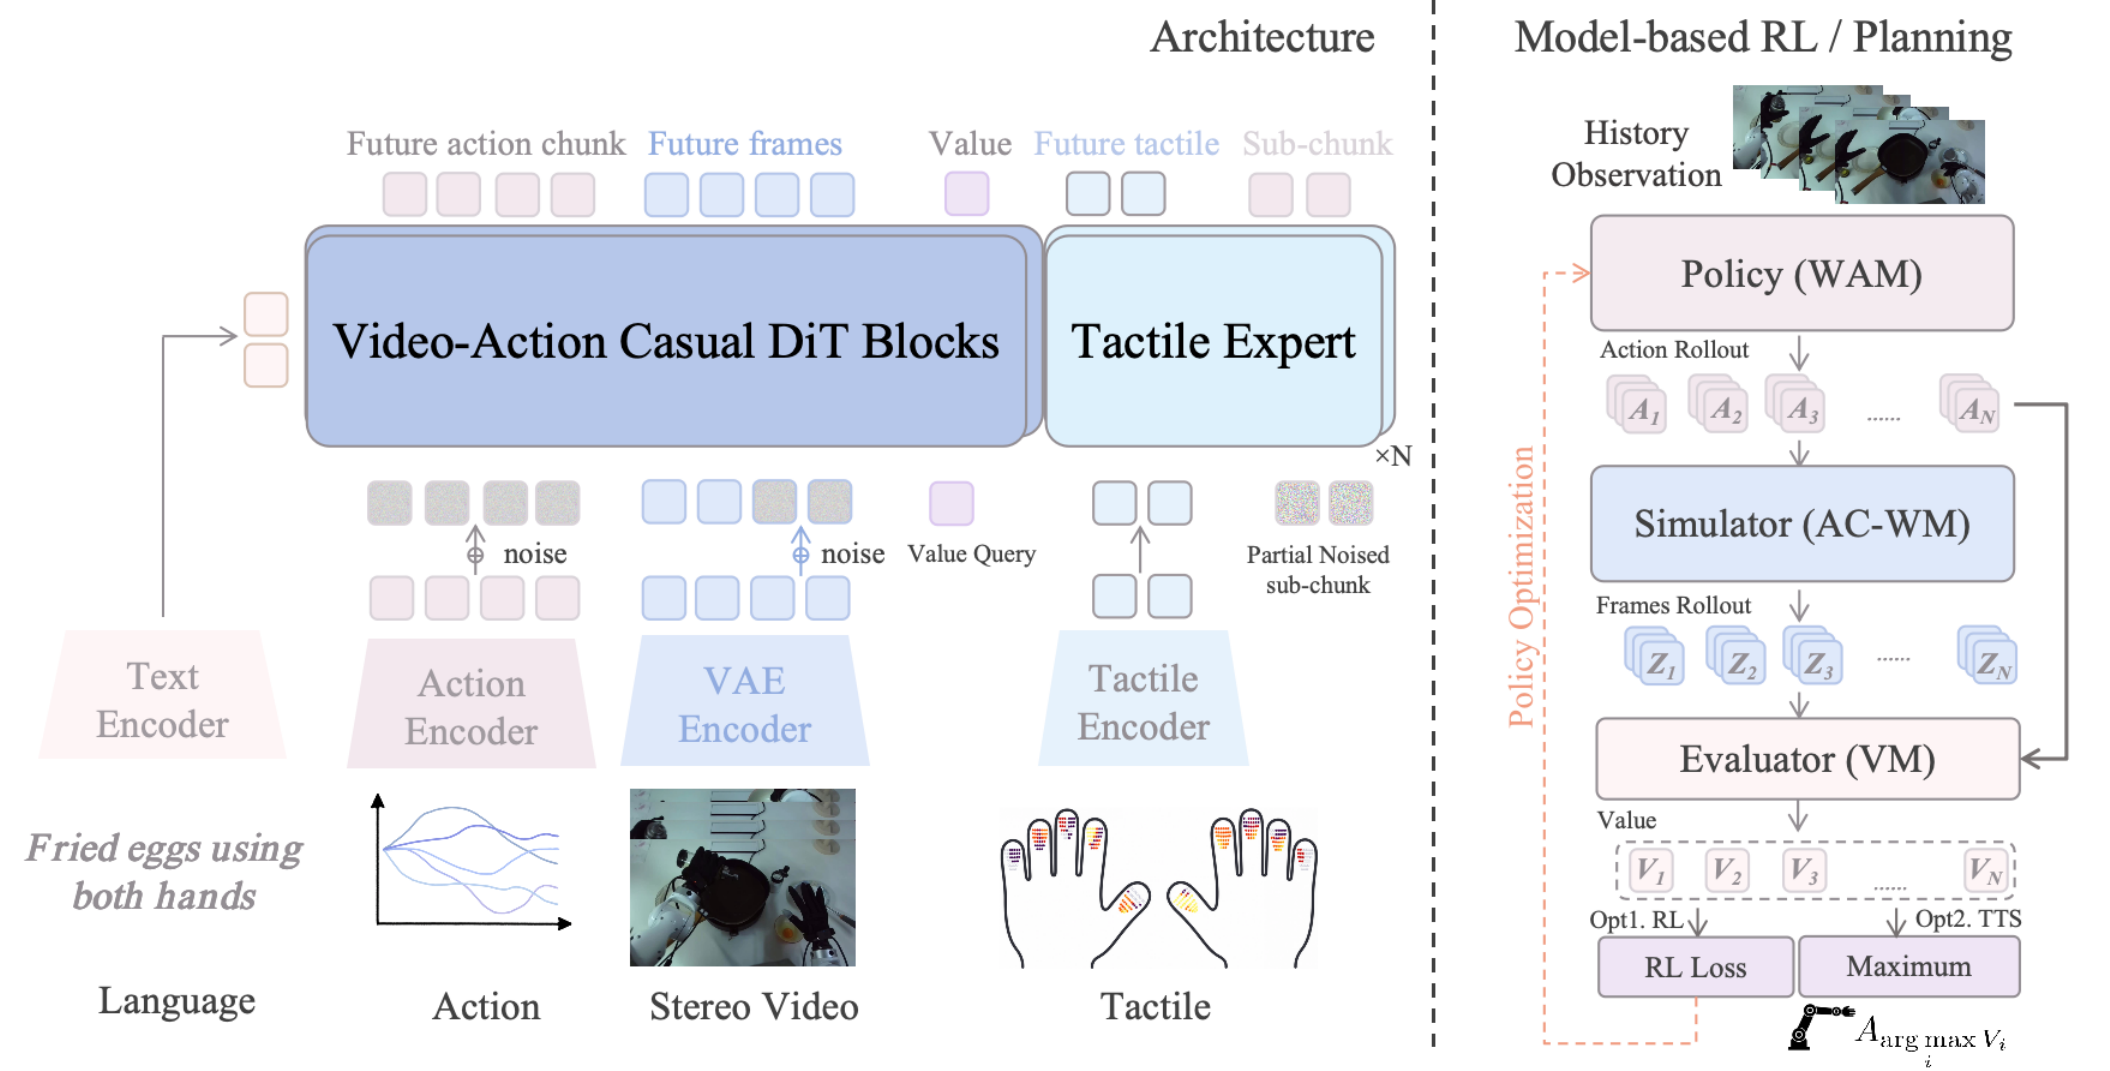
685shengshu-ai/Motus2Motus2 is a self-evolving general world model for dexterous robot manipulation. A single model with shared weights acts as a policy, a simulator, and an evaluator, coupling them into a closed decision-and-learning loop so the system can perceive, predict, act, and improve itself.
- 56
constellation-gemini
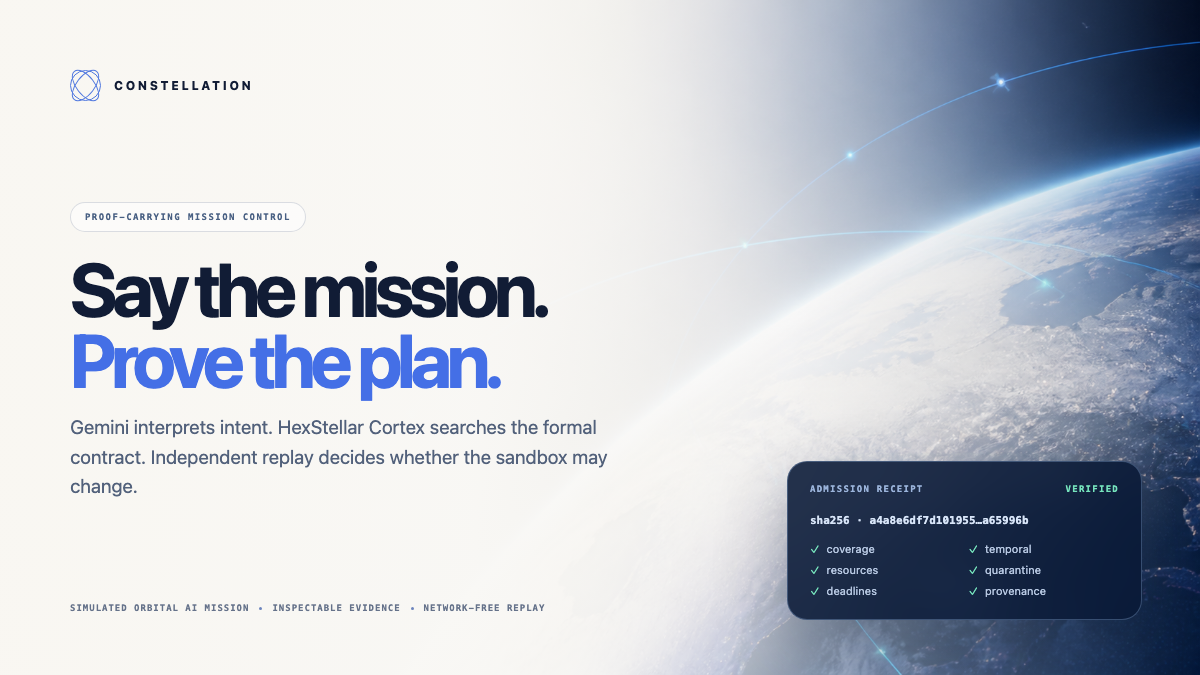
679brayonpi/constellation-gemini · PythonConstellation is a demo project where Gemini turns an operator's spoken orbital-mission request into a checklist, HexStellar Cortex searches for a complete recovery schedule for a broken satellite network, and a separate independent Python program checks that schedule rule by rule before it's allowed to update the simulation.
- 57
openOMSI
627openOMSI-org/openOMSI · RustopenOMSI is a from-scratch recreation of the bus simulator OMSI 2, written in Rust with a modern wgpu renderer (Metal/Vulkan/DirectX 12). It loads and plays the original OMSI 2's maps, buses and mods, but contains no game content of its own.
- 58

intrinsic-core
583intrinsic-ai/intrinsic-core · C++Intrinsic Core is an open, local runtime, SDK and hardware-agnostic real-time control framework for industrial robotics. It provides foundational building blocks for AI-enabled robot applications, from simulation and 6-DoF perception down to hardware execution.
- 59
apex-inference-chip
581SigmanticAI/apex-inference-chip · PythonAPEX is an open, verification-first hardware design for LLM inference: one transformer decoder layer written in real RTL that runs Qwen2.5-0.5B on an FPGA, with every circuit block checked bit-exact against a software golden model.
- 60

hypoarena
555OpSafari/hypoarena · Pythonhypoarena is a fully offline workbench that decomposes the generate-debate-evolve 'AI co-scientist' pipeline into individually testable mechanisms: a citation-bearing hypothesis-evidence graph, a synthetic literature factory, grounding verification, pluggable agent adapters, Elo tournaments, paraphrase dedup, and Bayesian evidence accumulation.
- 61
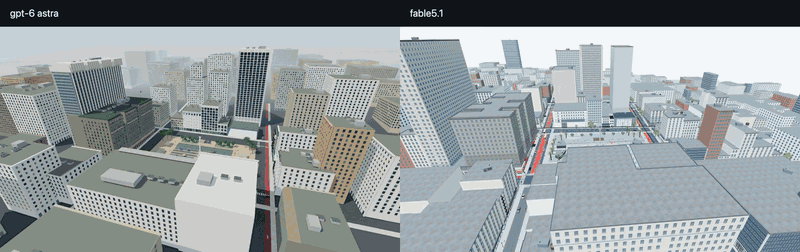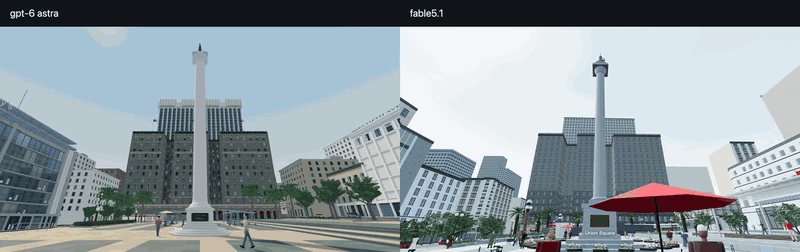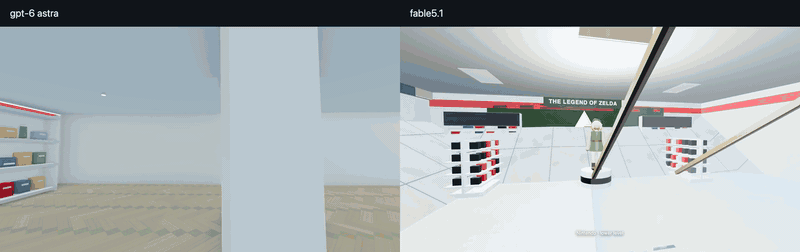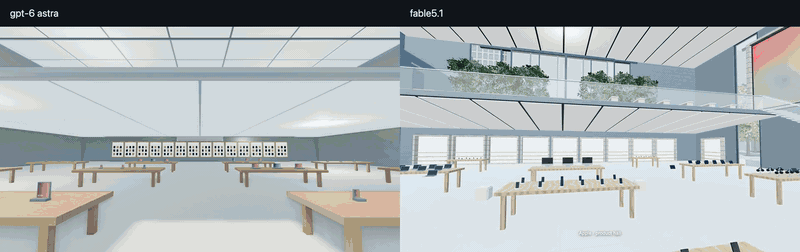
fable51-worlds
523PhiloLabs/fable51-worlds · JavaScriptThis project turns a single brief - a sentence, a photograph, or a video clip - into a walkable 3D world, generated by Claude-based agent swarms called 'Fable 5.1' that research the real place, model it, render it, and verify it.
- 62

awesome-nuclear
508paulromano/awesome-nuclearA curated directory of open source software for nuclear science and engineering: roughly 75 codes and tools spanning particle transport, nuclear data, fuel cycle, thermal hydraulics, and multiphysics, each a one-liner with a link.
- 63
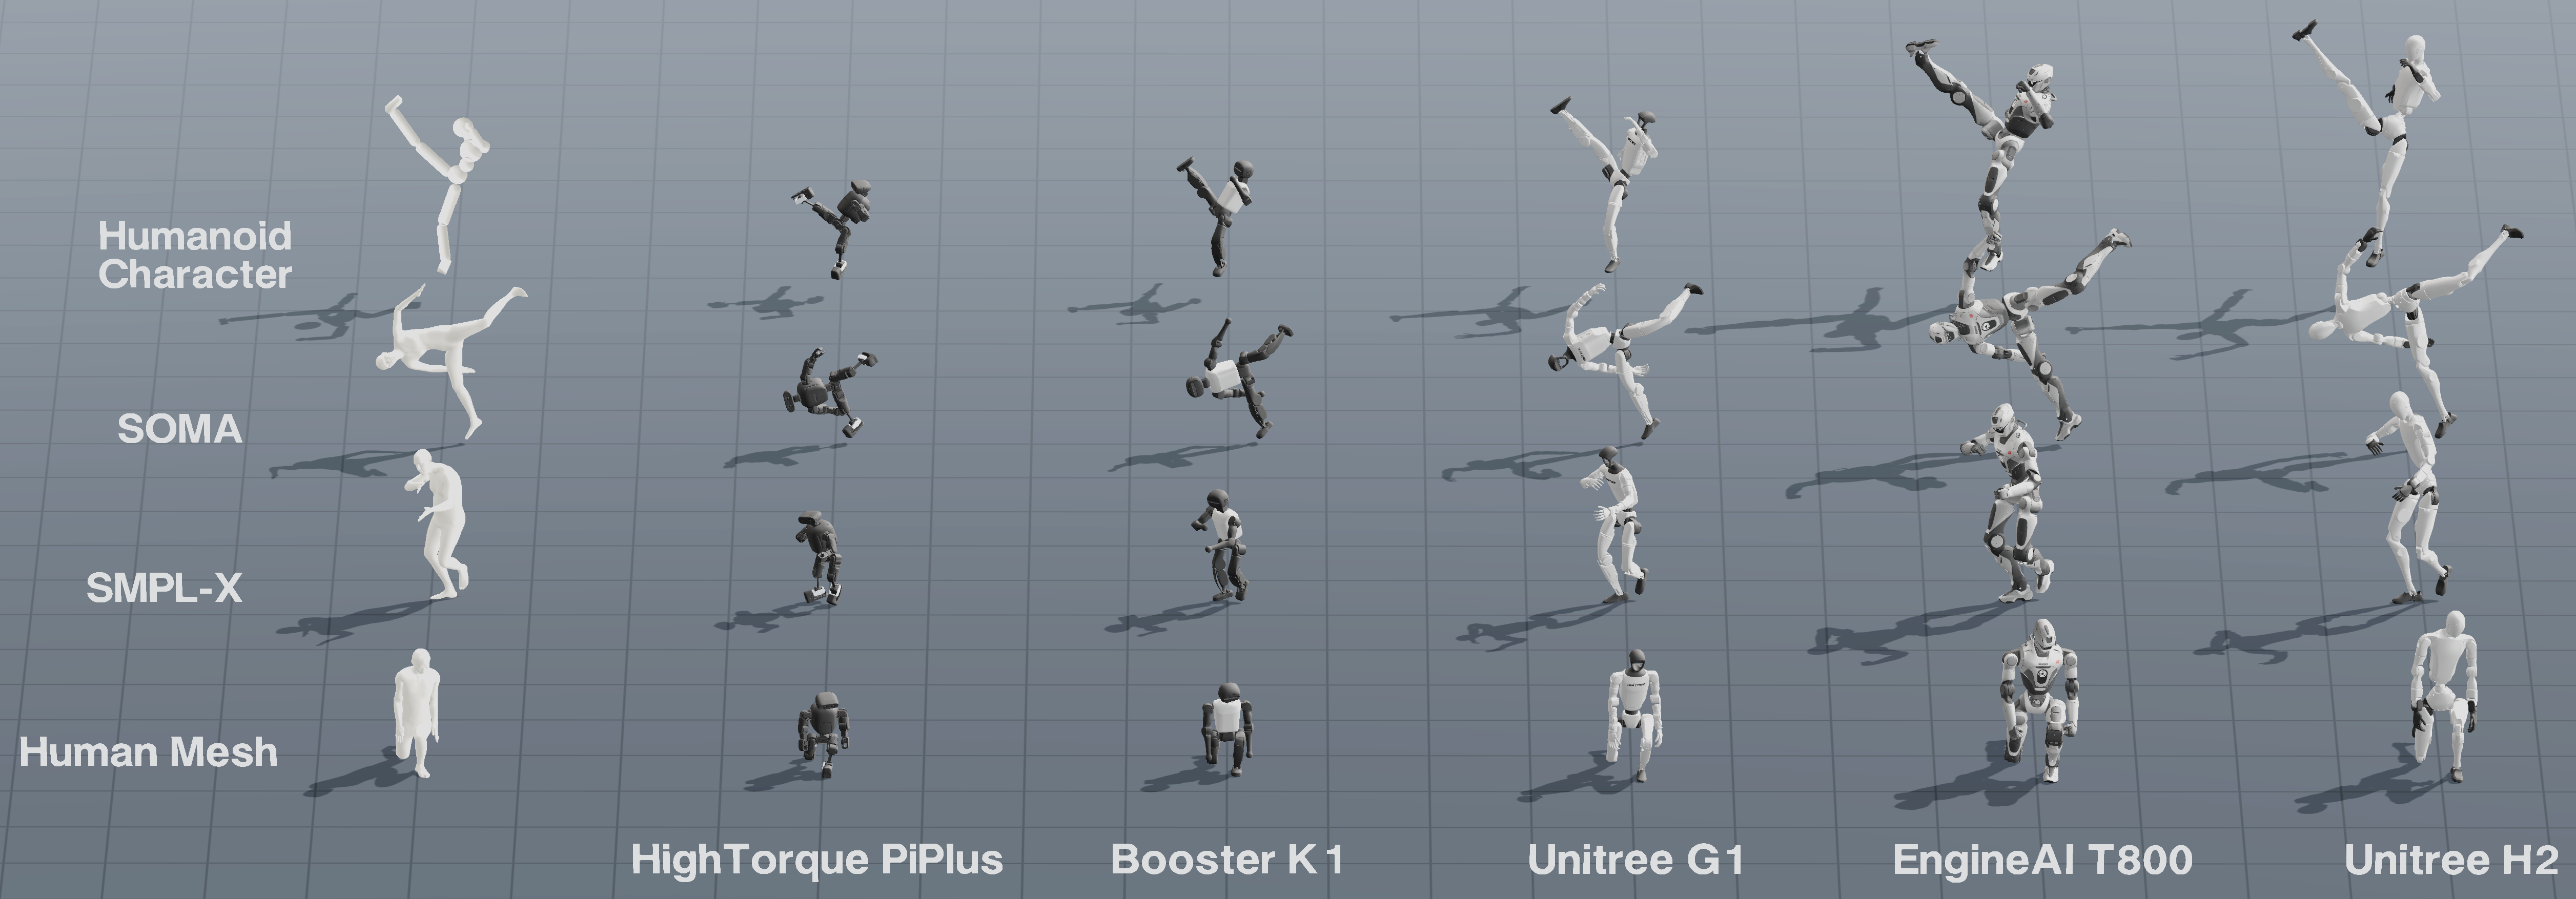
UMR
491hanyang9/UMR · PythonUMR (Unified Motion Retargeting) is a research codebase that retargets human motion onto humanoid robots by treating the moving exterior body surface as a shared interface between the source motion and the robot.
- 64
cadence
449muellerberndt/cadence · PythonCadence is an open research library toward general intelligence: a NumPy collection of 'brains' that compute by settling into an equilibrium and learn by detuning it, aiming to acquire skills from live experience the way animals and humans do.
- 65
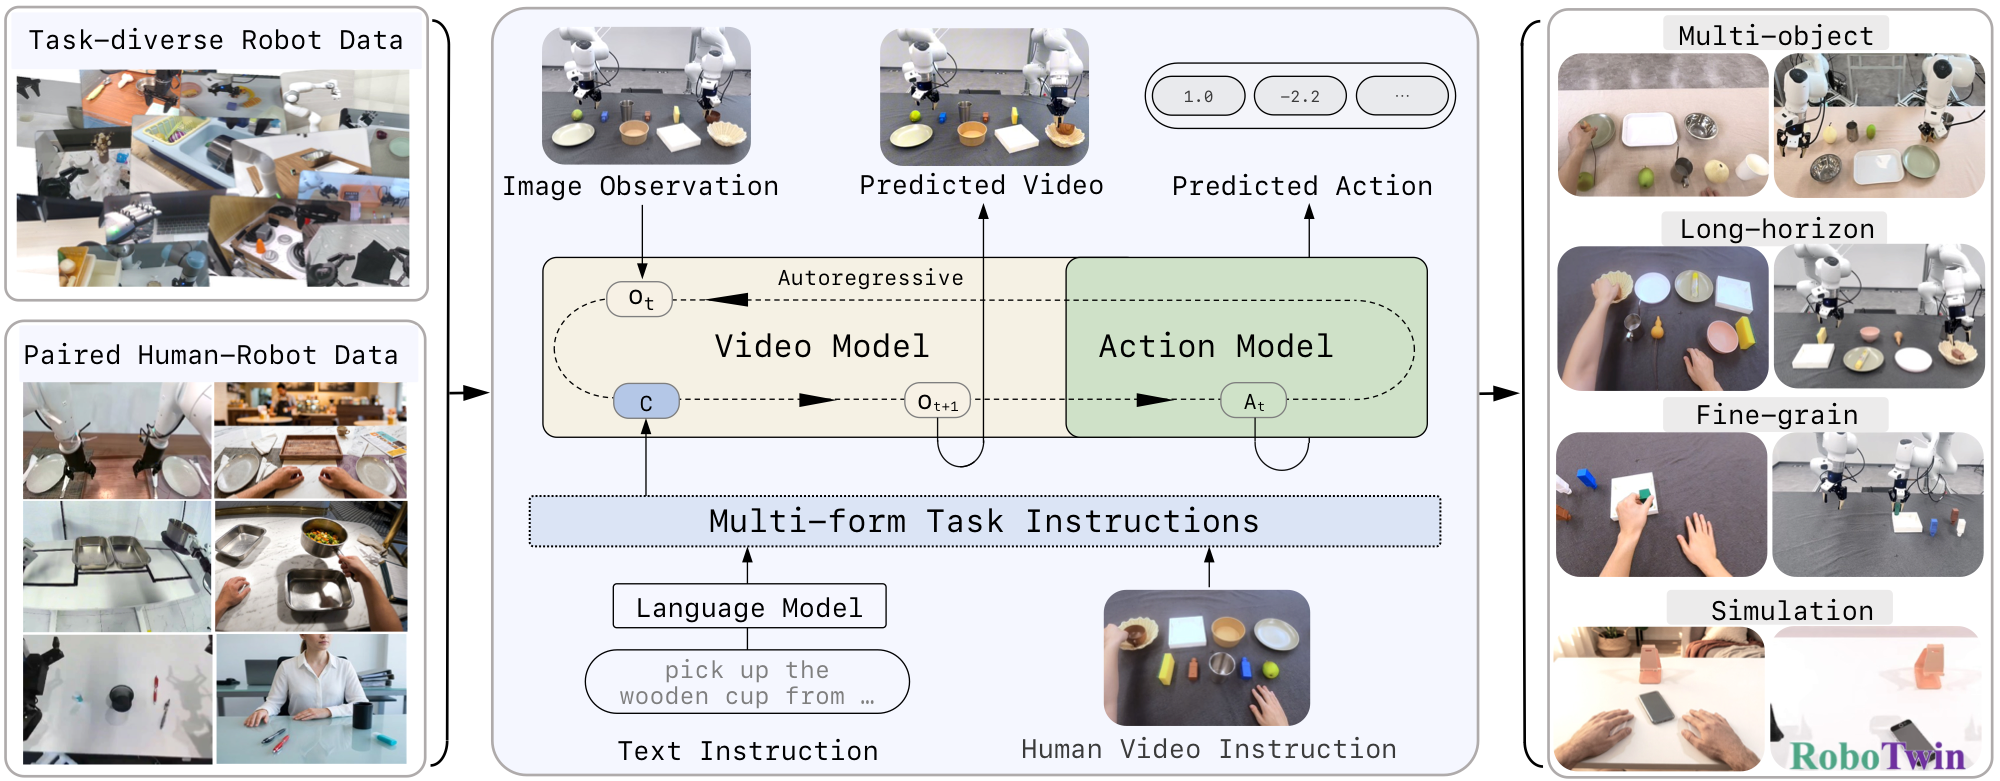
Zero-WAM
434robbyant-research/Zero-WAM · PythonZero-WAM is a research method for zero-shot cross-task robotic manipulation: a causal video-action policy that learns in-context world-action modeling, predicting future robot observations and executable actions from either language instructions or human demonstration videos.
- 66
Code-as-World
419MirroS-Lab/Code-as-World · PythonCode-as-World is a research project that represents the physical world as executable code, discovered through an agentic loop of simulation and verification, so models get reusable physical data (states, dynamics, mechanisms) instead of just raw pixels.
- 67

statecraft-israel
377eyalgolan/statecraft-israel · C#Statecraft: Israel is a turn-based grand-strategy game where you play as the prime minister starting on 15 May 1948, managing real ministers, a real coalition, and sourced historical events through a deterministic C# simulation rendered in Unity.
- 68

OpenCourant
374OpenCourant/OpenCourant · FortranOpenCourant is an open-source build of OpenRadioss, an explicit finite element solver used to simulate highly nonlinear dynamic events like crashes, impacts, and explosions.
- 69
natural-disasters
287Token-Gremlin/natural-disasters · JavaScriptABYSSAL is a fully procedural cinematic ocean and extreme-weather simulation that runs entirely in a browser tab, rendering multi-cascade FFT ocean waves, volumetric clouds, hurricanes and tsunamis with zero external assets, built on Three.js, WebGL2 and GLSL3.
- 70
RoboICL
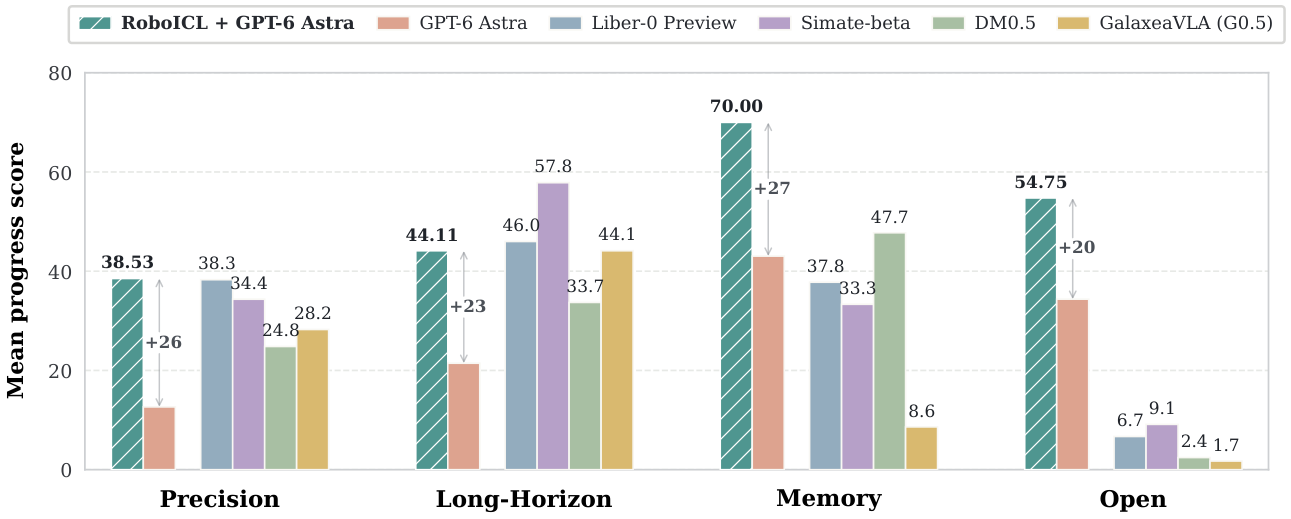
268Mosi-AI/RoboICL · PythonRoboICL is a research framework that lets a frozen, general-purpose vision-language model (GPT-6 Astra) control a robot in simulation purely through in-context learning, without training a dedicated robot policy.
- 71

pluto
265tscmoo/plutoPluto is an AI bot for StarCraft: Brood War — a single neural network trained end-to-end by self-play reinforcement learning that plays macro and micro for all three races, with no scripted logic.
- 72

quackd
263rokbenko/quackd · Pythonquackd is an open-source daemon that gives small robots a brain: it takes a goal in plain language and plans the right sequence of the robot's own existing skills to carry it out, using an LLM like Claude, OpenAI, Gemini, Grok or a local model.
- 73

iudsim
247THU-iUWLab/iudsimIUDSim (Integrated Urban Drainage Simulator) is an urban drainage system simulator built by Tsinghua's iUWLab that tightly couples surface runoff, pipe networks, wastewater treatment, rivers, and human movement into one simulation to model the full event-facility-social-environmental process chain.
- 74
RoboHarness
246BinceQu/RoboHarness · PythonRoboHarness is a training-free harness that gives an LLM agent a visual-geometric control panel: the model marks points of interest on 2D images, which get tracked and turned into geometric constraints so the LLM can directly compose and execute embodied manipulation actions.
- 75

vistep
240int64ago/vistep · TypeScriptvistep.ai is a bilingual collection of short visual stories that explain everyday mechanisms, science and computation, letting you watch a process happen and then experiment with the underlying model.
- 76
circuitRF
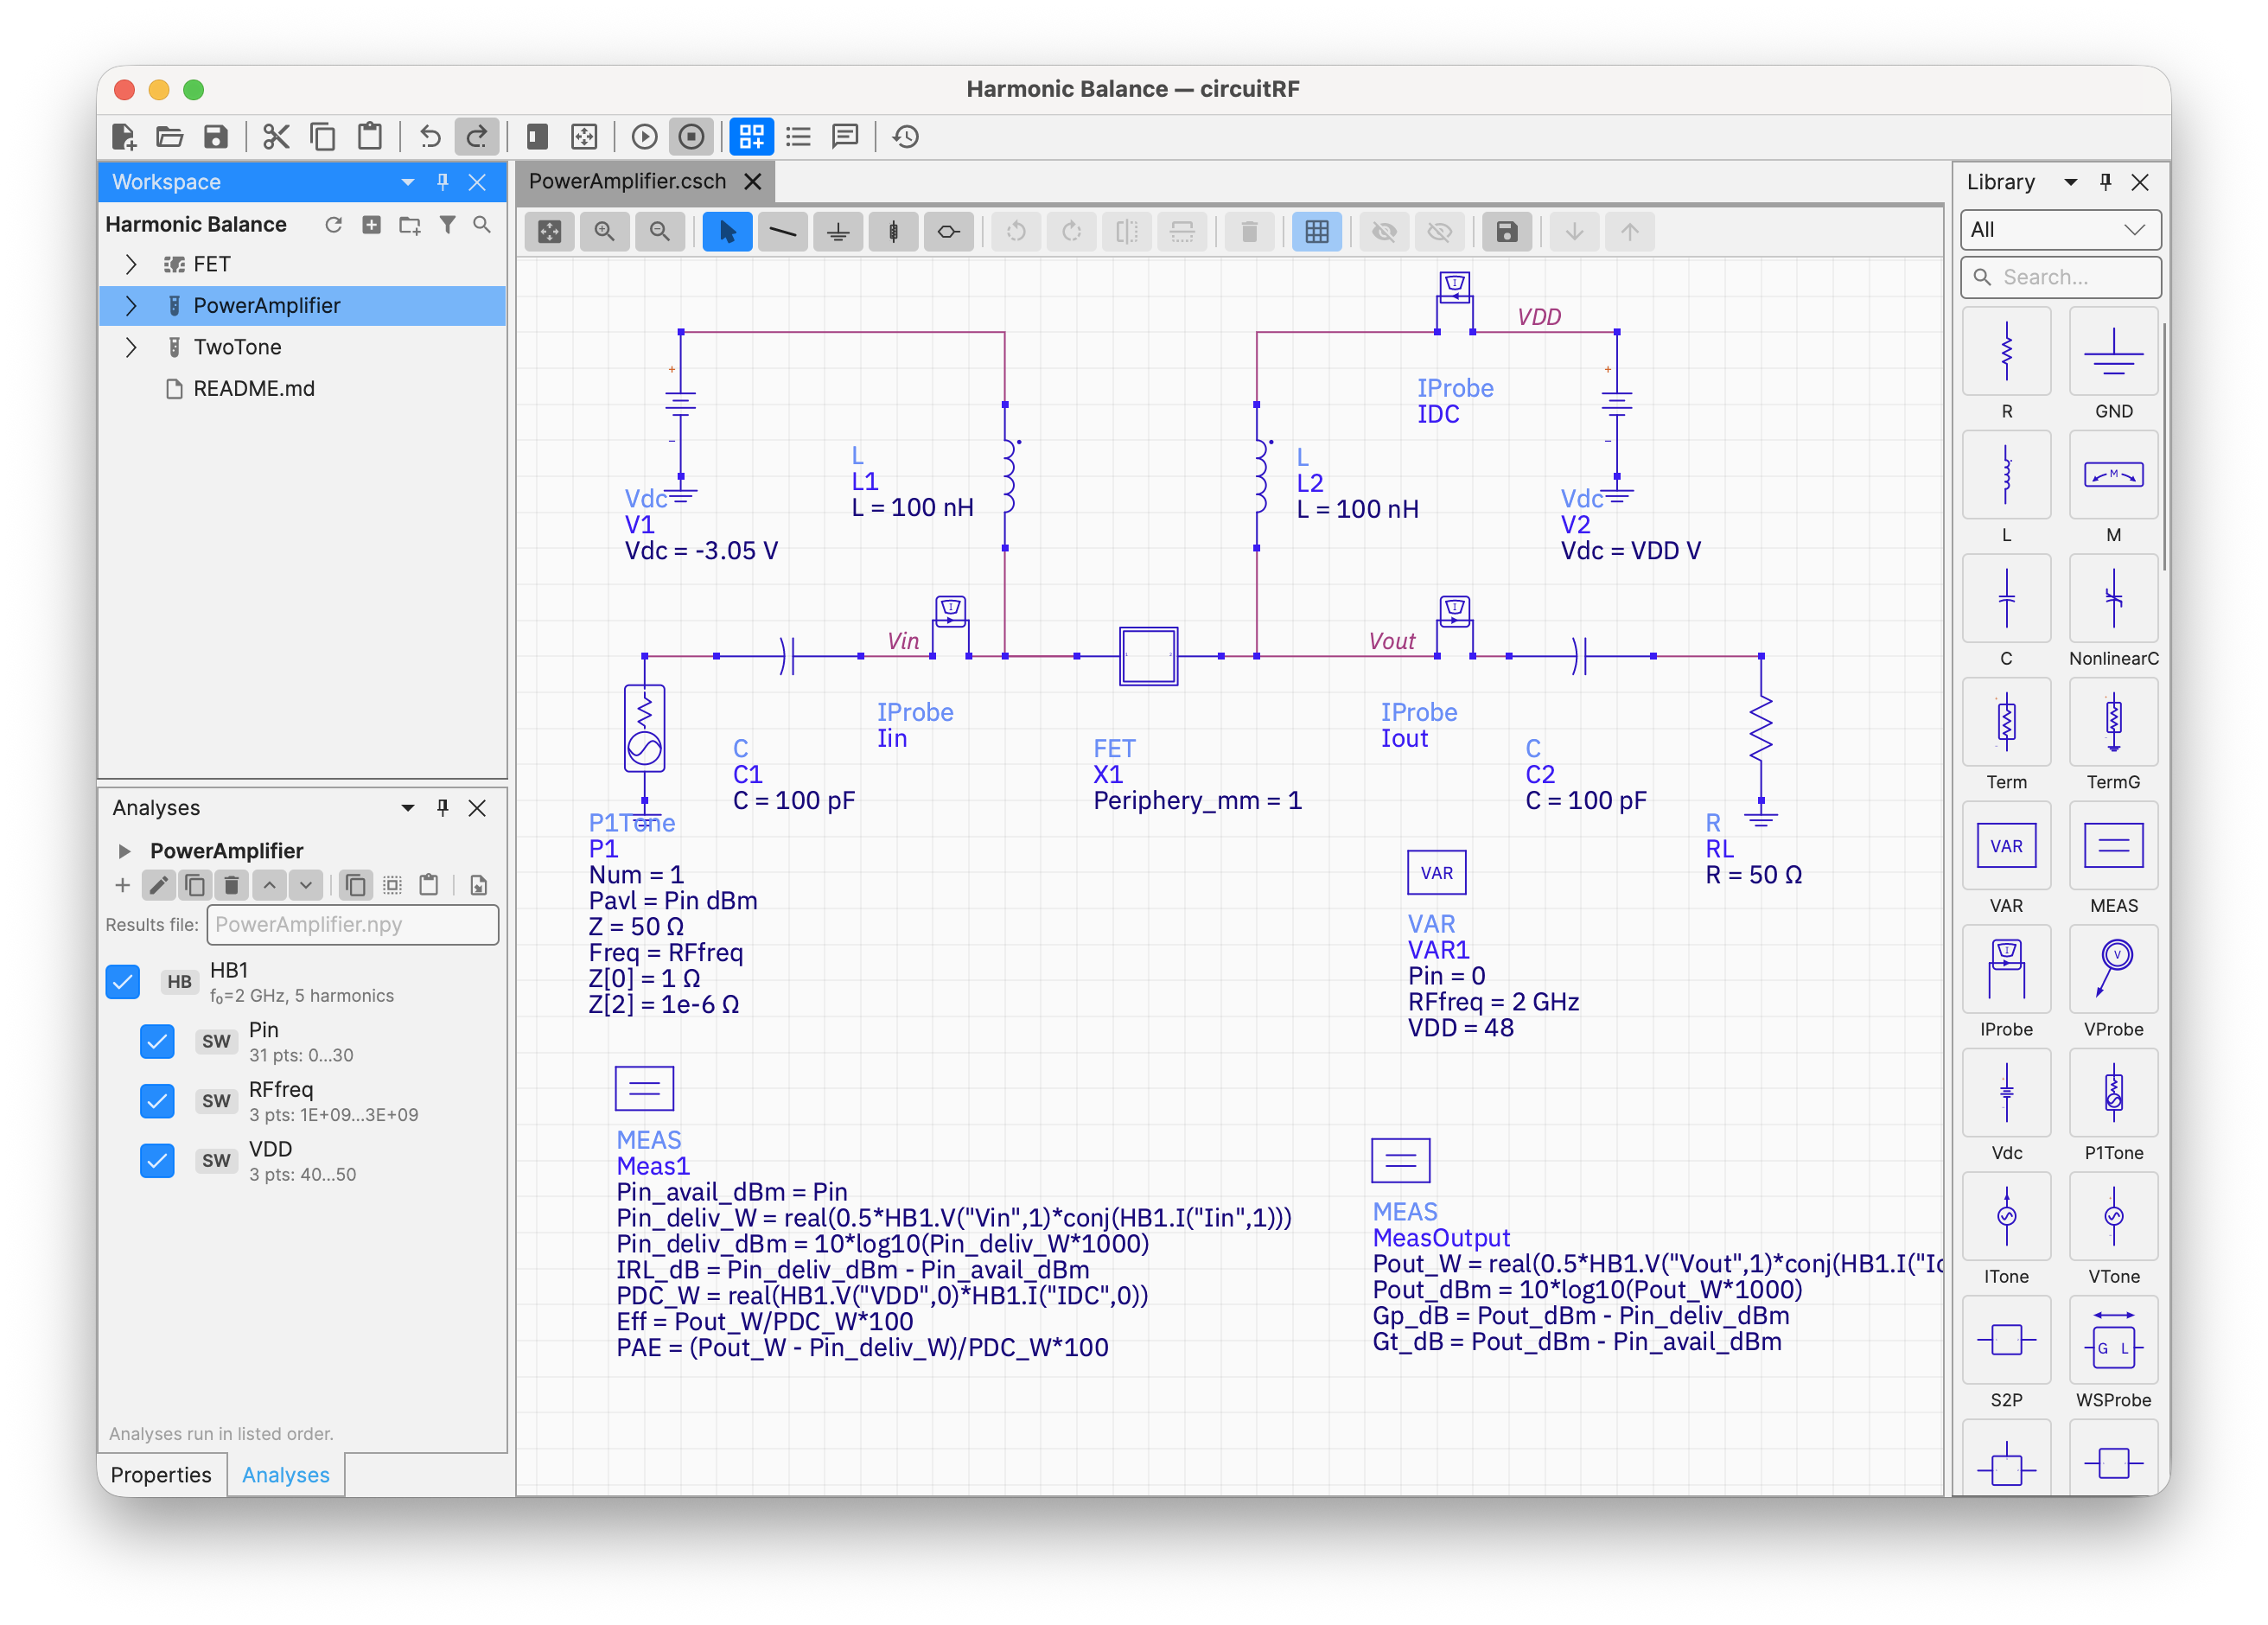
231potatobeanradio/circuitRF · C#circuitRF is a lightweight, cross-platform EDA tool for RF and microwave circuit design: schematic capture with DC/S-parameter/harmonic-balance simulation and loadpull, a 2D/3D layout editor, and electromagnetic (MoM/FEM/FDTD) plus thermal FEM solvers, all in one application.
- 77
multitown
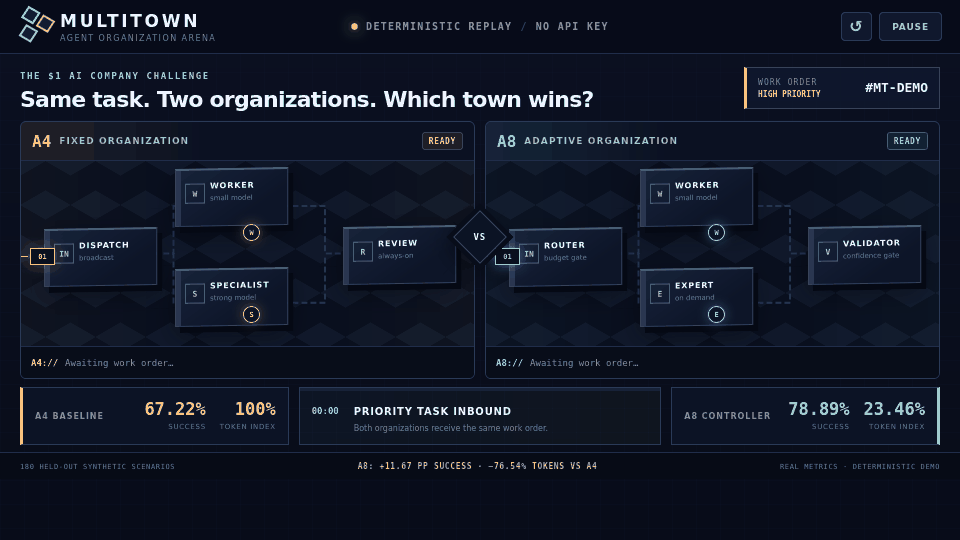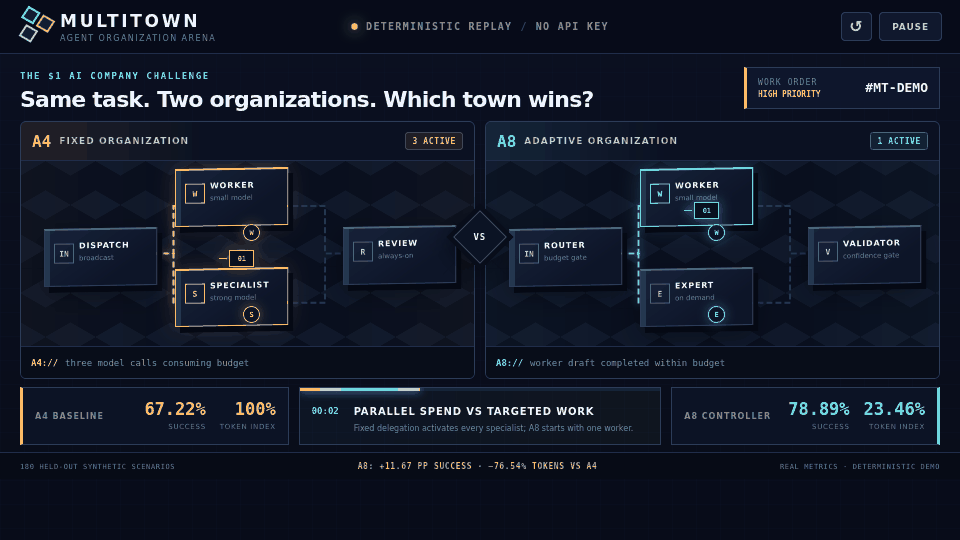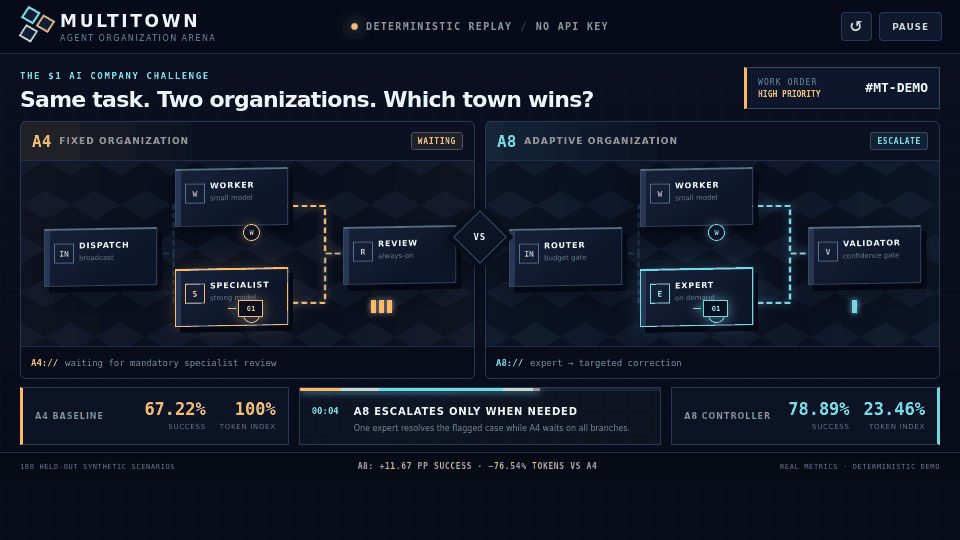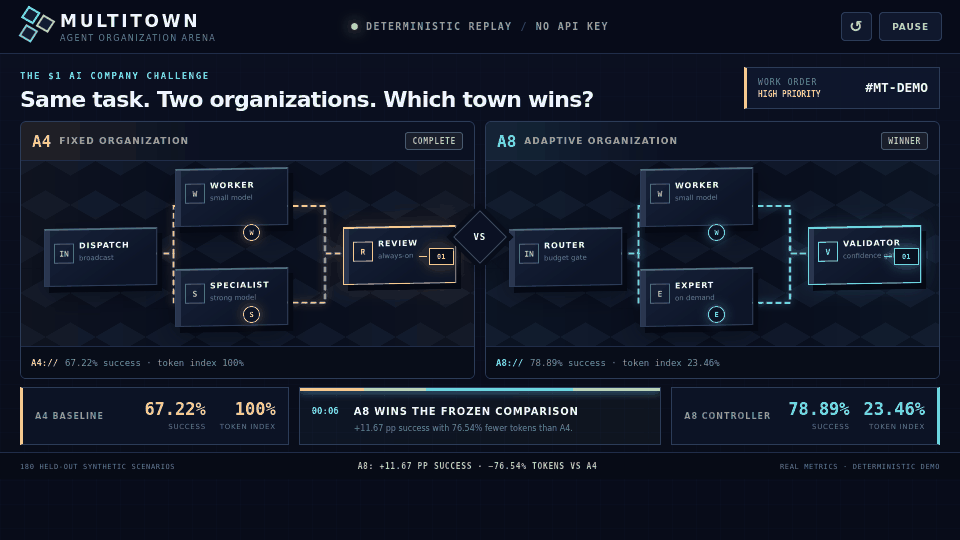
201w1u2d3i4/multitown · PythonMultiTown is a code-only Python runtime toolkit for cost-aware multi-agent organization and control, where Planner, Worker, Specialist, Validator and Router agents become buildings and residents in a visual 'cyber town' you can watch, compare and control.
- 78
Embodied-AI-Start
199ppsdk/Embodied-AI-StartA Chinese-language 'Embodied AI Starter Map' that organizes a learning path from robotics fundamentals (coordinates, kinematics, ROS 2) up to VLA policies, World Models, model-based RL and World Action Models (WAM), linking papers, code, benchmarks and practice guides at each step.
- 79
Air-Lingjing
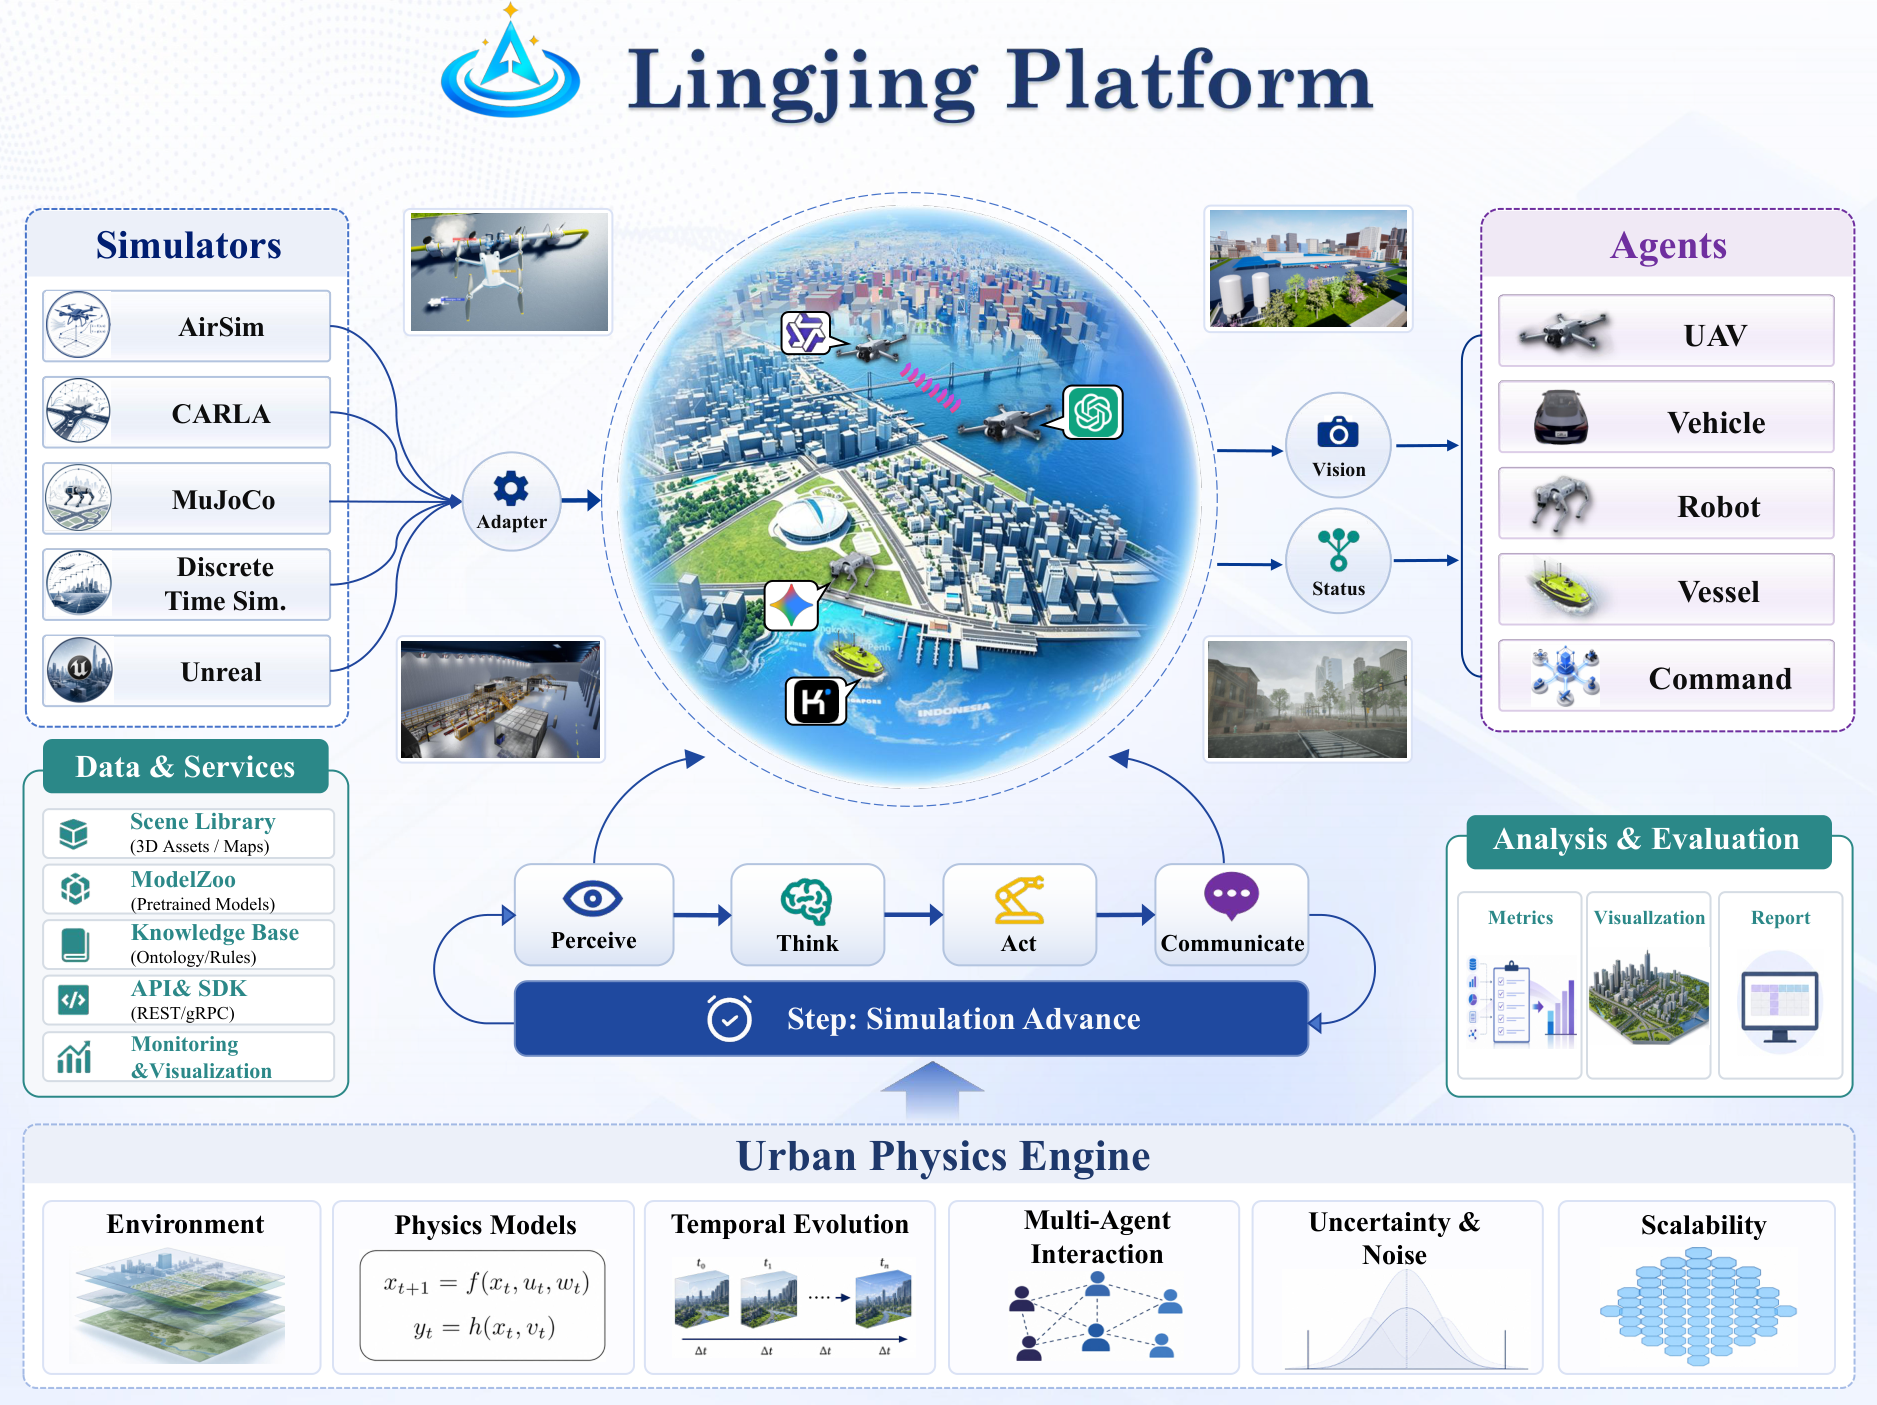
194seanlxh/Air-Lingjing · PythonLingJing is an open simulation stack for LLM-driven embodied agents in large 3D environments: a FastAPI/LangGraph backend plus a Cesium-powered Unreal Engine 5.5 plugin, with runnable example cases.
- 80
cbirds
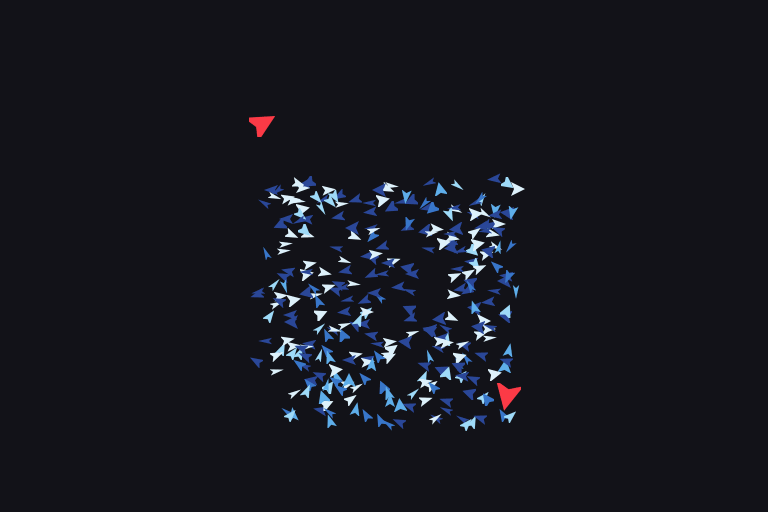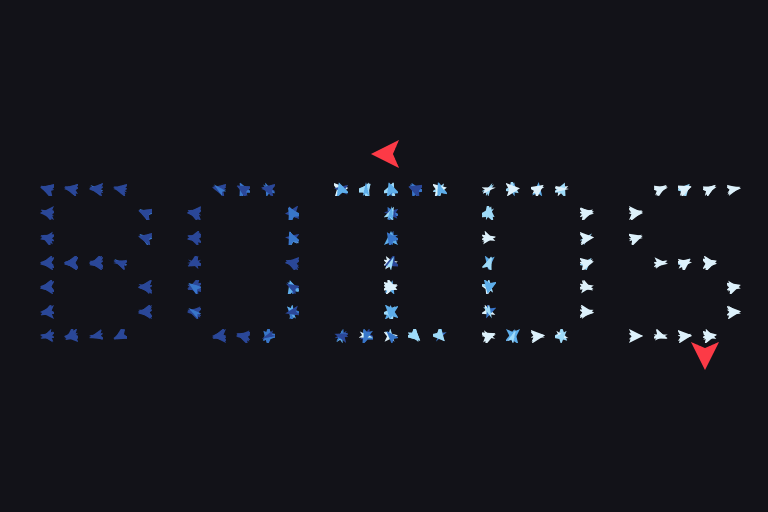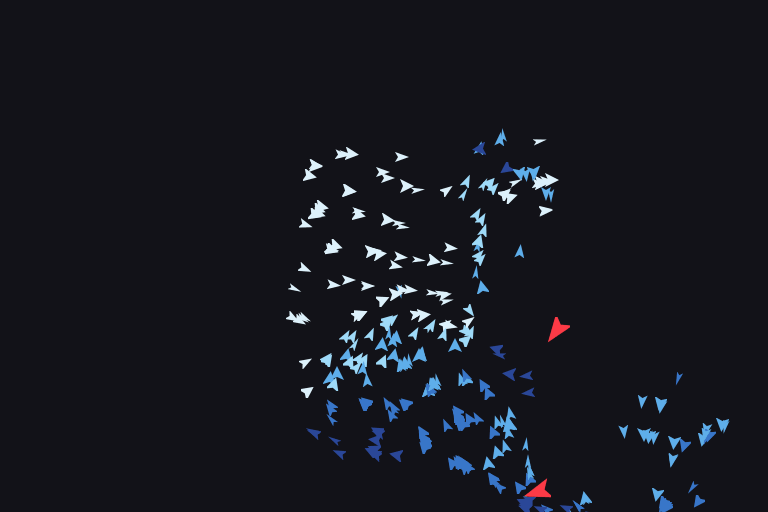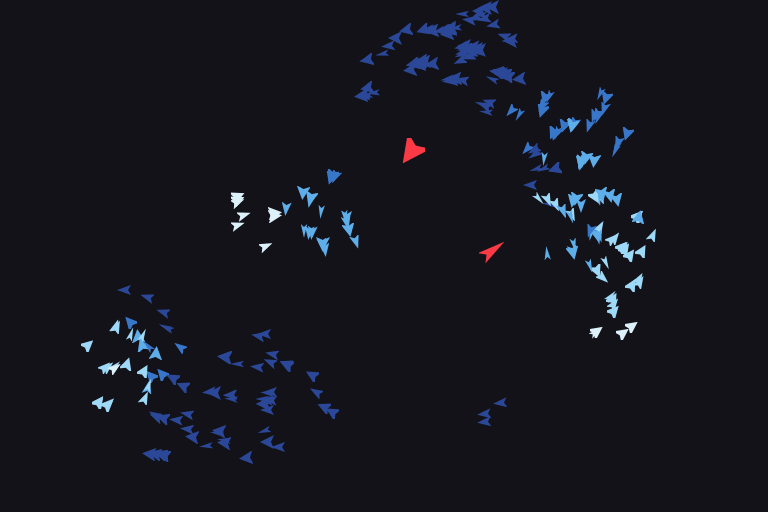
190clainstone/cbirds · Ccbirds is a terminal toy that simulates Craig Reynolds' boids - a flock of birds flying around your terminal, drawn in braille by default or as real sprites in Kitty/Ghostty via the Kitty graphics protocol.
- 81

Overflow
170Dollbar/Overflow · SystemVerilogOverflow is an open-source hardware engineering project from the Dollbar organization at USTC that builds synthesizable RTL for an AI accelerator SoC (NPU plus KDLink interconnect), targeting a Kimi-K3-scale mixture-of-experts model as the reference workload.
- 82

Jelly-Baby
170scottstts/Jelly-Baby · JavaScriptJelly Baby is a small 3D web toy: a bouncy jelly character living on a tabletop that you poke, stretch, and bounce around on a swing or trampoline, with no goals or scoring.
- 83

umat-skill
154xvchujin/umat-skill · PythonA sanitized public set of 25 skills for OpenAI Codex, covering Abaqus UMAT/VUMAT development: constitutive mechanism routing, return mapping, tensor interfaces, state contracts, damage audits, tangent verification and hierarchical validation.
- 84

fly-paradise
149pyd021226/fly-paradise · JavaScriptFly Paradise (果蝇乐园) is a Windows desktop virtual pet: a little colony of fruit flies lives and breeds right on your desktop.
- 85

karotte
143preferencemodel/karotte · PythonKarotte is an open-source framework from Preference Model for building robust reinforcement learning (RL) environments used to train aligned AI.
- 86

Wispverse
132mufengyuan6/Wispverse · PythonWispverse (芥子) is an AI-native evolution simulation game: 15-20 anthropomorphized characters autonomously develop division of labor, society and culture in a garden, while you play the 21st character — a disguised infiltrator who secretly steers the civilization through rare decision moments until they eventually identify you.
- 87
dreamforge
130rzc156/dreamforge · PythonDreamforge is a research pipeline that mines a robot policy's own failure states, uses a latent world model (CEM) to imagine corrective actions, and verifies each correction by replaying it in the real simulator before claiming it helps.
- 88

kantor-ai
116kangkungmozzarella/kantor-ai · JavaScriptKantor Kita is an interactive 3D paper-model visualization of a four-floor office housing a 13-person team, combined with a simple local task tracker for that team.
- 89
KISS-Knowledge-Infrastructure-for-Scientific-Simulation
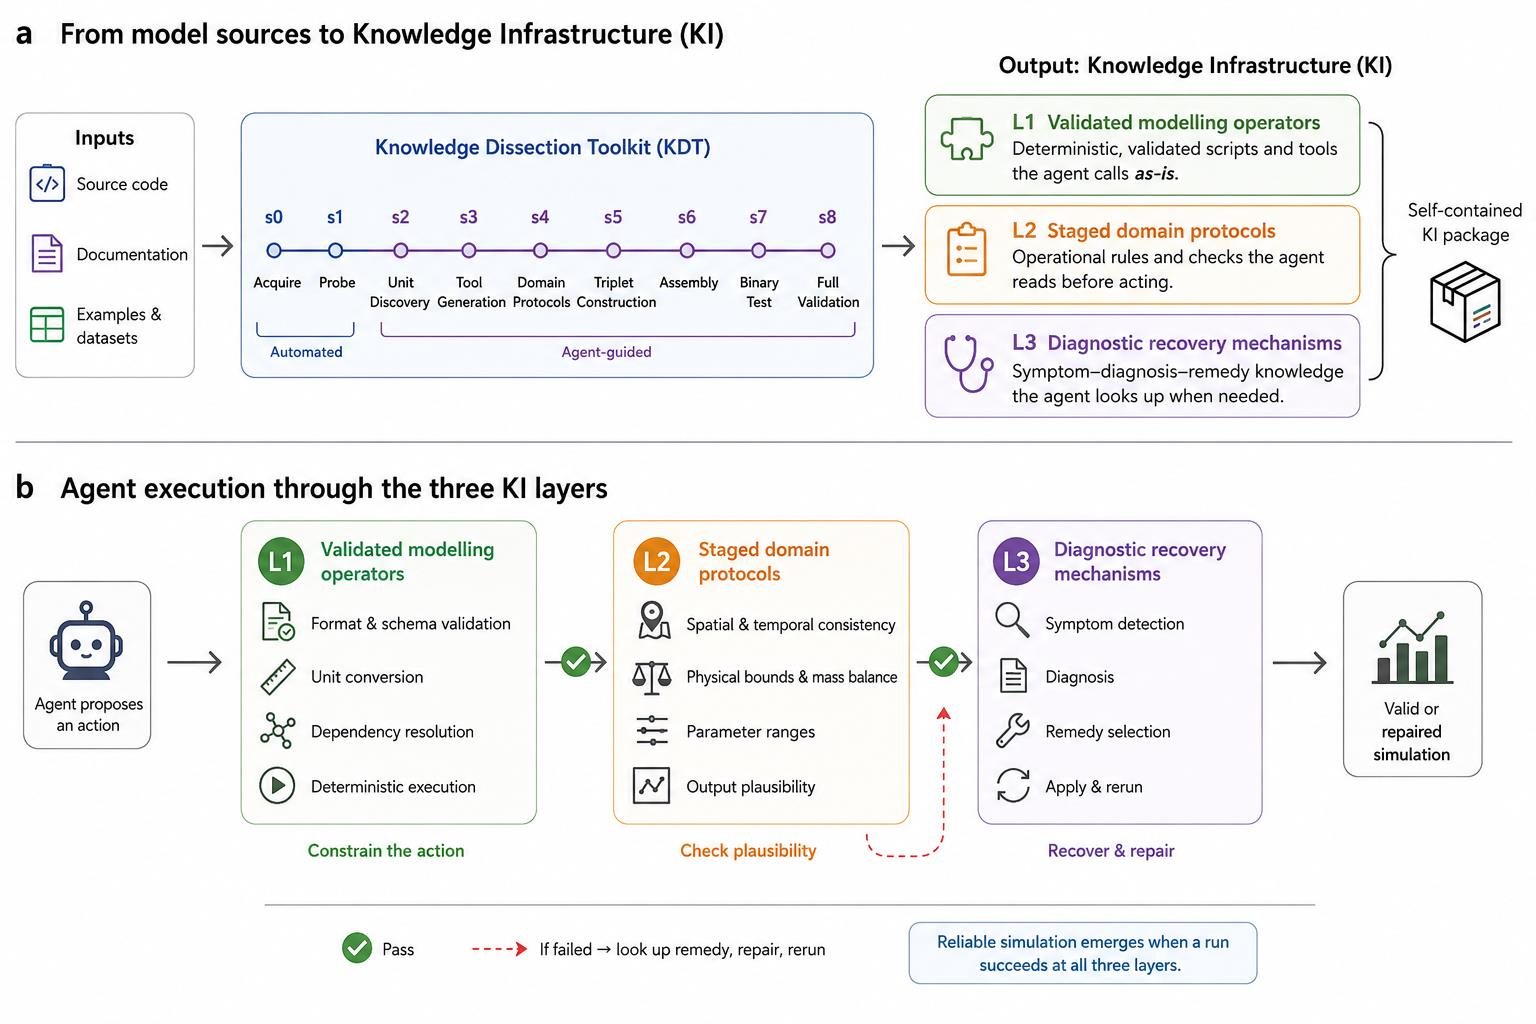
40lzwei196/KISS-Knowledge-Infrastructure-for-Scientific-Simulation · PythonKISS is a Knowledge Infrastructure (KI) framework that packages the operational expertise behind running scientific simulation models — how to prepare inputs, judge whether results are physically plausible, and recover from failures — so AI coding agents can run these models reliably, not just know their equations.
Related topics
Often tagged together
- open-source5,666
- python2,383
- linux4,184
- research764
- mit3,312
- machine-learning916
- windows3,403
- macos3,544
- robotics88
- deep-learning737
- gpu789
- ai1,955
- cross-platform2,623
- reinforcement-learning149
- benchmark431
- embodied-ai32
- 3d202
- framework758
- web2,447
- academic-research209
- apache-2.01,434
- c++418
- computer-vision384
- library1,587