Topics / #robot
Robot projects on GitHub
Robotics and automation, from embodied AI to desktop bots; mixed.
As of , the most-starred Robot projects on GitHub are PythonRobotics (30.7K stars), lerobot (28.2K stars) and ItChat (26.5K stars). GitHub.Locker tracks 21 Robot repositories with 176.7K stars combined. The fastest-growing on October 16 was microduck, with +47 stars in a day.
Hot right now
Most stars gained in a day · Oct 16
microduck
pollen-robotics/microduck · ★ 9.5KMicroduck is a tiny biped duck robot (about 25cm, 800g), and this repo is the robot's brain: Rust daemons that run a 50Hz control loop driving fifteen servos using reinforcement-learning policies exported to ONNX.
 +28
jumper
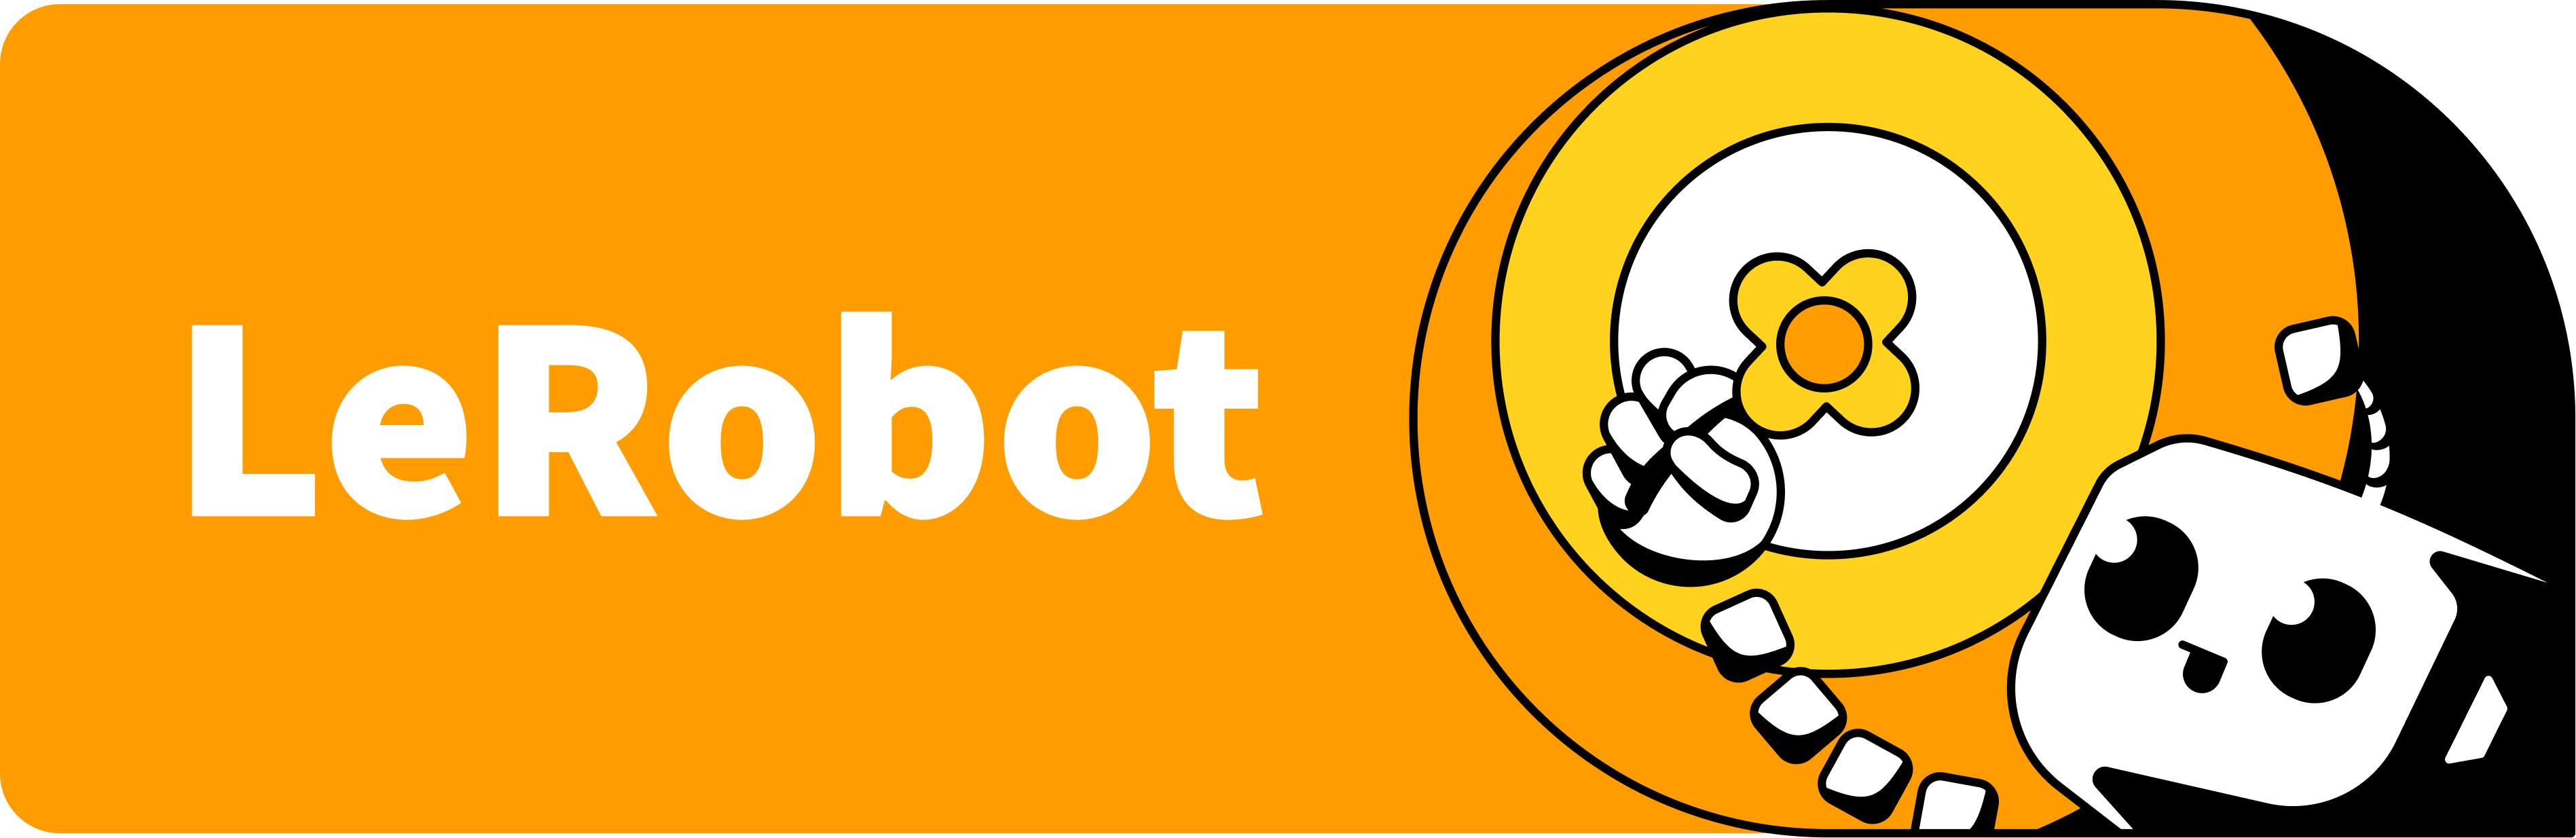
KingKongRobotics/jumper · ★ 2.7KJumper is a 22-DoF crab robot, and this repository is its AI toolkit for creating appearances, training motions, and building scenes for it.
 +24
lerobot
huggingface/lerobot · ★ 28.2KLeRobot is Hugging Face's open-source project providing models, datasets, and tools for real-world robotics in PyTorch, aiming to lower the barrier to entry for building and deploying robot learning policies.
 +17
Embodied-AI-Guide
TianxingChen/Embodied-AI-Guide · ★ 16.5KA free, encyclopedia-style Chinese knowledge base and resource index for embodied AI — robots that perceive and act in the physical world — maintained by the Lumina Embodied AI community. It is one of the most popular embodied-AI guides in China, with over 16,000 GitHub stars.
The all-time top
21 projects · by stars
- 30.7K
 #1 · AtsushiSakai/PythonRobotics
PythonRobotics
PythonRobotics is a Python code collection and textbook of classic robotics algorithms, covering localization, mapping, SLAM, path planning, path tracking, arm navigation, aerial navigation, and bipedal control.
- 28.2K#2 · huggingface/lerobot
lerobot
LeRobot is Hugging Face's open-source project providing models, datasets, and tools for real-world robotics in PyTorch, aiming to lower the barrier to entry for building and deploying robot learning policies.
- 26.5K
 #3 · littlecodersh/ItChat
ItChat
ItChat is an open-source API for WeChat personal accounts: you drive WeChat from Python, and a bot that handles every message type takes under 30 lines of code.
- 4

hubot
16.8Khubotio/hubot · JavaScriptHubot is a framework for building chat bots, modeled after GitHub's own internal Campfire bot of the same name. It's distributed as an npm library that you use to build your own bot which can run on many different chat services.
- 5
Embodied-AI-Guide
16.5KTianxingChen/Embodied-AI-GuideA free, encyclopedia-style Chinese knowledge base and resource index for embodied AI — robots that perceive and act in the physical world — maintained by the Lumina Embodied AI community. It is one of the most popular embodied-AI guides in China, with over 16,000 GitHub stars.
- 6

Dummy-Robot
15.6Kpeng-zhihui/Dummy-Robot · CThis is the author's open-source design for a super-compact robotic arm, including mechanical CAD files, custom PCB electronics, STM32 firmware, and PC control software for a self-built 6-axis desktop arm.
- 7

autoware
12.2Kautowarefoundation/autoware · DockerfileAutoware is the world's leading open-source autonomous driving framework — a complete software stack for building self-driving vehicles.
- 8
robotgo
10.9Kgo-vgo/robotgo · GoA Go library for native cross-platform desktop automation: it drives the mouse and keyboard, reads the screen, manages windows and processes, and listens to global events — aimed at RPA, auto-testing and AI computer use.
- 9
microduck
9.5Kpollen-robotics/microduck · RustMicroduck is a tiny biped duck robot (about 25cm, 800g), and this repo is the robot's brain: Rust daemons that run a 50Hz control loop driving fifteen servos using reinforcement-learning policies exported to ONNX.
- 10
jumper
2.7KKingKongRobotics/jumper · PythonJumper is a 22-DoF crab robot, and this repository is its AI toolkit for creating appearances, training motions, and building scenes for it.
- 11
Zetta-Embodiment
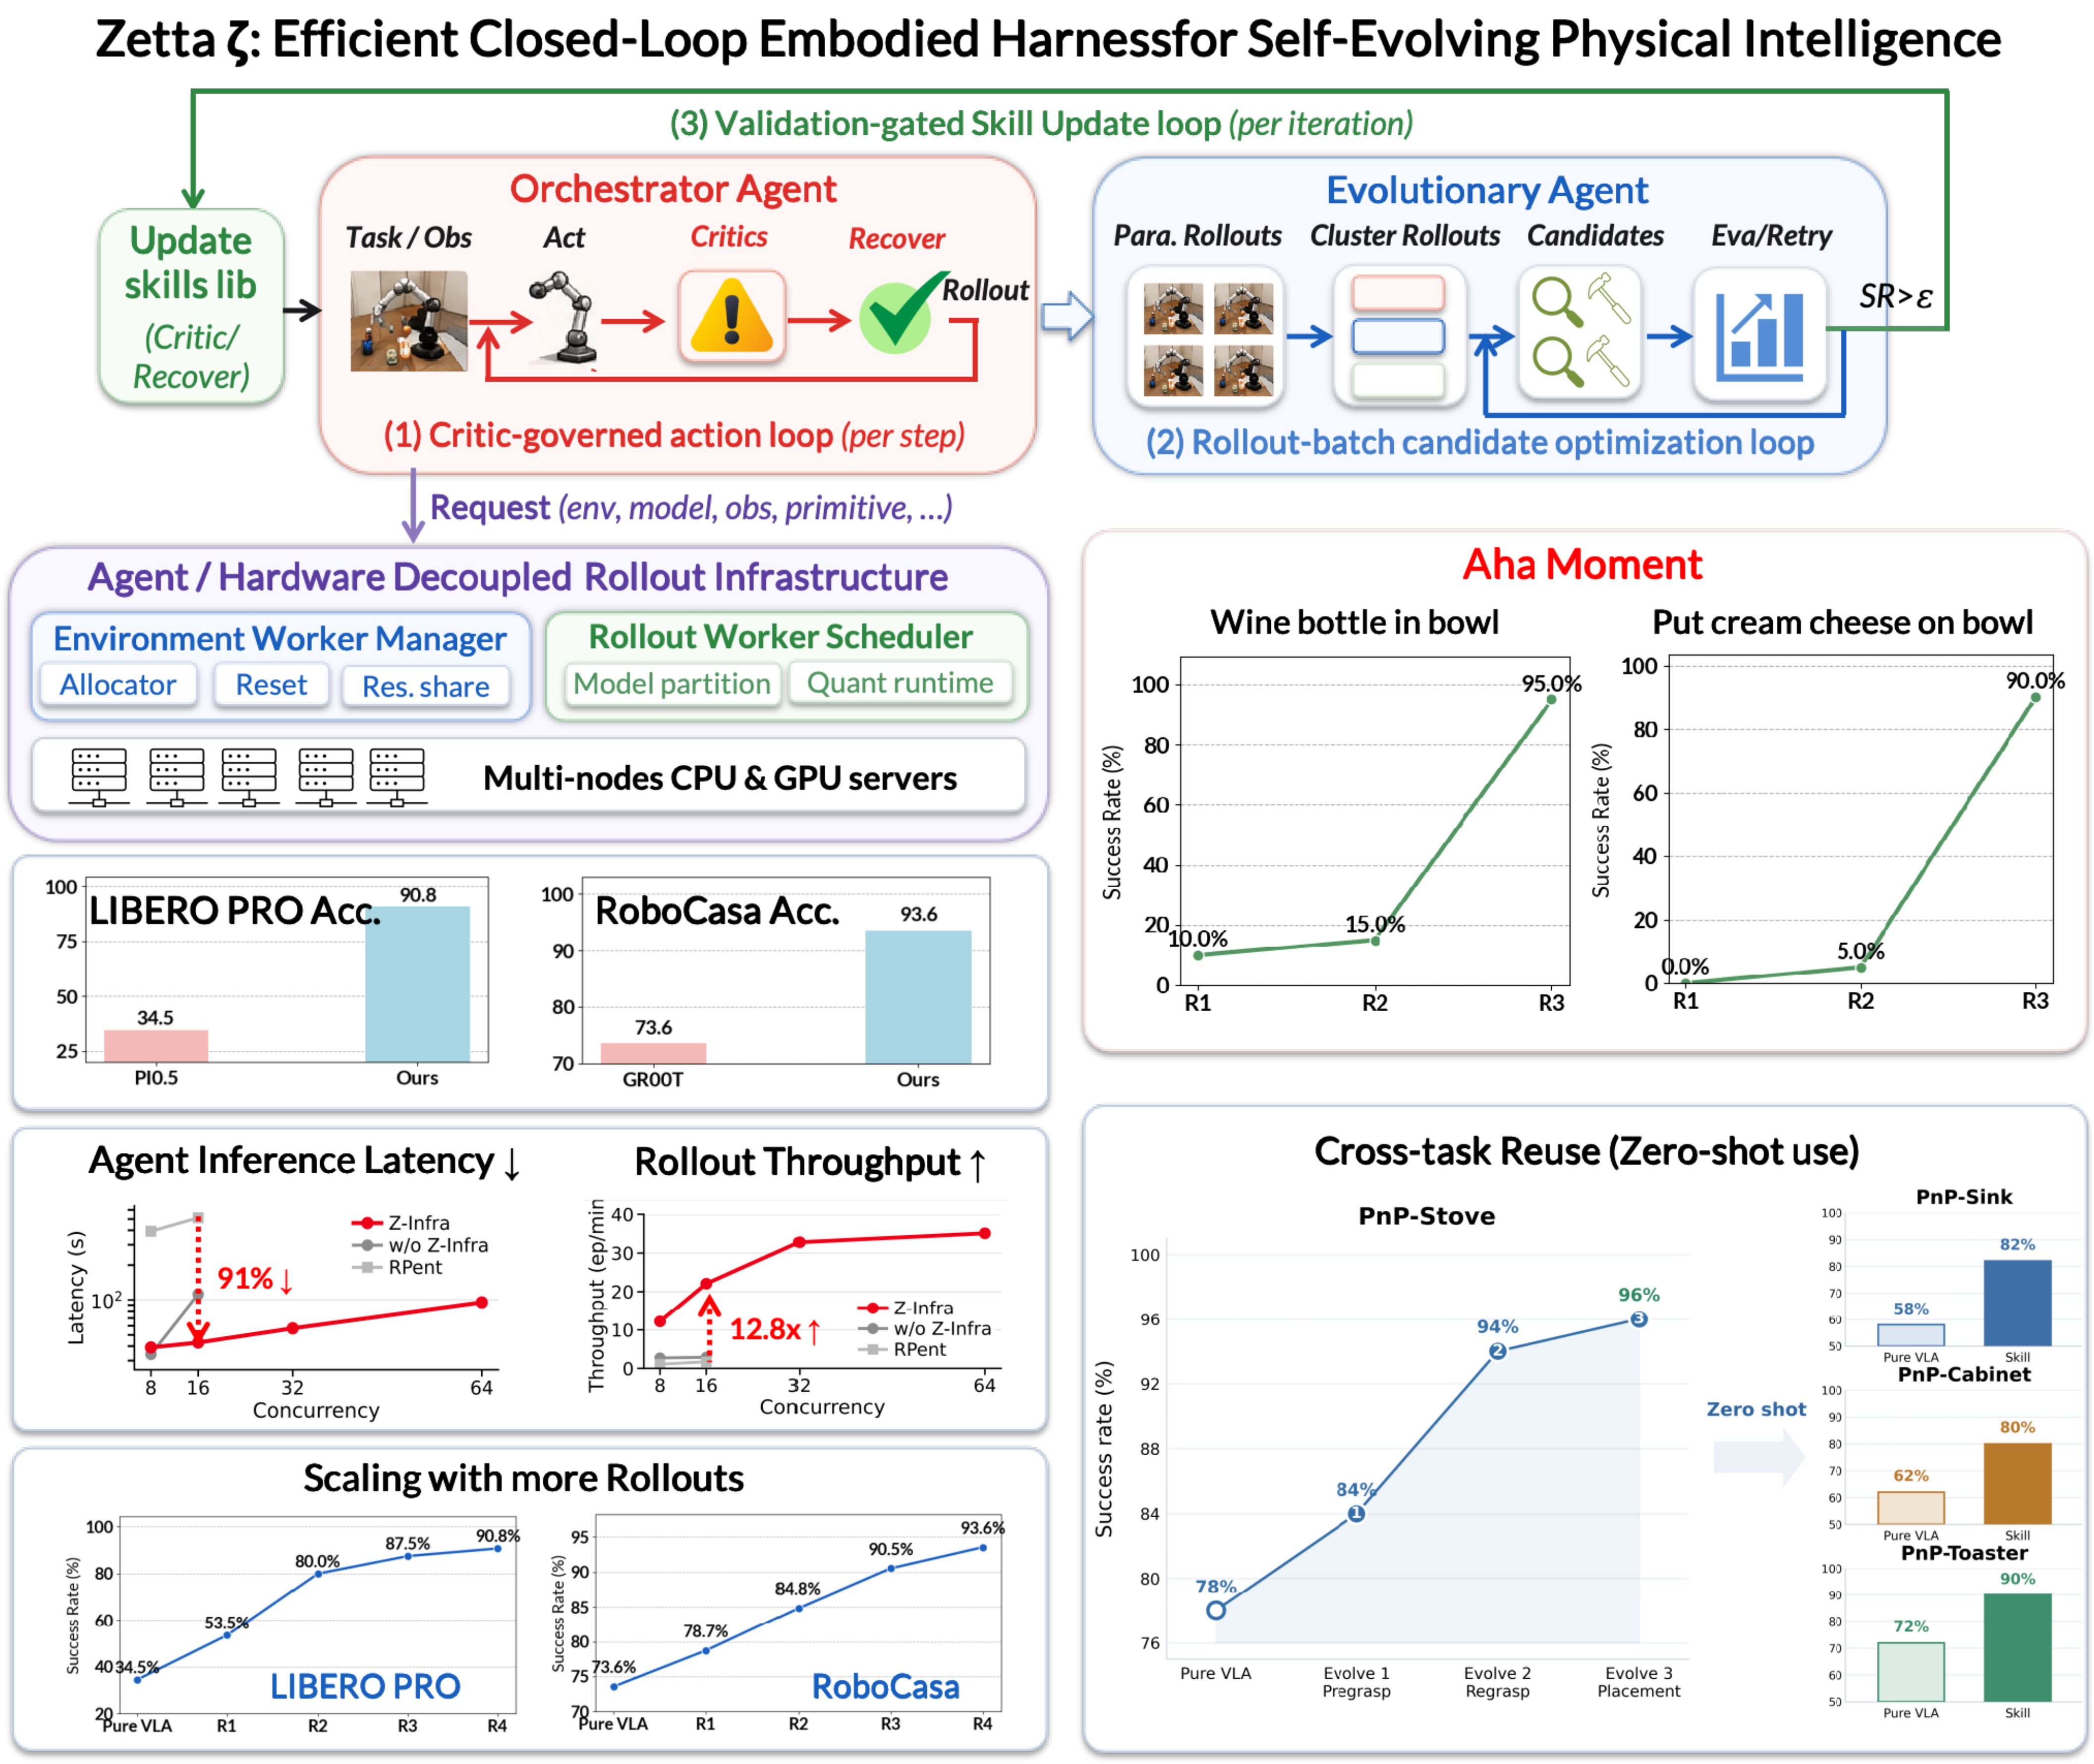
1.3Kair-embodied-brain/Zetta-Embodiment · PythonZetta is a closed-loop embodied harness that evolves code-based runtime critics and recovery skills online while keeping the base robot policy frozen, reaching 90.8% success on LIBERO-Pro and 93.6% on RoboCasa with an 11.1x inference speedup.
- 12
Microduck-build-tutorial
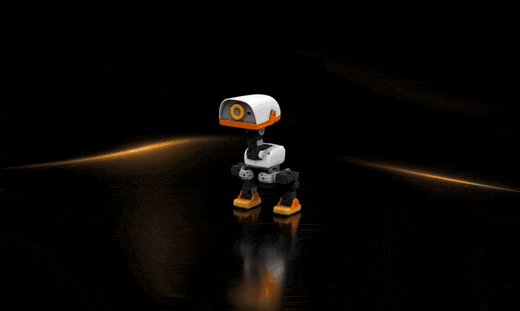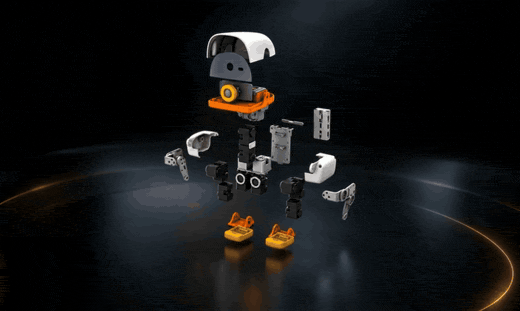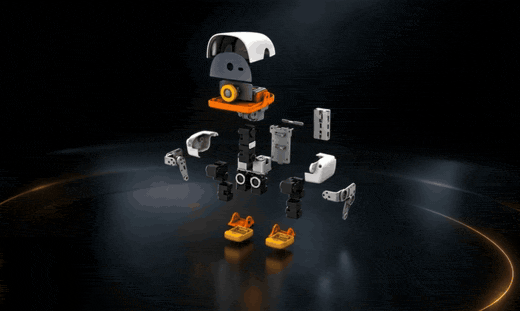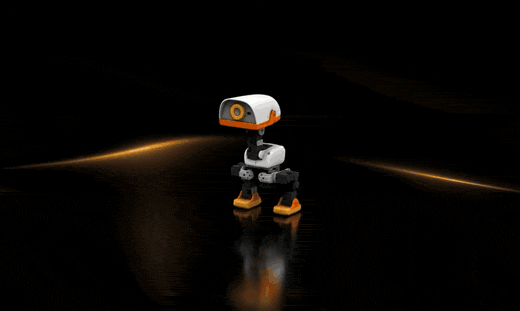
1.3KAI-FanGe/Microduck-build-tutorial · PythonMicroduck is a build tutorial and codebase for a compact biped (two-legged) robot: deployment code that runs on a Raspberry Pi Zero 2 W to drive Dynamixel servos using an ONNX reinforcement-learning walking policy, plus a MuJoCo/MjLab-based training environment to produce that policy.
- 13

microduck-replica
1.2Kfanhao375/microduck-replica · HTMLThis is a third-party reverse-engineering project that reconstructs the hardware of Pollen Robotics' Microduck bipedal robot duck - deriving assembly drawings, CAD files and a full electronics scheme from the official public MJCF simulation model and Rust source code, since the mechanical parts and one PCB were never officially open-sourced.
- 14
Motus2
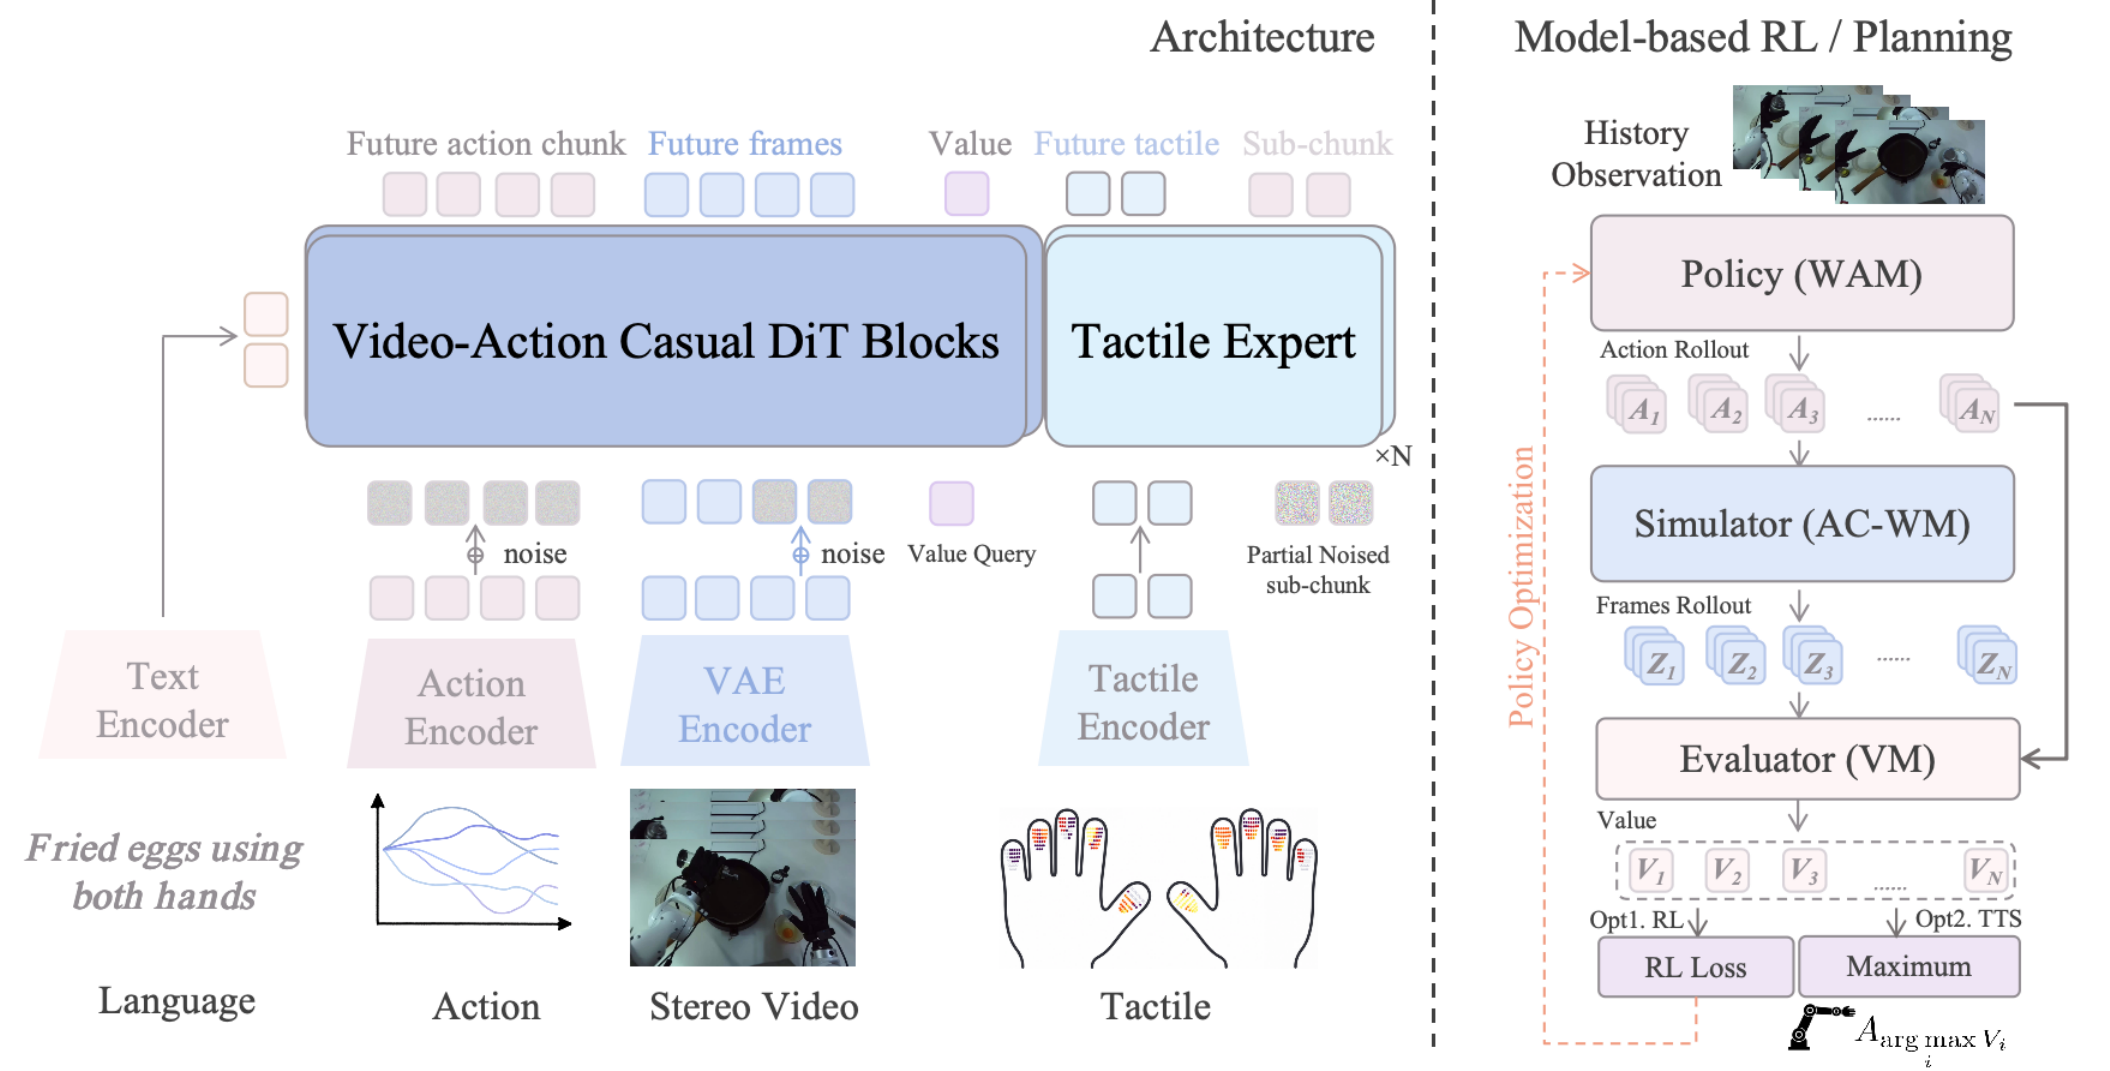
685shengshu-ai/Motus2Motus2 is a self-evolving general world model for dexterous robot manipulation. A single model with shared weights acts as a policy, a simulator, and an evaluator, coupling them into a closed decision-and-learning loop so the system can perceive, predict, act, and improve itself.
- 15
WholebodyVLA
580OpenDriveLab/WholebodyVLAWholeBodyVLA is an ICLR 2026 research project introducing a unified Vision-Language-Action framework for closed-loop humanoid whole-body loco-manipulation control, and this repository doubles as a curated, continuously updated list of VLA papers for humanoid robots.
- 16
UMR
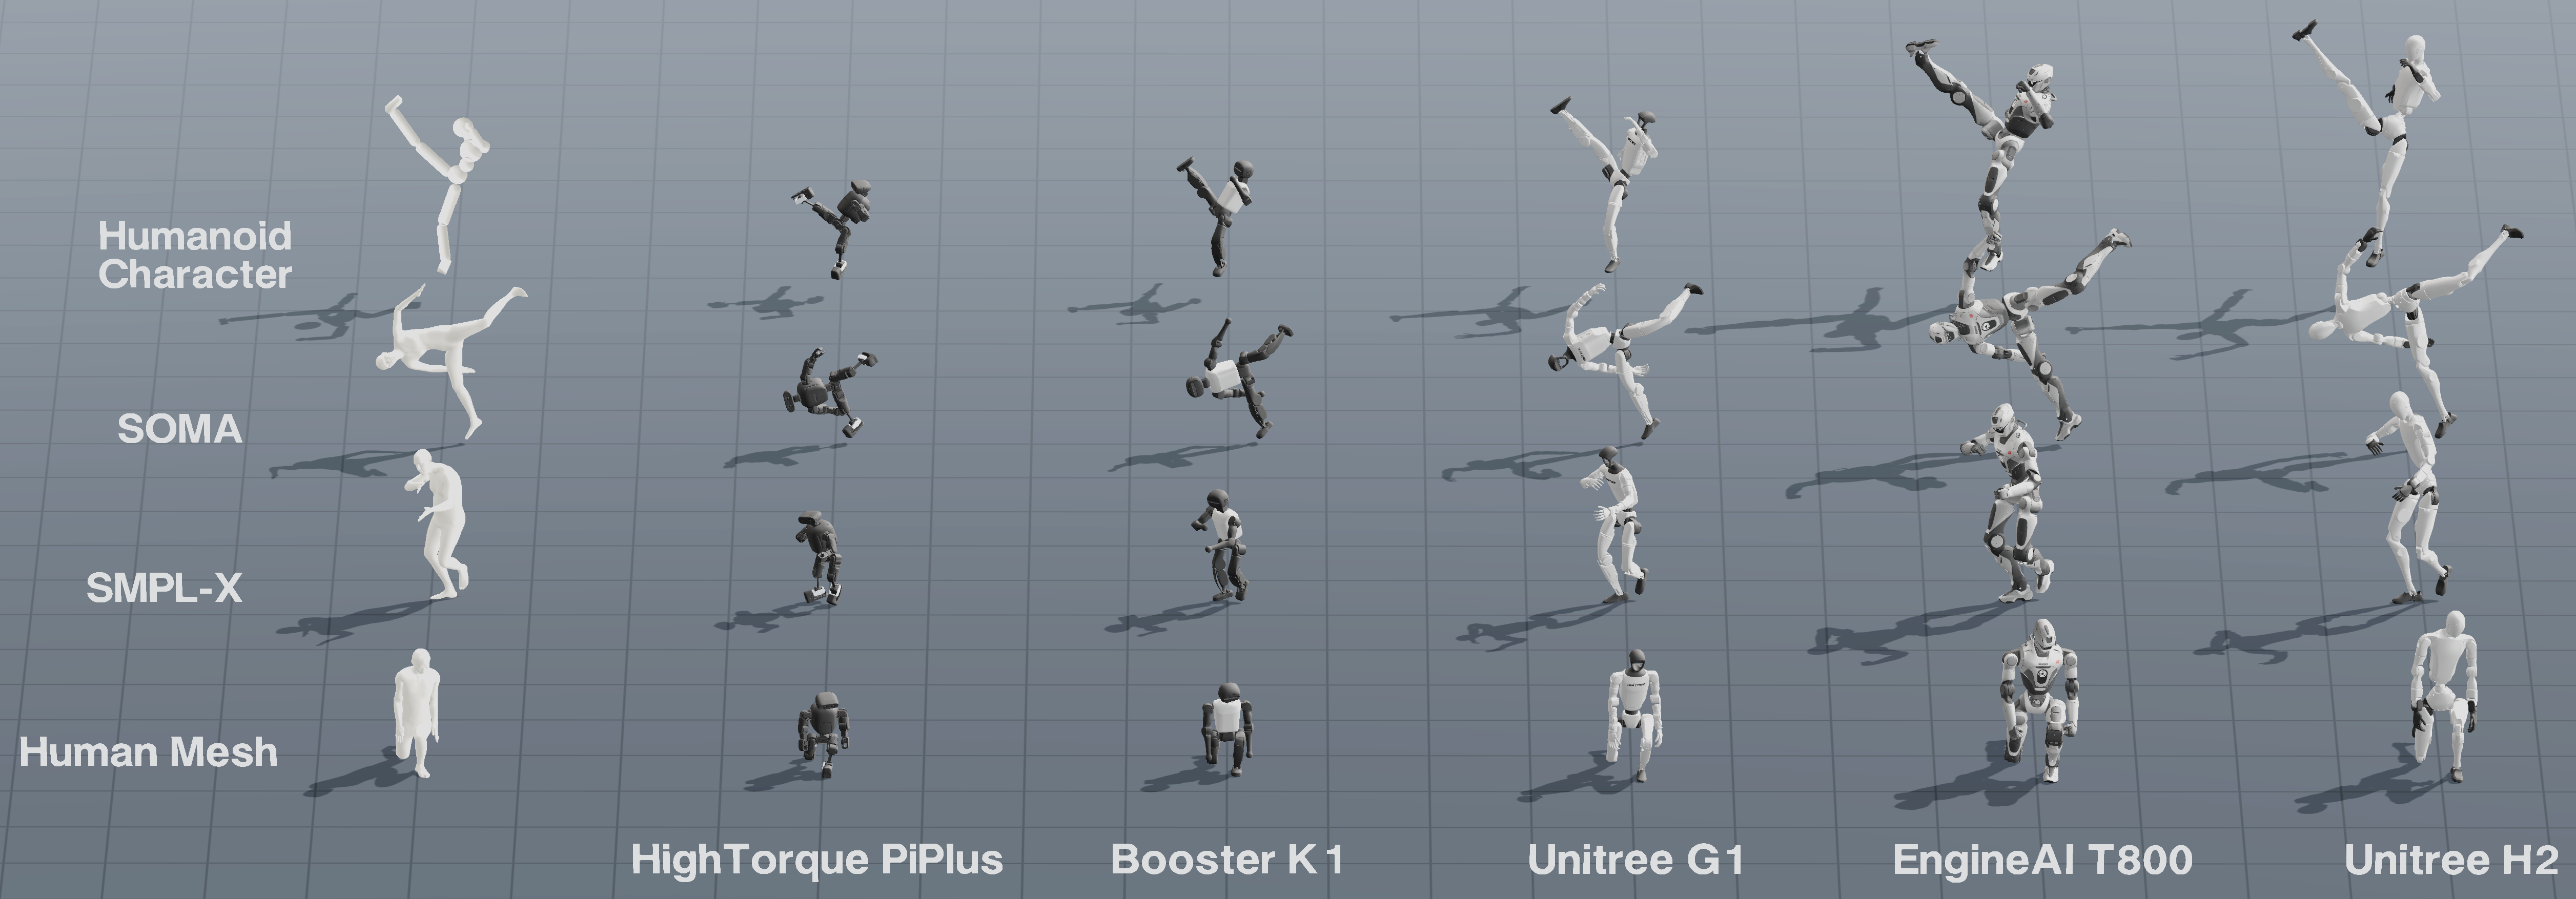
491hanyang9/UMR · PythonUMR (Unified Motion Retargeting) is a research codebase that retargets human motion onto humanoid robots by treating the moving exterior body surface as a shared interface between the source motion and the robot.
- 17
Zero-WAM
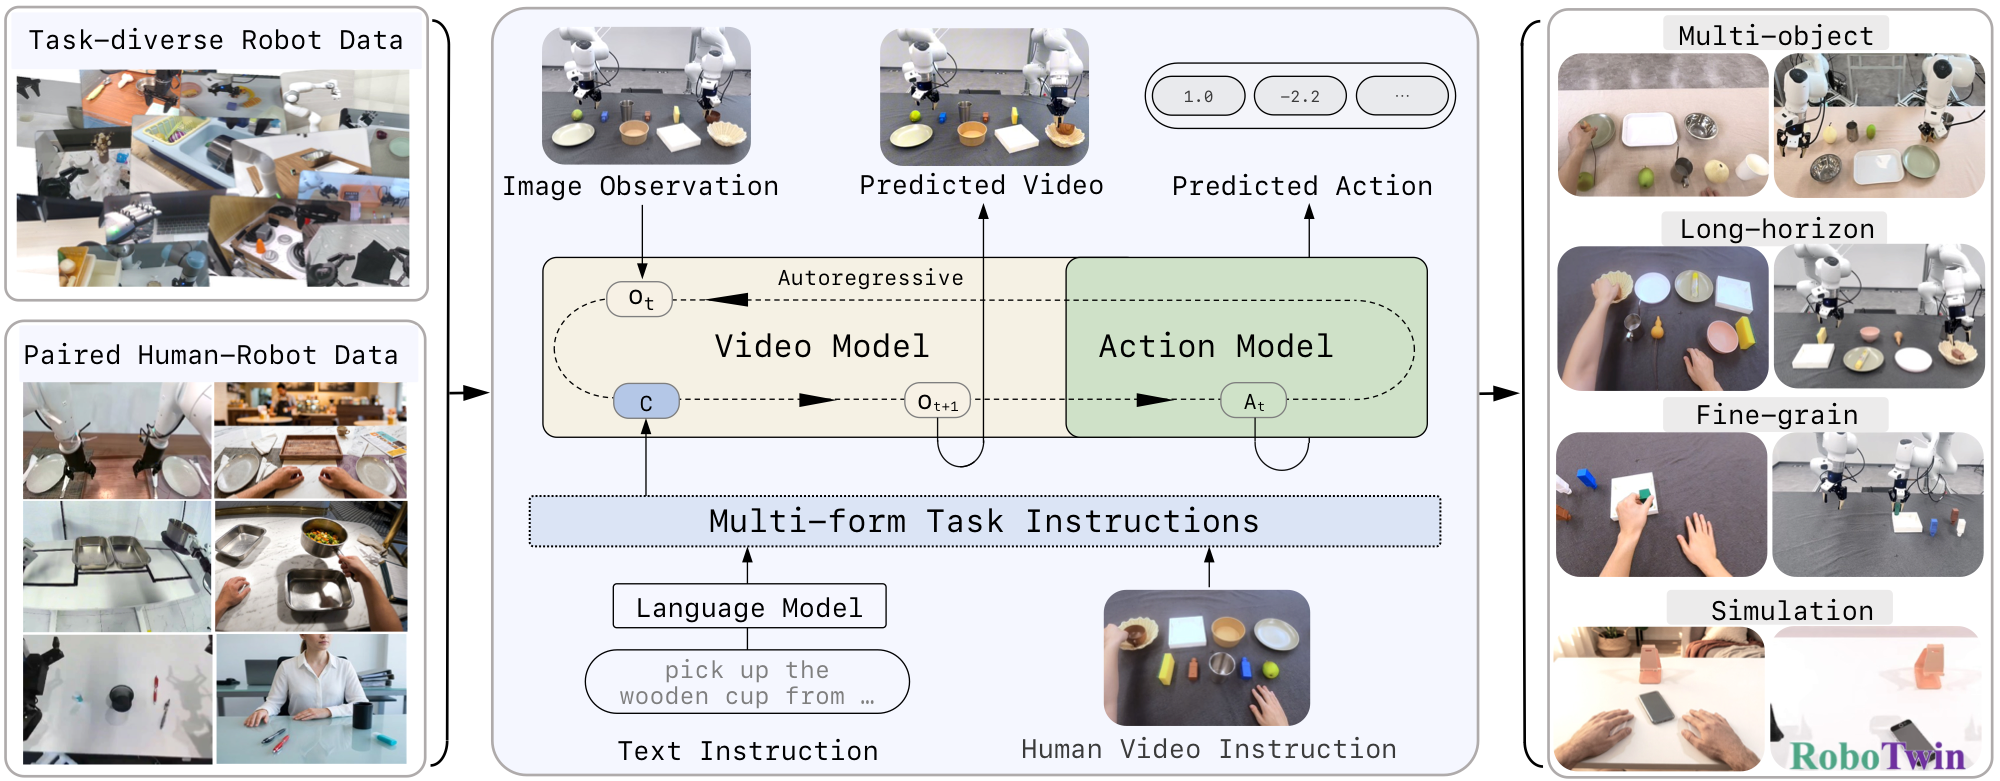
434robbyant-research/Zero-WAM · PythonZero-WAM is a research method for zero-shot cross-task robotic manipulation: a causal video-action policy that learns in-context world-action modeling, predicting future robot observations and executable actions from either language instructions or human demonstration videos.
- 18

robot-heads
353fayazara/robot-heads · TypeScriptrobot-heads is a React component library that renders animated, TV-headed robot avatars with LED-matrix faces showing what an AI agent is currently doing — thinking, searching, listening, speaking and more.
- 19
RoboICL
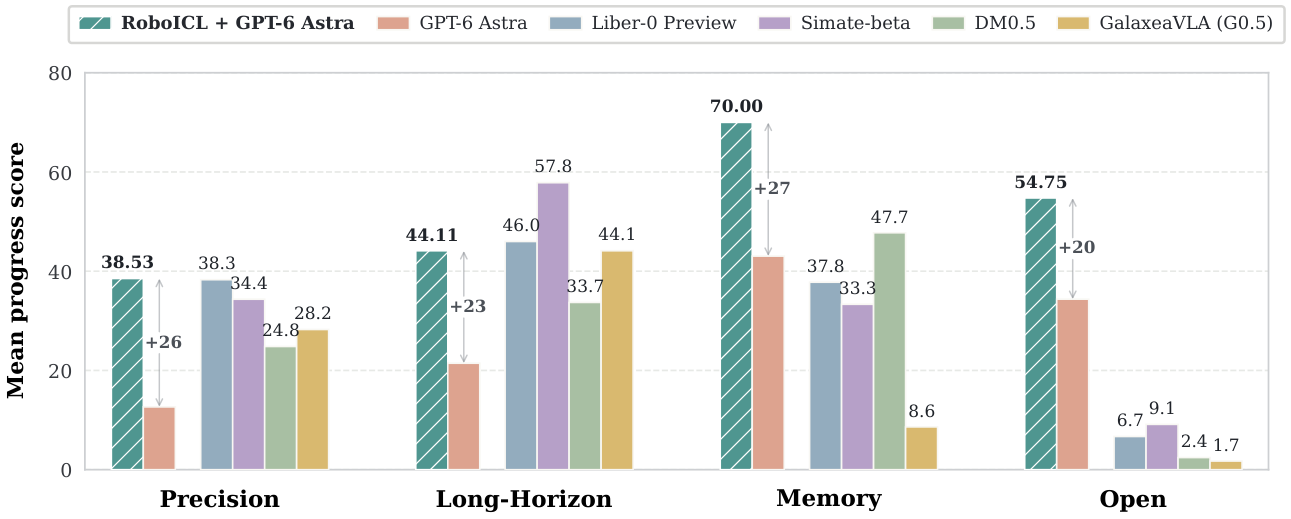
268Mosi-AI/RoboICL · PythonRoboICL is a research framework that lets a frozen, general-purpose vision-language model (GPT-6 Astra) control a robot in simulation purely through in-context learning, without training a dedicated robot policy.
- 20
RoboHarness
246BinceQu/RoboHarness · PythonRoboHarness is a training-free harness that gives an LLM agent a visual-geometric control panel: the model marks points of interest on 2D images, which get tracked and turned into geometric constraints so the LLM can directly compose and execute embodied manipulation actions.
- 21
flex-pi
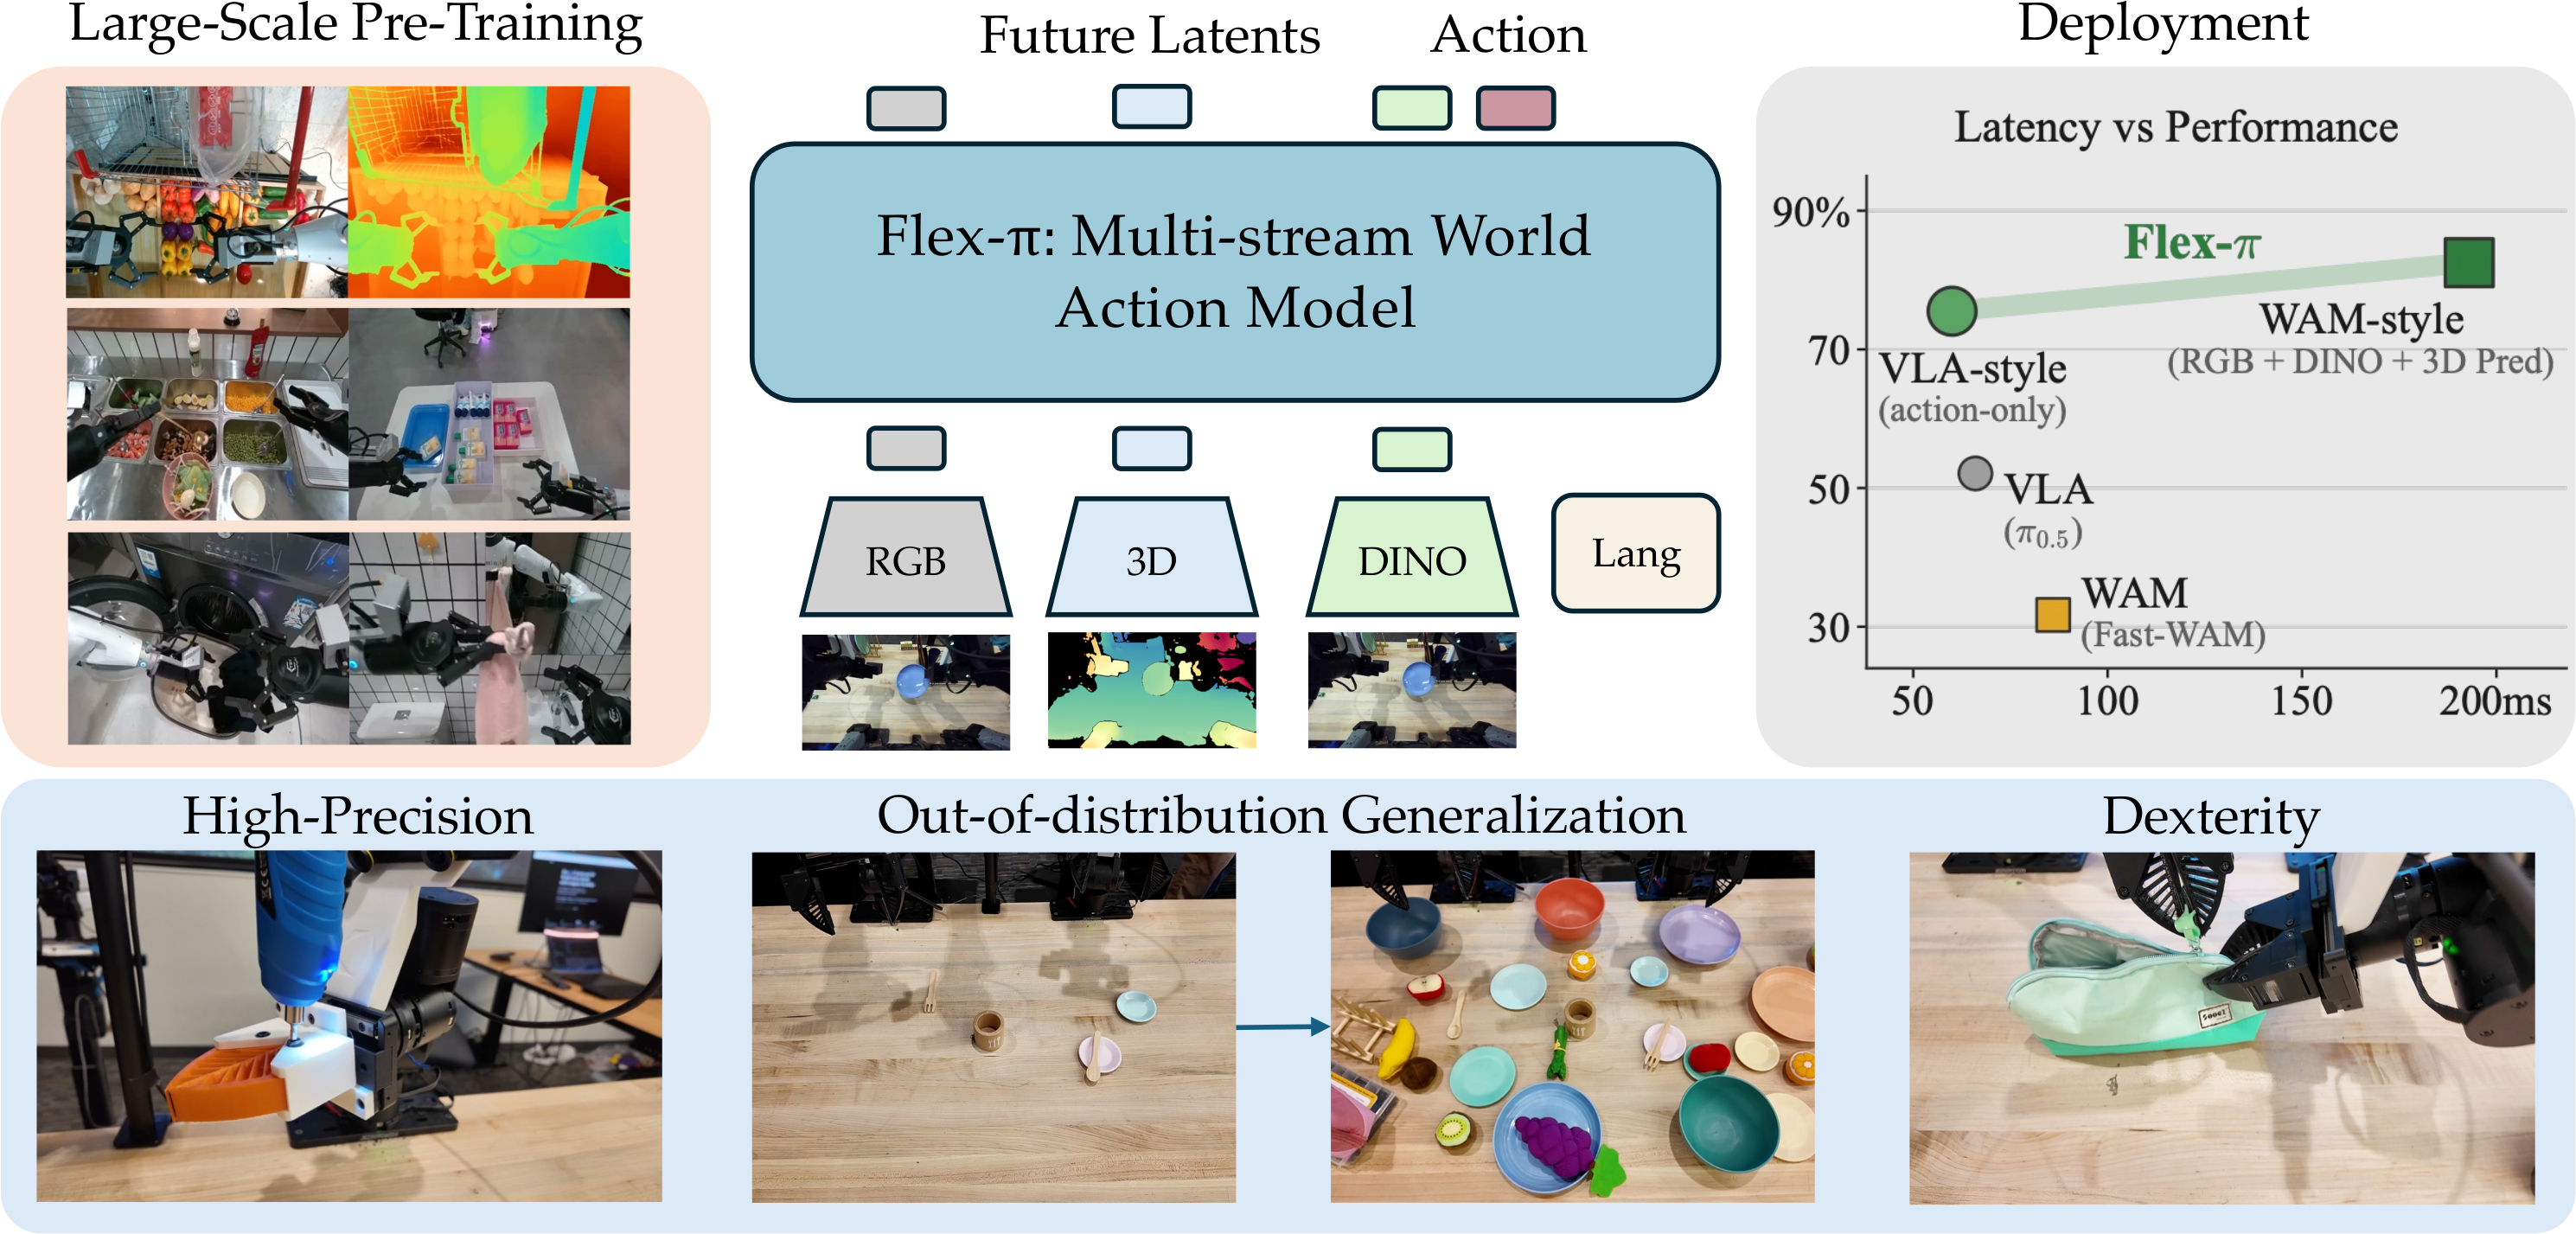
225geyan21/flex-pi · PythonFlex-π is a 6B-parameter world-action model for robot manipulation that jointly predicts future RGB, 3D pointmaps, DINOv3 semantics, and actions from one checkpoint, so it can deploy as a VLA, a full world model, or anything in between.
Related topics
Often tagged together
- robotics88
- open-source5,666
- research764
- python2,383
- embodied-ai32
- simulation89
- computer-vision384
- linux4,184
- mit3,312
- machine-learning916
- benchmark431
- deep-learning737
- reinforcement-learning149
- apache-2.01,434
- gpu789
- developer-tools2,924
- hardware182
- academic-research209
- chinese1,159
- embedded138
- framework758
- library1,587
- multimodal189
- world-models29