Topics / #physical-ai
Physical AI projects on GitHub
AI applied to robotics and real-world physical systems.
As of , the most-starred Physical AI projects on GitHub are cs249r_book (29K stars), lerobot (28.2K stars) and Zetta-Embodiment (1.3K stars). GitHub.Locker tracks 8 Physical AI repositories with 60.6K stars combined. The fastest-growing on October 16 was lerobot, with +24 stars in a day.
Hot right now
Most stars gained in a day · Oct 16
 +24
lerobot
huggingface/lerobot · ★ 28.2KLeRobot is Hugging Face's open-source project providing models, datasets, and tools for real-world robotics in PyTorch, aiming to lower the barrier to entry for building and deploying robot learning policies.
 +15
cs249r_book
harvard-edge/cs249r_book · ★ 29KAn open textbook and full curriculum on Machine Learning Systems — AI engineering — from Harvard's CS249r course: four volumes covering foundations, scaling, agentic AI, and physical AI, plus labs, projects, and instructor materials.
 +4
intrinsic-core
intrinsic-ai/intrinsic-core · ★ 583Intrinsic Core is an open, local runtime, SDK and hardware-agnostic real-time control framework for industrial robotics. It provides foundational building blocks for AI-enabled robot applications, from simulation and 6-DoF perception down to hardware execution.
 +2
hflow
Hebbian-Robotics/hflow · ★ 298HFlow is an open source SDK from Hebbian Robotics (YC S26) for building scalable multimodal data pipelines for robotics and physical AI, letting teams verify the quality of the data they use to train AI models.
The all-time top
8 projects · by stars
- 29K#1 · harvard-edge/cs249r_book
cs249r_book
An open textbook and full curriculum on Machine Learning Systems — AI engineering — from Harvard's CS249r course: four volumes covering foundations, scaling, agentic AI, and physical AI, plus labs, projects, and instructor materials.
- 28.2K#2 · huggingface/lerobot
lerobot
LeRobot is Hugging Face's open-source project providing models, datasets, and tools for real-world robotics in PyTorch, aiming to lower the barrier to entry for building and deploying robot learning policies.
- 1.3K
 #3 · air-embodied-brain/Zetta-Embodiment
Zetta-Embodiment
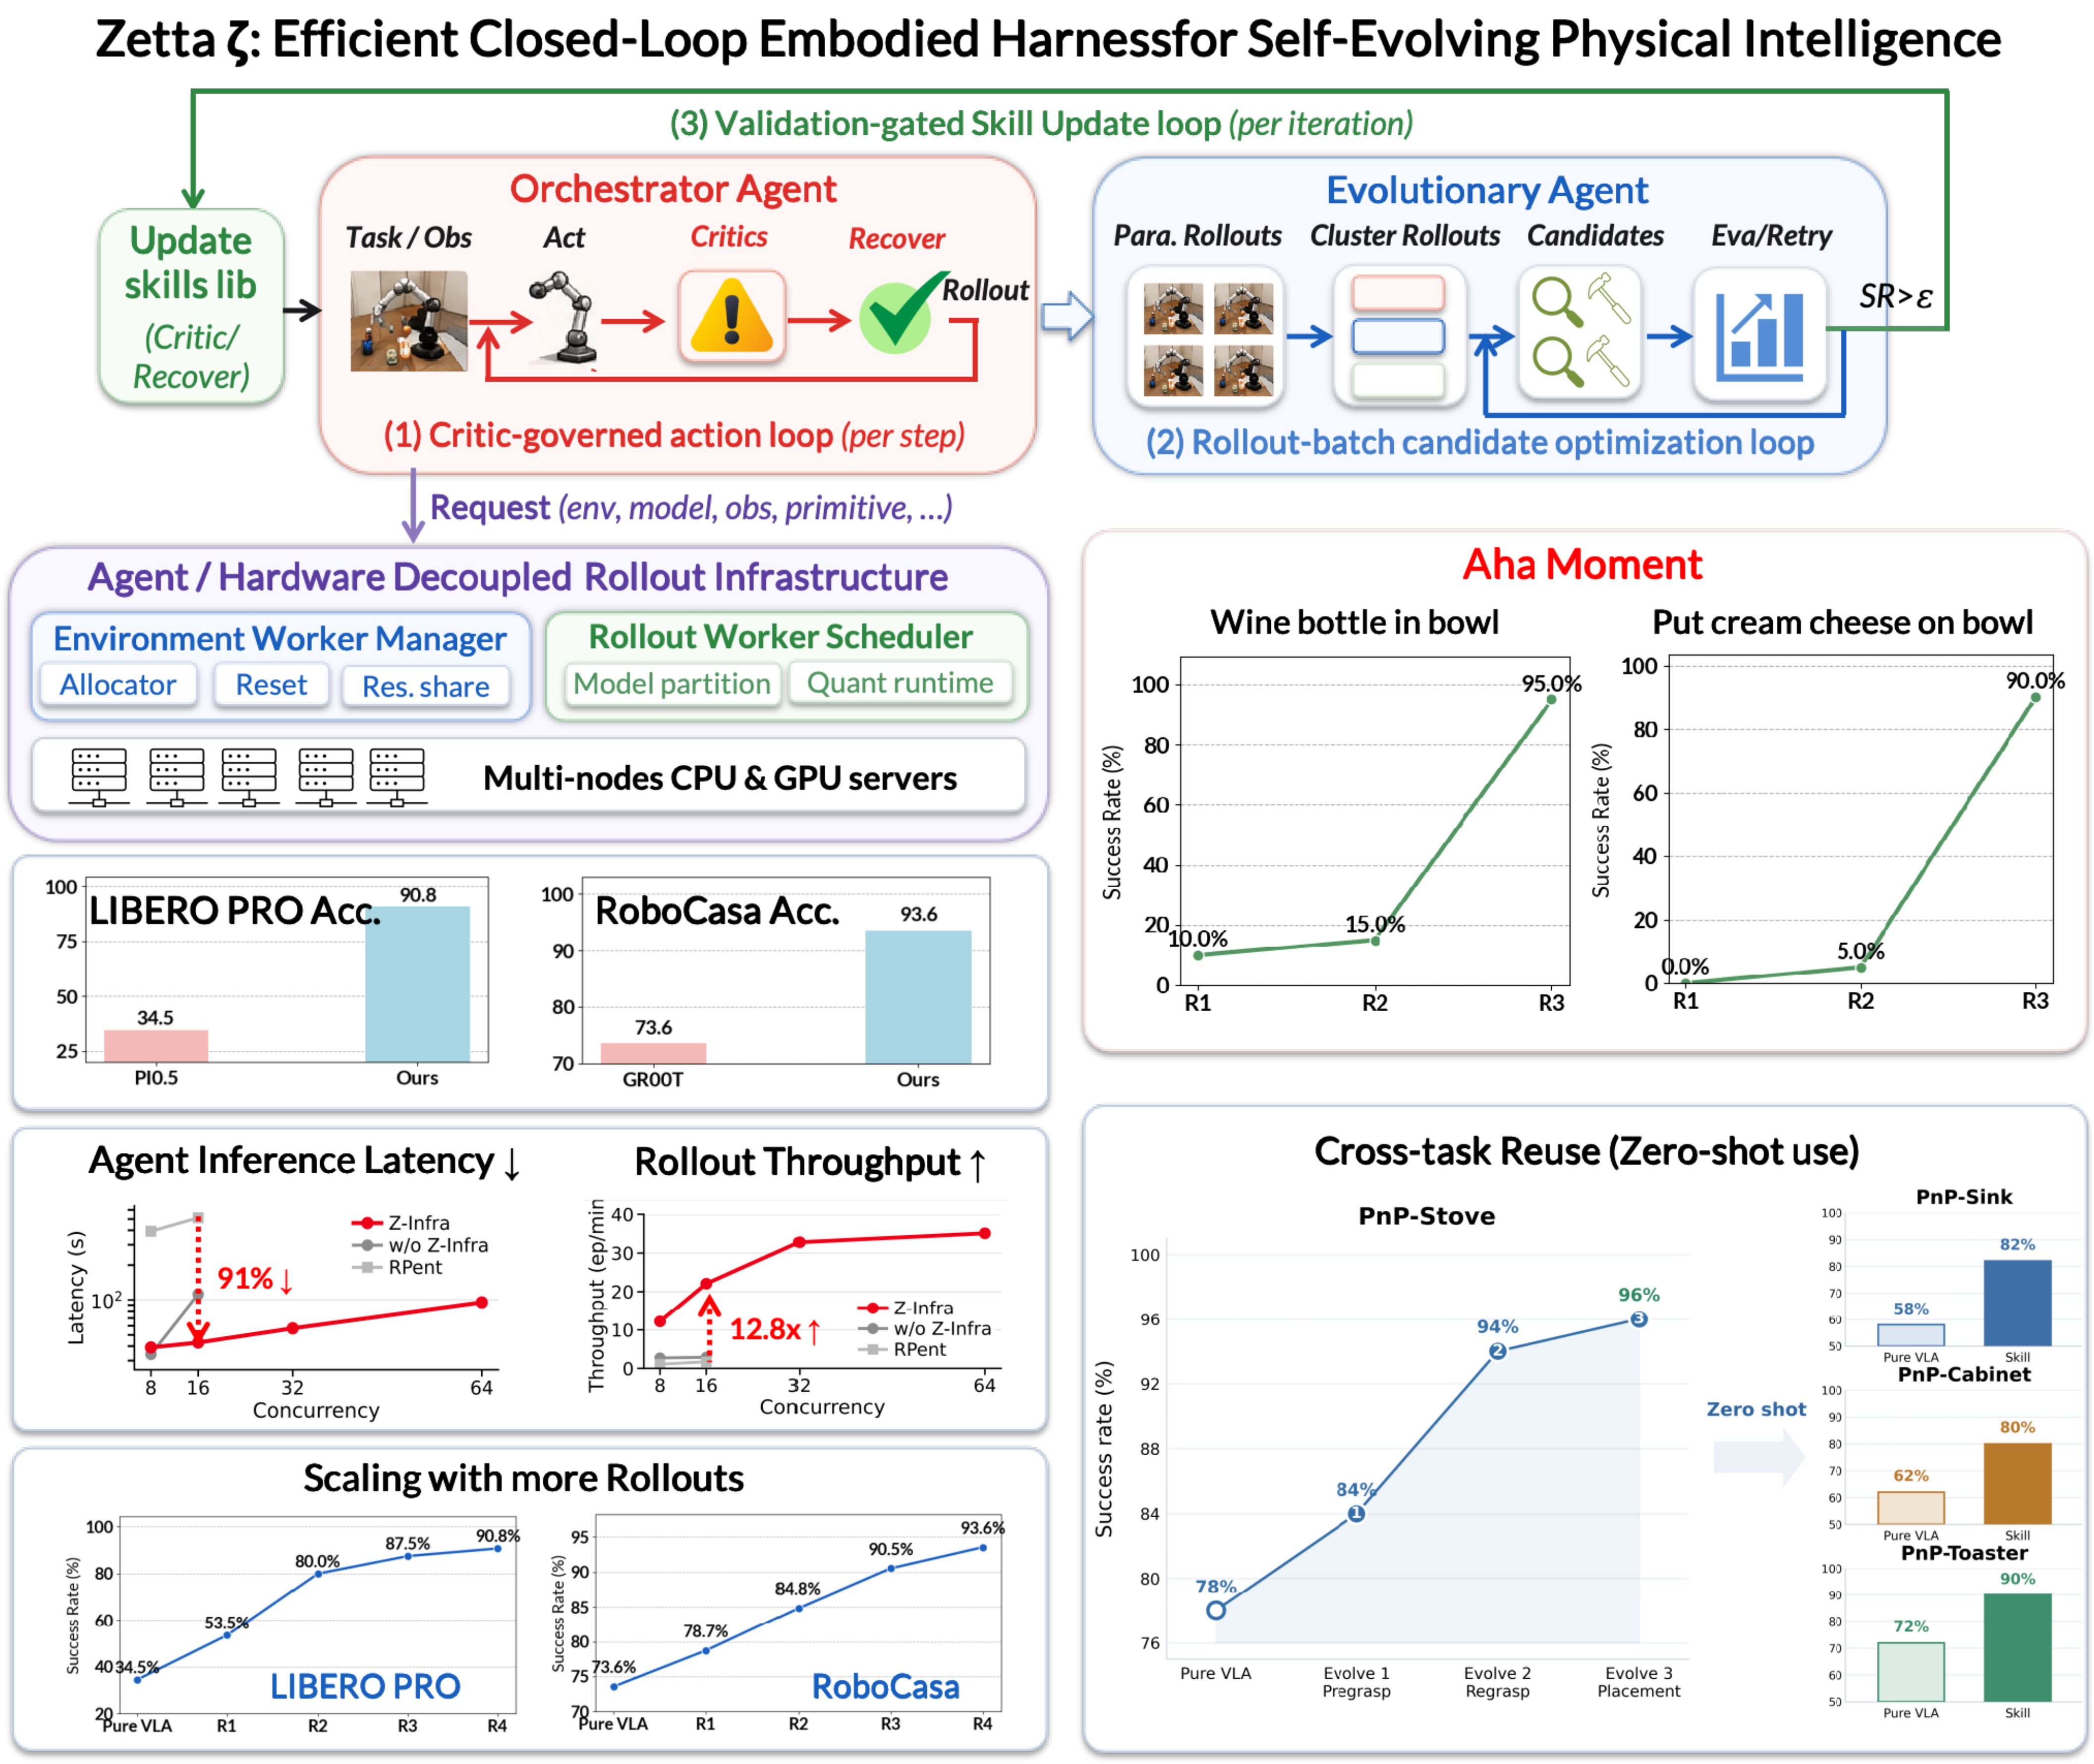
Zetta is a closed-loop embodied harness that evolves code-based runtime critics and recovery skills online while keeping the base robot policy frozen, reaching 90.8% success on LIBERO-Pro and 93.6% on RoboCasa with an 11.1x inference speedup.
- 4
Motus2
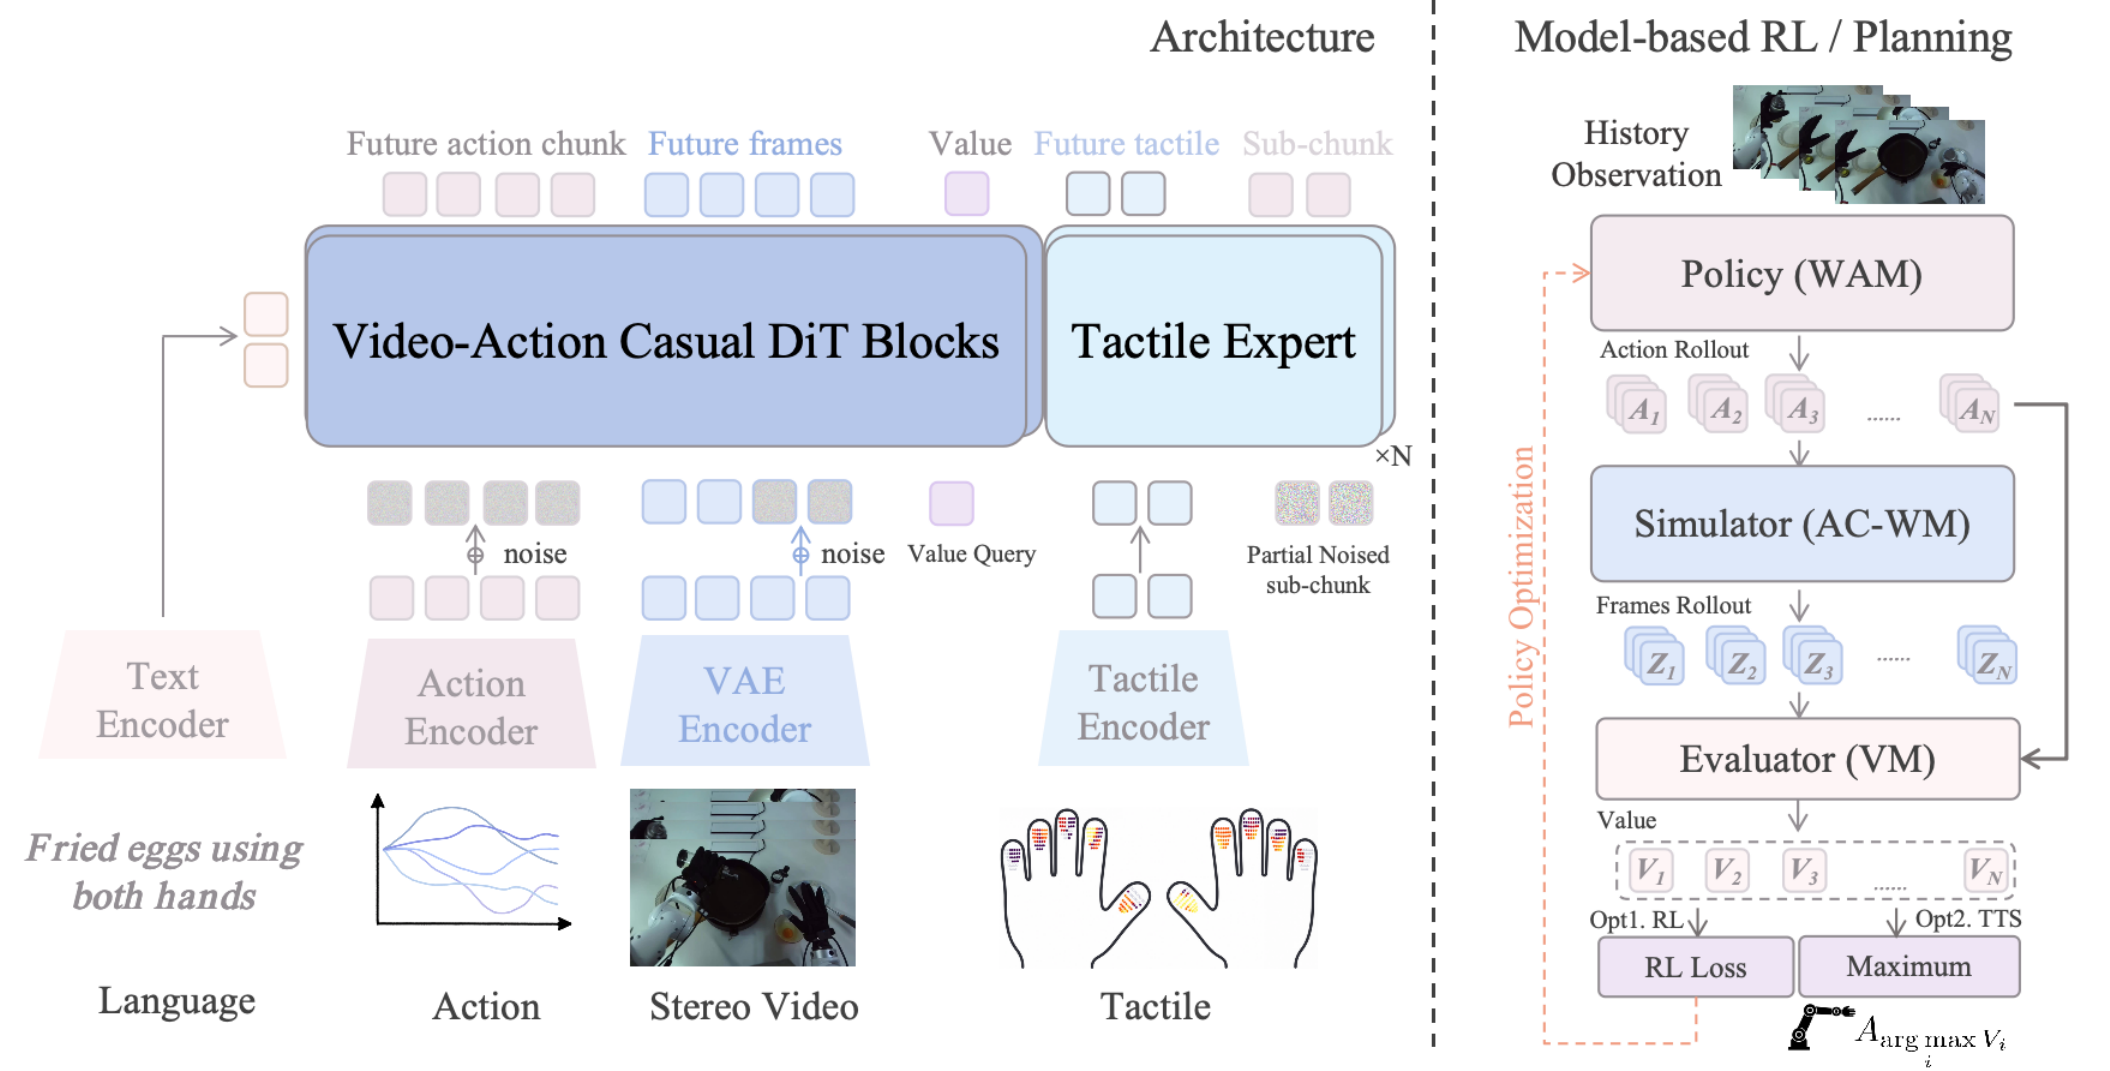
685shengshu-ai/Motus2Motus2 is a self-evolving general world model for dexterous robot manipulation. A single model with shared weights acts as a policy, a simulator, and an evaluator, coupling them into a closed decision-and-learning loop so the system can perceive, predict, act, and improve itself.
- 5
intrinsic-core
583intrinsic-ai/intrinsic-core · C++Intrinsic Core is an open, local runtime, SDK and hardware-agnostic real-time control framework for industrial robotics. It provides foundational building blocks for AI-enabled robot applications, from simulation and 6-DoF perception down to hardware execution.
- 6
hflow
298Hebbian-Robotics/hflow · PythonHFlow is an open source SDK from Hebbian Robotics (YC S26) for building scalable multimodal data pipelines for robotics and physical AI, letting teams verify the quality of the data they use to train AI models.
- 7

quackd
263rokbenko/quackd · Pythonquackd is an open-source daemon that gives small robots a brain: it takes a goal in plain language and plans the right sequence of the robot's own existing skills to carry it out, using an LLM like Claude, OpenAI, Gemini, Grok or a local model.
- 8
S-Space
174MirroS-Lab/S-Space · PythonS-Space is a research project that finds a three-dimensional linear subspace inside multimodal model activations which encodes object positions along horizontal, vertical, and distance axes, and shows it can be read out and even causally edited to change the model's spatial judgments.
Related topics
Often tagged together
- robotics88
- embodied-ai32
- python2,383
- apache-2.01,434
- gpu789
- linux4,184
- machine-learning916
- simulation89
- ai1,955
- deep-learning737
- research764
- benchmark431
- cli2,227
- computer-vision384
- docker1,660
- framework758
- open-source5,666
- reinforcement-learning149
- robot21
- academic-research209
- ai-agents1,289
- artificial-intelligence267
- cuda396
- dataset124