



4.4K ·GitHub
What is this?
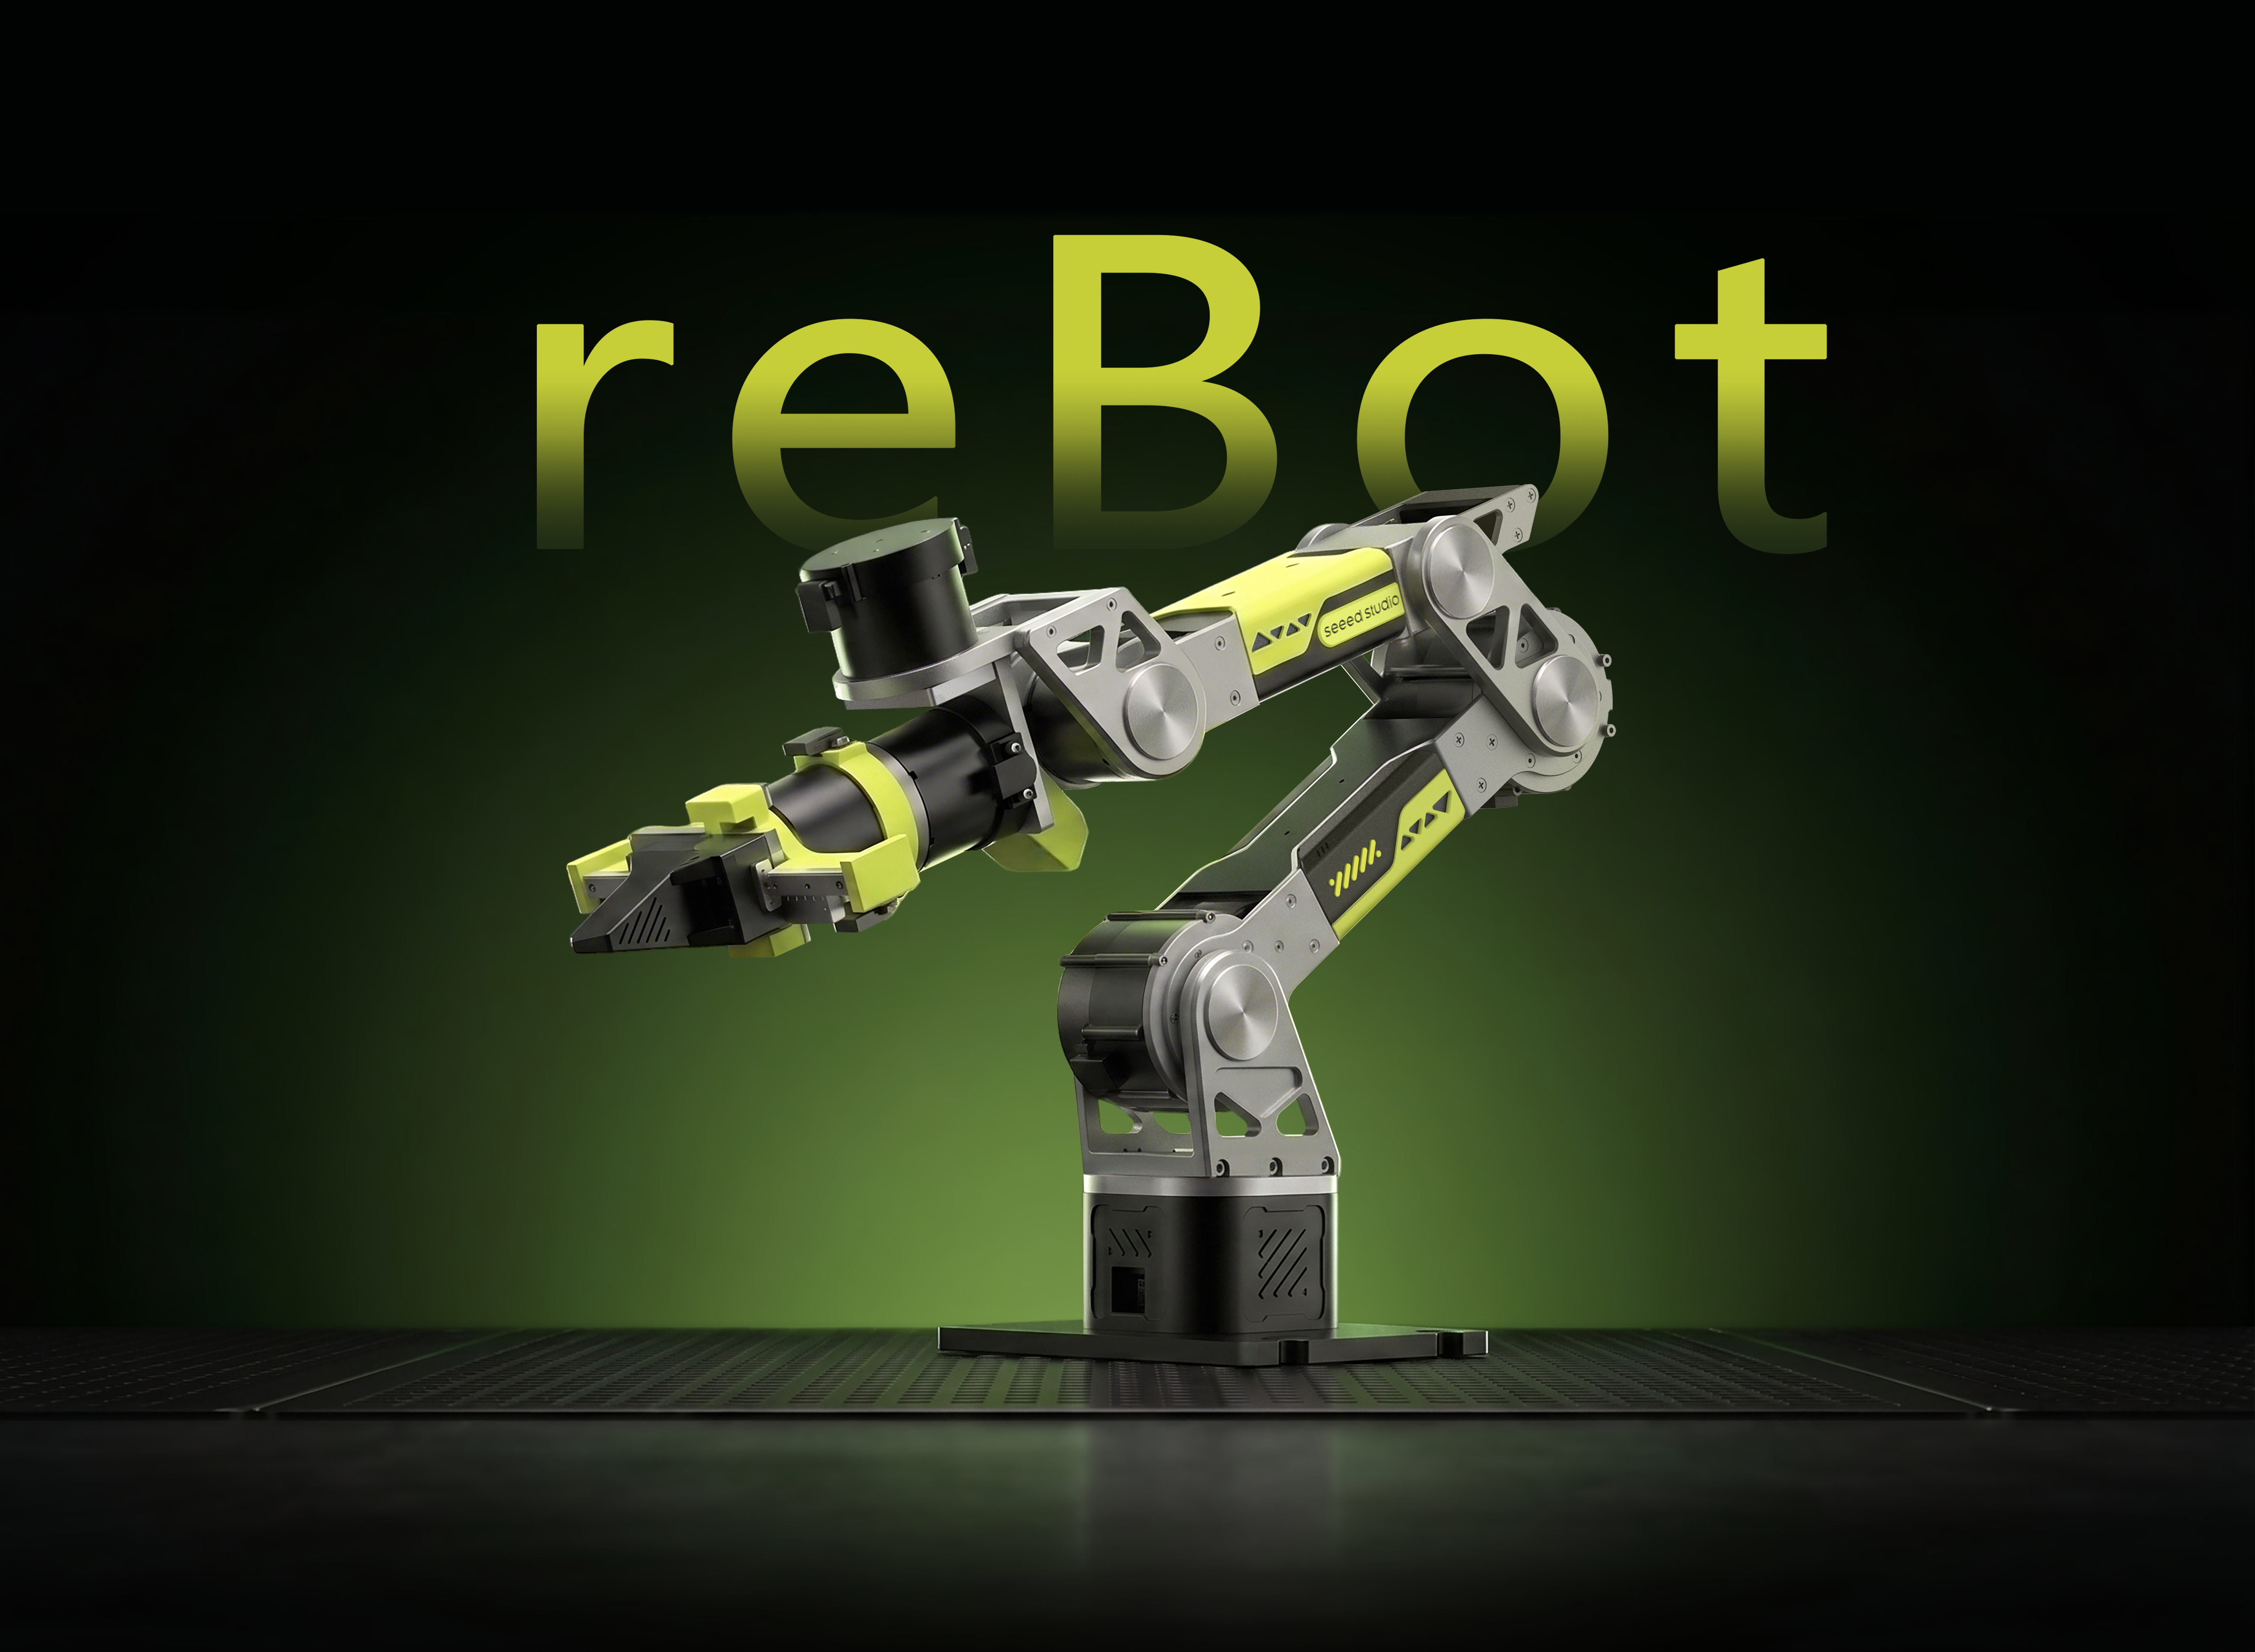
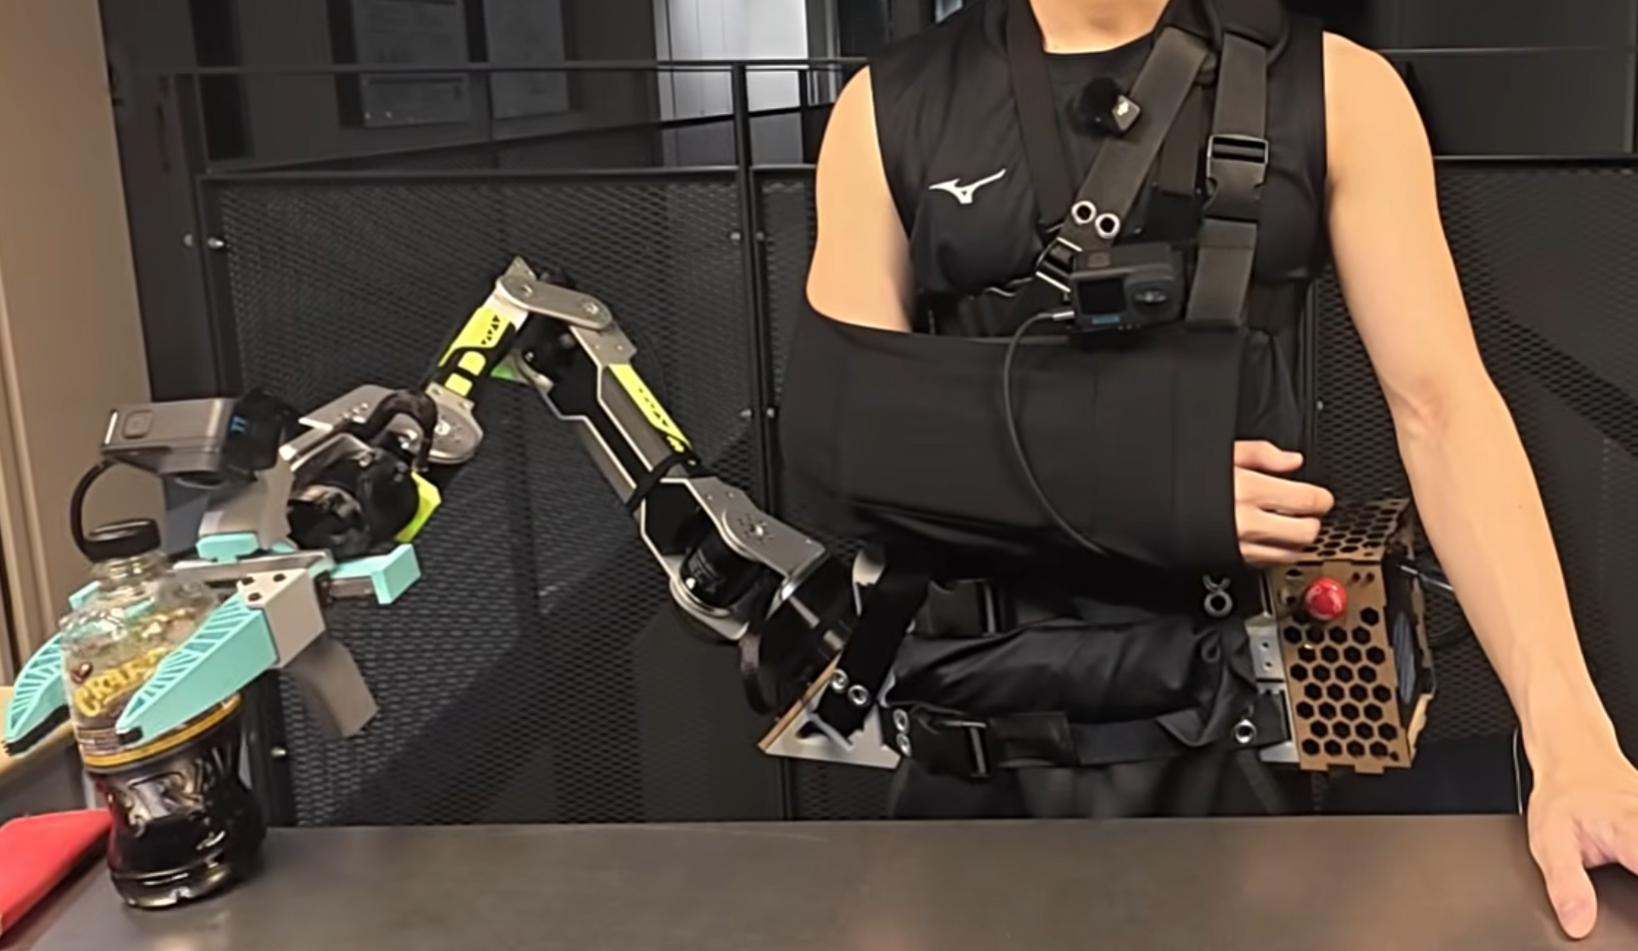
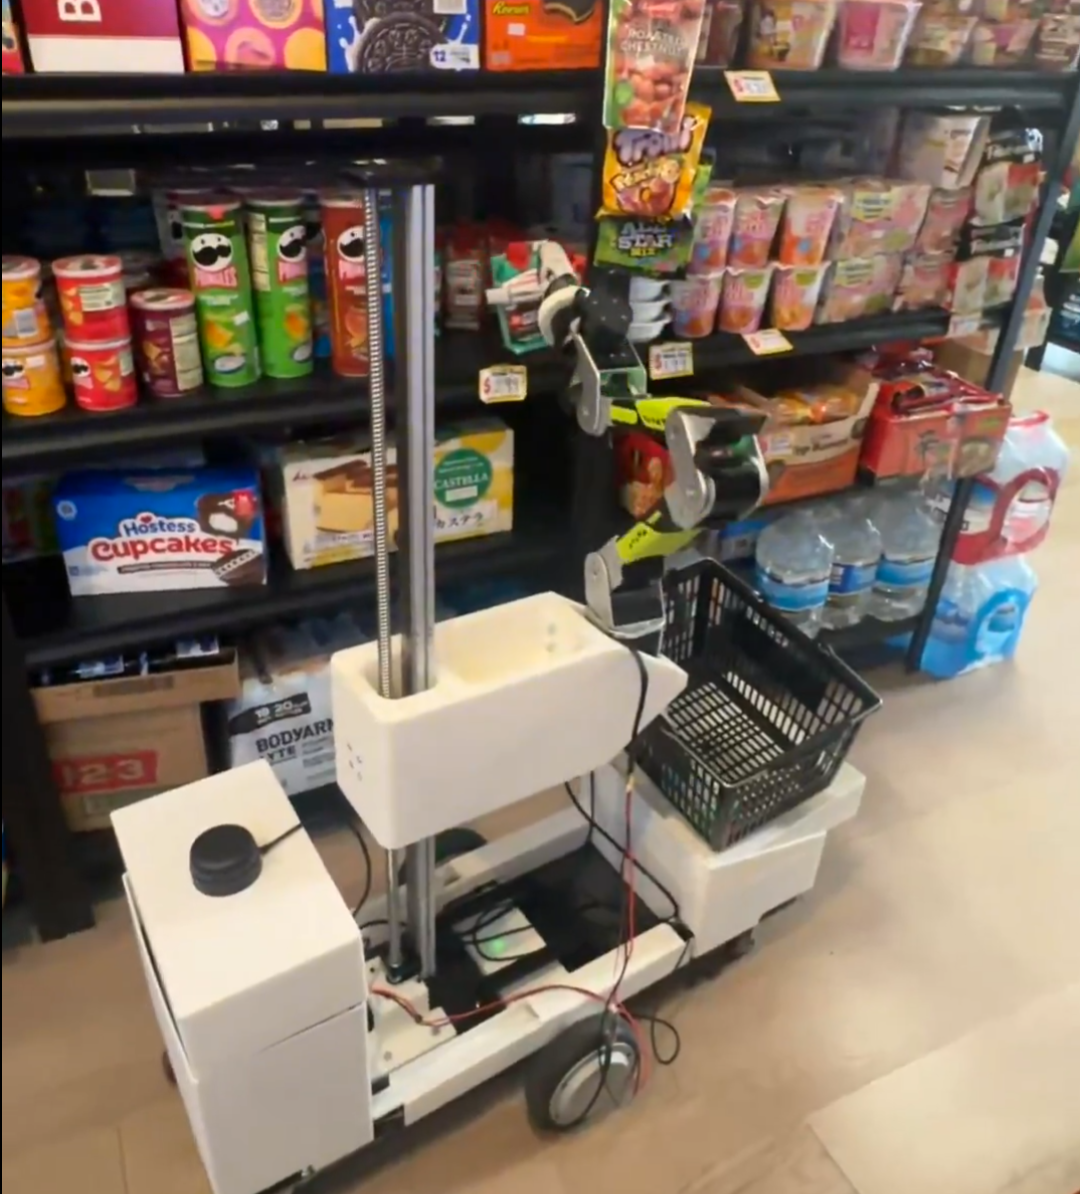
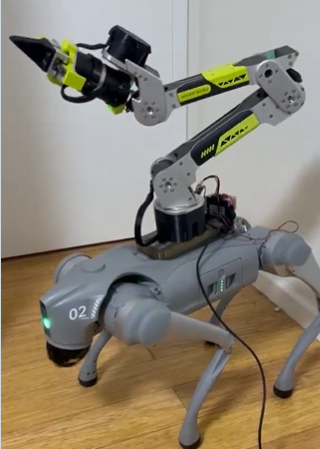
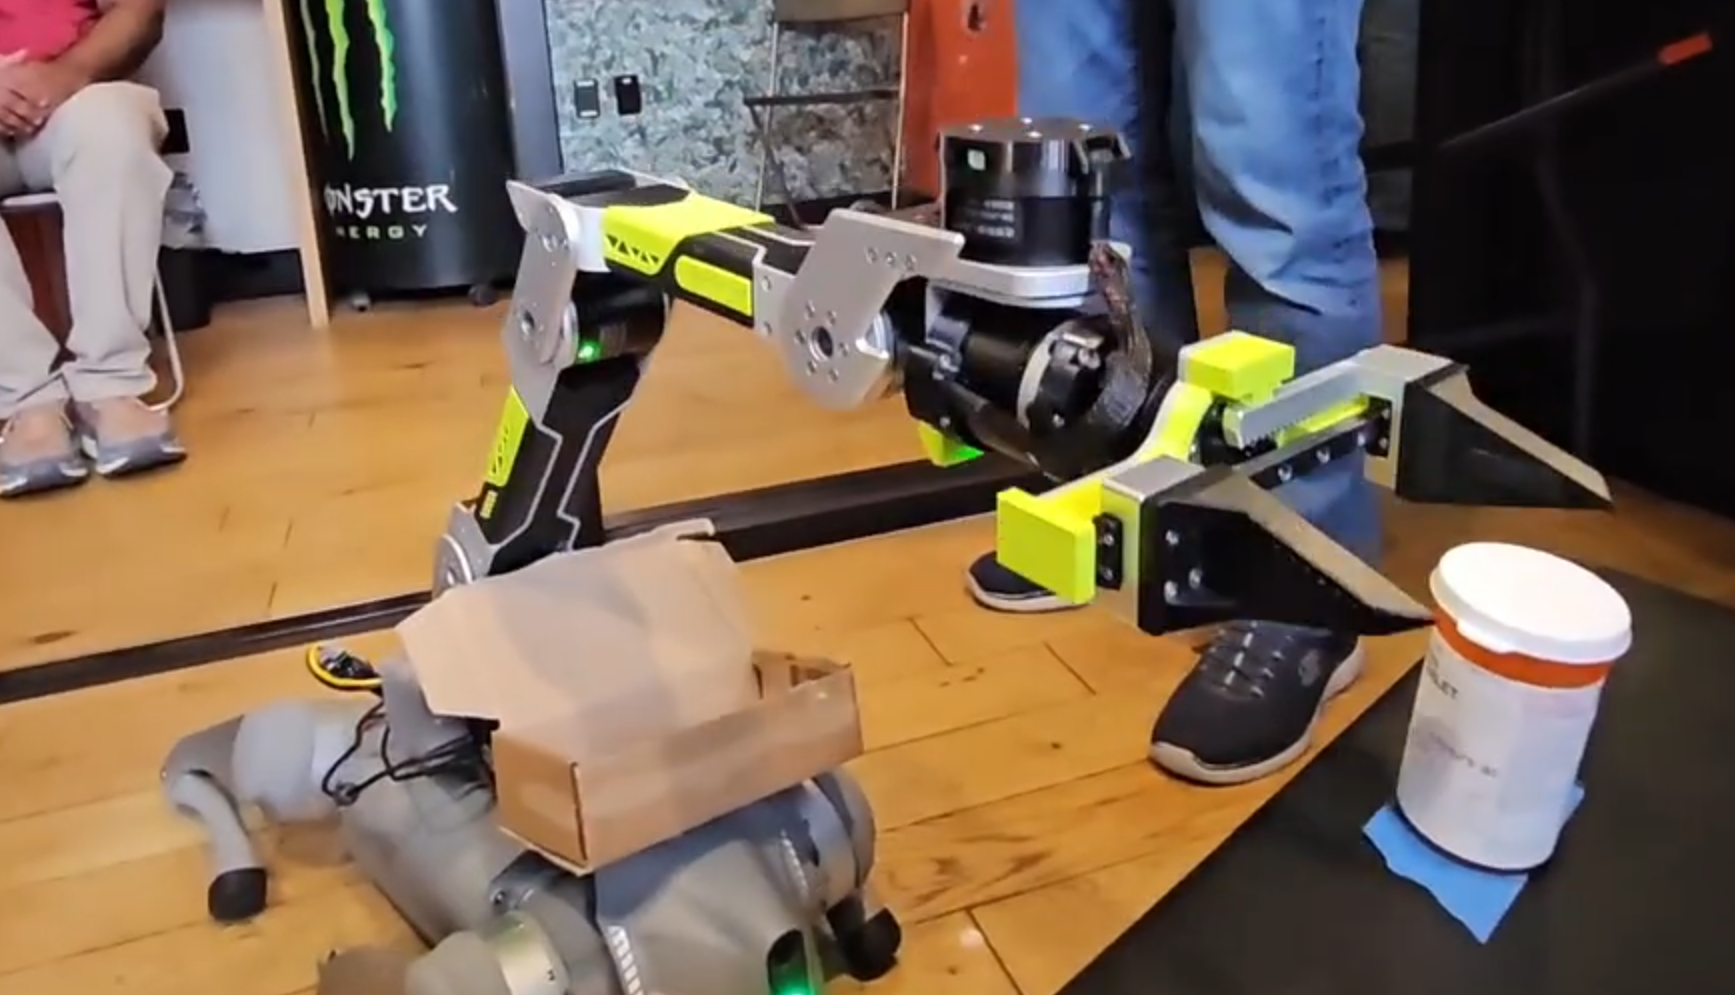
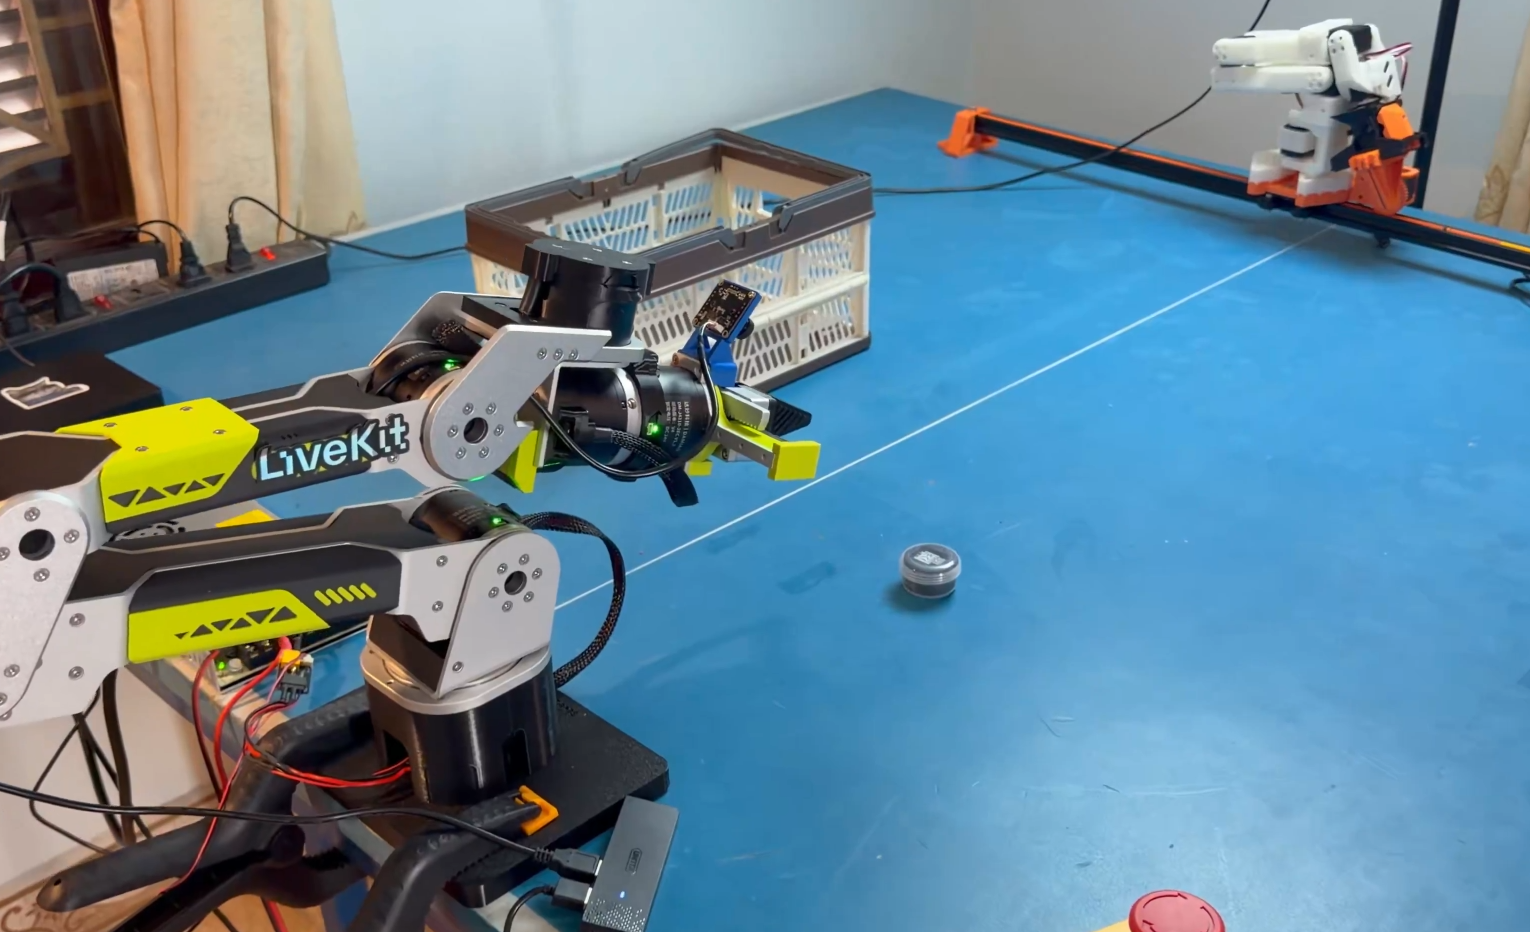
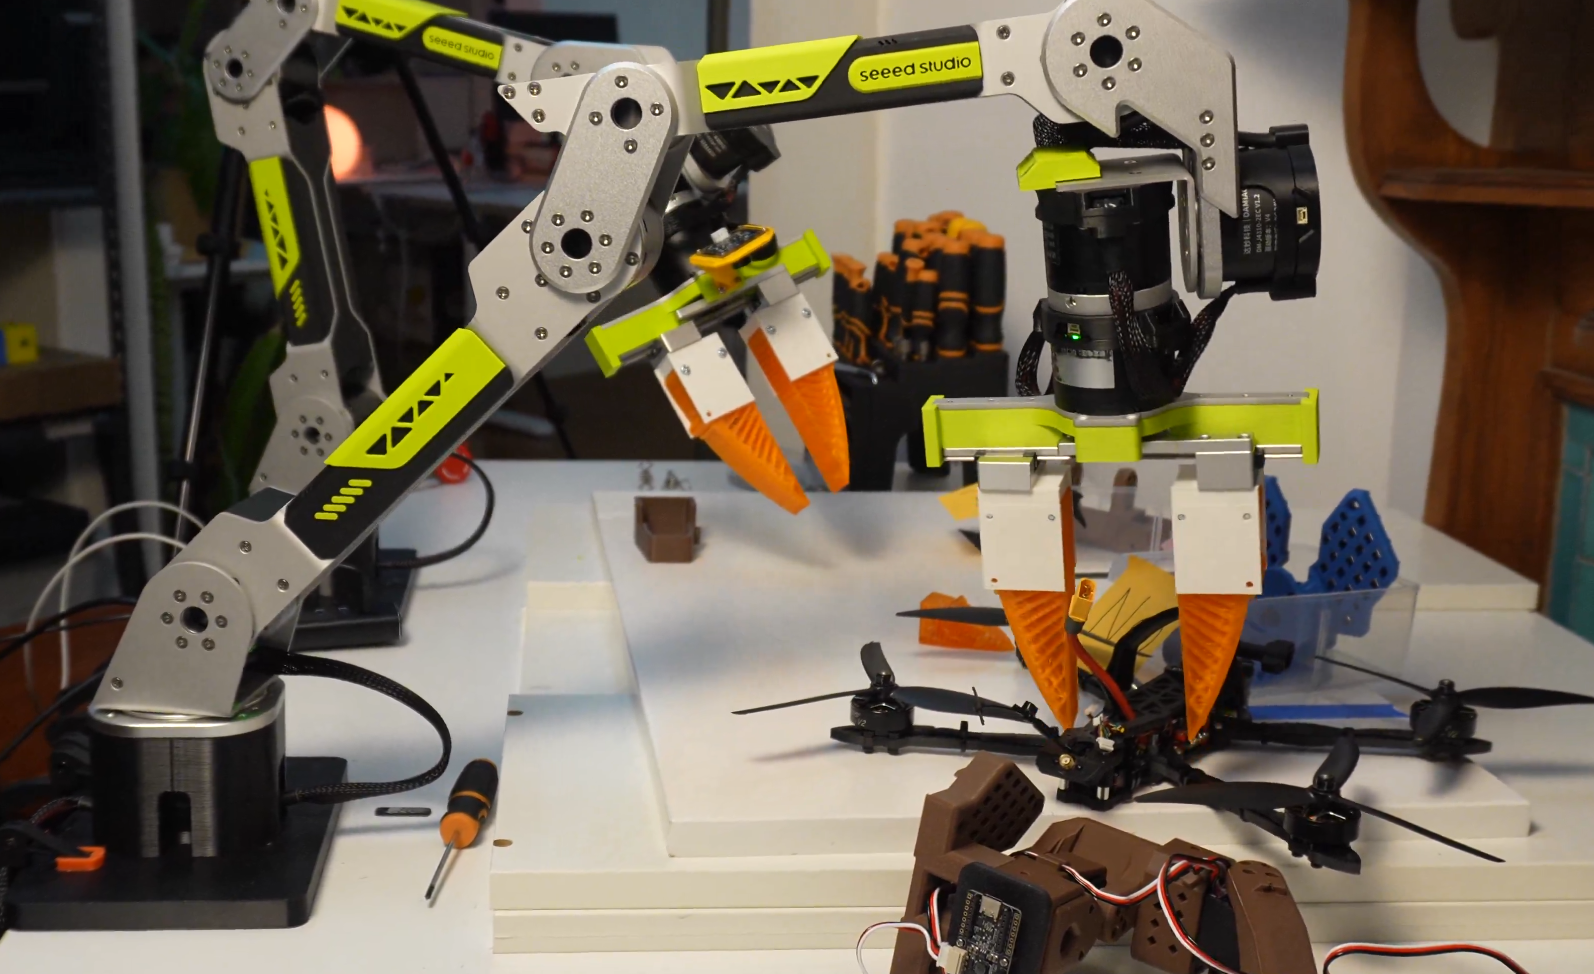
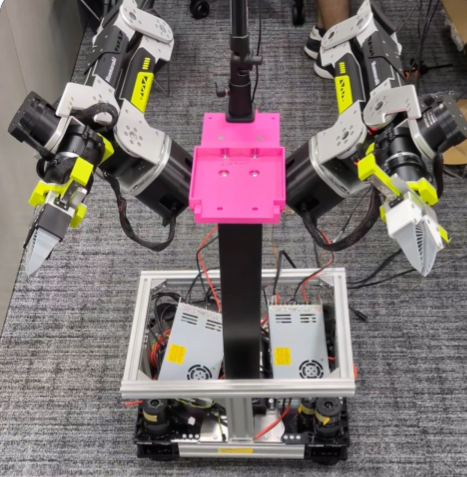
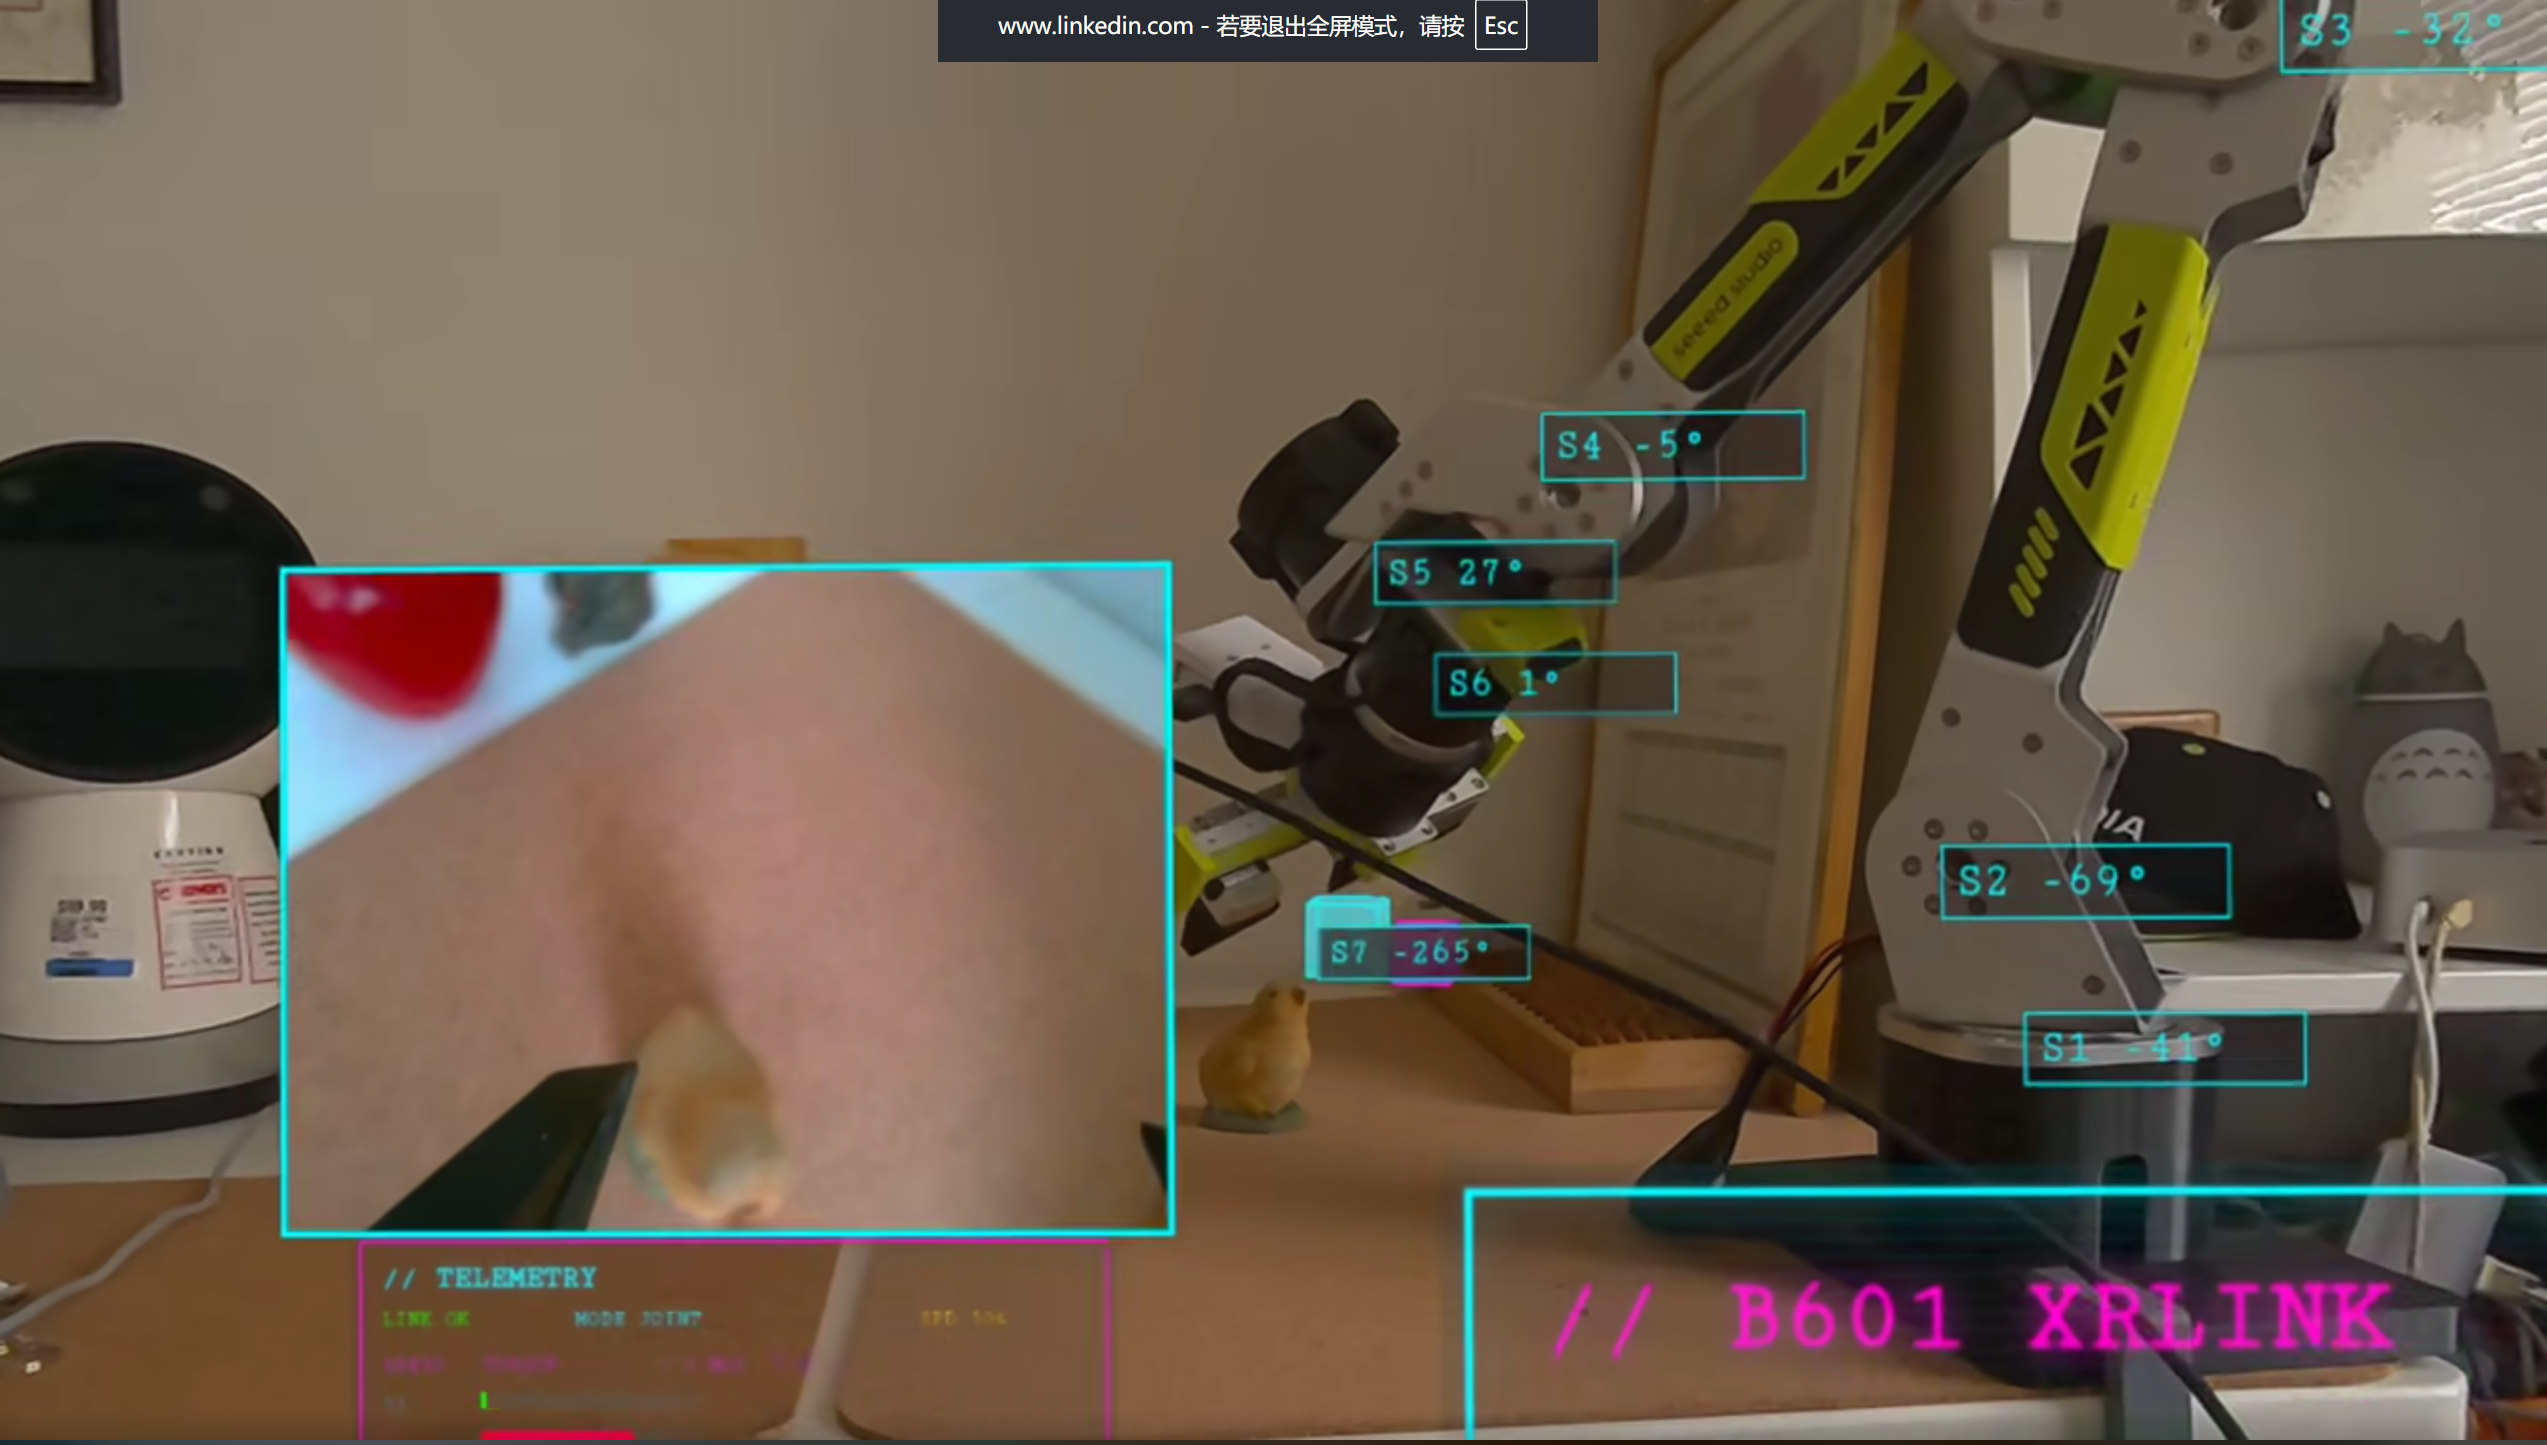
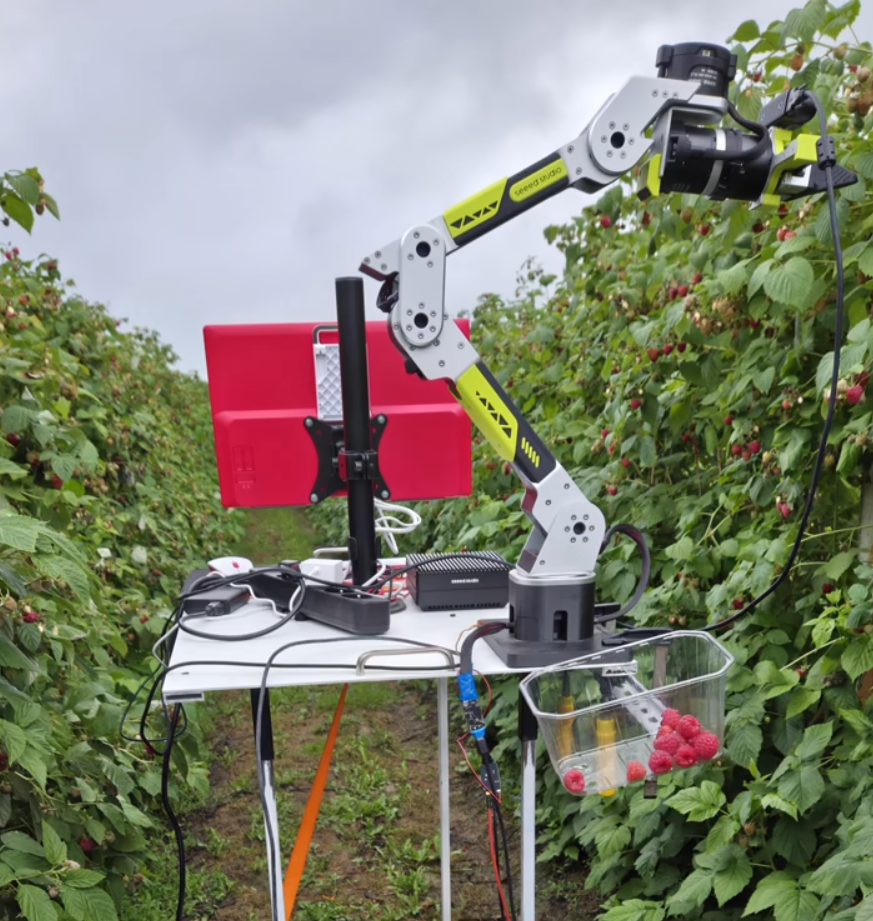
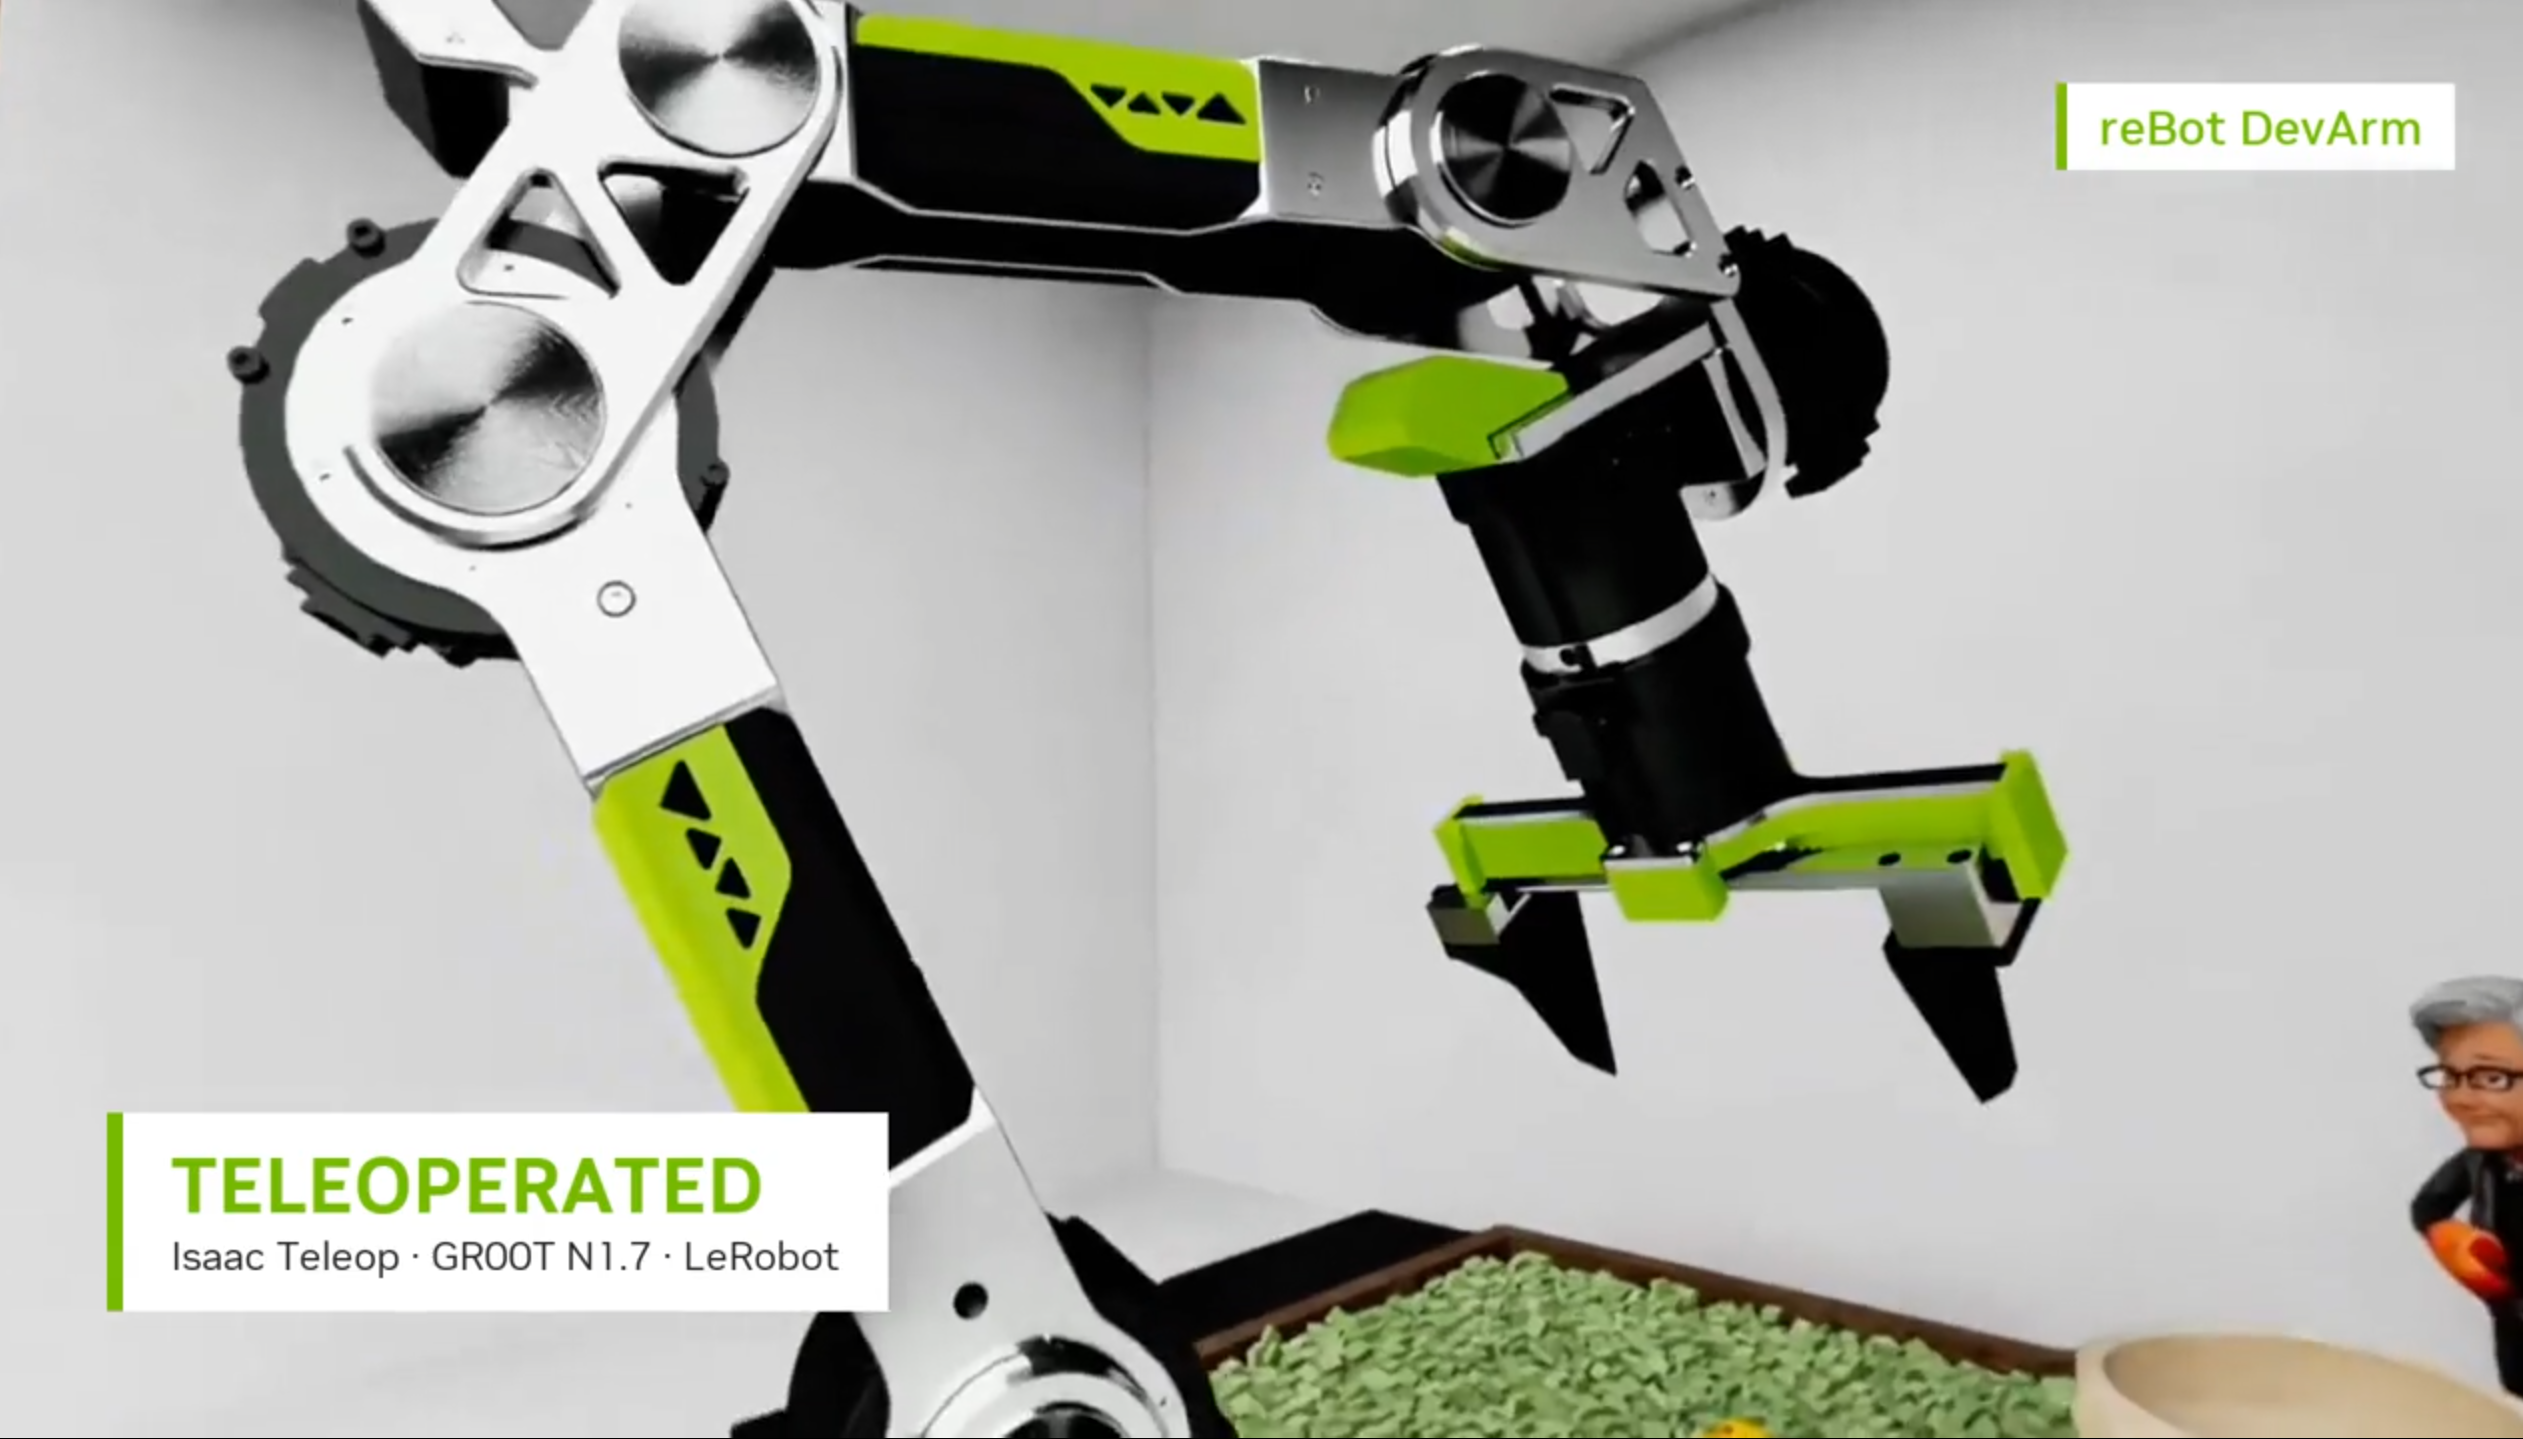
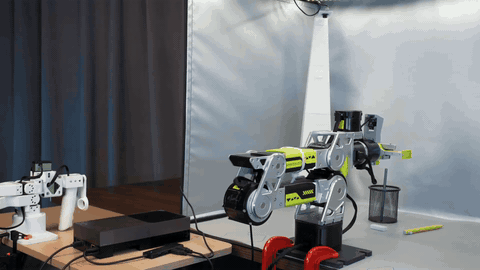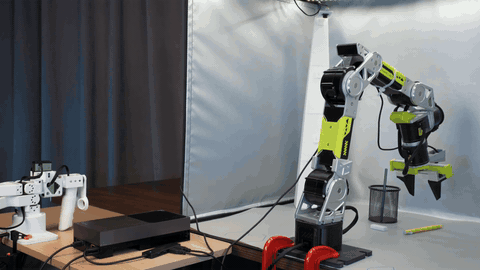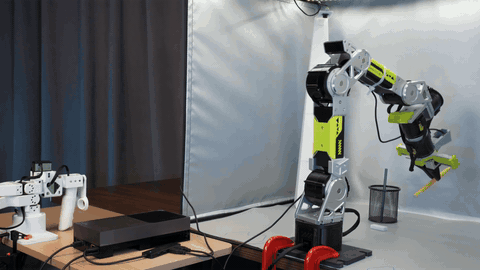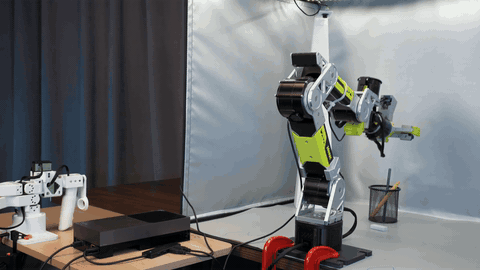
 reBot-DevArm is a fully open-source robotic arm project (B601-DM and B601-RS models) aimed at lowering the barrier to learning Embodied AI, with all hardware files, BOM, and software openly released.
Is this just software, or do I need to buy hardware too?It's a complete hardware+software stack: you need the physical robotic arm (buy a kit or pre-assembled unit from Seeedstudio/Amazon/Aliexpress, or 3D print/machine the parts yourself using the open BOM), plus the Python SDK, ROS integration, and simulation tools provided in the repo.
It's a complete hardware+software stack: you need the physical robotic arm (buy a kit or pre-assembled unit from Seeedstudio/Amazon/Aliexpress, or 3D print/machine the parts yourself using the open BOM), plus the Python SDK, ROS integration, and simulation tools provided in the repo.How do I get started with the arm?Buy or build one of five kit options (motor kit, structural kit, gripper kit, full kit, or pre-assembled arm) from Seeedstudio, then follow the model-specific Getting Started guide for assembly, basic motor control, and software integration (Python SDK, ROS2, LeRobot, etc.). You can also try the online MuJoCo simulation in your browser without any hardware.
Buy or build one of five kit options (motor kit, structural kit, gripper kit, full kit, or pre-assembled arm) from Seeedstudio, then follow the model-specific Getting Started guide for assembly, basic motor control, and software integration (Python SDK, ROS2, LeRobot, etc.). You can also try the online MuJoCo simulation in your browser without any hardware.What hardware do I actually need to buy to power this?You need the arm kit itself plus a separate power supply (not included by default): a 12V 10A supply for the DM/Leader version, or a recommended Meanwell 48V 12.5A (or 48V 25A for full performance) supply for the RS model.
You need the arm kit itself plus a separate power supply (not included by default): a 12V 10A supply for the DM/Leader version, or a recommended Meanwell 48V 12.5A (or 48V 25A for full performance) supply for the RS model.Is everything on the roadmap finished already?Most core features (basic motor control, ROS2, Pinocchio, LeRobot, depth-camera grasping, voice control) are marked complete, but items like Isaac Sim simulation for the DM model are still in progress, and planned free courses/ongoing algorithm updates are not yet released.
Most core features (basic motor control, ROS2, Pinocchio, LeRobot, depth-camera grasping, voice control) are marked complete, but items like Isaac Sim simulation for the DM model are still in progress, and planned free courses/ongoing algorithm updates are not yet released.Who is this aimed at?It targets developers, roboticists, and learners who want to study or deploy Embodied AI with a real, fully open desktop robotic arm rather than a closed commercial platform.
It targets developers, roboticists, and learners who want to study or deploy Embodied AI with a real, fully open desktop robotic arm rather than a closed commercial platform.Does this run on specific operating systems or robot frameworks?The software stack targets Linux-based robotics environments via ROS1/ROS2, Isaac Sim, Pinocchio, and Hugging Face's LeRobot, with a Python SDK for motor control; the online simulator runs in Chrome or Edge in any browser.
The software stack targets Linux-based robotics environments via ROS1/ROS2, Isaac Sim, Pinocchio, and Hugging Face's LeRobot, with a Python SDK for motor control; the online simulator runs in Chrome or Edge in any browser.What's the difference between the DM and RS arm versions?Both share the same appearance but use different motor brands (Damiao vs Robstride); the DM model has a 1.5kg payload and 767mm reach, while the RS model has a stronger 2.5kg payload, 754mm reach, and supports an embodied agent that executes natural-language pick commands.
Both share the same appearance but use different motor brands (Damiao vs Robstride); the DM model has a 1.5kg payload and 767mm reach, while the RS model has a stronger 2.5kg payload, 754mm reach, and supports an embodied agent that executes natural-language pick commands.Can the arm understand voice or natural-language commands?Yes, it integrates a reSpeaker Flex 4-mic array for voice-driven control, and the B601-RS has an Embodied Agent Architecture that accepts natural-language commands like 'pick up the red block' and automatically plans the grasp.
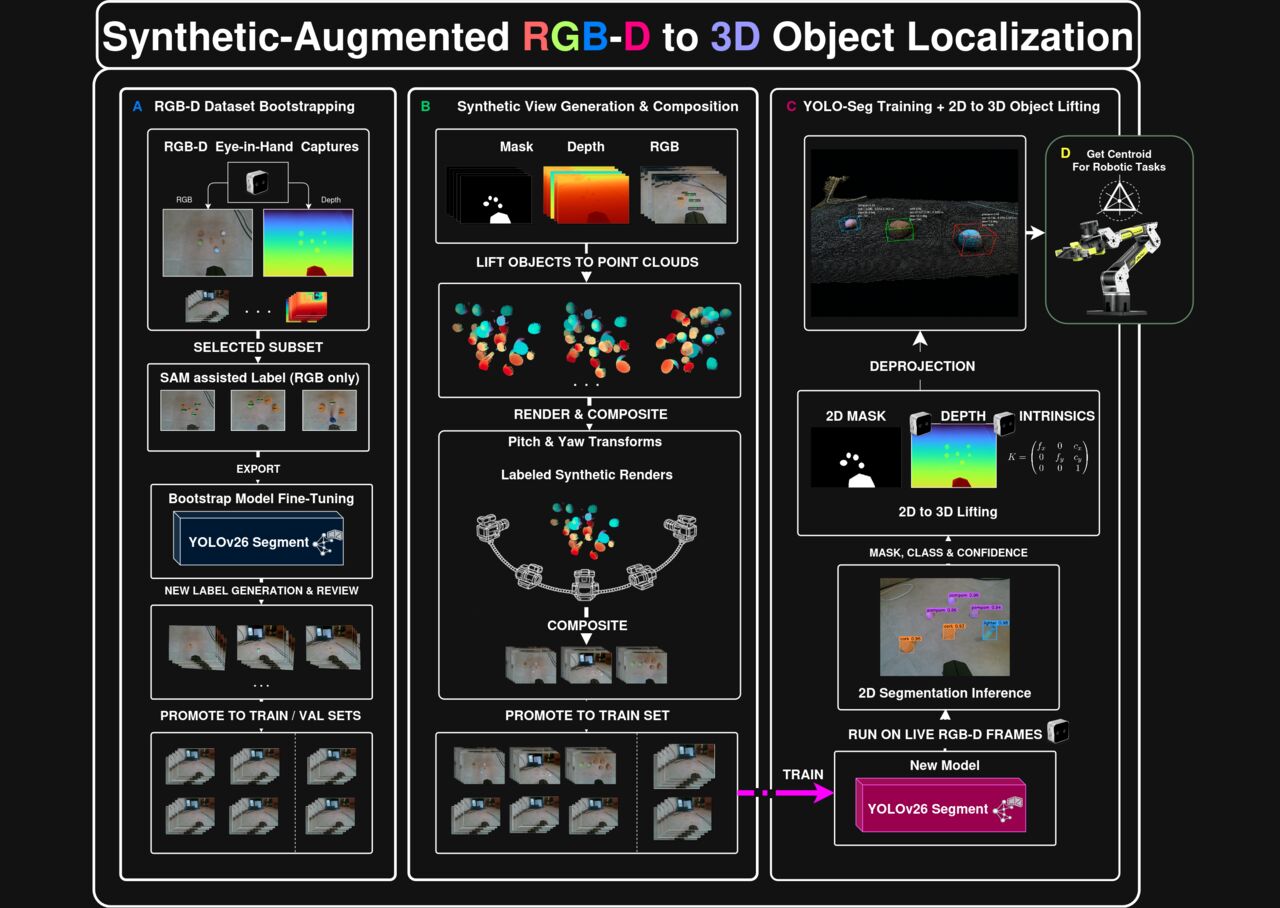
Yes, it integrates a reSpeaker Flex 4-mic array for voice-driven control, and the B601-RS has an Embodied Agent Architecture that accepts natural-language commands like 'pick up the red block' and automatically plans the grasp.Does it support visual grasping?Yes, it includes a visual grasping demo combining YOLO object detection with depth cameras (D435i, D405, Gemini) for perception-based pick-and-place.
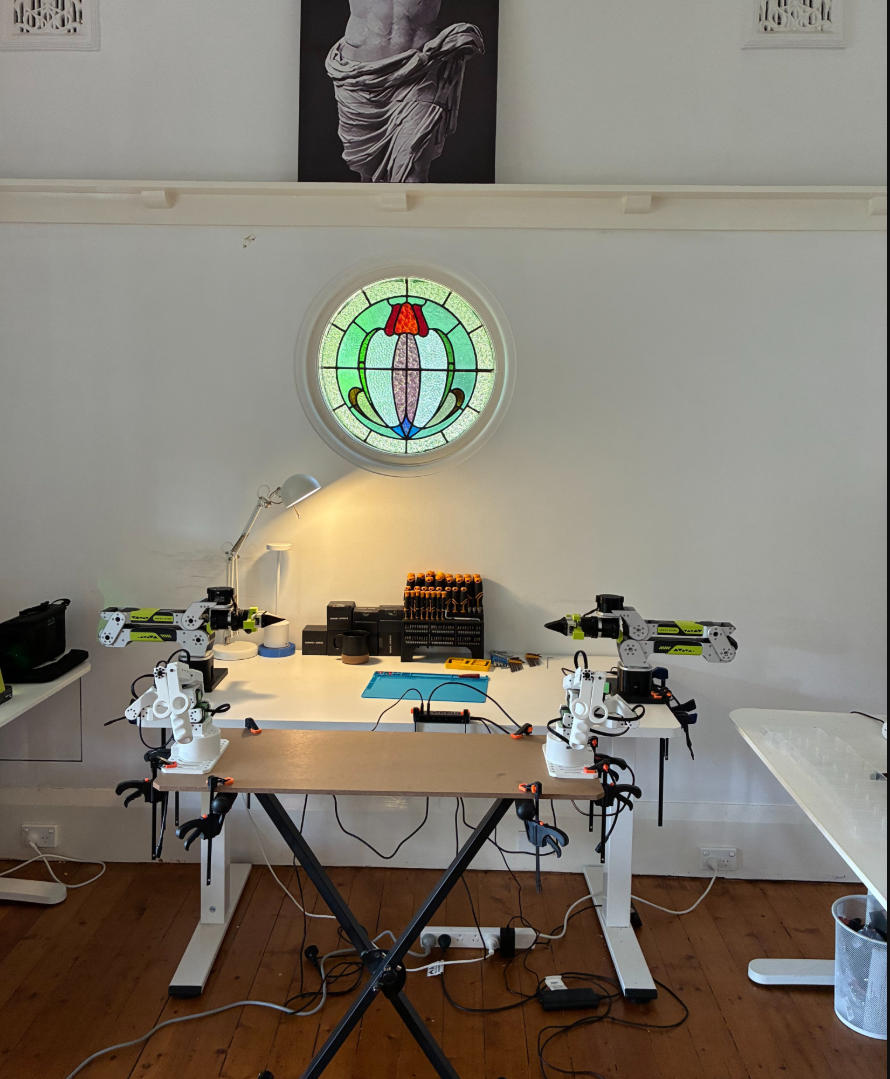
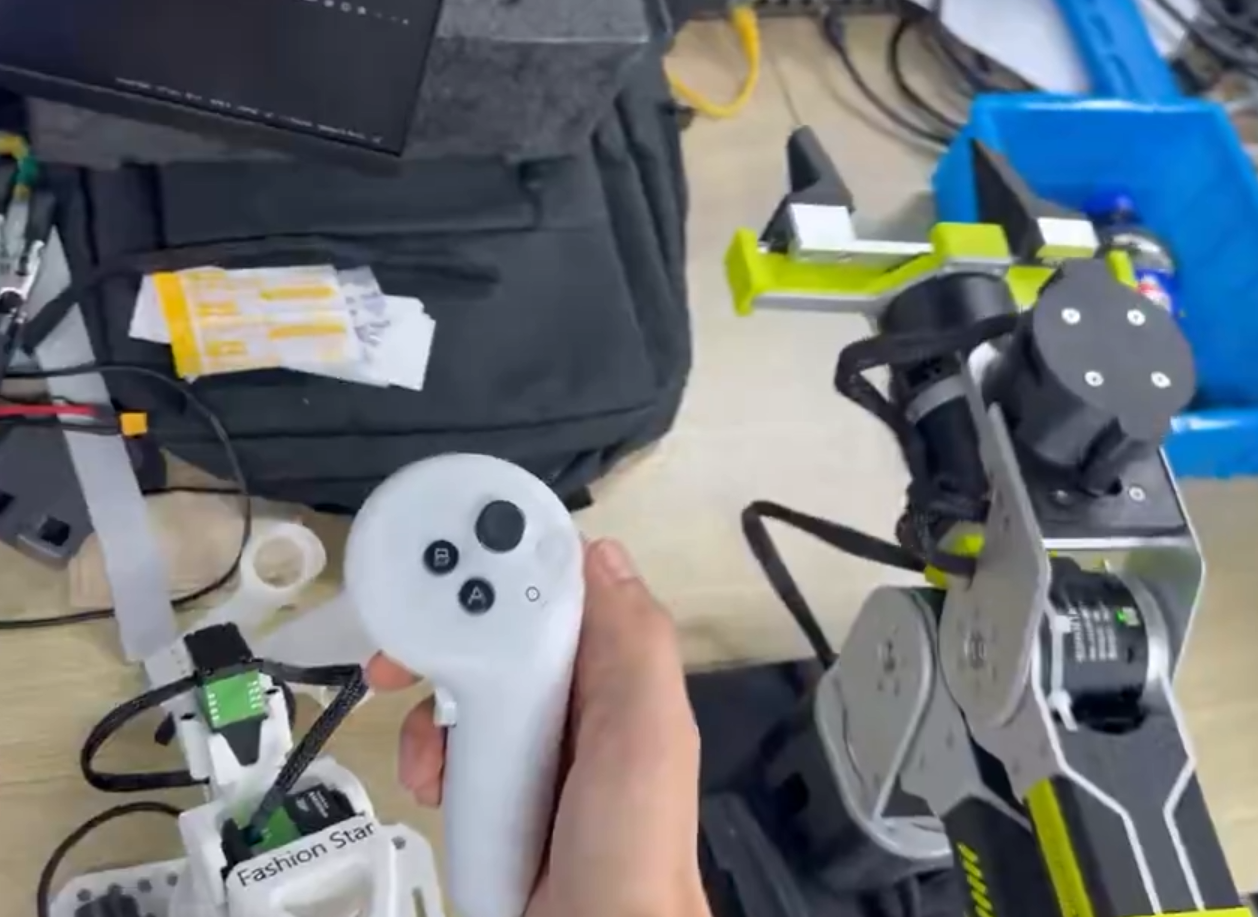
Yes, it includes a visual grasping demo combining YOLO object detection with depth cameras (D435i, D405, Gemini) for perception-based pick-and-place.Can I control a leader/follower teleoperation setup?Yes, the arm is compatible with a Leader Arm (Star Arm 102-LD) for teleoperation, and supports gamepad-based IK/FK teleop via community ROS2 contributions.
Yes, the arm is compatible with a Leader Arm (Star Arm 102-LD) for teleoperation, and supports gamepad-based IK/FK teleop via community ROS2 contributions.What are similar projects?FluxVLA, intrinsic-core, LightNav-0, carla, Embodied-AI-Guide, jumper, ZDTaichu5.0-9B, RoboHarness
FluxVLA, intrinsic-core, LightNav-0, carla, Embodied-AI-Guide, jumper, ZDTaichu5.0-9B, RoboHarnessWhich topics is it in?ros, yolo, 3d-printing, embodied-ai, voice, object-detection, robotics, simulation, iot, hardware, gaming, huggingface
ros, yolo, 3d-printing, embodied-ai, voice, object-detection, robotics, simulation, iot, hardware, gaming, huggingface