Topics / #robotics
Robotics projects on GitHub
Programming robots: control, perception, and simulation.
As of , the most-starred Robotics projects on GitHub are cs-video-courses (83.7K stars), awesome-cpp (73.9K stars) and openpilot (63.9K stars). GitHub.Locker tracks 88 Robotics repositories with 956K stars combined. The fastest-growing on October 16 was text-to-cad, with +292 stars in a day.
Hot right now
Most stars gained in a day · Oct 16
 +292
text-to-cad
earthtojake/text-to-cad · ★ 21.3Ktext-to-cad is a library of agent skills for CAD, CAE and CAM: it gives coding agents focused workflows to generate, inspect, source, slice, and hand off CAD and robot-description artifacts from your local project files.
 +134
ai-agent-book
bojieli/ai-agent-book · ★ 54.7KAn open-source book by Li Bojie taking AI agents from design principles to engineering practice, built on the formula Agent = LLM + context + tools; text, figures and labs all live in this repo.
 +97
oomwoo
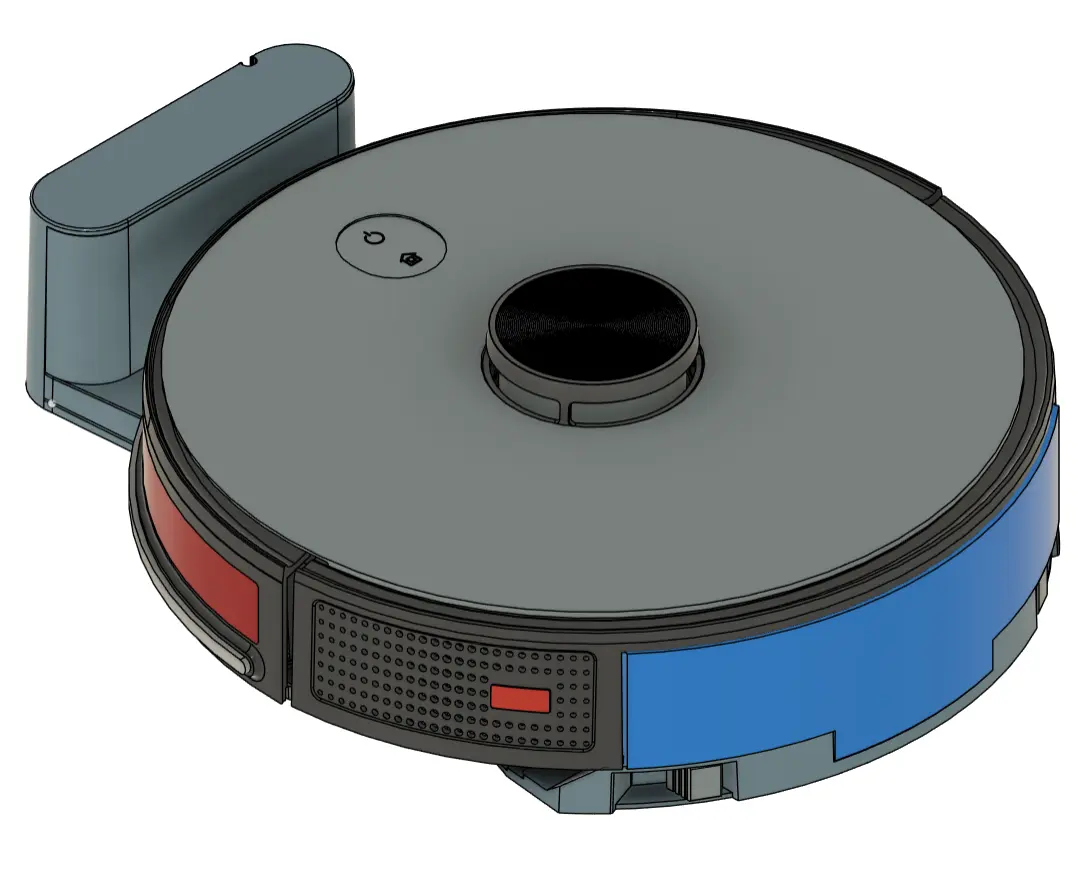
makerspet/oomwoo · ★ 12KOOMWOO is an open-source home vacuum robot you build yourself, using a Raspberry Pi, 3D-printed parts, Home Assistant, Arduino and ROS2, navigating with an affordable 2D LiDAR.
microduck
pollen-robotics/microduck · ★ 9.5KMicroduck is a tiny biped duck robot (about 25cm, 800g), and this repo is the robot's brain: Rust daemons that run a 50Hz control loop driving fifteen servos using reinforcement-learning policies exported to ONNX.
The all-time top
88 projects · by stars
- 83.7K
 #1 · Developer-Y/cs-video-courses
cs-video-courses
A curated list of university-level Computer Science courses that have publicly available video lectures, covering topics from intro programming to machine learning, security, robotics, and more.
- 73.9K
 #2 · fffaraz/awesome-cpp
awesome-cpp
A curated list (awesome-list) of C and C++ frameworks, libraries, tools, and resources, organized by category like AI, audio, networking, GUI, databases, and more.
- 63.9K
 #3 · commaai/openpilot
openpilot
openpilot is an operating system for robotics that currently powers the driver assistance system in over 300 supported cars.
- 4
ai-agent-book
54.7Kbojieli/ai-agent-book · PythonAn open-source book by Li Bojie taking AI agents from design principles to engineering practice, built on the formula Agent = LLM + context + tools; text, figures and labs all live in this repo.
- 5
EasySpider
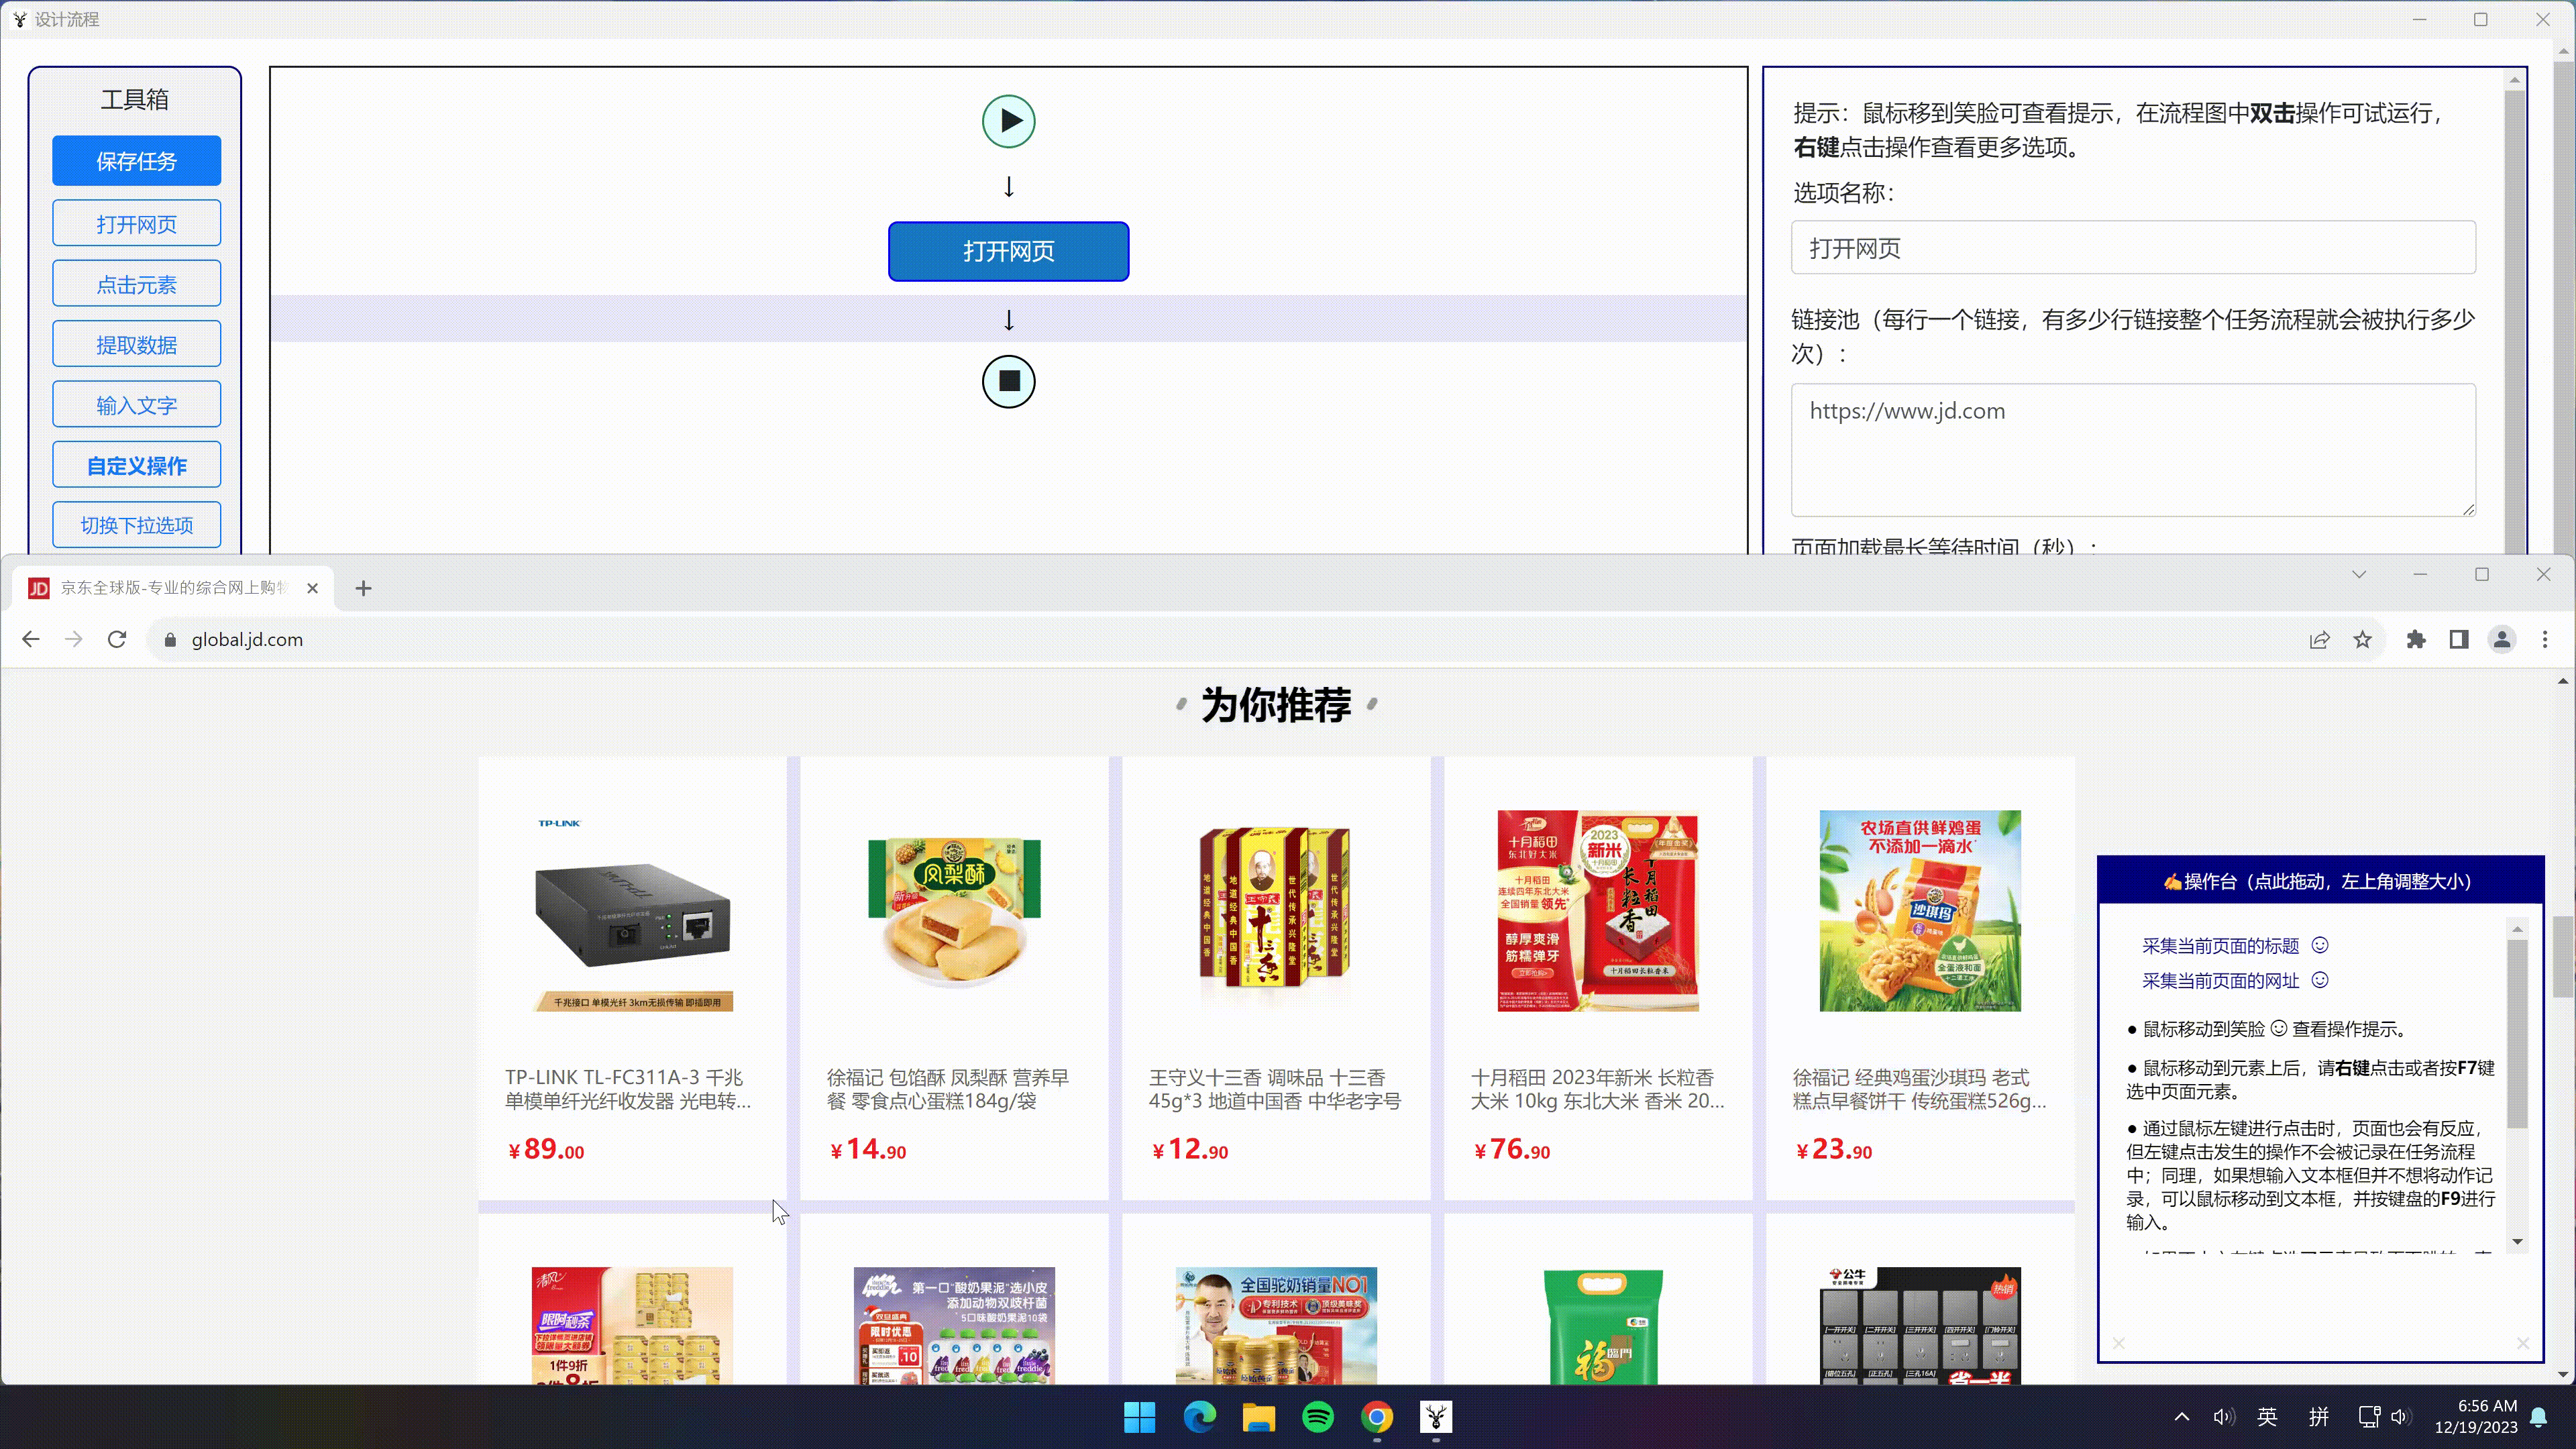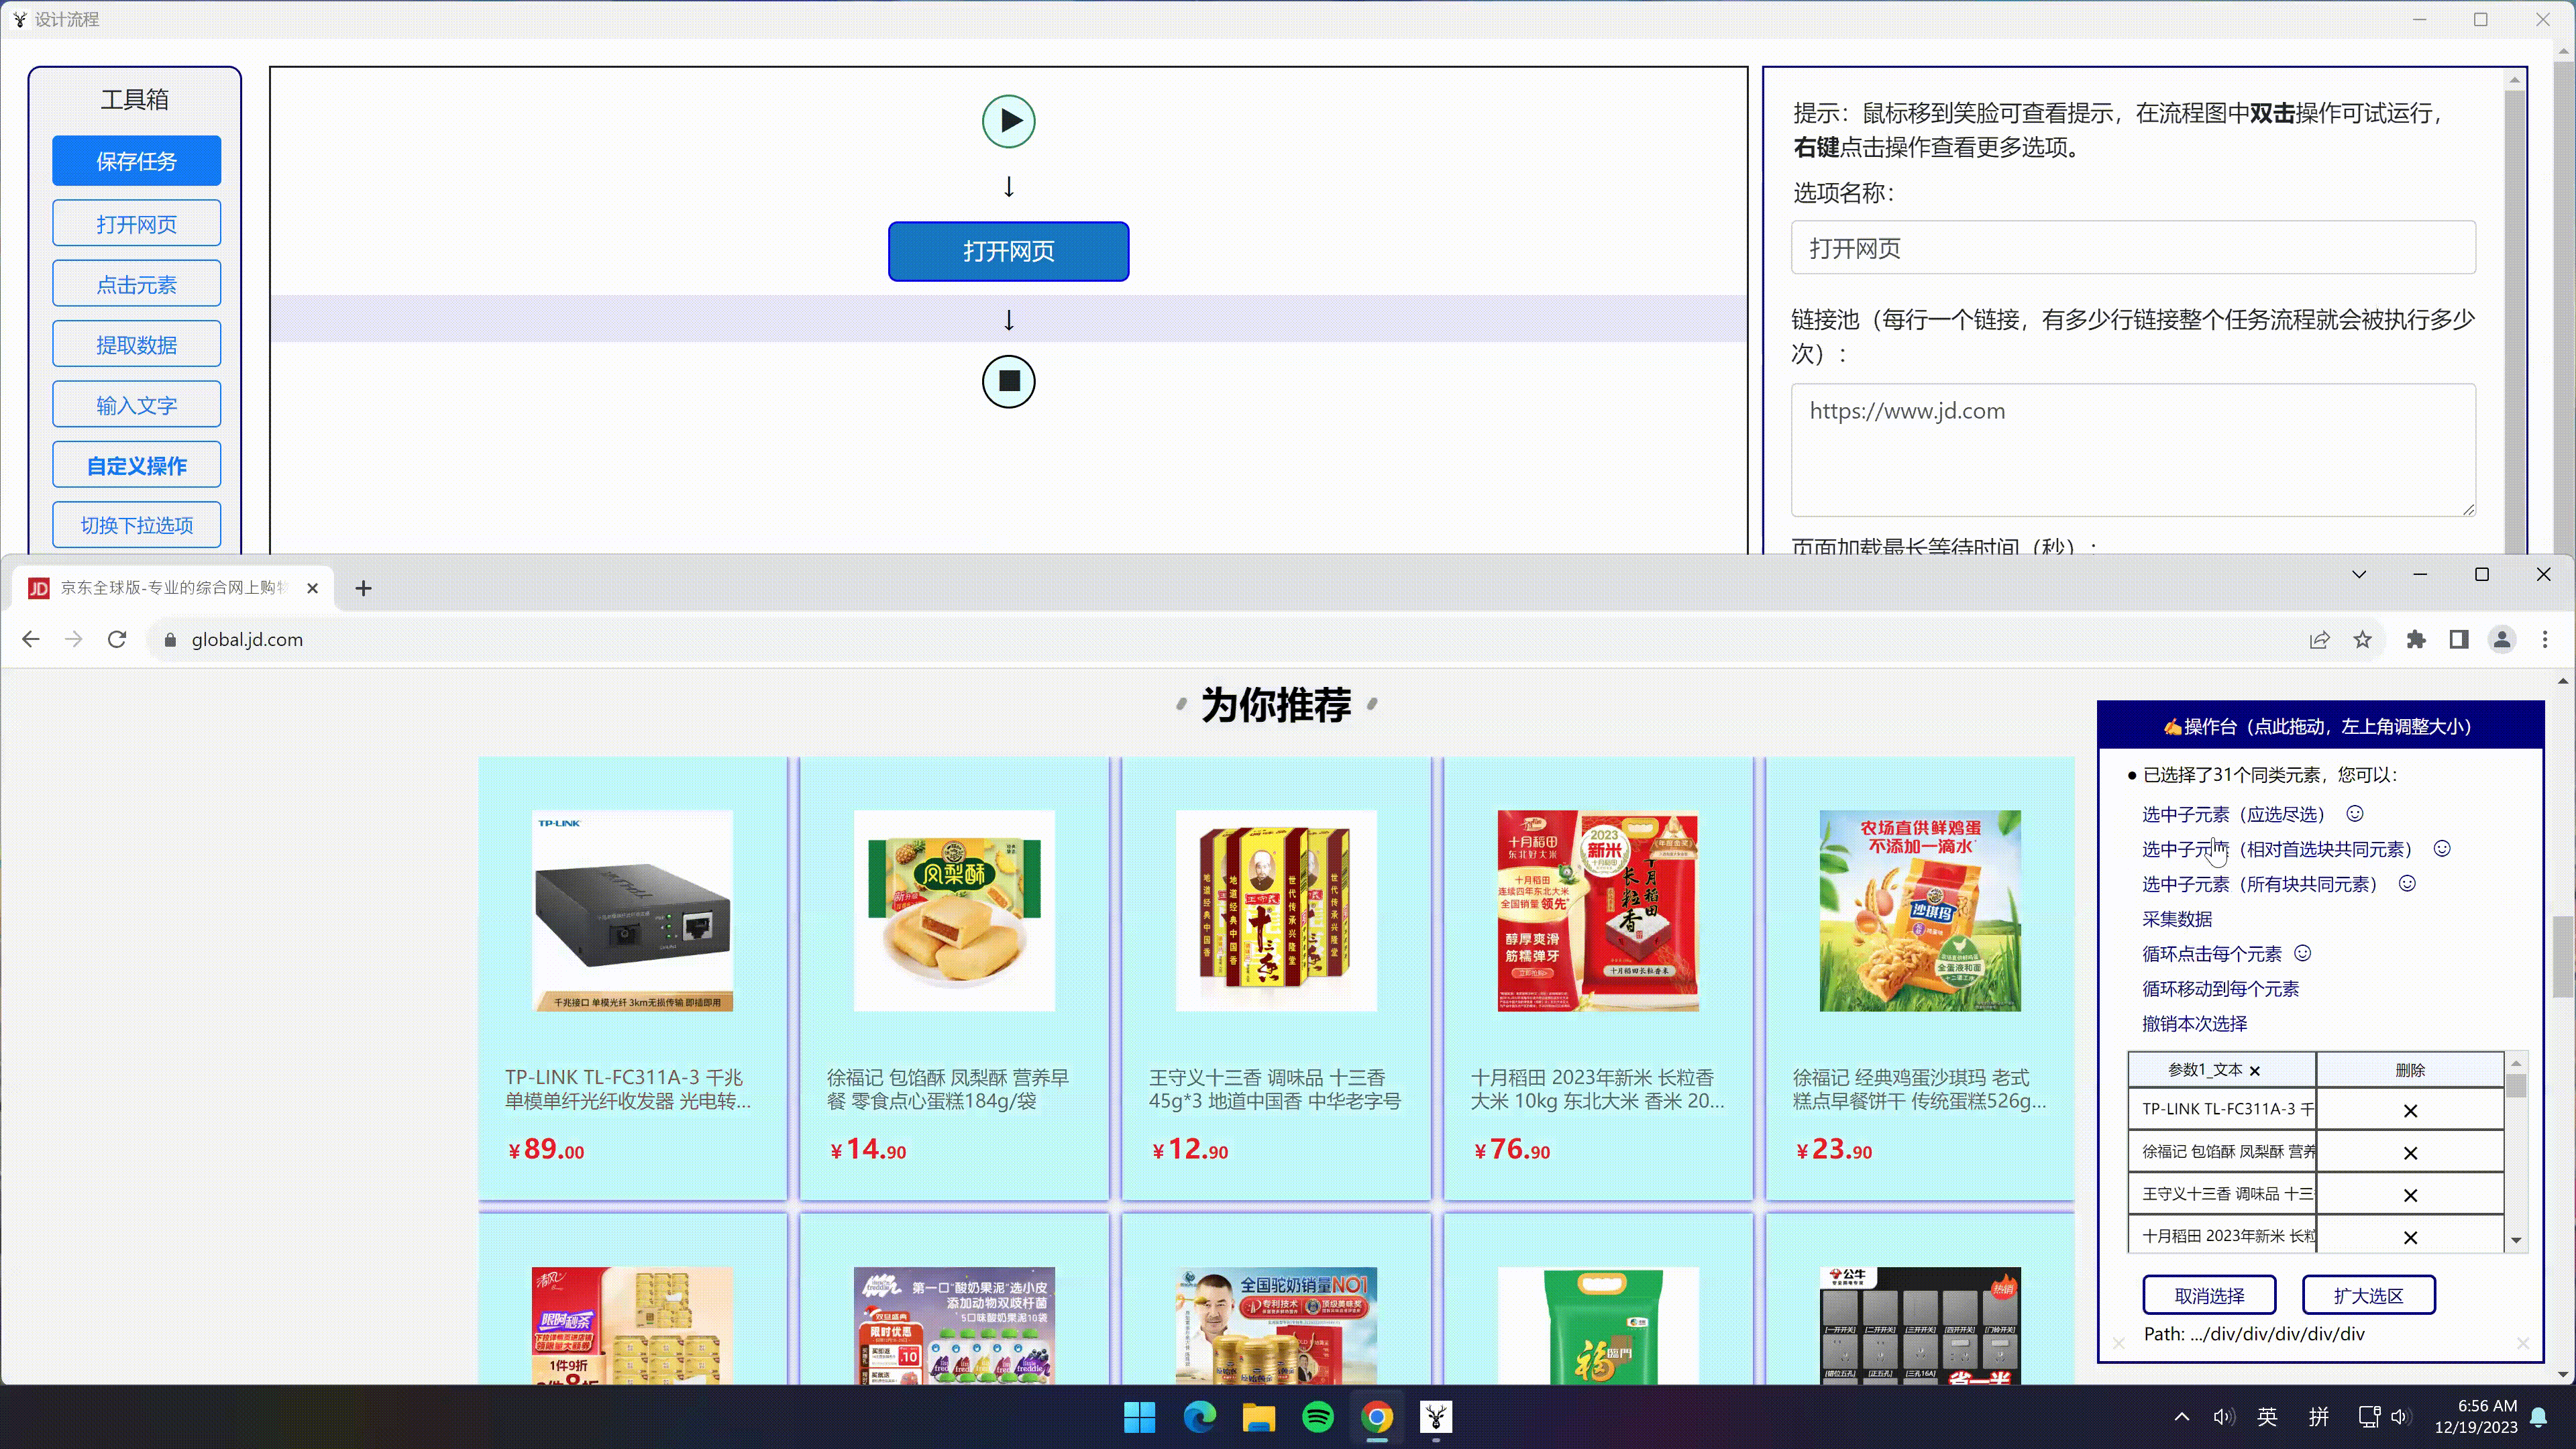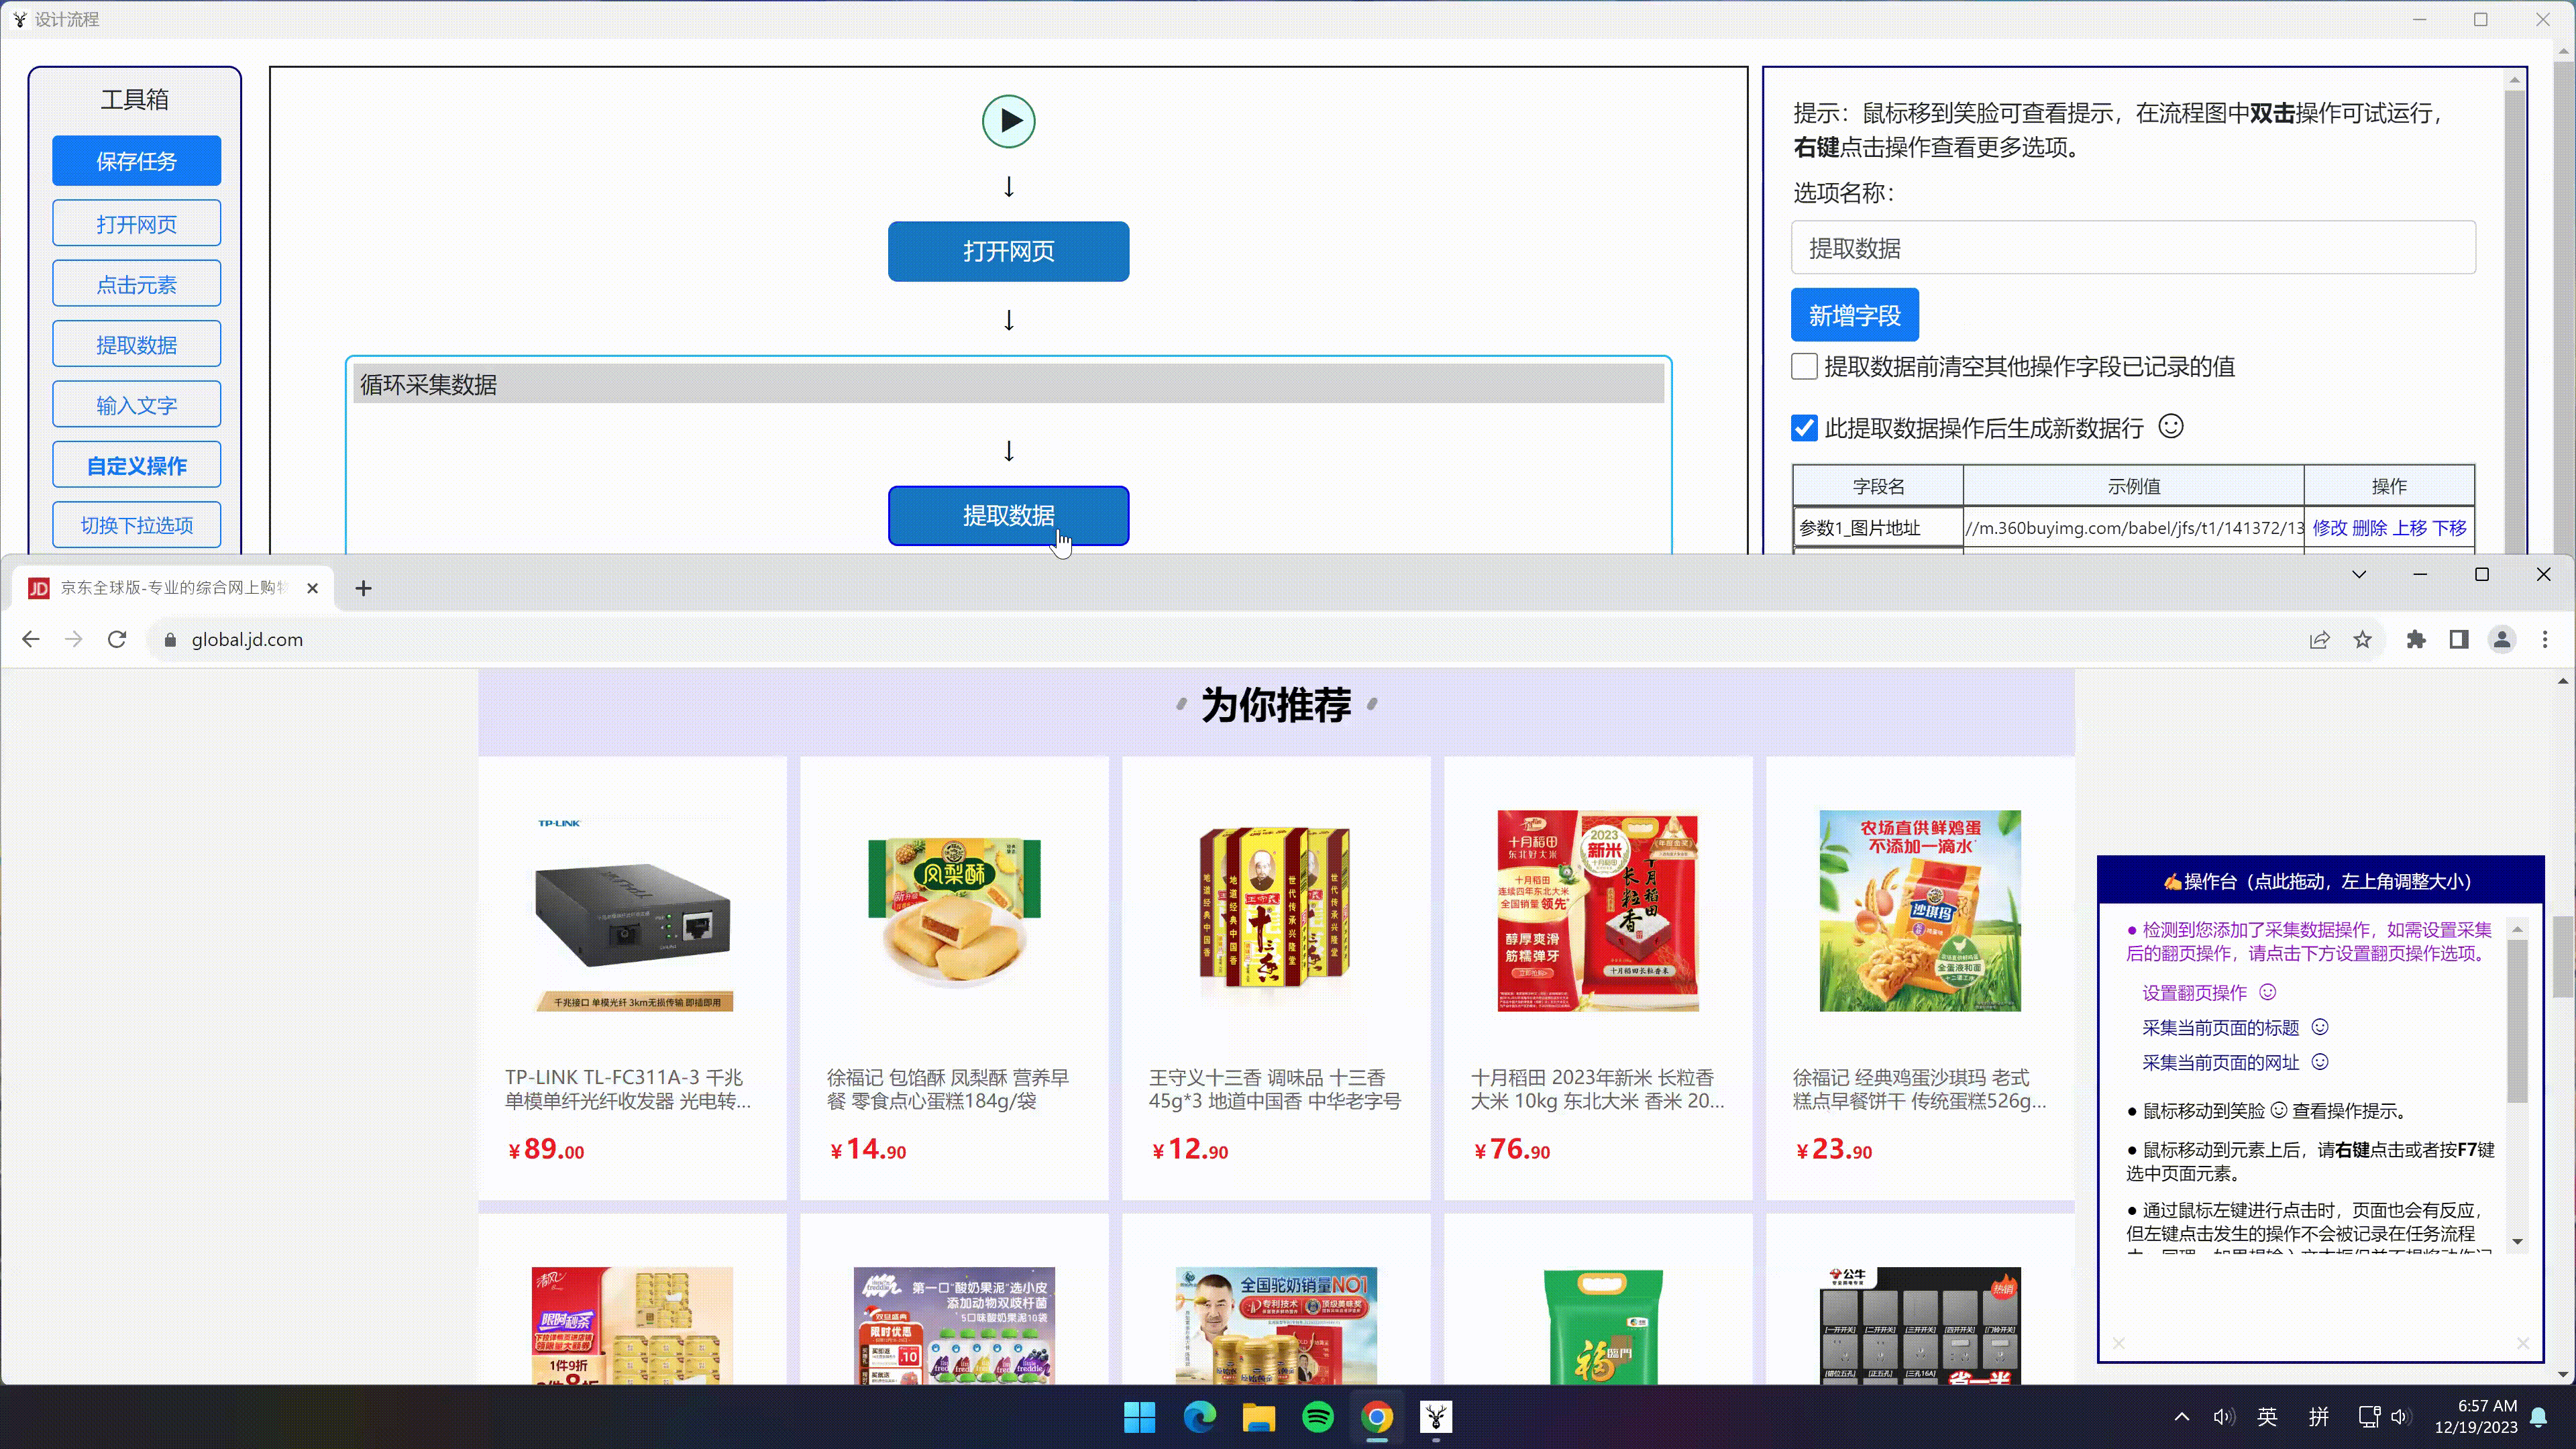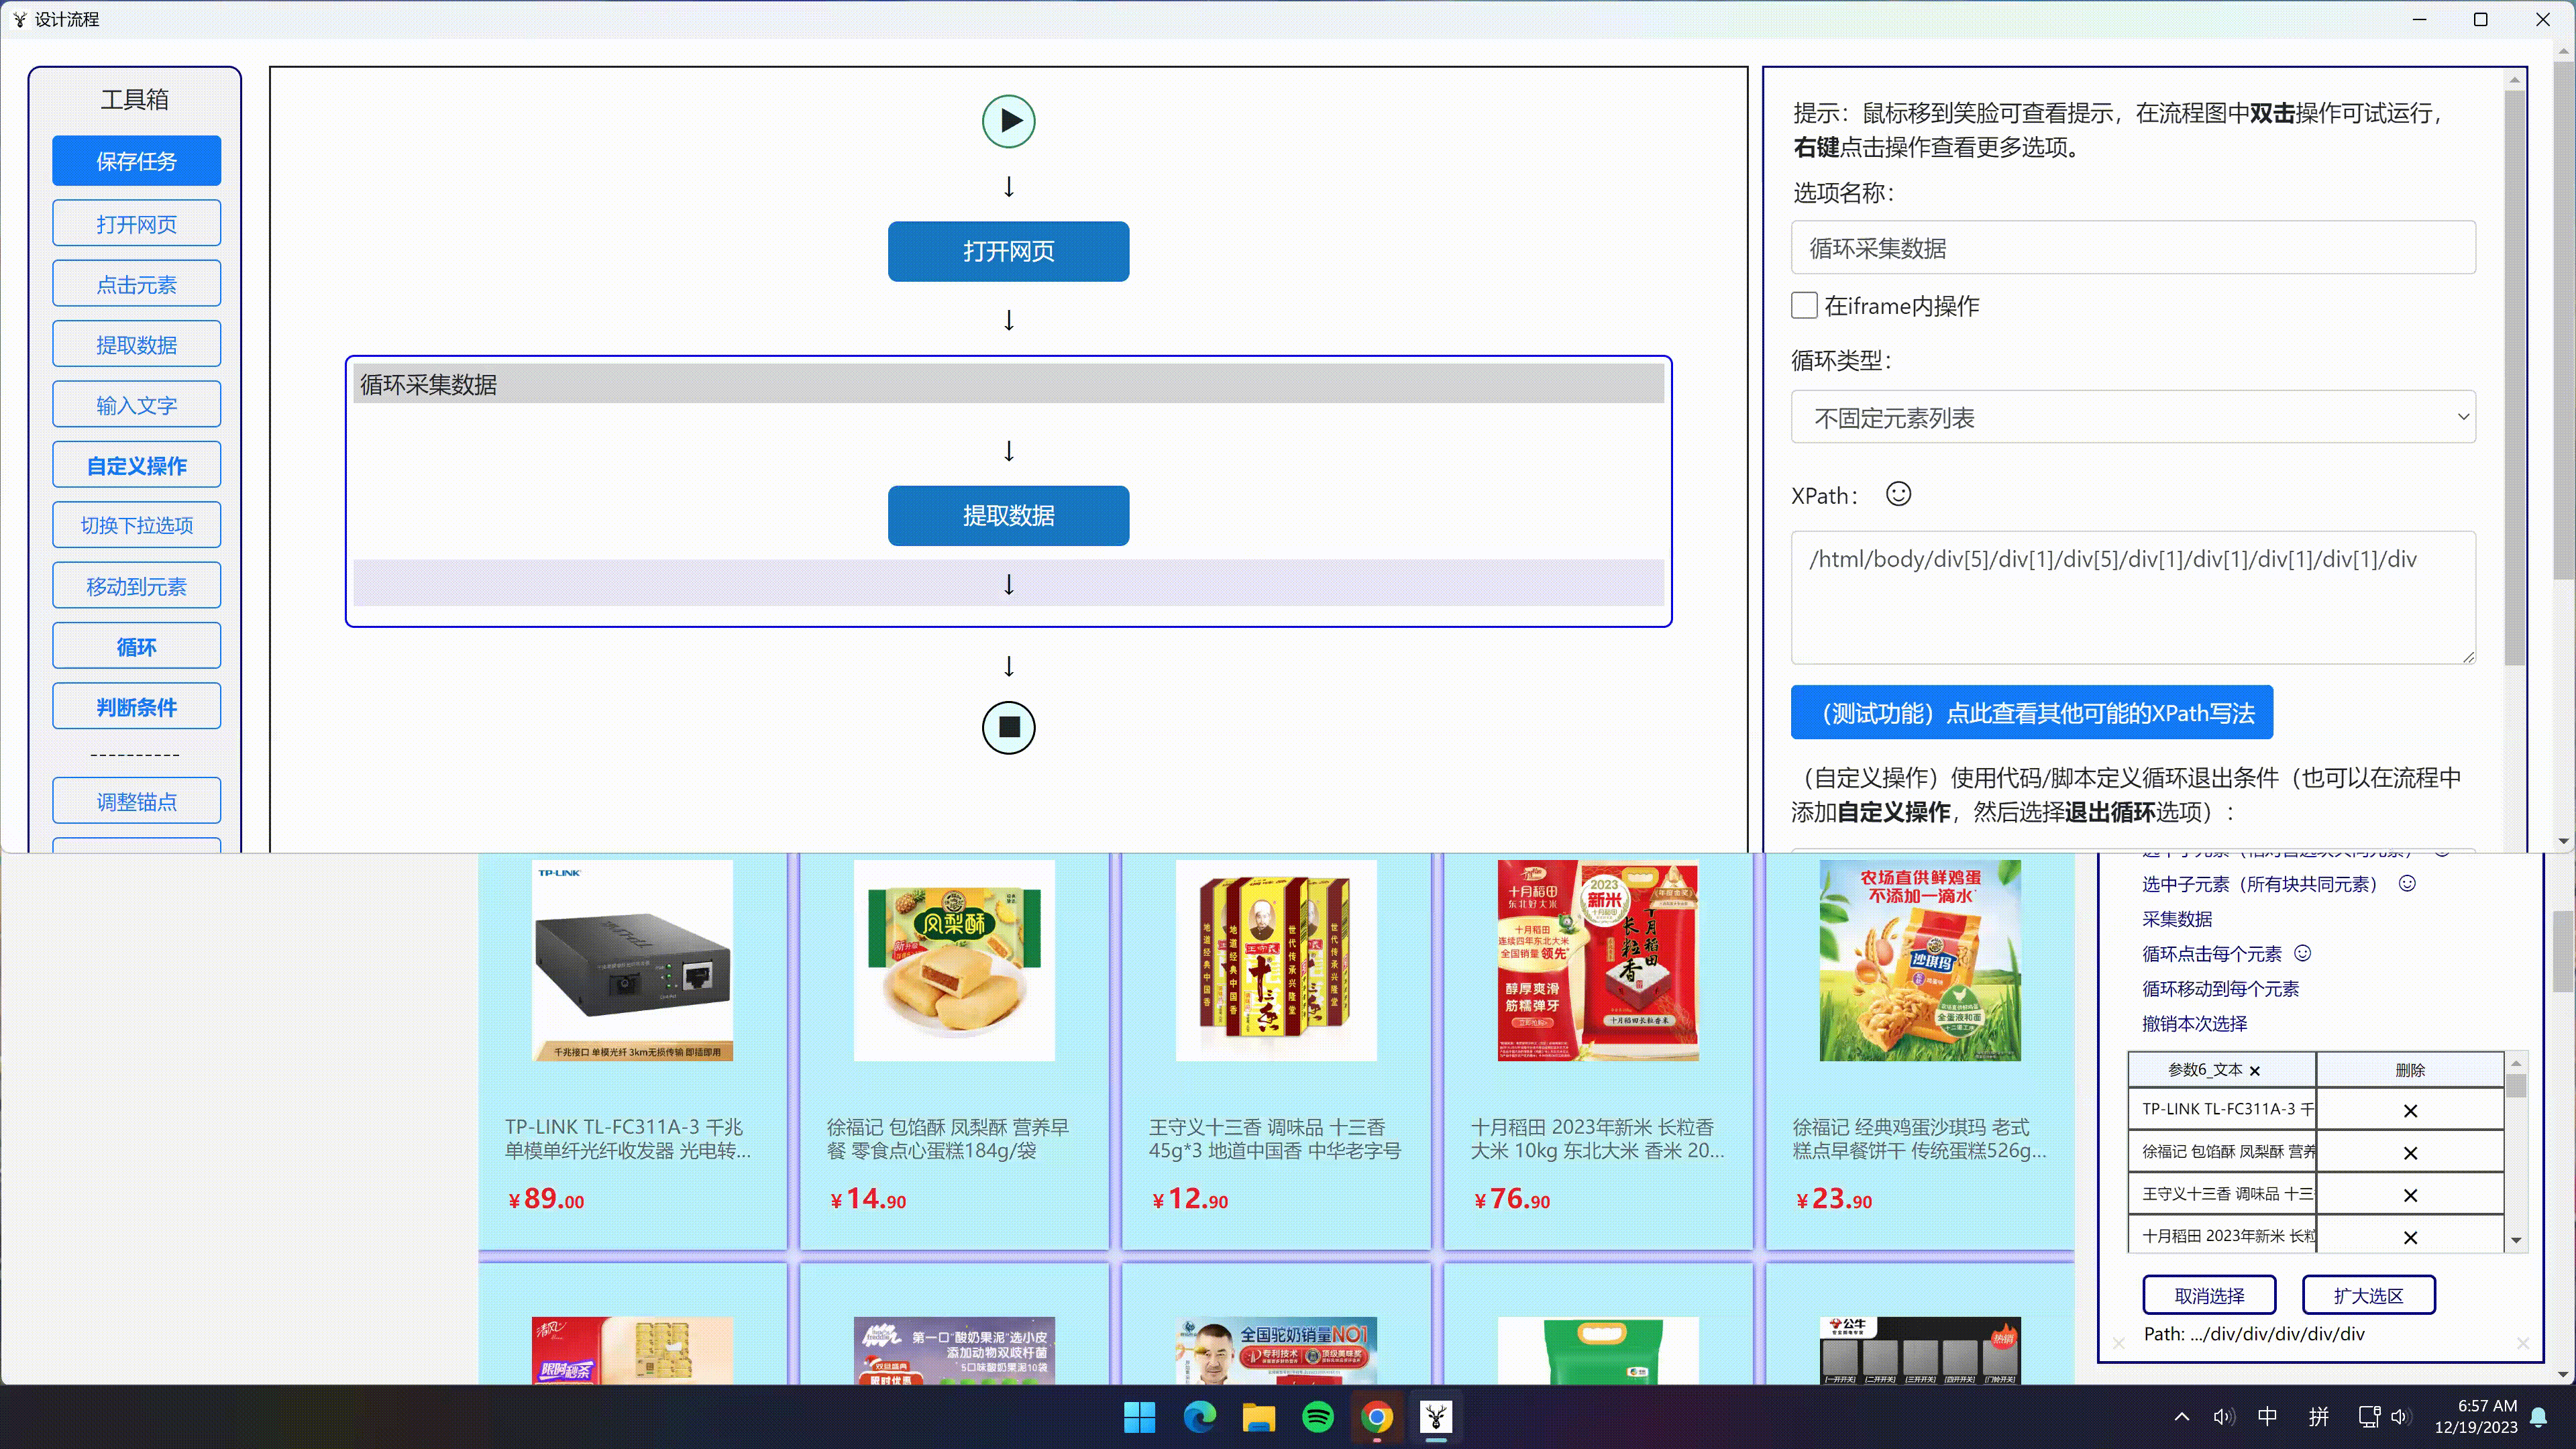
44.7KNaiboWang/EasySpider · JavaScriptEasySpider (易采集) is a visual, no-code web crawler and browser automation tool. You select elements on a webpage with clicks instead of writing code, and it designs and runs the scraping/testing task for you.
- 6
PythonRobotics
30.7KAtsushiSakai/PythonRobotics · PythonPythonRobotics is a Python code collection and textbook of classic robotics algorithms, covering localization, mapping, SLAM, path planning, path tracking, arm navigation, aerial navigation, and bipedal control.
- 7
genesis-world
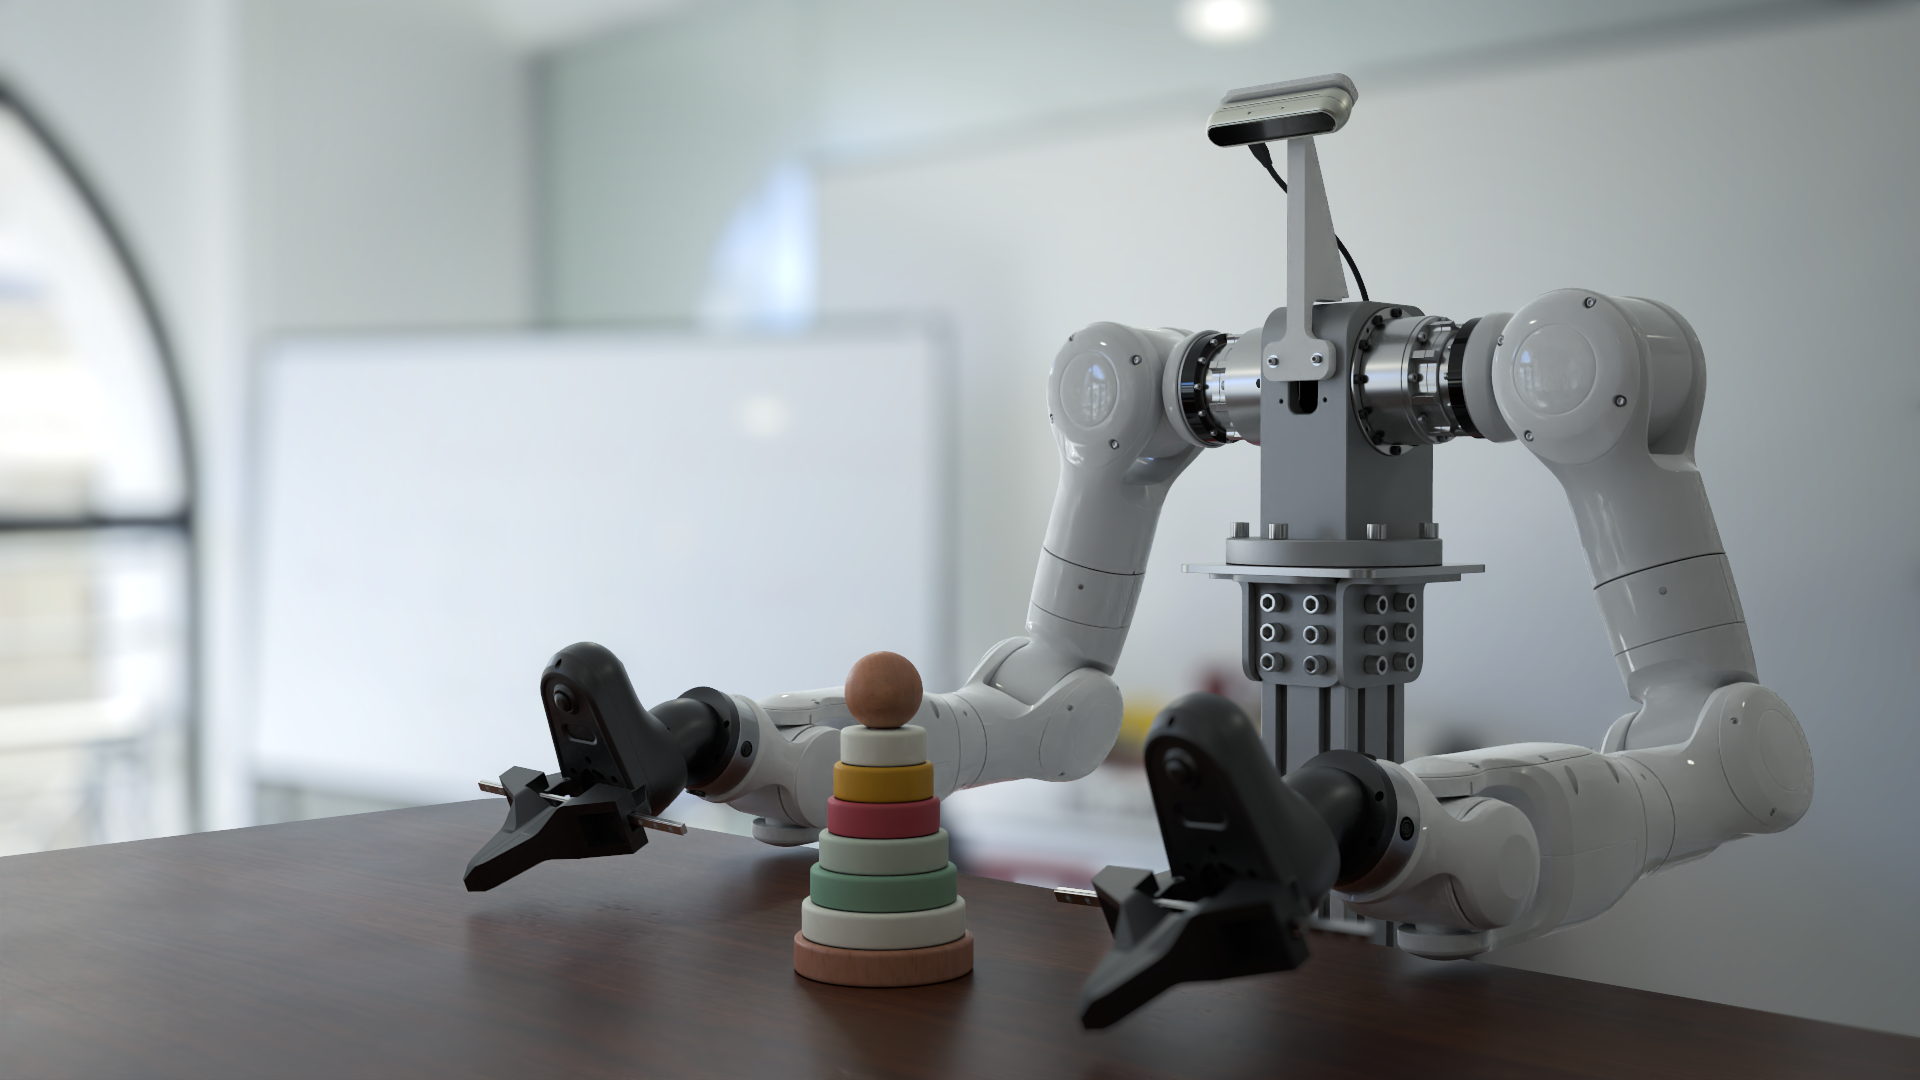
30.1KGenesis-Embodied-AI/genesis-world · PythonIt's a simulation platform for general-purpose robotics and embodied AI learning: a multi-physics engine, a photorealistic renderer (Nyx) and a cross-platform compiler (Quadrants) behind one Python API.
- 8

cs249r_book
29.1Kharvard-edge/cs249r_book · PythonAn open textbook and full curriculum on Machine Learning Systems — AI engineering — from Harvard's CS249r course: four volumes covering foundations, scaling, agentic AI, and physical AI, plus labs, projects, and instructor materials.
- 9
lerobot
28.3Khuggingface/lerobot · PythonLeRobot is Hugging Face's open-source project providing models, datasets, and tools for real-world robotics in PyTorch, aiming to lower the barrier to entry for building and deploying robot learning policies.
- 10

apollo
26.9KApolloAuto/apollo · C++An open autonomous driving platform from Baidu: a high-performance, flexible software stack covering perception, prediction, planning and control, for developing, testing and deploying self-driving vehicles.
- 11

wechaty
23.4Kwechaty/wechaty · TypeScriptWechaty is an RPA (Robotic Process Automation) SDK for building chatbots that lets you write a bot once in JavaScript, Python, Go or Java and run it across WhatsApp, WeChat, QQ and other platforms with the same code.
- 12
learnopencv
23.2Kspmallick/learnopencv · Jupyter NotebookThis is the companion code repository for the LearnOpenCV.com blog, containing C++ and Python examples that accompany articles on computer vision, deep learning, and AI research.
- 13
text-to-cad
21.3Kearthtojake/text-to-cad · Pythontext-to-cad is a library of agent skills for CAD, CAE and CAM: it gives coding agents focused workflows to generate, inspect, source, slice, and hand off CAD and robot-description artifacts from your local project files.
- 14
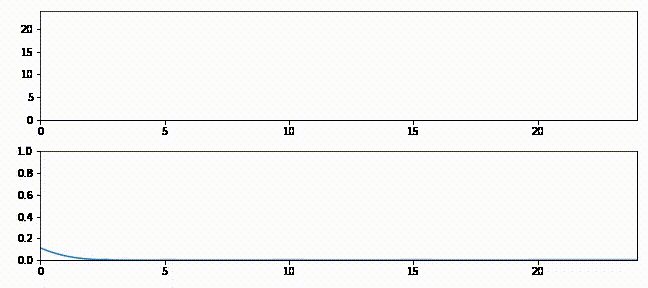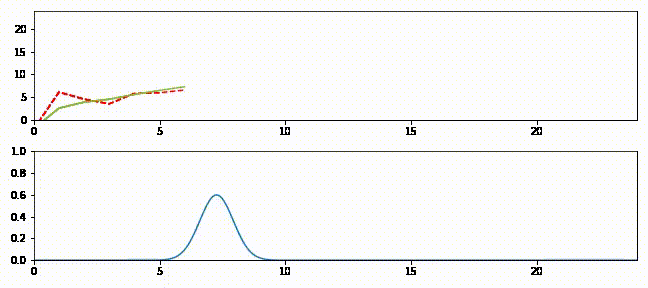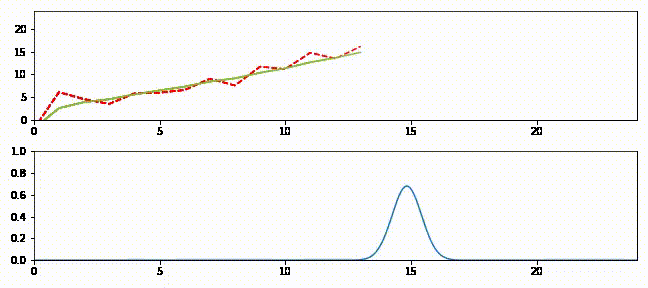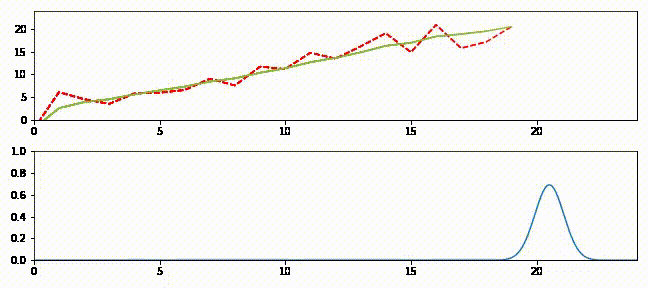
Kalman-and-Bayesian-Filters-in-Python
19.4Krlabbe/Kalman-and-Bayesian-Filters-in-Python · Jupyter NotebookAn interactive book that teaches Kalman and Bayesian filters (Kalman, extended Kalman, unscented Kalman, particle filters) using Python and Jupyter Notebook, focused on intuition rather than formal proofs.
- 15
AirSim
18.6Kmicrosoft/AirSim · C++AirSim is an open-source simulator for drones, cars and more, built on Unreal Engine and created by Microsoft AI & Research. There is also an experimental Unity release.
- 16

questdb
17.4Kquestdb/questdb · JavaQuestDB is an open-source, low-latency time-series database on open formats: it ingests millions of events per second, computes on live data in milliseconds, and keeps years of history queryable through one SQL engine.
- 17
Embodied-AI-Guide
16.5KTianxingChen/Embodied-AI-GuideA free, encyclopedia-style Chinese knowledge base and resource index for embodied AI — robots that perceive and act in the physical world — maintained by the Lumina Embodied AI community. It is one of the most popular embodied-AI guides in China, with over 16,000 GitHub stars.
- 18
nicegui
16.3Kzauberzeug/nicegui · PythonNiceGUI is an easy-to-use, Python-based UI framework that shows up in your web browser, letting you build buttons, dialogs, 3D scenes, plots, dashboards and more without writing frontend code yourself.
- 19
ardupilot
16.1KArduPilot/ardupilot · C++ArduPilot is an open source autopilot, in development since 2010, that can control almost any unmanned vehicle: planes, multicopters and helicopters, rovers, boats, balance bots and even submarines.
- 20
mujoco
15.7Kgoogle-deepmind/mujoco · C++MuJoCo is a general-purpose physics engine for simulating articulated structures interacting with their environment, maintained by Google DeepMind. It targets robotics, biomechanics, graphics/animation, and machine learning research.
- 21

Dummy-Robot
15.7Kpeng-zhihui/Dummy-Robot · CThis is the author's open-source design for a super-compact robotic arm, including mechanical CAD files, custom PCB electronics, STM32 firmware, and PC control software for a self-built 6-axis desktop arm.
- 22
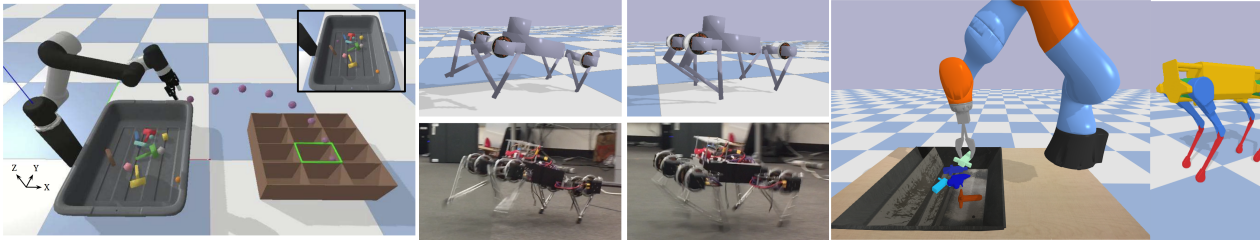
bullet3
14.8Kbulletphysics/bullet3 · C++Bullet Physics SDK is the official C++ library for real-time collision detection and multi-physics simulation, used in VR, games, visual effects, robotics and machine learning.
- 23
carla
14.5Kcarla-simulator/carla · C++CARLA is an open-source simulator for autonomous driving research, built from the ground up to support development, training, and validation of self-driving systems, with open urban layouts, buildings, and vehicle assets.
- 24

openpi
14.3KPhysical-Intelligence/openpi · Pythonopenpi is a collection of open-source vision-language-action (VLA) models for robotics from the Physical Intelligence team, including pi0, pi0-FAST, and pi0.5, with pretrained checkpoints and code for fine-tuning and running them.
- 25
stable-baselines3
13.9KDLR-RM/stable-baselines3 · PythonStable Baselines3 (SB3) is a set of reliable PyTorch implementations of reinforcement learning algorithms, meant to serve as solid baselines for research and industry projects.
- 26

speech-to-speech
13.5Khuggingface/speech-to-speech · PythonIt's a low-latency, fully modular voice-agent pipeline (VAD -> STT -> LLM -> TTS) for building voice agents with open-source speech and language models, exposed over WebSocket and WebRTC via the OpenAI Realtime API event set.
- 27

johnny-five
13.4Krwaldron/johnny-five · JavaScriptJohnny-Five is an open-source JavaScript framework for robotics and IoT, built on the Firmata protocol, that lets you write JS code to control hardware like Arduino, Raspberry Pi, Tessel 2, and Intel Edison boards.
- 28

PX4-Autopilot
12.8KPX4/PX4-Autopilot · C++PX4 is an open-source autopilot stack for drones and unmanned vehicles — the flight software behind multirotors, fixed-wing planes, VTOLs, rovers and other unmanned platforms.
- 29

autoware
12.2Kautowarefoundation/autoware · DockerfileAutoware is the world's leading open-source autonomous driving framework — a complete software stack for building self-driving vehicles.
- 30
cosmos
12.1KNVIDIA/cosmos · Jupyter NotebookNVIDIA Cosmos is an open platform of world models, datasets, and tools for building Physical AI — systems that understand and generate the physical world for robots, autonomous vehicles, and smart infrastructure.
- 31
oomwoo
12Kmakerspet/oomwoo · PythonOOMWOO is an open-source home vacuum robot you build yourself, using a Raspberry Pi, 3D-printed parts, Home Assistant, Arduino and ROS2, navigating with an affordable 2D LiDAR.
- 32

fprime
11.8Knasa/fprime · C++F ́ (F Prime) is a component-driven flight software framework originally built at NASA's Jet Propulsion Laboratory for spaceflight and other embedded systems, including CubeSats, SmallSats, and instruments.
- 33

betaflight
11.7Kbetaflight/betaflight · CBetaflight is open-source flight controller firmware used to fly multi-rotor (drone) and fixed-wing aircraft, focused on flight performance and wide hardware target support.
- 34
rerun
11.6Krerun-io/rerun · RustRerun is a data layer for physical AI: it logs, queries, visualizes and streams multimodal robotics data (images, point clouds, transforms, time series, video) so you can debug sensor pipelines and feed data into training.
- 35

kornia
11.4Kkornia/kornia · PythonKornia is an open-source differentiable computer vision library for Python: 500+ image processing, geometry and augmentation operators plus pre-trained AI models, all built on PyTorch.
- 36
pcl
11.2KPointCloudLibrary/pcl · C++PCL (Point Cloud Library) is a standalone, large-scale open source project for 2D/3D image and point cloud processing, covering things like filtering, feature estimation, surface reconstruction, registration, model fitting and segmentation.
- 37

ORB_SLAM2
10.3Kraulmur/ORB_SLAM2 · C++ORB-SLAM2 is a real-time SLAM library for monocular, stereo and RGB-D cameras: it tracks the camera trajectory and builds a sparse 3D reconstruction, with loop detection and relocalization.
- 38
microduck
9.5Kpollen-robotics/microduck · RustMicroduck is a tiny biped duck robot (about 25cm, 800g), and this repo is the robot's brain: Rust daemons that run a 50Hz control loop driving fifteen servos using reinforcement-learning policies exported to ONNX.
- 39
maths-cs-ai-compendium
7.7KHenryNdubuaku/maths-cs-ai-compendium · TypeScriptAn open, unconventional online textbook covering maths, computing and AI from the ground up — intuition first, real-world context, for practitioners who want deep understanding rather than exam survival.
- 40
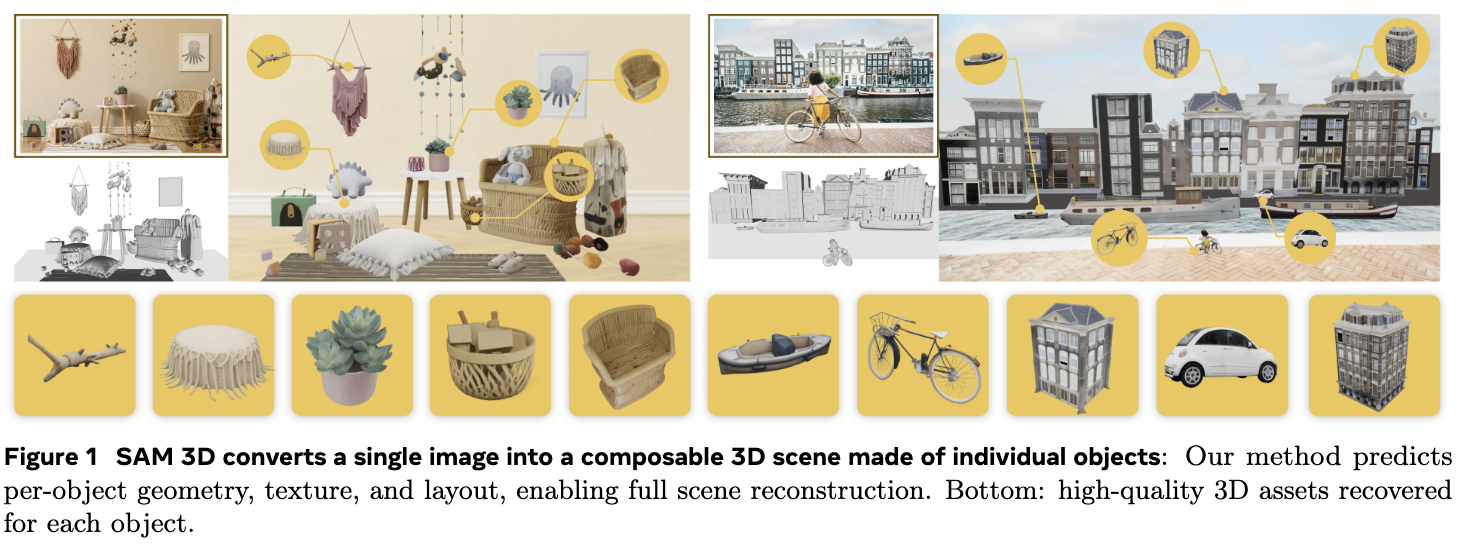
sam-3d-objects
7.5Kfacebookresearch/sam-3d-objects · PythonSAM 3D Objects is a foundation model from Meta that reconstructs full 3D shape geometry, texture, and object layout from a single 2D image, even in cluttered real-world scenes with occlusion.
- 41
vllm-omni
7.2Kvllm-project/vllm-omni · PythonvLLM-Omni is an inference and serving framework that extends vLLM beyond text-only LLMs to omni-modality models, handling text, image, audio, video, and action outputs.
- 42
sesame-robot
4.7Kdorianborian/sesame-robot · CSesame is an open-source DIY quadruped walking robot built around an ESP32 microcontroller, designed with an emphasis on expressive movement and a reactive face display.
- 43
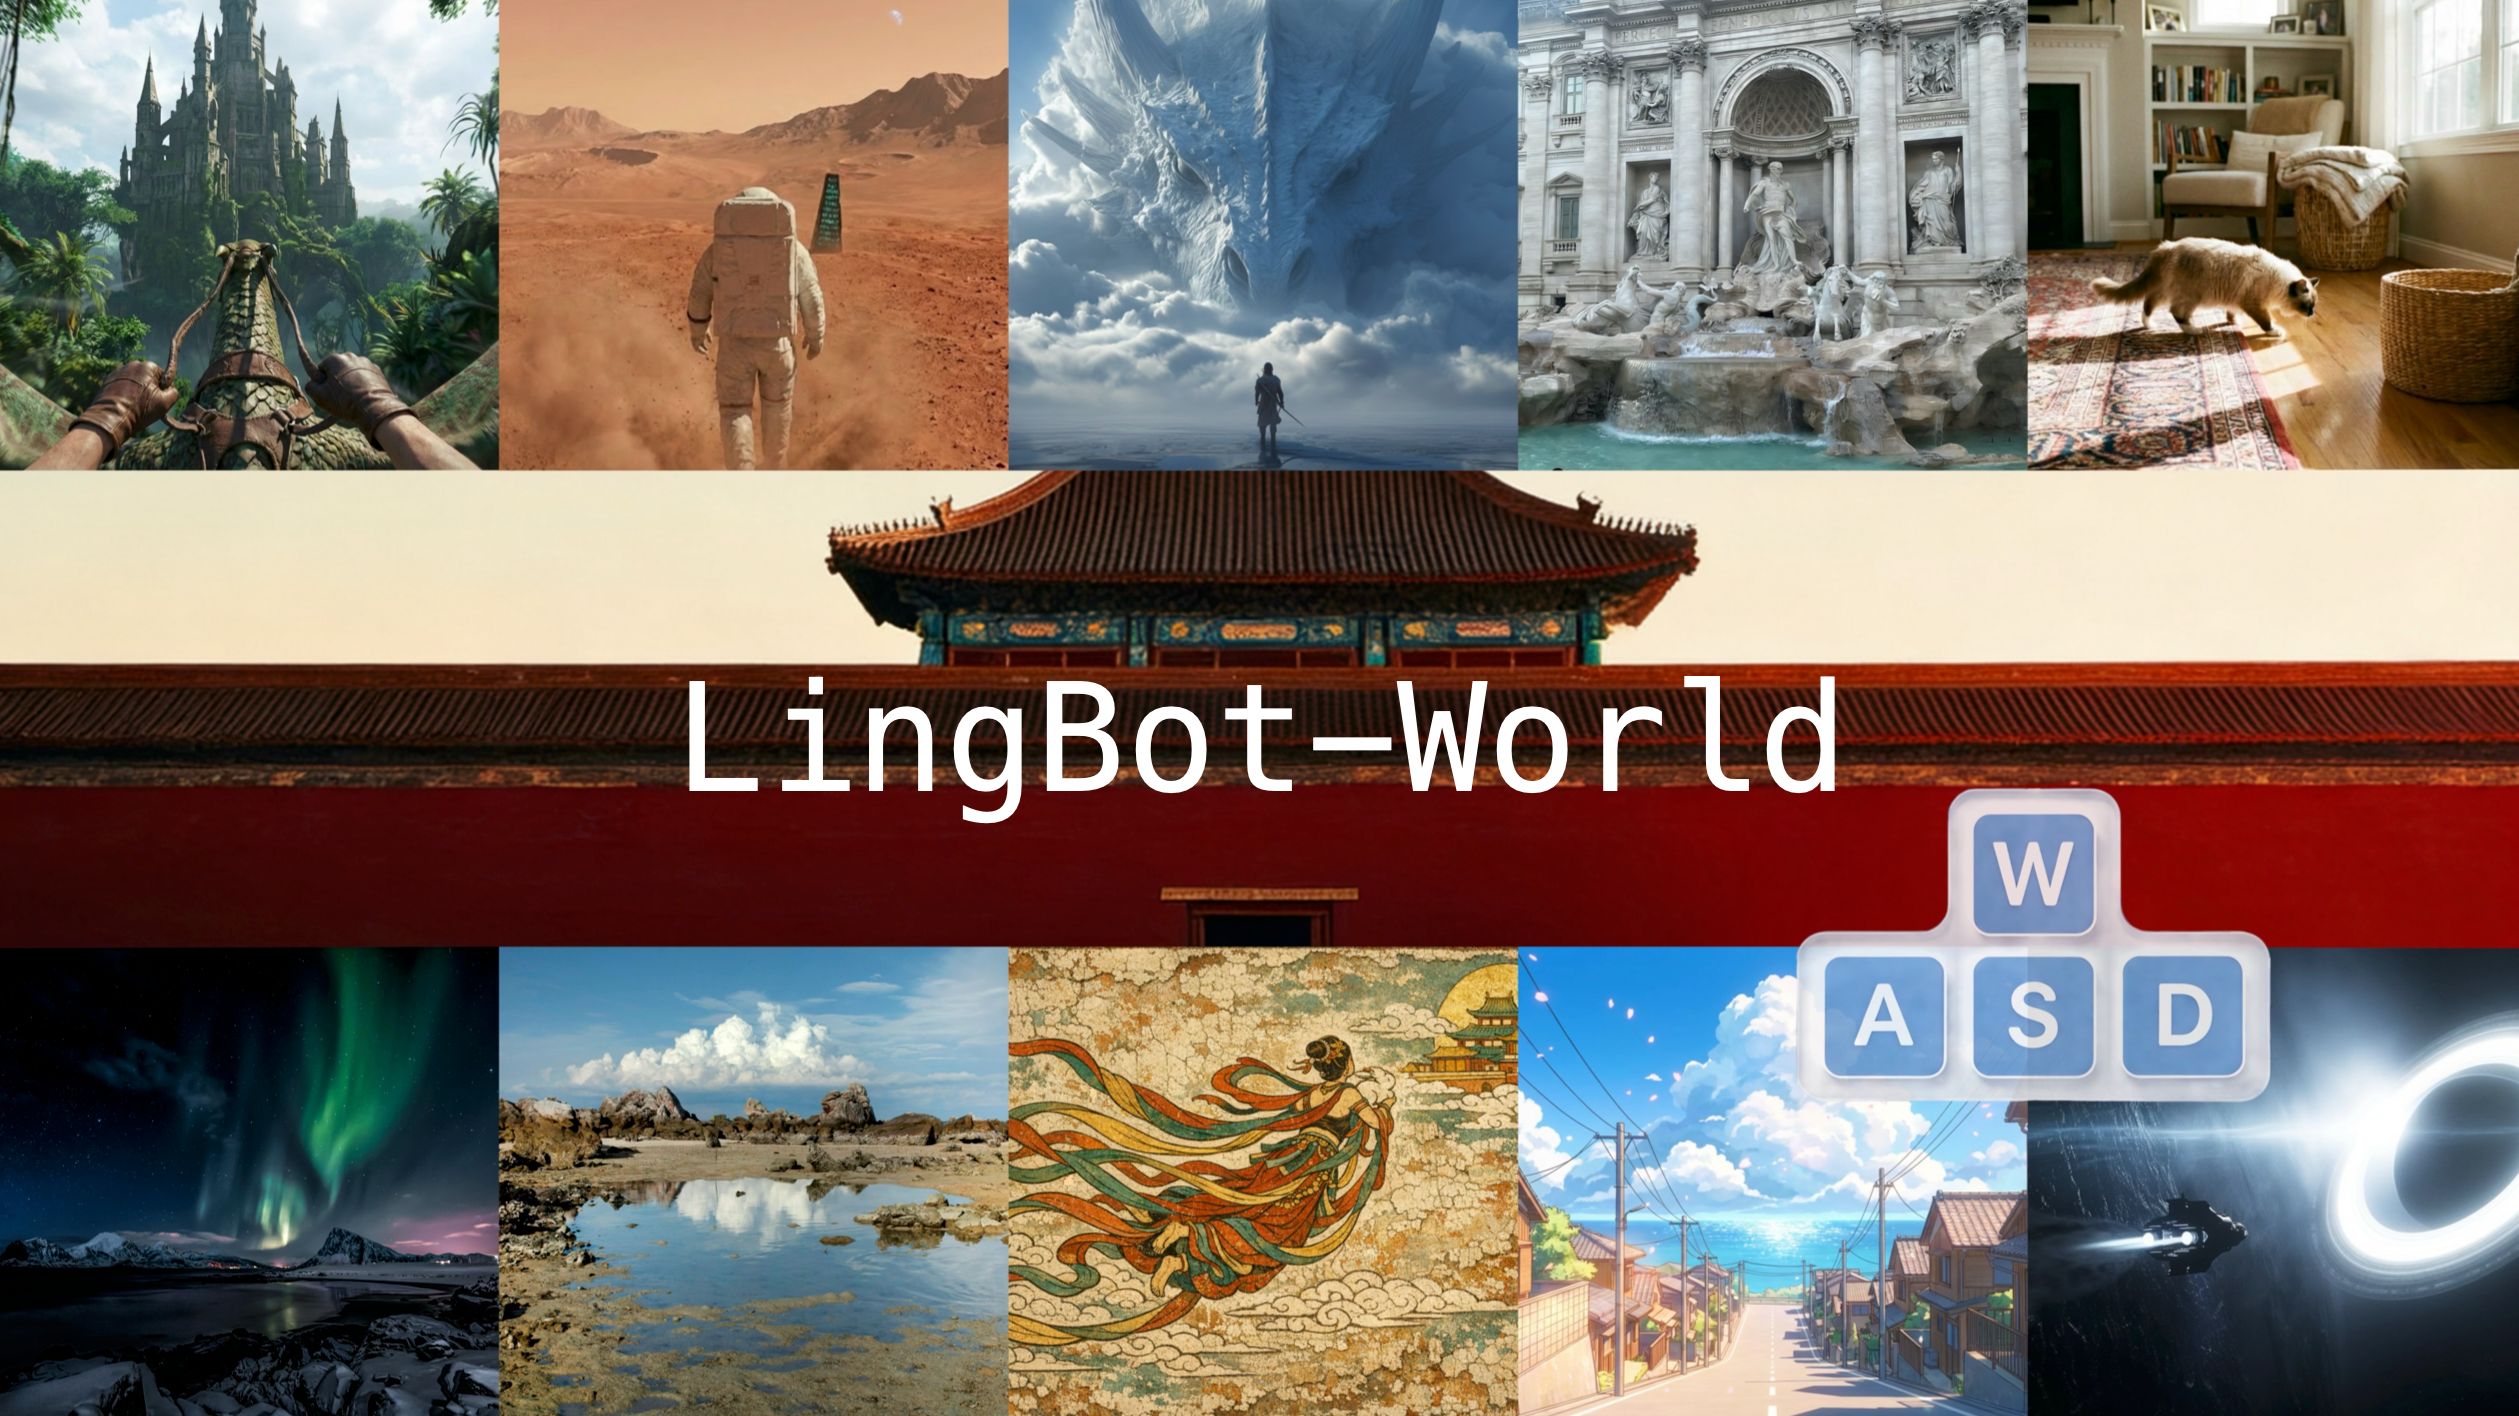
lingbot-world
4.5KRobbyant/lingbot-world · PythonLingBot-World is an open-source world model/simulator built from video generation: it turns an input image, text prompt, and optional control signals (camera poses or actions) into a long, controllable video that behaves like an interactive world.
- 44
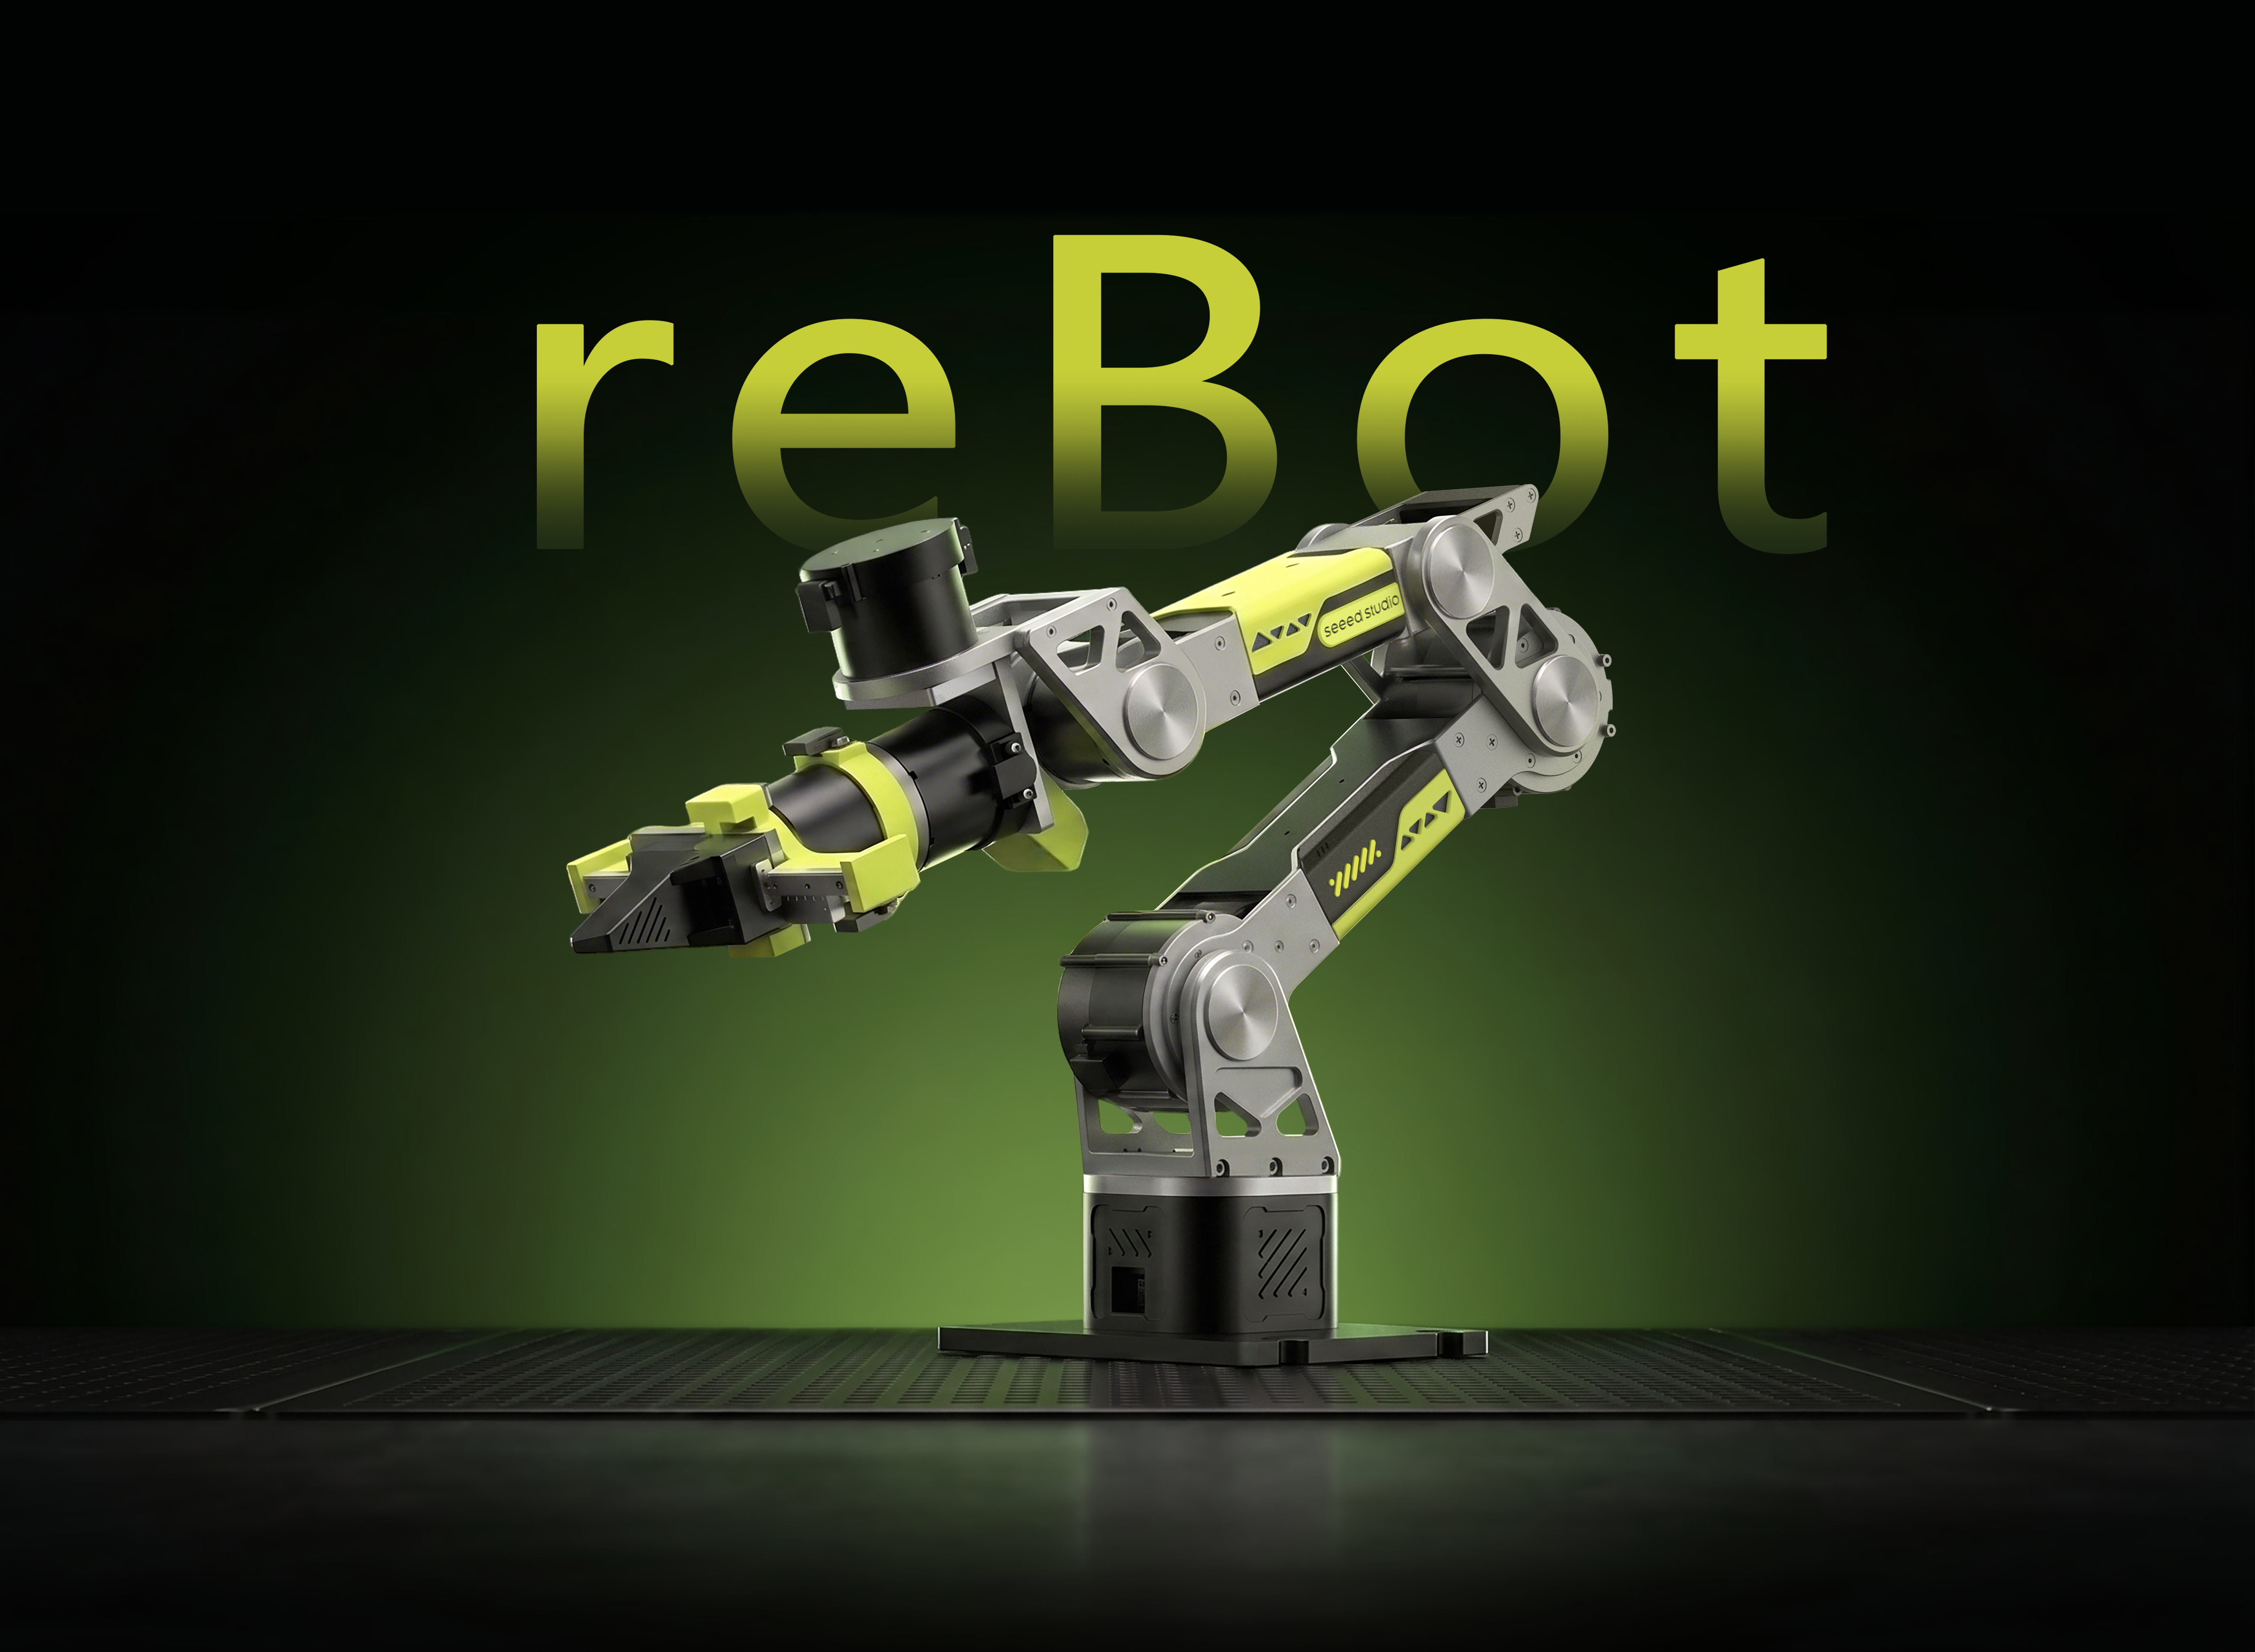
reBot-DevArm
4.4KSeeed-Projects/reBot-DevArm · PythonreBot-DevArm is a fully open-source robotic arm project (B601-DM and B601-RS models) aimed at lowering the barrier to learning Embodied AI, with all hardware files, BOM, and software openly released.
- 45
starVLA
3.8KstarVLA/starVLA · PythonStarVLA is an open-source, modular research codebase for building Vision-Language-Action (VLA) models that control generalist robots, letting you mix and match backbones, action heads, and training recipes like Lego bricks.
- 46
kimodo
3.8Knv-tlabs/kimodo · PythonKimodo is NVIDIA's kinematic motion diffusion model that generates high-quality 3D human and robot motion from text prompts and kinematic constraints like keyframes, end-effector positions, and 2D paths.
- 47

GR00T-WholeBodyControl
3.8KNVlabs/GR00T-WholeBodyControl · PythonNVIDIA GR00T Whole-Body Control — a codebase hosting pretrained checkpoints plus training, evaluation, and deployment code for advanced humanoid robot controllers: the Decoupled WBC used in GR00T N1.5/N1.6, the GEAR-SONIC series, and MotionBricks.
- 48
ZDTaichu5.0-9B
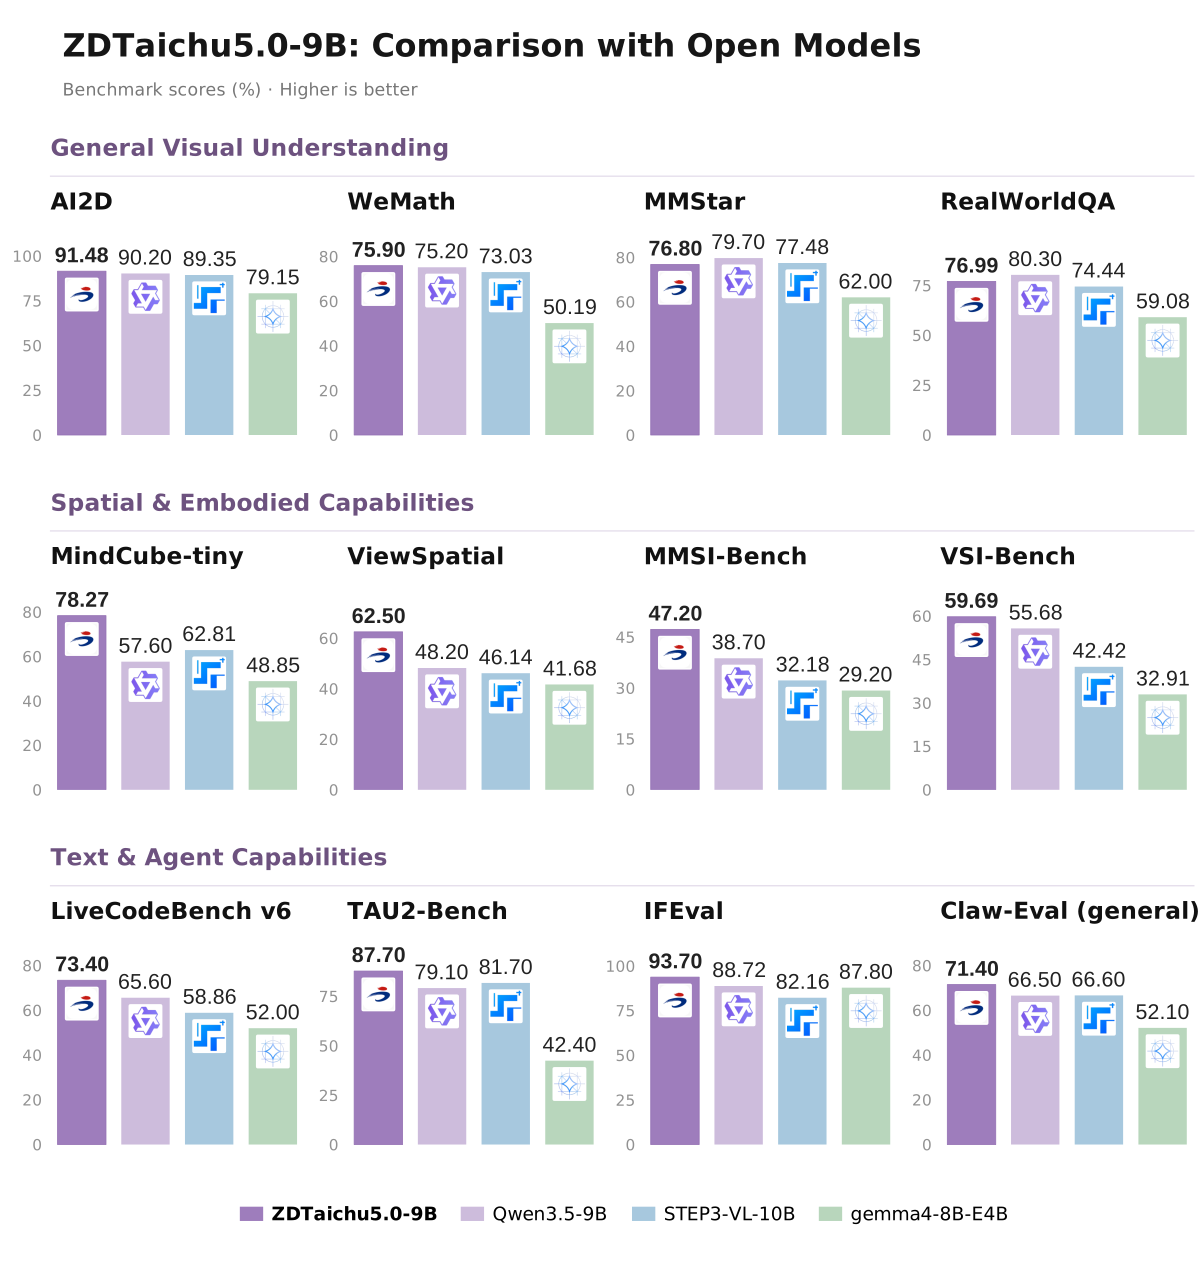
3.1KTaichu-AI/ZDTaichu5.0-9B · PythonZDTaichu5.0-9B is a multimodal foundation model that combines a Qwen3.5-9B language backbone with a C-RADIOv4-H vision encoder for general visual understanding, spatial reasoning, embodied-AI research and agentic tool use.
- 49
jumper
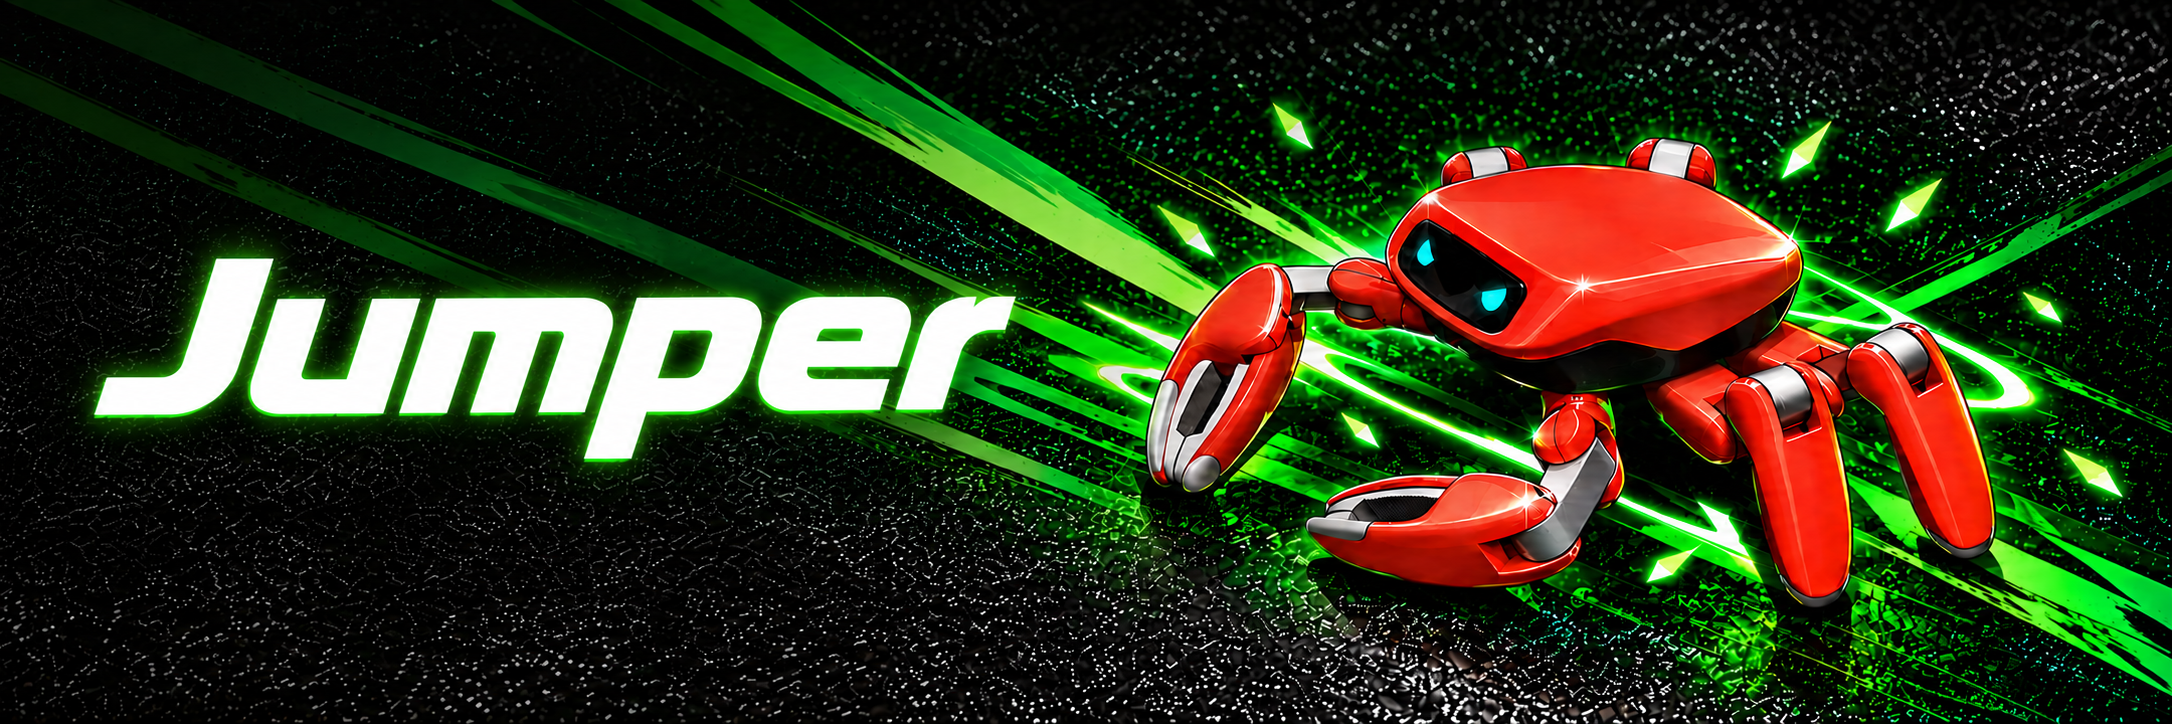
2.7KKingKongRobotics/jumper · PythonJumper is a 22-DoF crab robot, and this repository is its AI toolkit for creating appearances, training motions, and building scenes for it.
- 50
tapnet
2.2Kgoogle-deepmind/tapnet · Jupyter NotebookThis is Google DeepMind's official repository for Tracking Any Point (TAP) research: it bundles the TAP-Vid and TAPVid-3D benchmark datasets, the TAPIR/BootsTAPIR/TAPNext/TAPNext++ point-tracking models, the RoboTAP robotics extension, and the TRAJAN trajectory autoencoder.
- 51
ABot-Recon
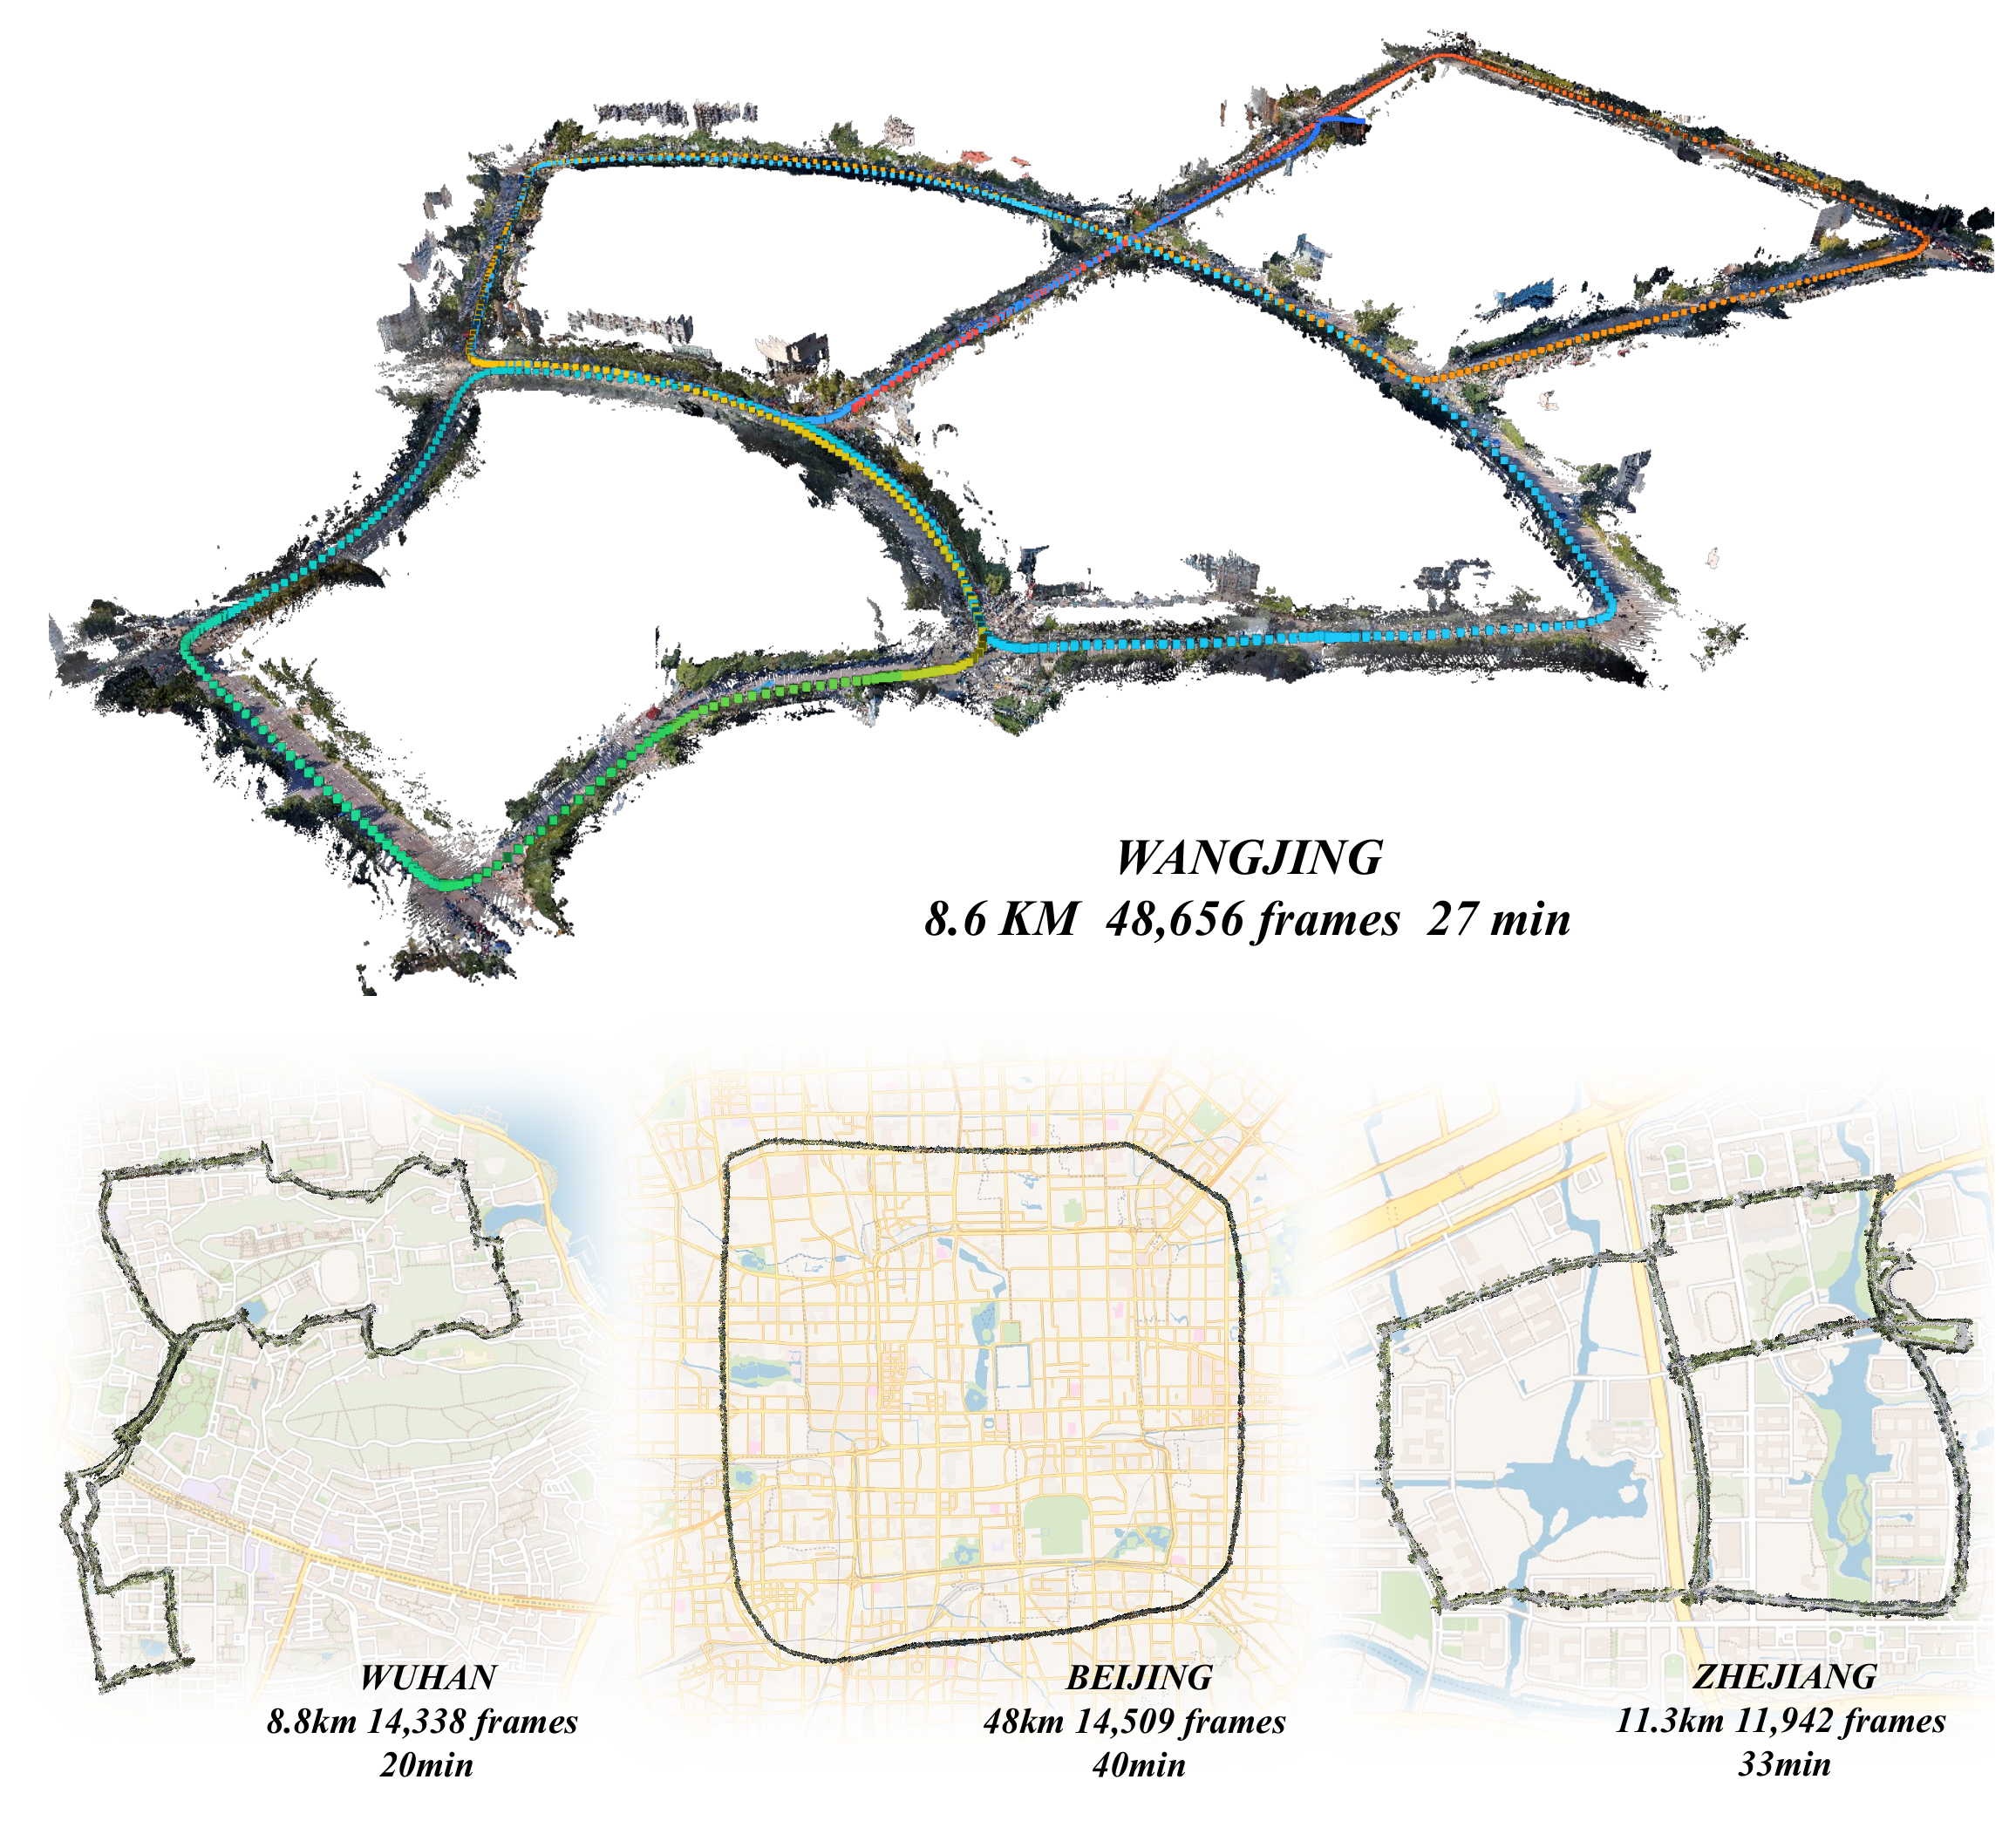
1.4Kamap-cvlab/ABot-Recon · PythonABot-Recon is a streaming 3D reconstruction system: feed it a video stream and it recovers the camera trajectory plus a 3D point cloud, using only a fixed 12-frame local context instead of persistent long-range memory.
- 52
Zetta-Embodiment
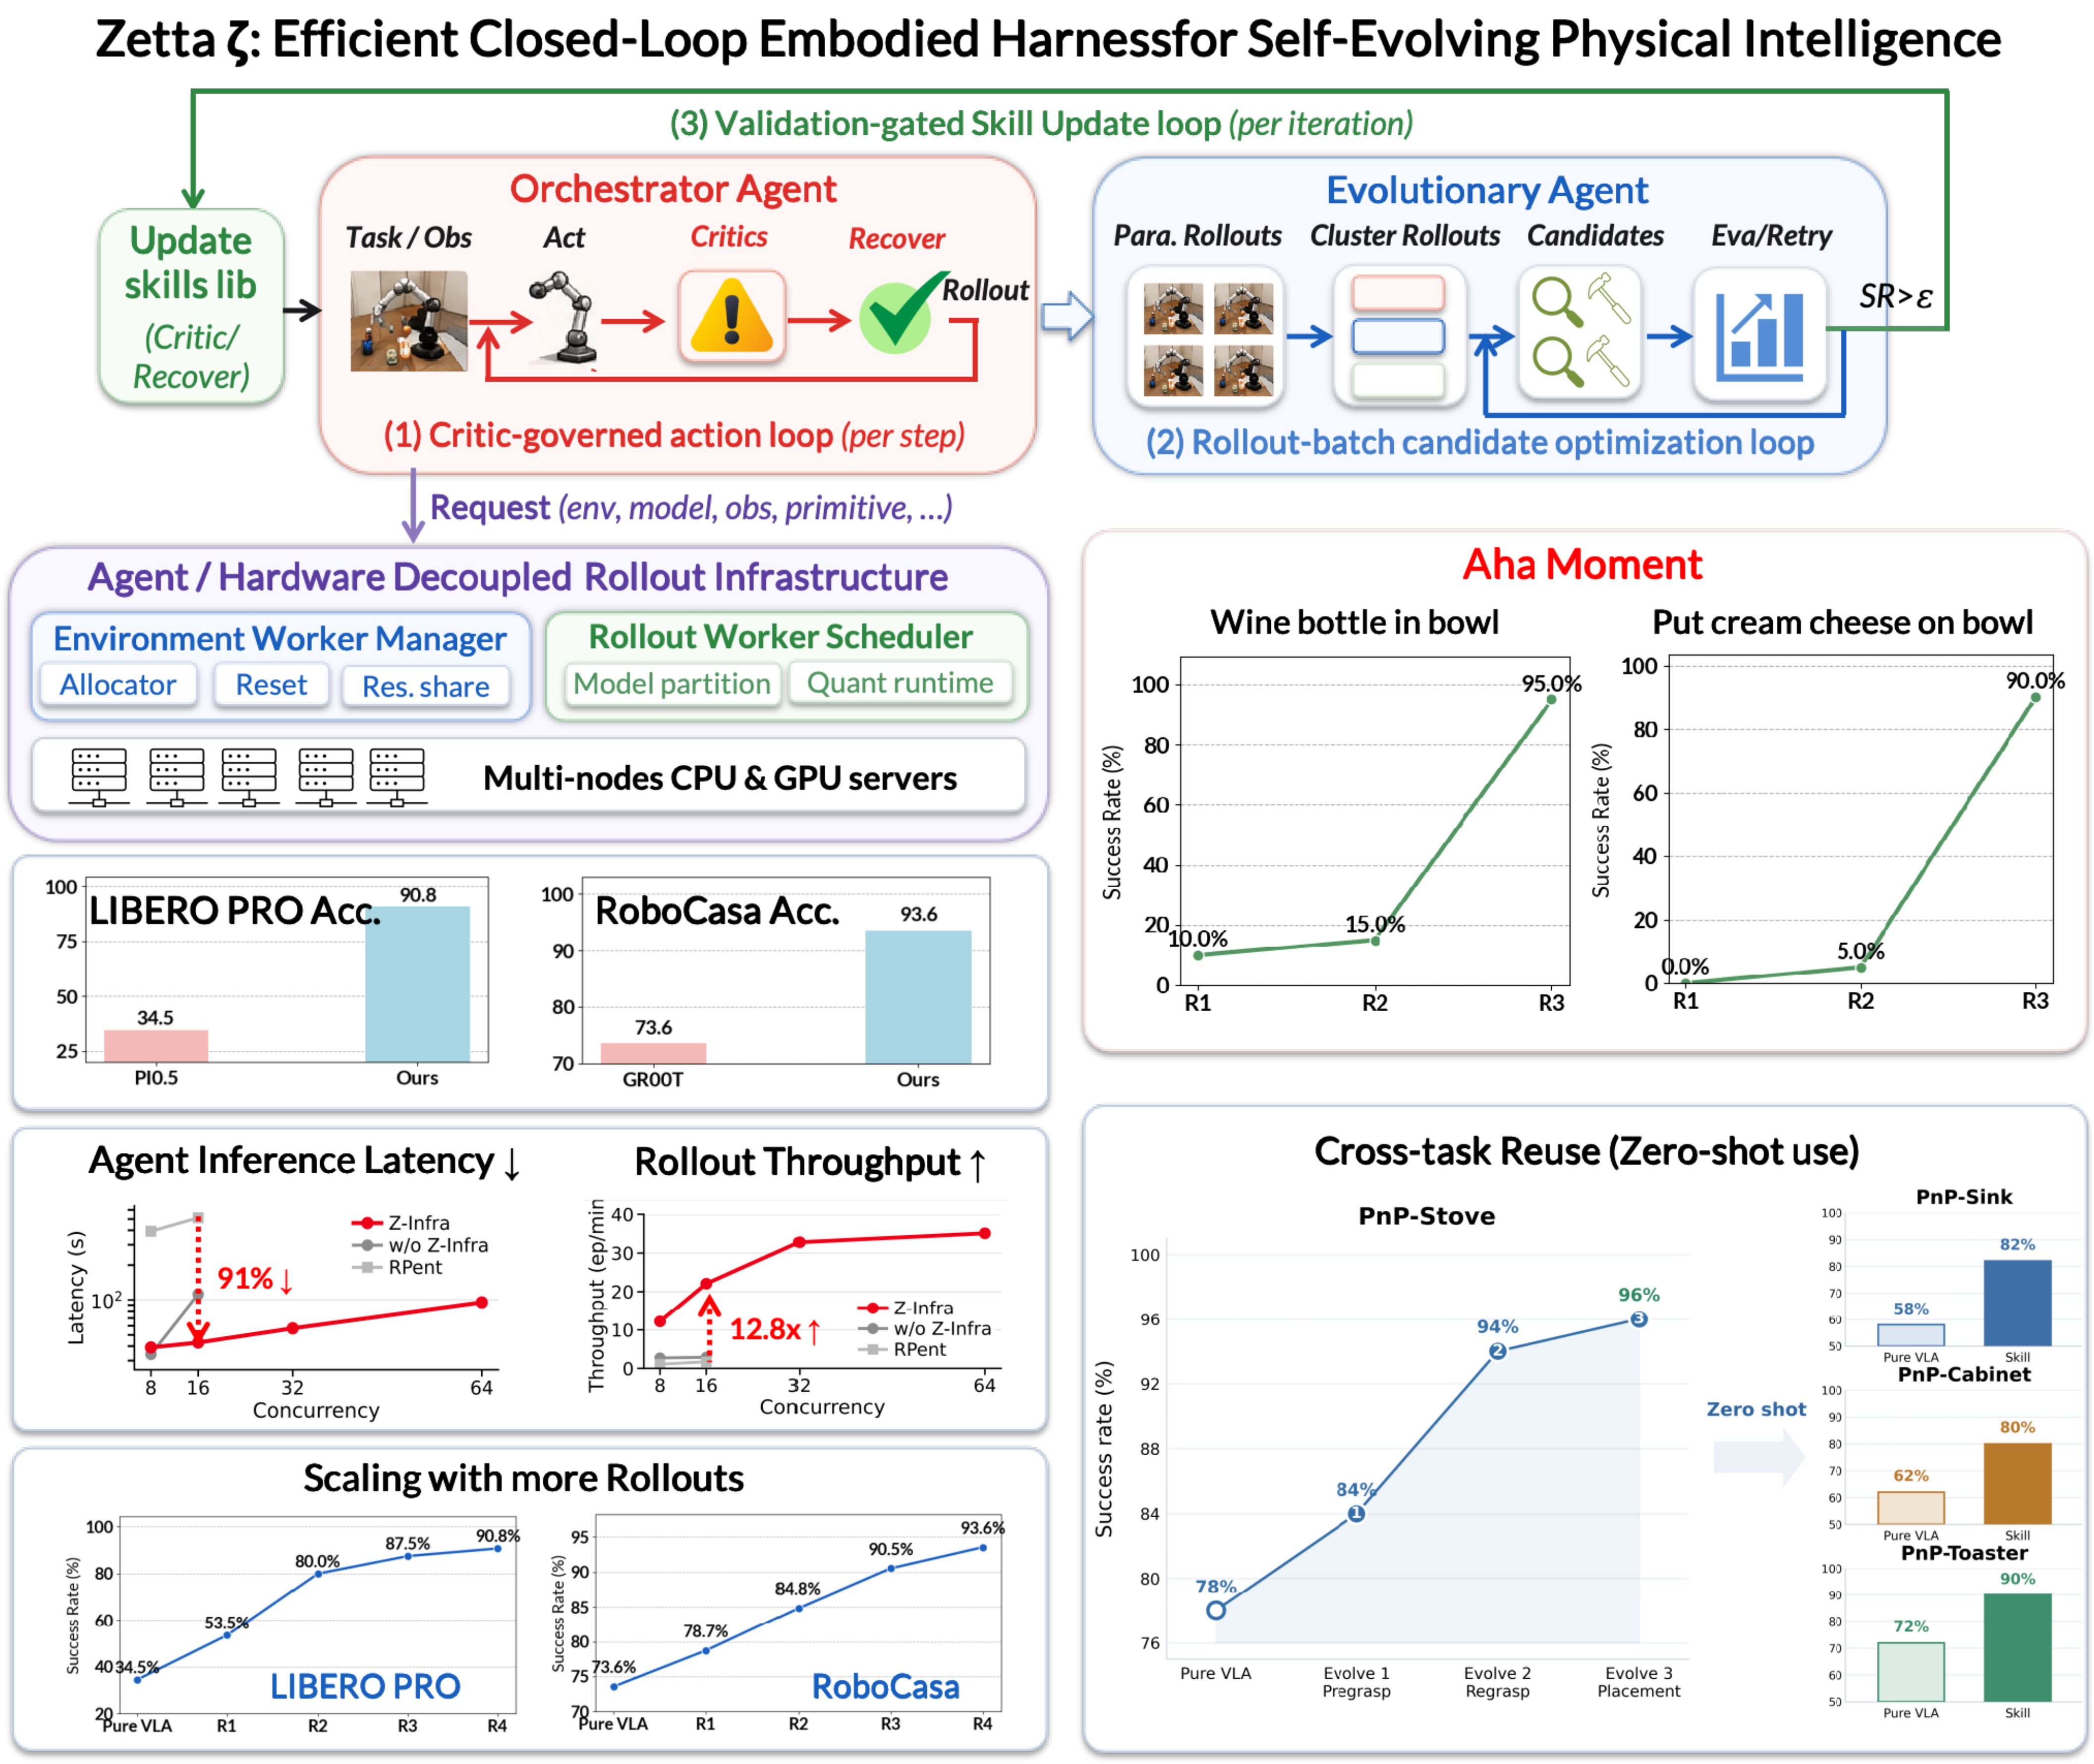
1.3Kair-embodied-brain/Zetta-Embodiment · PythonZetta is a closed-loop embodied harness that evolves code-based runtime critics and recovery skills online while keeping the base robot policy frozen, reaching 90.8% success on LIBERO-Pro and 93.6% on RoboCasa with an 11.1x inference speedup.
- 53
openharness
1.3Kautonomous-ai/openharness · TypeScriptA command center for AI coding agents: Claude Code, Codex, Cursor, OpenCode and more, side by side across all your machines in one native window. Beyond code it reaches into CAD, circuits, robotics, games and music.
- 54
Microduck-build-tutorial
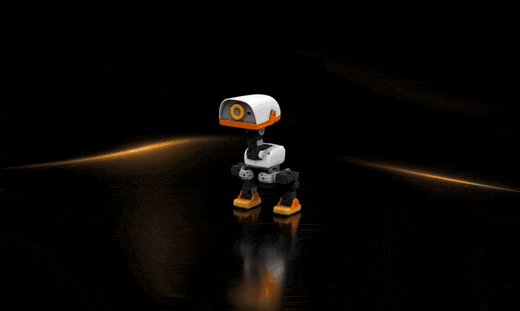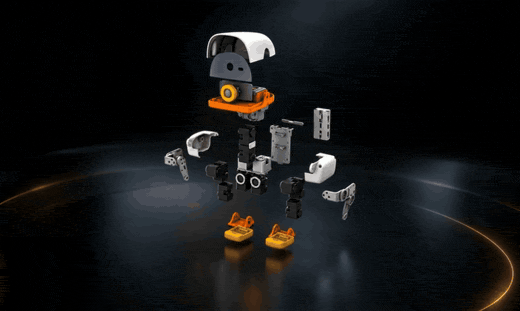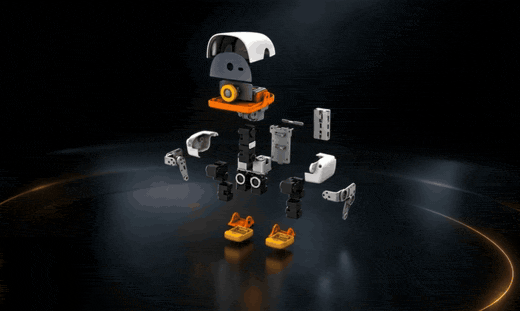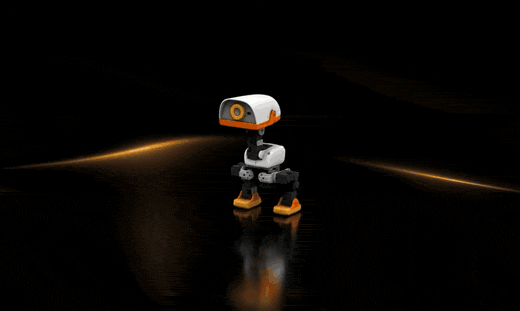
1.3KAI-FanGe/Microduck-build-tutorial · PythonMicroduck is a build tutorial and codebase for a compact biped (two-legged) robot: deployment code that runs on a Raspberry Pi Zero 2 W to drive Dynamixel servos using an ONNX reinforcement-learning walking policy, plus a MuJoCo/MjLab-based training environment to produce that policy.
- 55

microduck-replica
1.2Kfanhao375/microduck-replica · HTMLThis is a third-party reverse-engineering project that reconstructs the hardware of Pollen Robotics' Microduck bipedal robot duck - deriving assembly drawings, CAD files and a full electronics scheme from the official public MJCF simulation model and Rust source code, since the mechanical parts and one PCB were never officially open-sourced.
- 56
OpenWAM
1KOpenWAM-Official/OpenWAM · PythonOpenWAM is an open research stack for systematically building World-Action Models (WAMs) for robots, breaking the usual tightly-coupled design choices into modular, swappable components you can compare in controlled experiments.
- 57
FluxVLA
748FluxVLA/FluxVLA · PythonFluxVLA is a full-stack engineering platform for embodied AI covering the whole loop from data to real-robot deployment for vision-language-action (VLA) models, built to lower the engineering barrier for VLA research and development.
- 58
project_superdex
742facebookresearch/project_superdex · C++Project SuperDex is a unified simulation platform for dexterous manipulation research from Meta, combining a contact-first physics engine, robotics authoring tools, and a reinforcement learning interface, with VR-based teleoperation planned for Q4 2026.
- 59
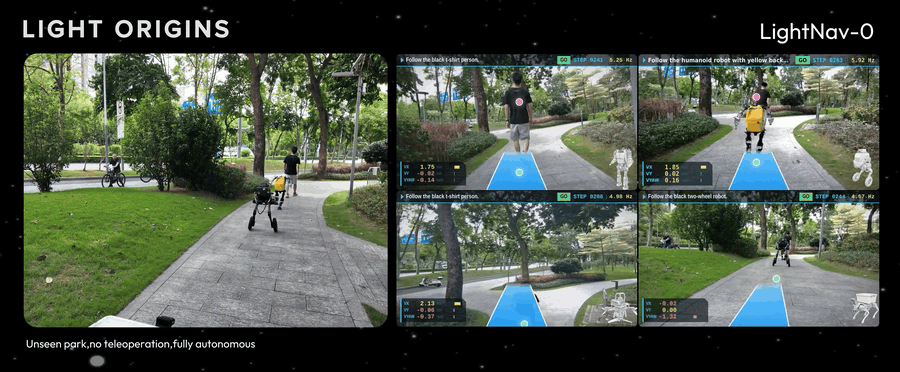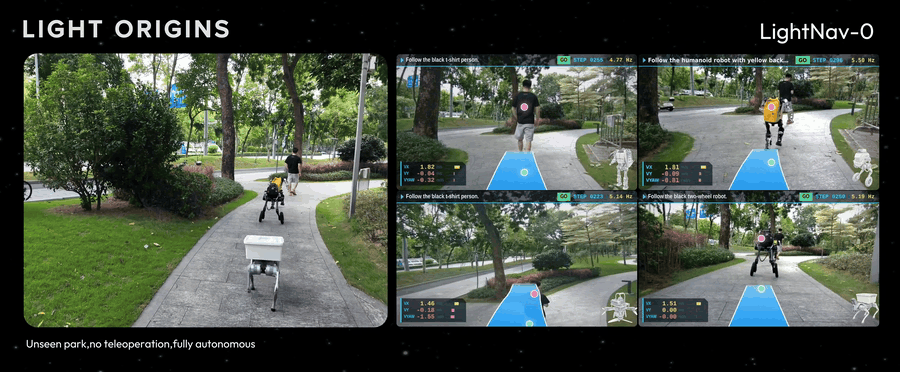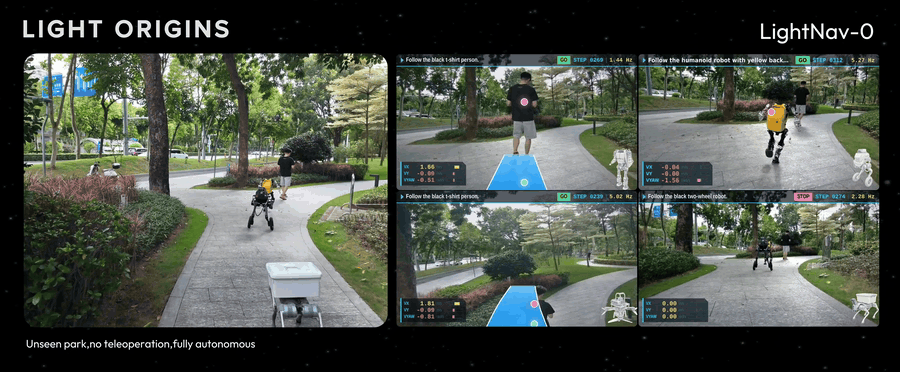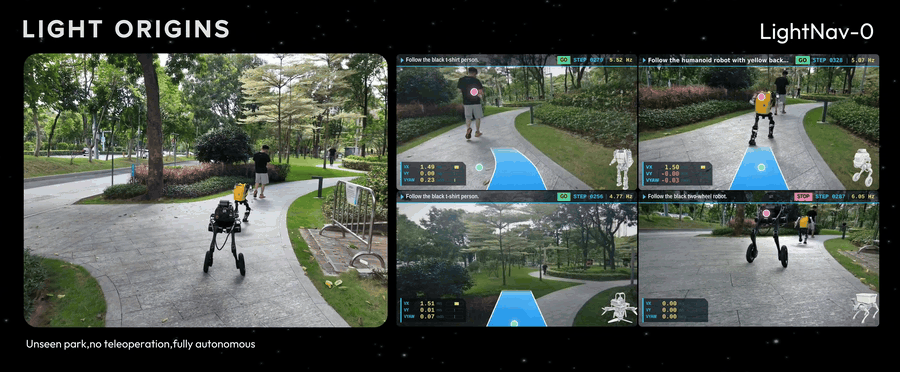
LightNav-0
721lightorigins/LightNav-0 · PythonLightNav-0 is a compact generalist embodied navigation model that gives humanoid, quadruped, wheeled and aerial robots the ability to follow language instructions and navigate autonomously in unseen environments, without any teleoperation.
- 60
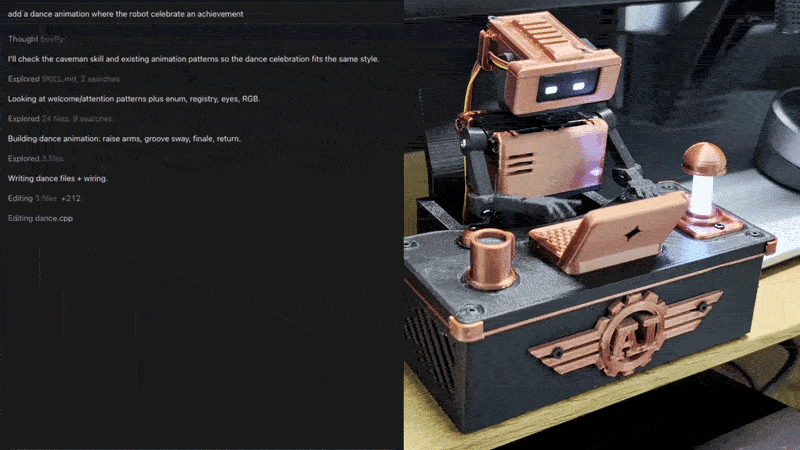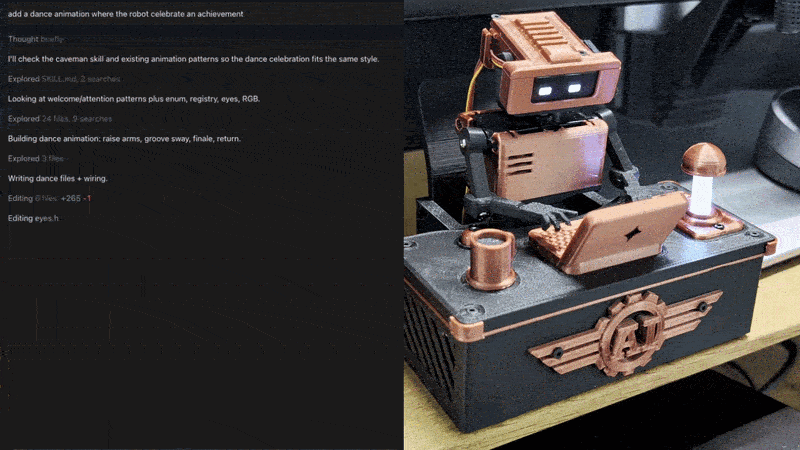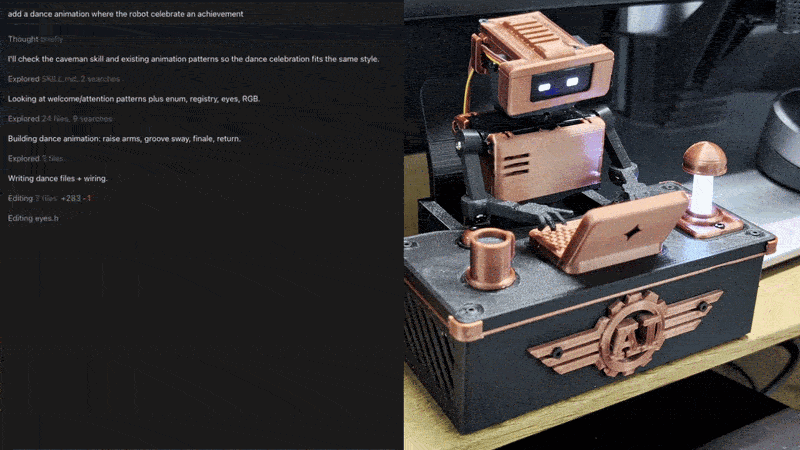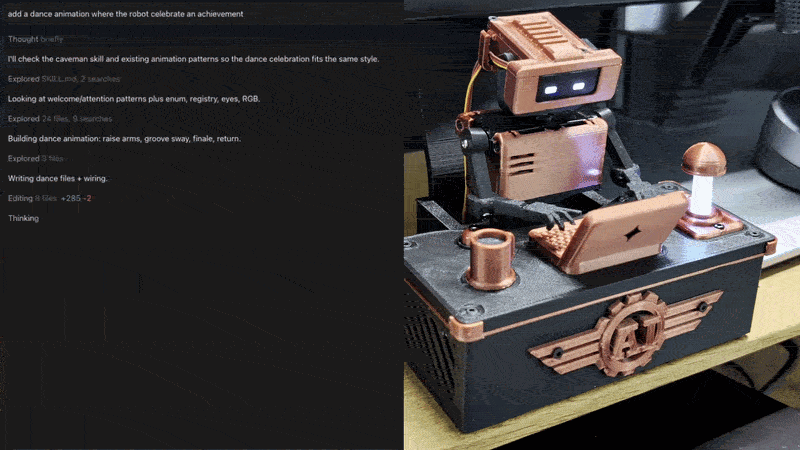
tiny-engineer
695jamro/tiny-engineer · C++Tiny Engineer is an open-source, 3D-printable desktop robot that physically acts out what your AI coding agent is doing — reading, thinking, writing code, and finishing tasks.
- 61
LoongForge
687baidu-baige/LoongForge · PythonAn open-source training framework from Baidu's Baige team for LLMs, VLMs, diffusion and embodied models, built for faster training and lower cost on NVIDIA GPUs and Kunlun XPUs.
- 62
Motus2
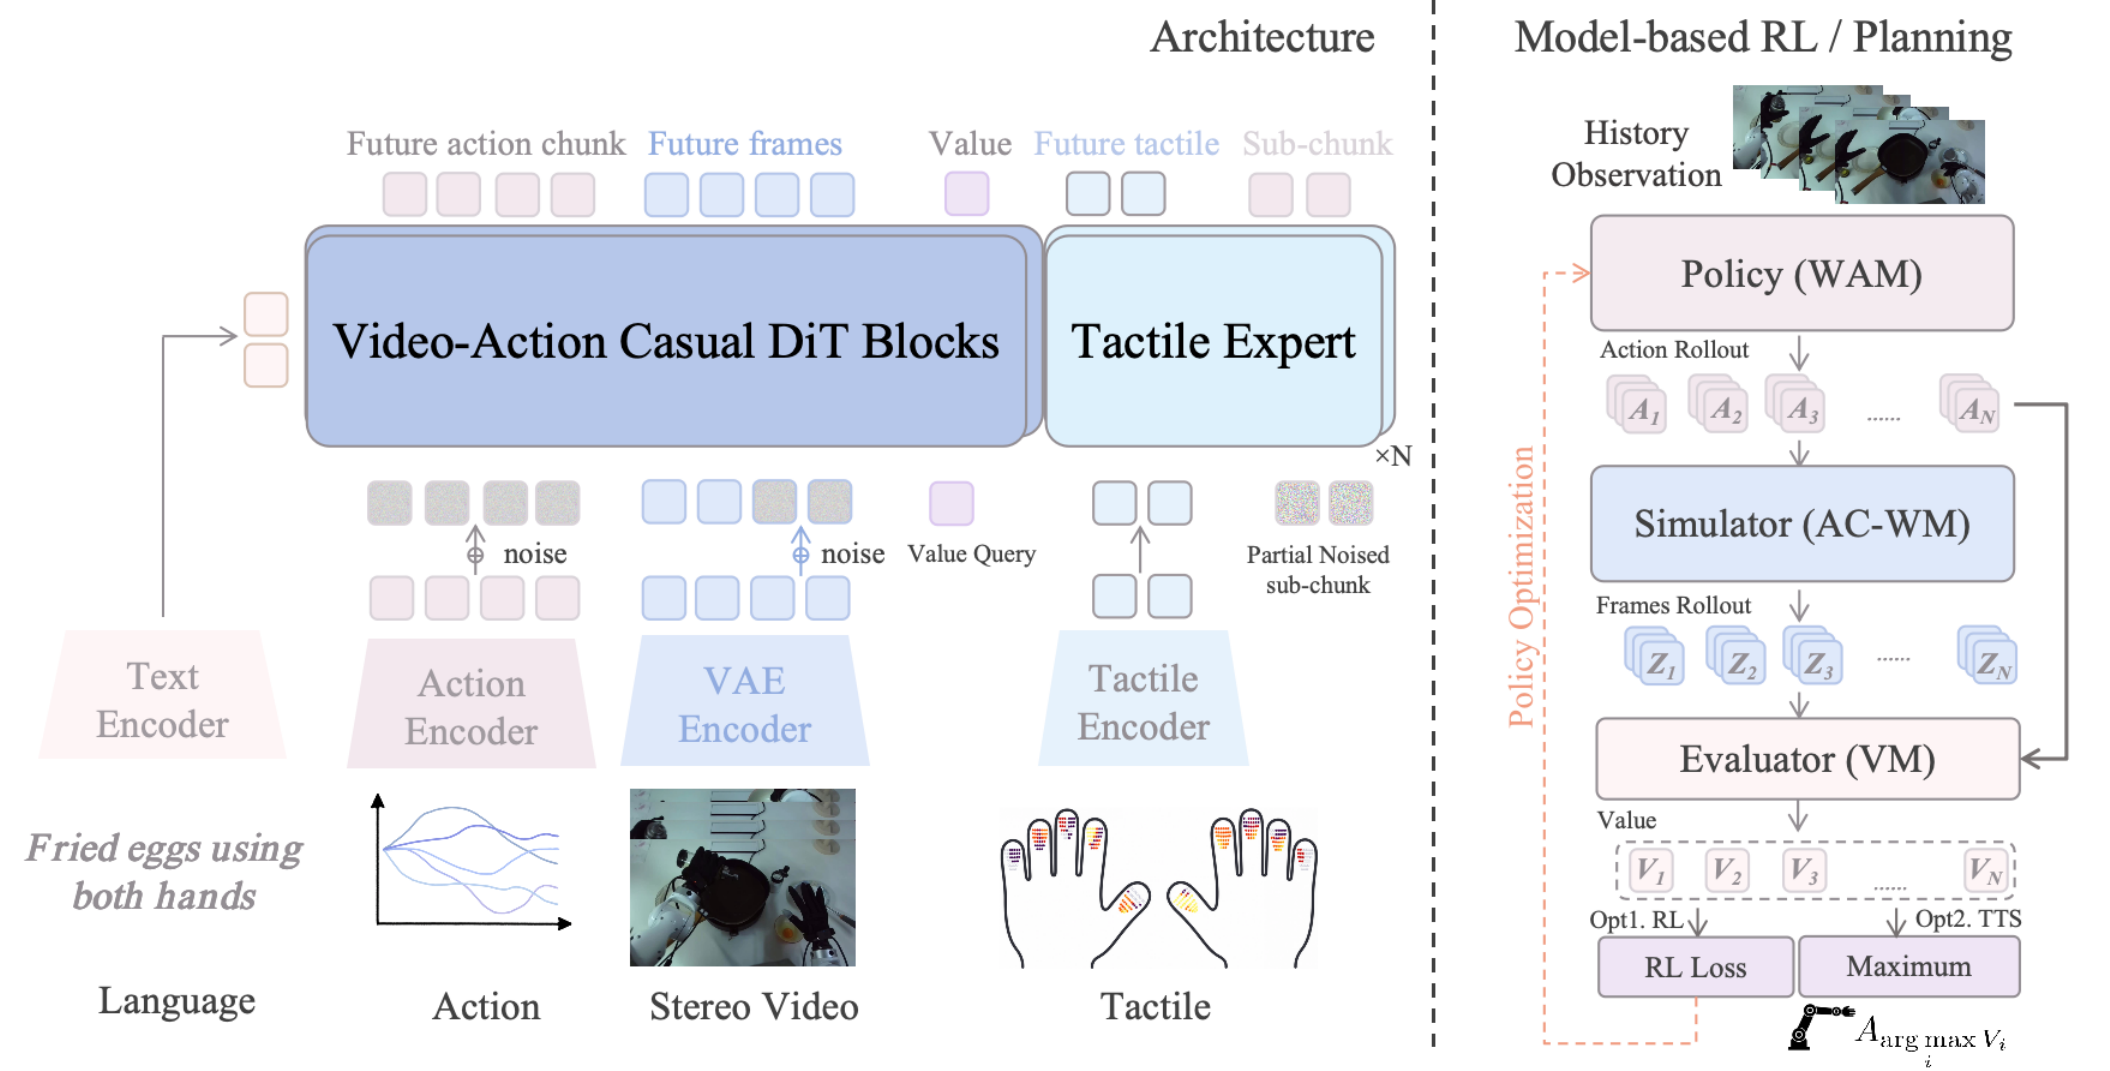
685shengshu-ai/Motus2Motus2 is a self-evolving general world model for dexterous robot manipulation. A single model with shared weights acts as a policy, a simulator, and an evaluator, coupling them into a closed decision-and-learning loop so the system can perceive, predict, act, and improve itself.
- 63
INSLIB
627jnz/INSLIB · CINSLIB is a portable C library for 3D navigation state estimation that fuses IMU data with GNSS/GPS, barometer, magnetometer and other sensors through Kalman filters, used in drones, robotics, cars and aerospace projects.
- 64

awesome-esp32
594s0lness/awesome-esp32A hand-picked, curated list of ESP32 microcontroller projects worth building, copying, or watching run, organized into finished applications and the tools/frameworks used to build them.
- 65

intrinsic-core
583intrinsic-ai/intrinsic-core · C++Intrinsic Core is an open, local runtime, SDK and hardware-agnostic real-time control framework for industrial robotics. It provides foundational building blocks for AI-enabled robot applications, from simulation and 6-DoF perception down to hardware execution.
- 66
WholebodyVLA
580OpenDriveLab/WholebodyVLAWholeBodyVLA is an ICLR 2026 research project introducing a unified Vision-Language-Action framework for closed-loop humanoid whole-body loco-manipulation control, and this repository doubles as a curated, continuously updated list of VLA papers for humanoid robots.
- 67
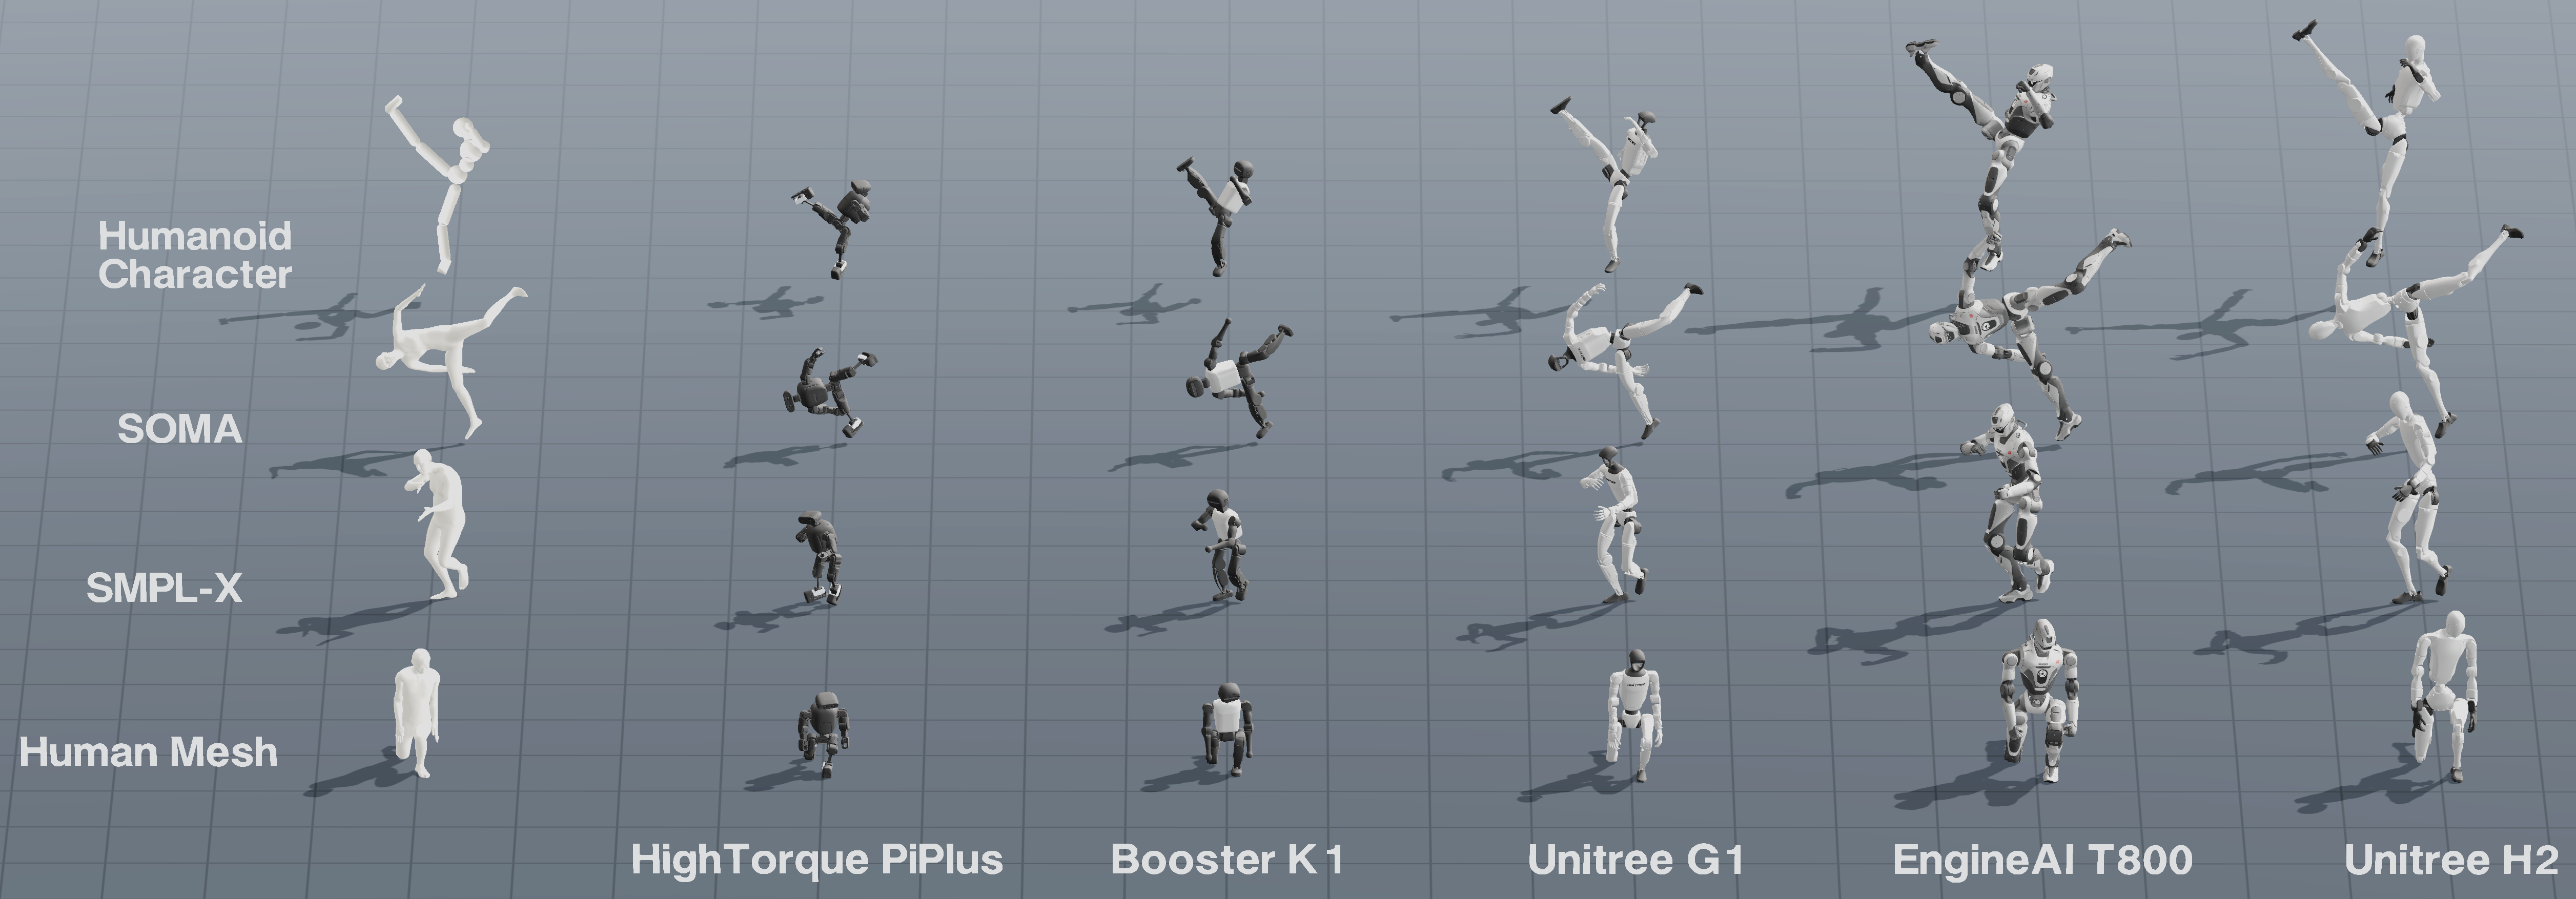
UMR
491hanyang9/UMR · PythonUMR (Unified Motion Retargeting) is a research codebase that retargets human motion onto humanoid robots by treating the moving exterior body surface as a shared interface between the source motion and the robot.
- 68
cadence
449muellerberndt/cadence · PythonCadence is an open research library toward general intelligence: a NumPy collection of 'brains' that compute by settling into an equilibrium and learn by detuning it, aiming to acquire skills from live experience the way animals and humans do.
- 69
Zero-WAM
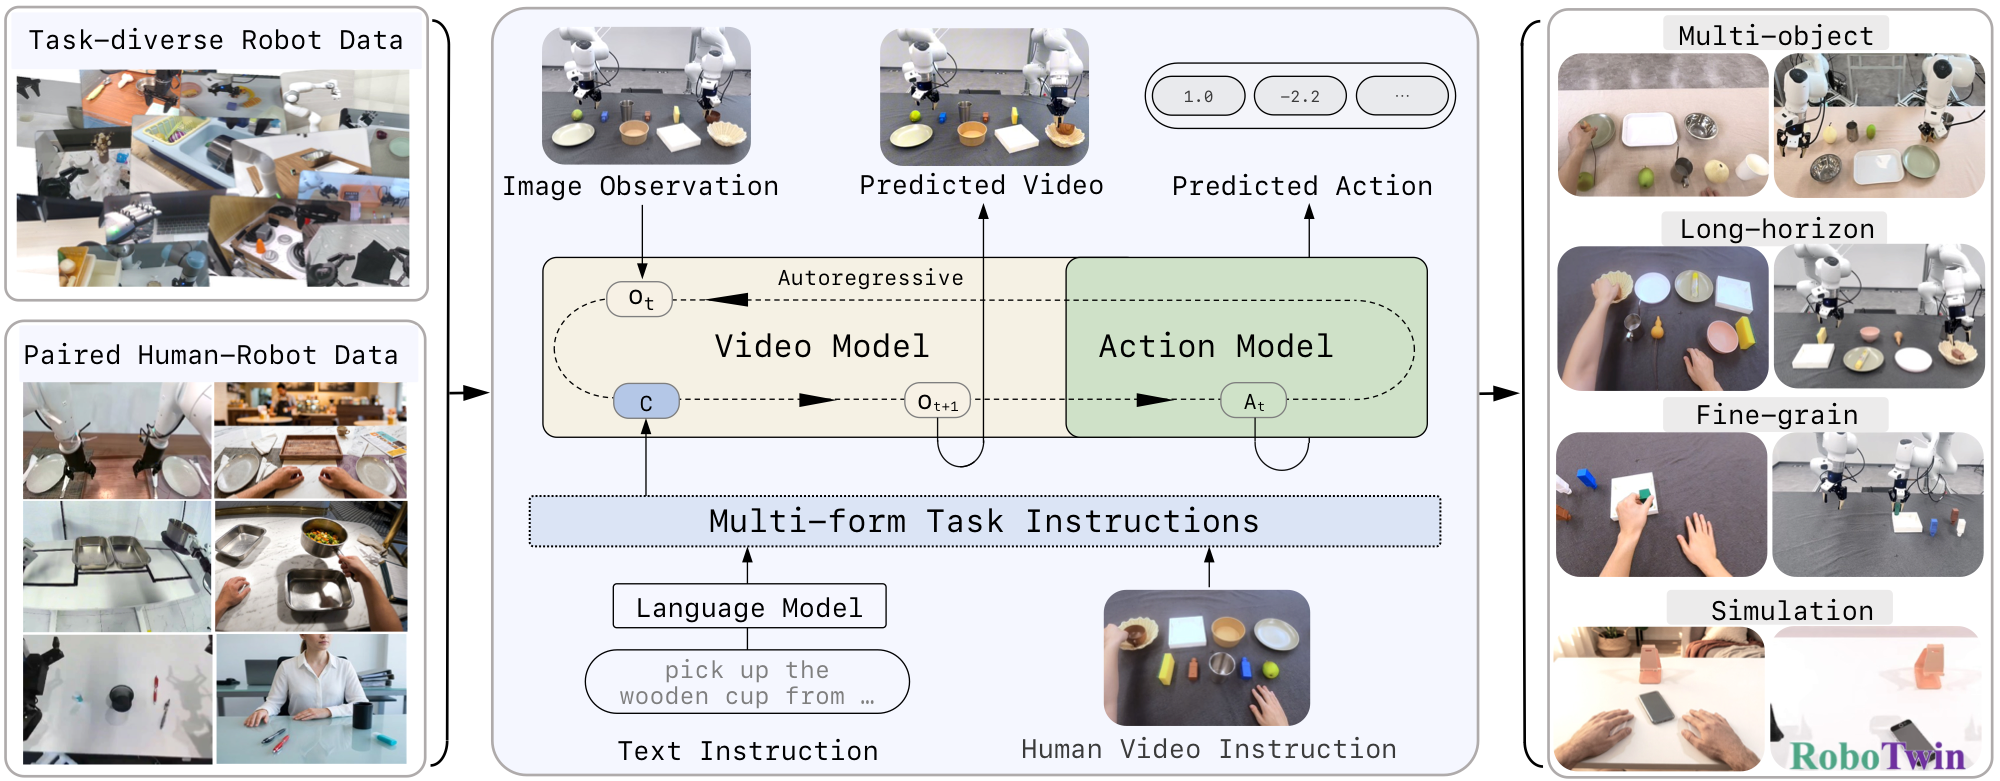
434robbyant-research/Zero-WAM · PythonZero-WAM is a research method for zero-shot cross-task robotic manipulation: a causal video-action policy that learns in-context world-action modeling, predicting future robot observations and executable actions from either language instructions or human demonstration videos.
- 70
Procedura
402SpatiaOS/Procedura · TypeScriptProcedura is an agentic 3D modeling pipeline that turns a text prompt (and optionally a reference image) into an editable procedural program — a parametric script with named parts joined by typed mates — written by an LLM, with optional per-part PBR materials and articulation exported to OpenUSD/URDF.
- 71
EasyWAM
401OpenMOSS/EasyWAM · PythonEasyWAM is a unified research codebase for training, fine-tuning, and evaluating World Action Models (WAMs) — models that jointly predict future video and robot actions for embodied-AI and robotics research.
- 72

motion-bricks.cpp
301localai-org/motion-bricks.cpp · C++A C++23/GGML port of NVIDIA MotionBricks: a neural network that turns keyframe commands into skeletal character animations, for games and robots. It runs on CPU or Vulkan and exposes a stable C API.
- 73
hflow
300Hebbian-Robotics/hflow · PythonHFlow is an open source SDK from Hebbian Robotics (YC S26) for building scalable multimodal data pipelines for robotics and physical AI, letting teams verify the quality of the data they use to train AI models.
- 74
RoboICL
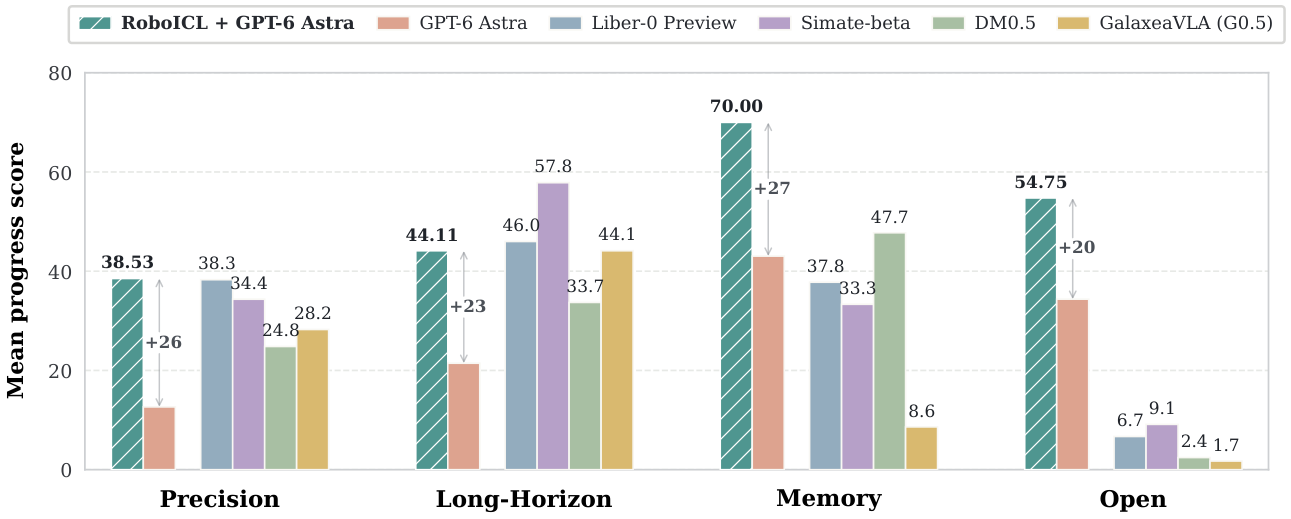
271Mosi-AI/RoboICL · PythonRoboICL is a research framework that lets a frozen, general-purpose vision-language model (GPT-6 Astra) control a robot in simulation purely through in-context learning, without training a dedicated robot policy.
- 75
autumn-recruitment
267Akun-python/autumn-recruitment · Jupyter NotebookIt is a community-built, Chinese-language collection of Jupyter notebooks covering math foundations, data structures, machine learning, deep learning, LLMs, agents, AI infrastructure, speech, and data science, aimed at job-hunting ('autumn recruitment') interview prep in the LLM era.
- 76

quackd
263rokbenko/quackd · Pythonquackd is an open-source daemon that gives small robots a brain: it takes a goal in plain language and plans the right sequence of the robot's own existing skills to carry it out, using an LLM like Claude, OpenAI, Gemini, Grok or a local model.
- 77
wuji-ego-mint
258wuji-technology/wuji-ego-mint · PythonMINT is a unified deep learning model that takes ordinary egocentric RGB video and directly predicts world-space camera motion and two-hand (MANO) motion, replacing the usual calibration + depth + SLAM + hand-reconstruction pipeline with a single pass.
- 78
video-prediction-policy-2
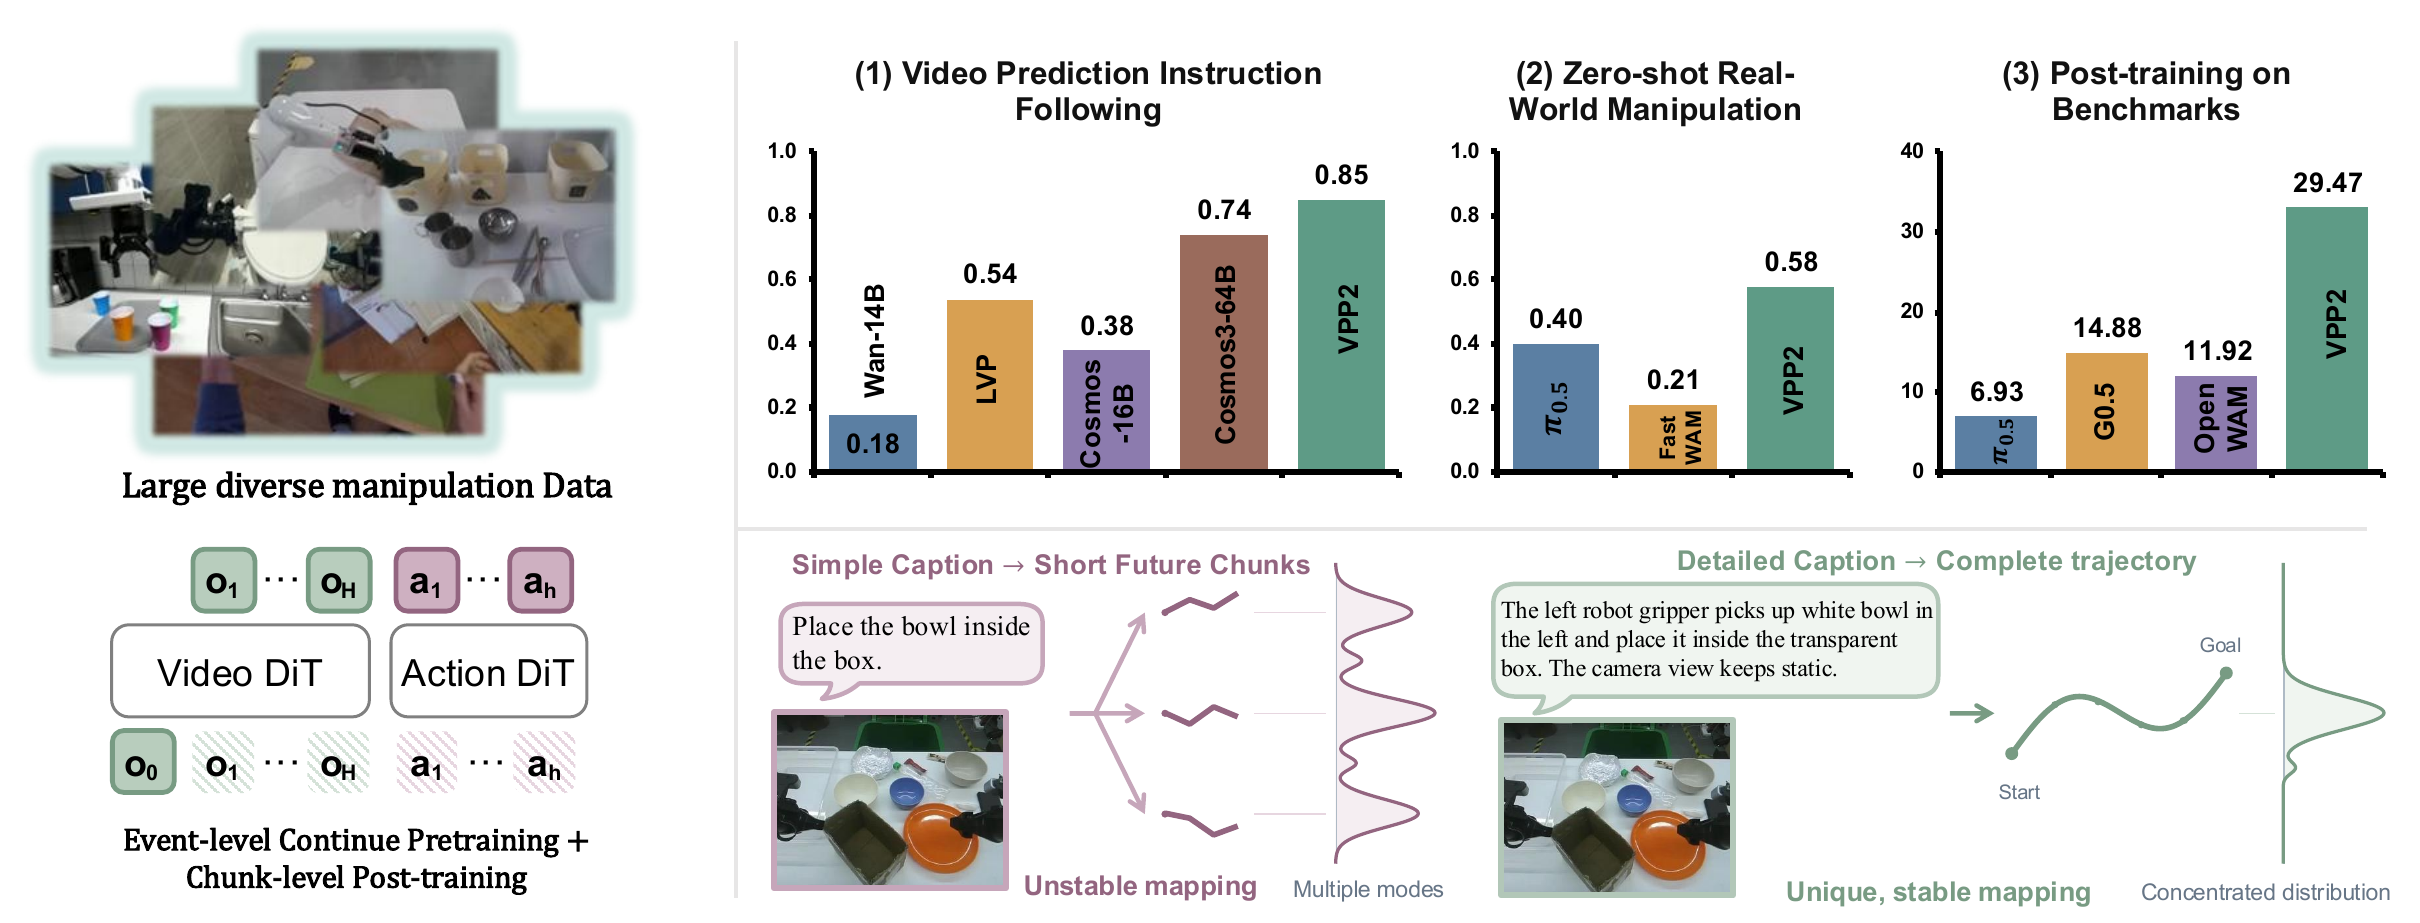
257roboterax/video-prediction-policy-2 · PythonVideo Prediction Policy 2 (VPP2) is a world-action model (WAM) for robot manipulation that predicts future video frames and converts them into robot actions, with strong zero-shot generalization across tasks.
- 79
RoboHarness
247BinceQu/RoboHarness · PythonRoboHarness is a training-free harness that gives an LLM agent a visual-geometric control panel: the model marks points of interest on 2D images, which get tracked and turned into geometric constraints so the LLM can directly compose and execute embodied manipulation actions.
- 80
flex-pi
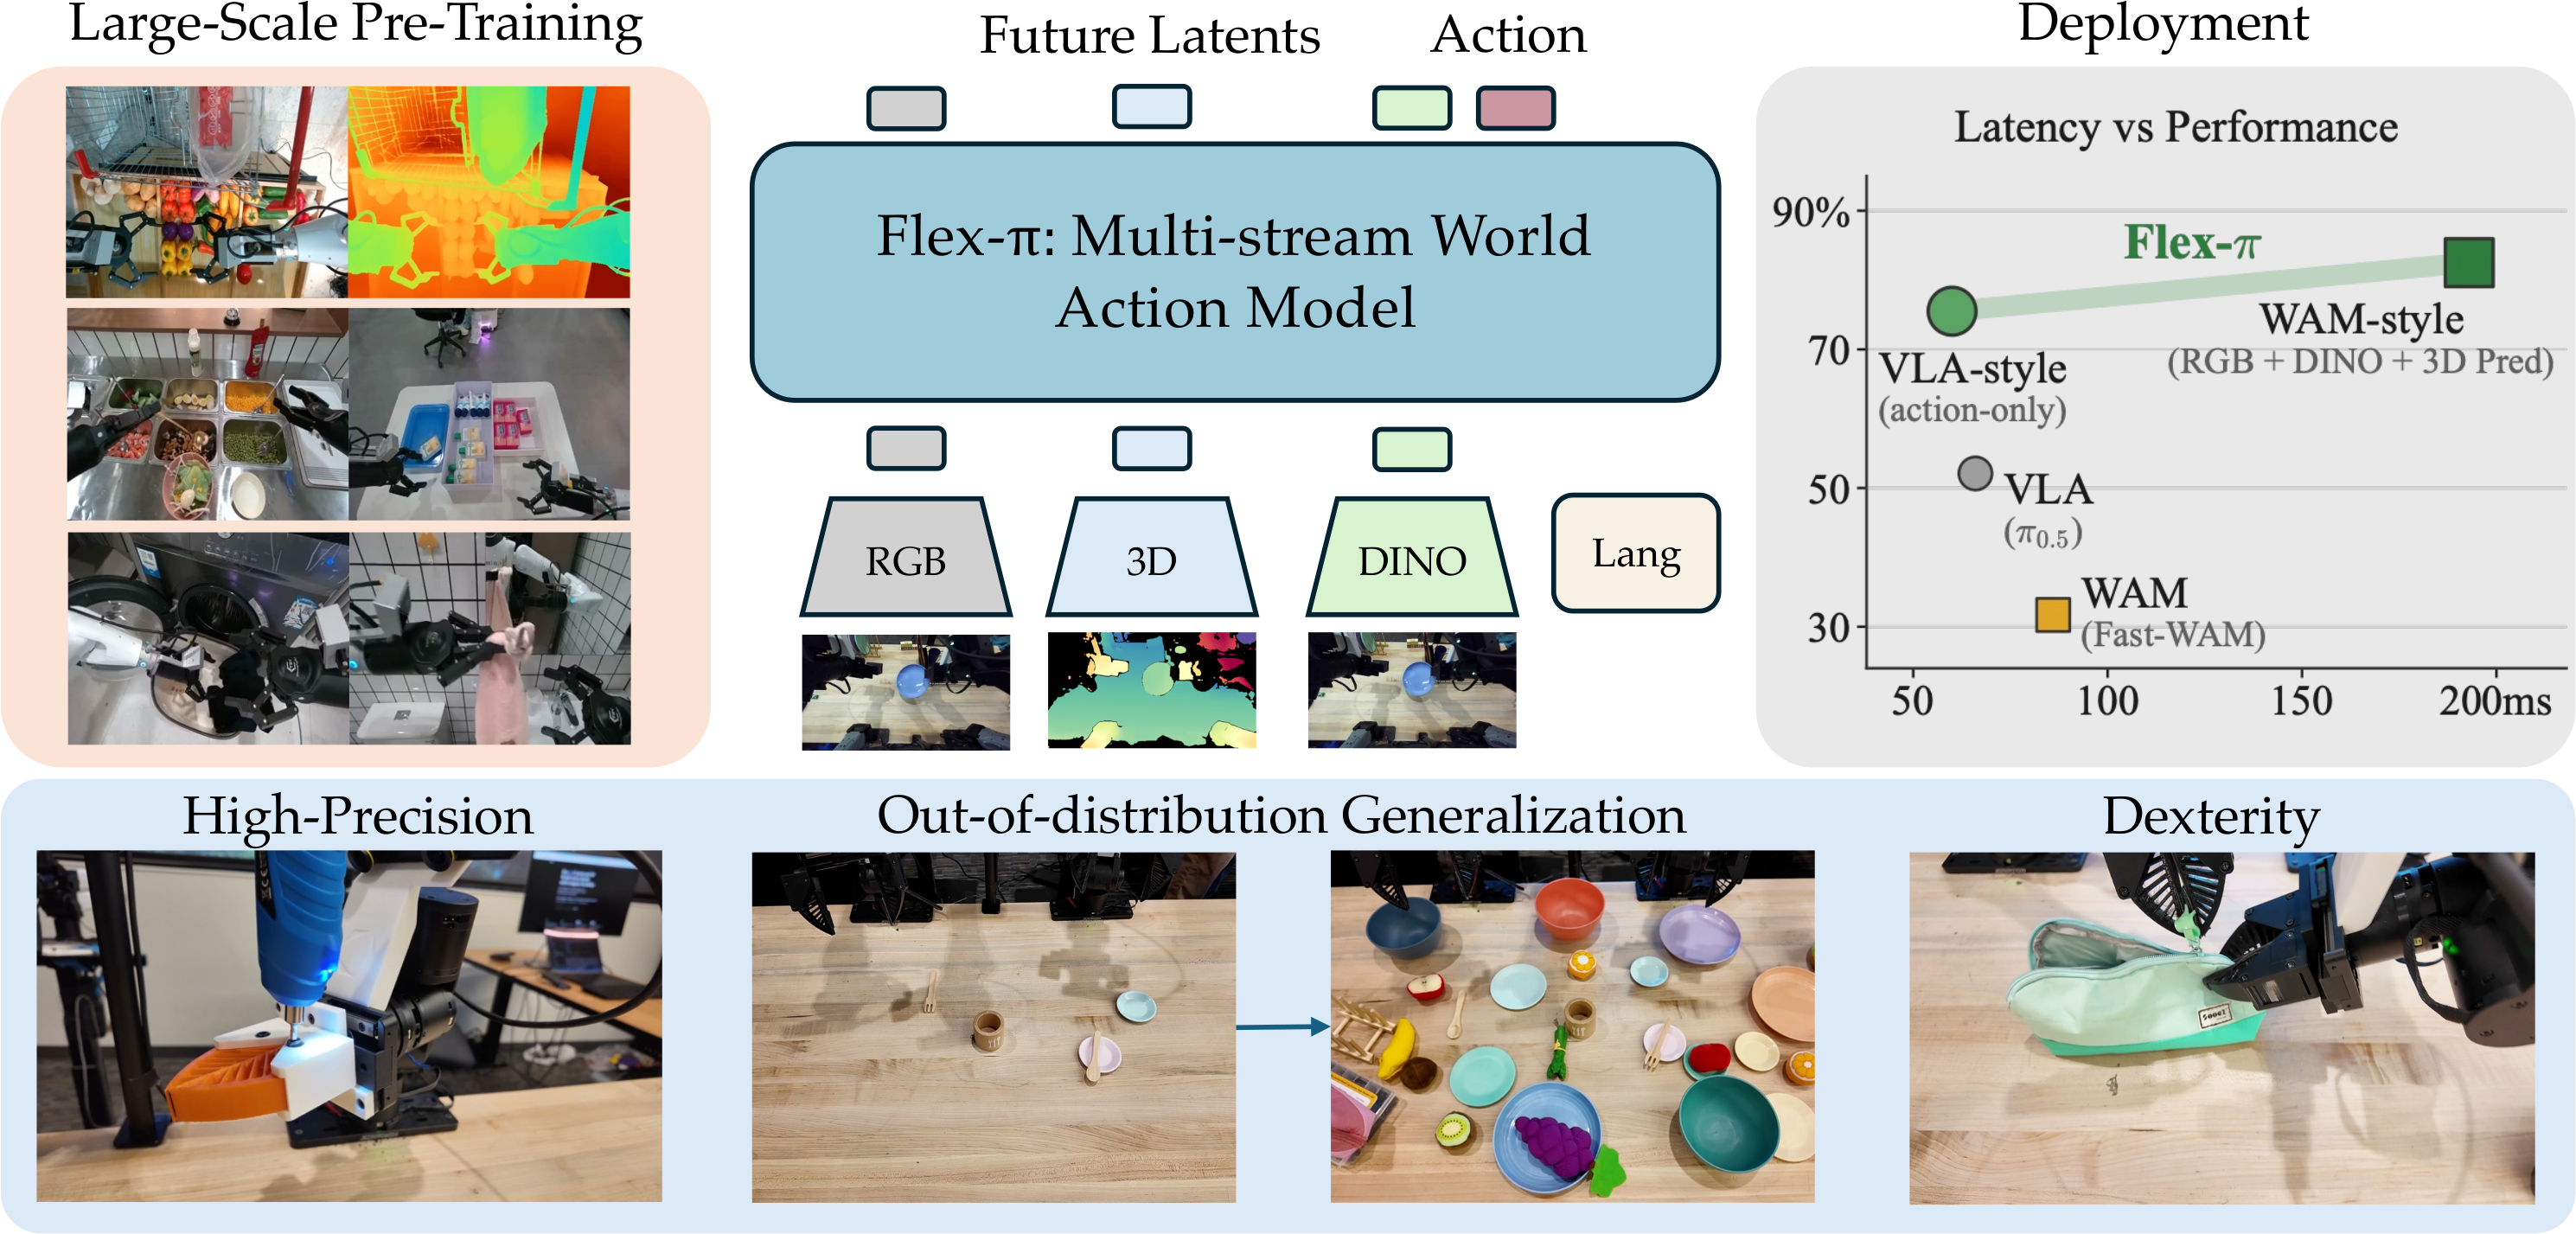
225geyan21/flex-pi · PythonFlex-π is a 6B-parameter world-action model for robot manipulation that jointly predicts future RGB, 3D pointmaps, DINOv3 semantics, and actions from one checkpoint, so it can deploy as a VLA, a full world model, or anything in between.
- 81
StreamPI
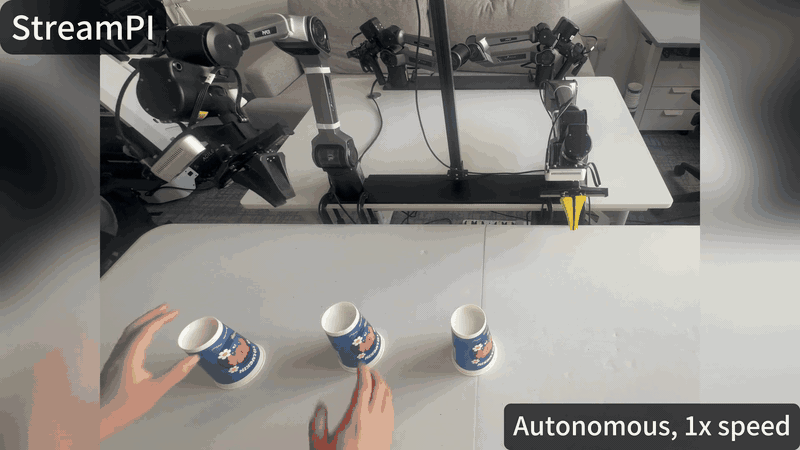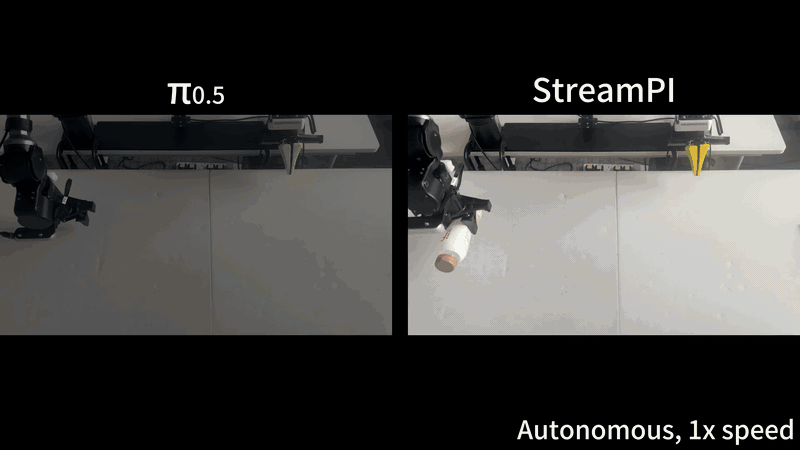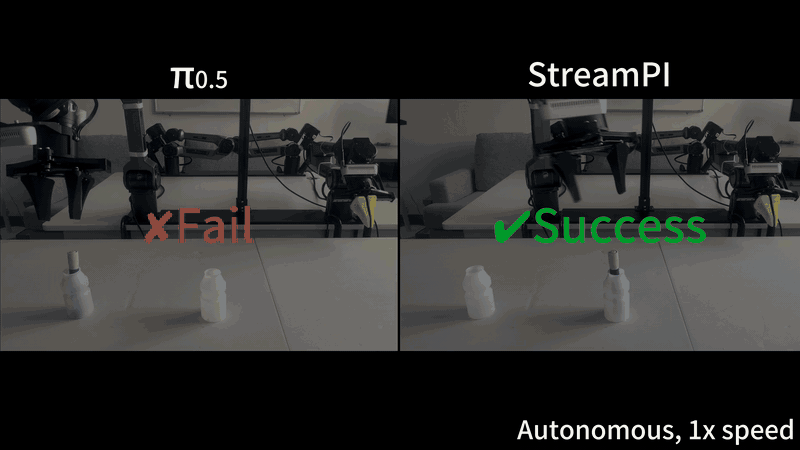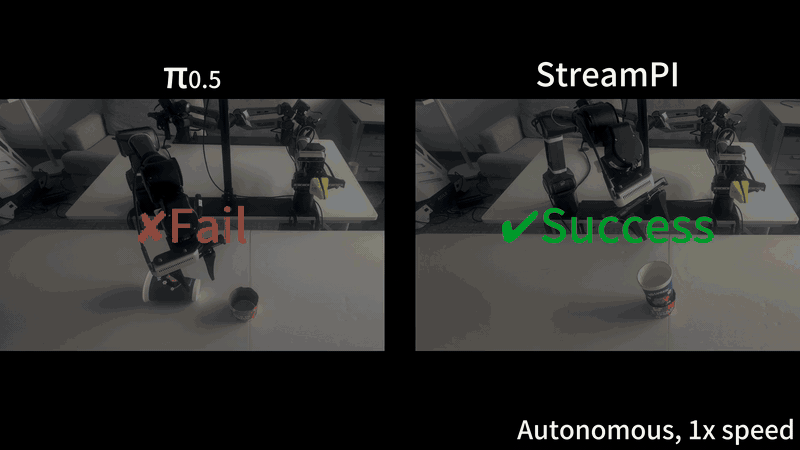
211hku-sail/StreamPI · PythonOfficial code of StreamPI (NeurIPS 2026, from HKU and ACE Robotics): a streaming temporal modeling framework that gives VLA robot policies like pi0.5 memory of past frames and multi-frame perception without adding any new parameters.
- 82
InstinctFlash
200General-Instinct/InstinctFlash · PythonInstinctFlash is a high-performance serving runtime for robotics foundation models - it loads checkpoints like GR00T, Cosmos3, pi0.5, LingBot-VA/VLA and DreamZero, applies acceleration (FP8, fused Triton kernels, caching) and serves them over Python or WebSocket, reporting up to 33.78x speedup on Jetson Thor.
- 83
Embodied-AI-Start
199ppsdk/Embodied-AI-StartA Chinese-language 'Embodied AI Starter Map' that organizes a learning path from robotics fundamentals (coordinates, kinematics, ROS 2) up to VLA policies, World Models, model-based RL and World Action Models (WAM), linking papers, code, benchmarks and practice guides at each step.
- 84
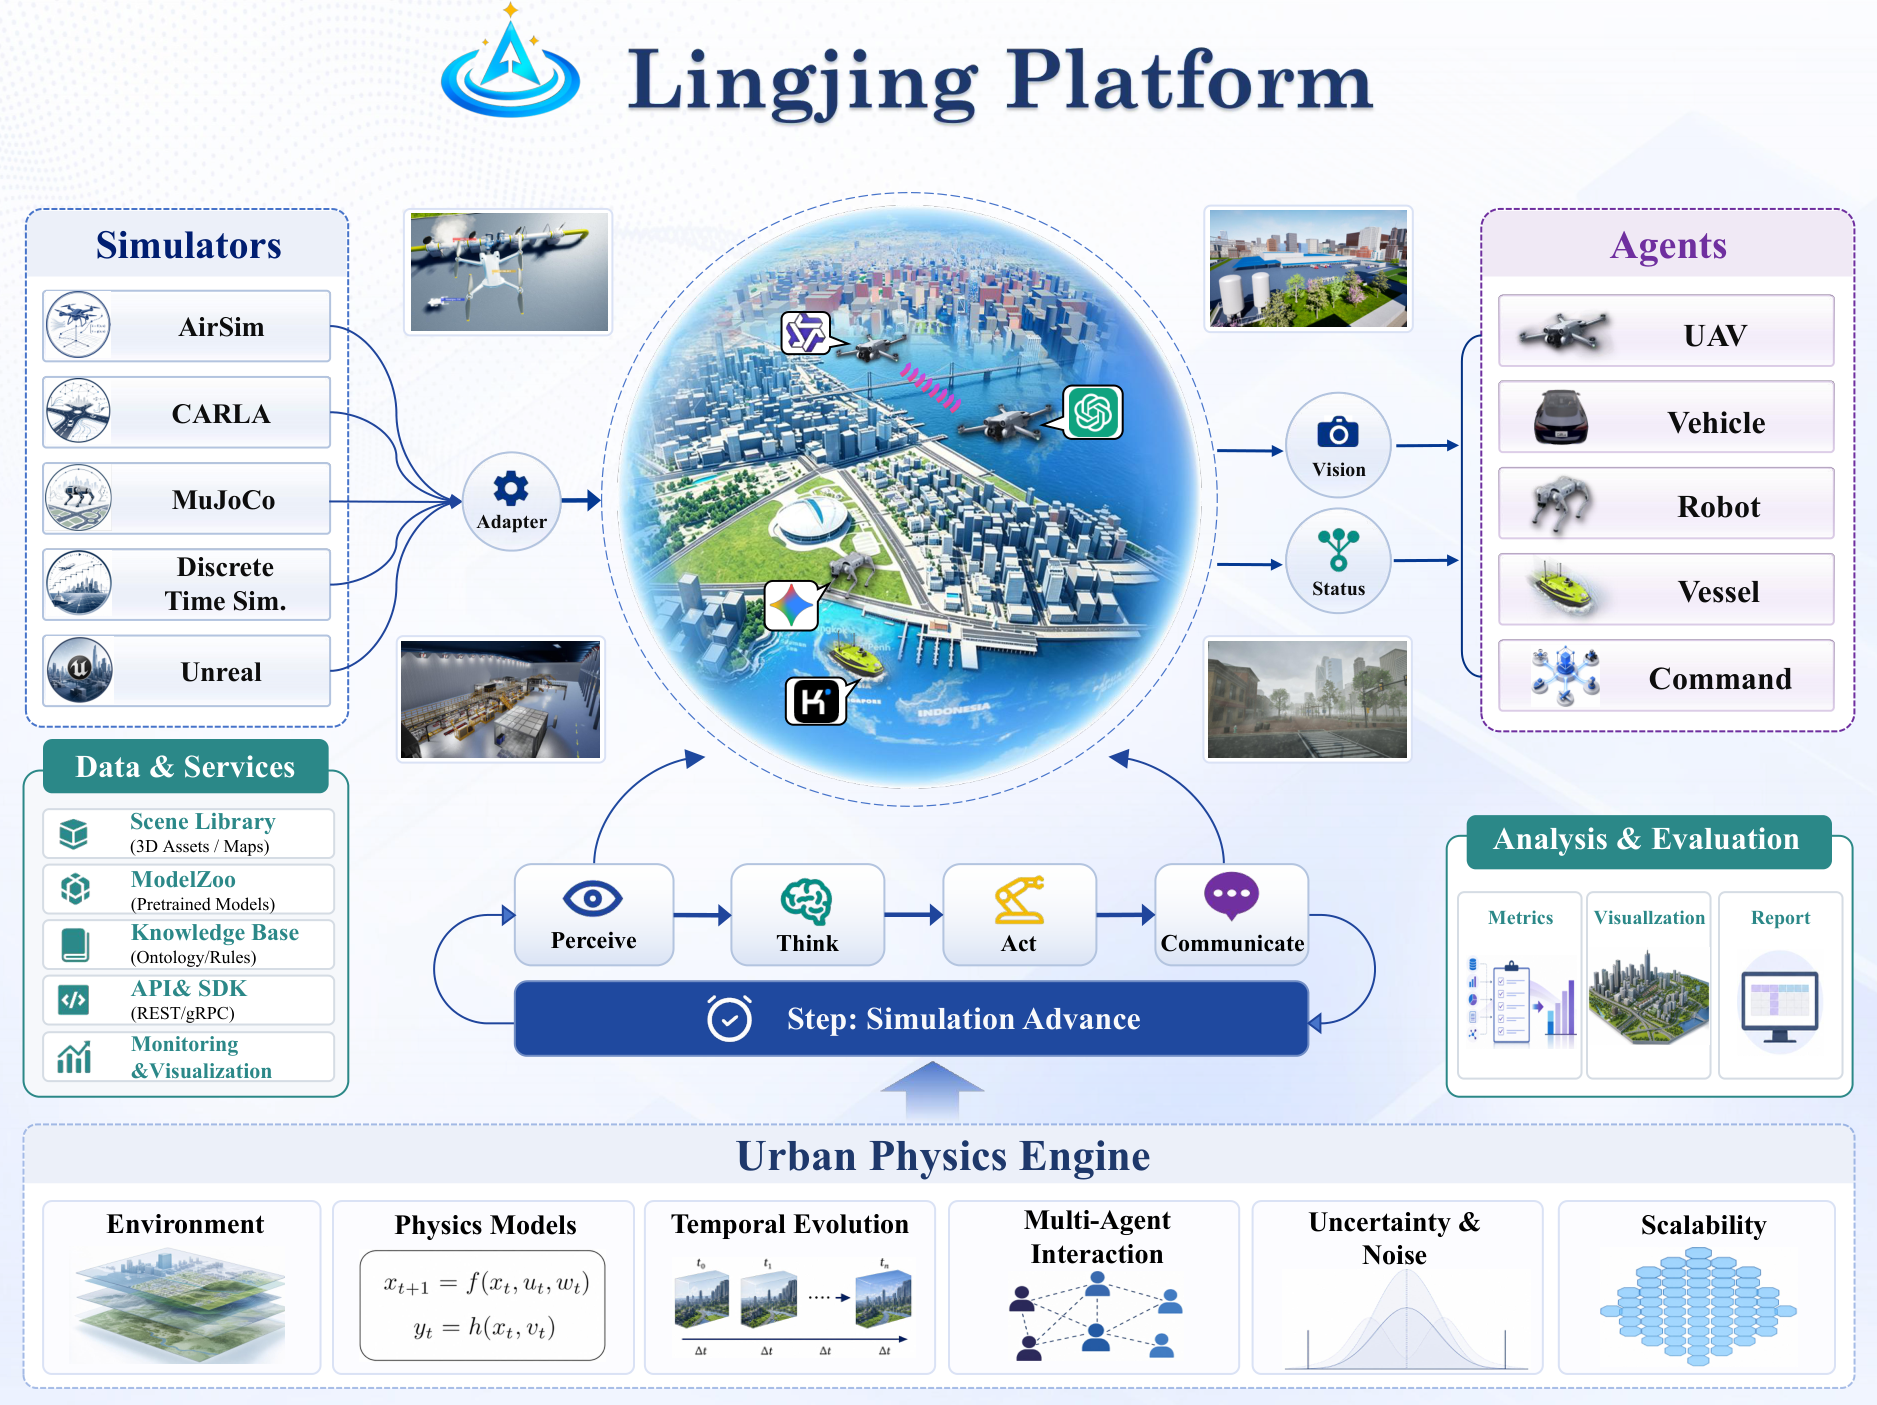
Air-Lingjing
194seanlxh/Air-Lingjing · PythonLingJing is an open simulation stack for LLM-driven embodied agents in large 3D environments: a FastAPI/LangGraph backend plus a Cesium-powered Unreal Engine 5.5 plugin, with runnable example cases.
- 85

swarm-agent
190lyt2003-yt/swarm-agent · PythonSwarmAgent is a conversational agent that turns natural-language requests like 'choreograph this song, make the second section gentler' into validated drone-swarm trajectories, built on the ReAct paradigm and sitting on top of a separately deployed SwarmGPT service.
- 86
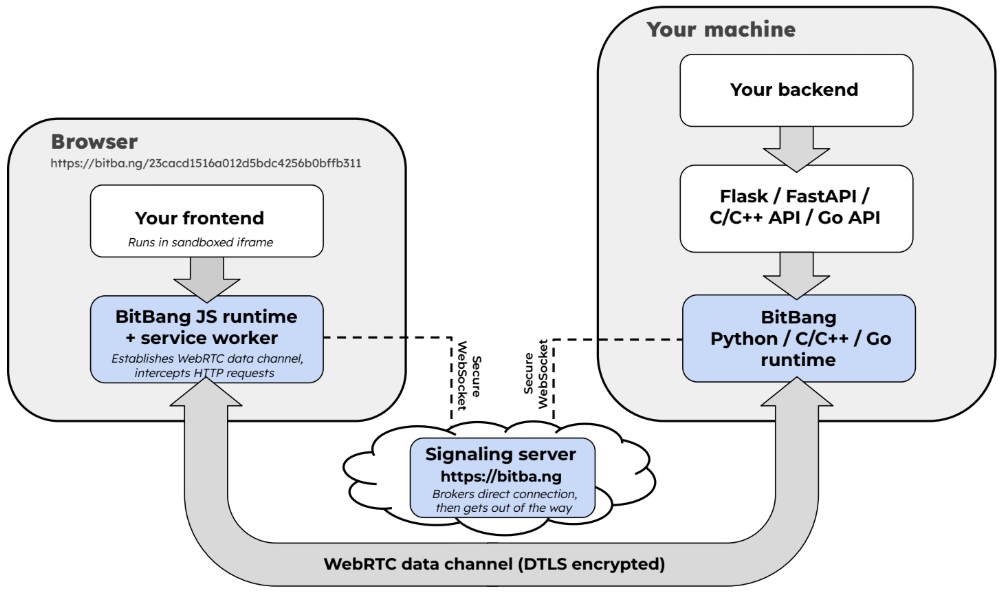
bitbang
184richlegrand/bitbangBitBang turns any machine into a URL: run it on the device, open the URL in any browser, and you are connected to that machine peer-to-peer with end-to-end encryption — no account, no port forwarding, nothing to install on the connecting side.
- 87
S-Space
174MirroS-Lab/S-Space · PythonS-Space is a research project that finds a three-dimensional linear subspace inside multimodal model activations which encodes object positions along horizontal, vertical, and distance axes, and shows it can be read out and even causally edited to change the model's spatial judgments.
- 88
dreamforge
130rzc156/dreamforge · PythonDreamforge is a research pipeline that mines a robot policy's own failure states, uses a latent world model (CEM) to imagine corrective actions, and verifies each correction by replaying it in the real simulator before claiming it helps.
Related topics
Often tagged together