Topics / #vla
Vla projects on GitHub
Vision-Language-Action models that map visual and text input to robot actions
As of , the most-starred Vla projects on GitHub are Zetta-Embodiment (1.3K stars), OpenWAM (1K stars) and LoongForge (687 stars). GitHub.Locker tracks 9 Vla repositories with 4.6K stars combined. The fastest-growing on October 16 was OpenWAM, with +2 stars in a day.
Hot right now
Most stars gained in a day · Oct 16
 +2
OpenWAM
OpenWAM-Official/OpenWAM · ★ 1KOpenWAM is an open research stack for systematically building World-Action Models (WAMs) for robots, breaking the usual tightly-coupled design choices into modular, swappable components you can compare in controlled experiments.
 +2
Zero-WAM
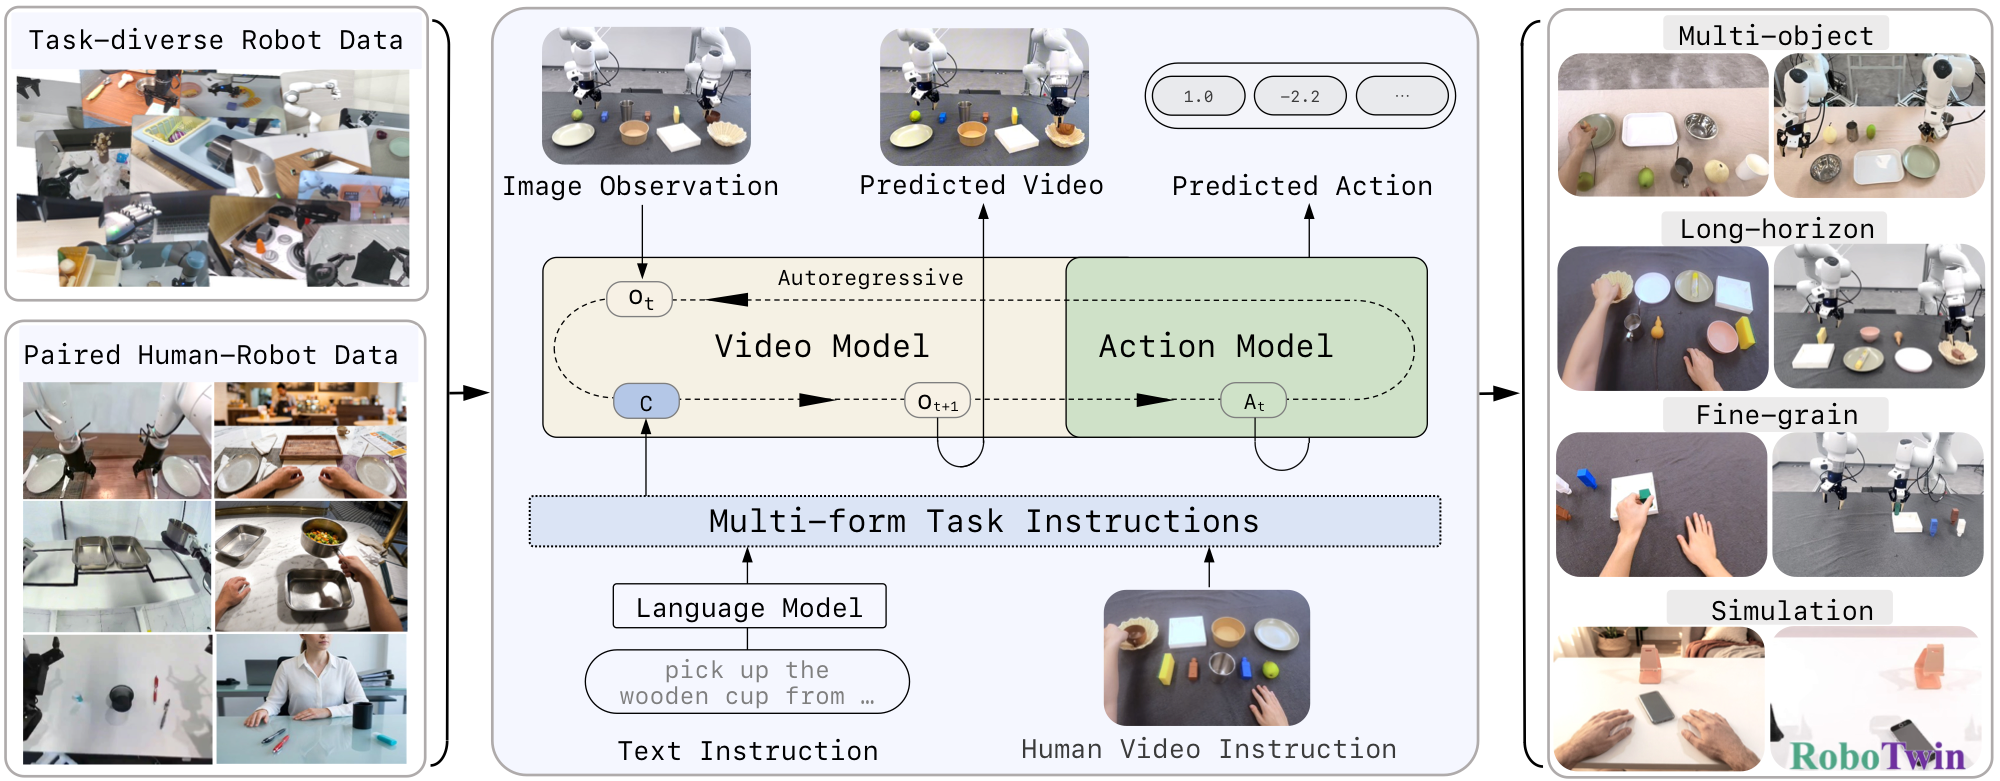
robbyant-research/Zero-WAM · ★ 434Zero-WAM is a research method for zero-shot cross-task robotic manipulation: a causal video-action policy that learns in-context world-action modeling, predicting future robot observations and executable actions from either language instructions or human demonstration videos.
 +1
RoboICL
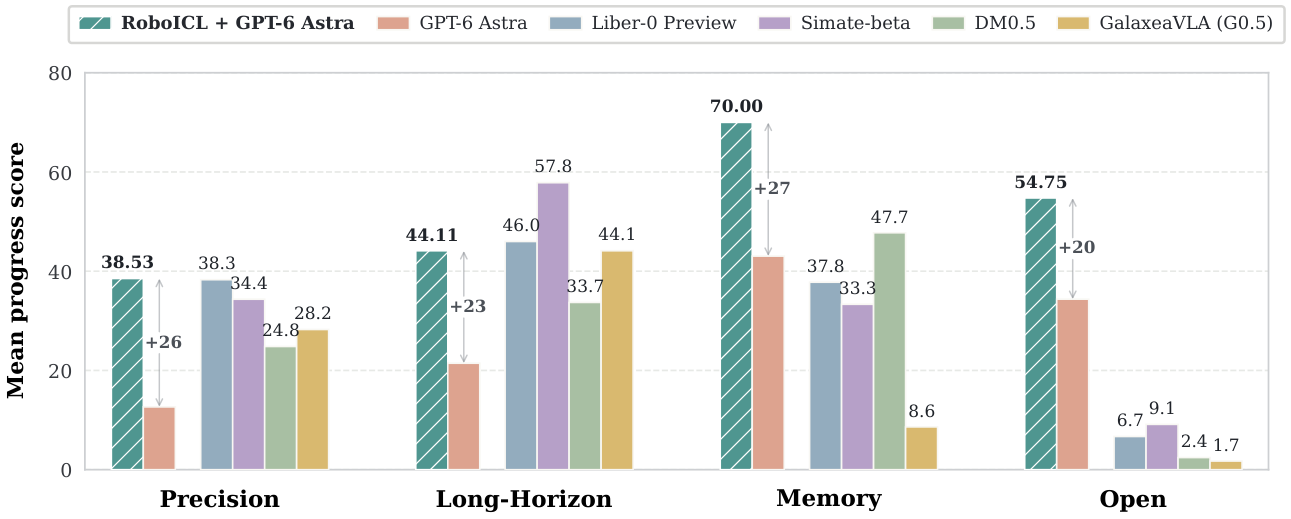
Mosi-AI/RoboICL · ★ 268RoboICL is a research framework that lets a frozen, general-purpose vision-language model (GPT-6 Astra) control a robot in simulation purely through in-context learning, without training a dedicated robot policy.
 +1
flex-pi
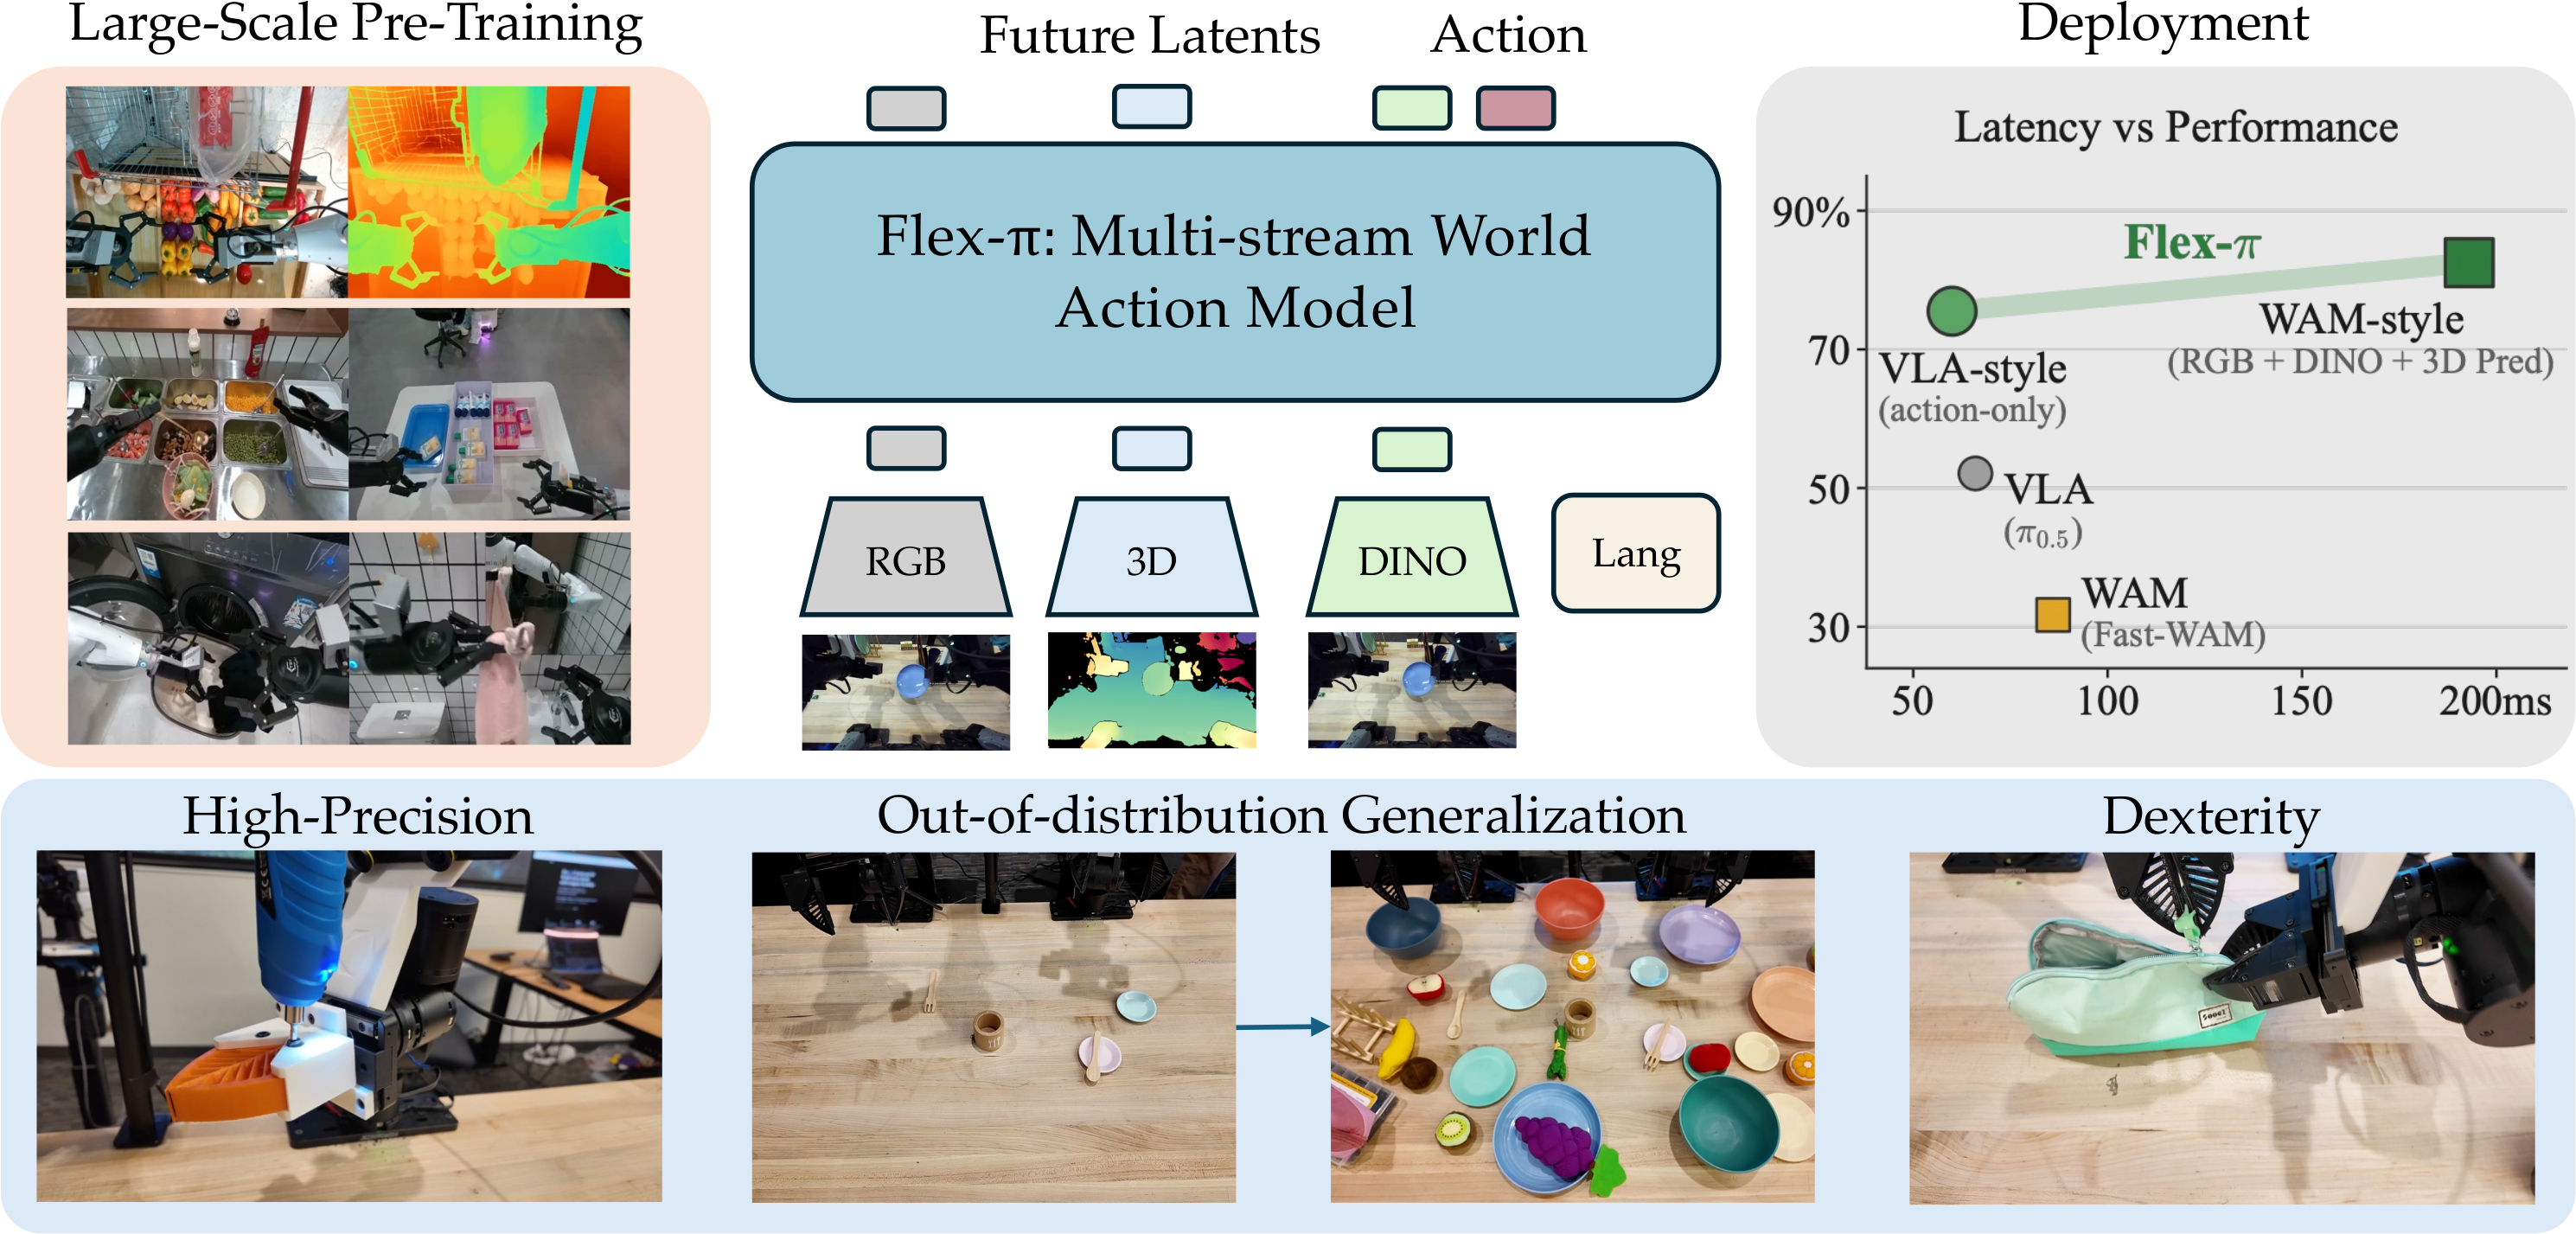
geyan21/flex-pi · ★ 225Flex-π is a 6B-parameter world-action model for robot manipulation that jointly predicts future RGB, 3D pointmaps, DINOv3 semantics, and actions from one checkpoint, so it can deploy as a VLA, a full world model, or anything in between.
The all-time top
9 projects · by stars
- 1.3K
 #1 · air-embodied-brain/Zetta-Embodiment
Zetta-Embodiment
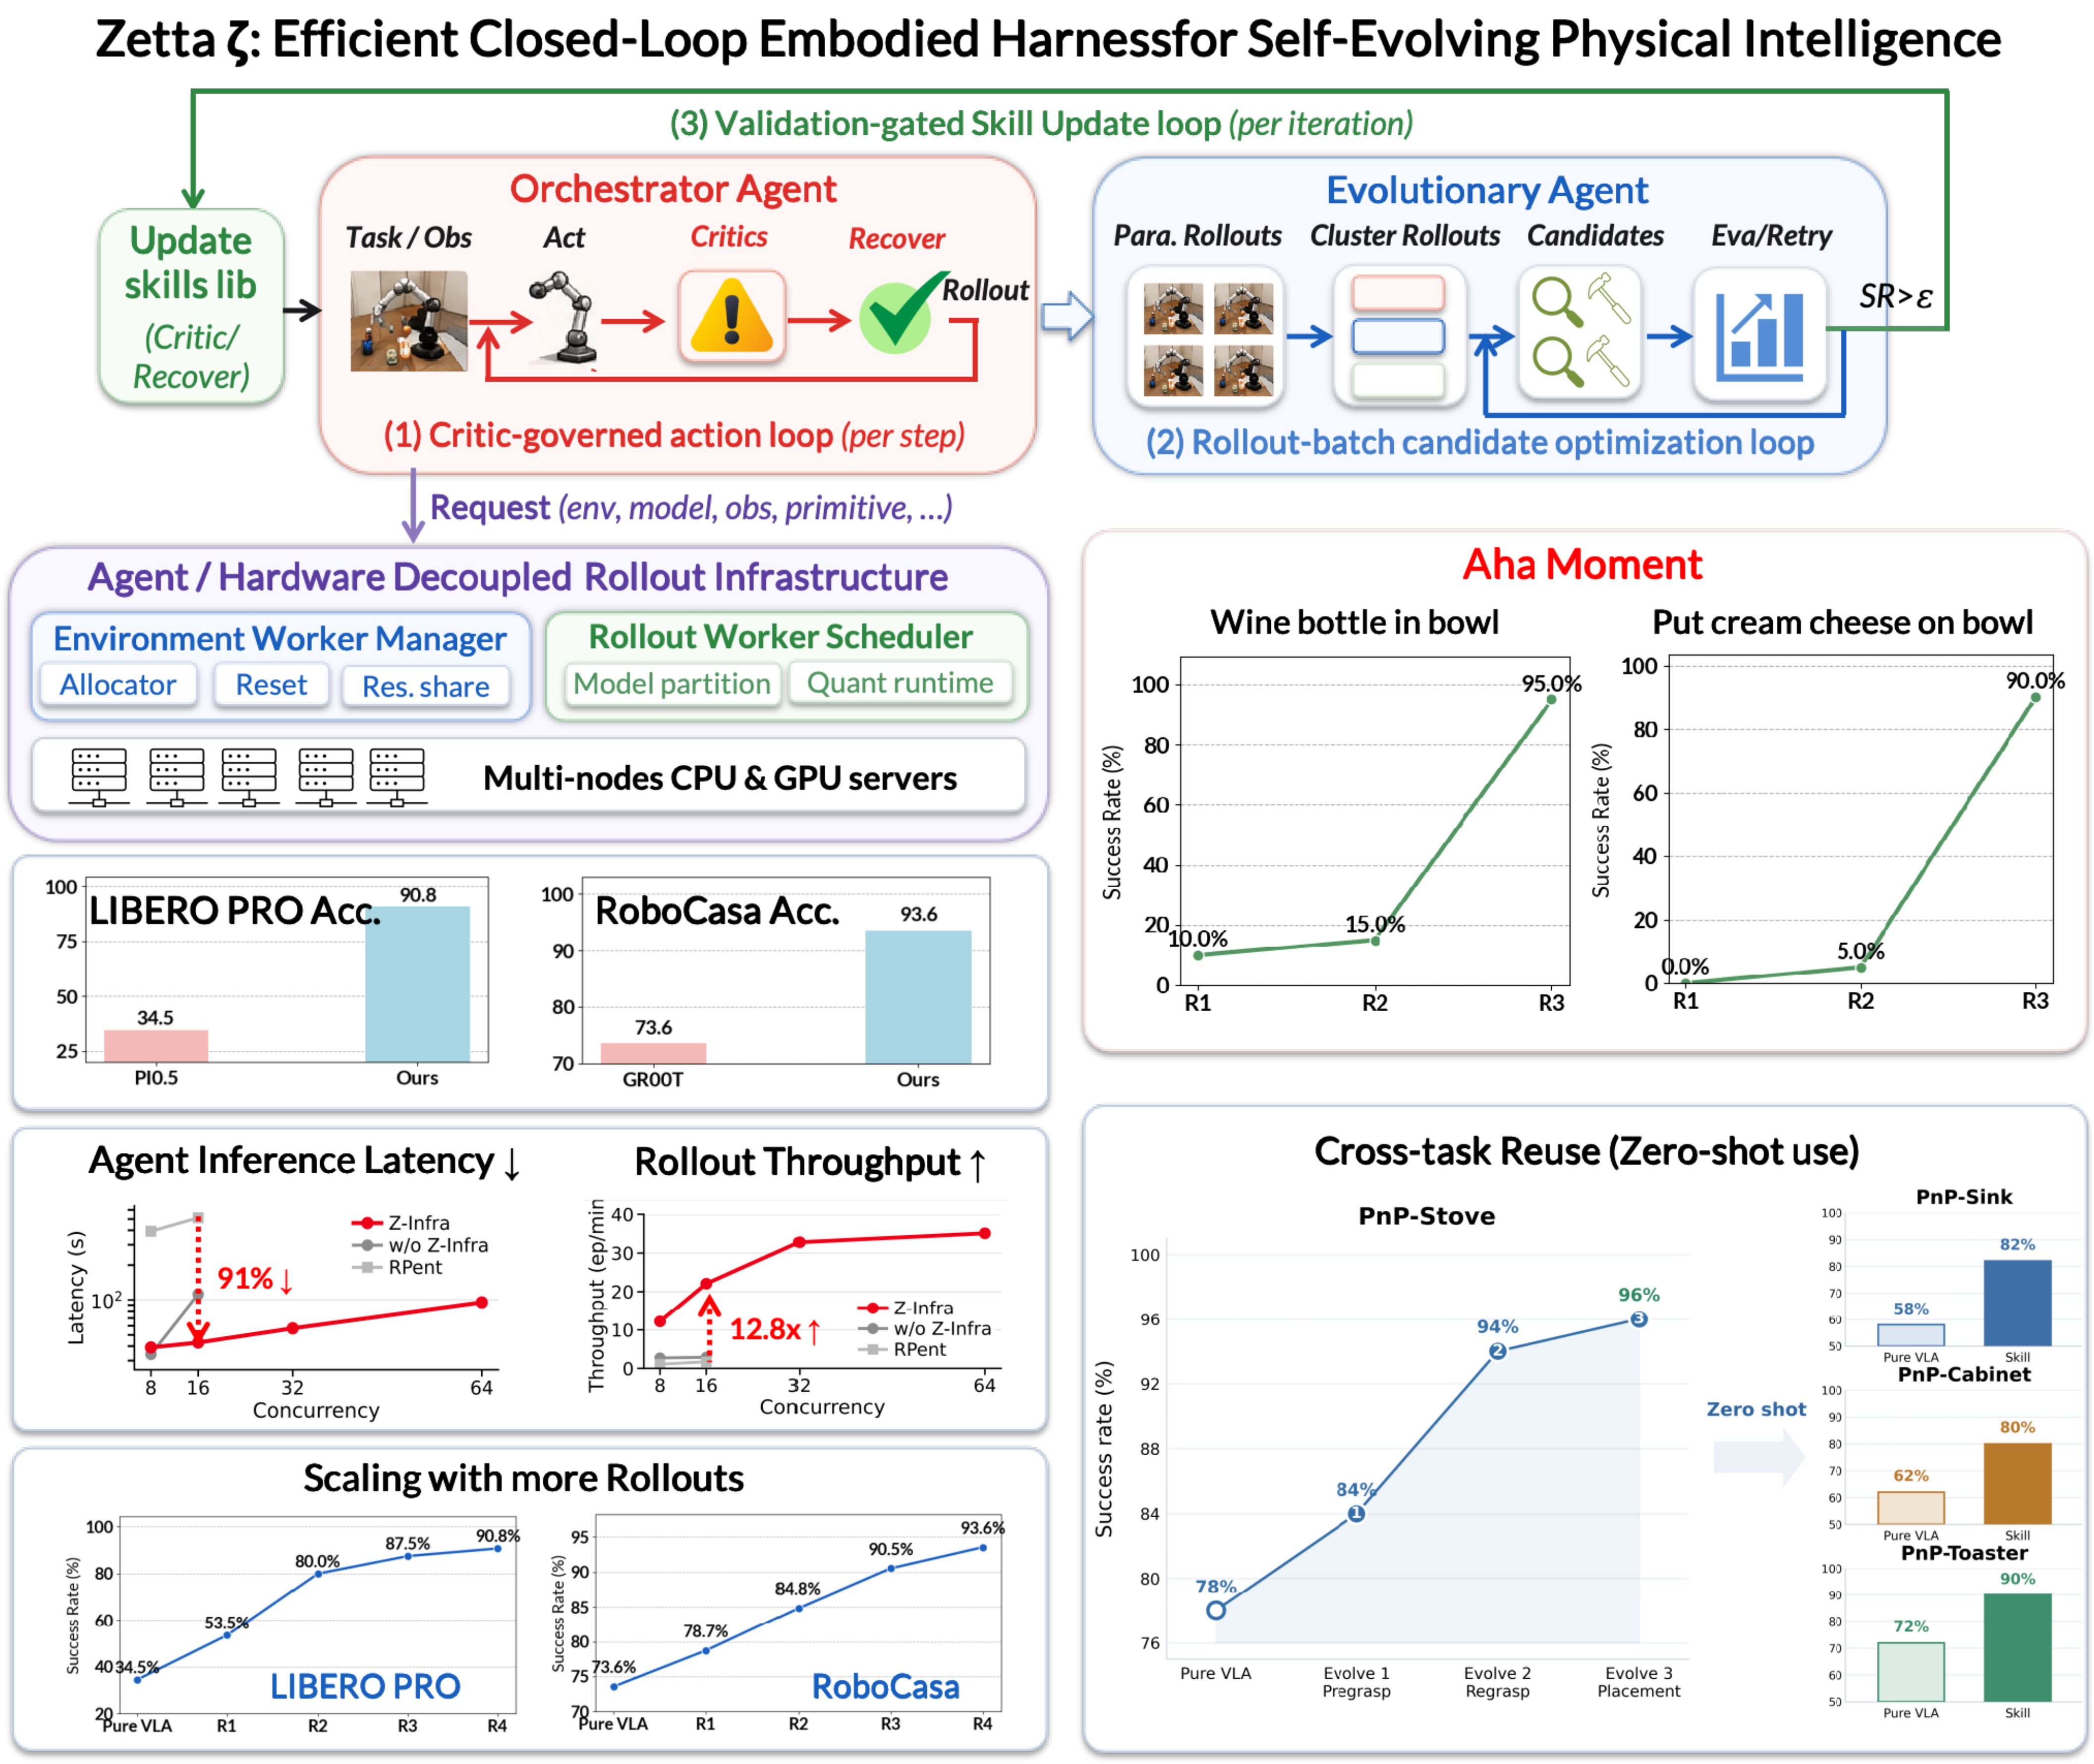
Zetta is a closed-loop embodied harness that evolves code-based runtime critics and recovery skills online while keeping the base robot policy frozen, reaching 90.8% success on LIBERO-Pro and 93.6% on RoboCasa with an 11.1x inference speedup.
- 1K#2 · OpenWAM-Official/OpenWAM
OpenWAM
OpenWAM is an open research stack for systematically building World-Action Models (WAMs) for robots, breaking the usual tightly-coupled design choices into modular, swappable components you can compare in controlled experiments.
- 687
 #3 · baidu-baige/LoongForge
LoongForge
An open-source training framework from Baidu's Baige team for LLMs, VLMs, diffusion and embodied models, built for faster training and lower cost on NVIDIA GPUs and Kunlun XPUs.
- 4
Zero-WAM
434robbyant-research/Zero-WAM · PythonZero-WAM is a research method for zero-shot cross-task robotic manipulation: a causal video-action policy that learns in-context world-action modeling, predicting future robot observations and executable actions from either language instructions or human demonstration videos.
- 5
RoboICL
268Mosi-AI/RoboICL · PythonRoboICL is a research framework that lets a frozen, general-purpose vision-language model (GPT-6 Astra) control a robot in simulation purely through in-context learning, without training a dedicated robot policy.
- 6

quackd
263rokbenko/quackd · Pythonquackd is an open-source daemon that gives small robots a brain: it takes a goal in plain language and plans the right sequence of the robot's own existing skills to carry it out, using an LLM like Claude, OpenAI, Gemini, Grok or a local model.
- 7
flex-pi
225geyan21/flex-pi · PythonFlex-π is a 6B-parameter world-action model for robot manipulation that jointly predicts future RGB, 3D pointmaps, DINOv3 semantics, and actions from one checkpoint, so it can deploy as a VLA, a full world model, or anything in between.
- 8
StreamPI
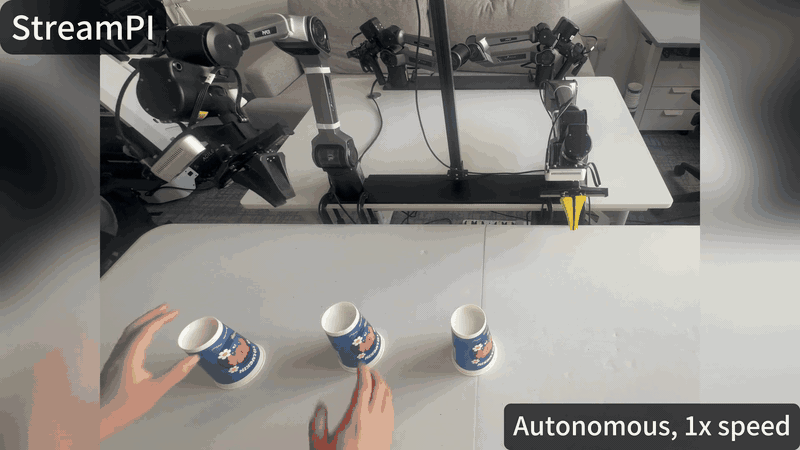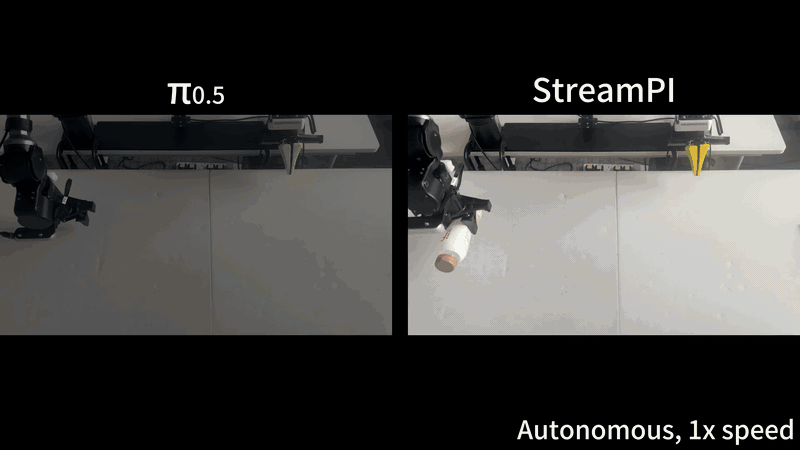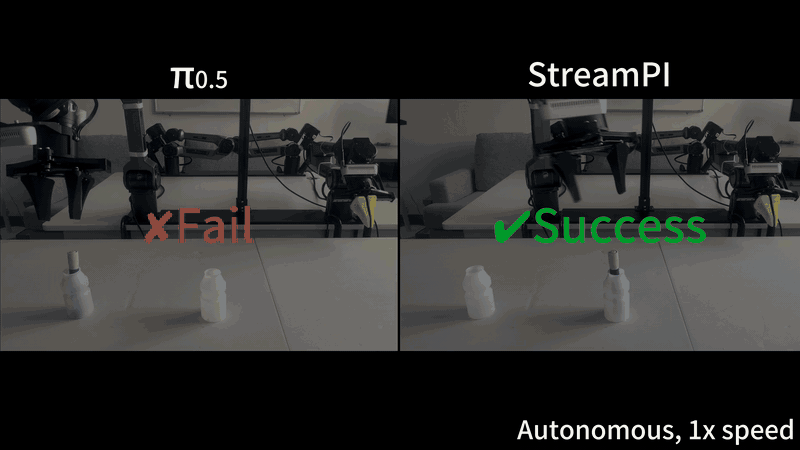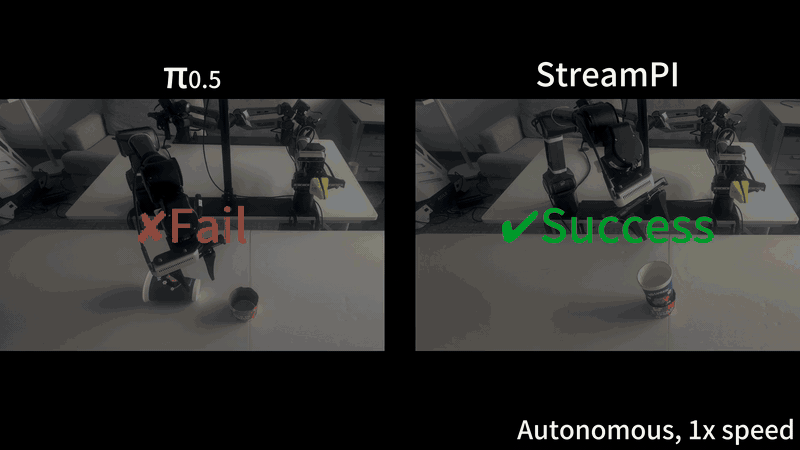
211hku-sail/StreamPI · PythonOfficial code of StreamPI (NeurIPS 2026, from HKU and ACE Robotics): a streaming temporal modeling framework that gives VLA robot policies like pi0.5 memory of past frames and multi-frame perception without adding any new parameters.
- 9
dreamforge
130rzc156/dreamforge · PythonDreamforge is a research pipeline that mines a robot policy's own failure states, uses a latent world model (CEM) to imagine corrective actions, and verifies each correction by replaying it in the real simulator before claiming it helps.
Related topics
Often tagged together