Topics / #mujoco
Mujoco projects on GitHub
Physics simulation engine for robotics research.
As of , the most-starred Mujoco projects on GitHub are mujoco (15.7K stars), tianshou (11K stars) and kimodo (3.8K stars). GitHub.Locker tracks 5 Mujoco repositories with 31.5K stars combined. The fastest-growing on October 16 was mujoco, with +21 stars in a day.
Hot right now
Most stars gained in a day · Oct 16
 +21
mujoco
google-deepmind/mujoco · ★ 15.7KMuJoCo is a general-purpose physics engine for simulating articulated structures interacting with their environment, maintained by Google DeepMind. It targets robotics, biomechanics, graphics/animation, and machine learning research.
 +5
kimodo
nv-tlabs/kimodo · ★ 3.8KKimodo is NVIDIA's kinematic motion diffusion model that generates high-quality 3D human and robot motion from text prompts and kinematic constraints like keyframes, end-effector positions, and 2D paths.
 +2
tianshou
thu-ml/tianshou · ★ 11KTianshou is an elegant deep reinforcement learning library built on pure PyTorch and Gymnasium, providing modular implementations of dozens of RL algorithms like DQN, PPO, SAC, and TD3.
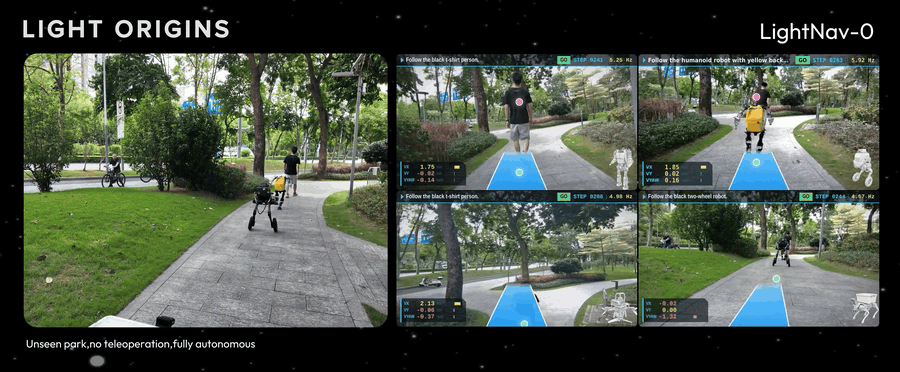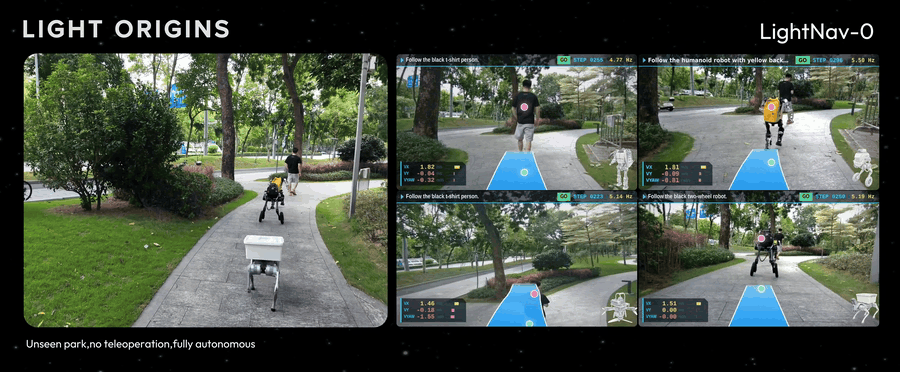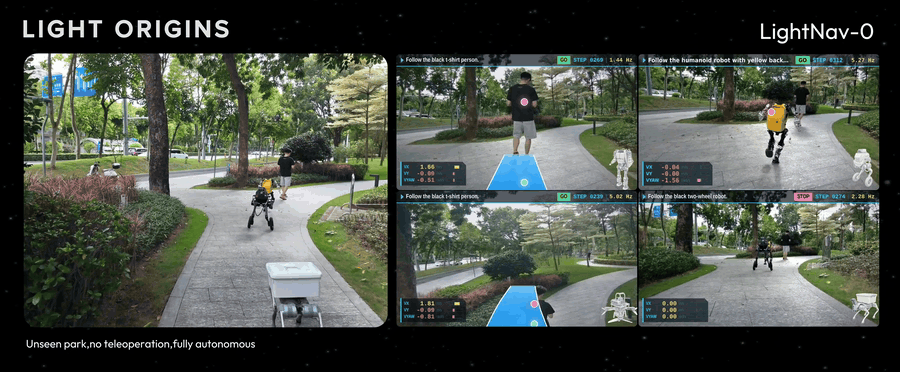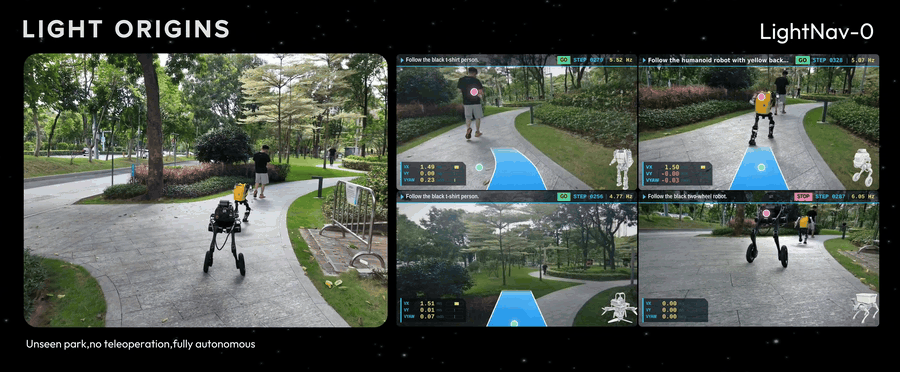 +2
LightNav-0
lightorigins/LightNav-0 · ★ 721LightNav-0 is a compact generalist embodied navigation model that gives humanoid, quadruped, wheeled and aerial robots the ability to follow language instructions and navigate autonomously in unseen environments, without any teleoperation.
The all-time top
5 projects · by stars
- 15.7K#1 · google-deepmind/mujoco
mujoco
MuJoCo is a general-purpose physics engine for simulating articulated structures interacting with their environment, maintained by Google DeepMind. It targets robotics, biomechanics, graphics/animation, and machine learning research.
- 11K#2 · thu-ml/tianshou
tianshou
Tianshou is an elegant deep reinforcement learning library built on pure PyTorch and Gymnasium, providing modular implementations of dozens of RL algorithms like DQN, PPO, SAC, and TD3.
- 3.8K#3 · nv-tlabs/kimodo
kimodo
Kimodo is NVIDIA's kinematic motion diffusion model that generates high-quality 3D human and robot motion from text prompts and kinematic constraints like keyframes, end-effector positions, and 2D paths.
- 4
LightNav-0
721lightorigins/LightNav-0 · PythonLightNav-0 is a compact generalist embodied navigation model that gives humanoid, quadruped, wheeled and aerial robots the ability to follow language instructions and navigate autonomously in unseen environments, without any teleoperation.
- 5

quackd
263rokbenko/quackd · Pythonquackd is an open-source daemon that gives small robots a brain: it takes a goal in plain language and plans the right sequence of the robot's own existing skills to carry it out, using an LLM like Claude, OpenAI, Gemini, Grok or a local model.
Related topics
Often tagged together