Topics / #world-models
World-models projects on GitHub
Neural models that learn simulated environments for prediction and planning.
As of , the most-starred World-models projects on GitHub are lerobot (28.2K stars), Embodied-AI-Guide (16.5K stars) and openpi (14.3K stars). GitHub.Locker tracks 29 World-models repositories with 105.4K stars combined. The fastest-growing on October 16 was lerobot, with +24 stars in a day.
Hot right now
Most stars gained in a day · Oct 16
 +24
lerobot
huggingface/lerobot · ★ 28.2KLeRobot is Hugging Face's open-source project providing models, datasets, and tools for real-world robotics in PyTorch, aiming to lower the barrier to entry for building and deploying robot learning policies.
 +17
Embodied-AI-Guide
TianxingChen/Embodied-AI-Guide · ★ 16.5KA free, encyclopedia-style Chinese knowledge base and resource index for embodied AI — robots that perceive and act in the physical world — maintained by the Lumina Embodied AI community. It is one of the most popular embodied-AI guides in China, with over 16,000 GitHub stars.
 +16
vllm-omni
vllm-project/vllm-omni · ★ 7.2KvLLM-Omni is an inference and serving framework that extends vLLM beyond text-only LLMs to omni-modality models, handling text, image, audio, video, and action outputs.
 +12
RSI-Anything
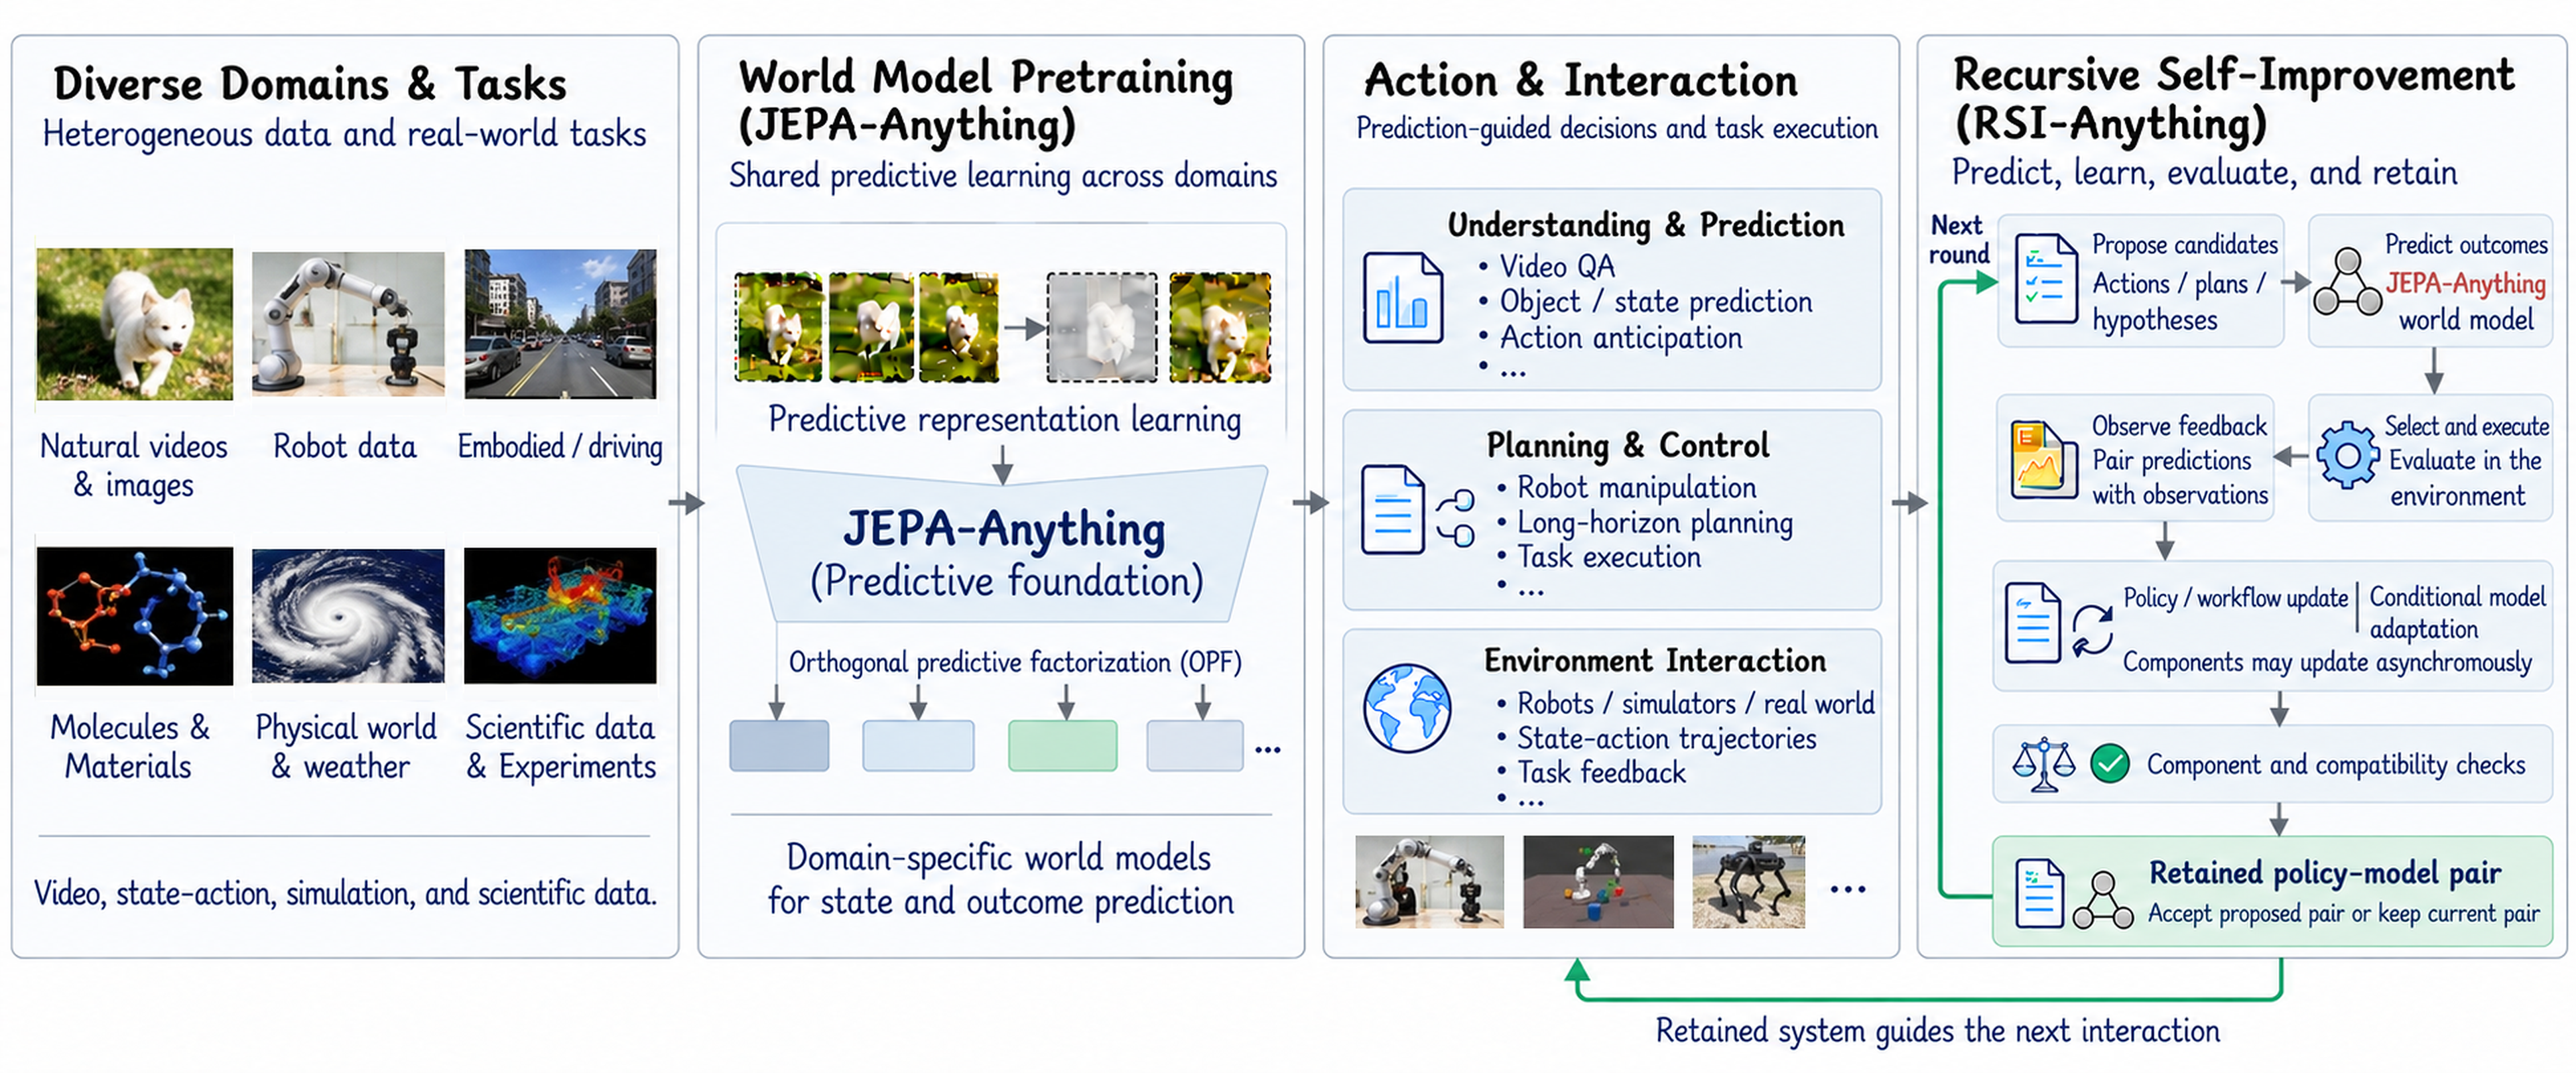
Gen-Verse/RSI-Anything · ★ 772RSI-Anything is a domain-general framework that turns world-model predictions and interaction feedback into recursive self-improvement, built on JEPA-Anything.
The all-time top
29 projects · by stars
- 28.2K#1 · huggingface/lerobot
lerobot
LeRobot is Hugging Face's open-source project providing models, datasets, and tools for real-world robotics in PyTorch, aiming to lower the barrier to entry for building and deploying robot learning policies.
- 16.5K#2 · TianxingChen/Embodied-AI-Guide
Embodied-AI-Guide
A free, encyclopedia-style Chinese knowledge base and resource index for embodied AI — robots that perceive and act in the physical world — maintained by the Lumina Embodied AI community. It is one of the most popular embodied-AI guides in China, with over 16,000 GitHub stars.
- 14.3K
 #3 · Physical-Intelligence/openpi
openpi
openpi is a collection of open-source vision-language-action (VLA) models for robotics from the Physical Intelligence team, including pi0, pi0-FAST, and pi0.5, with pretrained checkpoints and code for fine-tuning and running them.
- 4
cosmos
12.1KNVIDIA/cosmos · Jupyter NotebookNVIDIA Cosmos is an open platform of world models, datasets, and tools for building Physical AI — systems that understand and generate the physical world for robots, autonomous vehicles, and smart infrastructure.
- 5

LongCat-Video
9.2Kmeituan-longcat/LongCat-Video · PythonLongCat-Video is a 13.6B-parameter foundational video generation model that unifies Text-to-Video, Image-to-Video, and Video-Continuation generation in a single architecture, aimed at efficient long-video generation and framed as a first step toward world models.
- 6
vllm-omni
7.2Kvllm-project/vllm-omni · PythonvLLM-Omni is an inference and serving framework that extends vLLM beyond text-only LLMs to omni-modality models, handling text, image, audio, video, and action outputs.
- 7
le-wm
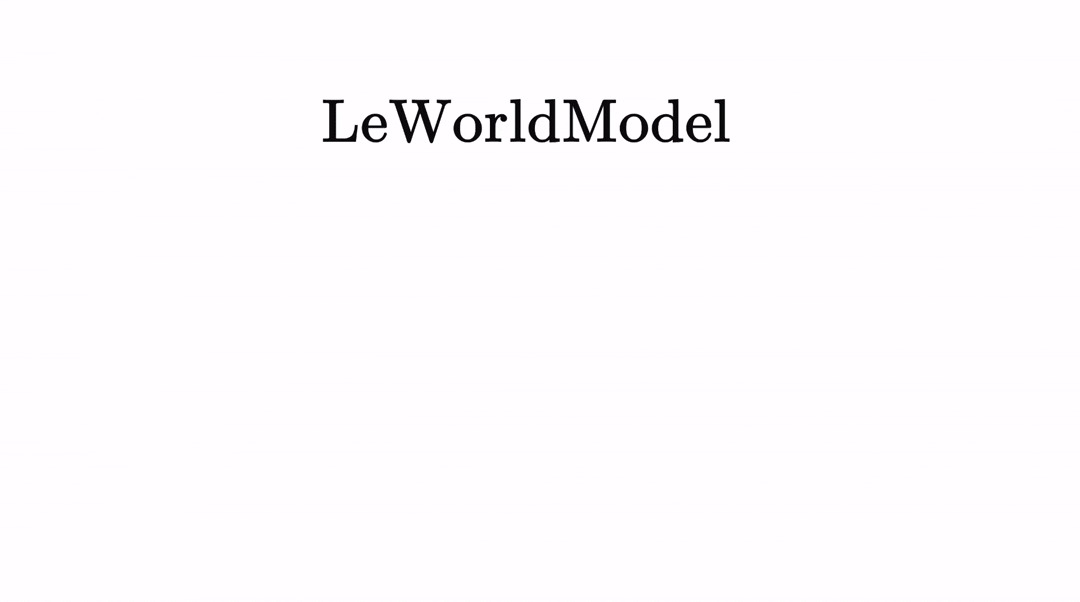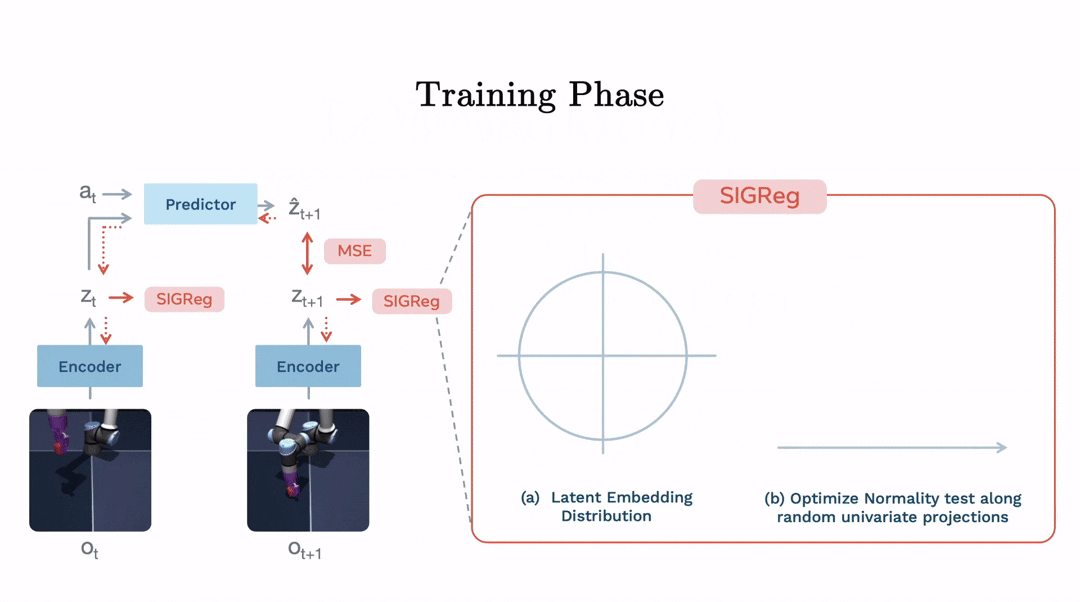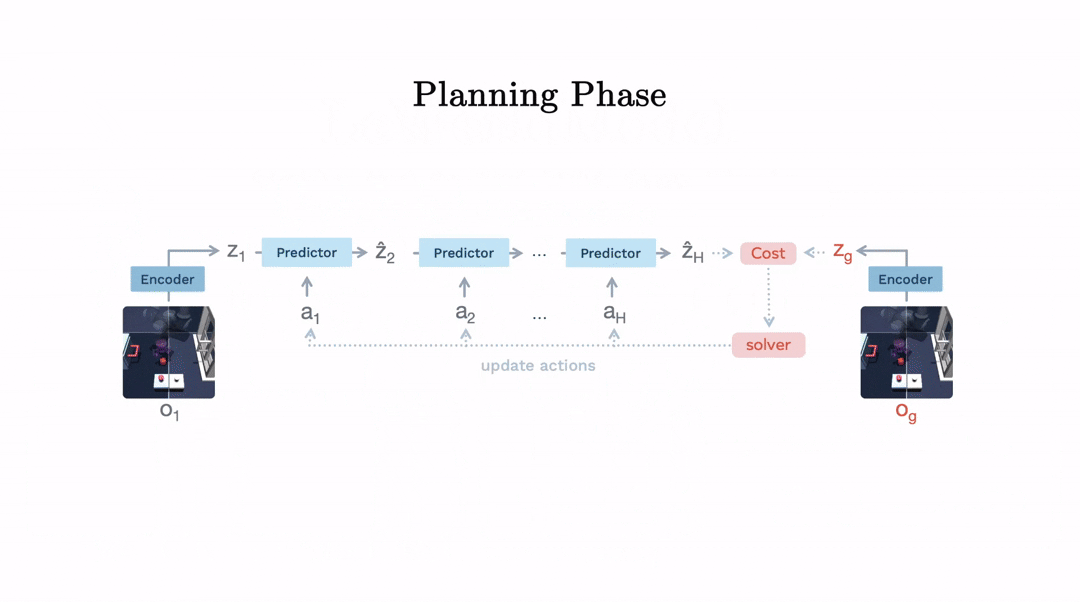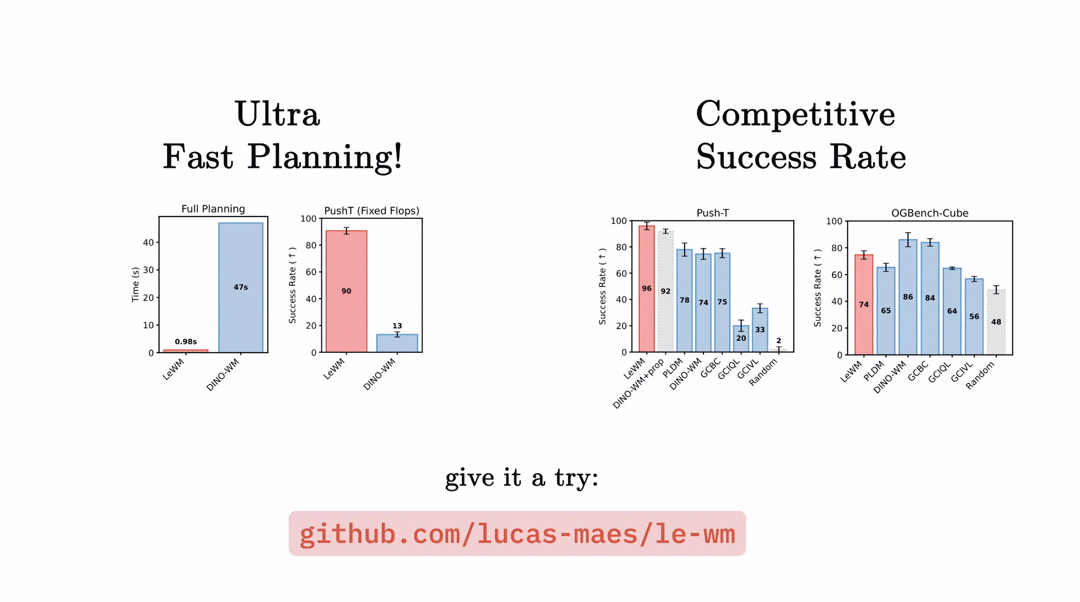
4.5Klucas-maes/le-wm · PythonThis is the official codebase for LeWorldModel (LeWM), a Joint-Embedding Predictive Architecture (JEPA) that learns a world model directly from pixels using just two loss terms, avoiding the usual tricks like EMA, pretrained encoders, or auxiliary supervision.
- 8
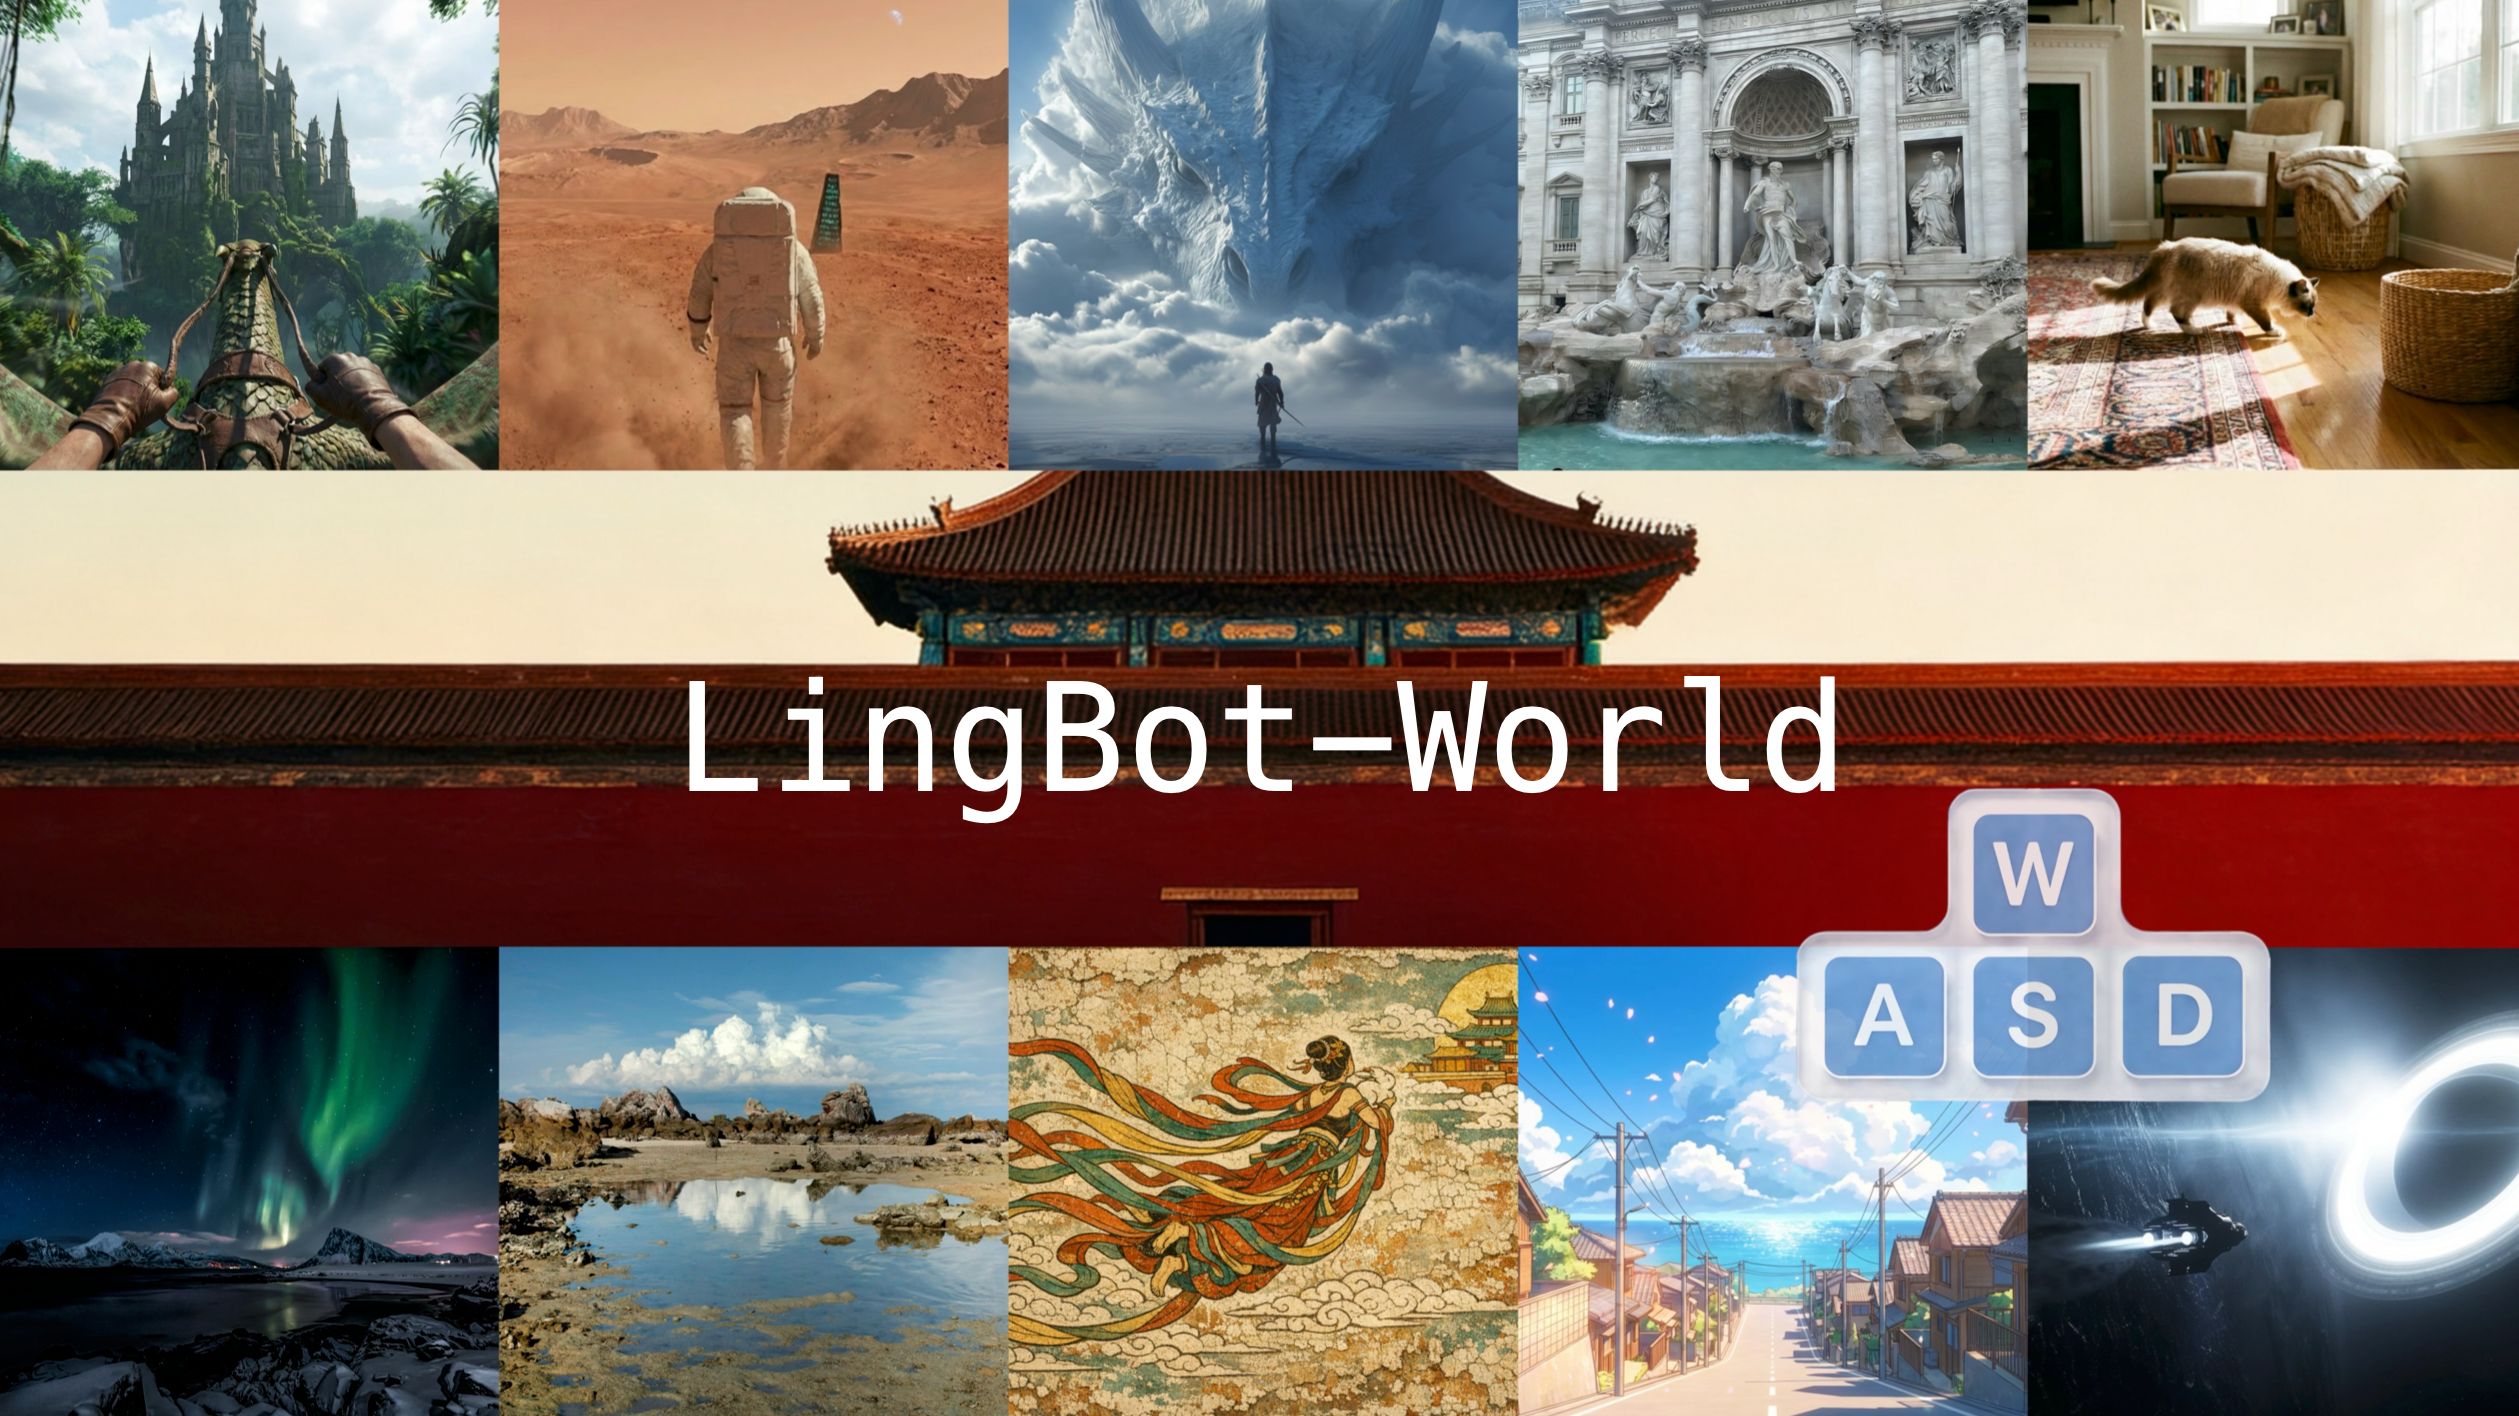
lingbot-world
4.5KRobbyant/lingbot-world · PythonLingBot-World is an open-source world model/simulator built from video generation: it turns an input image, text prompt, and optional control signals (camera poses or actions) into a long, controllable video that behaves like an interactive world.
- 9
OpenWAM
1KOpenWAM-Official/OpenWAM · PythonOpenWAM is an open research stack for systematically building World-Action Models (WAMs) for robots, breaking the usual tightly-coupled design choices into modular, swappable components you can compare in controlled experiments.
- 10
Evoke
861AlayaLab/Evoke · PythonEVOKE is a research implementation of an interactive 'world model' that generates endless, controllable video: a three-step, CFG-free system that remembers where it has already been, lets you redirect it mid-rollout, and is state-of-the-art on the WBench long-horizon benchmark.
- 11
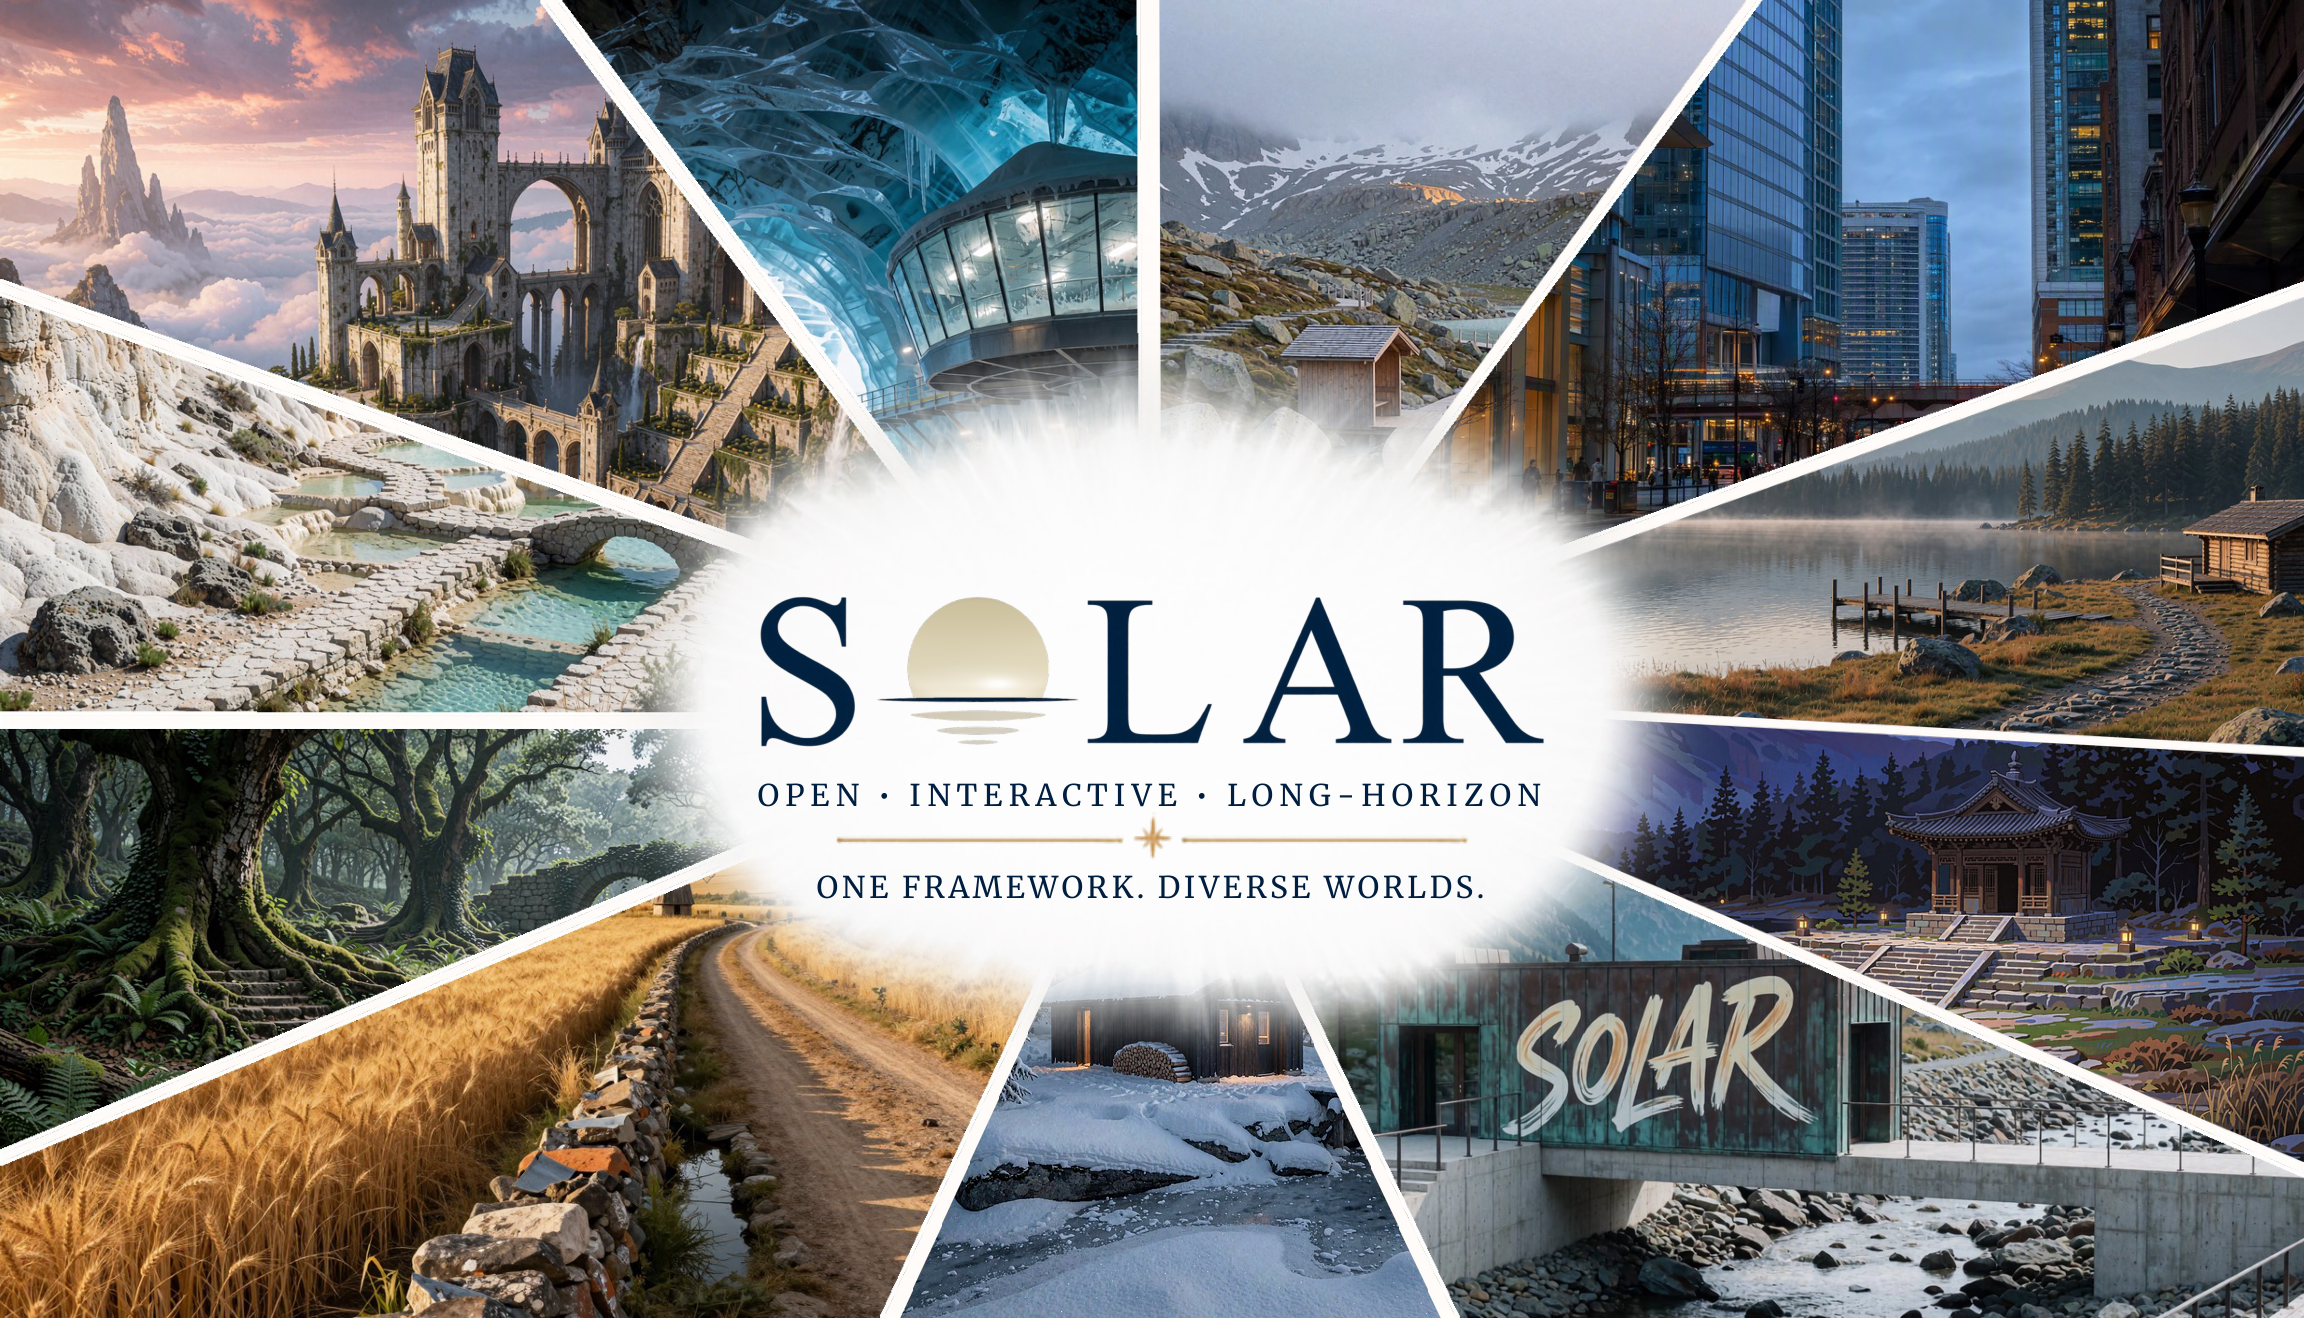
SolarWM
777Junchao-cs/SolarWM · PythonSolarWM is a fully open foundation for building interactive video world models, covering data preparation, scalable multi-backbone training, and long-horizon inference.
- 12
RSI-Anything
772Gen-Verse/RSI-Anything · HTMLRSI-Anything is a domain-general framework that turns world-model predictions and interaction feedback into recursive self-improvement, built on JEPA-Anything.
- 13
Motus2
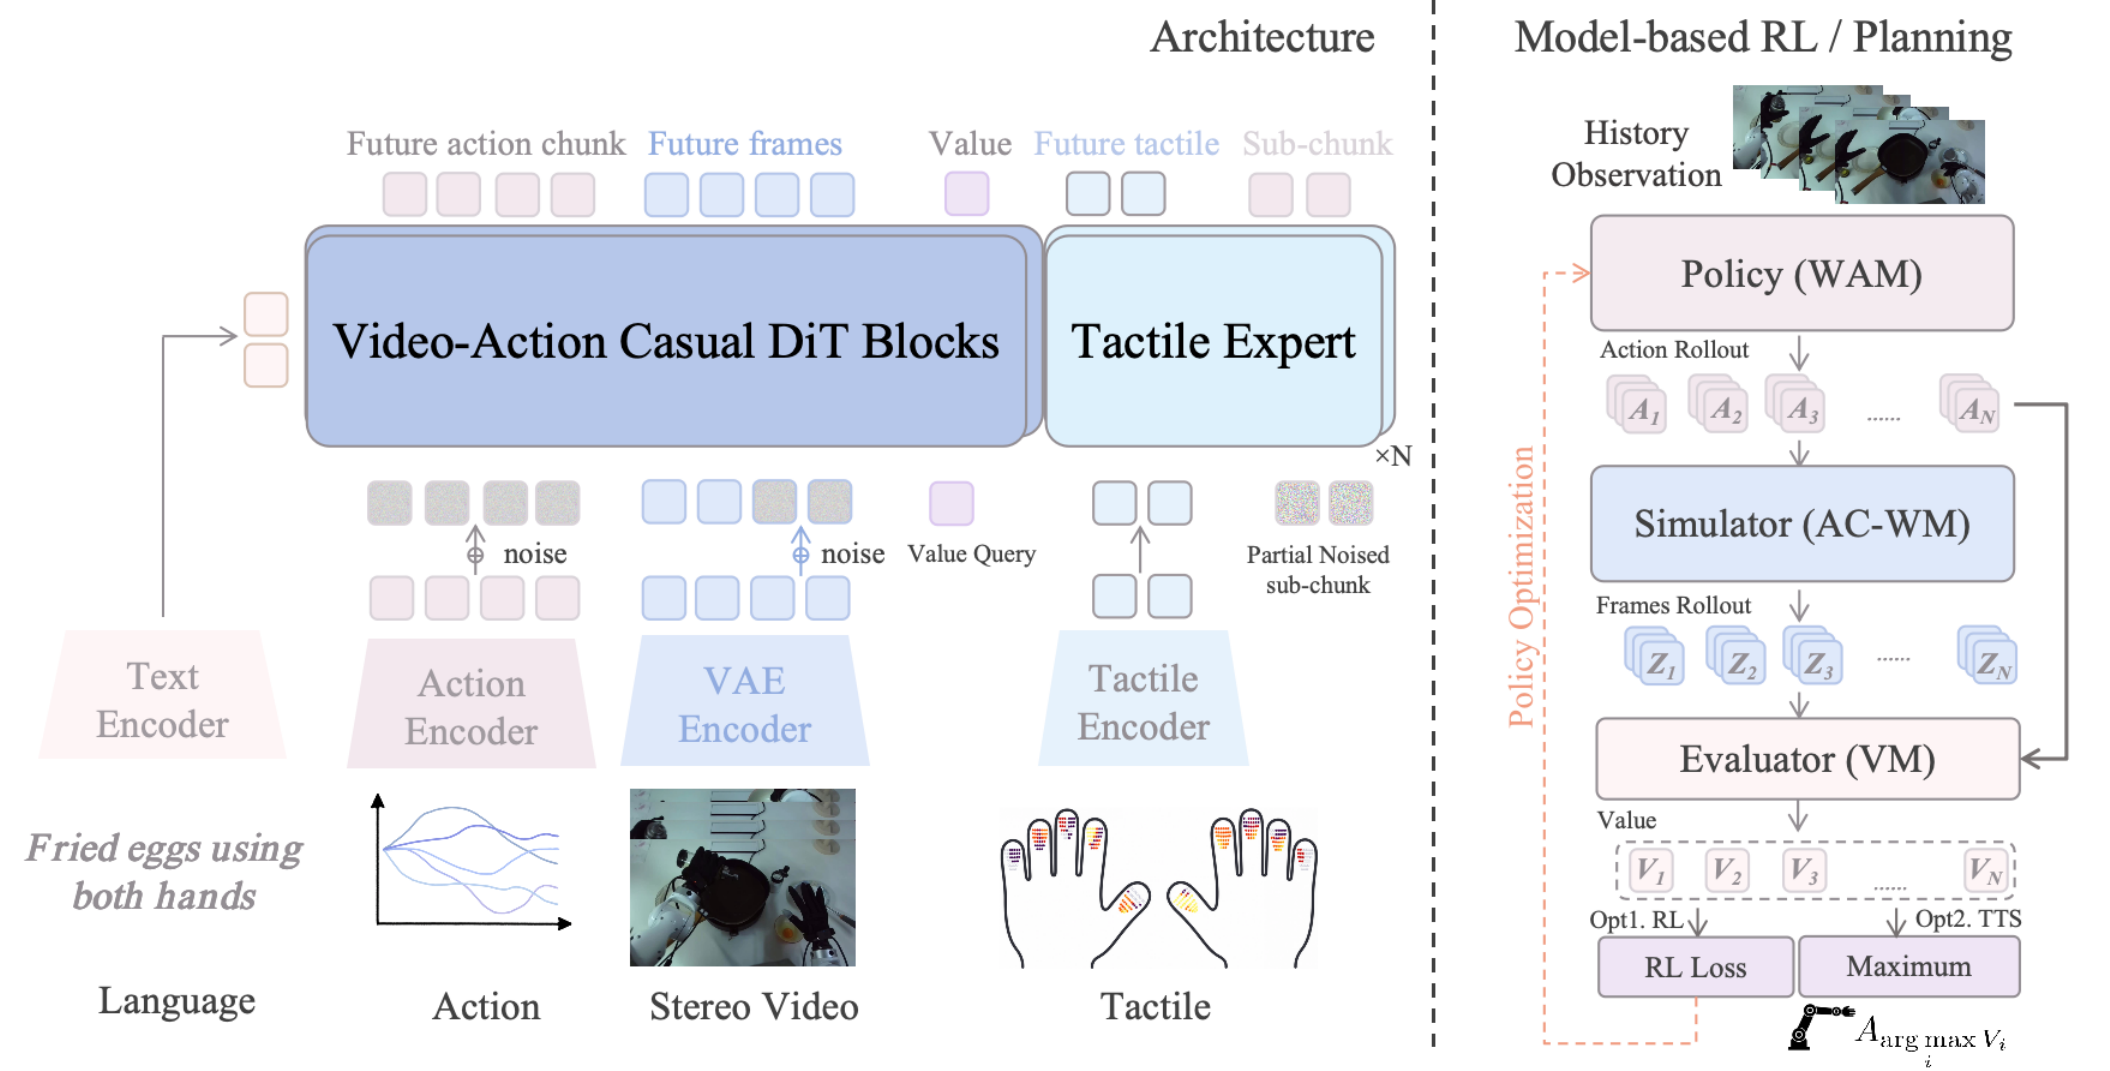
685shengshu-ai/Motus2Motus2 is a self-evolving general world model for dexterous robot manipulation. A single model with shared weights acts as a policy, a simulator, and an evaluator, coupling them into a closed decision-and-learning loop so the system can perceive, predict, act, and improve itself.
- 14
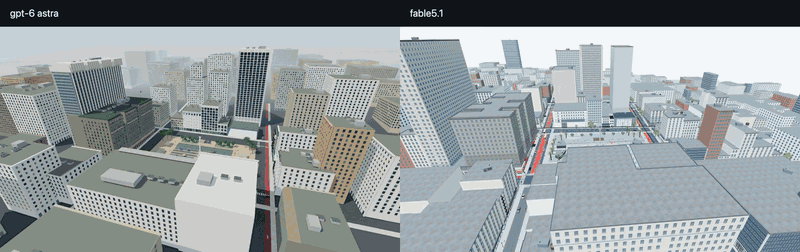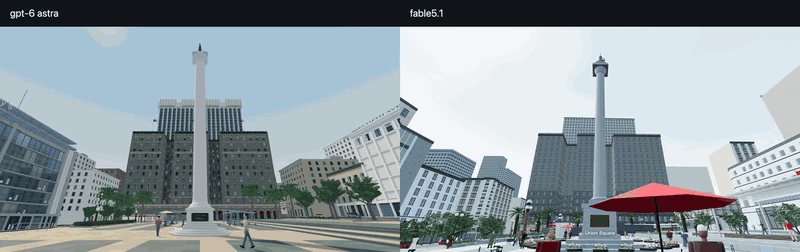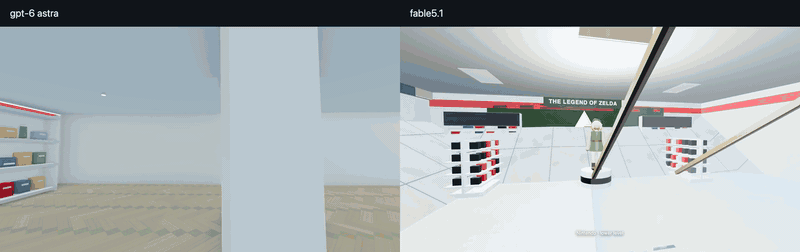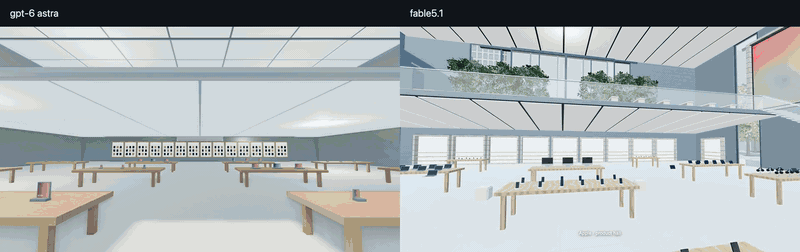
fable51-worlds
523PhiloLabs/fable51-worlds · JavaScriptThis project turns a single brief - a sentence, a photograph, or a video clip - into a walkable 3D world, generated by Claude-based agent swarms called 'Fable 5.1' that research the real place, model it, render it, and verify it.
- 15

code-world-model
508buaacyw/code-world-model · PythonCode World Model (CWM) is an academic research project on using a coding agent as a 'world brain', released with a public LoRA checkpoint and example data for reproducing experiments.
- 16
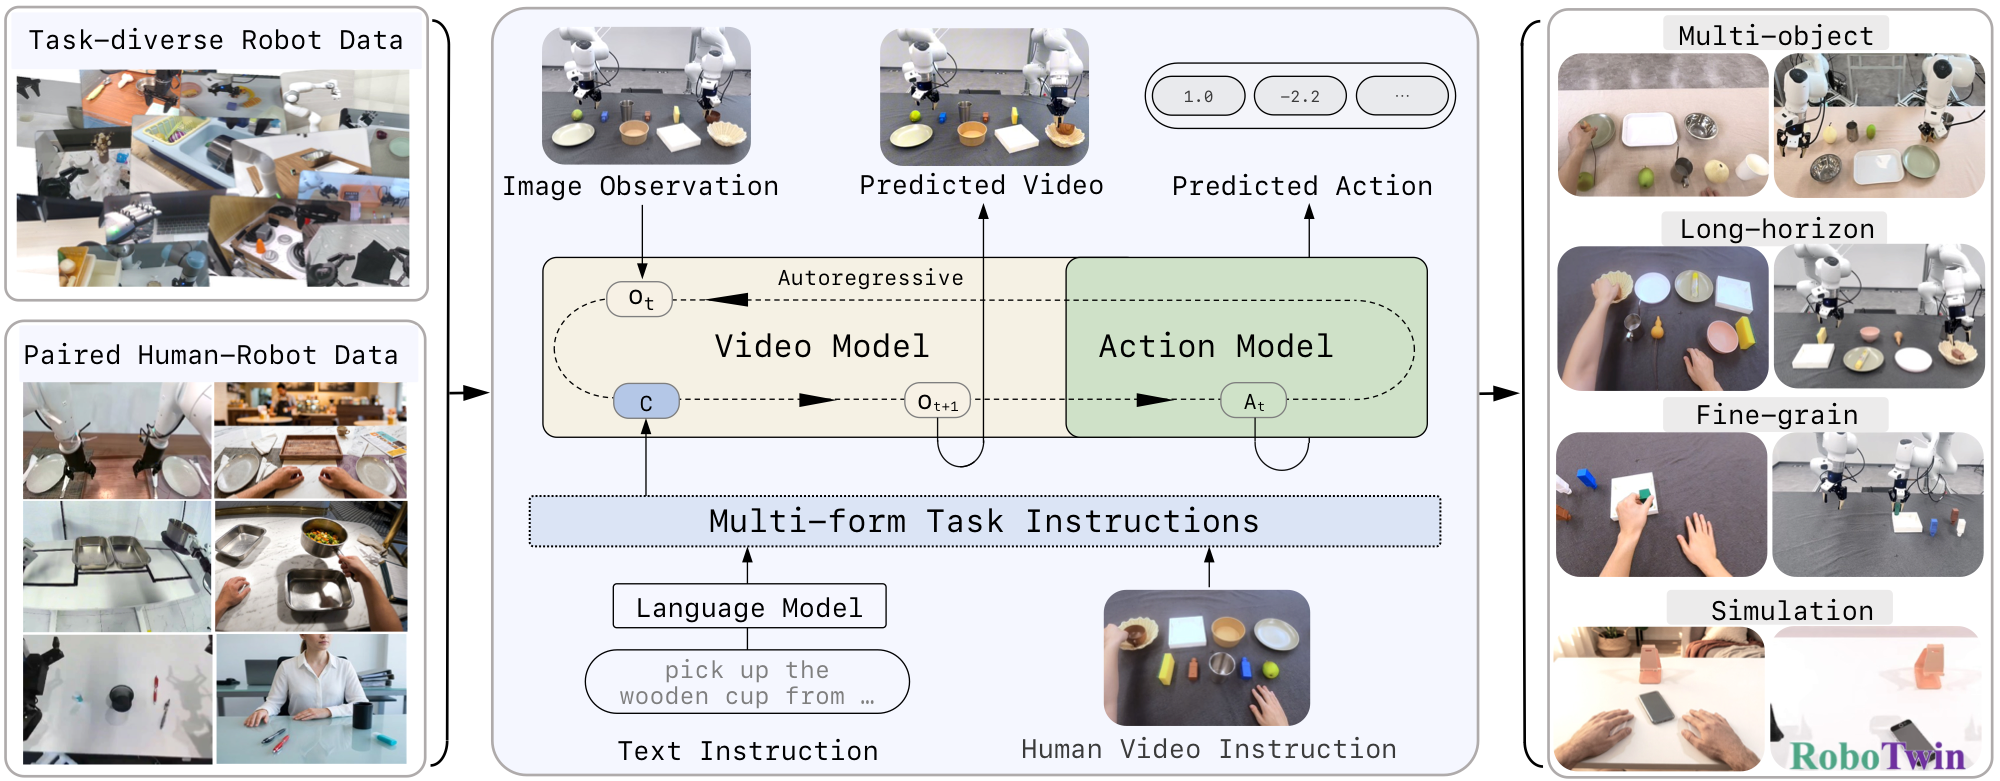
Zero-WAM
434robbyant-research/Zero-WAM · PythonZero-WAM is a research method for zero-shot cross-task robotic manipulation: a causal video-action policy that learns in-context world-action modeling, predicting future robot observations and executable actions from either language instructions or human demonstration videos.
- 17
Code-as-World
419MirroS-Lab/Code-as-World · PythonCode-as-World is a research project that represents the physical world as executable code, discovered through an agentic loop of simulation and verification, so models get reusable physical data (states, dynamics, mechanisms) instead of just raw pixels.
- 18

dsh-memory
402FuRongJun-1999/dsh-memory · Pythondsh-memory is a memory plugin for DeepSeek Harness (DSH) that gives AI agents persistent, cross-session memory built on a mostly non-LLM 'white-box' reasoning pipeline, a spatiotemporal knowledge graph, and auditable guardrails. It targets AGI research into self-cognition, continual learning, world models and self-improvement rather than everyday chat memory.
- 19
EasyWAM
401OpenMOSS/EasyWAM · PythonEasyWAM is a unified research codebase for training, fine-tuning, and evaluating World Action Models (WAMs) — models that jointly predict future video and robot actions for embodied-AI and robotics research.
- 20

H3-World
318Danzer1xxxxChan/H3-World · PythonH3-World is an interactive world model built on MiniMax-H3: give it one initial frame and it generates video you steer with keyboard actions, like driving a game world with your keys.
- 21
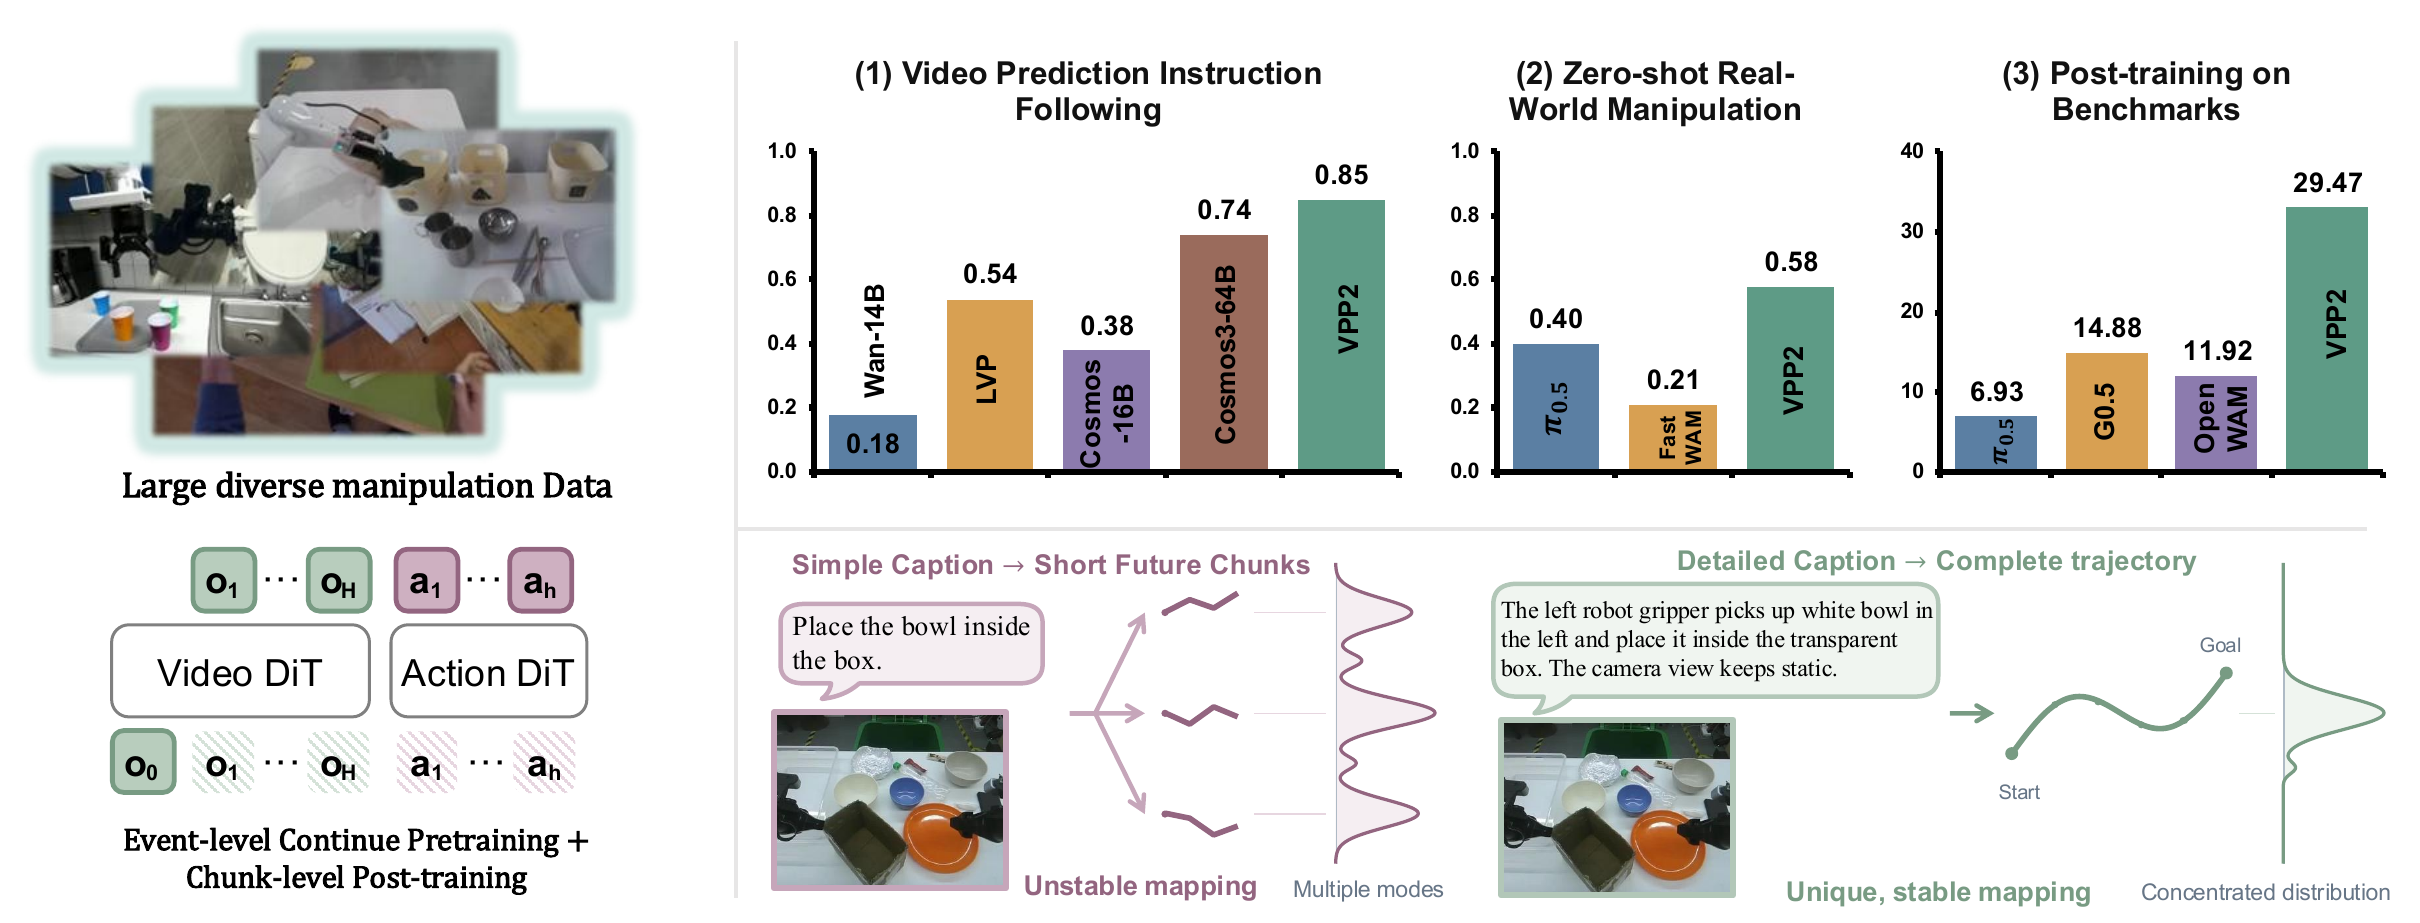
video-prediction-policy-2
249roboterax/video-prediction-policy-2 · PythonVideo Prediction Policy 2 (VPP2) is a world-action model (WAM) for robot manipulation that predicts future video frames and converts them into robot actions, with strong zero-shot generalization across tasks.
- 22
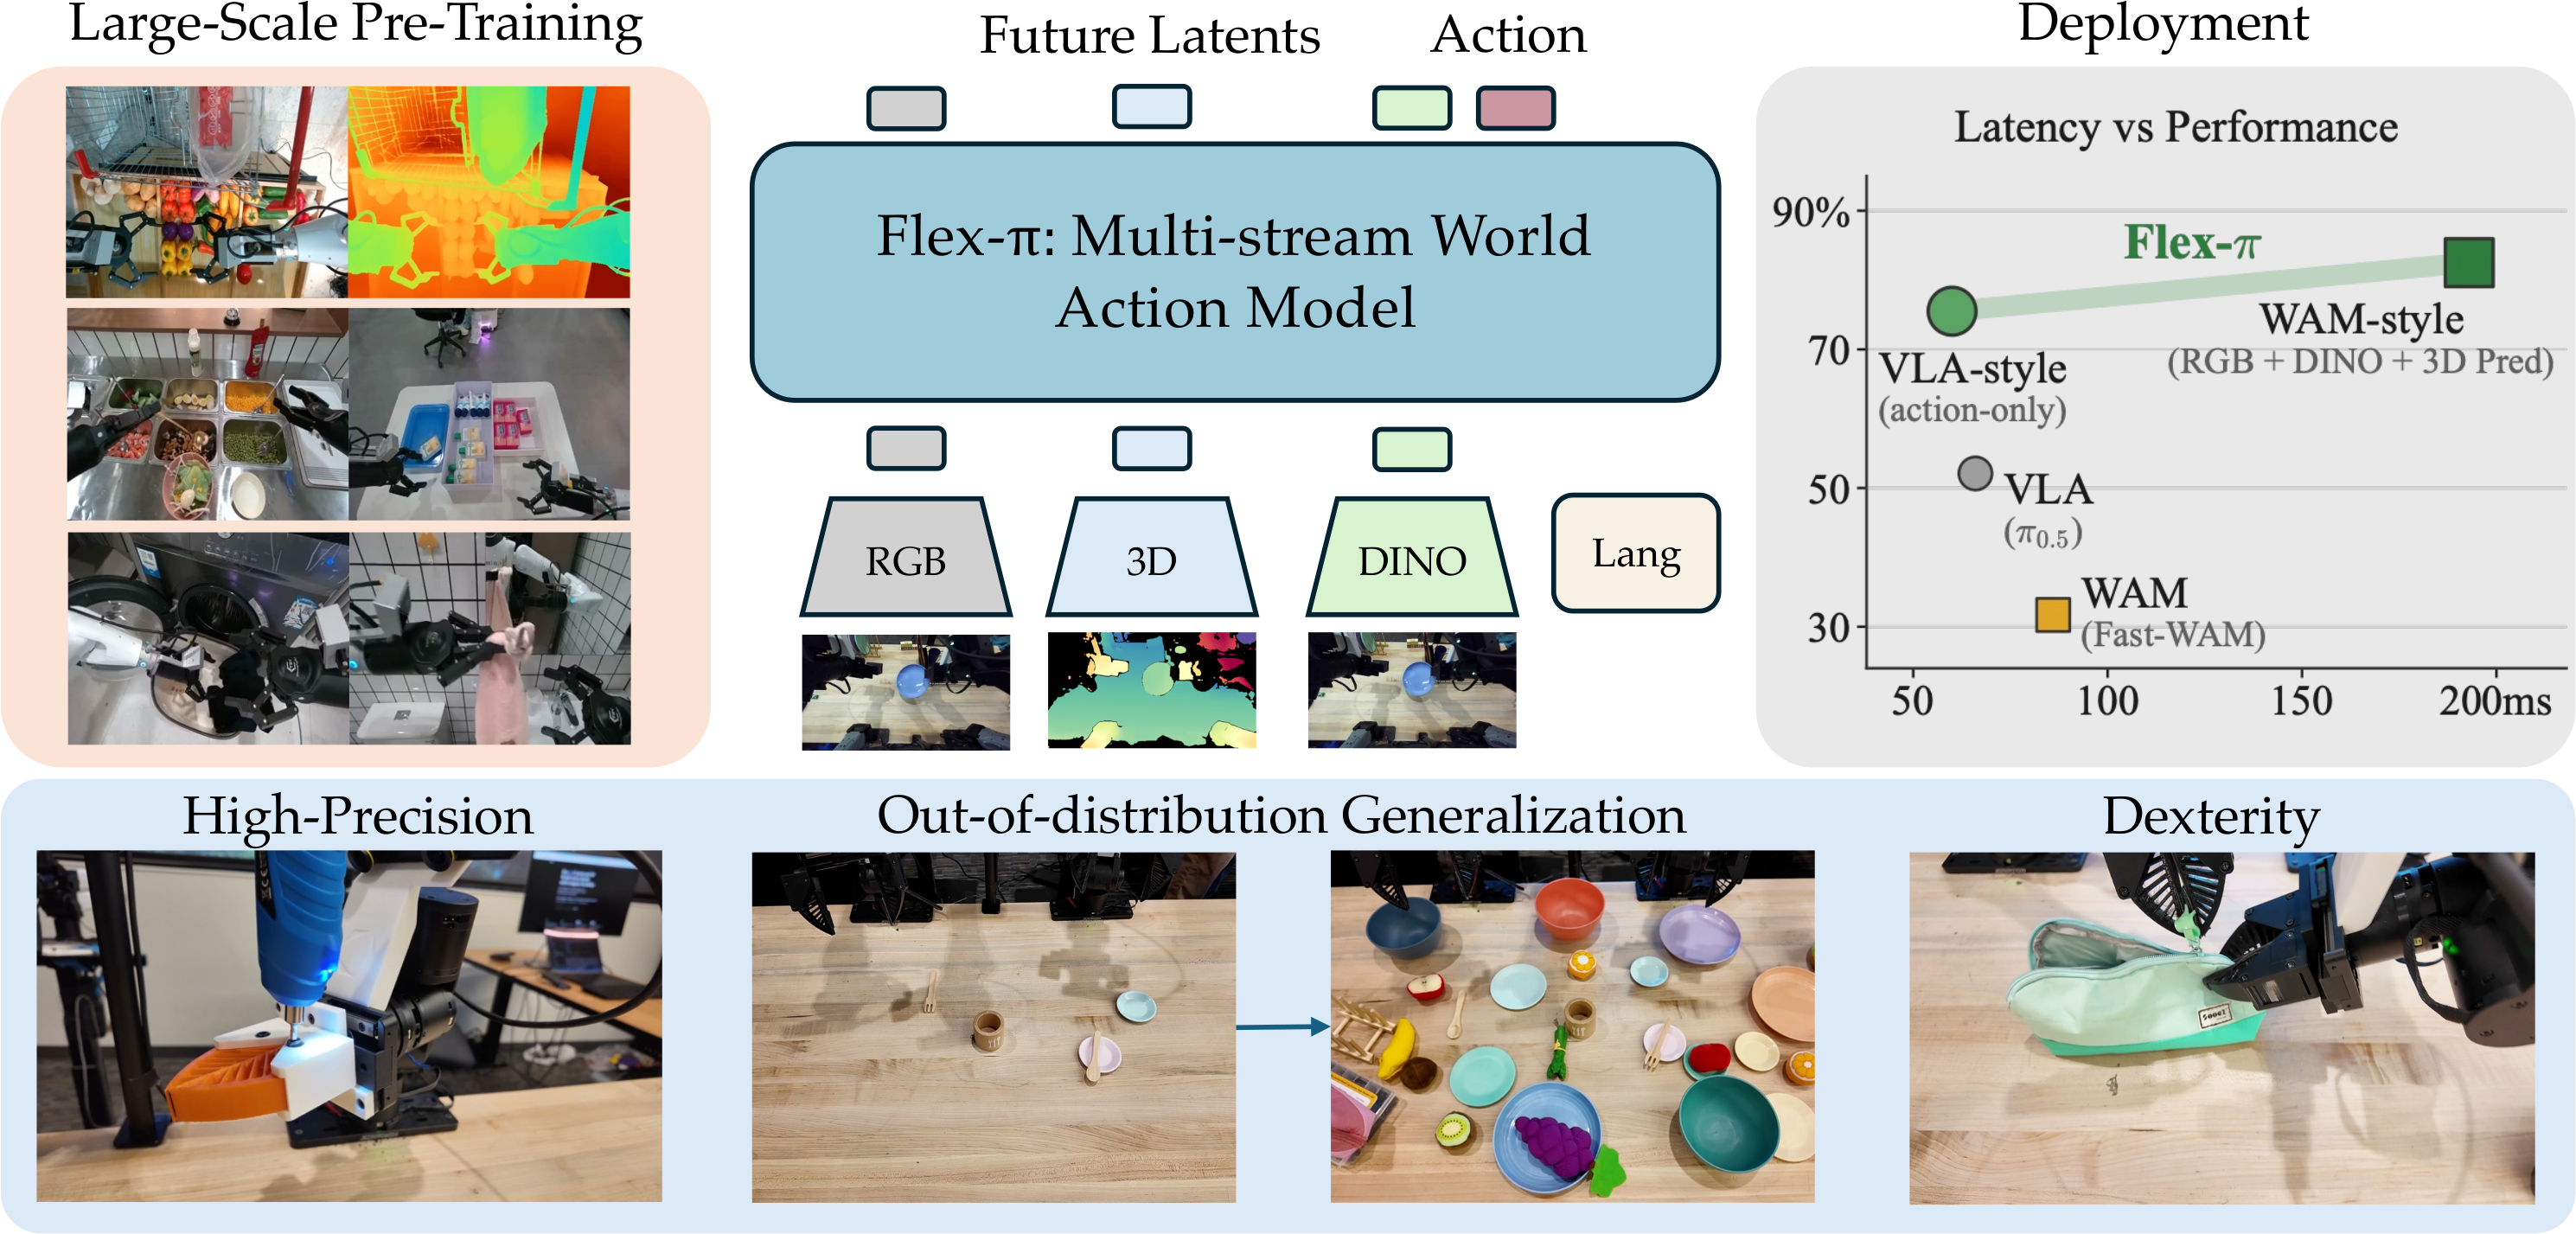
flex-pi
225geyan21/flex-pi · PythonFlex-π is a 6B-parameter world-action model for robot manipulation that jointly predicts future RGB, 3D pointmaps, DINOv3 semantics, and actions from one checkpoint, so it can deploy as a VLA, a full world model, or anything in between.
- 23
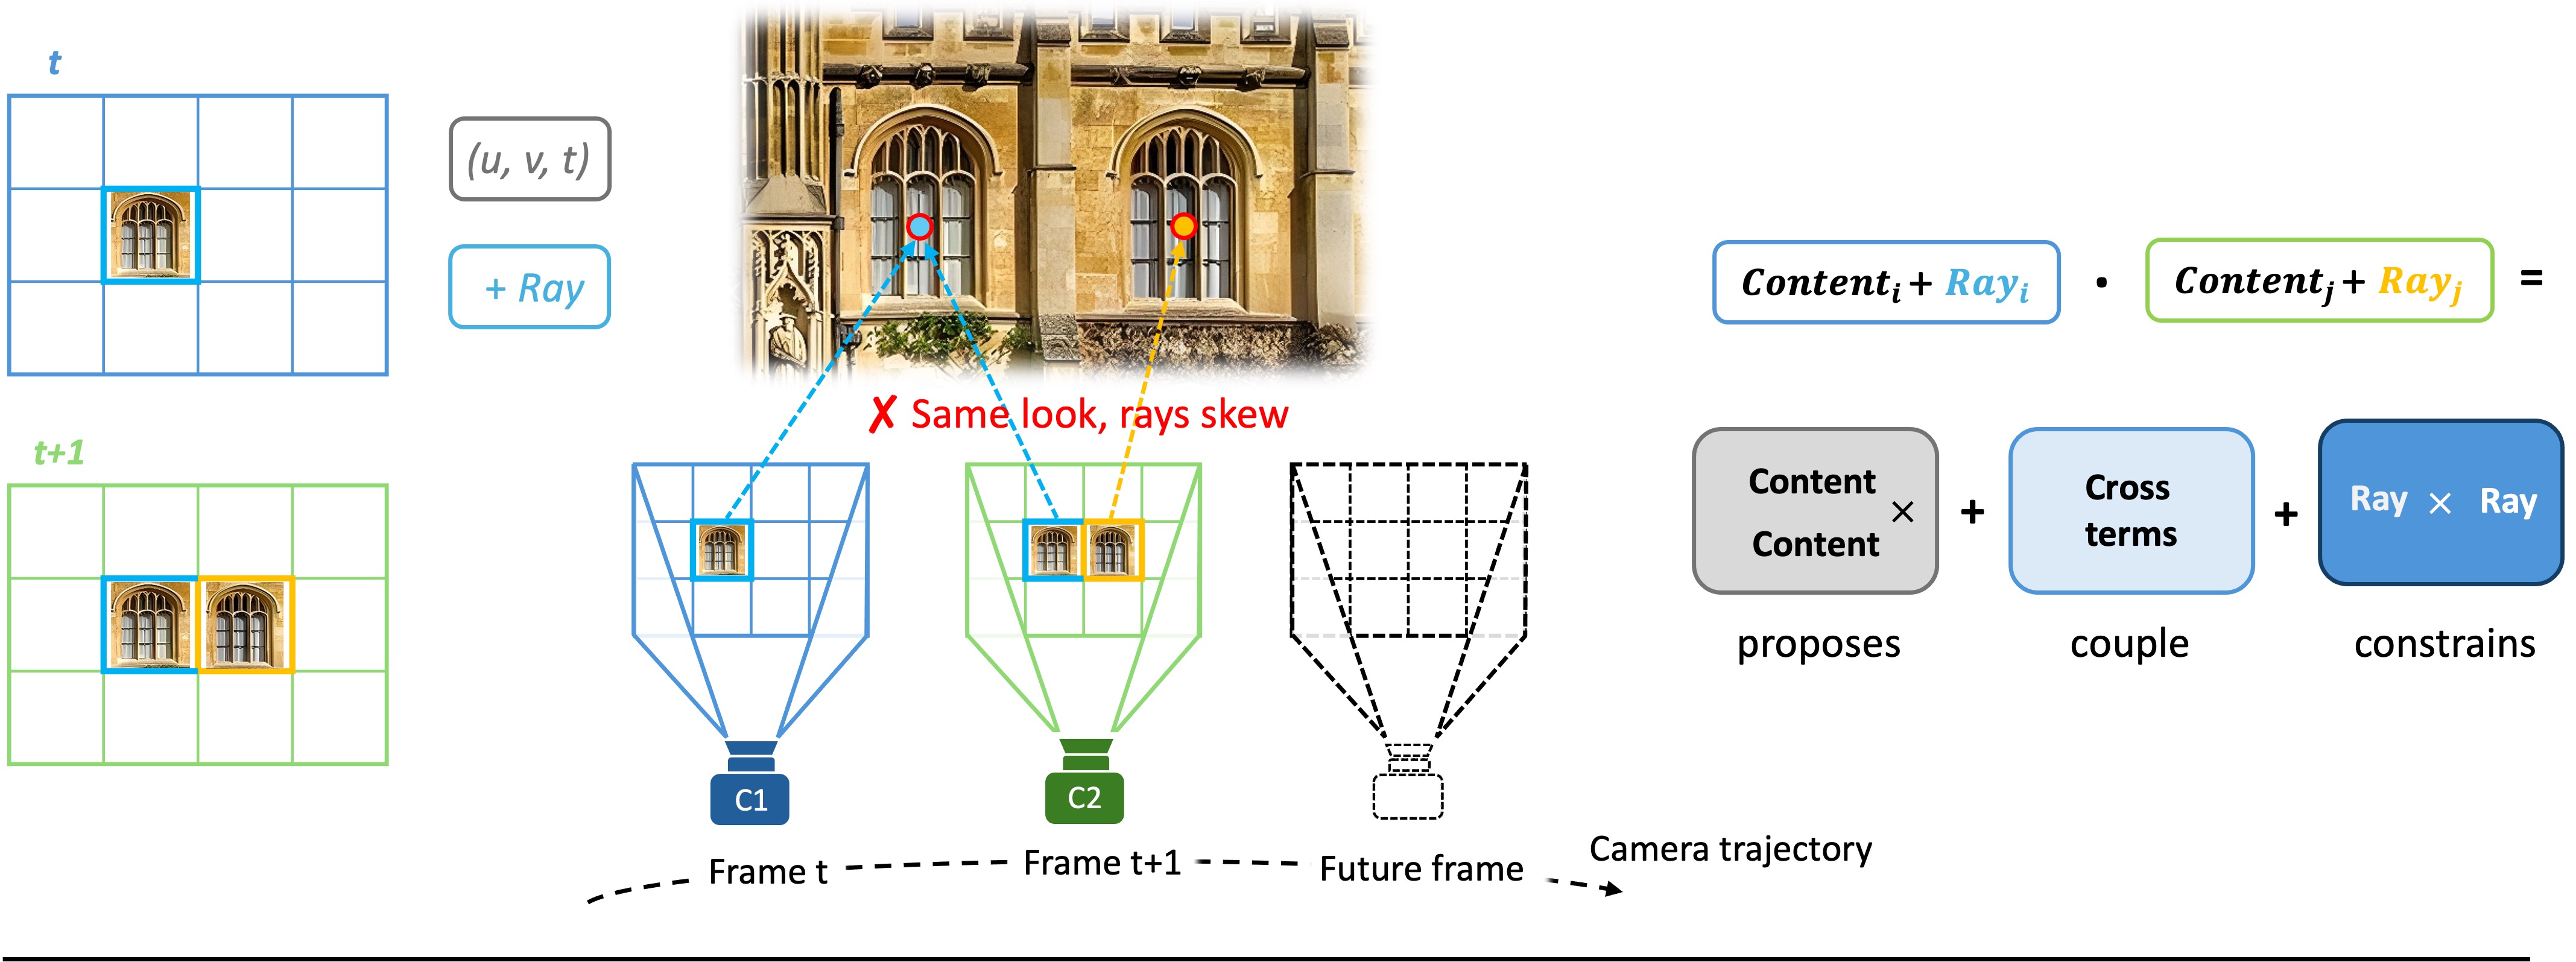
SCoPE
214TencentARC/SCoPE · PythonSCoPE is a research release that adds camera control to a pretrained video diffusion transformer (Wan2.2-I2V-A14B): given a first frame, a text prompt and a camera trajectory, it generates a video that follows the requested camera motion.
- 24
worldmodels101
205NiluK/worldmodels101 · TypeScriptA free, interactive online course that teaches how world models work in AI, covering prediction, latent dynamics, planning, JEPA, video models, and where they fail.
- 25
InstinctFlash
200General-Instinct/InstinctFlash · PythonInstinctFlash is a high-performance serving runtime for robotics foundation models - it loads checkpoints like GR00T, Cosmos3, pi0.5, LingBot-VA/VLA and DreamZero, applies acceleration (FP8, fused Triton kernels, caching) and serves them over Python or WebSocket, reporting up to 33.78x speedup on Jetson Thor.
- 26
Embodied-AI-Start
199ppsdk/Embodied-AI-StartA Chinese-language 'Embodied AI Starter Map' that organizes a learning path from robotics fundamentals (coordinates, kinematics, ROS 2) up to VLA policies, World Models, model-based RL and World Action Models (WAM), linking papers, code, benchmarks and practice guides at each step.
- 27
zing-world-model
170seedleap/zing-world-model · PythonZing-0.5 is an efficient causal world model that generates a real-time video world, letting you steer it live with text prompts and W/A/S/D/I/J/K/L keyboard actions.
- 28
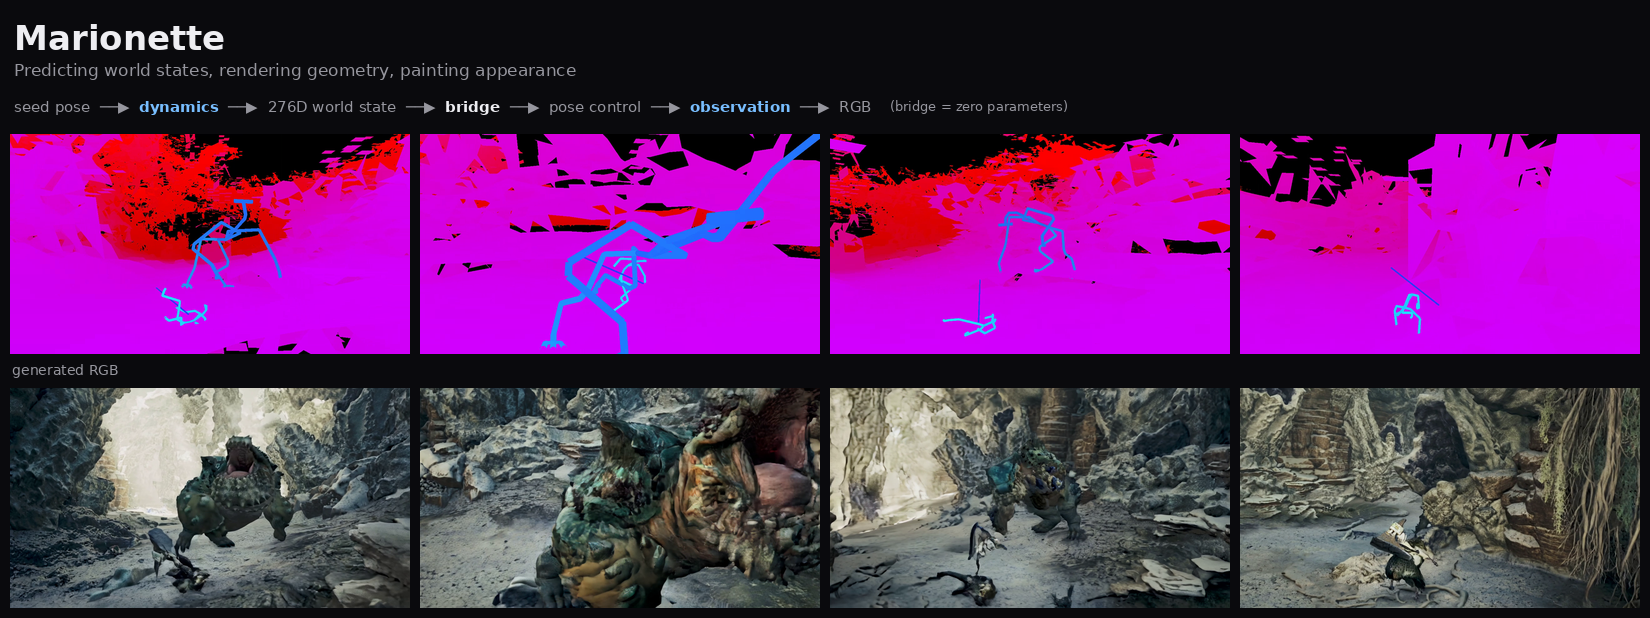
Marionette
147AlayaLab/Marionette · PythonA research world model for interactive 3D worlds. Instead of predicting pixels, it predicts an explicit 276D articulated state, turns that state into geometry with a parameter-free bridge, and lets a video diffusion model paint appearance on top.
- 29

arc-code
143jerber/arc-code · Pythonarc-code is a research harness that lets Claude Code (or Codex) play the ARC-AGI-3 benchmark games through a shell and filesystem, writing its own parsers, simulators and search code for each game instead of relying on built-in ARC-specific tooling.
Related topics
Often tagged together
- research764
- deep-learning737
- machine-learning916
- python2,383
- gpu789
- cuda396
- linux4,184
- pytorch419
- video-generation191
- benchmark431
- huggingface362
- robotics88
- ai1,955
- apache-2.01,434
- computer-vision384
- open-source5,666
- academic-research209
- embodied-ai32
- simulation89
- generative-ai339
- nvidia328
- diffusion-models80
- transformer212
- inference327