Topics / #ros
Ros projects on GitHub
Robot middleware for controlling drones, cars, and autonomous robots.
As of , the most-starred Ros projects on GitHub are ardupilot (16.1K stars), carla (14.5K stars) and PX4-Autopilot (12.8K stars). GitHub.Locker tracks 8 Ros repositories with 61.6K stars combined. The fastest-growing on October 16 was PX4-Autopilot, with +9 stars in a day.
Hot right now
Most stars gained in a day · Oct 16
 +9
PX4-Autopilot
PX4/PX4-Autopilot · ★ 12.8KPX4 is an open-source autopilot stack for drones and unmanned vehicles — the flight software behind multirotors, fixed-wing planes, VTOLs, rovers and other unmanned platforms.
ardupilot
ArduPilot/ardupilot · ★ 16.1KArduPilot is an open source autopilot, in development since 2010, that can control almost any unmanned vehicle: planes, multicopters and helicopters, rovers, boats, balance bots and even submarines.
 +5
carla
carla-simulator/carla · ★ 14.5KCARLA is an open-source simulator for autonomous driving research, built from the ground up to support development, training, and validation of self-driving systems, with open urban layouts, buildings, and vehicle assets.
 +2
autoware
autowarefoundation/autoware · ★ 12.2KAutoware is the world's leading open-source autonomous driving framework — a complete software stack for building self-driving vehicles.
The all-time top
8 projects · by stars
- 16.1K
#1 · ArduPilot/ardupilot
ardupilot
ArduPilot is an open source autopilot, in development since 2010, that can control almost any unmanned vehicle: planes, multicopters and helicopters, rovers, boats, balance bots and even submarines.
- 14.5K#2 · carla-simulator/carla
carla
CARLA is an open-source simulator for autonomous driving research, built from the ground up to support development, training, and validation of self-driving systems, with open urban layouts, buildings, and vehicle assets.
- 12.8K#3 · PX4/PX4-Autopilot
PX4-Autopilot
PX4 is an open-source autopilot stack for drones and unmanned vehicles — the flight software behind multirotors, fixed-wing planes, VTOLs, rovers and other unmanned platforms.
- 4
autoware
12.2Kautowarefoundation/autoware · DockerfileAutoware is the world's leading open-source autonomous driving framework — a complete software stack for building self-driving vehicles.
- 5
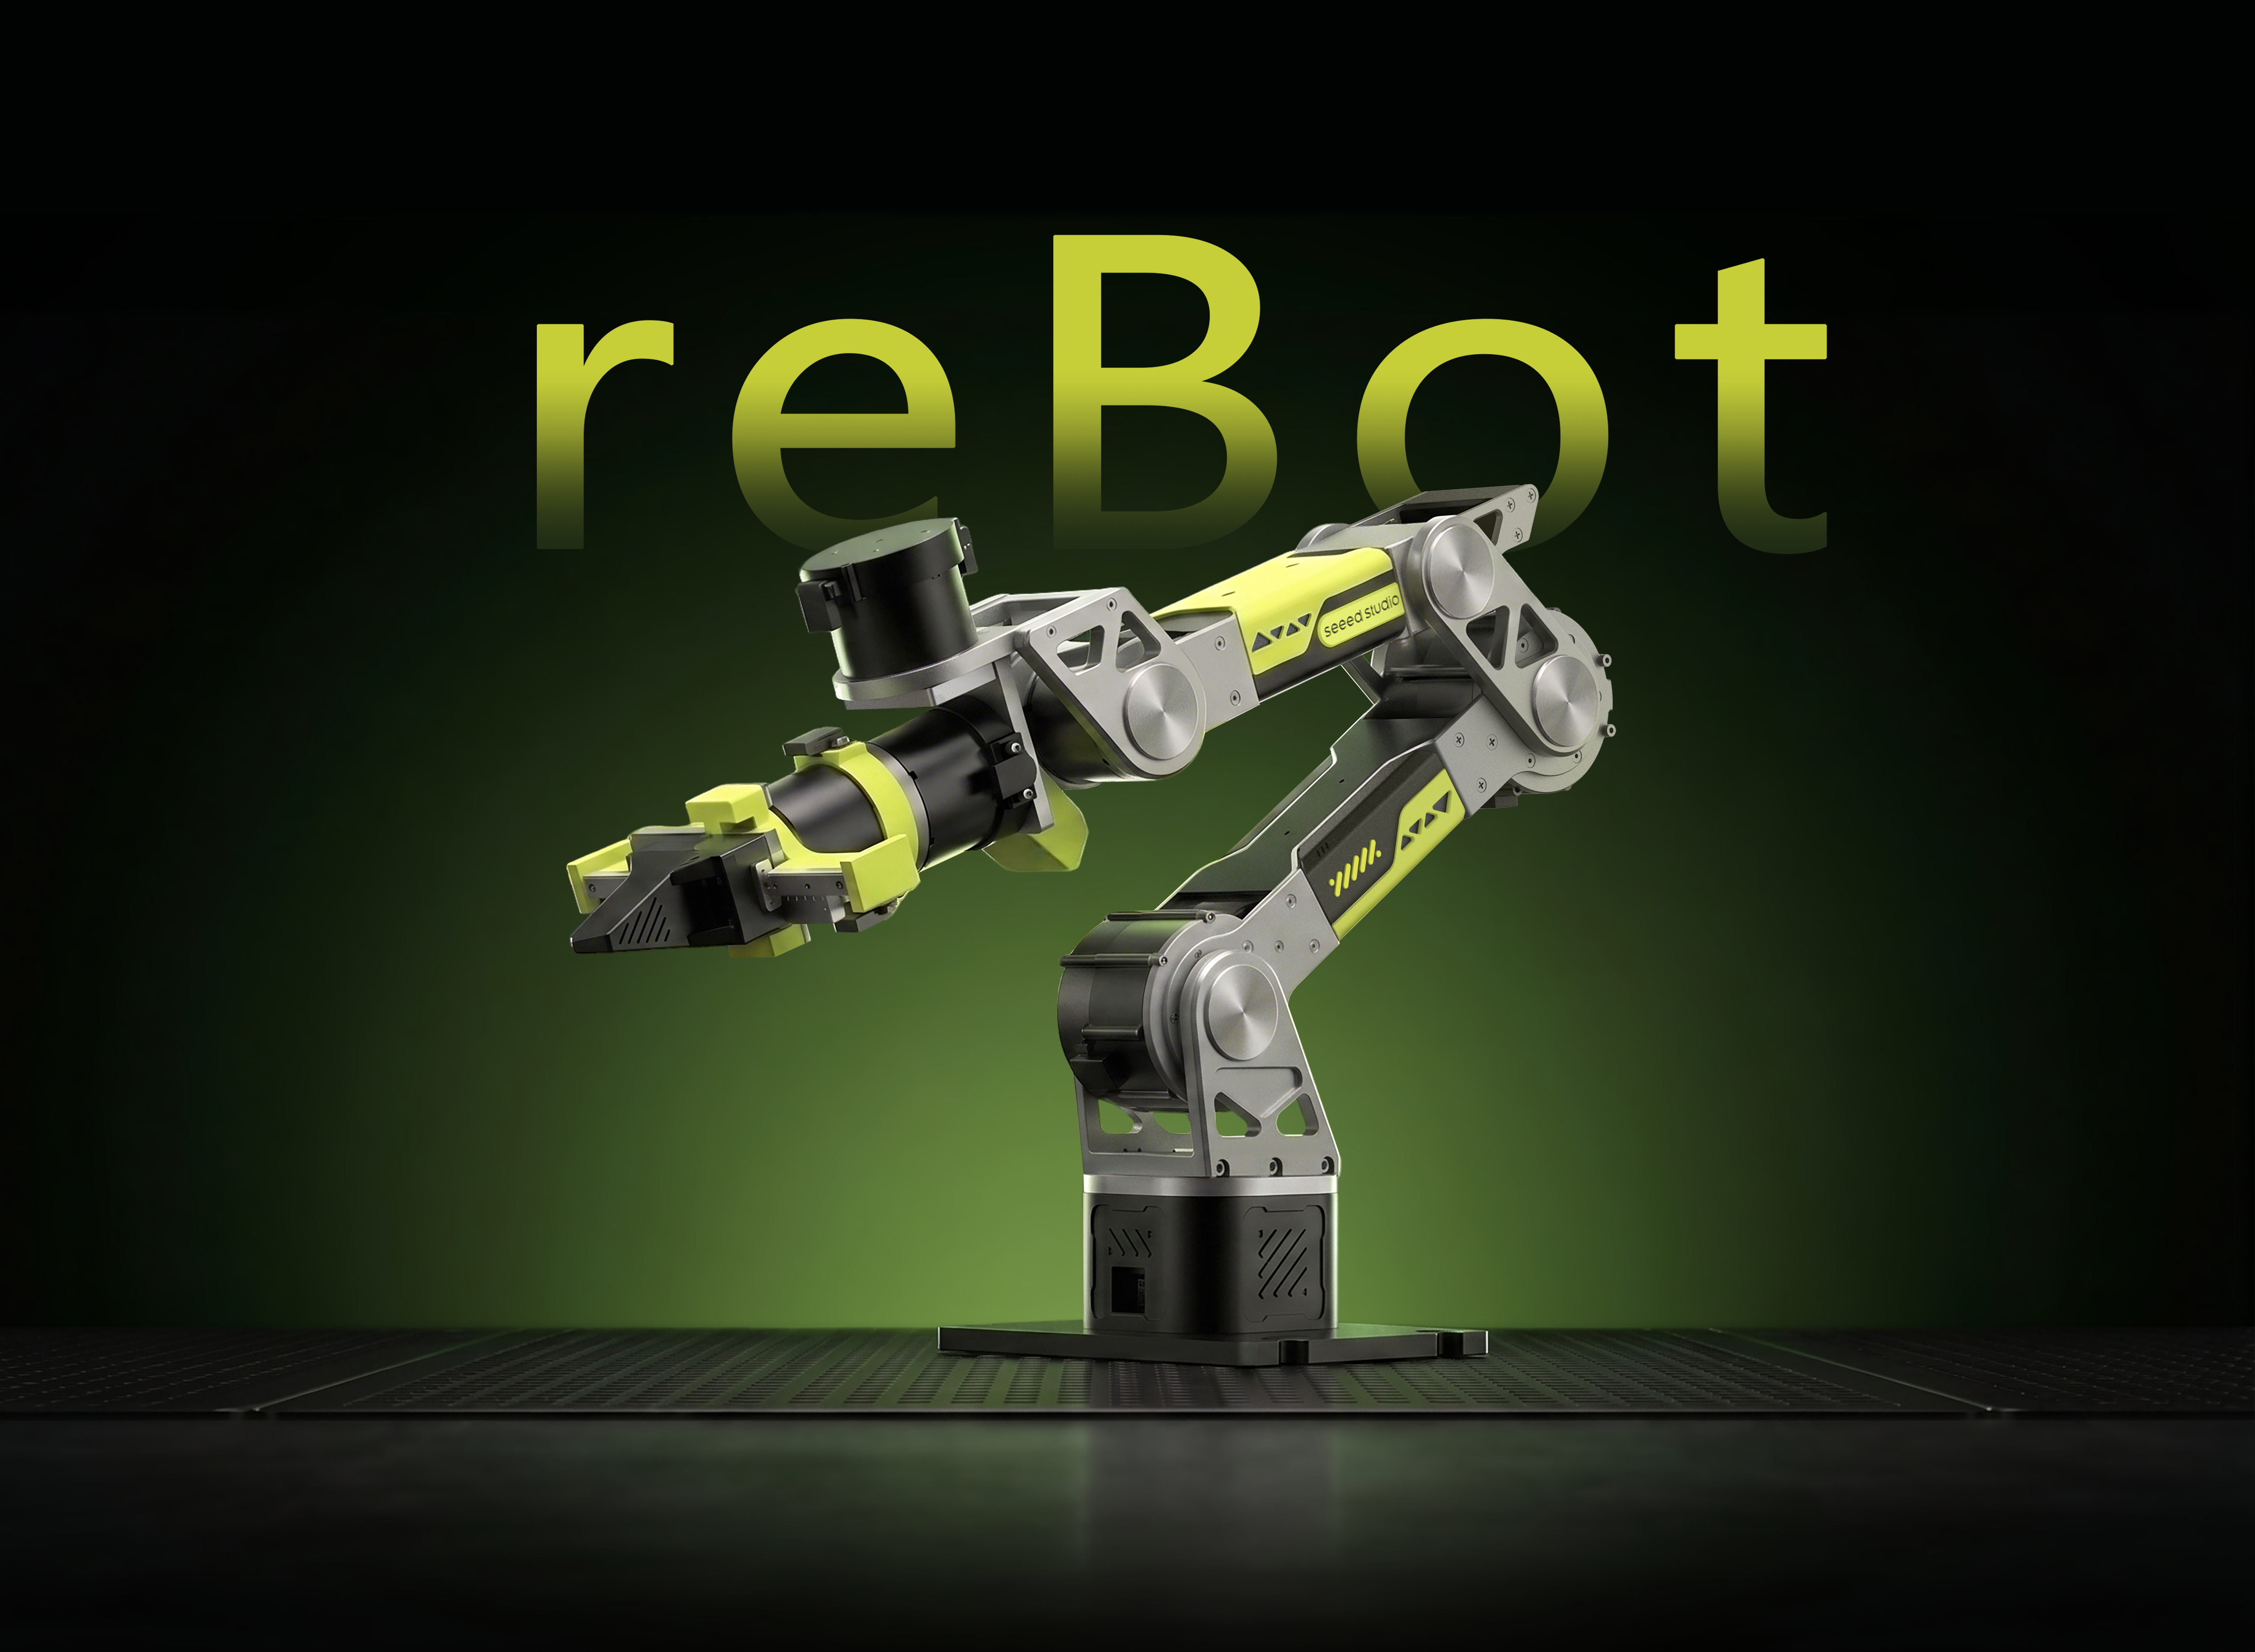
reBot-DevArm
4.4KSeeed-Projects/reBot-DevArm · PythonreBot-DevArm is a fully open-source robotic arm project (B601-DM and B601-RS models) aimed at lowering the barrier to learning Embodied AI, with all hardware files, BOM, and software openly released.
- 6
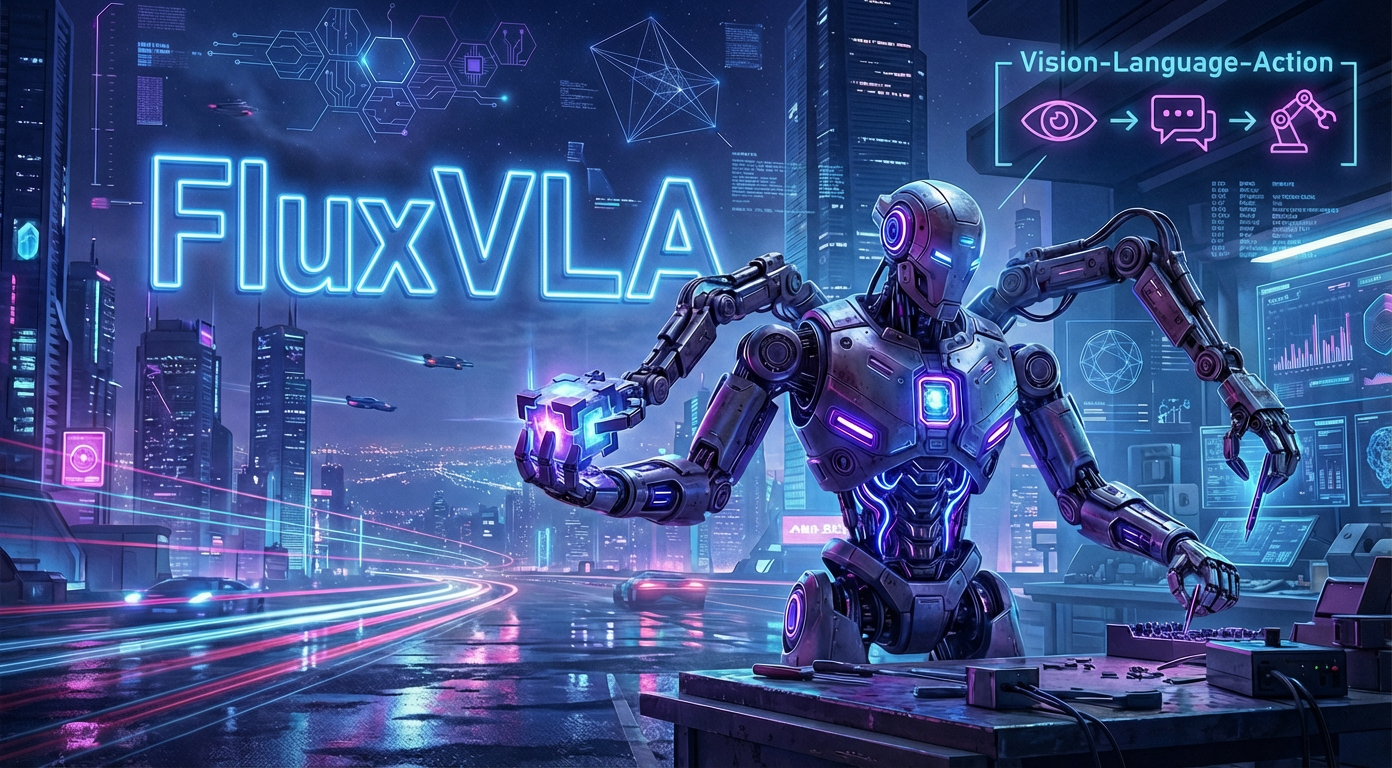
FluxVLA
748FluxVLA/FluxVLA · PythonFluxVLA is a full-stack engineering platform for embodied AI covering the whole loop from data to real-robot deployment for vision-language-action (VLA) models, built to lower the engineering barrier for VLA research and development.
- 7
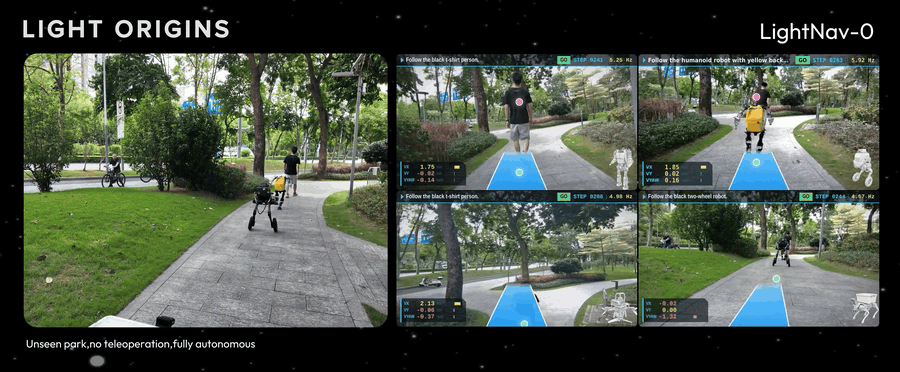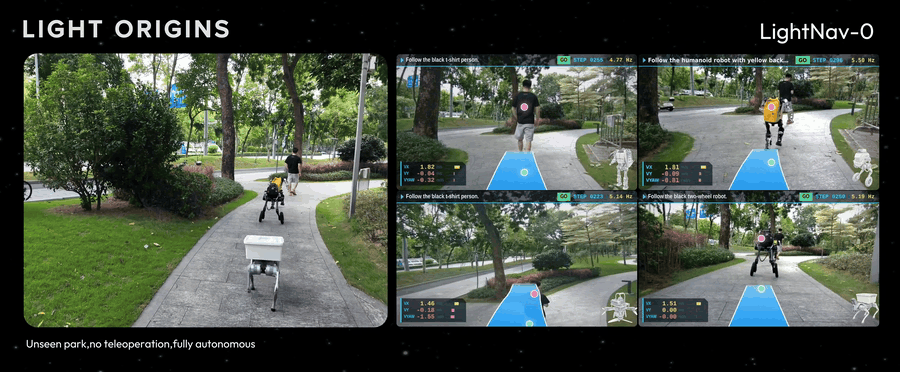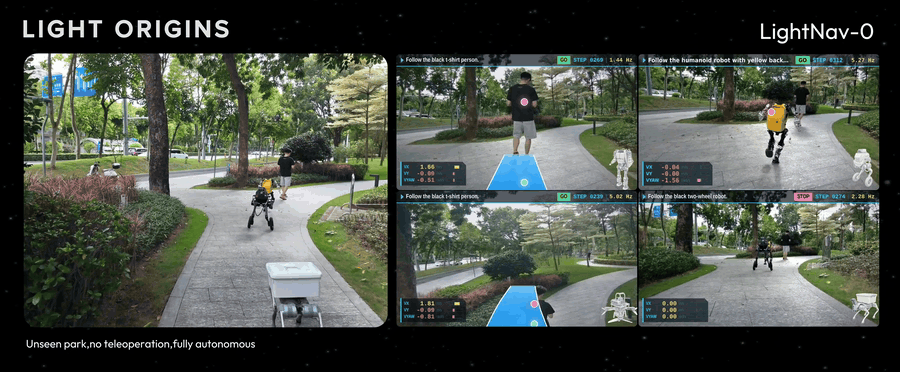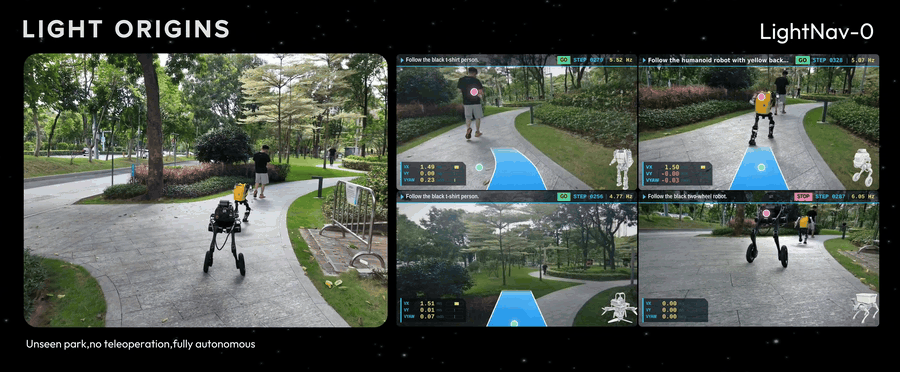
LightNav-0
721lightorigins/LightNav-0 · PythonLightNav-0 is a compact generalist embodied navigation model that gives humanoid, quadruped, wheeled and aerial robots the ability to follow language instructions and navigate autonomously in unseen environments, without any teleoperation.
- 8
Embodied-AI-Start
199ppsdk/Embodied-AI-StartA Chinese-language 'Embodied AI Starter Map' that organizes a learning path from robotics fundamentals (coordinates, kinematics, ROS 2) up to VLA policies, World Models, model-based RL and World Action Models (WAM), linking papers, code, benchmarks and practice guides at each step.
Related topics
Often tagged together