Topics / #world-action-model
World-action-model projects on GitHub
World-action models that couple environment prediction with action generation for robotics research.
As of , the most-starred World-action-model projects on GitHub are starVLA (3.8K stars), OpenWAM (1K stars) and FluxVLA (748 stars). GitHub.Locker tracks 8 World-action-model repositories with 7.1K stars combined. The fastest-growing on October 16 was video-prediction-policy-2, with +11 stars in a day.
Hot right now
Most stars gained in a day · Oct 16
 +11
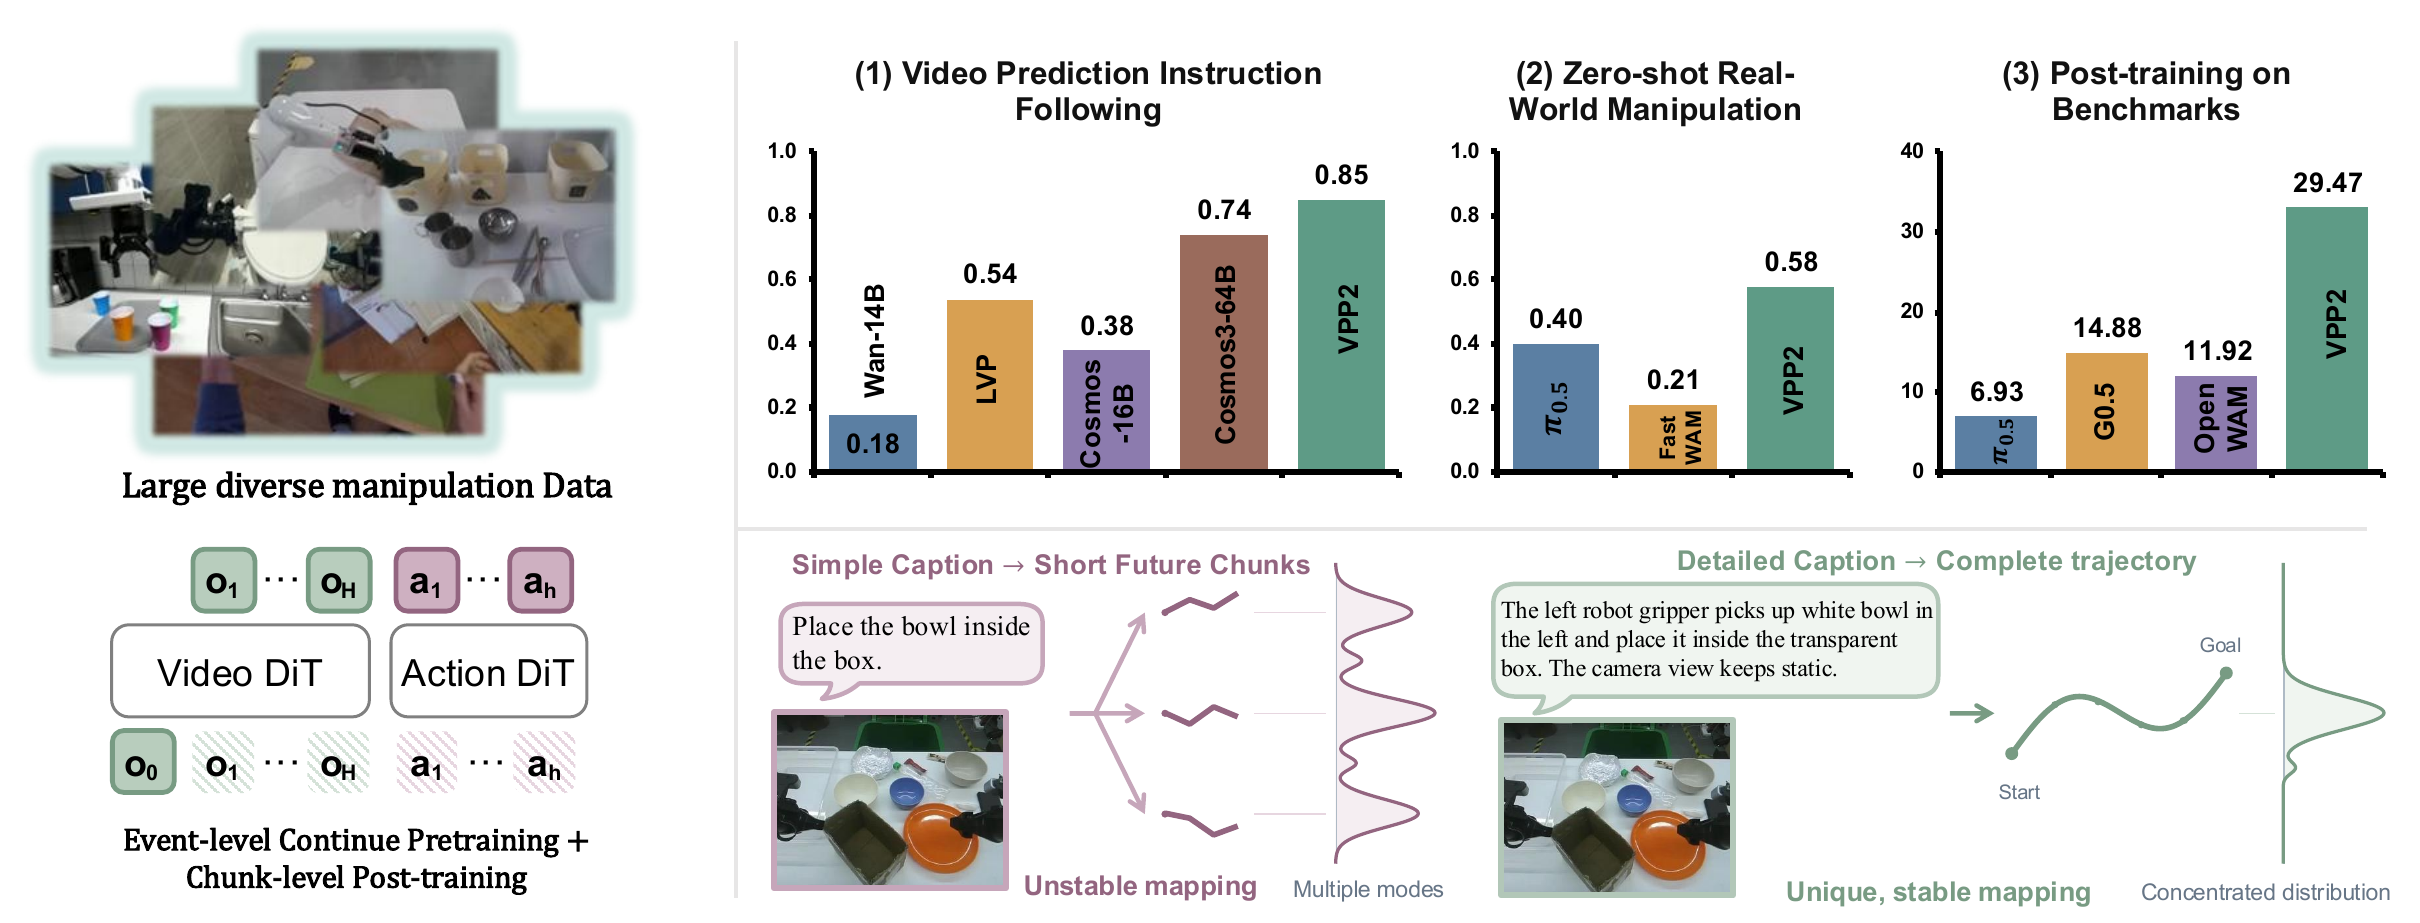
video-prediction-policy-2
roboterax/video-prediction-policy-2 · ★ 249Video Prediction Policy 2 (VPP2) is a world-action model (WAM) for robot manipulation that predicts future video frames and converts them into robot actions, with strong zero-shot generalization across tasks.
 +3
starVLA
starVLA/starVLA · ★ 3.8KStarVLA is an open-source, modular research codebase for building Vision-Language-Action (VLA) models that control generalist robots, letting you mix and match backbones, action heads, and training recipes like Lego bricks.
 +2
OpenWAM
OpenWAM-Official/OpenWAM · ★ 1KOpenWAM is an open research stack for systematically building World-Action Models (WAMs) for robots, breaking the usual tightly-coupled design choices into modular, swappable components you can compare in controlled experiments.
 +2
FluxVLA
FluxVLA/FluxVLA · ★ 748FluxVLA is a full-stack engineering platform for embodied AI covering the whole loop from data to real-robot deployment for vision-language-action (VLA) models, built to lower the engineering barrier for VLA research and development.
The all-time top
8 projects · by stars
- 3.8K#1 · starVLA/starVLA
starVLA
StarVLA is an open-source, modular research codebase for building Vision-Language-Action (VLA) models that control generalist robots, letting you mix and match backbones, action heads, and training recipes like Lego bricks.
- 1K#2 · OpenWAM-Official/OpenWAM
OpenWAM
OpenWAM is an open research stack for systematically building World-Action Models (WAMs) for robots, breaking the usual tightly-coupled design choices into modular, swappable components you can compare in controlled experiments.
- 748#3 · FluxVLA/FluxVLA
FluxVLA
FluxVLA is a full-stack engineering platform for embodied AI covering the whole loop from data to real-robot deployment for vision-language-action (VLA) models, built to lower the engineering barrier for VLA research and development.
- 4
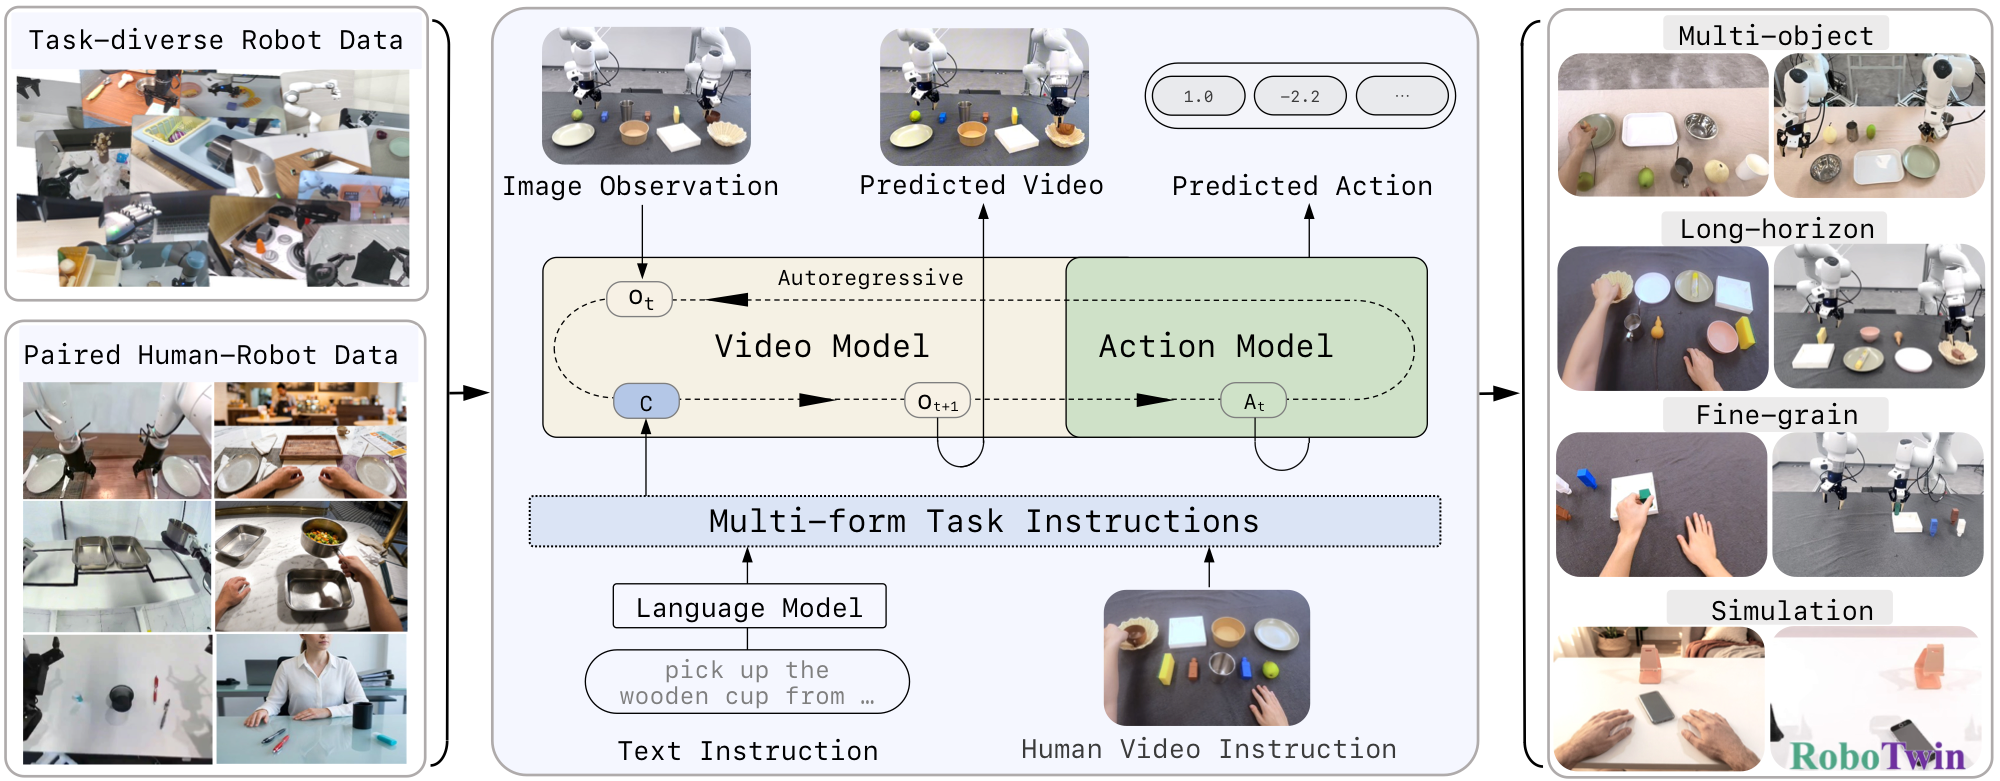
Zero-WAM
434robbyant-research/Zero-WAM · PythonZero-WAM is a research method for zero-shot cross-task robotic manipulation: a causal video-action policy that learns in-context world-action modeling, predicting future robot observations and executable actions from either language instructions or human demonstration videos.
- 5
EasyWAM
401OpenMOSS/EasyWAM · PythonEasyWAM is a unified research codebase for training, fine-tuning, and evaluating World Action Models (WAMs) — models that jointly predict future video and robot actions for embodied-AI and robotics research.
- 6
video-prediction-policy-2
249roboterax/video-prediction-policy-2 · PythonVideo Prediction Policy 2 (VPP2) is a world-action model (WAM) for robot manipulation that predicts future video frames and converts them into robot actions, with strong zero-shot generalization across tasks.
- 7
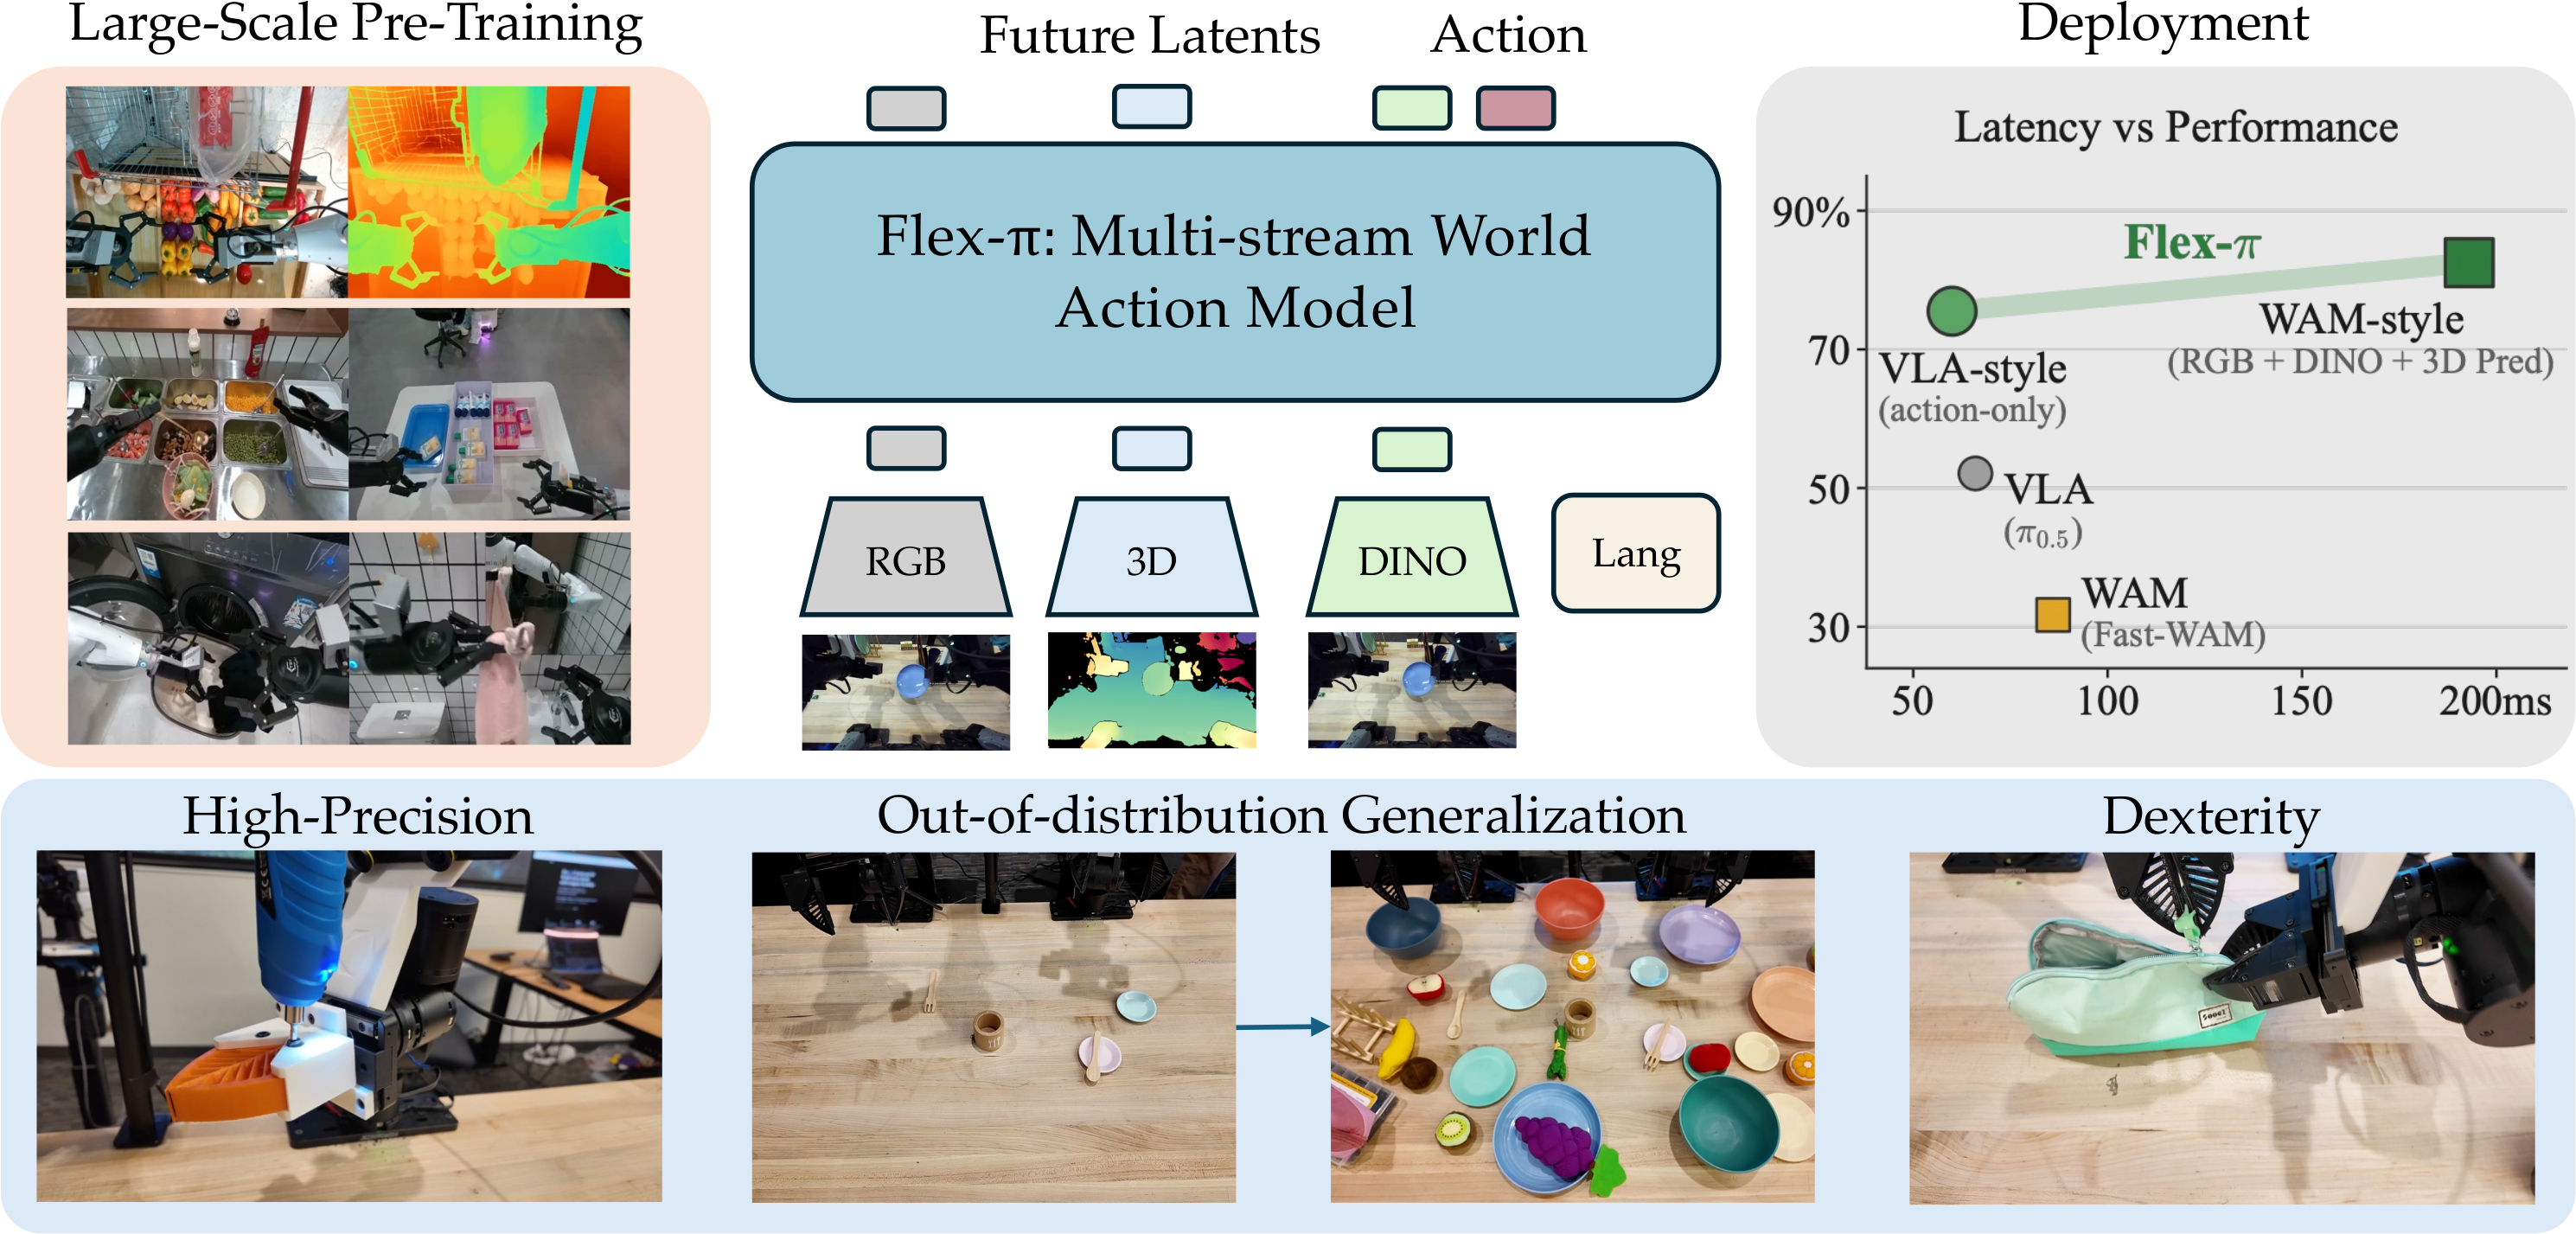
flex-pi
225geyan21/flex-pi · PythonFlex-π is a 6B-parameter world-action model for robot manipulation that jointly predicts future RGB, 3D pointmaps, DINOv3 semantics, and actions from one checkpoint, so it can deploy as a VLA, a full world model, or anything in between.
- 8
Embodied-AI-Start
199ppsdk/Embodied-AI-StartA Chinese-language 'Embodied AI Starter Map' that organizes a learning path from robotics fundamentals (coordinates, kinematics, ROS 2) up to VLA policies, World Models, model-based RL and World Action Models (WAM), linking papers, code, benchmarks and practice guides at each step.
Related topics
Often tagged together