Topics / #embodied-ai
Embodied AI projects on GitHub
AI that perceives and acts in physical or simulated environments like robotics.
As of , the most-starred Embodied AI projects on GitHub are genesis-world (30.1K stars), cs249r_book (29K stars) and lerobot (28.2K stars). GitHub.Locker tracks 32 Embodied AI repositories with 143.1K stars combined. The fastest-growing on October 16 was jumper, with +28 stars in a day.
Hot right now
Most stars gained in a day · Oct 16
 +28
jumper
KingKongRobotics/jumper · ★ 2.7KJumper is a 22-DoF crab robot, and this repository is its AI toolkit for creating appearances, training motions, and building scenes for it.
 +24
lerobot
huggingface/lerobot · ★ 28.2KLeRobot is Hugging Face's open-source project providing models, datasets, and tools for real-world robotics in PyTorch, aiming to lower the barrier to entry for building and deploying robot learning policies.
 +17
Embodied-AI-Guide
TianxingChen/Embodied-AI-Guide · ★ 16.5KA free, encyclopedia-style Chinese knowledge base and resource index for embodied AI — robots that perceive and act in the physical world — maintained by the Lumina Embodied AI community. It is one of the most popular embodied-AI guides in China, with over 16,000 GitHub stars.
 +15
cs249r_book
harvard-edge/cs249r_book · ★ 29KAn open textbook and full curriculum on Machine Learning Systems — AI engineering — from Harvard's CS249r course: four volumes covering foundations, scaling, agentic AI, and physical AI, plus labs, projects, and instructor materials.
The all-time top
32 projects · by stars
- 30.1K
 #1 · Genesis-Embodied-AI/genesis-world
genesis-world
It's a simulation platform for general-purpose robotics and embodied AI learning: a multi-physics engine, a photorealistic renderer (Nyx) and a cross-platform compiler (Quadrants) behind one Python API.
- 29K#2 · harvard-edge/cs249r_book
cs249r_book
An open textbook and full curriculum on Machine Learning Systems — AI engineering — from Harvard's CS249r course: four volumes covering foundations, scaling, agentic AI, and physical AI, plus labs, projects, and instructor materials.
- 28.2K#3 · huggingface/lerobot
lerobot
LeRobot is Hugging Face's open-source project providing models, datasets, and tools for real-world robotics in PyTorch, aiming to lower the barrier to entry for building and deploying robot learning policies.
- 4
Embodied-AI-Guide
16.5KTianxingChen/Embodied-AI-GuideA free, encyclopedia-style Chinese knowledge base and resource index for embodied AI — robots that perceive and act in the physical world — maintained by the Lumina Embodied AI community. It is one of the most popular embodied-AI guides in China, with over 16,000 GitHub stars.
- 5

openpi
14.3KPhysical-Intelligence/openpi · Pythonopenpi is a collection of open-source vision-language-action (VLA) models for robotics from the Physical Intelligence team, including pi0, pi0-FAST, and pi0.5, with pretrained checkpoints and code for fine-tuning and running them.
- 6
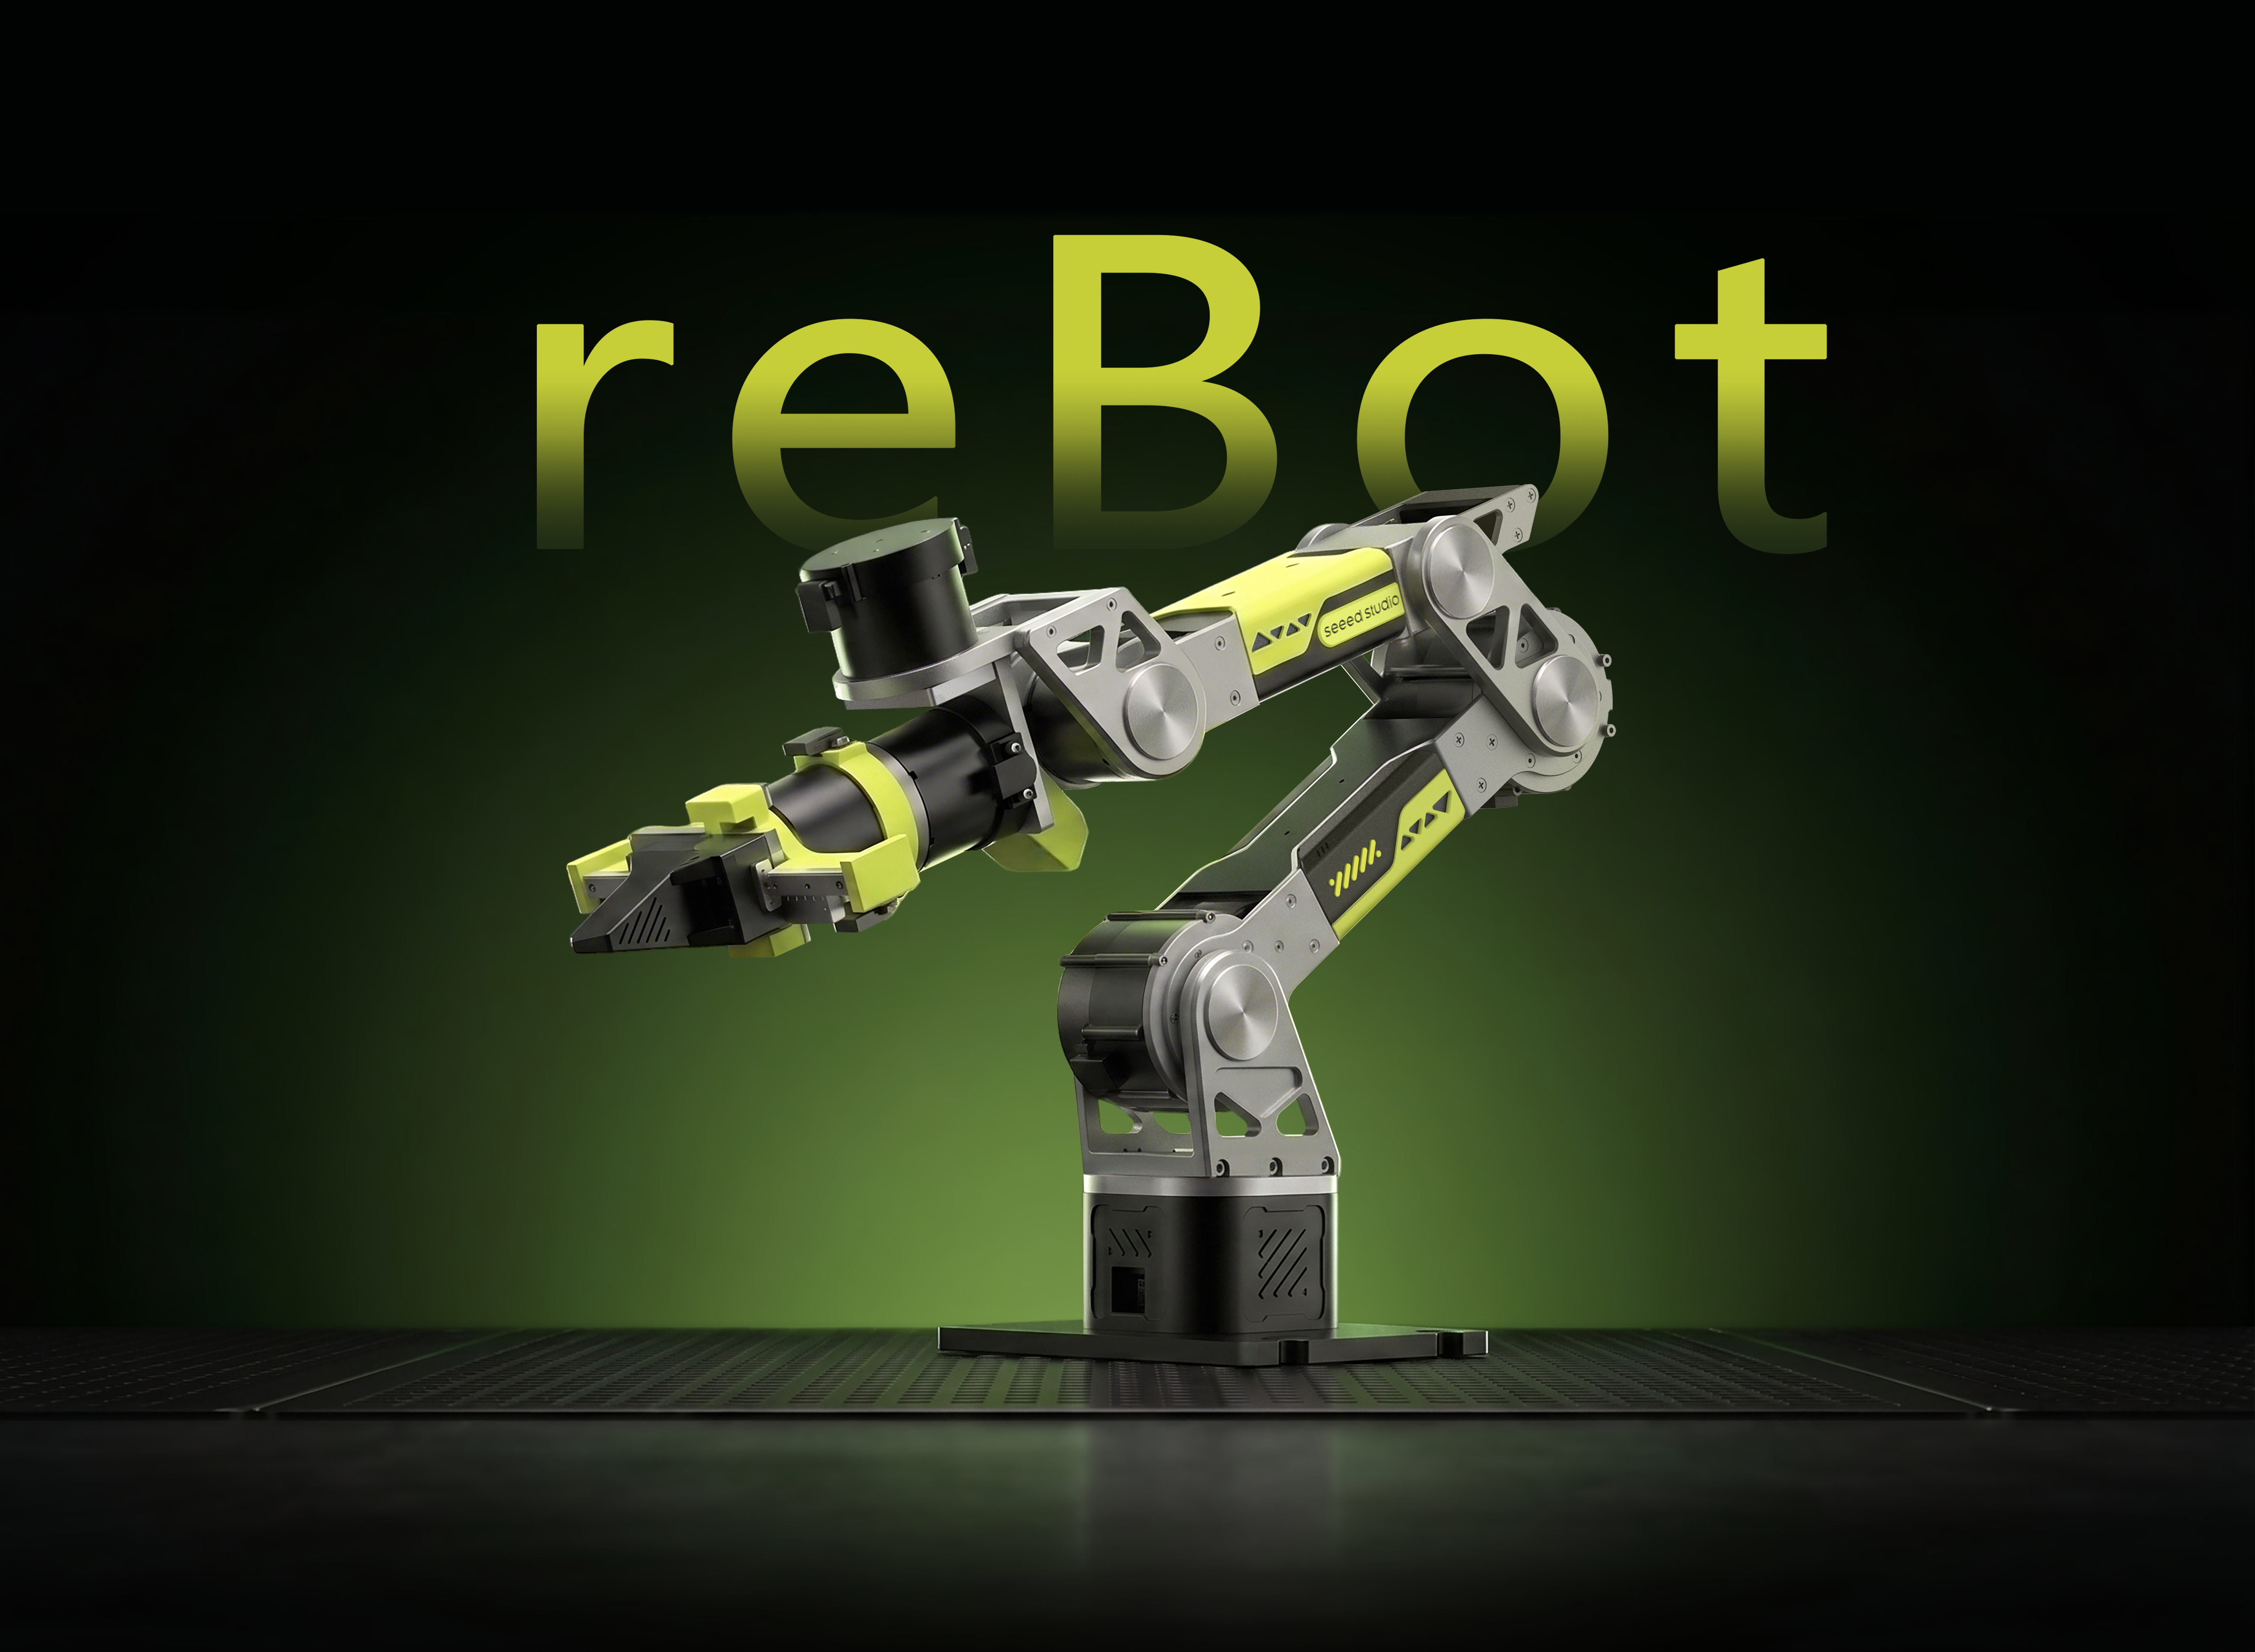
reBot-DevArm
4.4KSeeed-Projects/reBot-DevArm · PythonreBot-DevArm is a fully open-source robotic arm project (B601-DM and B601-RS models) aimed at lowering the barrier to learning Embodied AI, with all hardware files, BOM, and software openly released.
- 7

GR00T-WholeBodyControl
3.8KNVlabs/GR00T-WholeBodyControl · PythonNVIDIA GR00T Whole-Body Control — a codebase hosting pretrained checkpoints plus training, evaluation, and deployment code for advanced humanoid robot controllers: the Decoupled WBC used in GR00T N1.5/N1.6, the GEAR-SONIC series, and MotionBricks.
- 8
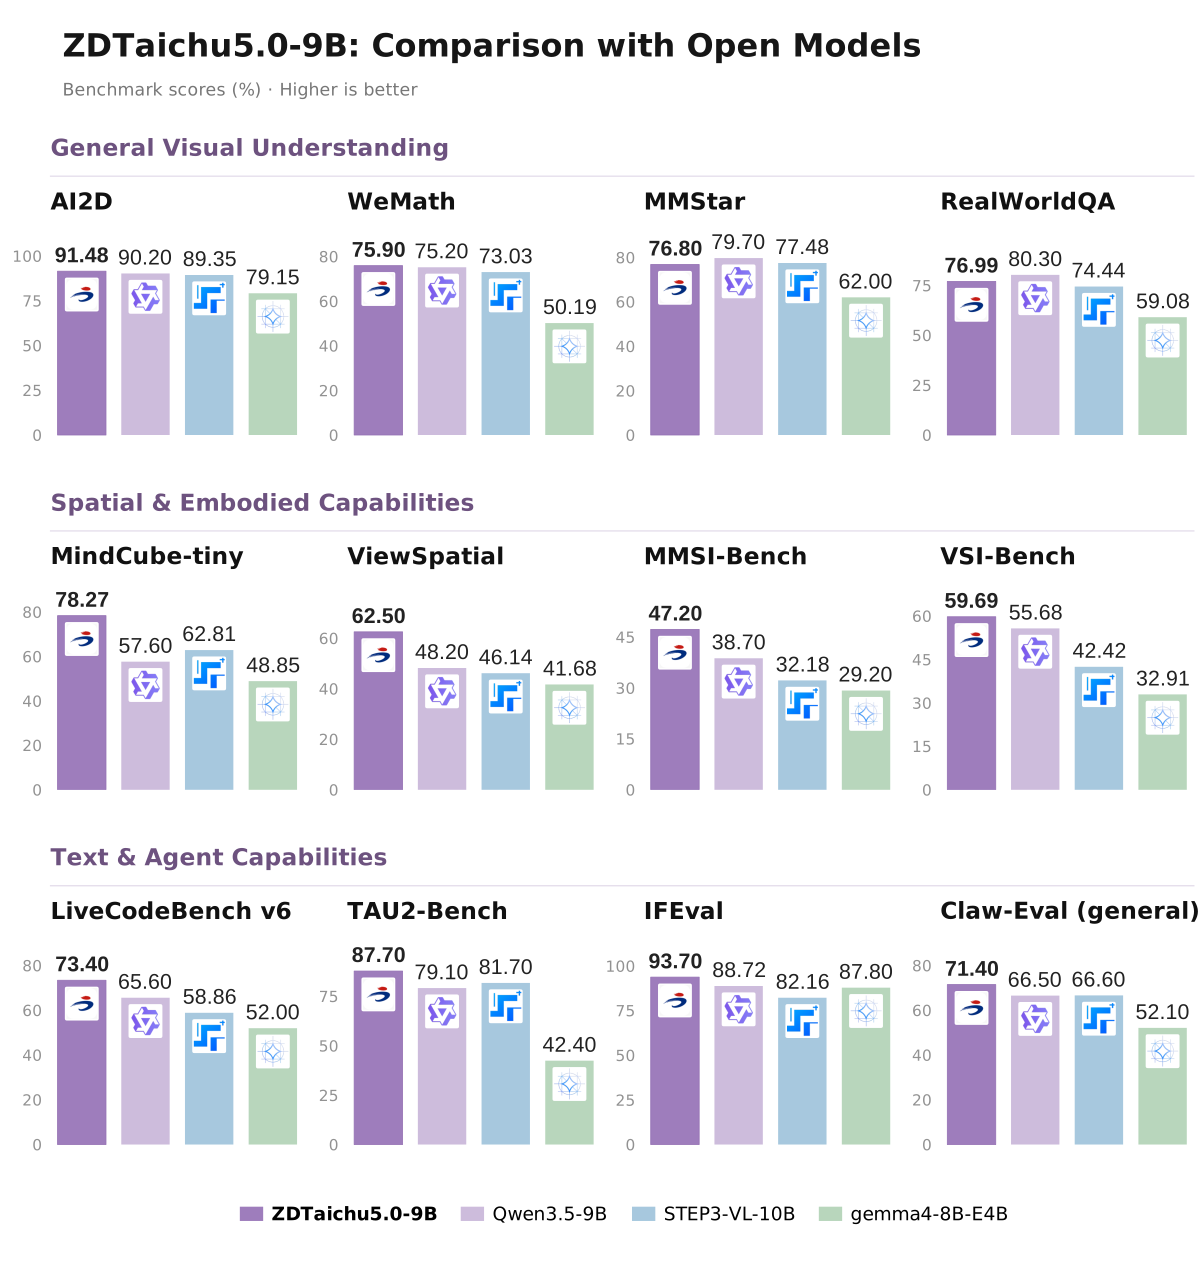
ZDTaichu5.0-9B
3.1KTaichu-AI/ZDTaichu5.0-9B · PythonZDTaichu5.0-9B is a multimodal foundation model that combines a Qwen3.5-9B language backbone with a C-RADIOv4-H vision encoder for general visual understanding, spatial reasoning, embodied-AI research and agentic tool use.
- 9
jumper
2.7KKingKongRobotics/jumper · PythonJumper is a 22-DoF crab robot, and this repository is its AI toolkit for creating appearances, training motions, and building scenes for it.
- 10
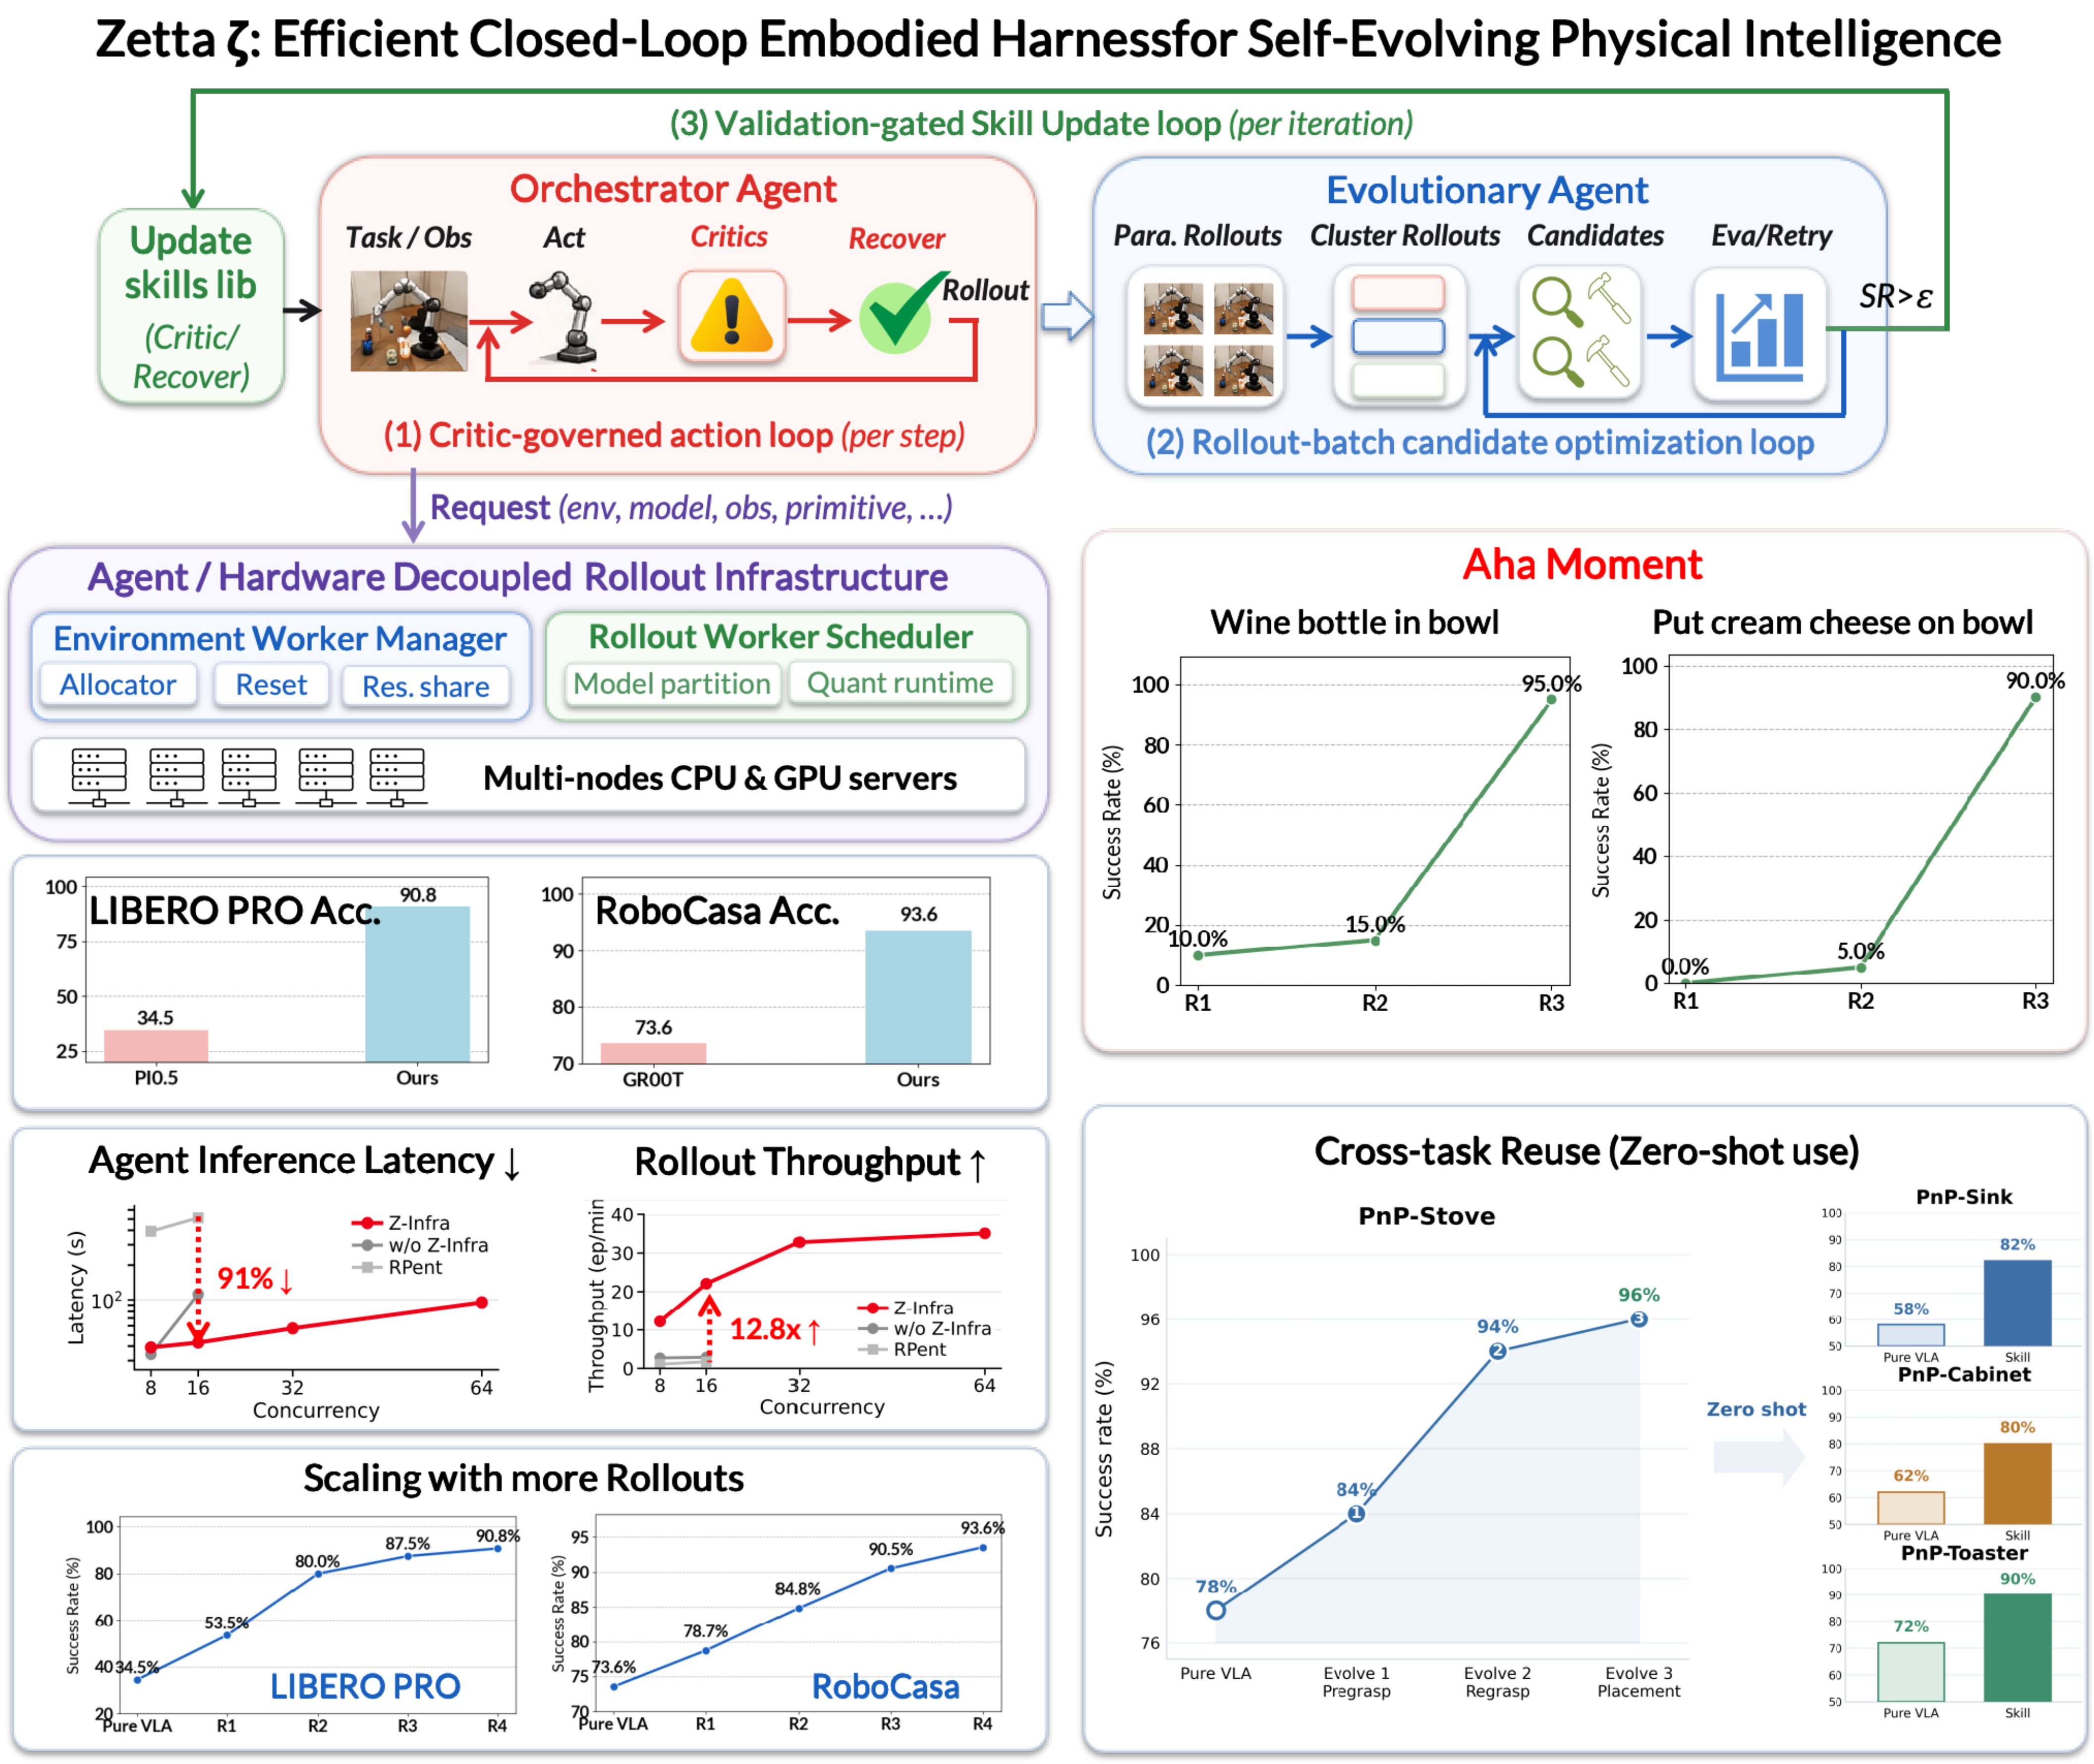
Zetta-Embodiment
1.3Kair-embodied-brain/Zetta-Embodiment · PythonZetta is a closed-loop embodied harness that evolves code-based runtime critics and recovery skills online while keeping the base robot policy frozen, reaching 90.8% success on LIBERO-Pro and 93.6% on RoboCasa with an 11.1x inference speedup.
- 11
OpenWAM
1KOpenWAM-Official/OpenWAM · PythonOpenWAM is an open research stack for systematically building World-Action Models (WAMs) for robots, breaking the usual tightly-coupled design choices into modular, swappable components you can compare in controlled experiments.
- 12
FluxVLA
748FluxVLA/FluxVLA · PythonFluxVLA is a full-stack engineering platform for embodied AI covering the whole loop from data to real-robot deployment for vision-language-action (VLA) models, built to lower the engineering barrier for VLA research and development.
- 13
project_superdex
738facebookresearch/project_superdex · C++Project SuperDex is a unified simulation platform for dexterous manipulation research from Meta, combining a contact-first physics engine, robotics authoring tools, and a reinforcement learning interface, with VR-based teleoperation planned for Q4 2026.
- 14
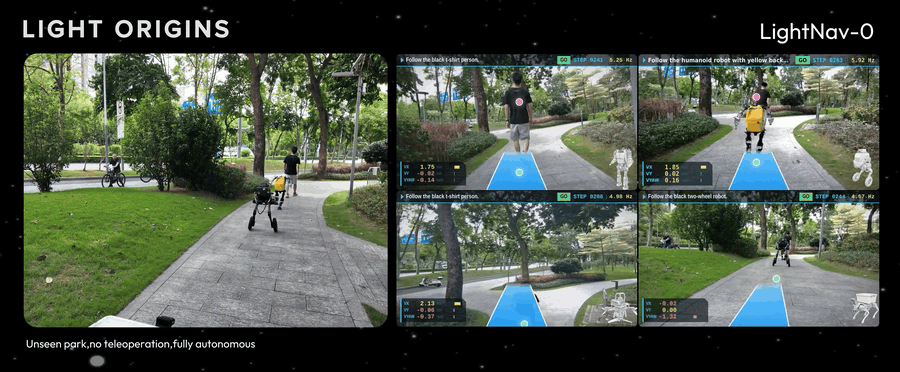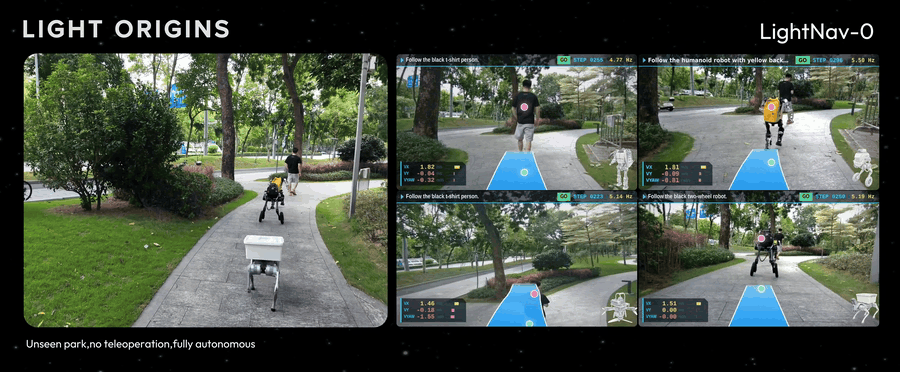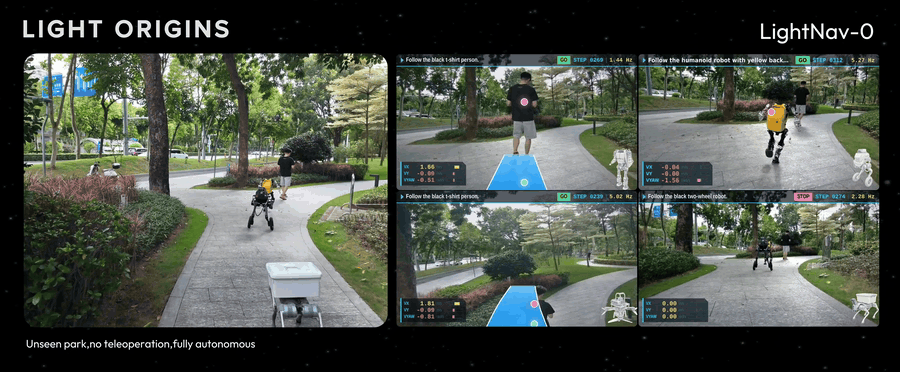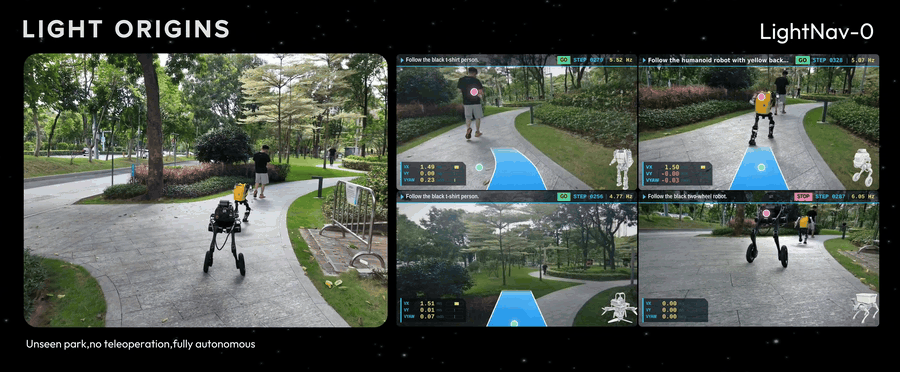
LightNav-0
721lightorigins/LightNav-0 · PythonLightNav-0 is a compact generalist embodied navigation model that gives humanoid, quadruped, wheeled and aerial robots the ability to follow language instructions and navigate autonomously in unseen environments, without any teleoperation.
- 15
LoongForge
687baidu-baige/LoongForge · PythonAn open-source training framework from Baidu's Baige team for LLMs, VLMs, diffusion and embodied models, built for faster training and lower cost on NVIDIA GPUs and Kunlun XPUs.
- 16
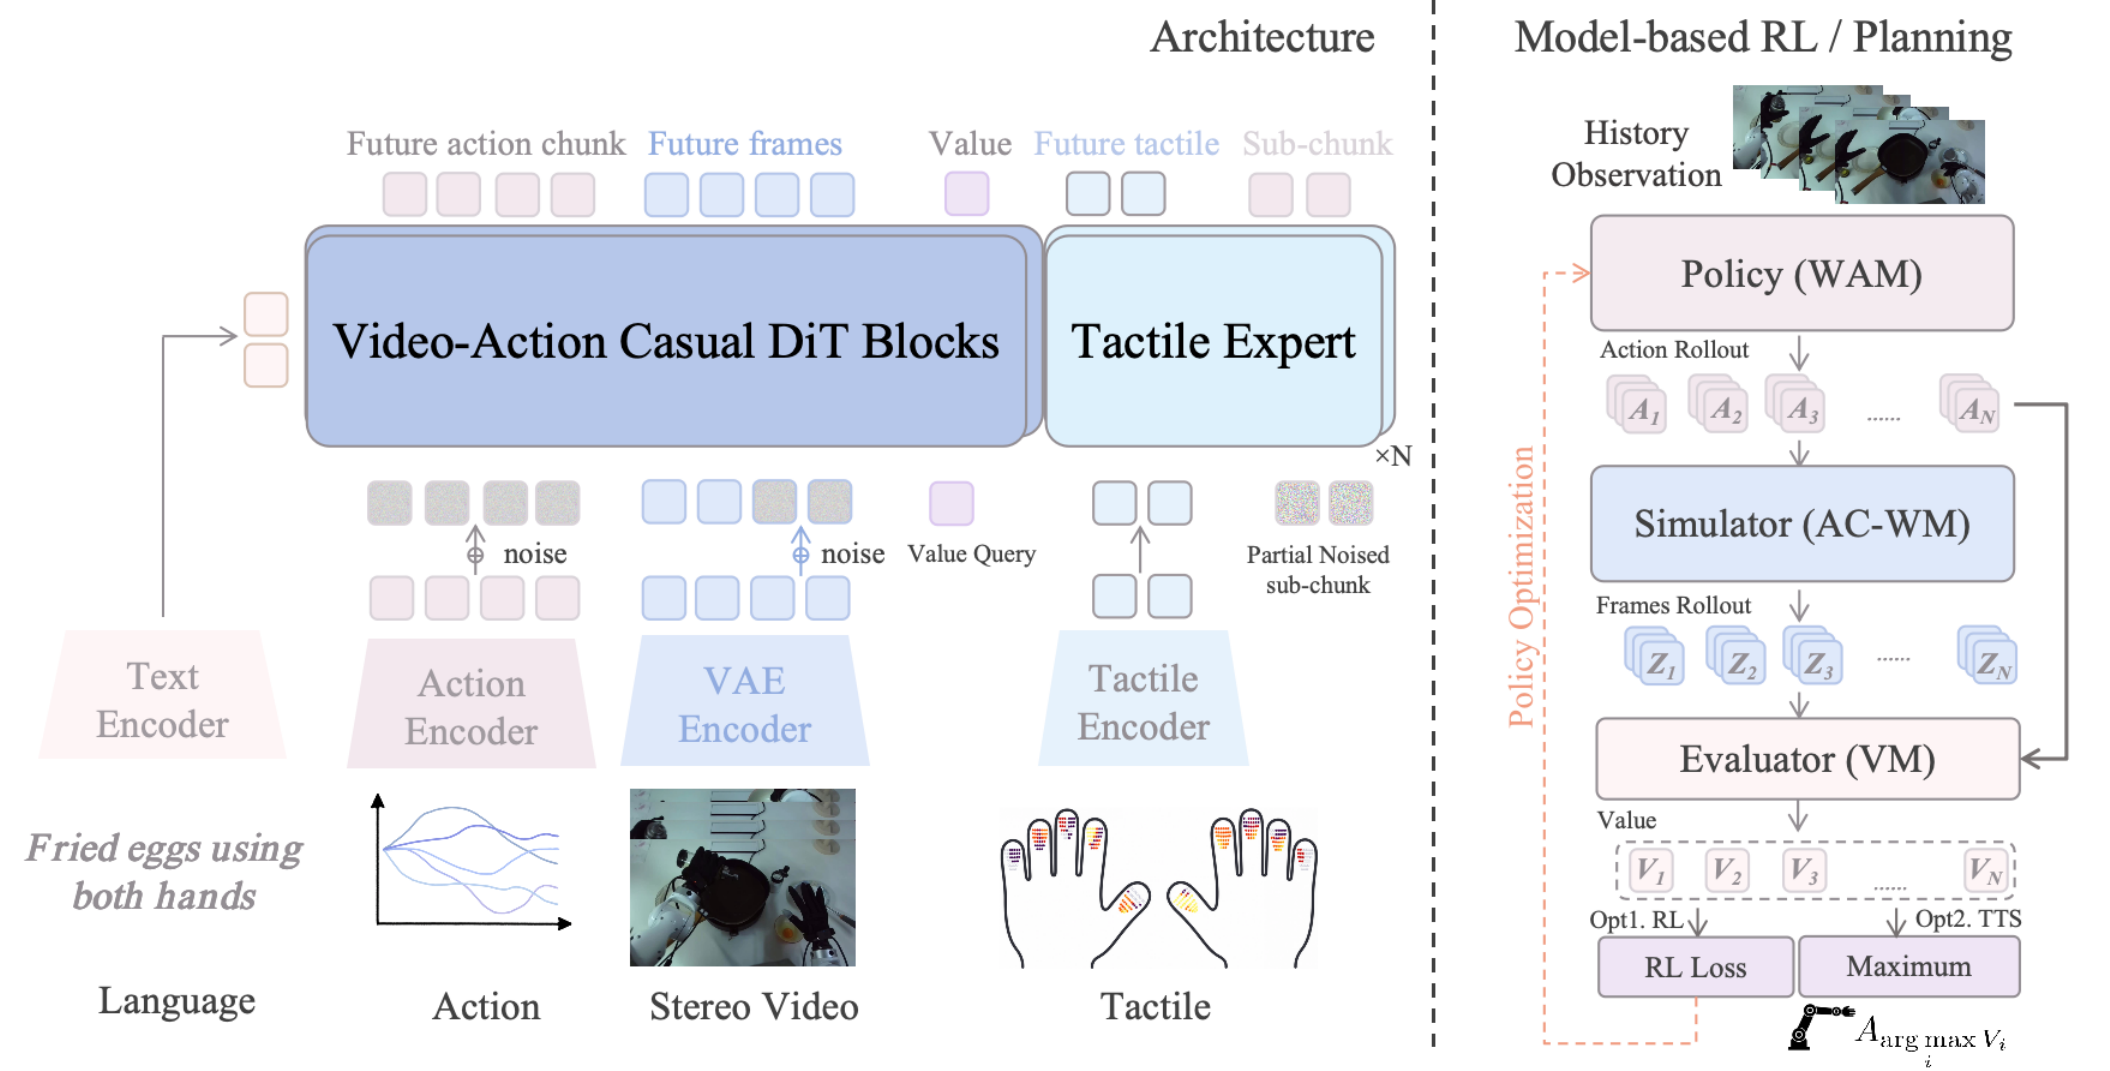
Motus2
685shengshu-ai/Motus2Motus2 is a self-evolving general world model for dexterous robot manipulation. A single model with shared weights acts as a policy, a simulator, and an evaluator, coupling them into a closed decision-and-learning loop so the system can perceive, predict, act, and improve itself.
- 17

intrinsic-core
583intrinsic-ai/intrinsic-core · C++Intrinsic Core is an open, local runtime, SDK and hardware-agnostic real-time control framework for industrial robotics. It provides foundational building blocks for AI-enabled robot applications, from simulation and 6-DoF perception down to hardware execution.
- 18
WholebodyVLA
580OpenDriveLab/WholebodyVLAWholeBodyVLA is an ICLR 2026 research project introducing a unified Vision-Language-Action framework for closed-loop humanoid whole-body loco-manipulation control, and this repository doubles as a curated, continuously updated list of VLA papers for humanoid robots.
- 19
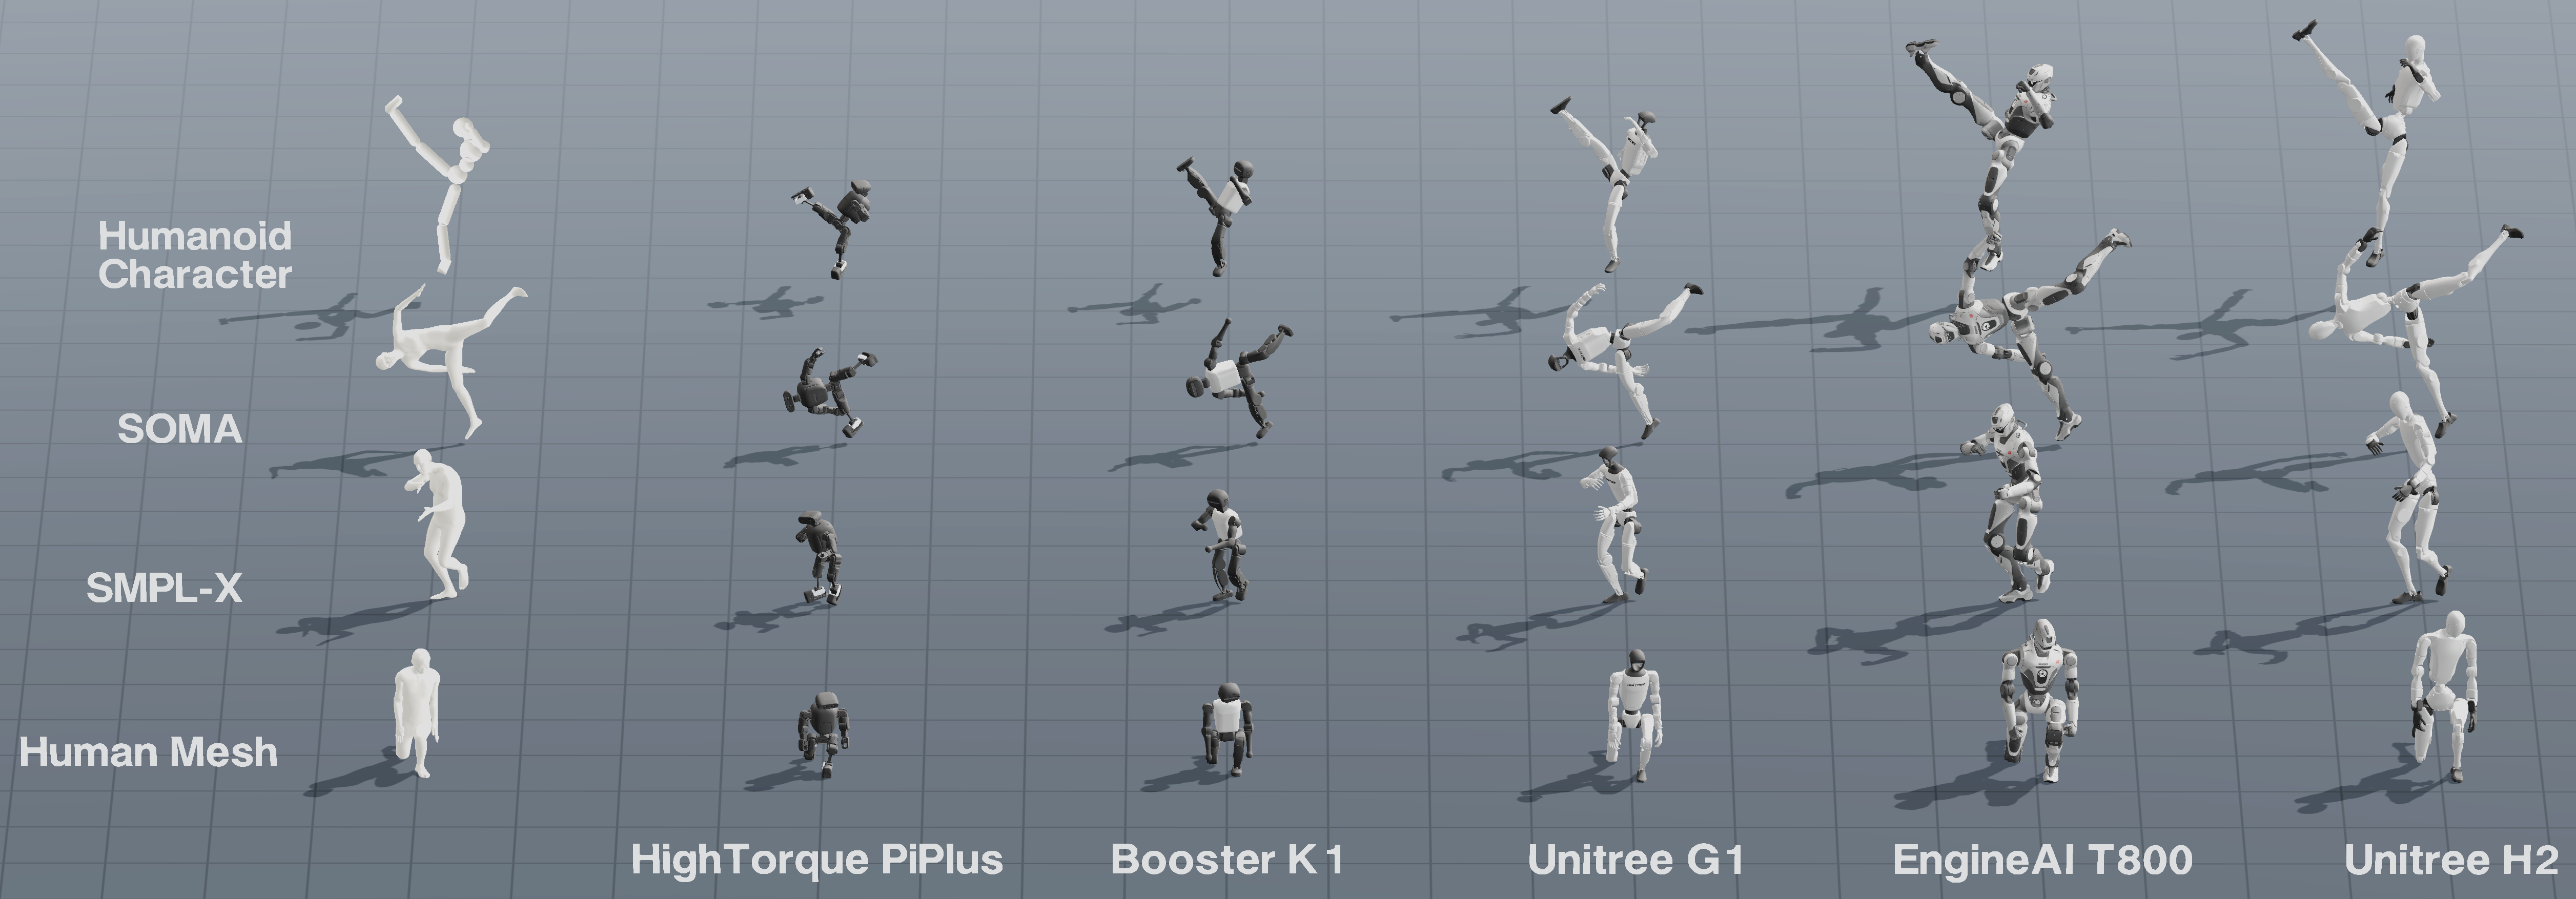
UMR
491hanyang9/UMR · PythonUMR (Unified Motion Retargeting) is a research codebase that retargets human motion onto humanoid robots by treating the moving exterior body surface as a shared interface between the source motion and the robot.
- 20
cadence
449muellerberndt/cadence · PythonCadence is an open research library toward general intelligence: a NumPy collection of 'brains' that compute by settling into an equilibrium and learn by detuning it, aiming to acquire skills from live experience the way animals and humans do.
- 21
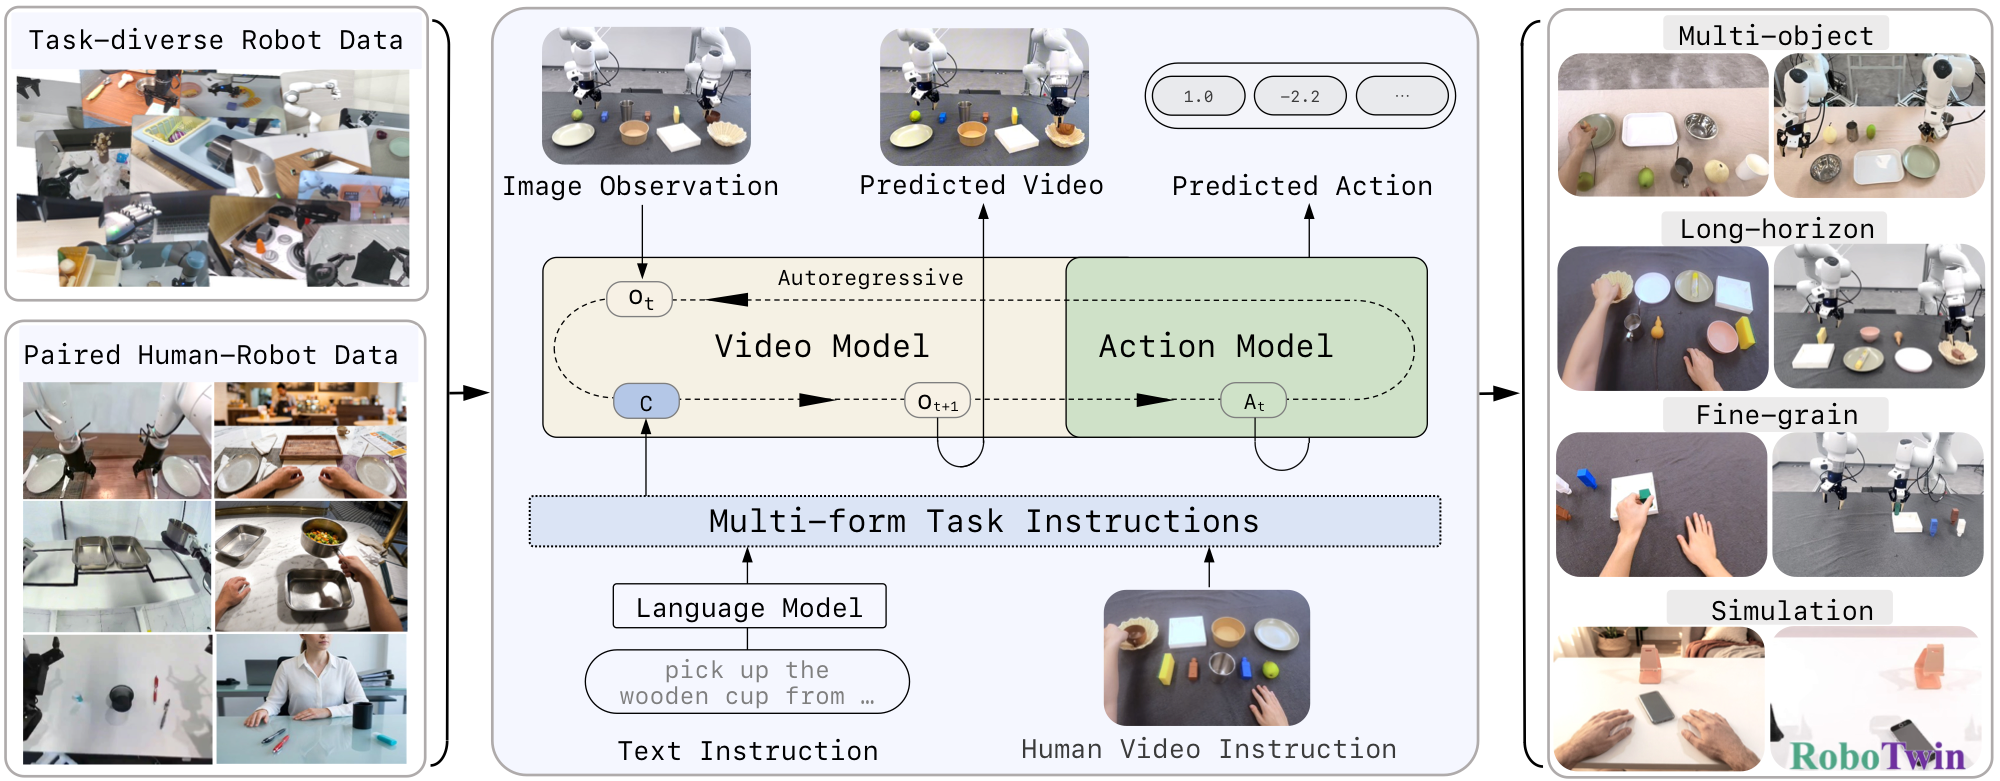
Zero-WAM
434robbyant-research/Zero-WAM · PythonZero-WAM is a research method for zero-shot cross-task robotic manipulation: a causal video-action policy that learns in-context world-action modeling, predicting future robot observations and executable actions from either language instructions or human demonstration videos.
- 22
EasyWAM
401OpenMOSS/EasyWAM · PythonEasyWAM is a unified research codebase for training, fine-tuning, and evaluating World Action Models (WAMs) — models that jointly predict future video and robot actions for embodied-AI and robotics research.
- 23
RoboICL
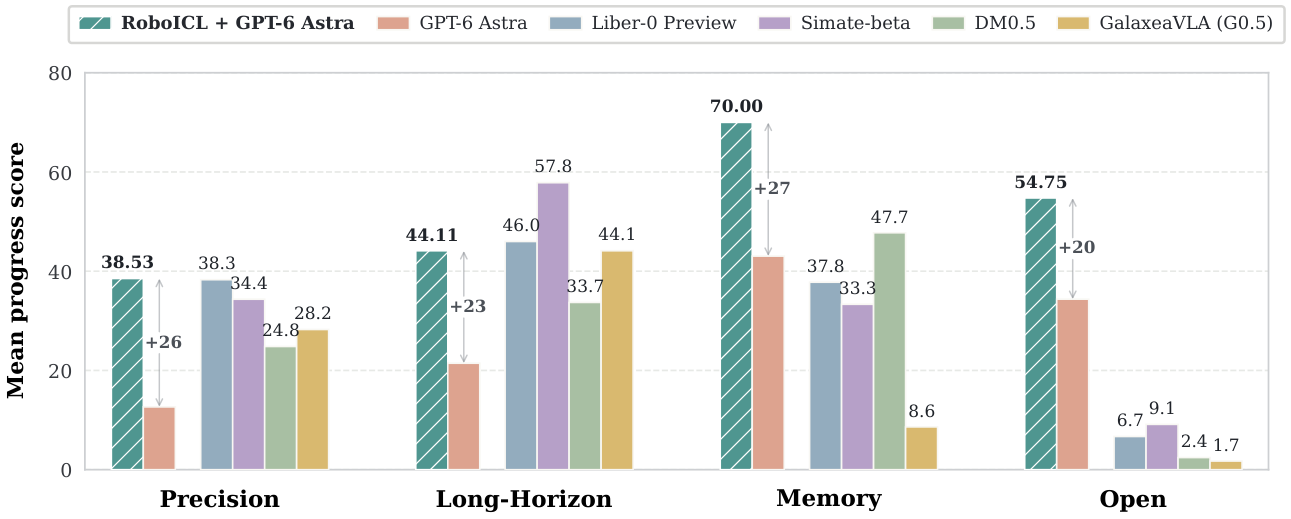
268Mosi-AI/RoboICL · PythonRoboICL is a research framework that lets a frozen, general-purpose vision-language model (GPT-6 Astra) control a robot in simulation purely through in-context learning, without training a dedicated robot policy.
- 24

quackd
263rokbenko/quackd · Pythonquackd is an open-source daemon that gives small robots a brain: it takes a goal in plain language and plans the right sequence of the robot's own existing skills to carry it out, using an LLM like Claude, OpenAI, Gemini, Grok or a local model.
- 25
video-prediction-policy-2
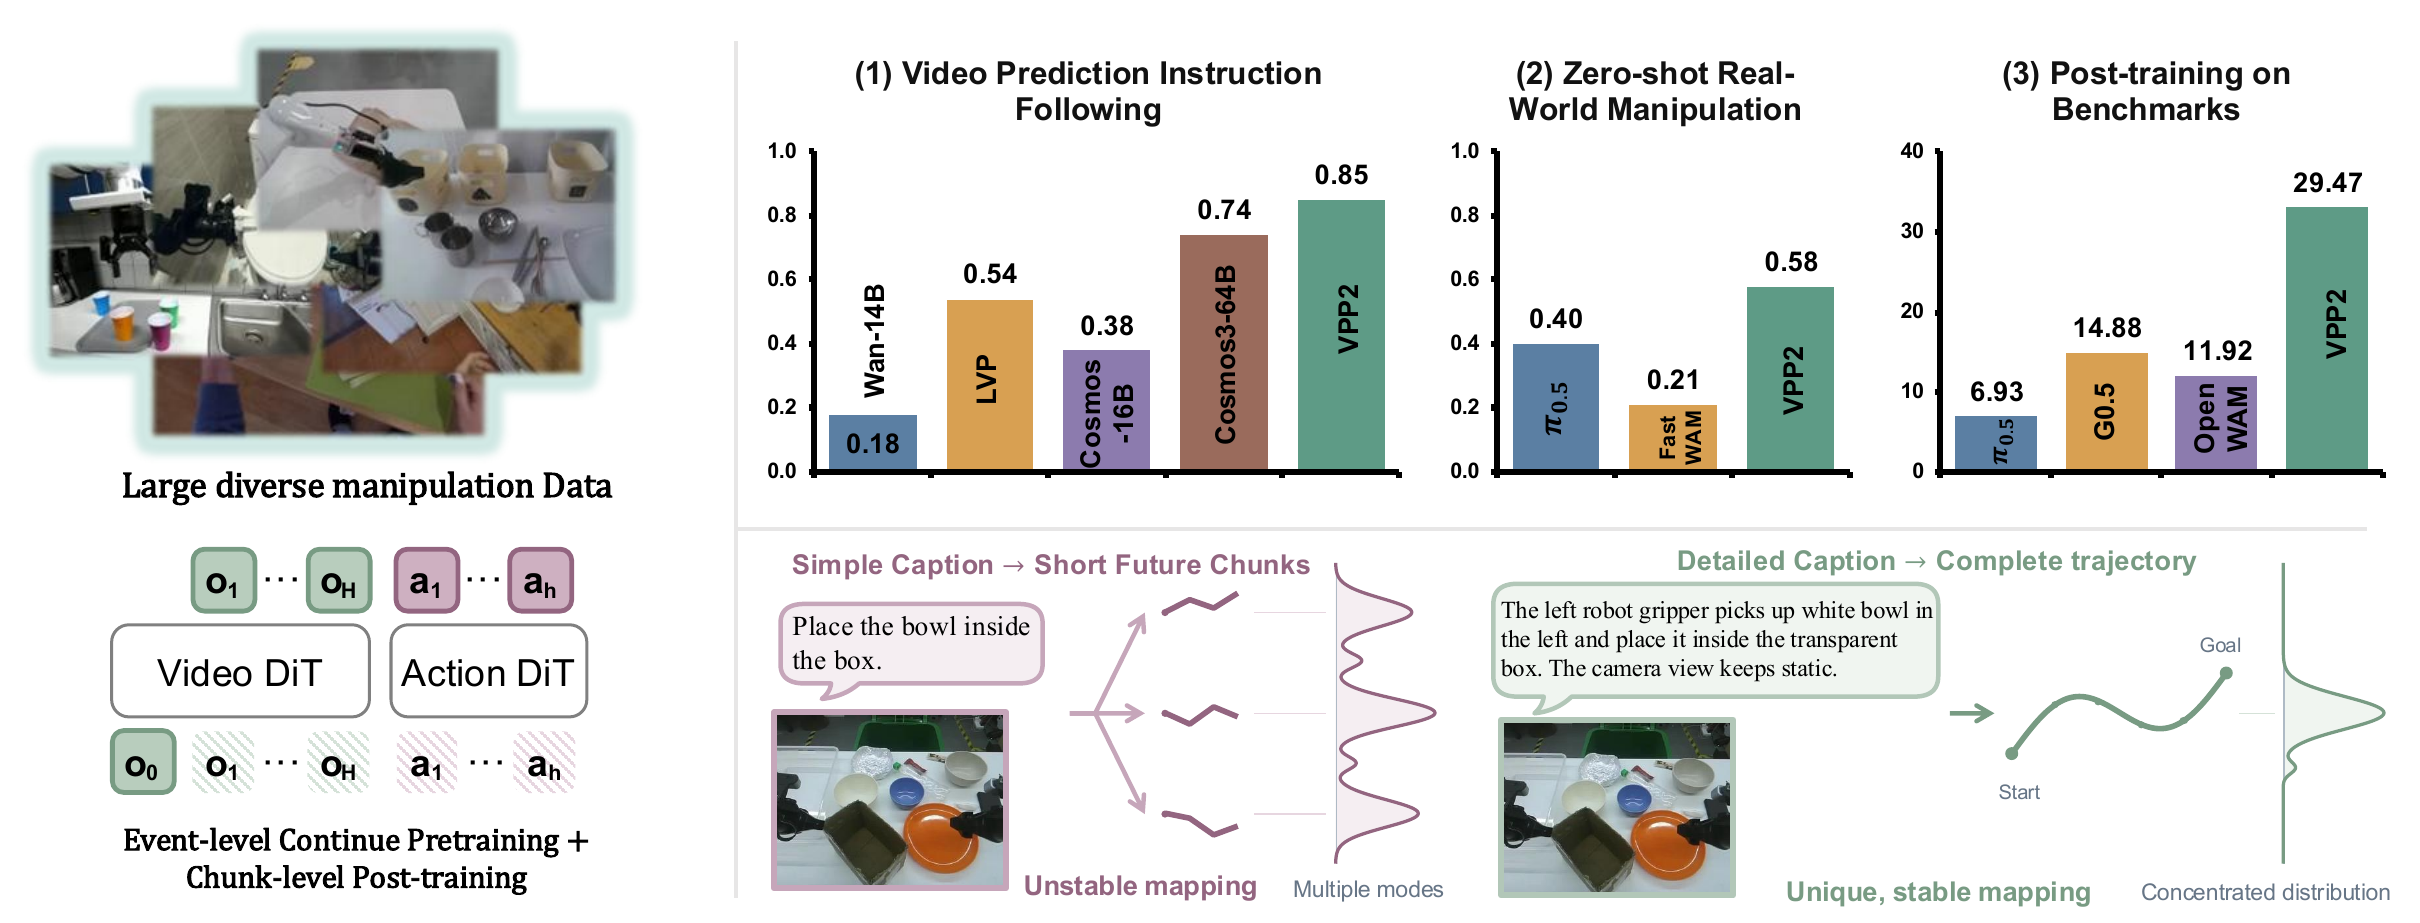
249roboterax/video-prediction-policy-2 · PythonVideo Prediction Policy 2 (VPP2) is a world-action model (WAM) for robot manipulation that predicts future video frames and converts them into robot actions, with strong zero-shot generalization across tasks.
- 26
RoboHarness
246BinceQu/RoboHarness · PythonRoboHarness is a training-free harness that gives an LLM agent a visual-geometric control panel: the model marks points of interest on 2D images, which get tracked and turned into geometric constraints so the LLM can directly compose and execute embodied manipulation actions.
- 27
flex-pi
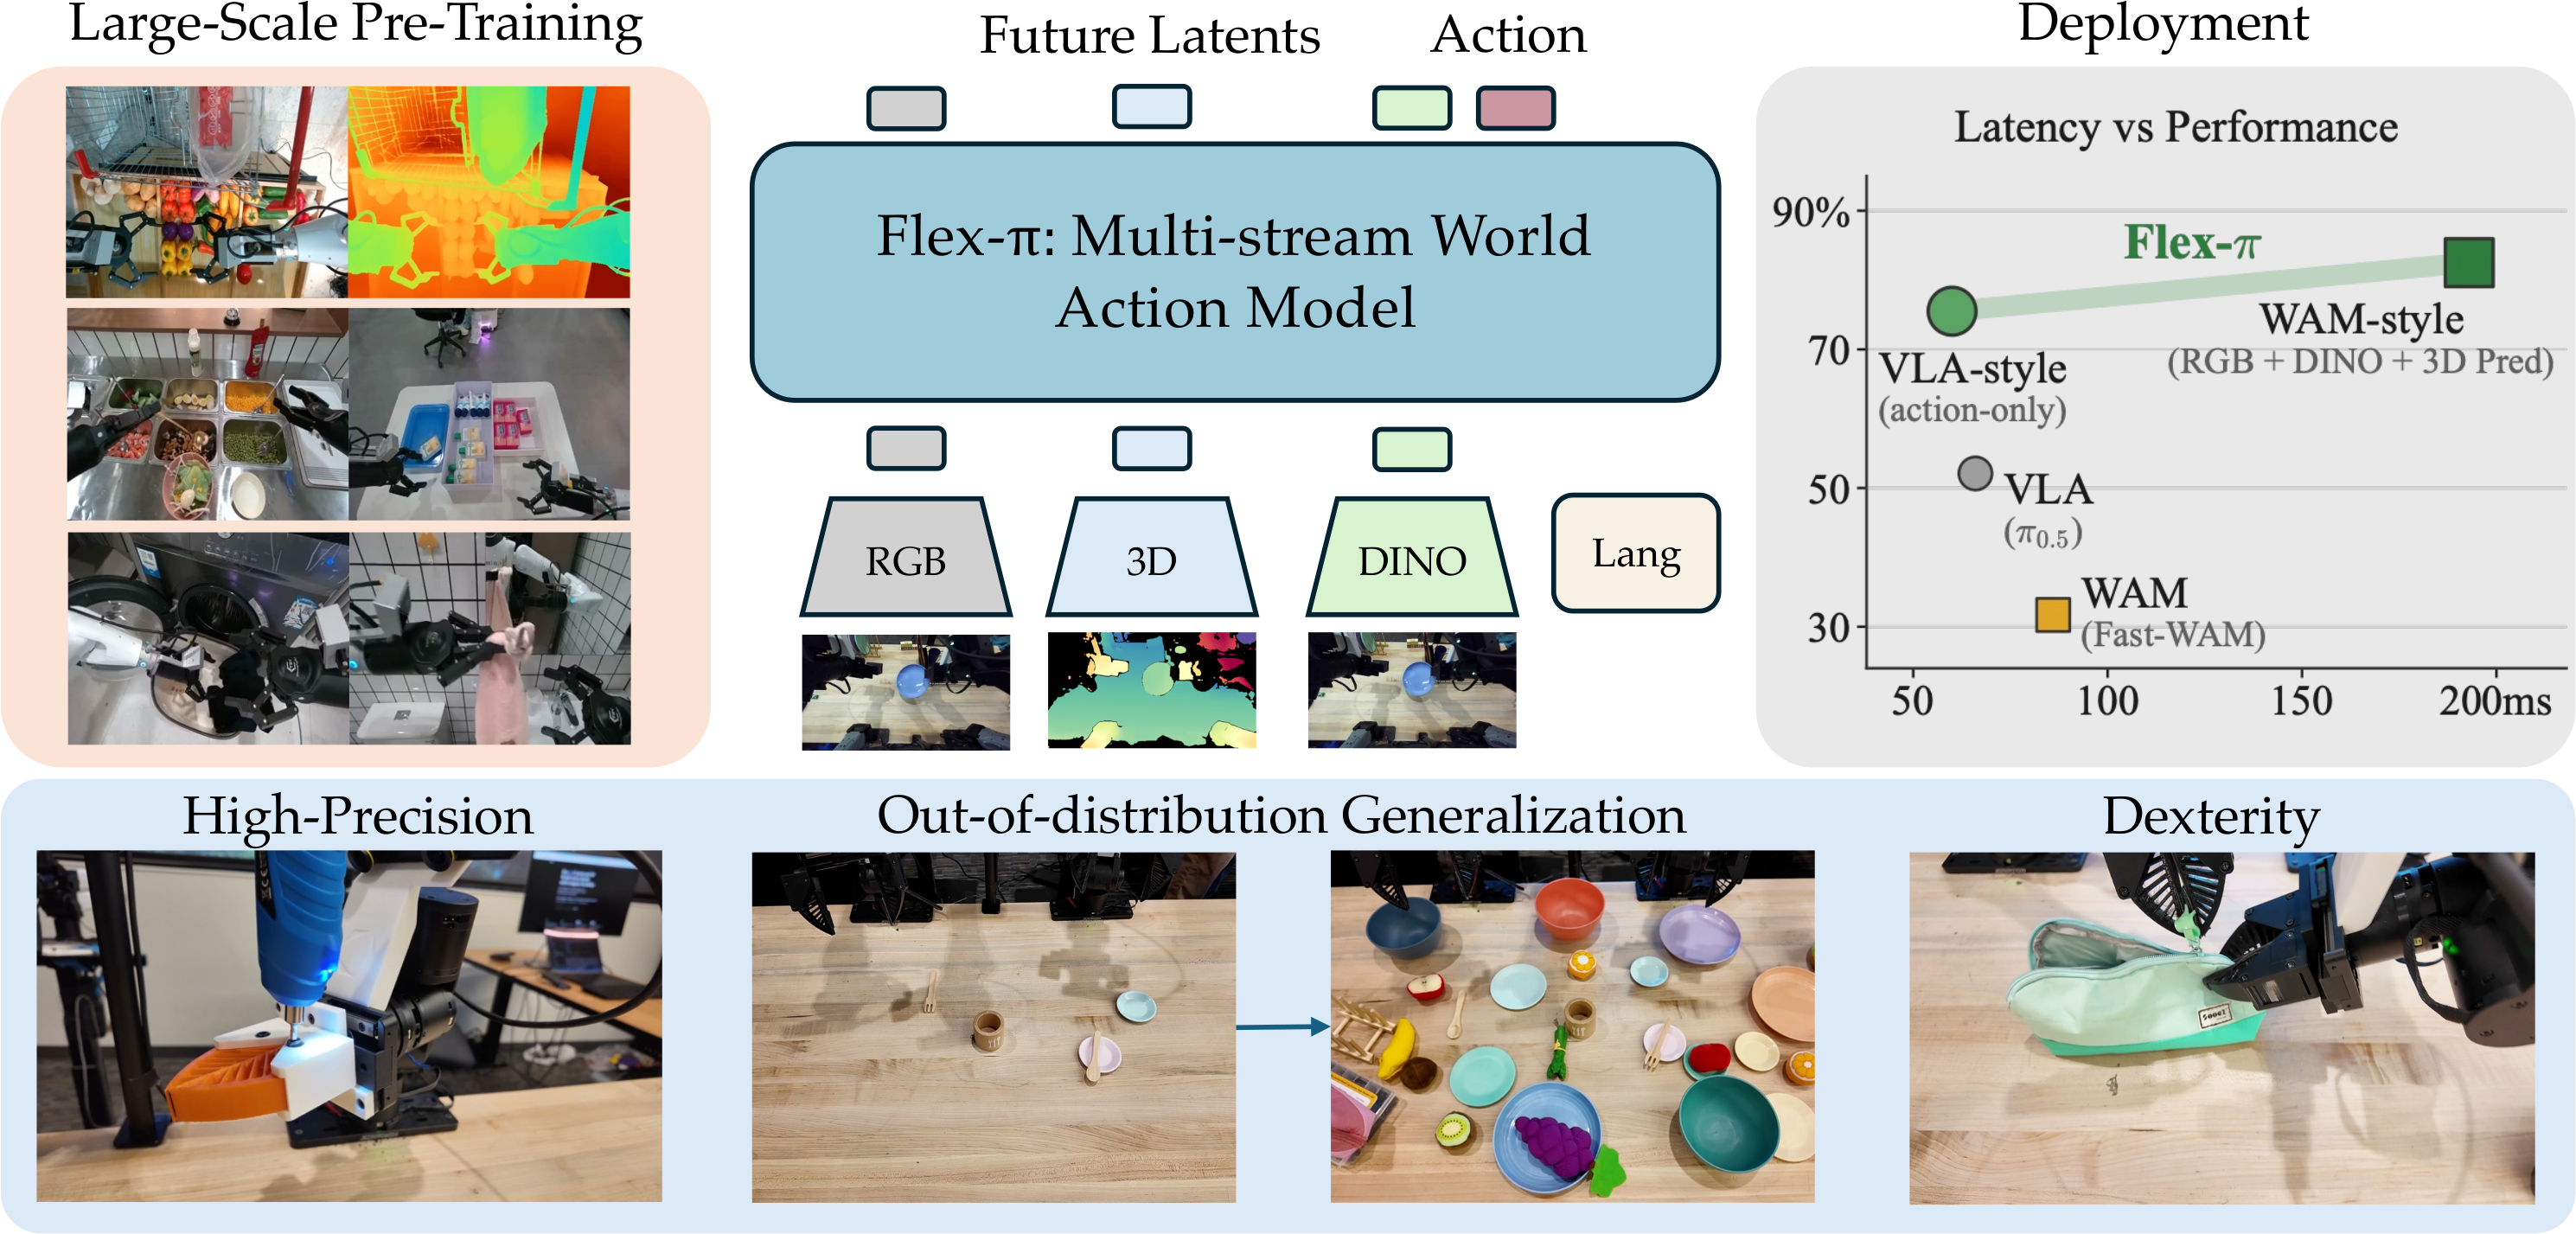
225geyan21/flex-pi · PythonFlex-π is a 6B-parameter world-action model for robot manipulation that jointly predicts future RGB, 3D pointmaps, DINOv3 semantics, and actions from one checkpoint, so it can deploy as a VLA, a full world model, or anything in between.
- 28
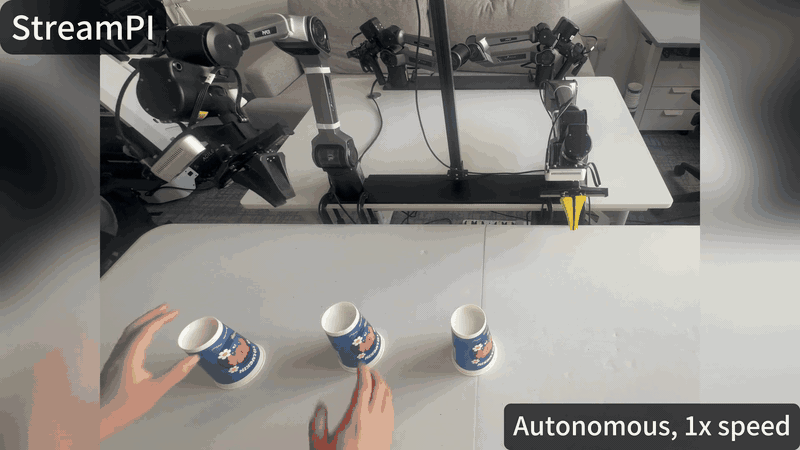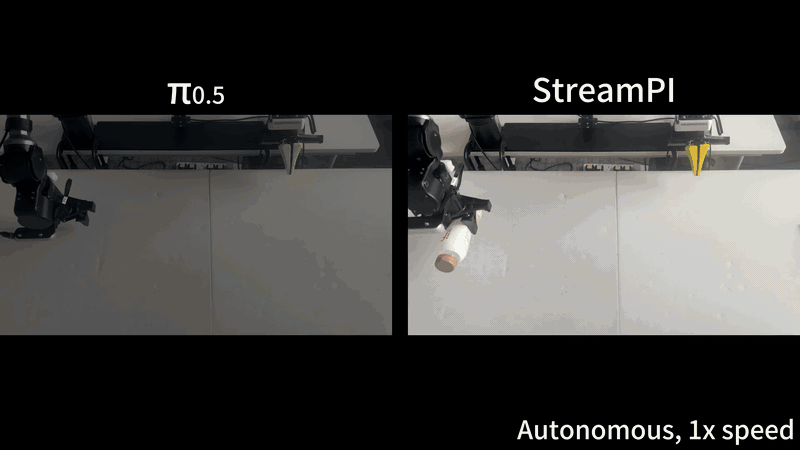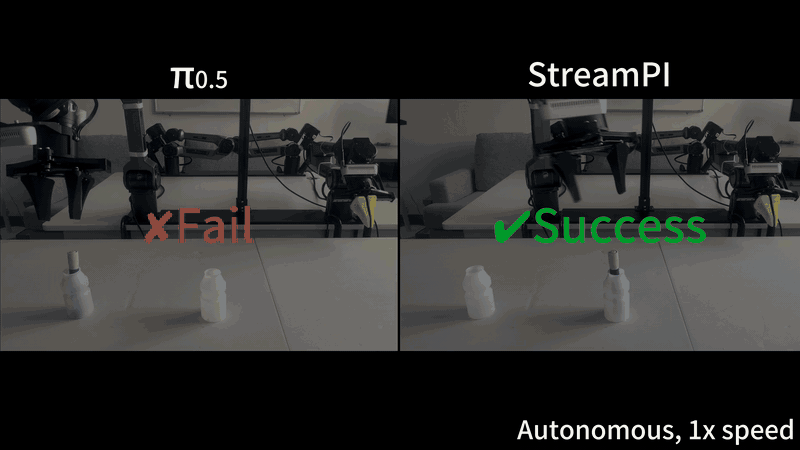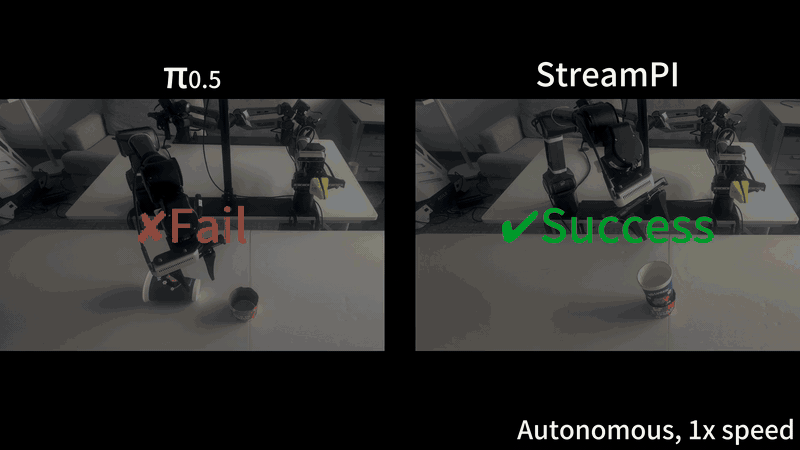
StreamPI
211hku-sail/StreamPI · PythonOfficial code of StreamPI (NeurIPS 2026, from HKU and ACE Robotics): a streaming temporal modeling framework that gives VLA robot policies like pi0.5 memory of past frames and multi-frame perception without adding any new parameters.
- 29
InstinctFlash
200General-Instinct/InstinctFlash · PythonInstinctFlash is a high-performance serving runtime for robotics foundation models - it loads checkpoints like GR00T, Cosmos3, pi0.5, LingBot-VA/VLA and DreamZero, applies acceleration (FP8, fused Triton kernels, caching) and serves them over Python or WebSocket, reporting up to 33.78x speedup on Jetson Thor.
- 30
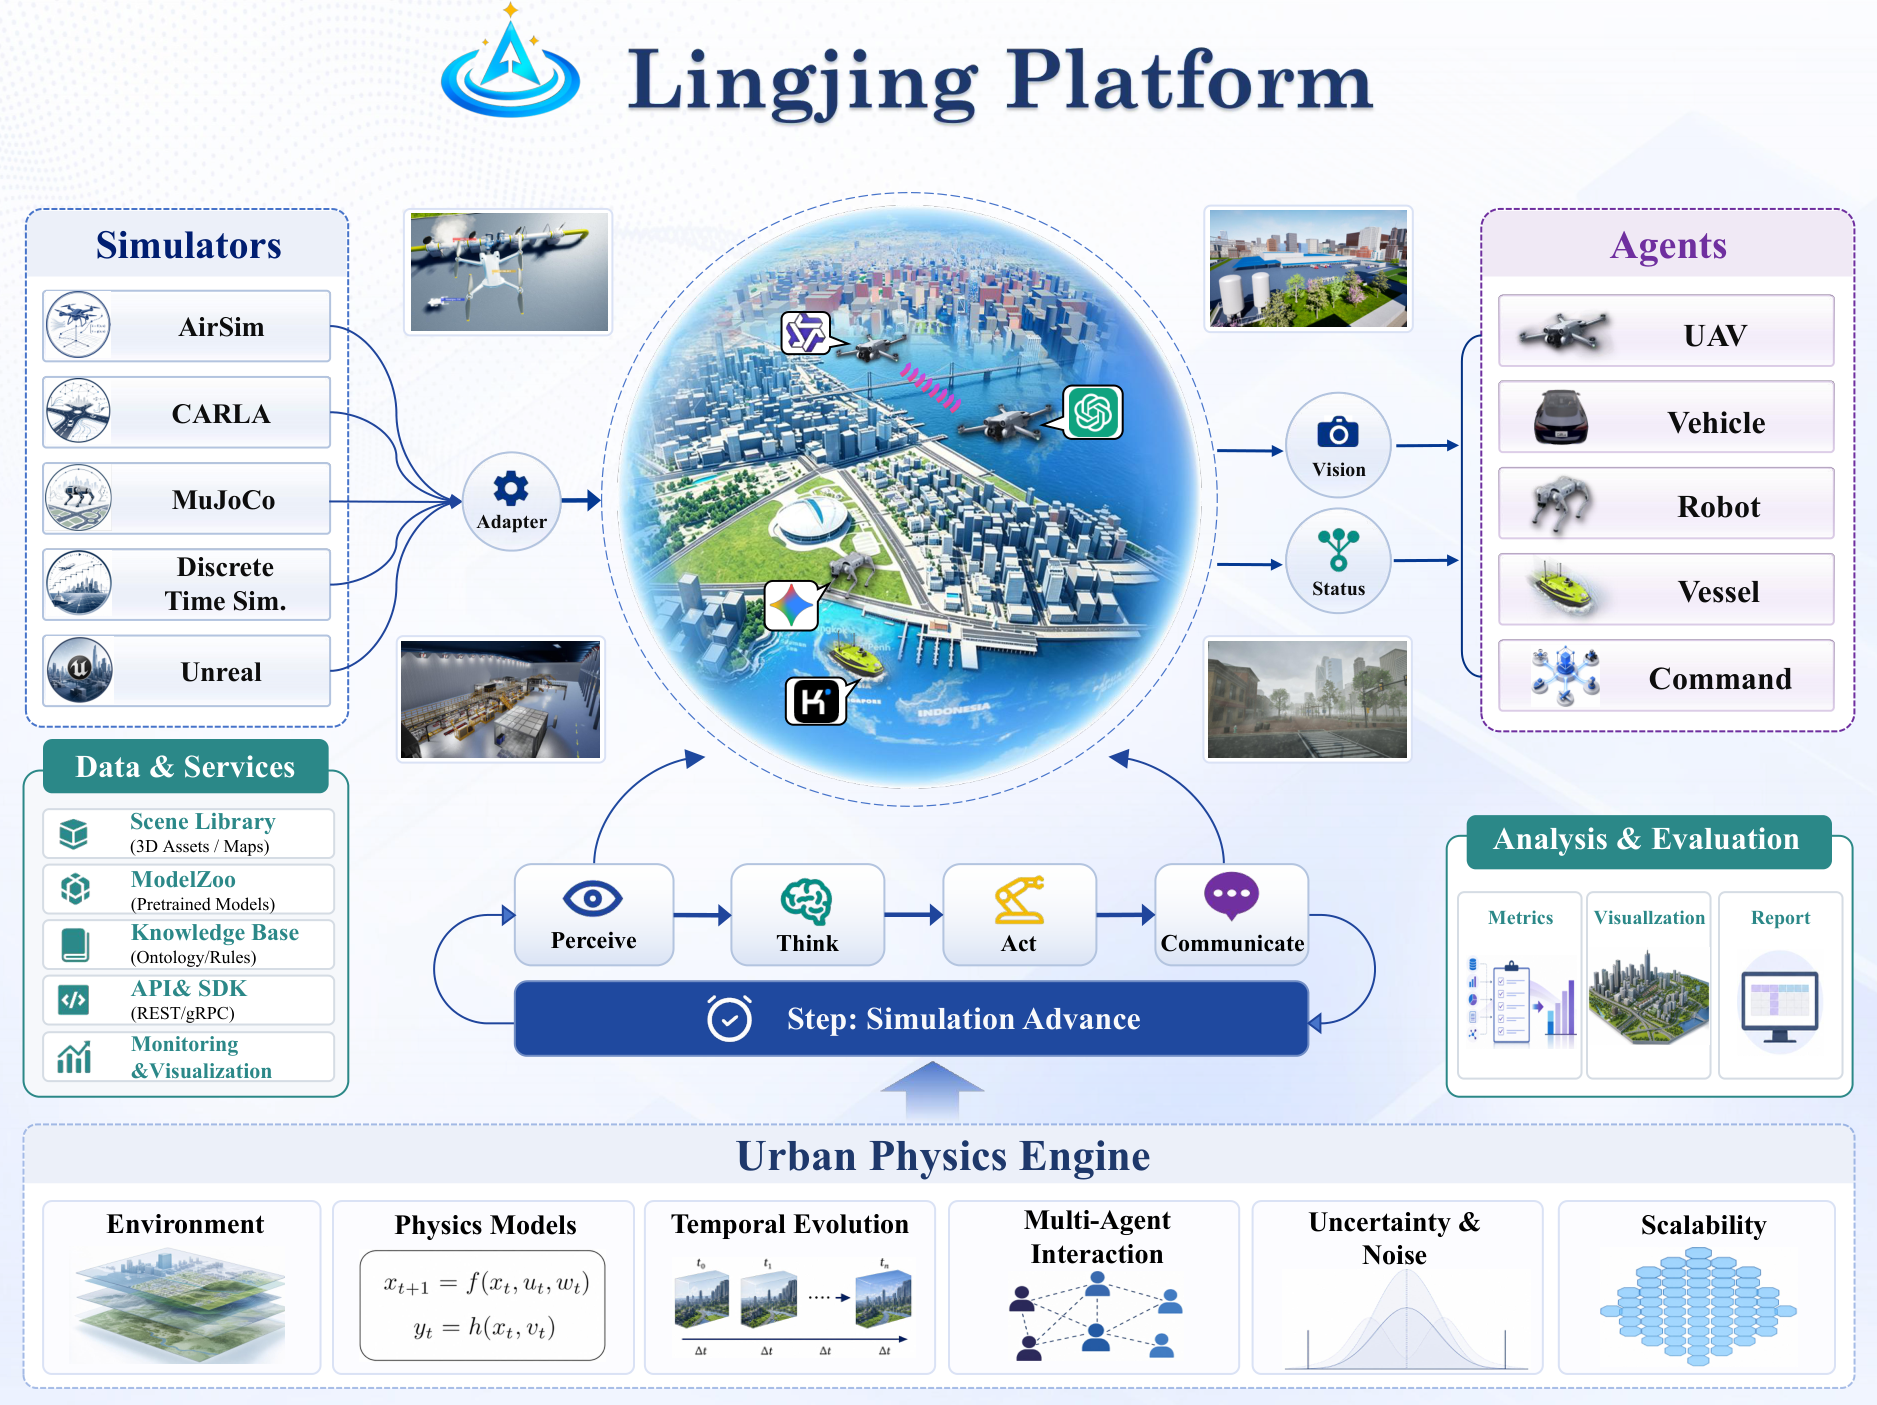
Air-Lingjing
194seanlxh/Air-Lingjing · PythonLingJing is an open simulation stack for LLM-driven embodied agents in large 3D environments: a FastAPI/LangGraph backend plus a Cesium-powered Unreal Engine 5.5 plugin, with runnable example cases.
- 31
S-Space
174MirroS-Lab/S-Space · PythonS-Space is a research project that finds a three-dimensional linear subspace inside multimodal model activations which encodes object positions along horizontal, vertical, and distance axes, and shows it can be read out and even causally edited to change the model's spatial judgments.
- 32
dreamforge
130rzc156/dreamforge · PythonDreamforge is a research pipeline that mines a robot policy's own failure states, uses a latent world model (CEM) to imagine corrective actions, and verifies each correction by replaying it in the real simulator before claiming it helps.
Related topics
Often tagged together