






Что это такое?
 Copper — это среда выполнения и SDK на Rust для создания, запуска, записи и детерминированного воспроизведения статических графов задач роботов. Его часто называют «операционной системой для роботов». Он работает везде: от Linux до микроконтроллеров без операционной системы (bare-metal).
Это полноценное ядро операционной системы или фреймворк, который я компилирую в код своего робота?Несмотря на формулировку «ОС для роботов», это фреймворк и среда выполнения на Rust. Граф задач вы описываете в конфигурационном файле RON, и он встраивается в вашу программу на этапе компиляции, а не запускается как отдельное ядро системы.
Несмотря на формулировку «ОС для роботов», это фреймворк и среда выполнения на Rust. Граф задач вы описываете в конфигурационном файле RON, и он встраивается в вашу программу на этапе компиляции, а не запускается как отдельное ядро системы.Как собрать своё первое приложение на Copper?Установите последнюю стабильную версию набора инструментов Rust, затем с помощью генератора проектов Copper создайте каркас приложения с файлами copperconfig.ron, src/main.rs и src/tasks.rs. В проект входит justfile для просмотра логов, анализа графа, планирования и воспроизведения.
Установите последнюю стабильную версию набора инструментов Rust, затем с помощью генератора проектов Copper создайте каркас приложения с файлами copperconfig.ron, src/main.rs и src/tasks.rs. В проект входит justfile для просмотра логов, анализа графа, планирования и воспроизведения.Есть ли подводные камни при работе с bare-metal оборудованием?Если при создании проекта выбрать цель bare-metal/nostd, генератор пропустит каркас для Profile-Guided Scheduling, а файл schedule.ron по умолчанию будет лишь осторожной заглушкой, которую всё равно нужно настроить под вашу реальную нагрузку.
Если при создании проекта выбрать цель bare-metal/nostd, генератор пропустит каркас для Profile-Guided Scheduling, а файл schedule.ron по умолчанию будет лишь осторожной заглушкой, которую всё равно нужно настроить под вашу реальную нагрузку.Какое железо Copper реально может запускать?Copper работает на компьютерах разработчиков с Linux и macOS, на одноплатных компьютерах вроде Raspberry Pi и на микроконтроллерах без операционной системы (bare-metal), например на полётных контроллерах STM32H7, которые используются в демонстрации квадрокоптера.
Copper работает на компьютерах разработчиков с Linux и macOS, на одноплатных компьютерах вроде Raspberry Pi и на микроконтроллерах без операционной системы (bare-metal), например на полётных контроллерах STM32H7, которые используются в демонстрации квадрокоптера.Можно ли использовать Copper вместе с существующим роботом на ROS 2?Да, Copper подключается к ROS 2 через Zenoh, поэтому его можно интегрировать в стек на базе ROS и переходить на него постепенно, а не переписывать всё сразу.
Да, Copper подключается к ROS 2 через Zenoh, поэтому его можно интегрировать в стек на базе ROS и переходить на него постепенно, а не переписывать всё сразу.Что такое отладка с путешествием во времени?Можно перематывать записанный запуск, восстанавливать состояние задач в любой момент и повторно выполнять код с теми же записанными входными данными и часами робота. Так проще разобраться, что именно произошло на реальном роботе.
Можно перематывать записанный запуск, восстанавливать состояние задач в любой момент и повторно выполнять код с теми же записанными входными данными и часами робота. Так проще разобраться, что именно произошло на реальном роботе.Что такое планирование на основе профилирования (PGS)?PGS преобразует измеренные тайминги, частоты датчиков и дедлайны в варианты расписания выполнения. Их можно сравнить по производительности и скомпилировать в среду выполнения, используя вспомогательные команды just pgs-baseline и just pgs-measure.
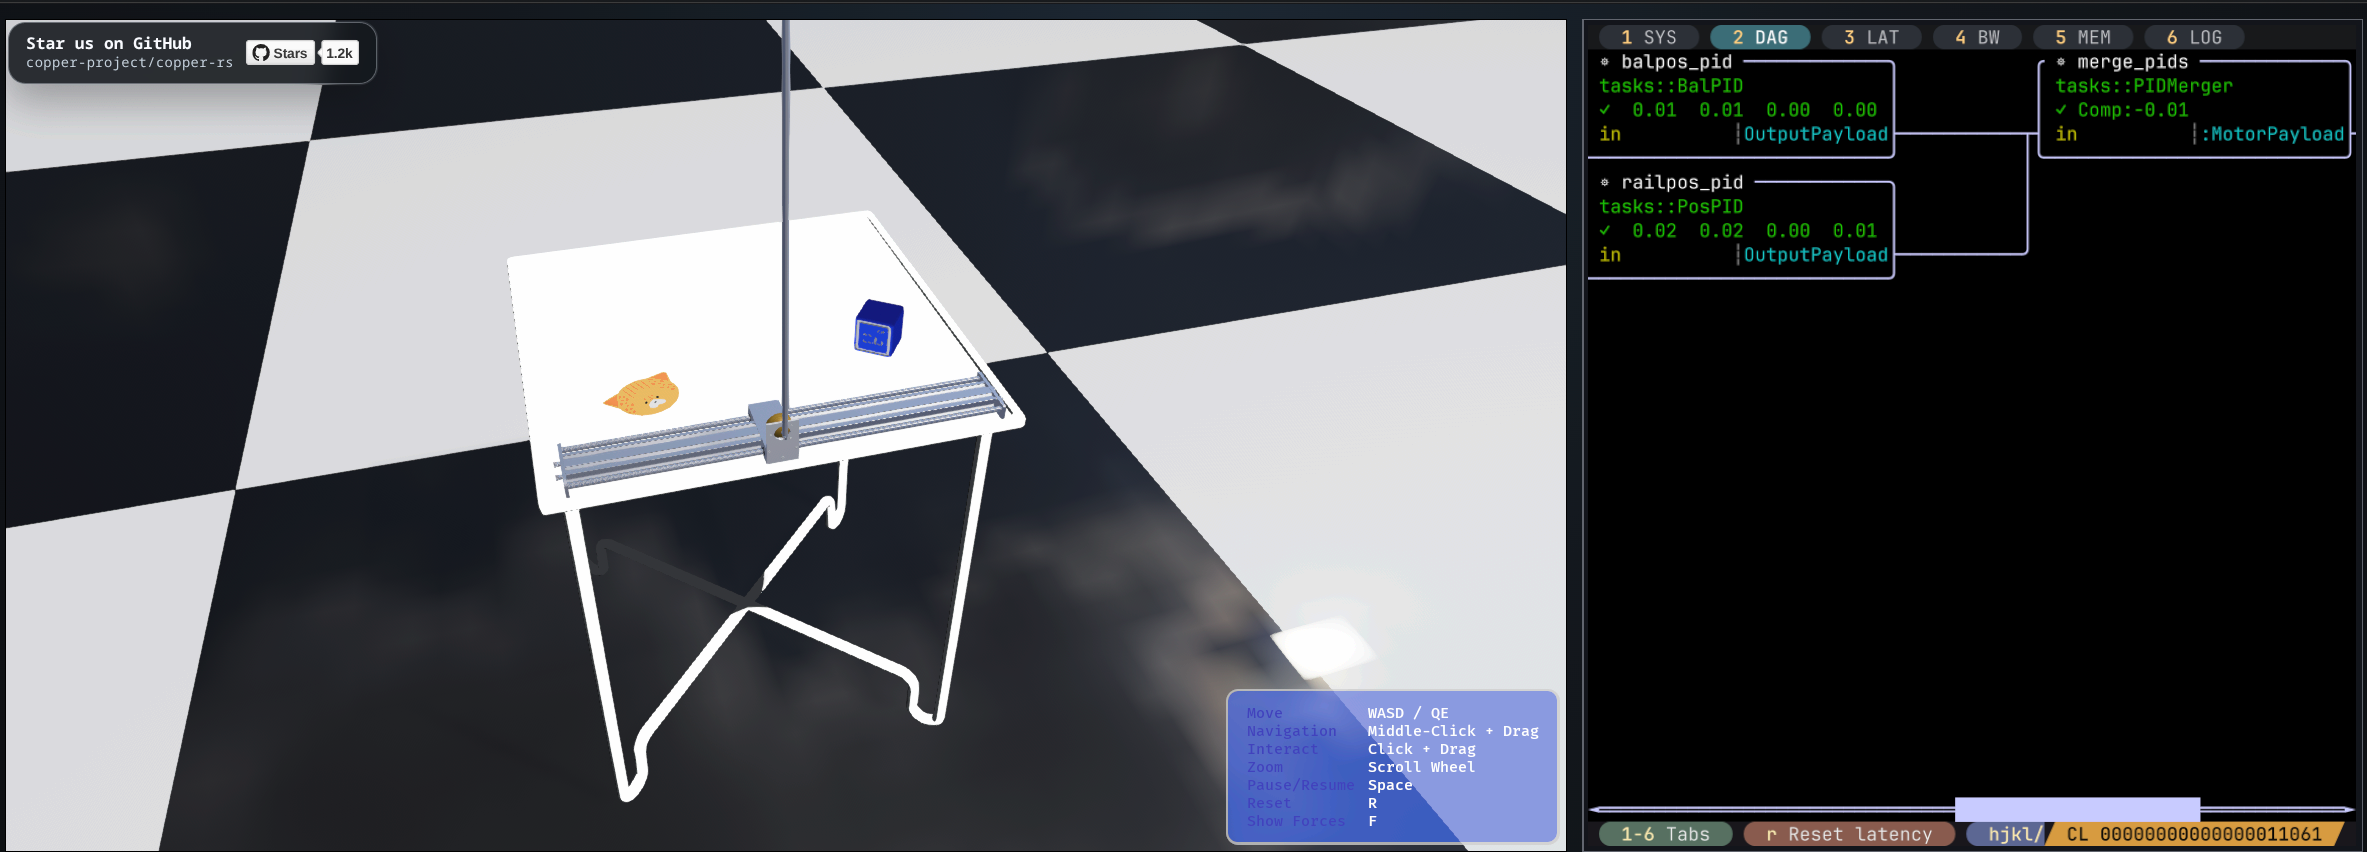
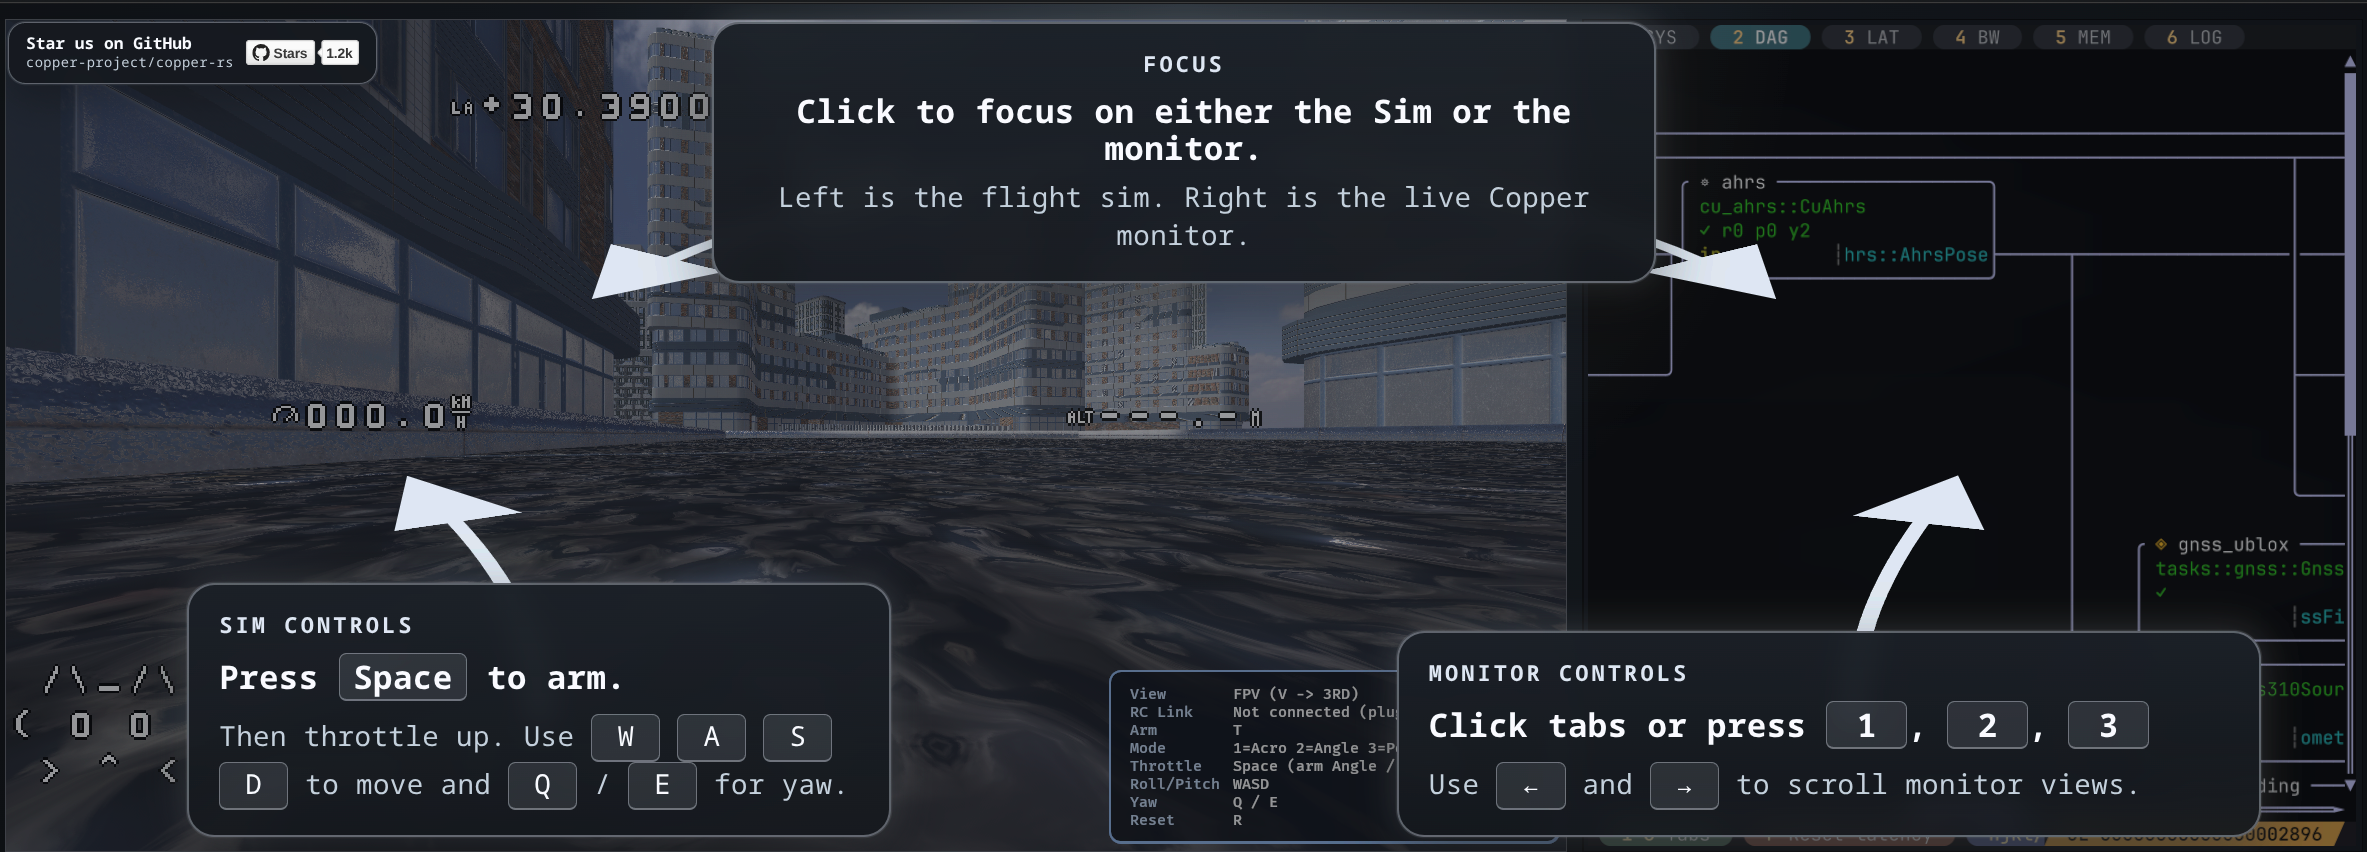
PGS преобразует измеренные тайминги, частоты датчиков и дедлайны в варианты расписания выполнения. Их можно сравнить по производительности и скомпилировать в среду выполнения, используя вспомогательные команды just pgs-baseline и just pgs-measure.Copper уже использовался на настоящих роботах?В README сказано, что его уже применяют для полётов в воздухе, вождения, плавания, космических миссий и управления гуманоидами. Также есть симуляции, которые можно запустить в браузере: это точные копии приложений, работающих на балансирующем роботе на Raspberry Pi и квадрокоптере на STM32H7.
В README сказано, что его уже применяют для полётов в воздухе, вождения, плавания, космических миссий и управления гуманоидами. Также есть симуляции, которые можно запустить в браузере: это точные копии приложений, работающих на балансирующем роботе на Raspberry Pi и квадрокоптере на STM32H7.Какие есть похожие проекты?betaflight, Jet, ftl, zxdesk, rt-thread, xgoduck_hardware, autoware, fprime
betaflight, Jet, ftl, zxdesk, rt-thread, xgoduck_hardware, autoware, fprimeВ каких он темах?drone, physical-ai, ros, stm32, bare-metal, robot, telemetry, microcontroller, logging, operating-system, embedded-systems, robotics
drone, physical-ai, ros, stm32, bare-metal, robot, telemetry, microcontroller, logging, operating-system, embedded-systems, robotics- Автор
- copper-project
- Размер
- 1.4 GB
- Звёзды
- 1.6K
- Обновлён
- КоммитNov 17Релизv1.3.2Nov 09
- Возраст
- 6 г
- Коммиты · 90 дней