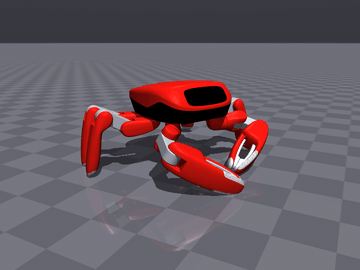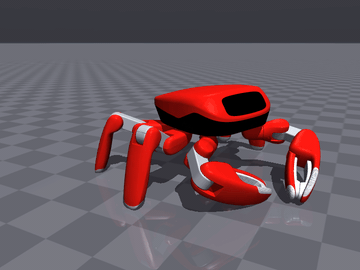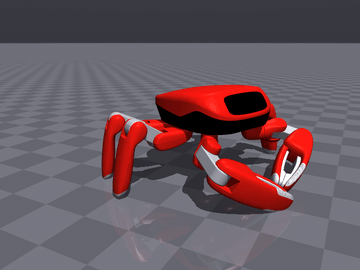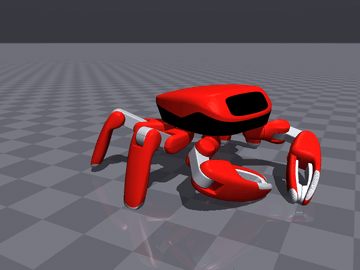
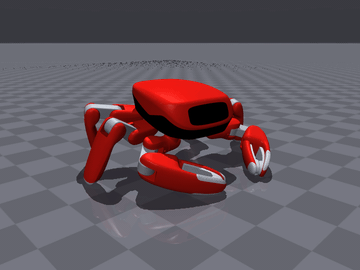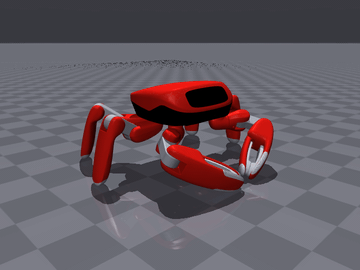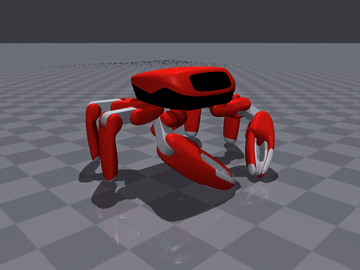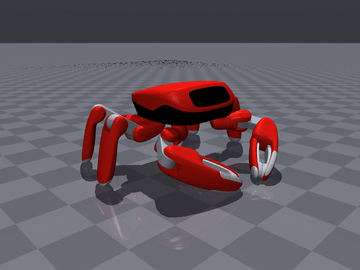
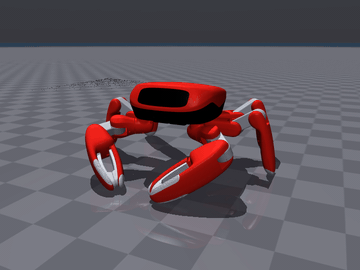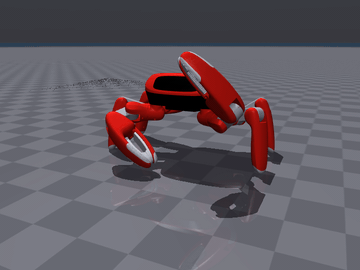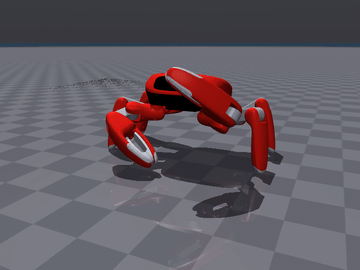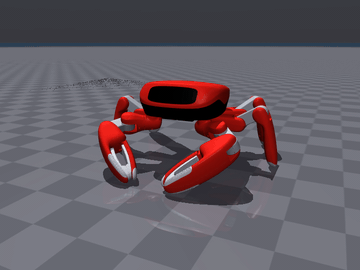
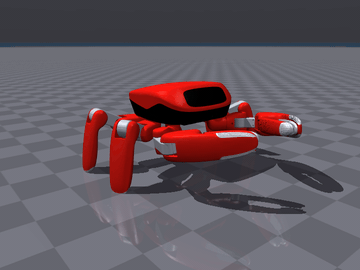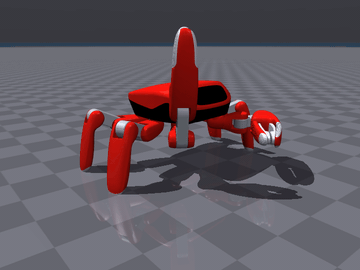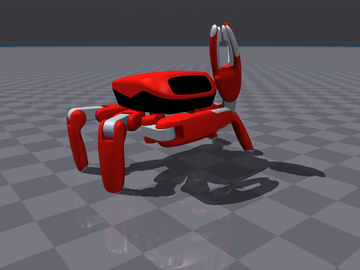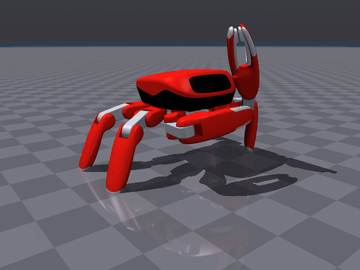
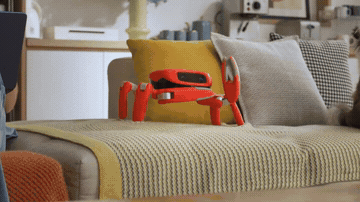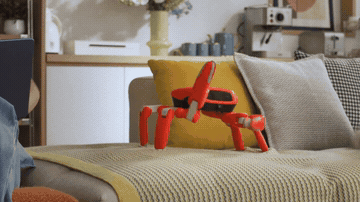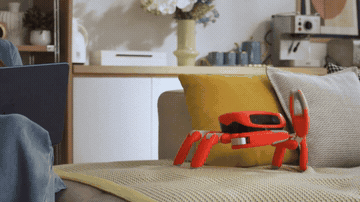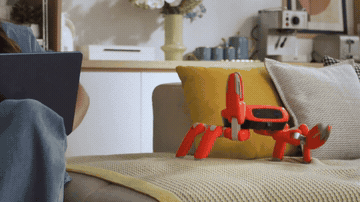
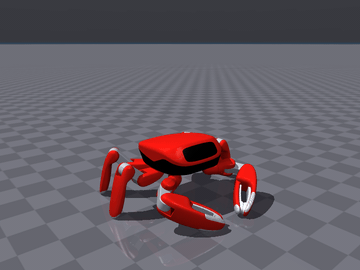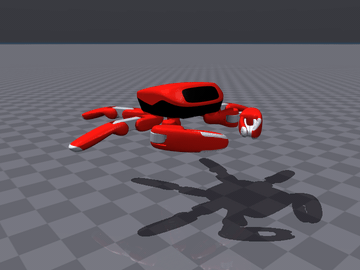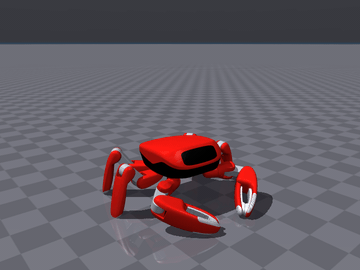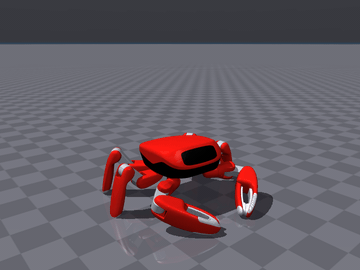
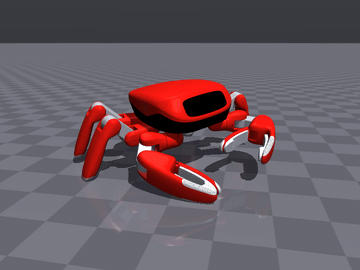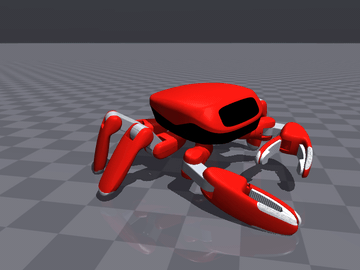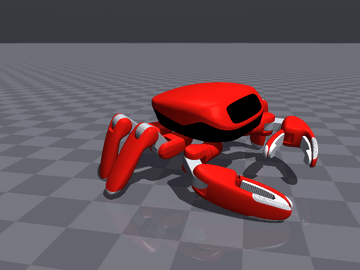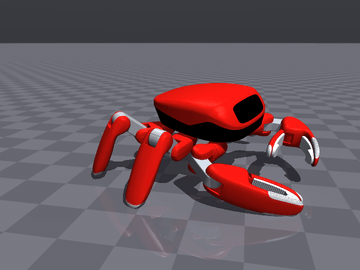
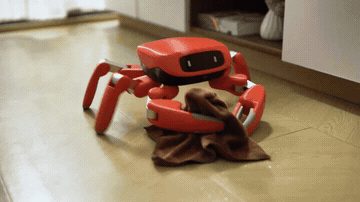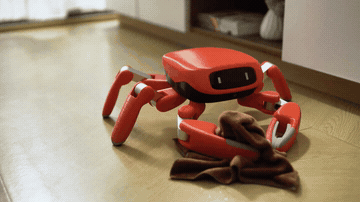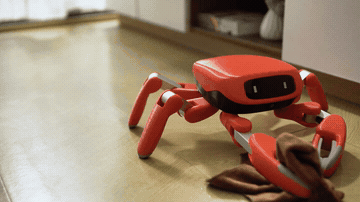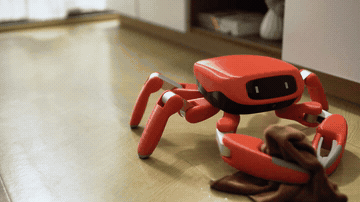
What is this?
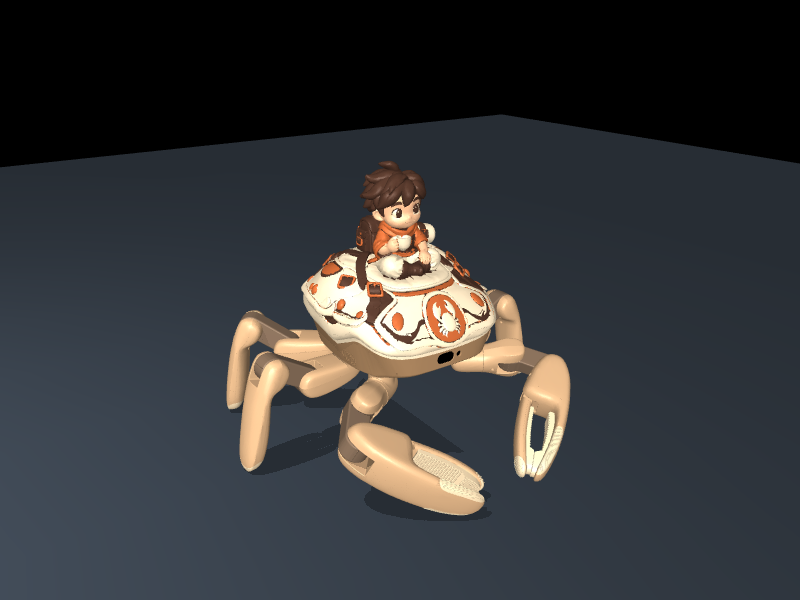
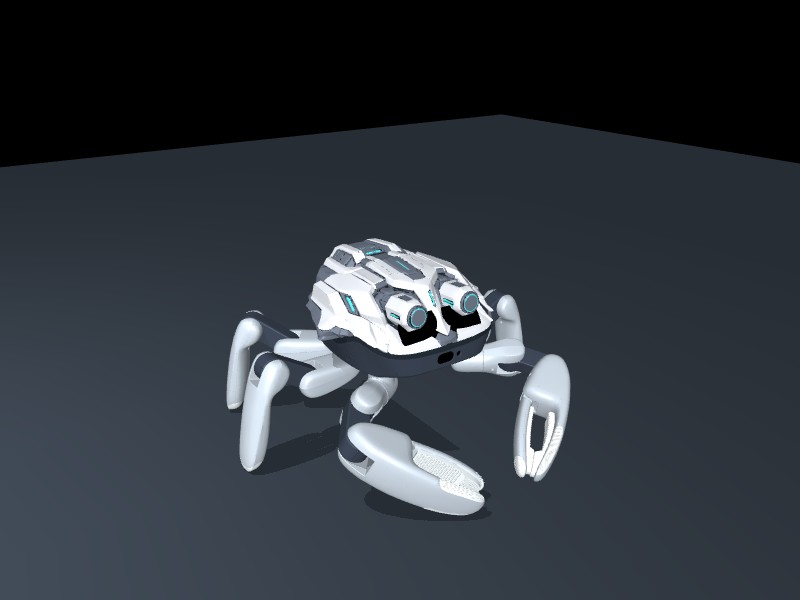
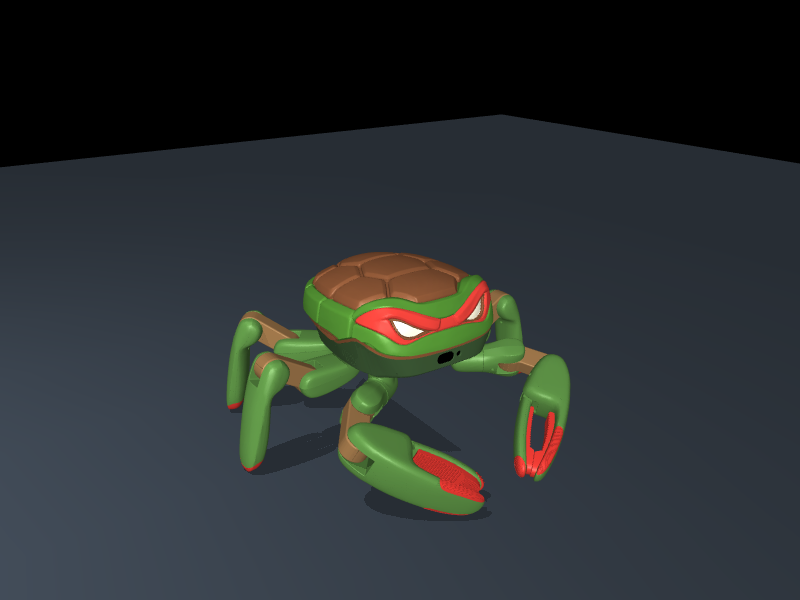
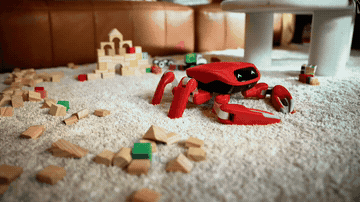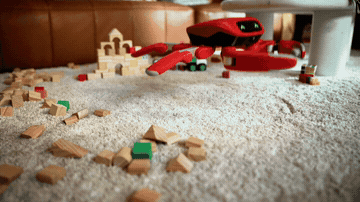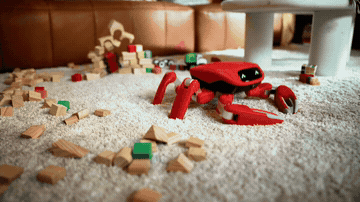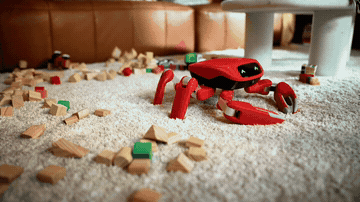
 Jumper is a 22-DoF crab robot, and this repository is its AI toolkit for creating appearances, training motions, and building scenes for it.
Is this the actual robot hardware, or just software for it?It is the software side: a toolkit of instructions and assets meant to be used inside an AI coding assistant via natural-language prompts, while the physical robot design lives in a separate hardware repo.
It is the software side: a toolkit of instructions and assets meant to be used inside an AI coding assistant via natural-language prompts, while the physical robot design lives in a separate hardware repo.How do I actually design an appearance, train a motion, or build a scene with it?Open the repo in an AI coding assistant and type a one-sentence prompt, such as asking it to design a skin, train a gait, or build a scene, and it exports the result as a .skin, .app, or .map file.
Open the repo in an AI coding assistant and type a one-sentence prompt, such as asking it to design a skin, train a gait, or build a scene, and it exports the result as a .skin, .app, or .map file.What does motion training actually run on?Motion training is built on mjlab, rslrl, MuJoCo, and MuJoCo Warp for physics simulation and reinforcement learning.
Motion training is built on mjlab, rslrl, MuJoCo, and MuJoCo Warp for physics simulation and reinforcement learning.If I generate a skin or motion with the AI assistant, is it automatically covered by the repo's license?No, generated outputs (and third-party materials used as examples) don't automatically inherit the repository's Apache-2.0 license.
No, generated outputs (and third-party materials used as examples) don't automatically inherit the repository's Apache-2.0 license.What motions can be trained for the crab robot out of the box?Example prompts cover a tripod walking gait, posture, gesture, dance, jump, and grasp, trained through reinforcement learning and then packaged as .app motion bundles.
Example prompts cover a tripod walking gait, posture, gesture, dance, jump, and grasp, trained through reinforcement learning and then packaged as .app motion bundles.Can I get a real physical Jumper robot?Yes, the README advertises a giveaway with a link explaining how to get a free Jumper unit.
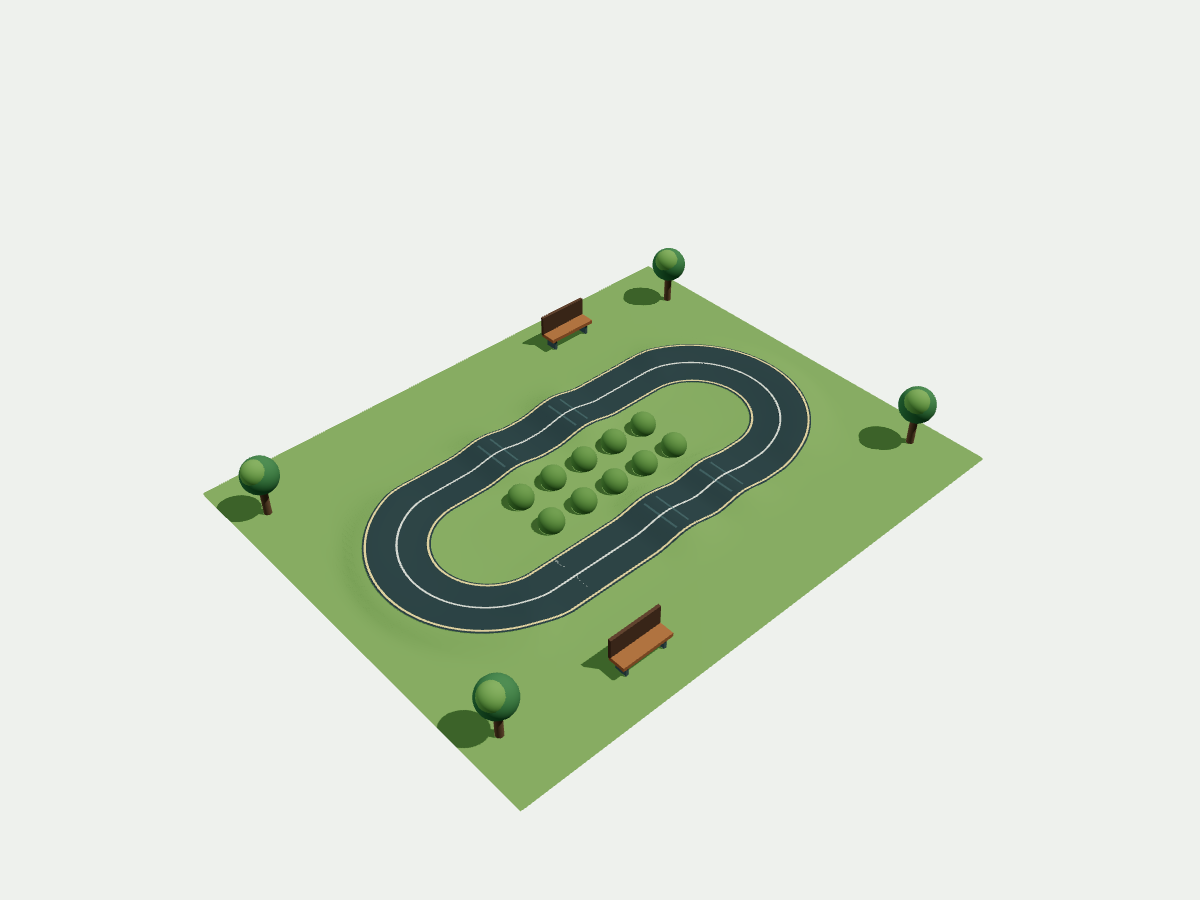
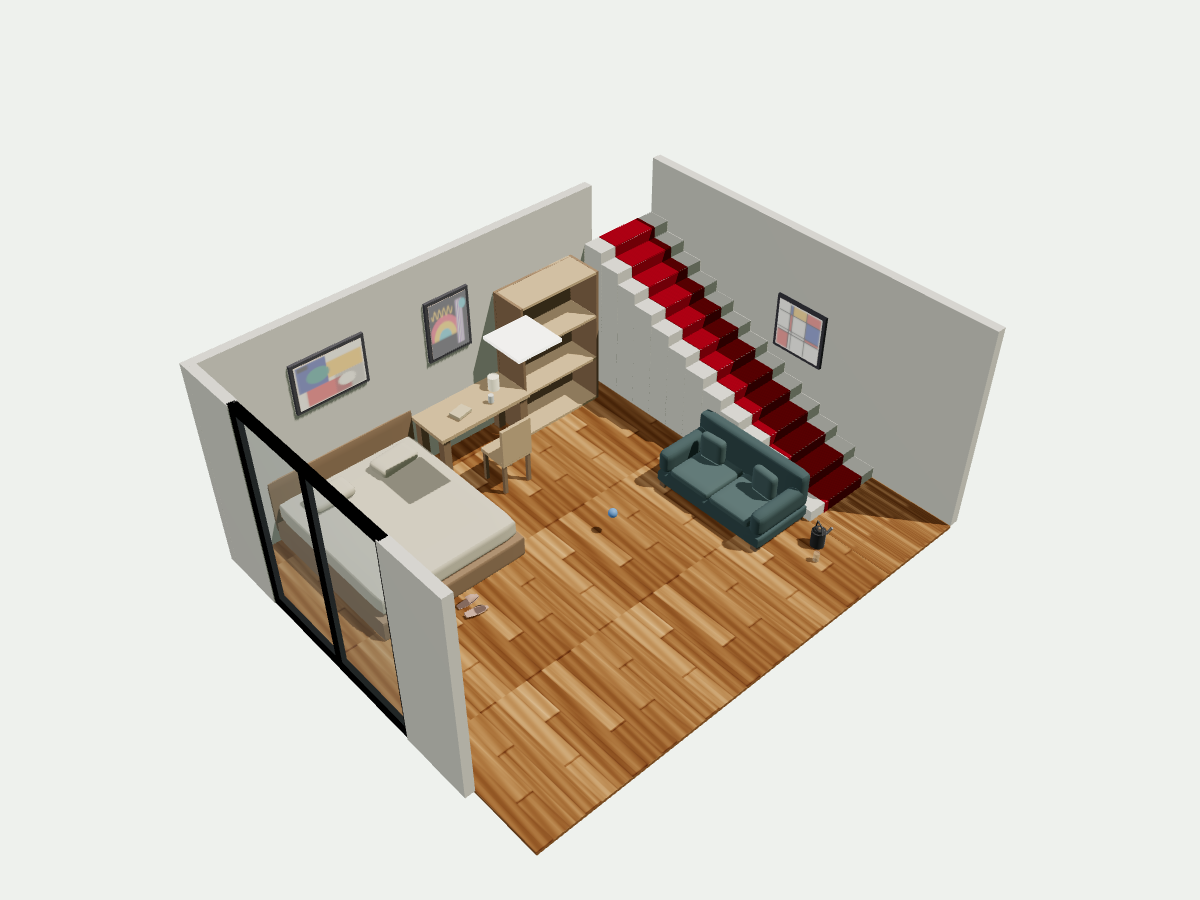
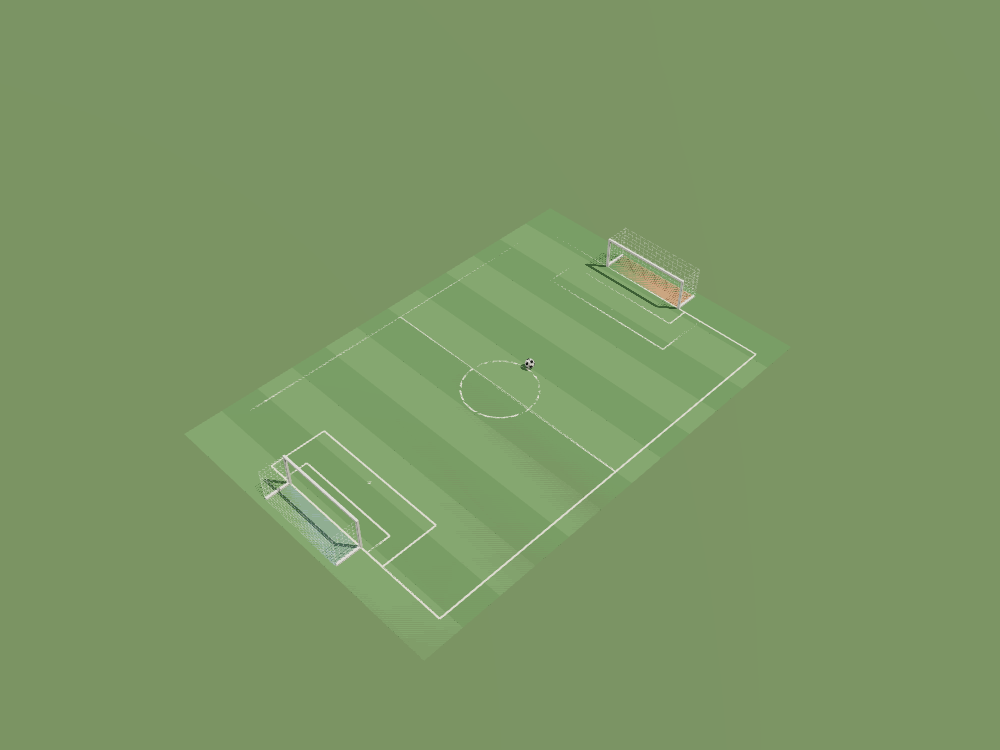
Yes, the README advertises a giveaway with a link explaining how to get a free Jumper unit.What kinds of scenes can I generate for the robot?You can prompt the assistant to build environments like a park pump-track, a bedroom, or a soccer field, each exported as a .map file.
You can prompt the assistant to build environments like a park pump-track, a bedroom, or a soccer field, each exported as a .map file.What are similar projects?genesis-world, lerobot, Zetta-Embodiment, Embodied-AI-Guide, project_superdex, Motus2, bullet3, UMR
genesis-world, lerobot, Zetta-Embodiment, Embodied-AI-Guide, project_superdex, Motus2, bullet3, UMRWhich topics is it in?physics-simulation, robot, embodied-ai, design-tools, creative-tools, toolkit, robotics, simulation, ai-tools, reinforcement-learning, hardware, prompt-engineering
physics-simulation, robot, embodied-ai, design-tools, creative-tools, toolkit, robotics, simulation, ai-tools, reinforcement-learning, hardware, prompt-engineering