


Что это такое?
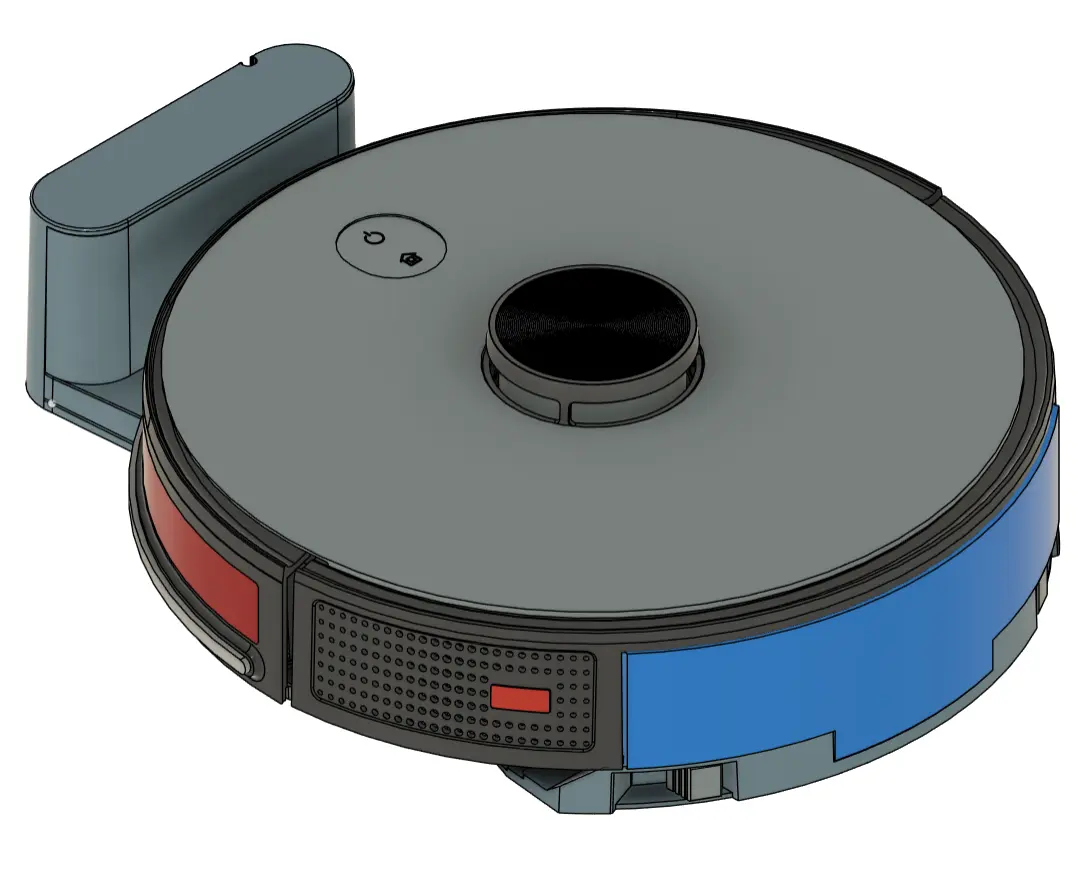
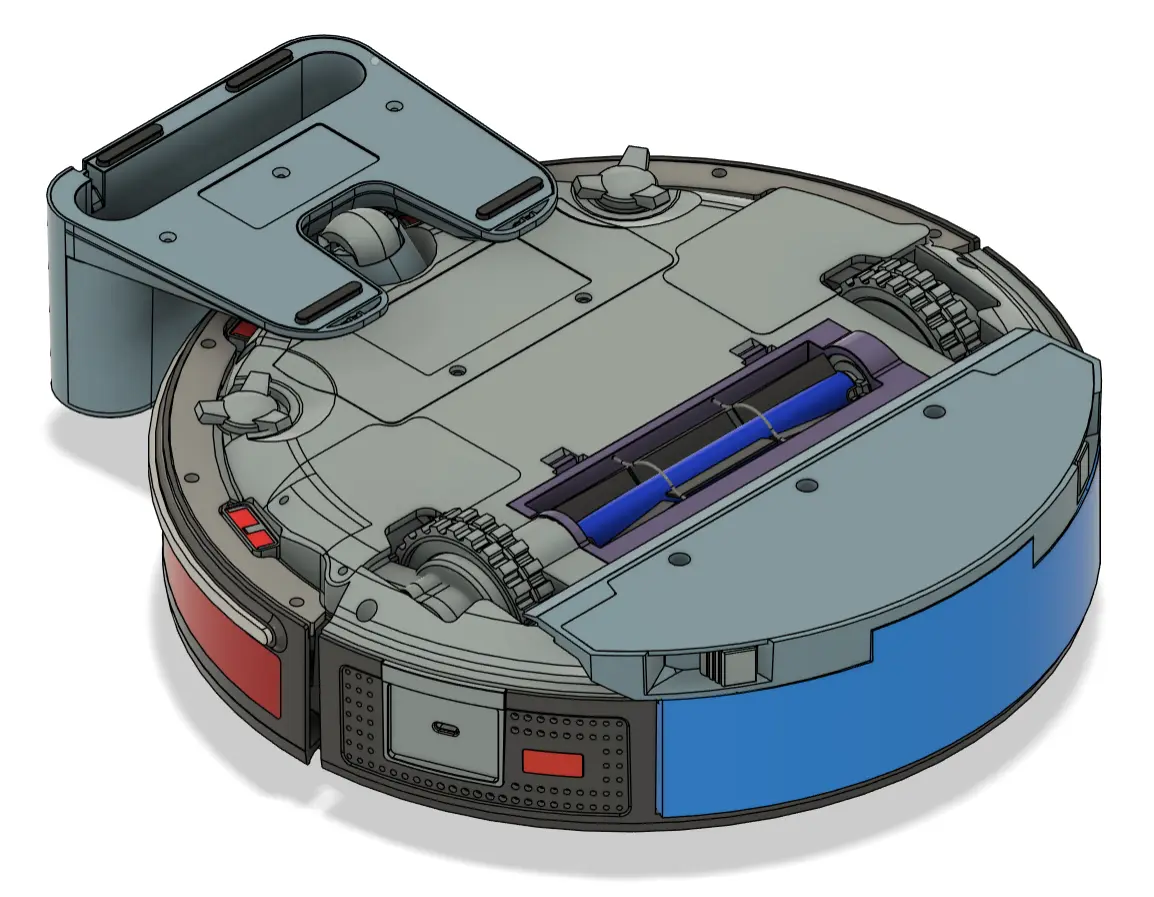
 OOMWOO — это открытый домашний робот-пылесос, который вы собираете сами, используя Raspberry Pi, детали, напечатанные на 3D-принтере, Home Assistant, Arduino и ROS2. Навигация работает на недорогом 2D LiDAR.
Это готовый пылесос, который можно купить, или проект для самостоятельной сборки?Это проект для самостоятельной сборки: корпус вы печатаете на 3D-принтере, электронику закупаете сами и запускаете на ней ПО ROS2. Также планируется необязательный готовый набор деталей от makerspet.com, но готового продукта пока нет.
Это проект для самостоятельной сборки: корпус вы печатаете на 3D-принтере, электронику закупаете сами и запускаете на ней ПО ROS2. Также планируется необязательный готовый набор деталей от makerspet.com, но готового продукта пока нет.Как начать сборку?Поскольку собственное железо OOMWOO ещё не готово, вы собираете и тестируете робота в симуляции ROS2 Gazebo (oomwoo-one) или на реальном роботе-заглушке (Proscenic M6 Pro, подключённом к ROS2), выбирая открытый модуль на доске RFC для работы.
Поскольку собственное железо OOMWOO ещё не готово, вы собираете и тестируете робота в симуляции ROS2 Gazebo (oomwoo-one) или на реальном роботе-заглушке (Proscenic M6 Pro, подключённом к ROS2), выбирая открытый модуль на доске RFC для работы.Какое железо нужно для сборки?Raspberry Pi CM4/CM5 с ROS2, 2D LiDAR для картографии, 3D-принтер для корпуса, а также платы драйверов моторов и ввода-вывода (IO) на STM32 с прошивкой для ESP32/Arduino.
Raspberry Pi CM4/CM5 с ROS2, 2D LiDAR для картографии, 3D-принтер для корпуса, а также платы драйверов моторов и ввода-вывода (IO) на STM32 с прошивкой для ESP32/Arduino.Можно ли собрать OOMWOO уже сегодня?Пока нельзя — большинство пунктов в дорожной карте (файлы для 3D-печати, ПО для Raspberry Pi, платы драйверов и датчиков, прошивка, инструкции по сборке) ещё не отмечены как выполненные, а первые инструкции по сборке запланированы на осень 2026 года.
Пока нельзя — большинство пунктов в дорожной карте (файлы для 3D-печати, ПО для Raspberry Pi, платы драйверов и датчиков, прошивка, инструкции по сборке) ещё не отмечены как выполненные, а первые инструкции по сборке запланированы на осень 2026 года.Нужно ли пылесосу интернет-соединение или облачный аккаунт для работы?Нет — OOMWOO работает локально для обычной уборки и картографии, без облака и привязки к производителю. Облако нужно только для необязательных дополнений, например будущего магазина приложений.
Нет — OOMWOO работает локально для обычной уборки и картографии, без облака и привязки к производителю. Облако нужно только для необязательных дополнений, например будущего магазина приложений.Почему проект назван OOMWOO?«OOMWOO» — это ротационная амбиграмма: слово читается одинаково при повороте на 180 градусов, что отражает то, как робот ездит по полу во всех направлениях.
«OOMWOO» — это ротационная амбиграмма: слово читается одинаково при повороте на 180 градусов, что отражает то, как робот ездит по полу во всех направлениях.Можно ли просто купить набор деталей вместо того, чтобы искать всё самому?Да, makerspet.com планирует продавать необязательный набор с моторами, платами, щётками, прокладками и LiDAR, но это лишь удобство. Каждую деталь можно найти и самостоятельно, так как вся конструкция открыта.
Да, makerspet.com планирует продавать необязательный набор с моторами, платами, щётками, прокладками и LiDAR, но это лишь удобство. Каждую деталь можно найти и самостоятельно, так как вся конструкция открыта.На какие существующие проекты опирается OOMWOO или с какими он сравнивается?Он ссылается на предшественников, например Valetudo (прошивка для коммерческих пылесосов без облака), библиотеки kaiaai/LDS для LiDAR, мост ROS2 для пылесосов от remakeai, исследования разборки роботов-пылесосов Денниса Гизе и проект уличной газонокосилки Open Mower как источник вдохновения.
Он ссылается на предшественников, например Valetudo (прошивка для коммерческих пылесосов без облака), библиотеки kaiaai/LDS для LiDAR, мост ROS2 для пылесосов от remakeai, исследования разборки роботов-пылесосов Денниса Гизе и проект уличной газонокосилки Open Mower как источник вдохновения.What are similar projects?ardupilot, Marlin, muse-gadget-sdk, tiny-engineer, Tasmota, awesome-esp32, smartknob, tinygo
ardupilot, Marlin, muse-gadget-sdk, tiny-engineer, Tasmota, awesome-esp32, smartknob, tinygoWhich topics is it in?slam, ros2, stm32, sensors, navigation, arduino, 3d-printing, home-assistant, esp32, robotics, firmware, iot
slam, ros2, stm32, sensors, navigation, arduino, 3d-printing, home-assistant, esp32, robotics, firmware, iot