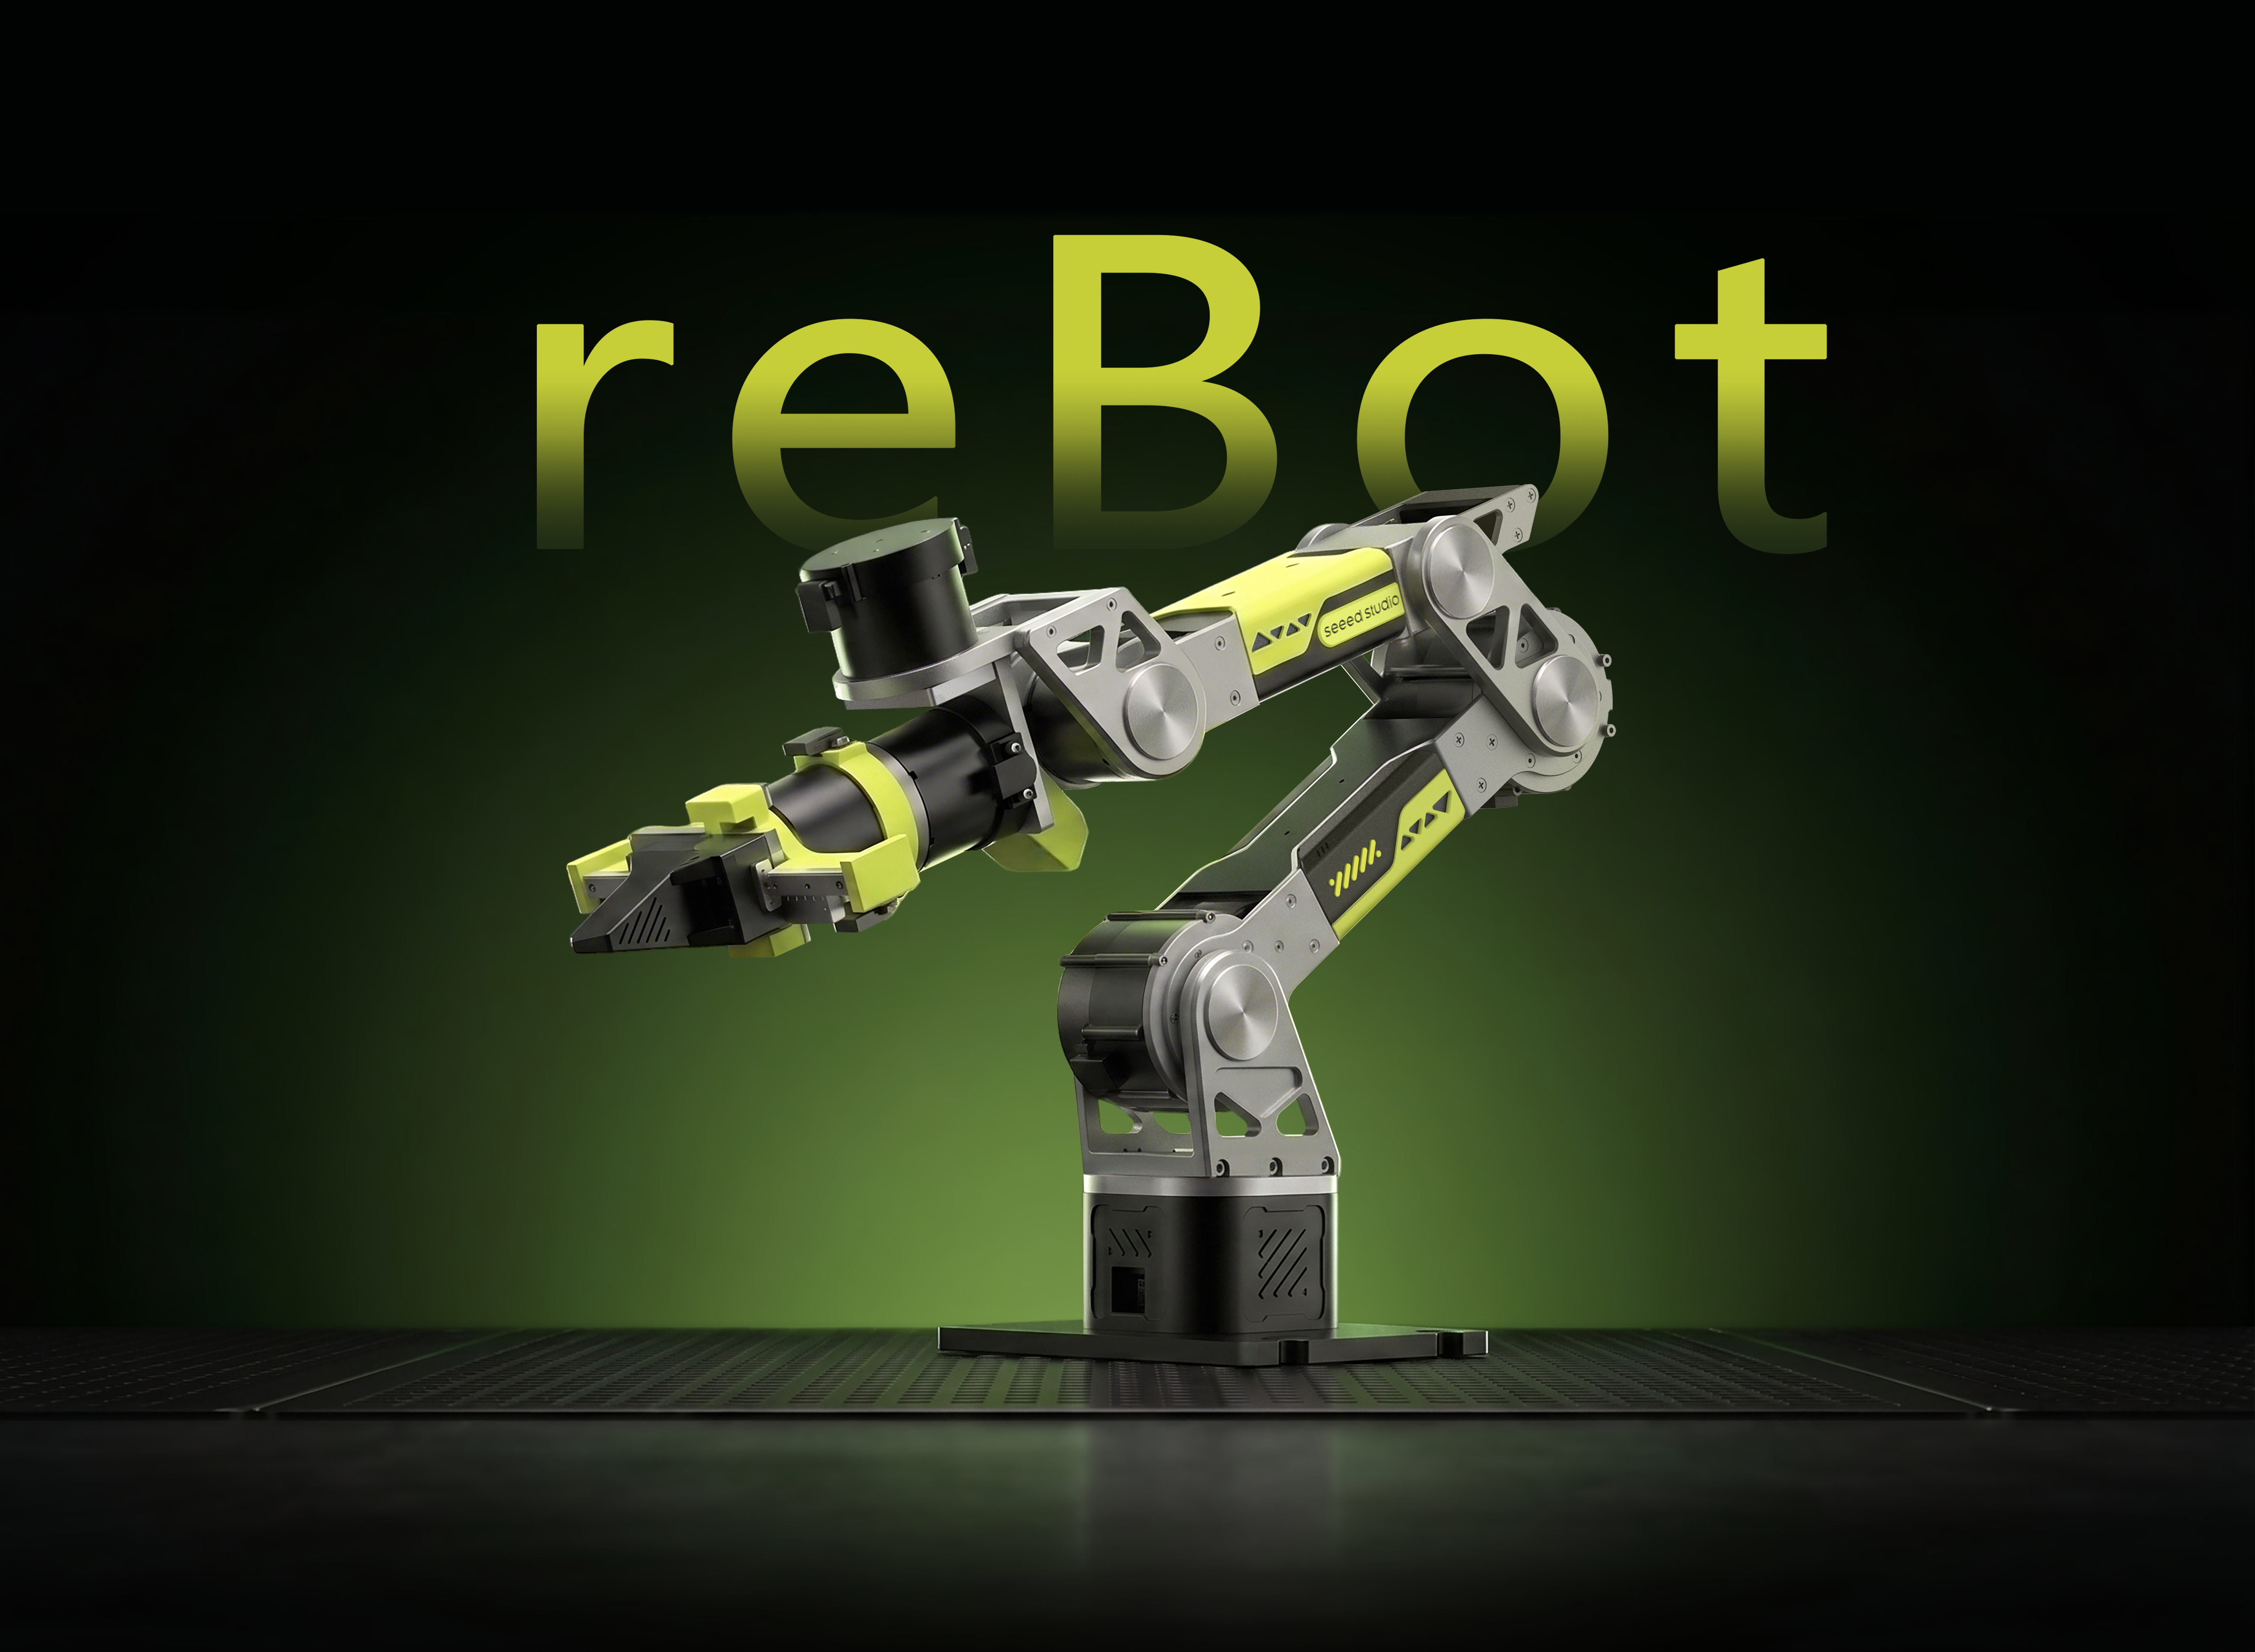
🦾 reBot-DevArm: Open Source Robotic Arm for All Developers

🚀 100% Open Source · Embodied AI · Full Hardware + Software Stack
📦 Build your own robotic arm · 🧠 Learn robotics · 🏭 Deploy real applications
简体中文 |
English |
日本語 |
français |
Español
🛒 Official Purchase
📖 Introduction
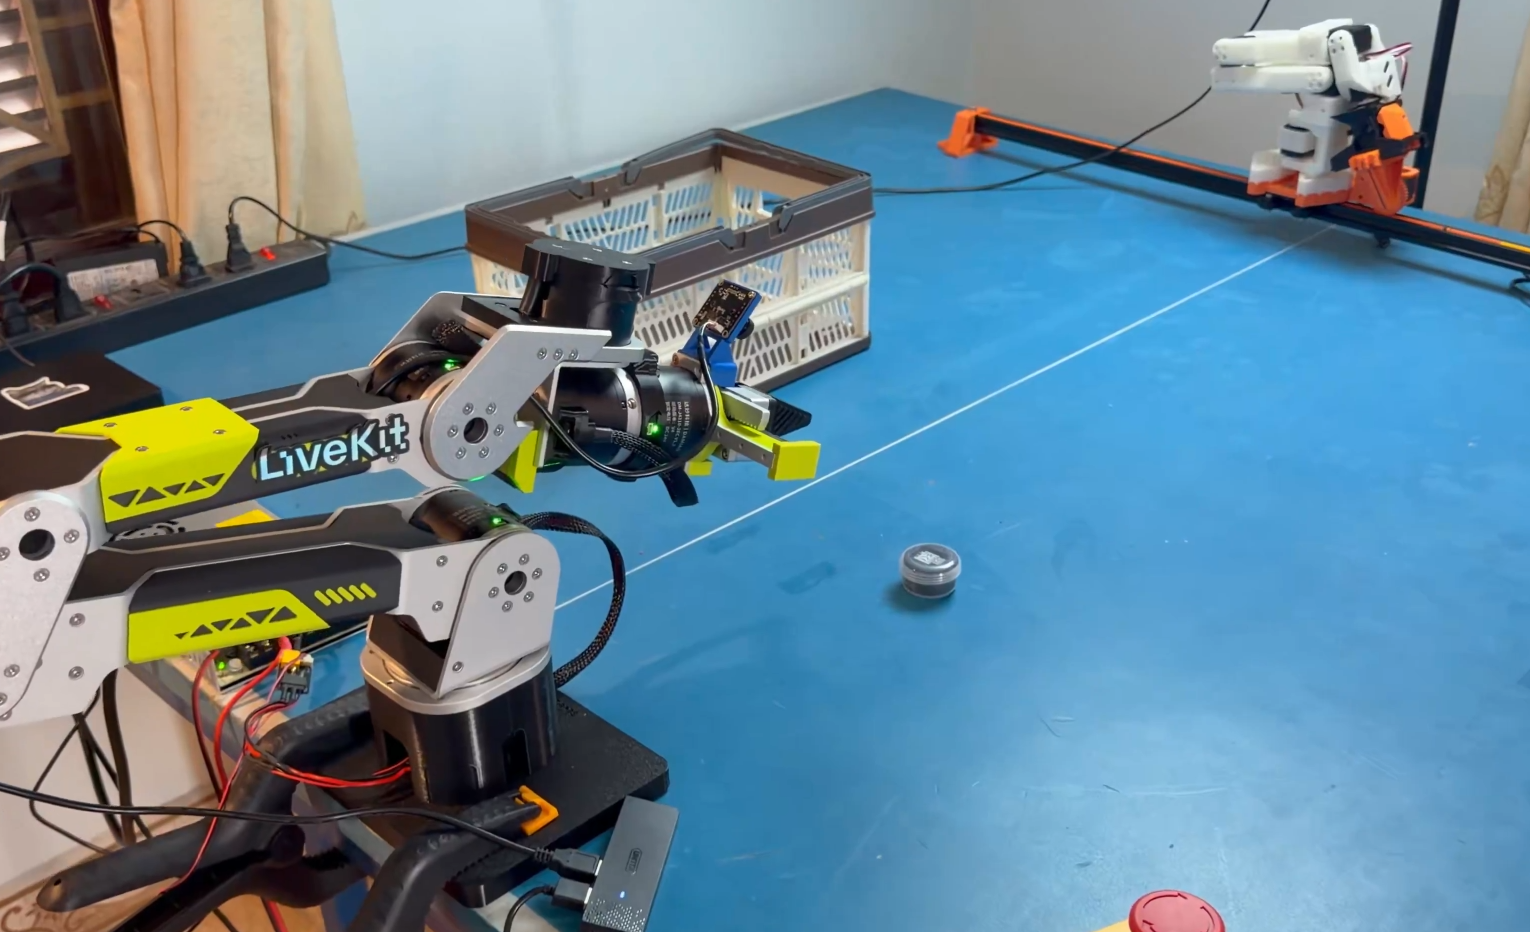
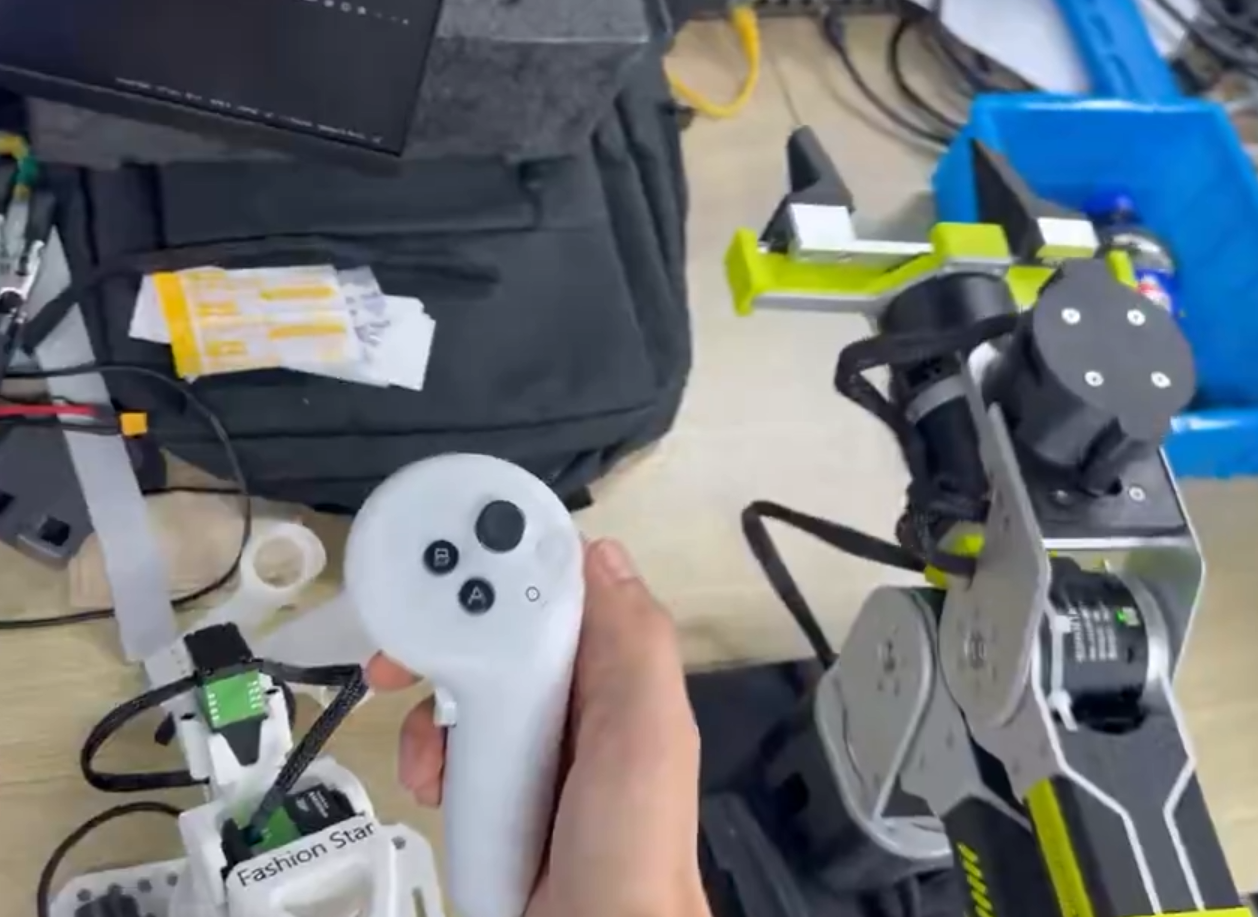
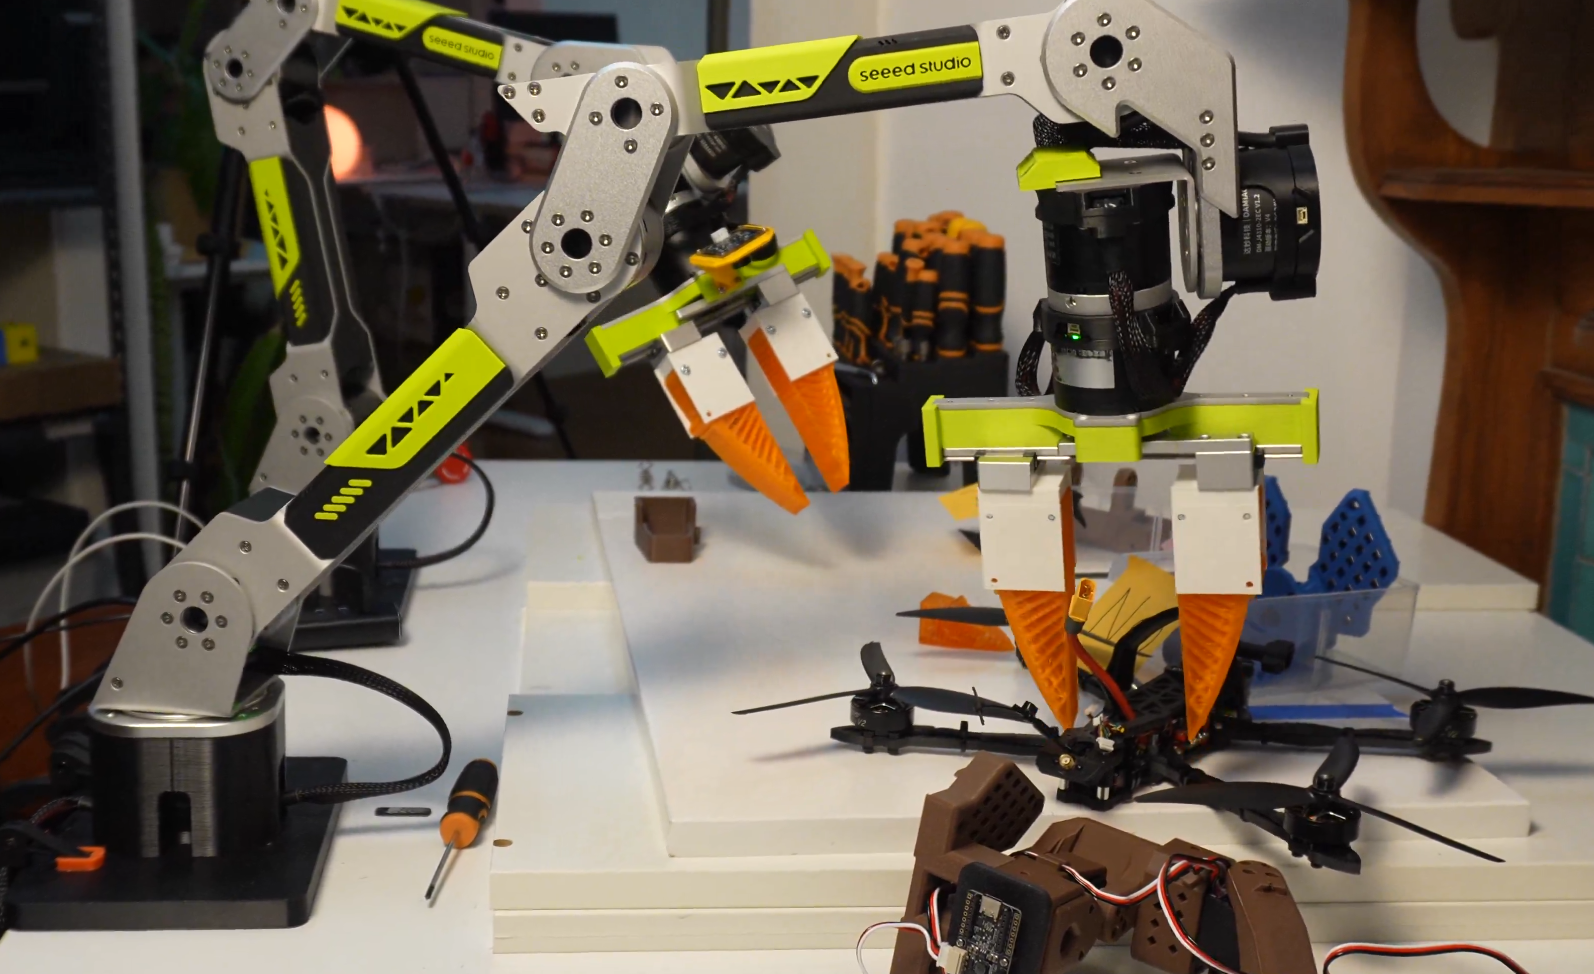
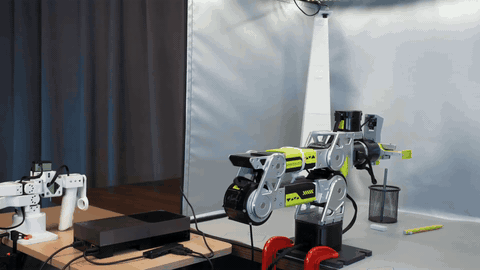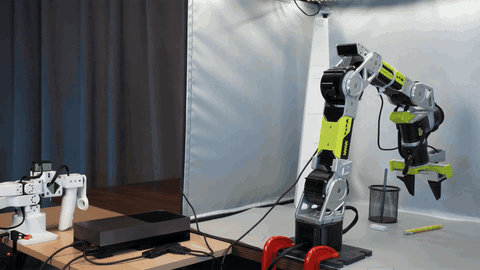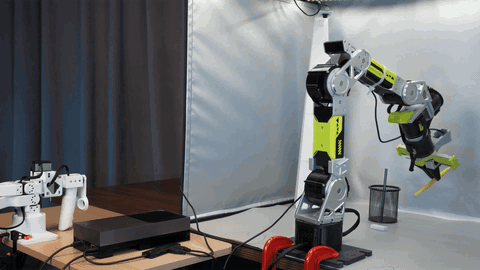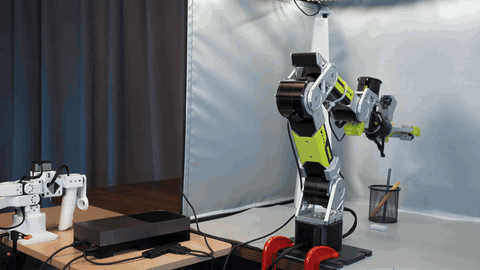
reBot-DevArm (reBot Arm B601 DM and reBot Arm B601 RS) is a robotic arm project dedicated to lowering the barrier to learning Embodied AI. We focus on "True Open Source" — not just the code, we unreservedly open source everything:
- 🦾 Two versions of the robotic arm:We will provide all open-source files for two versions of the robotic arm with the same appearance: Robostride and Damiao.
- 🛠️ Hardware Blueprints: Source files for sheet metal parts and 3D printed parts.
- 🔩 BOM List: Detailed down to the specifications and purchase links for every single screw.
- 💻 Software & Algorithms: Python SDK, ROS1/2, Isaac Sim, LeRobot, etc.
Get Your Own reBot Arm
We offer five kit options at Seeedstudio.com :
- Arm Body Motor Kit: Includes only motors and wiring harnesses for the robotic arm.
- Arm Body Structural Kit: Includes only mechanical structural components.
- Gripper Complete Kit: Includes motors, wiring harnesses and structural components for the gripper.
- Full Kit: Includes the complete set of the robotic arm body and gripper.
- Pre‑assembled Robotic Arm: Fully assembled finished robotic arm.
The Seeedstudio kit does not include a power adapter and C-clamps as standard accessories. This arrangement takes into account that users may power the unit via batteries or mount it with a custom DIY base. You may purchase a power supply separately and Power Cord, or refer to the Mean Well power solution shown at the bottom of our BOM.
You can also purchase the Leader Arm and 12V 10A Power Supply You may also use the 12VDC power adapter of SO-ARM101 to supply power to the Leader.
For reBot Arm RS Version, We offer five kit options at Seeedstudio.com :
- Full Kit: Includes the unassembled complete set of the robotic arm body and gripper.
- Pre‑assembled Robotic Arm: Fully assembled finished robotic arm.
We highly recommend using the Meanwell 48V 12.5A power supply for the RS model. If you need stronger power to unlock its full performance, you may opt for a 48V 25A power adapter.
🚀 Try the Online Simulation
Experience the reBot Arm B601-RS MuJoCo digital twin directly in your browser—no installation required. Switch between the standard arm and AGV configurations, control the joints and TCP, view the overhead and D405 wrist cameras, and run the automated put-away and stacking demos. The initial model download may take a moment; Chrome or Edge is recommended.
▶ Launch the reBot Arm Interactive Demo
🗺️ Roadmap & Status
We are committed to continuously maintaining and adapting to mainstream robot development ecosystems. Below is our current adaptation progress and planned release schedule:
reBot Arm B601 DM
| Supported Ecosystem |
Status |
Description / Estimated Release Date |
Related Documentation |
| Basic Motor Usage |
✅ Completed |
Basic motion control and API encapsulation |
Damiao Technology |
| Open-Sourcing of the New STEP 3D Structural Parts and BOM |
✅ Completed |
STEP files for all parts in the new version, parts BOM, and reference prices for all machined components |
reBot Arm B601-DM BOM |
| Reference for Real Machine Performance Testing |
✅ Completed |
Performance Reference of Robotic Arm under Normal and Extreme Operating Conditions |
Performance Testing |
| Assembly Video |
✅ Completed |
Ultra-detailed assembly steps and video |
Getting Started with reBot Arm B601-DM |
| Python SDK |
✅Continuously optimized, PRs welcome |
One-stop integration of motor read/write and control for Robstride, Damiao, Mota, Gaoqing, Hexfellow and other motors. |
Getting Started with Motorbridge and Web UI |
| ROS2 Integration |
✅ Completed |
ROS2 integrated reBot Arm controller with support for kinematics, trajectory planning, and gravity compensation |
reBot Arm B601-DM ROS2 Integration Guide |
| Pinocchio Integration |
✅ Completed |
Adaptation to the Pinocchio framework, enabling forward/inverse kinematics and gravity compensation for the robotic arm |
Getting Started with Pinocchio for reBot Arm B601-DM and Github repo |
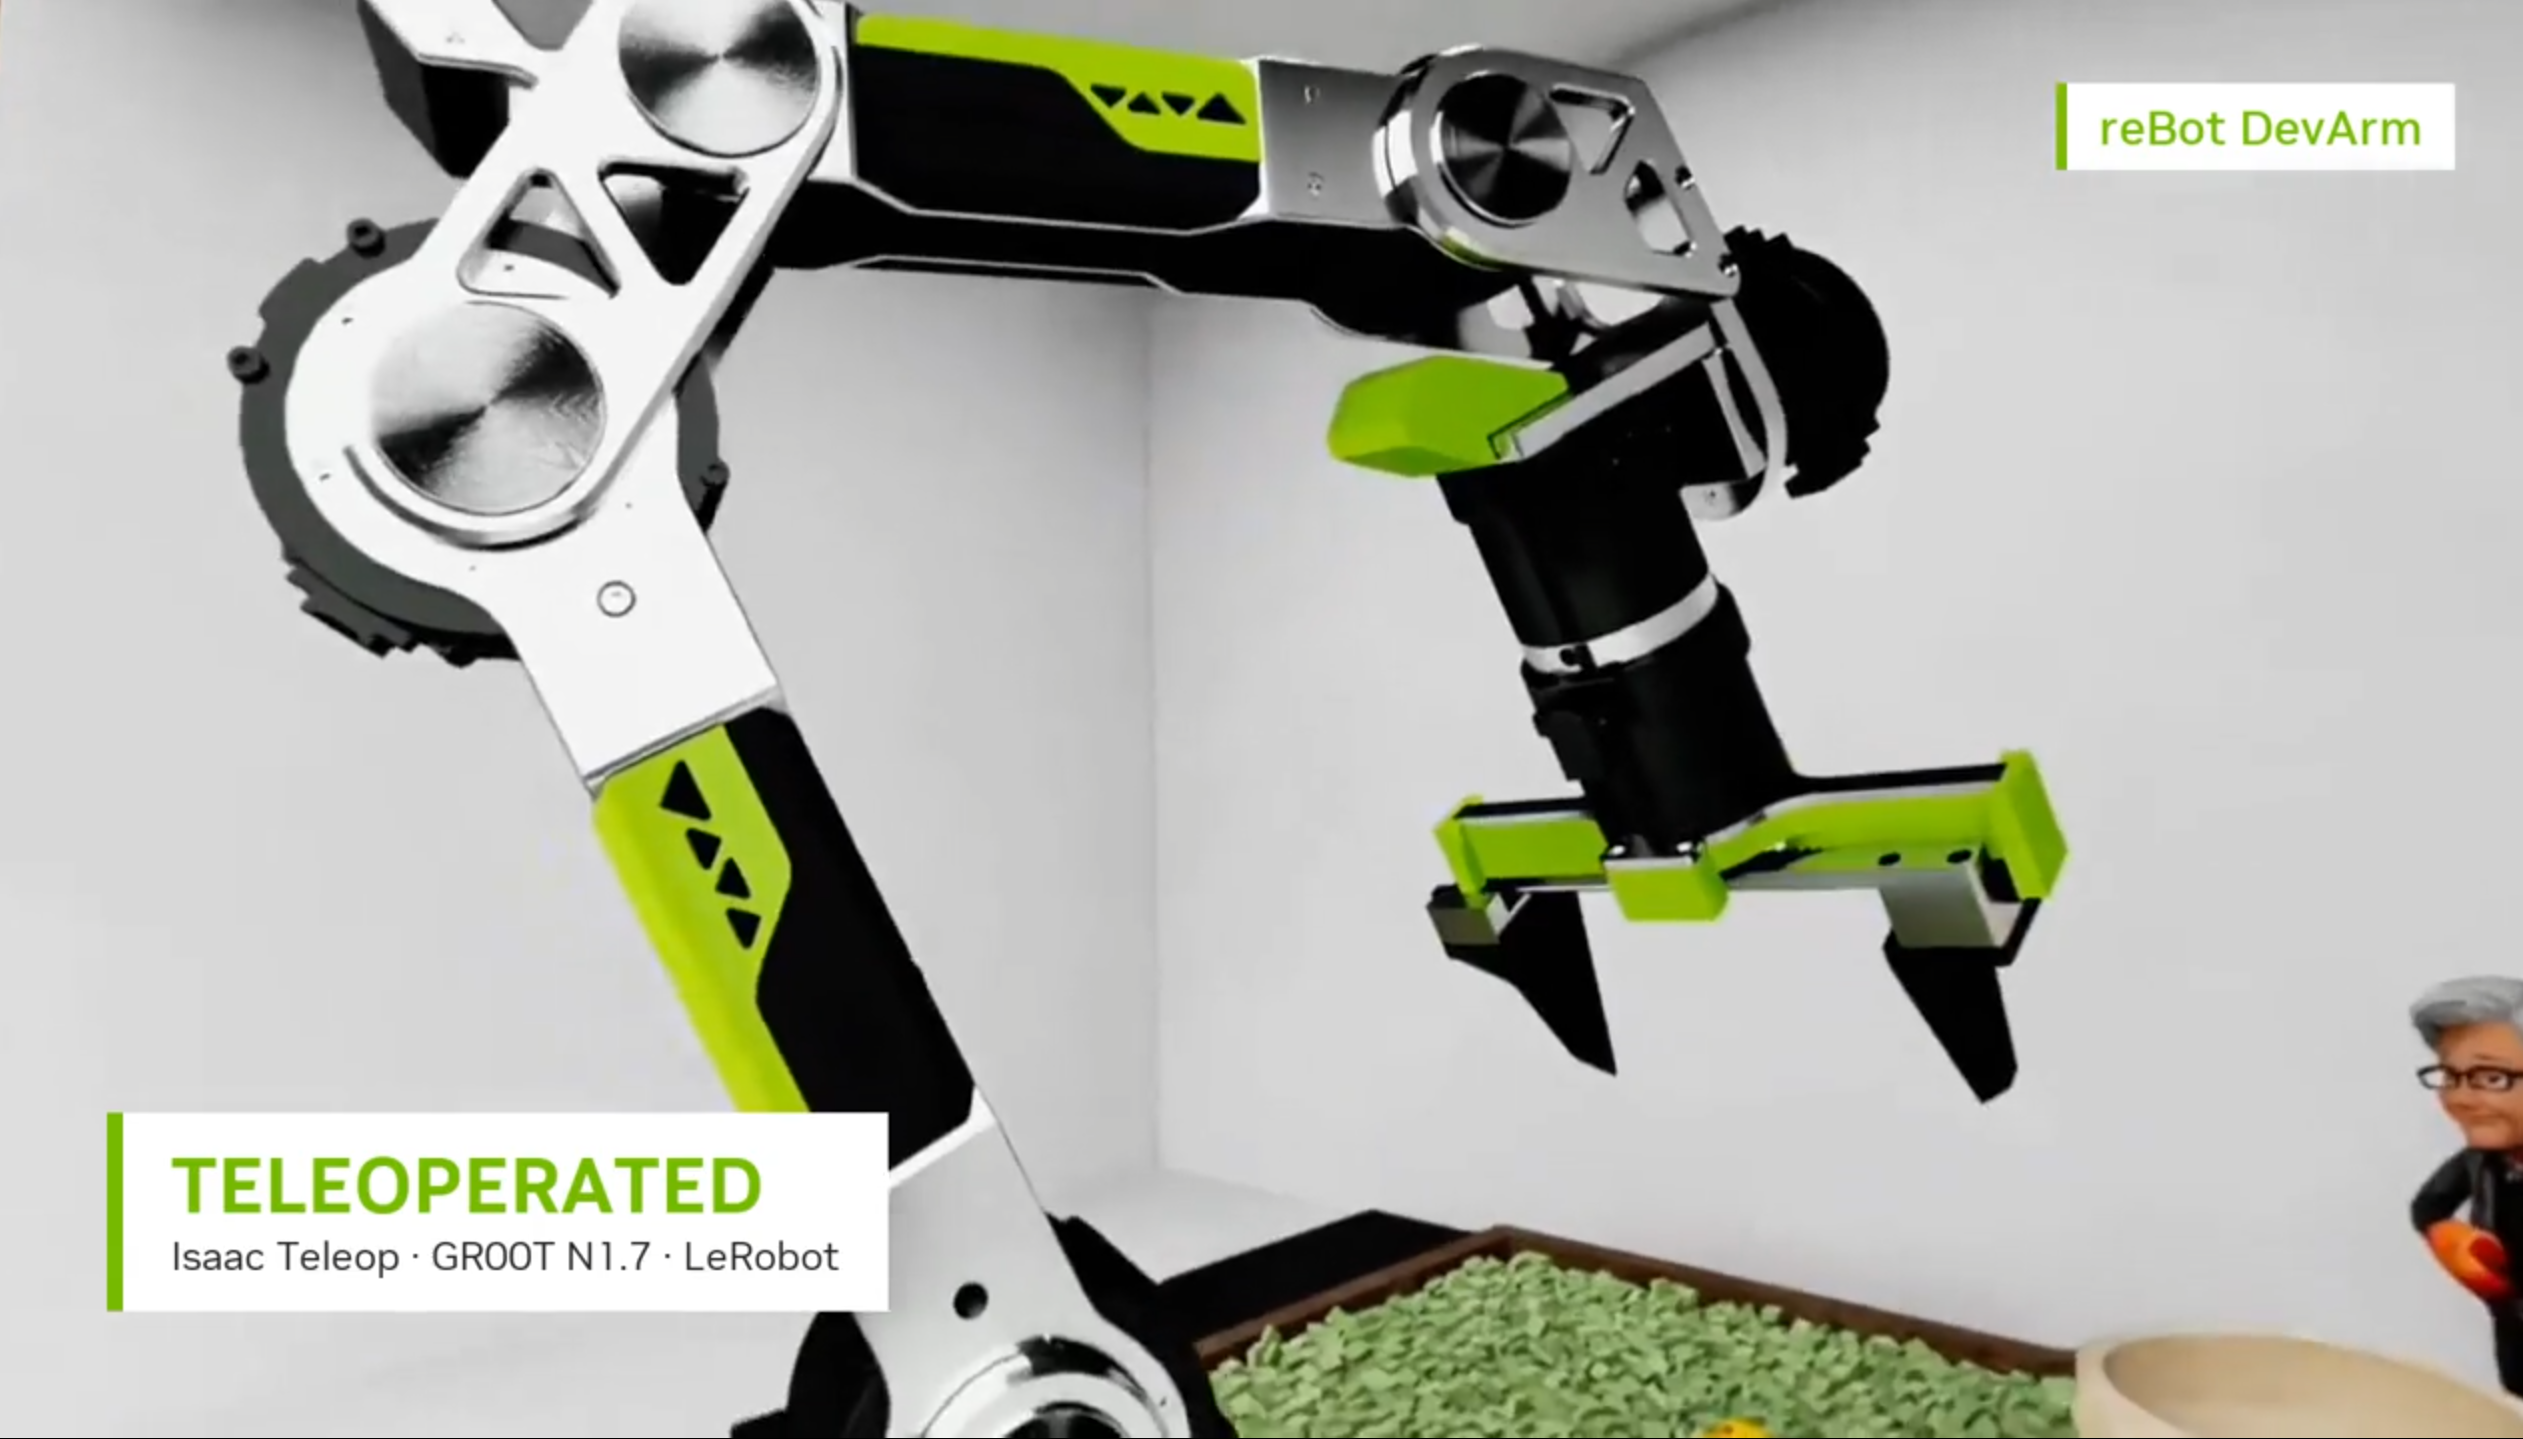
| Isaac Sim Simulation |
🚧 In Progress |
Import USD models and enable simulated teleoperation |
Wiki |
| LeRobot Integration |
✅ Completed |
Adaptation to the Hugging Face LeRobot training framework |
Getting Started with LeRobot-based reBot Arm |
| Depth Camera Integration |
✅ Completed |
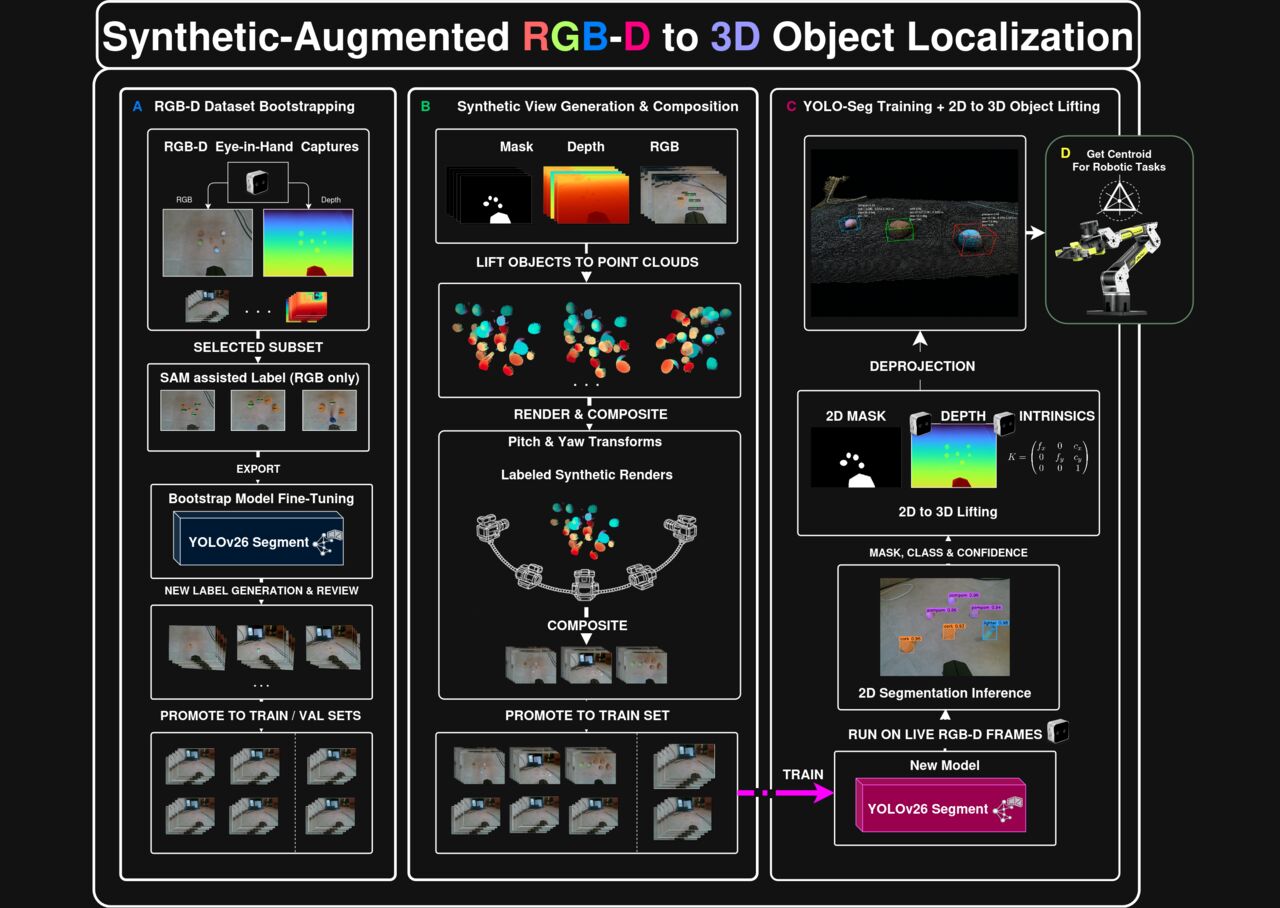
Visual Grasping Demonstration Based on YOLO and Depth Camera |
Getting Started with Visual Grasping Demo |
| reSpeaker Voice Integration |
✅ Completed |
Add reSpeaker Flex 4-mic array to build a voice-driven intelligent robot arm control system with spatial awareness |
reBot Arm B601-DM Voice Control |
| Gradual Updates of the Latest Algorithms |
⏳ Planned |
Mainstream algorithms will be updated progressively |
Ongoing |
| Launch of a Series of Completely Free Courses |
⏳ Planned |
Mainstream algorithms will be updated progressively |
Ongoing |
Contributions from Developers
| Supported Ecosystem |
Authors |
Description / Estimated Release Date |
Related Documentation or Repository |
| ROS2 (Humble), third_party integration, URDF / rebotarm_bringup |
@danieldoradotalaveron-rb |
1. Passive diagnostics monitor (rebotarm_monitor_ros2): /diagnostics overlay for rqt_robot_monitor, serial/CAN-aware aggregator;
2. Safe park & shutdown: Capture rest pose on connect, slow return on shutdown or /rebotarm/park to prevent sudden drop;
3. Gravity compensation (smooth stop): MIT ramp-out when exiting gravity compensation to eliminate clack, jerk and instability during pos/vel handoff;
4. Gamepad teleop with IK/FK and safety measures: Gamepad control for end-effector via IK, live robot state visualization in RViz (simulation-only test);
5. D405 eye-in-hand TF: Xacro setup under end_link in rebotarm_bringup for RViz visualization & TF only (no driver/depth/intrinsics). Mount pose adjustable via launch file, bracket calibration not completed. Teleop FK/IK uses arm-only fixend_core URDF, full xacro for RSP/RViz. |
rebotarm_monitor_ros2、reBotArmController_ROS2 |
reBot Arm B601 RS
⚙️ Hardware Specifications
reBot-DevArm is designed for desktop Embodied AI applications, balancing payload capacity with flexibility.
| Parameter |
reBot Arm B601-DM |
reBot Arm B601-RS |
| Payload |
1.5kg |
2.5kg |
| Recommended Workspace |
70% arm reach workspace |
70% arm reach workspace |
| Max Reach |
767 mm |
754 mm |
| Weight |
Approx. 4.5 kg |
Approx. 6.7 kg |
| Repeatability |
< 0.2 mm |
< 0.2 mm |
| Degrees of Freedom (DOF) |
6 DOF + 1 Gripper |
6 DOF + 1 Gripper |
| Supported Platforms/Ecosystems |
ROS1, ROS2, LeRobot, Pinocchio, Isaac Sim, Python SDK |
ROS1, ROS2, LeRobot, Pinocchio, Isaac Sim, Python SDK |
| Supply Voltage |
DC 24V |
DC 48V |
🧹Optional Hardware
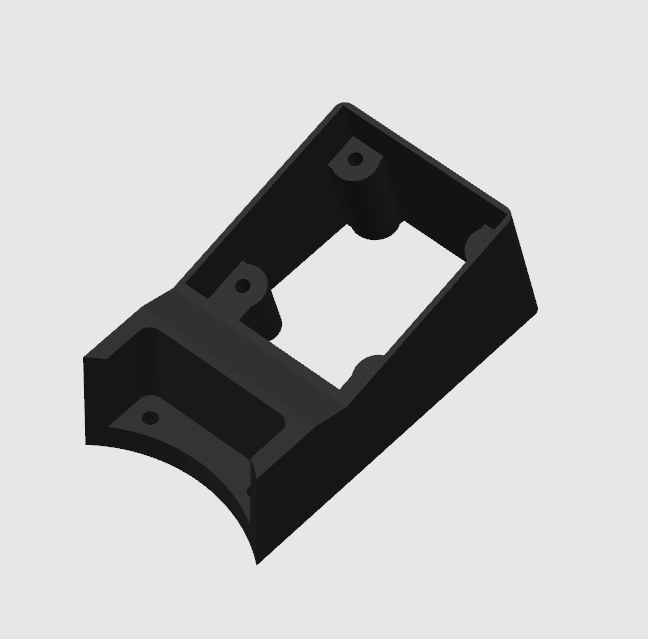
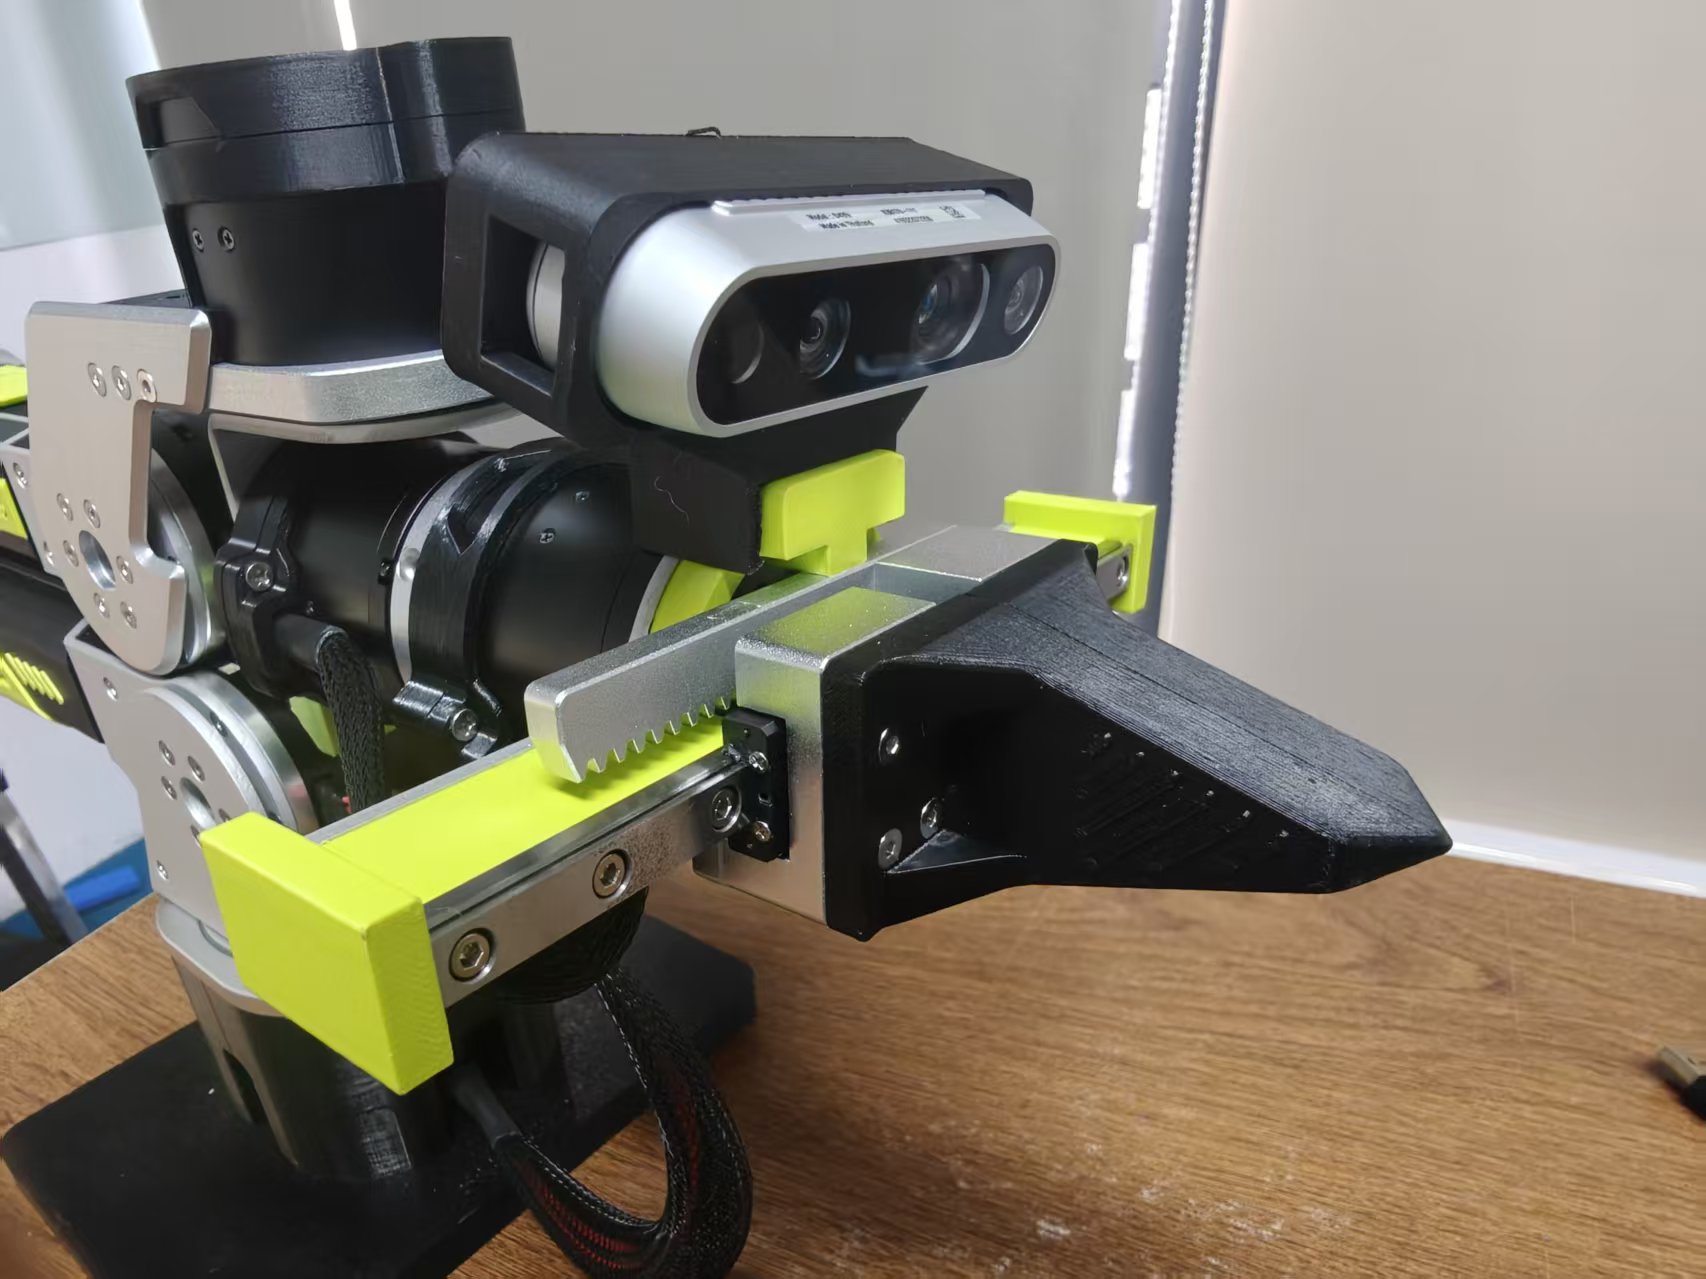
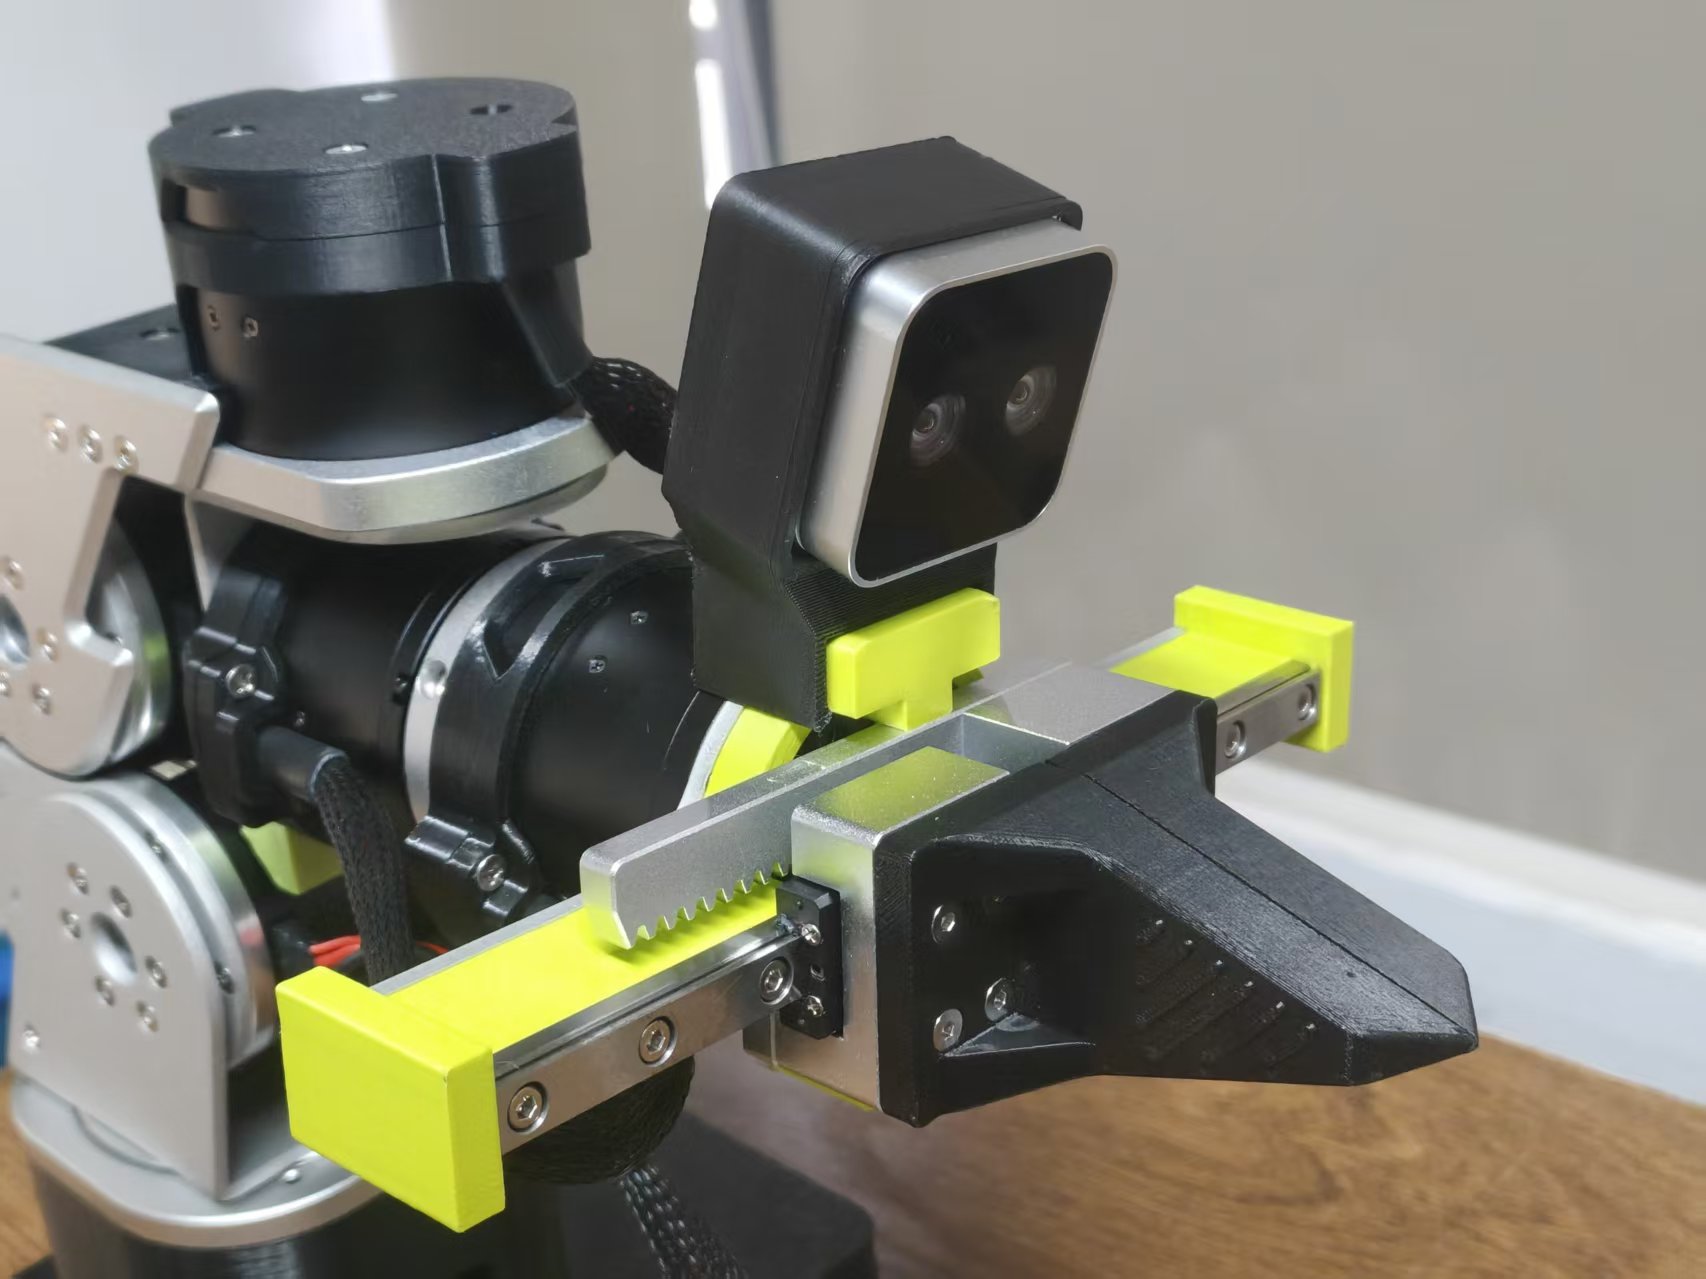
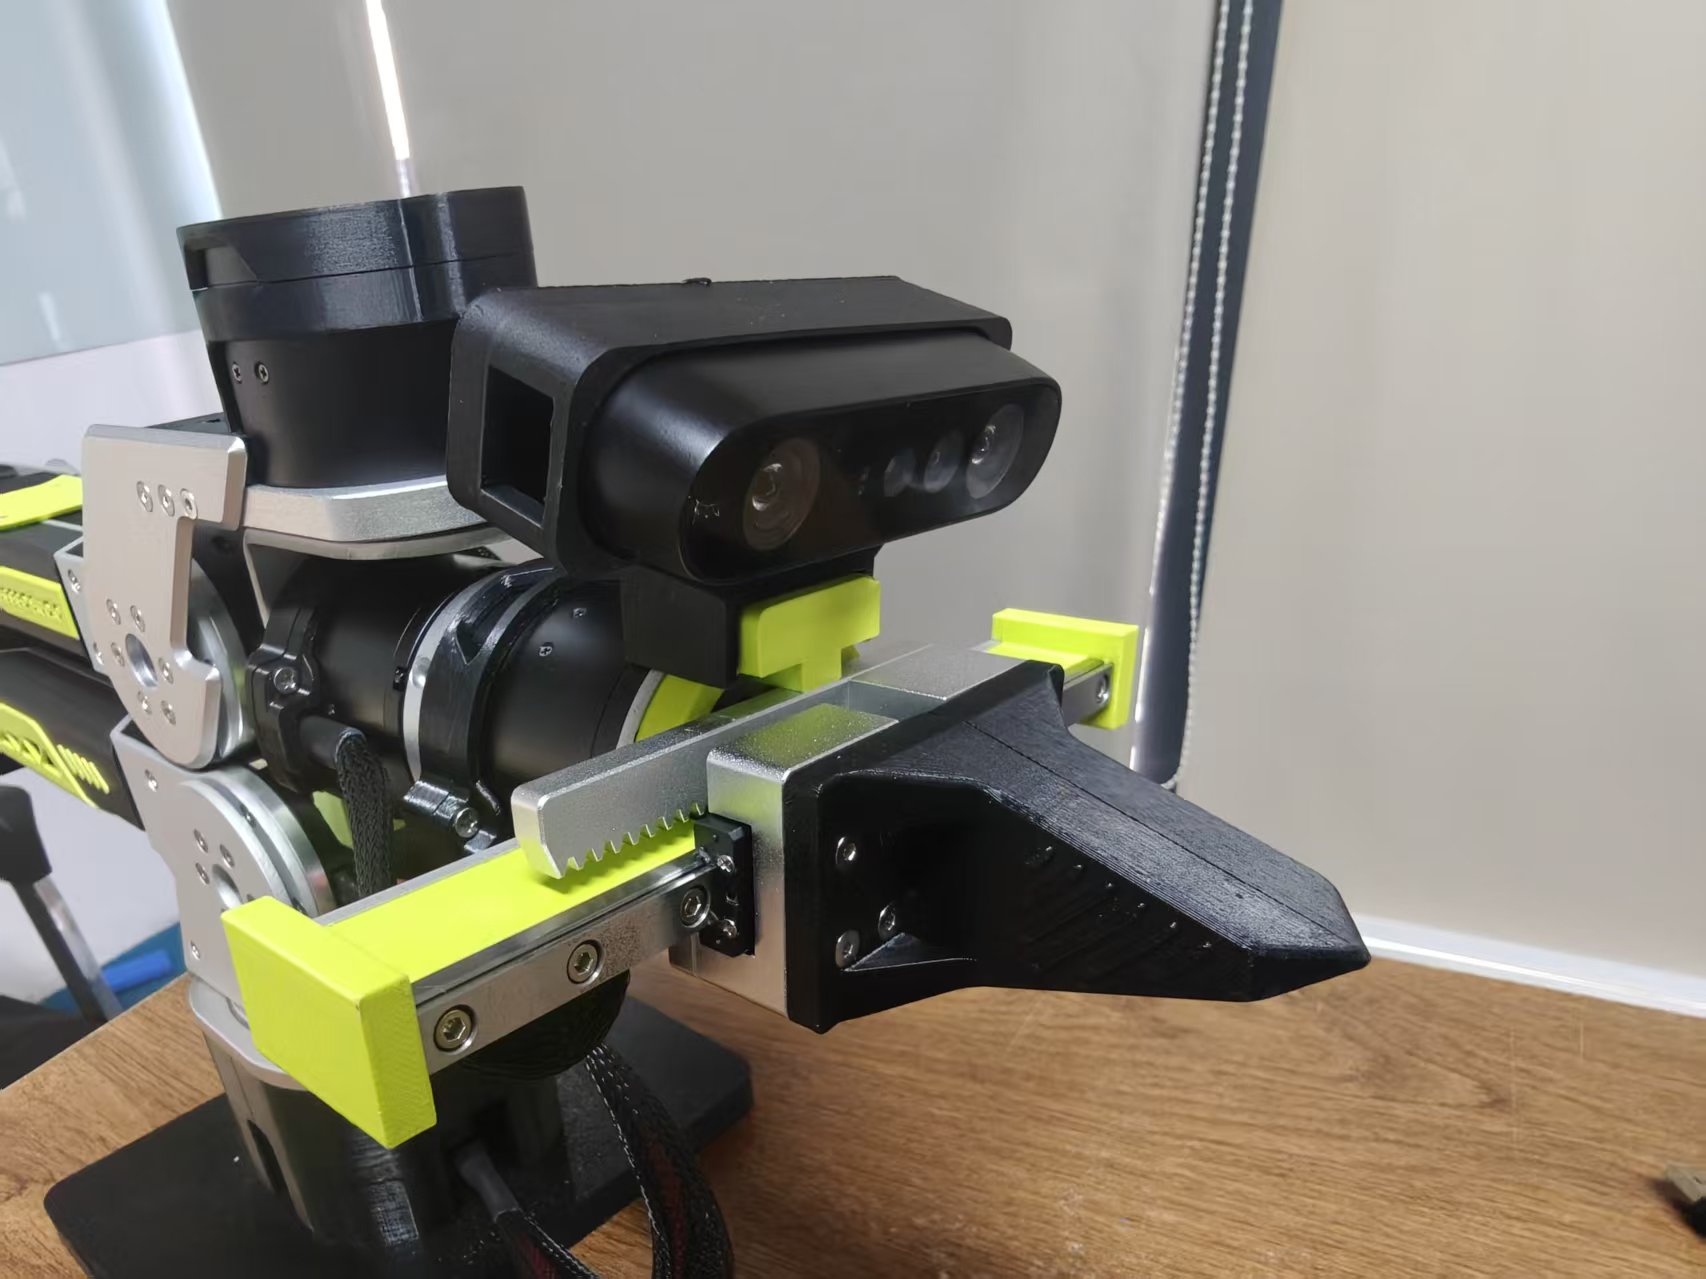
Wirst Camera Mount
Compatible with Leader Arm
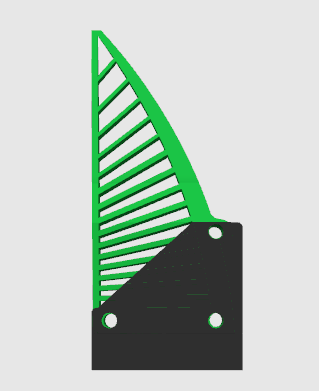
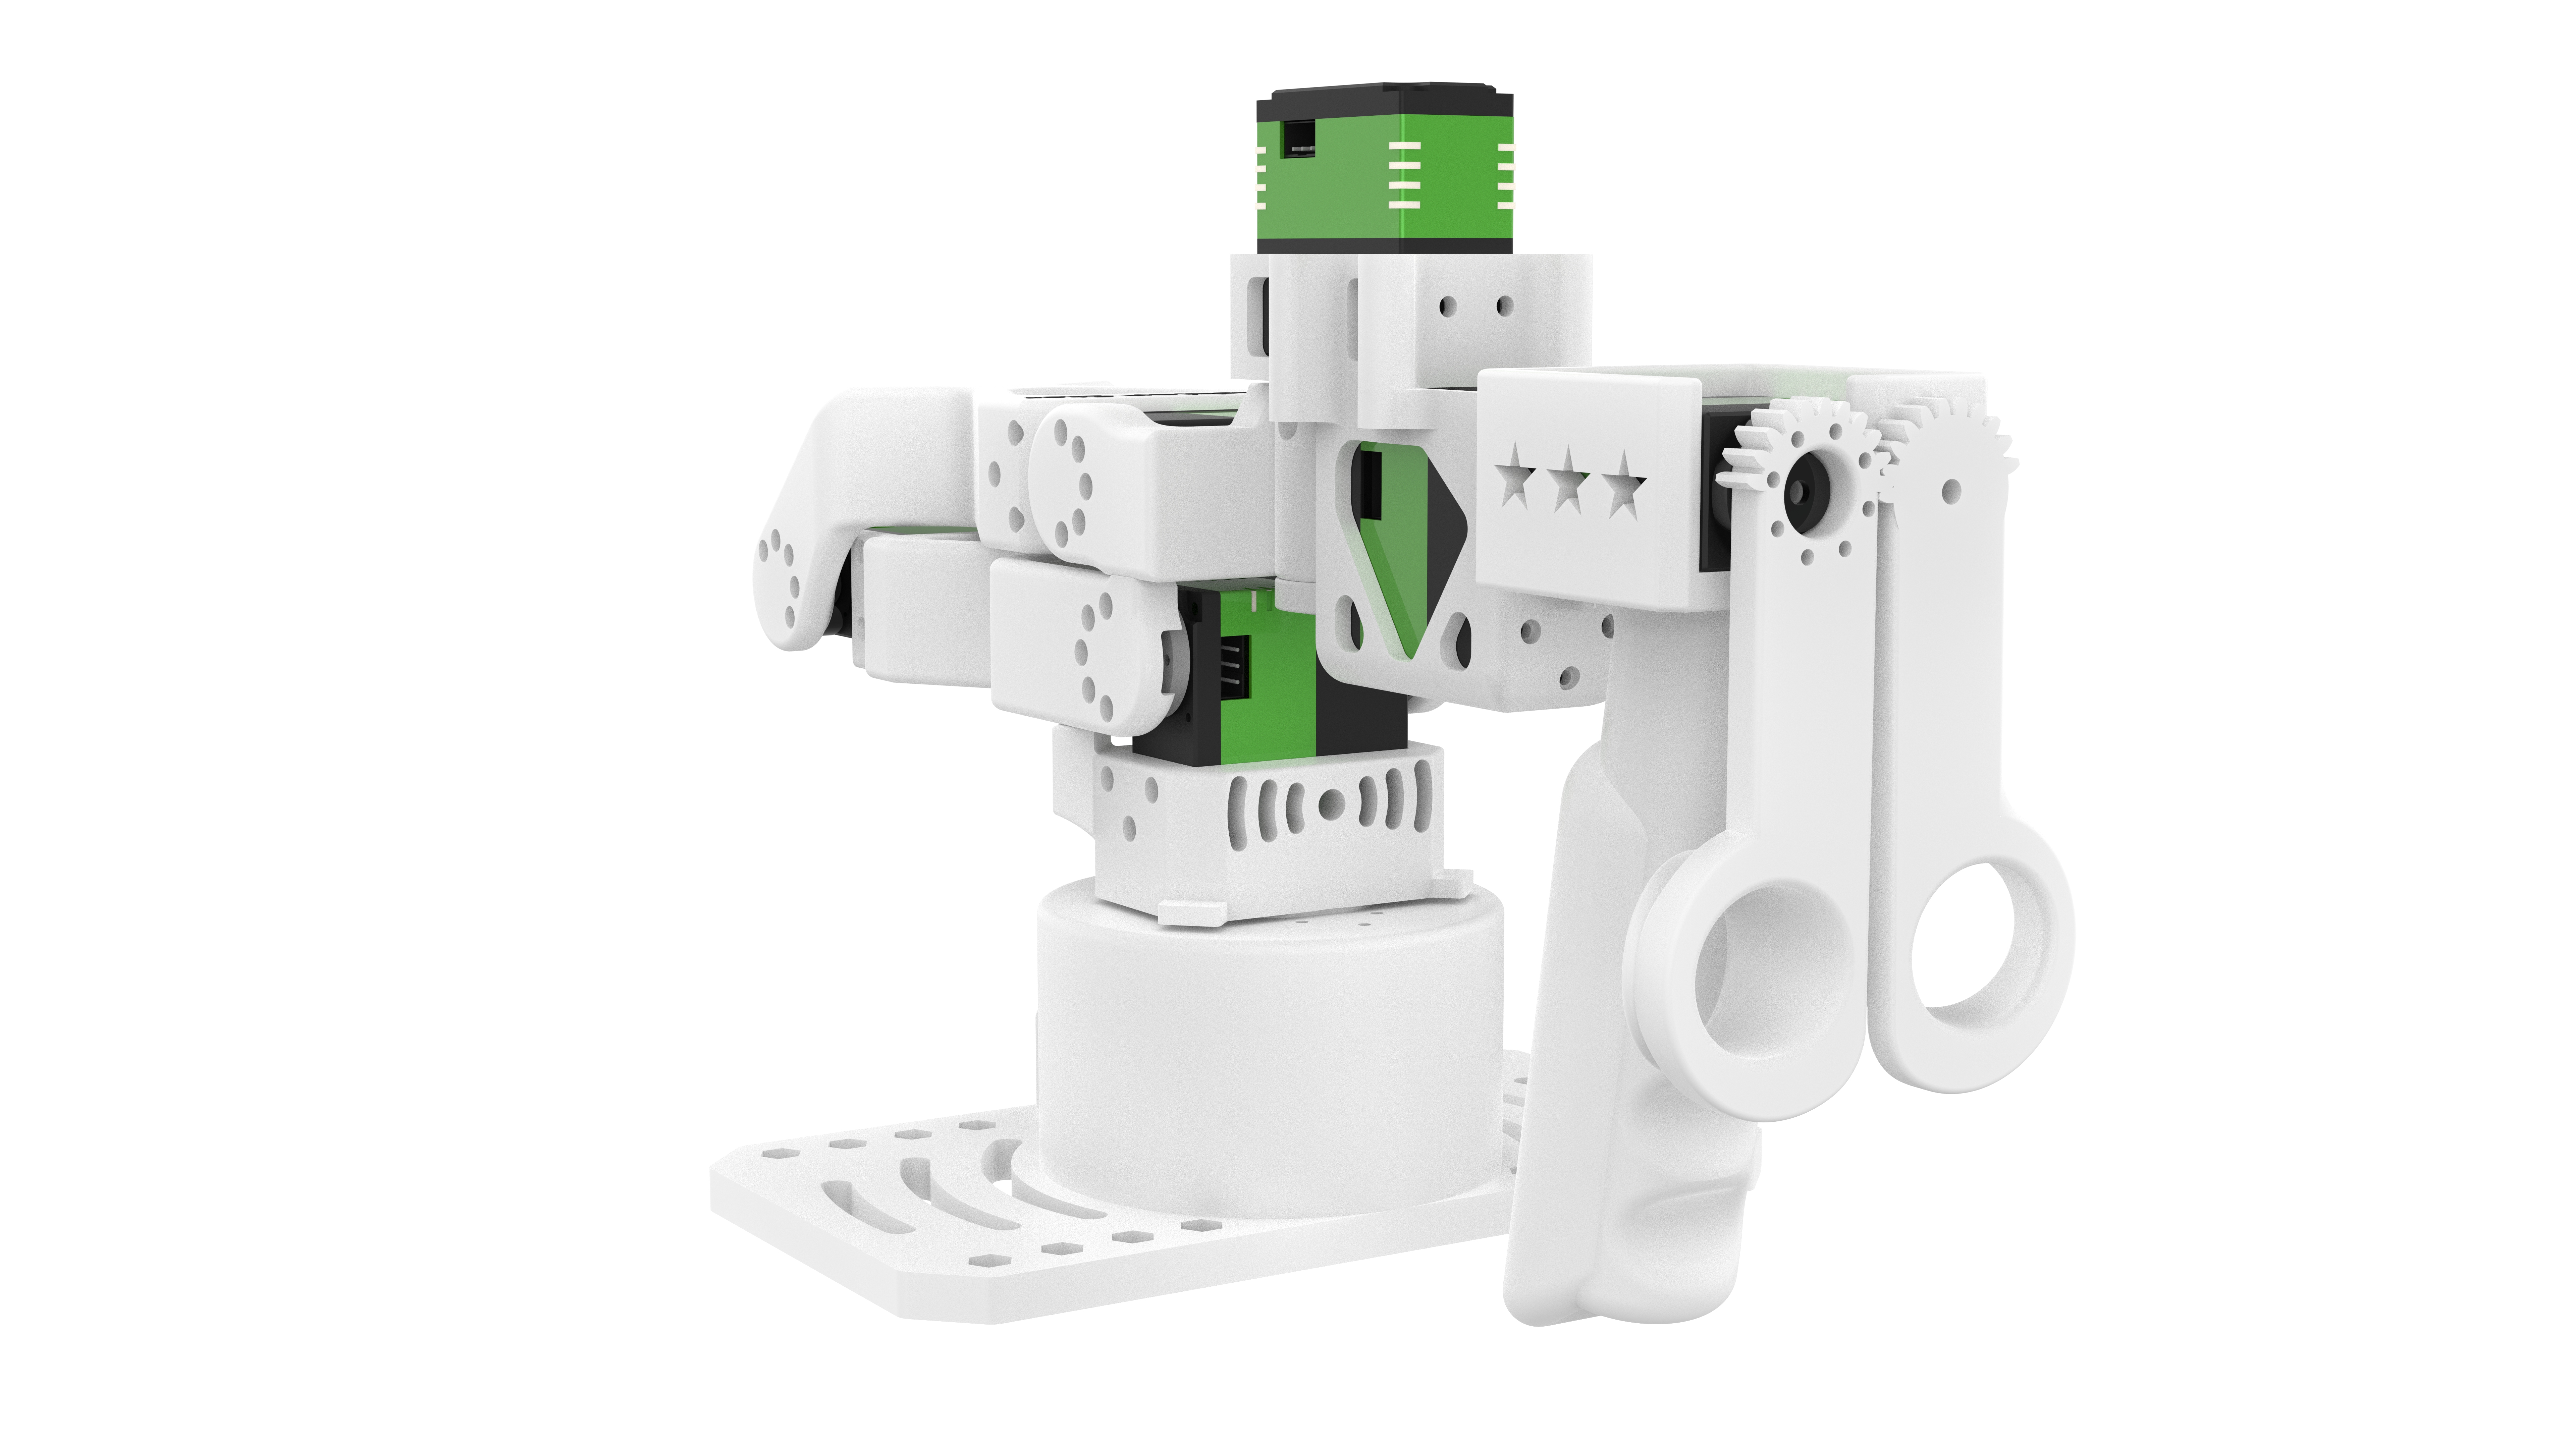
DIY Finger
| Soft Finger |
Open to compatibility integration |
 |
Comming soon |
| [Finger Mount(ABS/ |
|
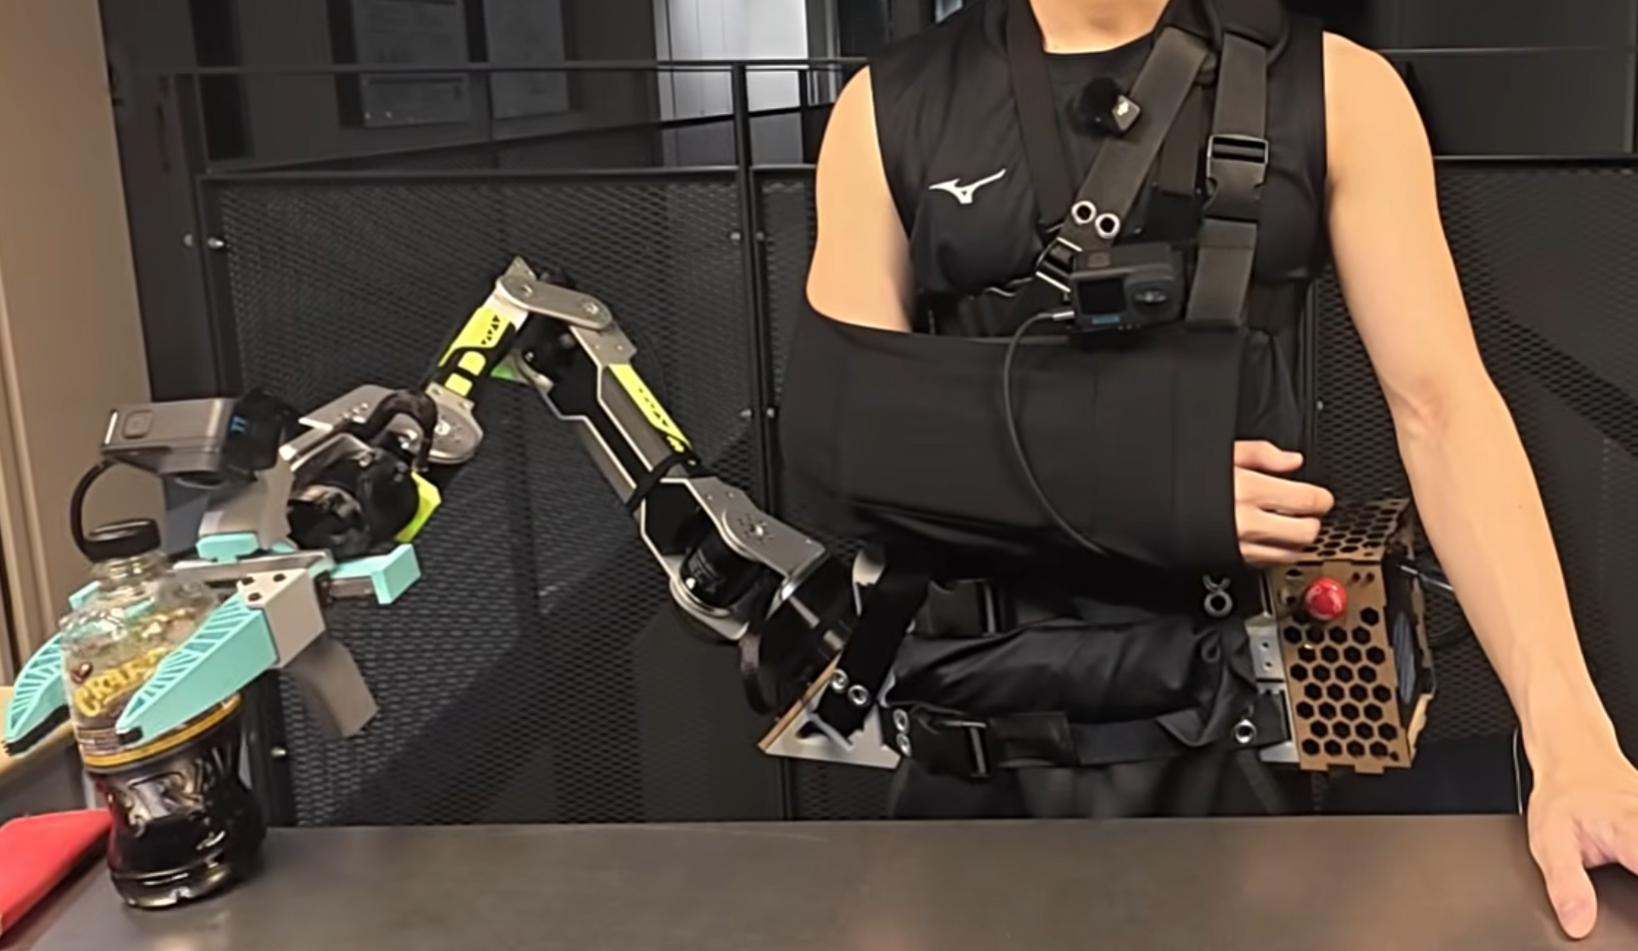
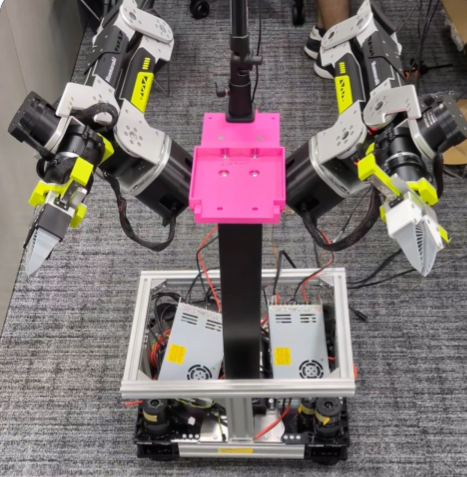
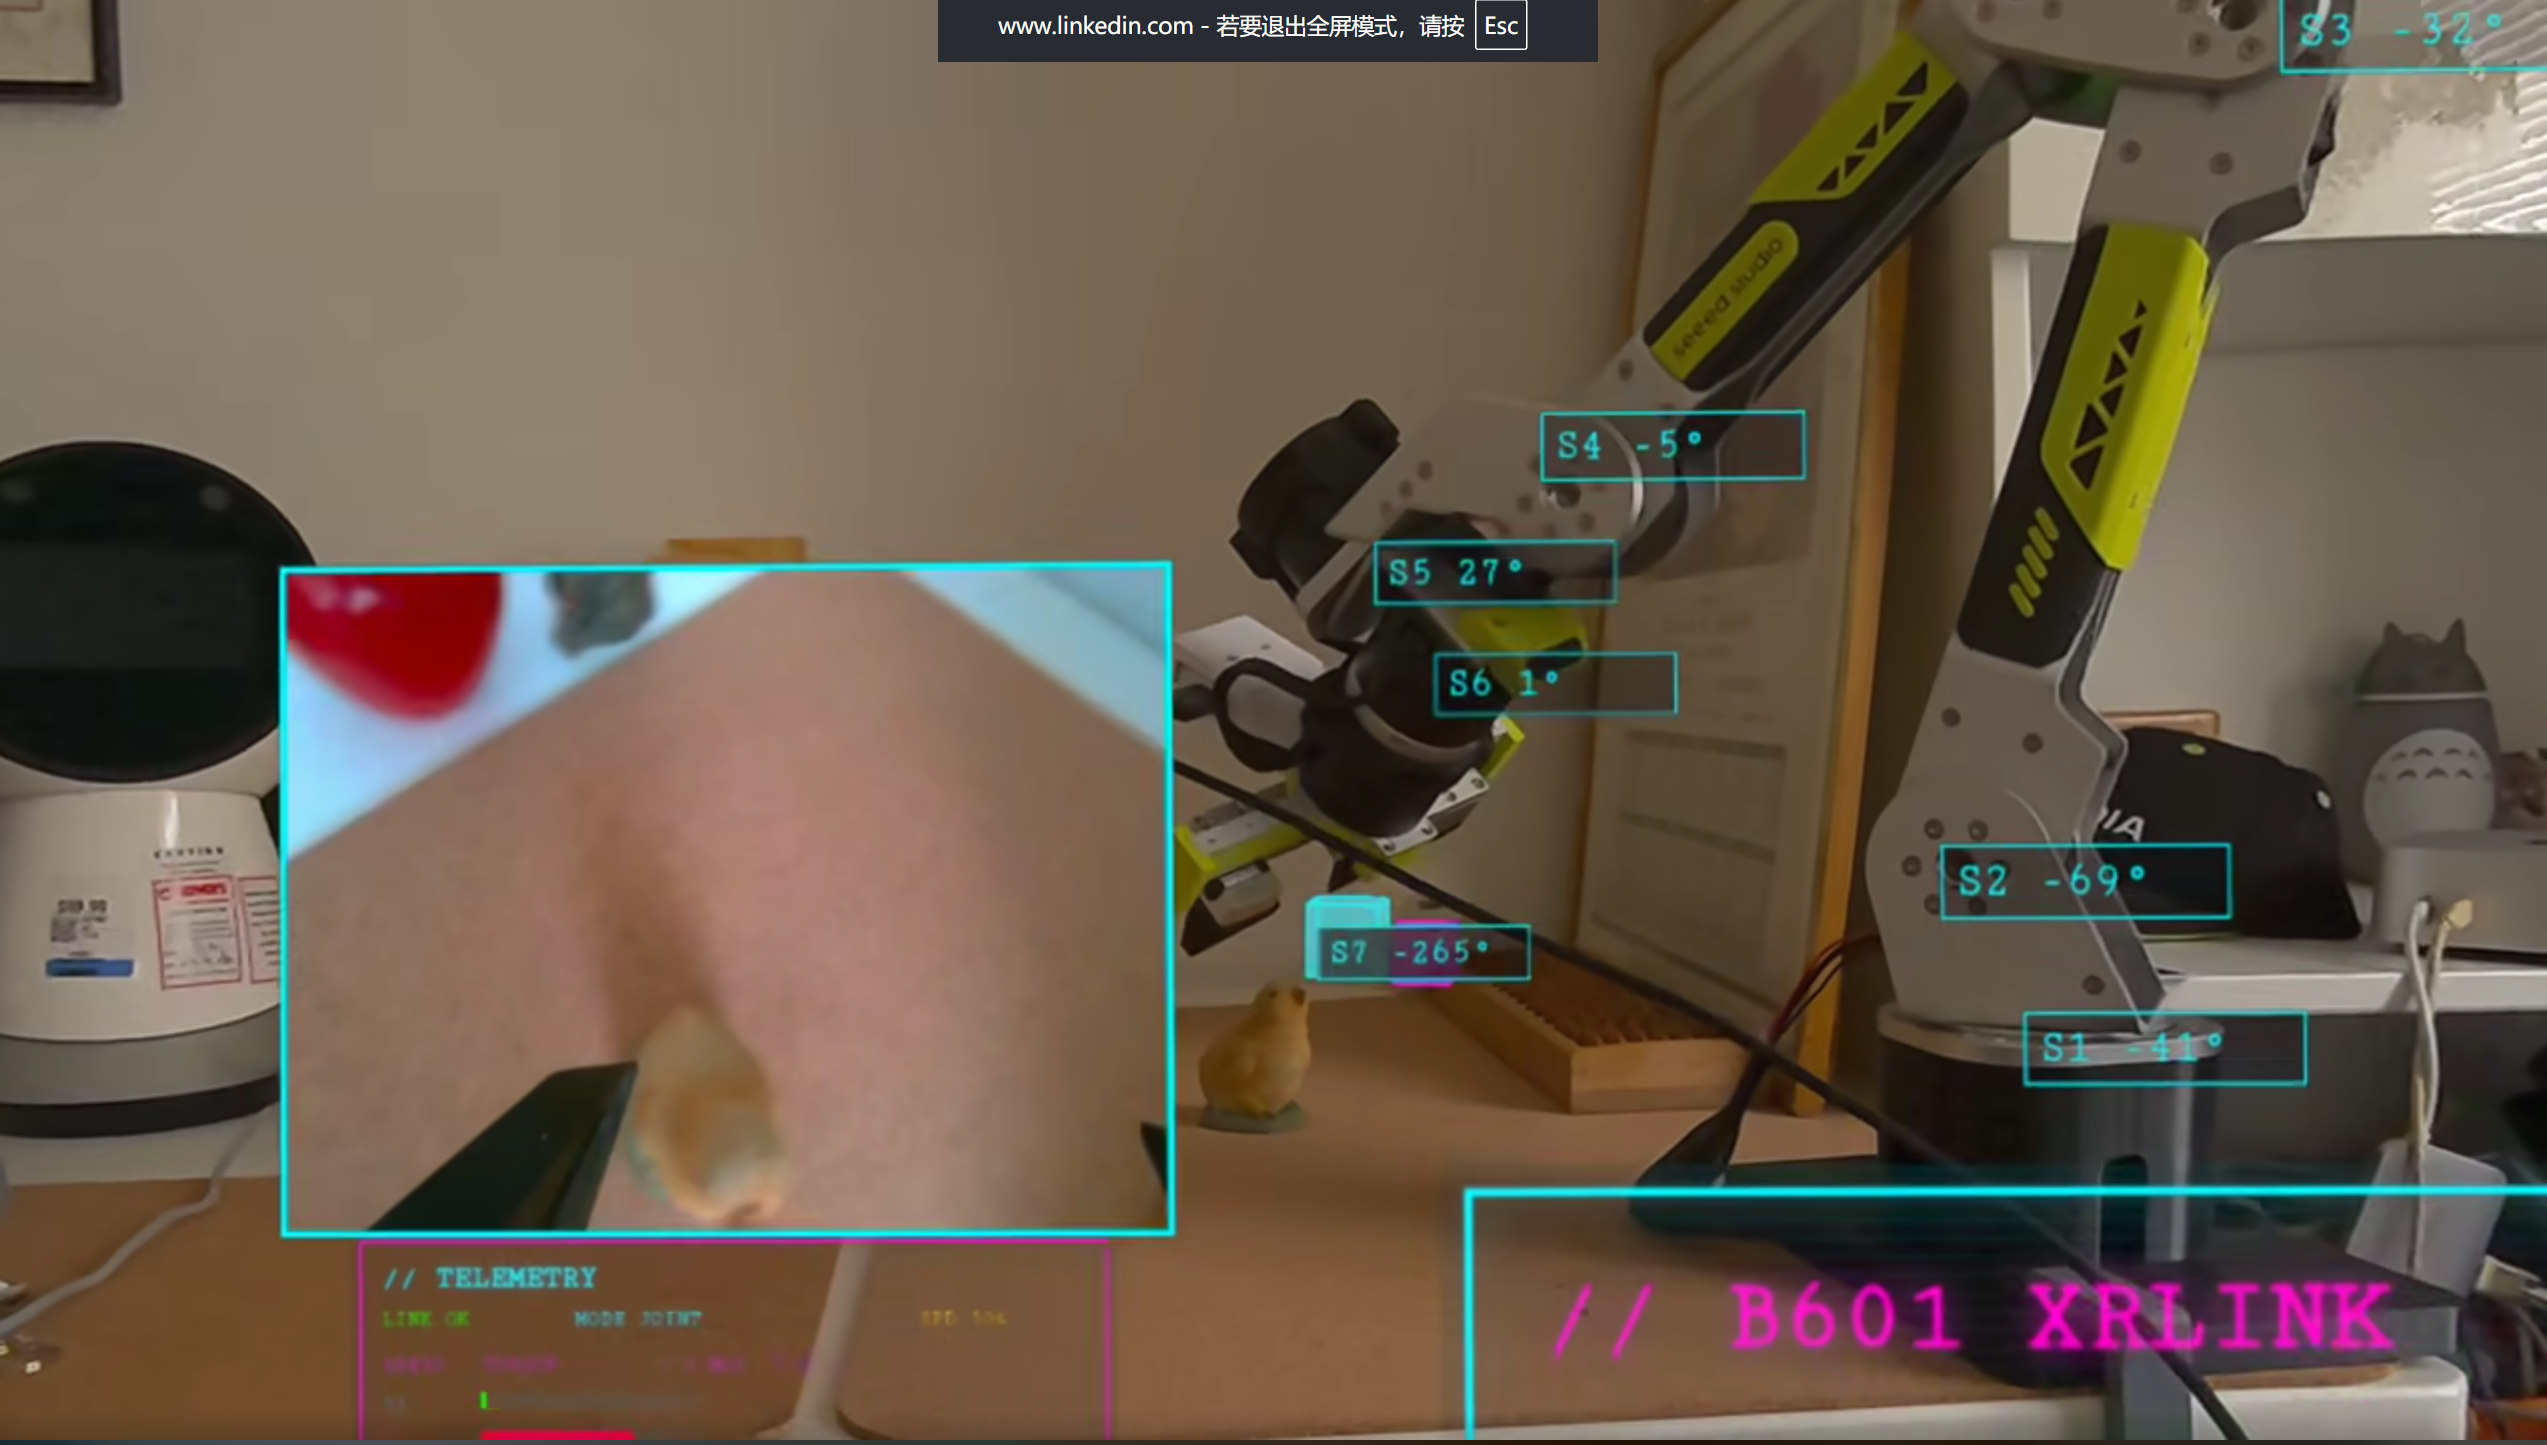
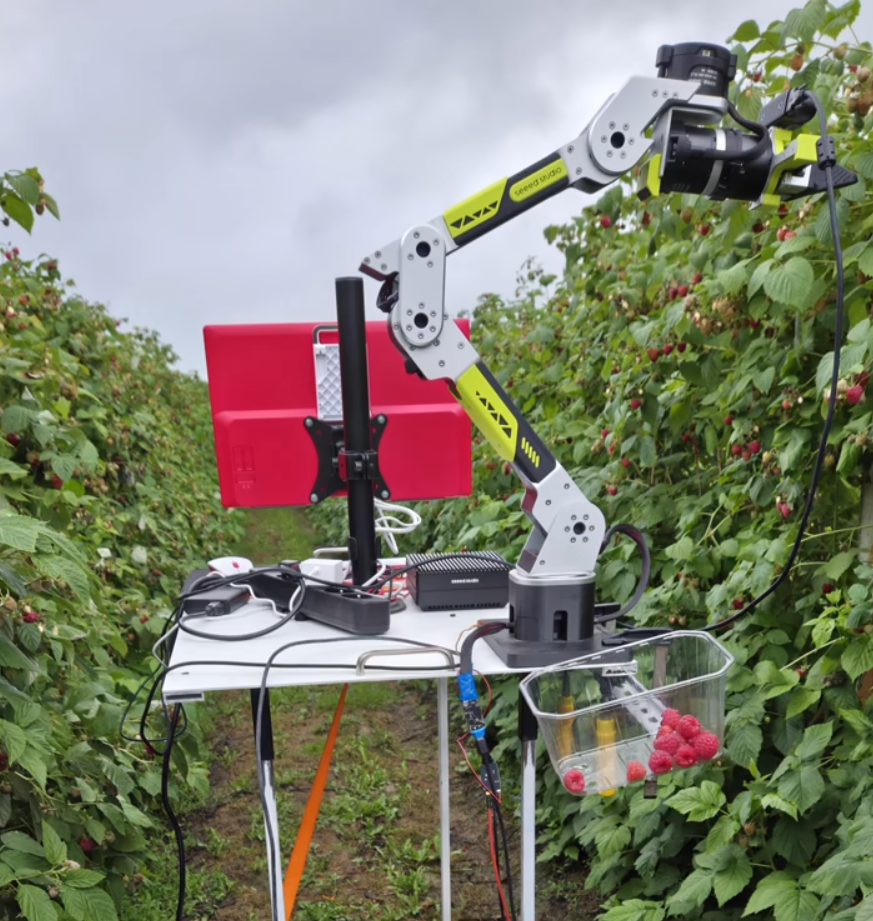

 reBot-DevArm 是一个完全开源的机械臂项目(B601-DM 和 B601-RS 两个型号),旨在降低学习具身智能(Embodied AI)的门槛,所有硬件文件、BOM 和软件都公开发布。