



4.4K ·GitHub
Что это такое?
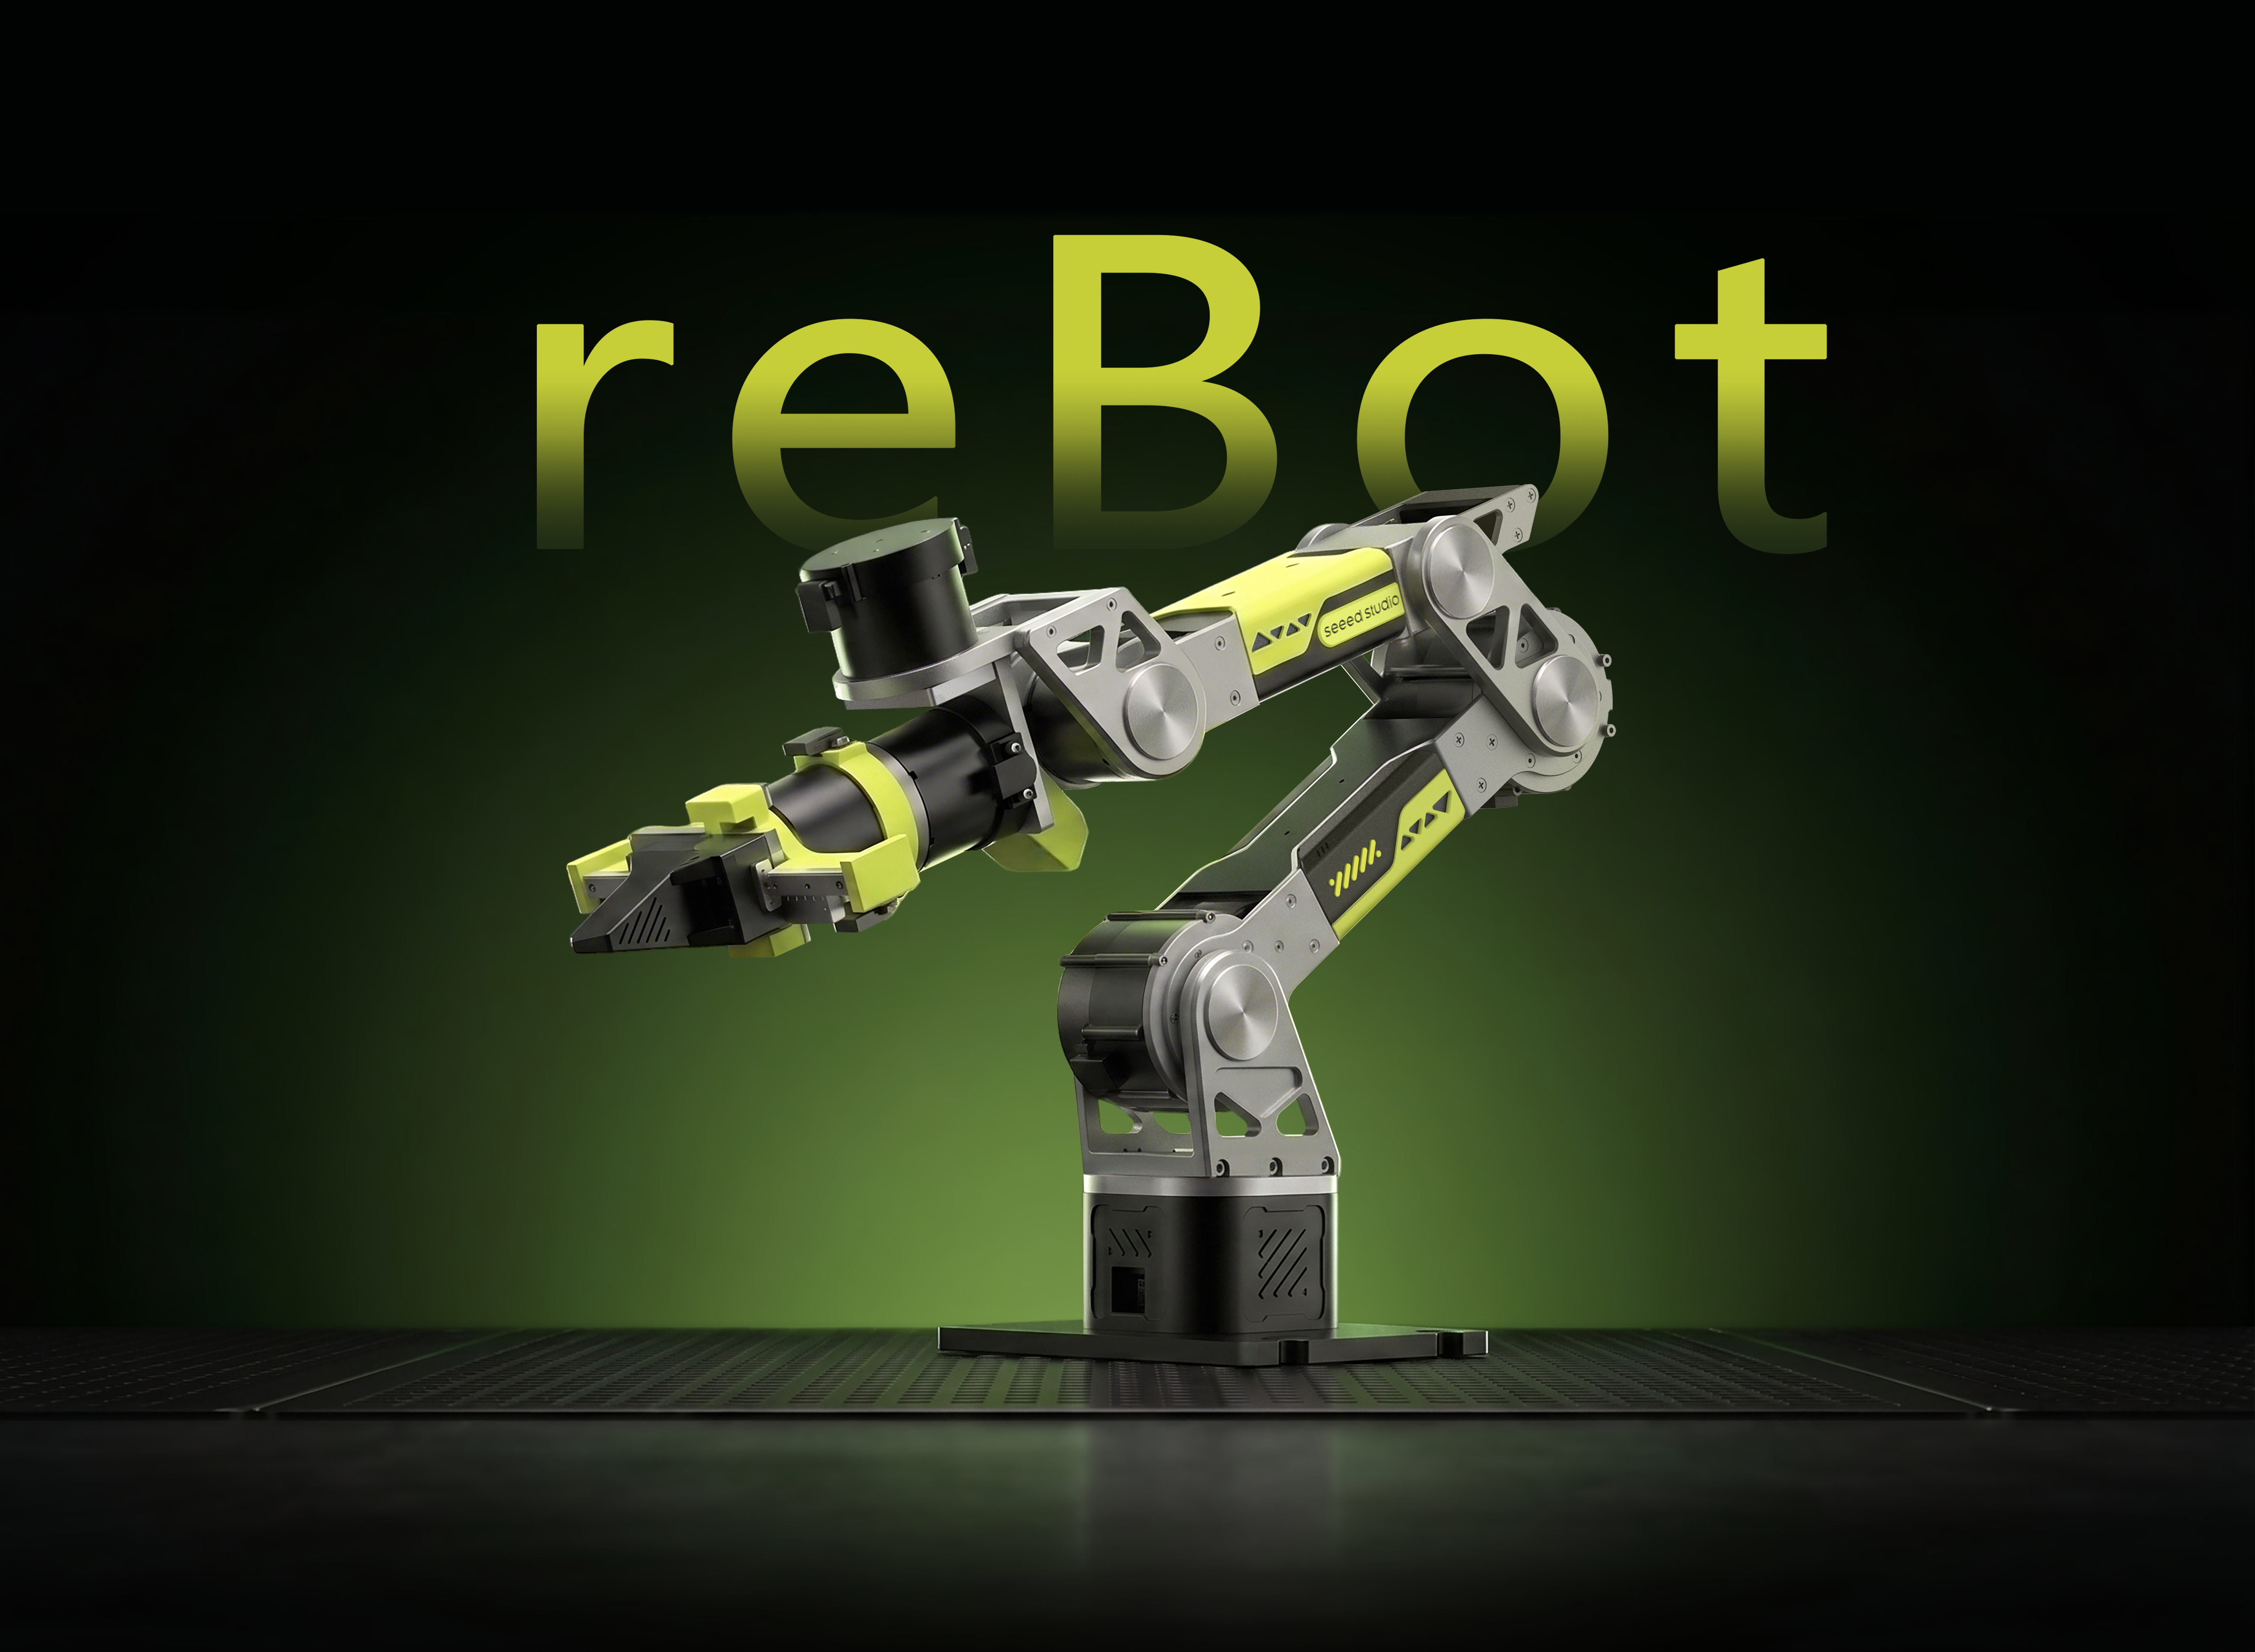
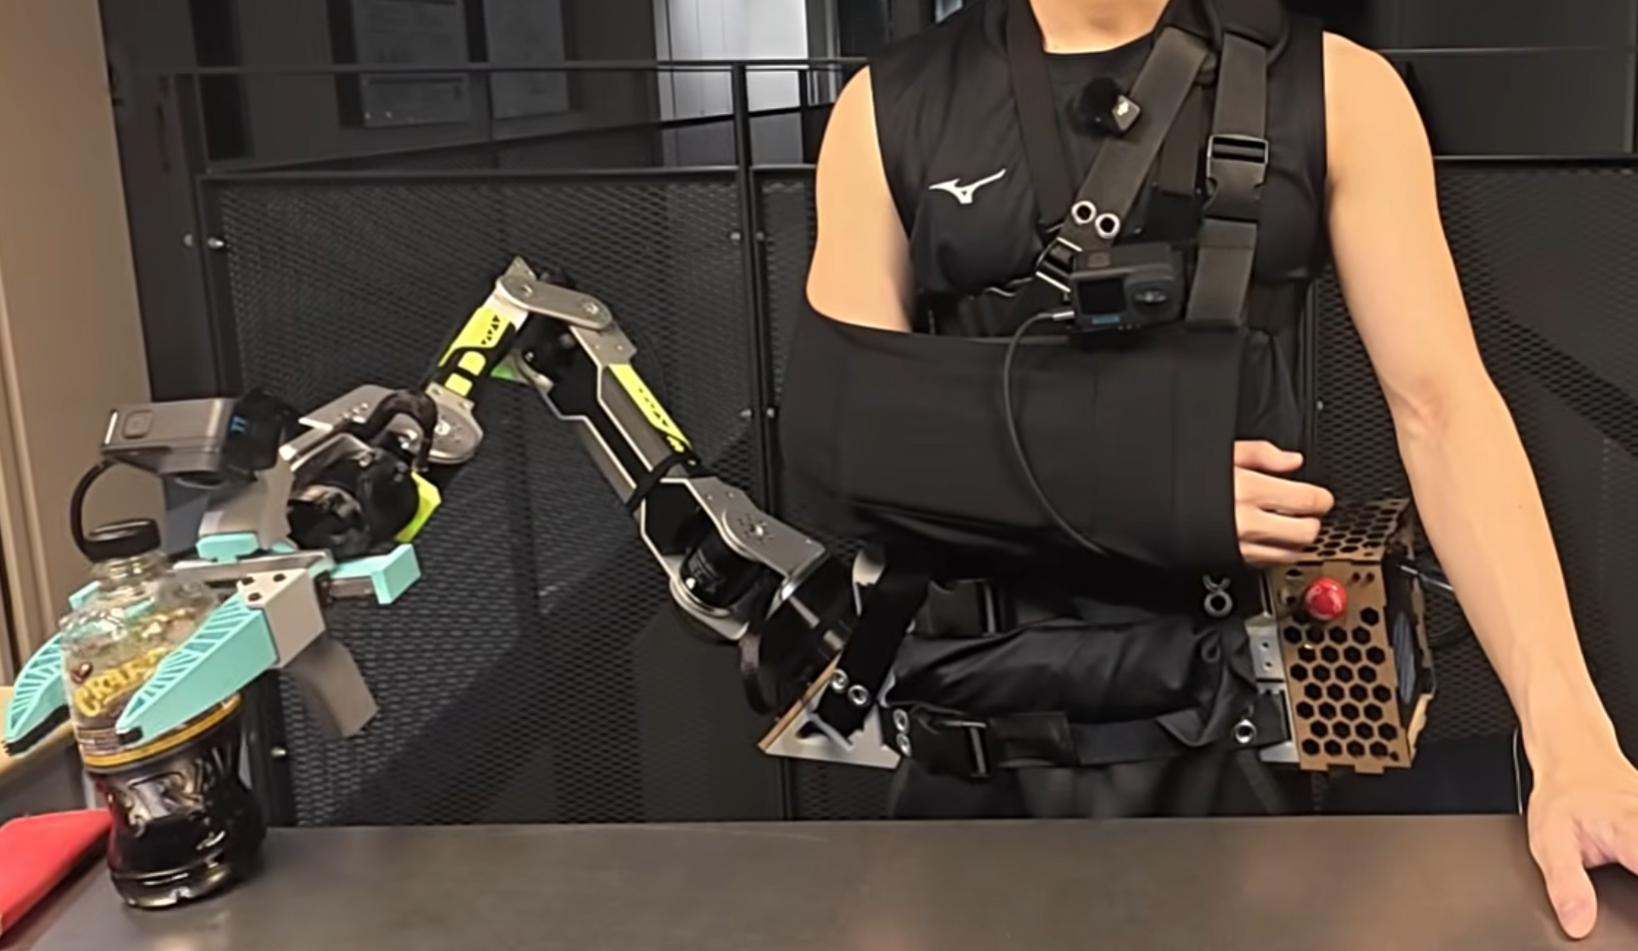
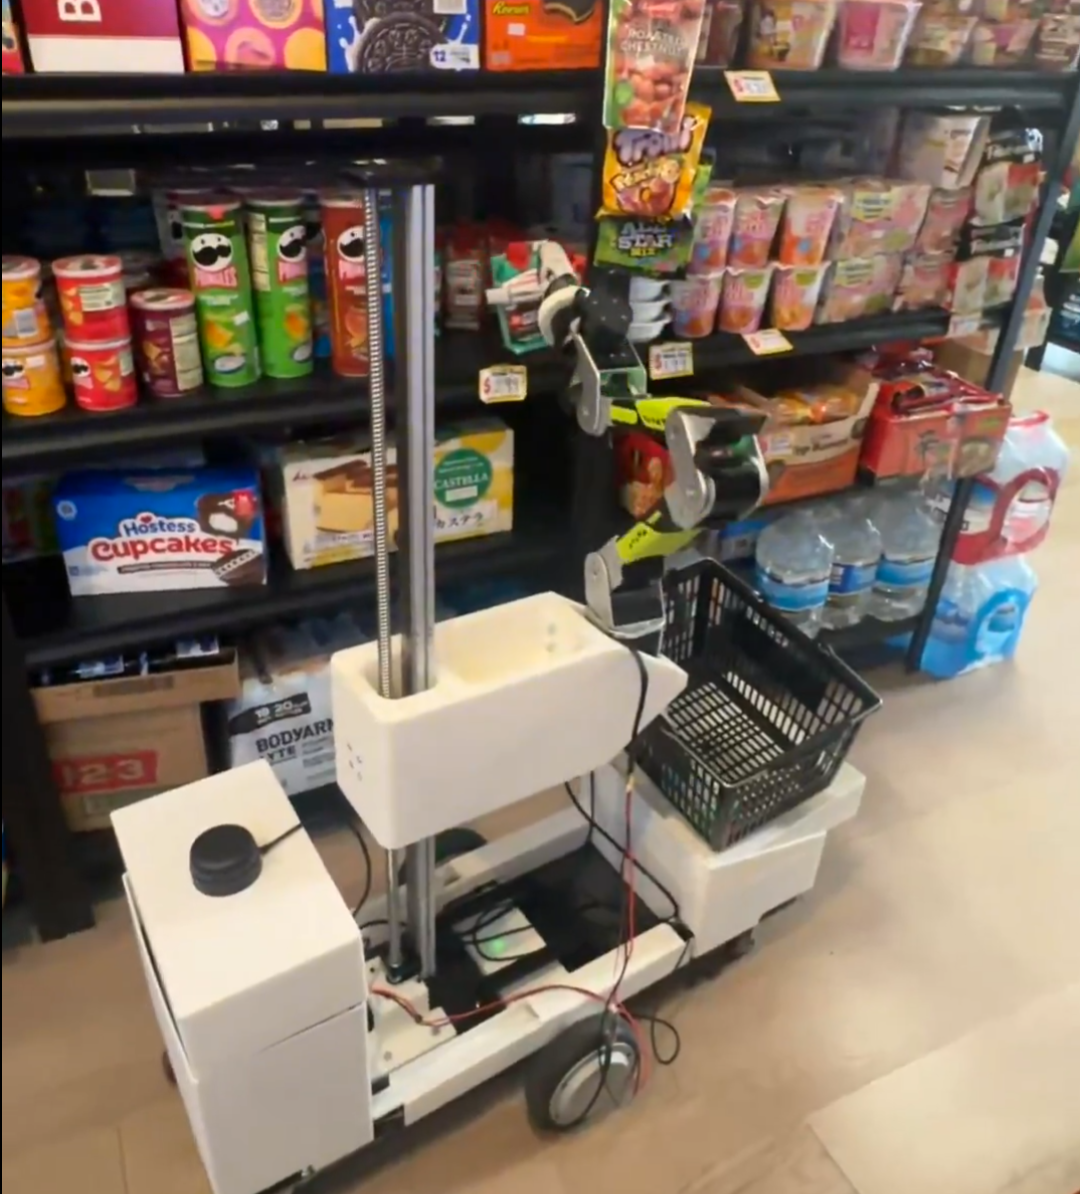
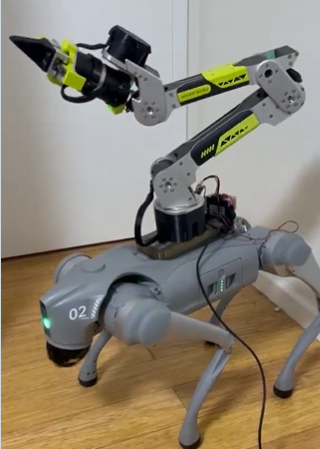
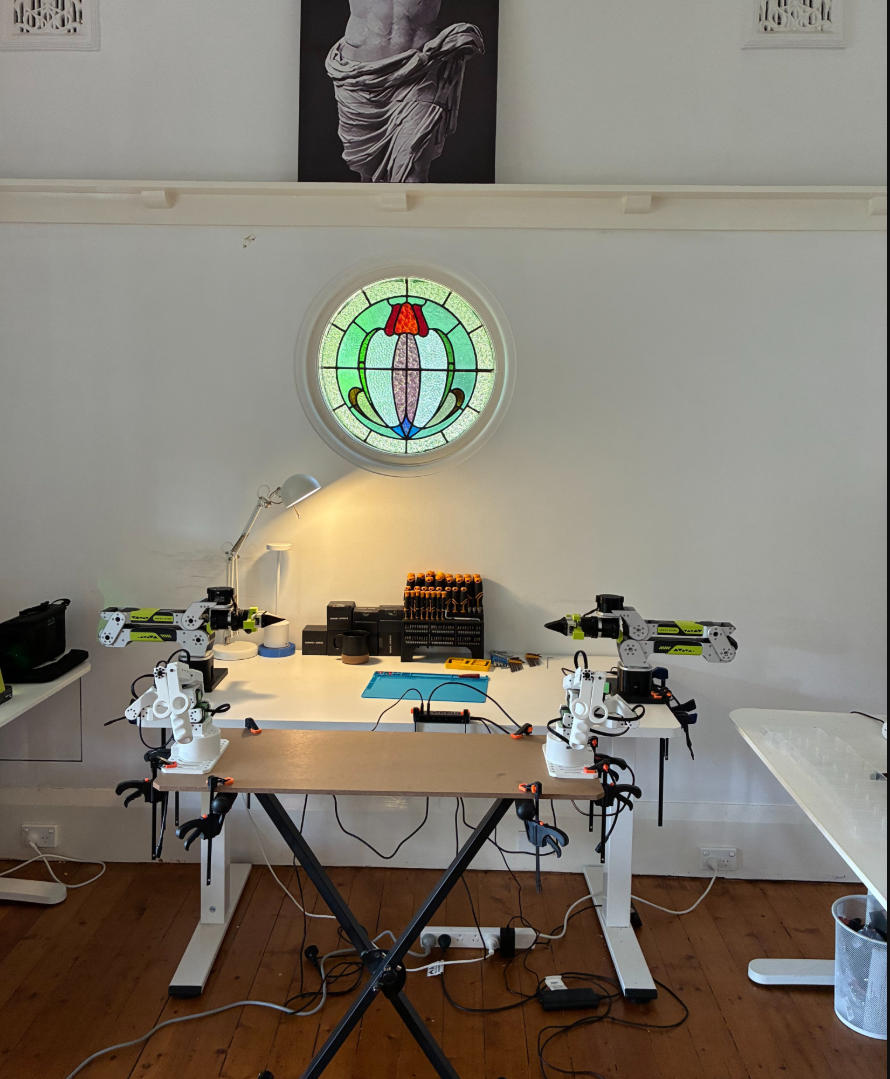
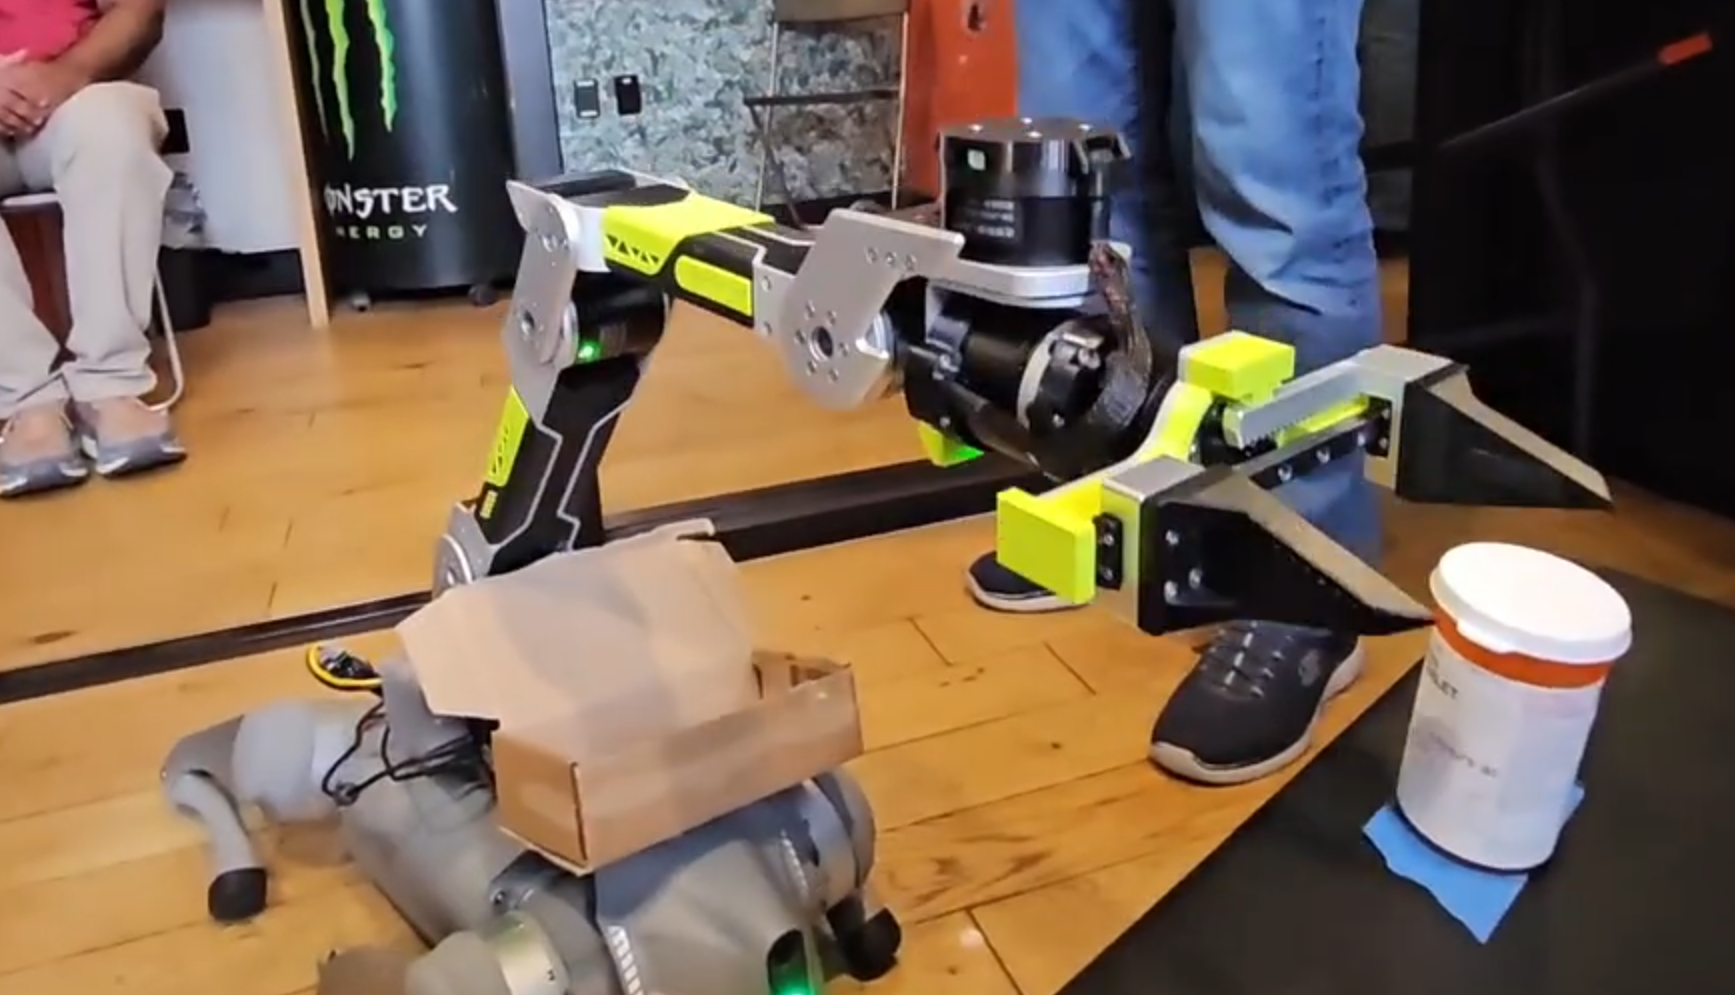
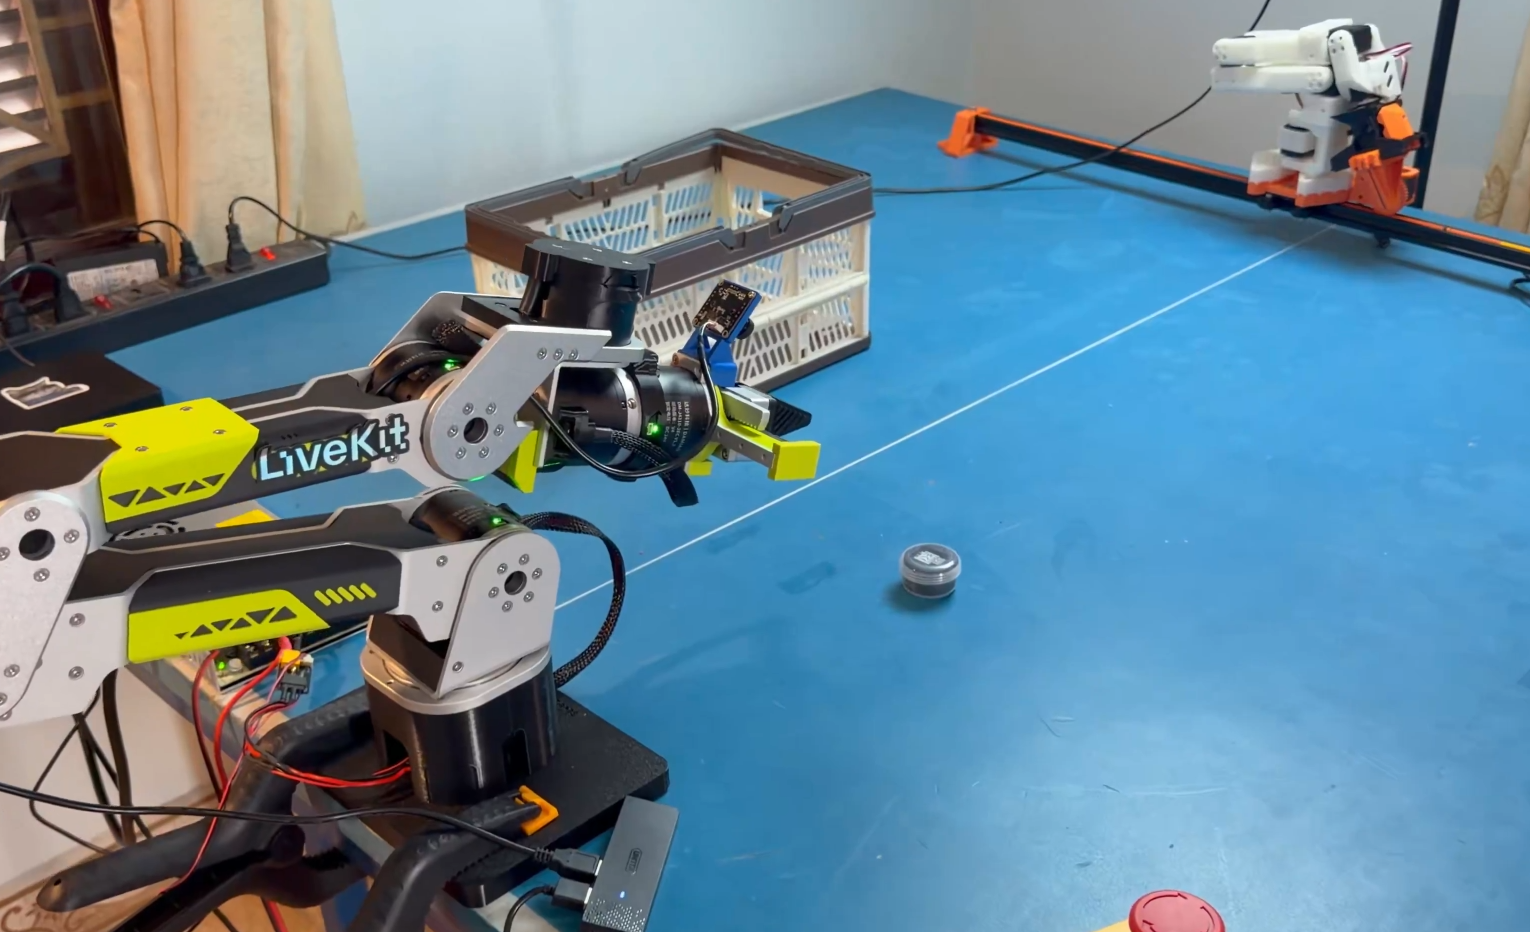
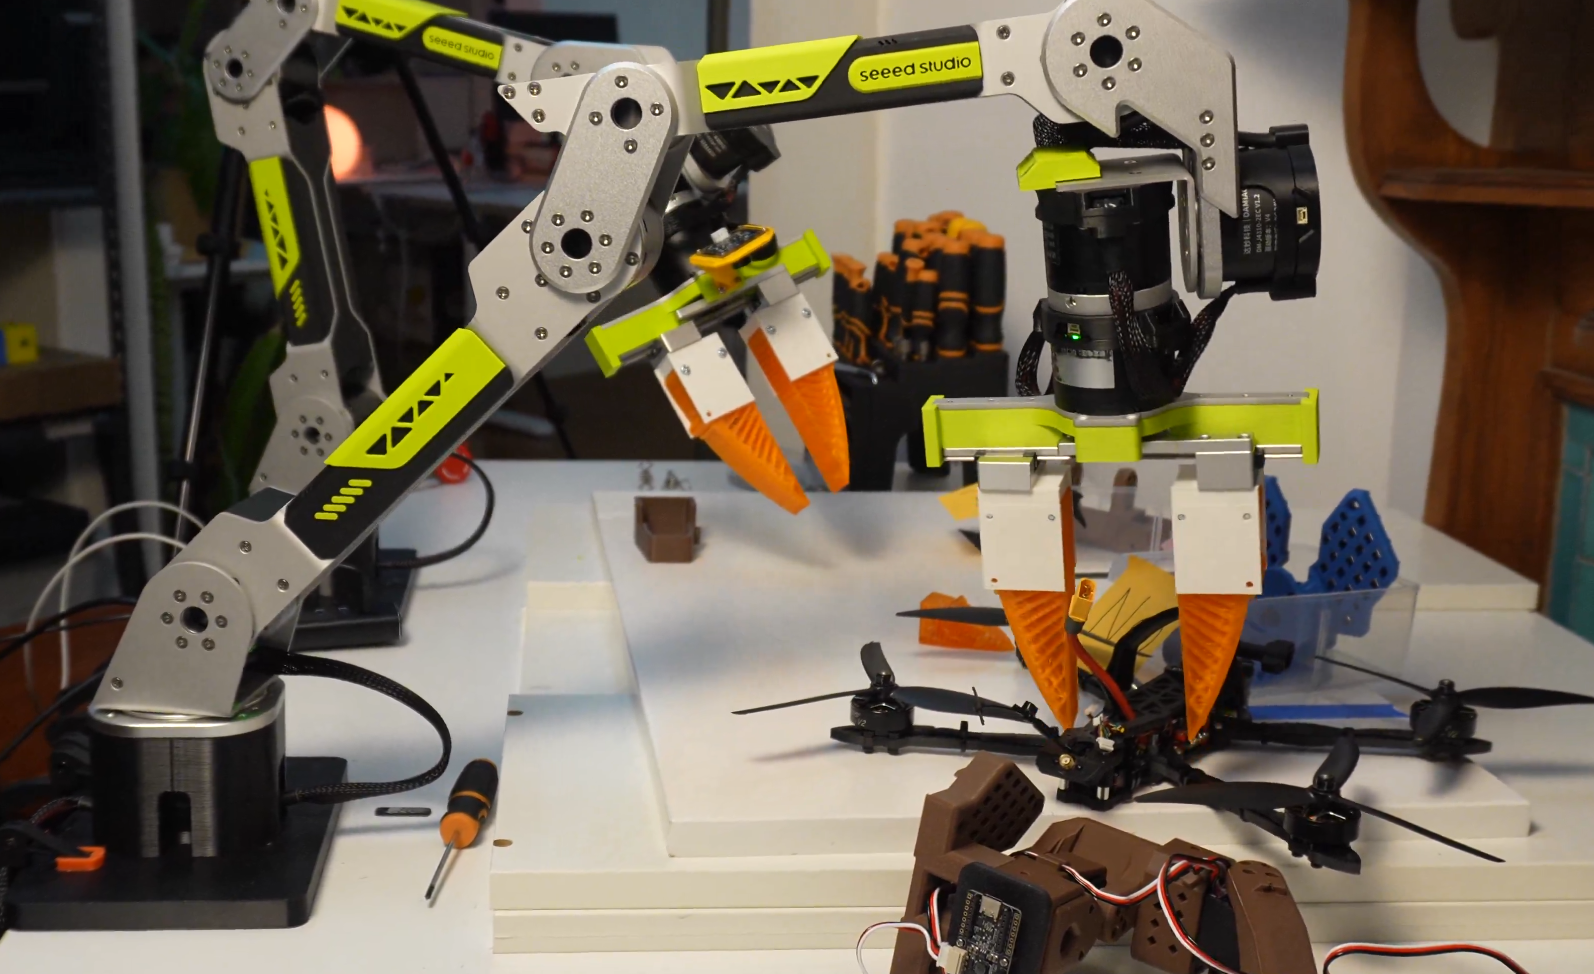
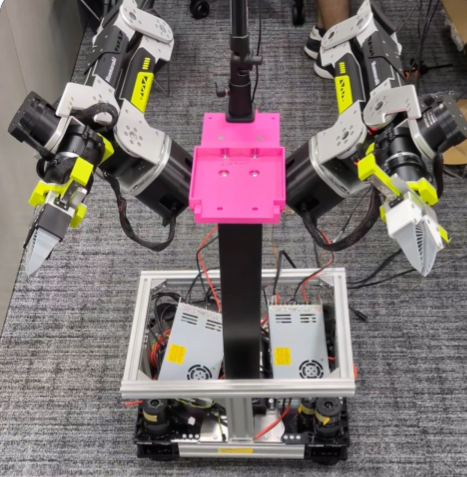
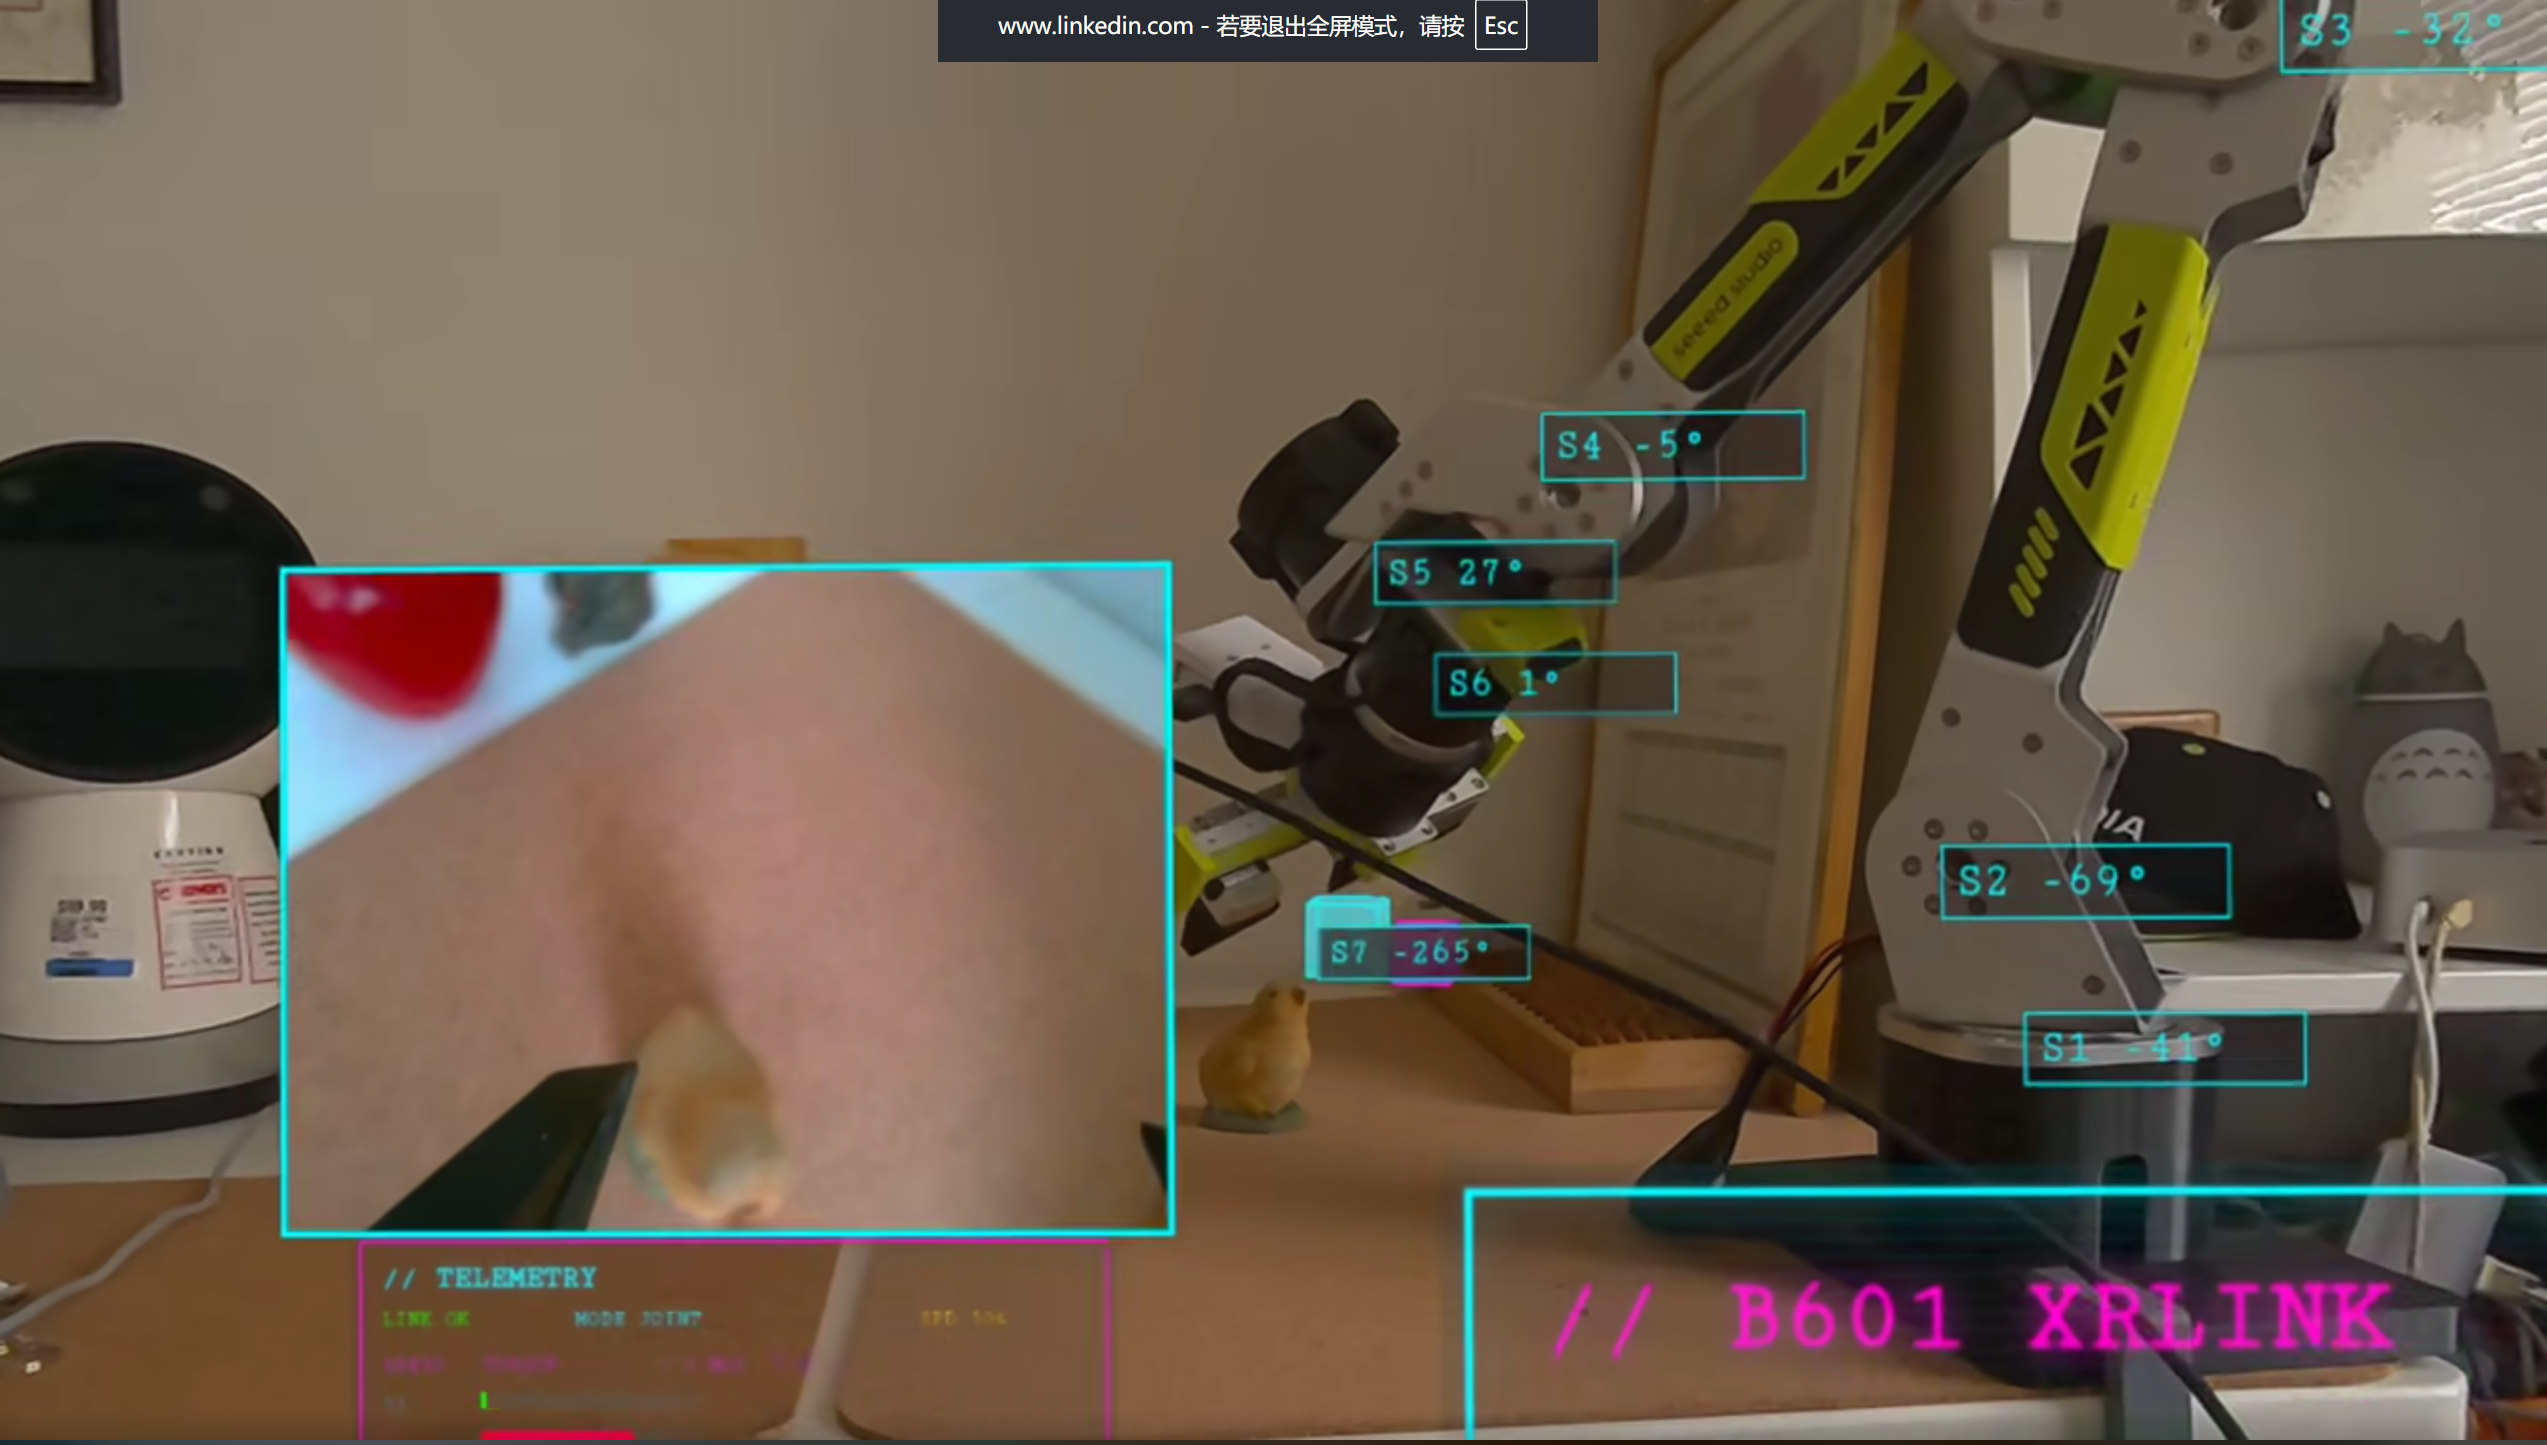
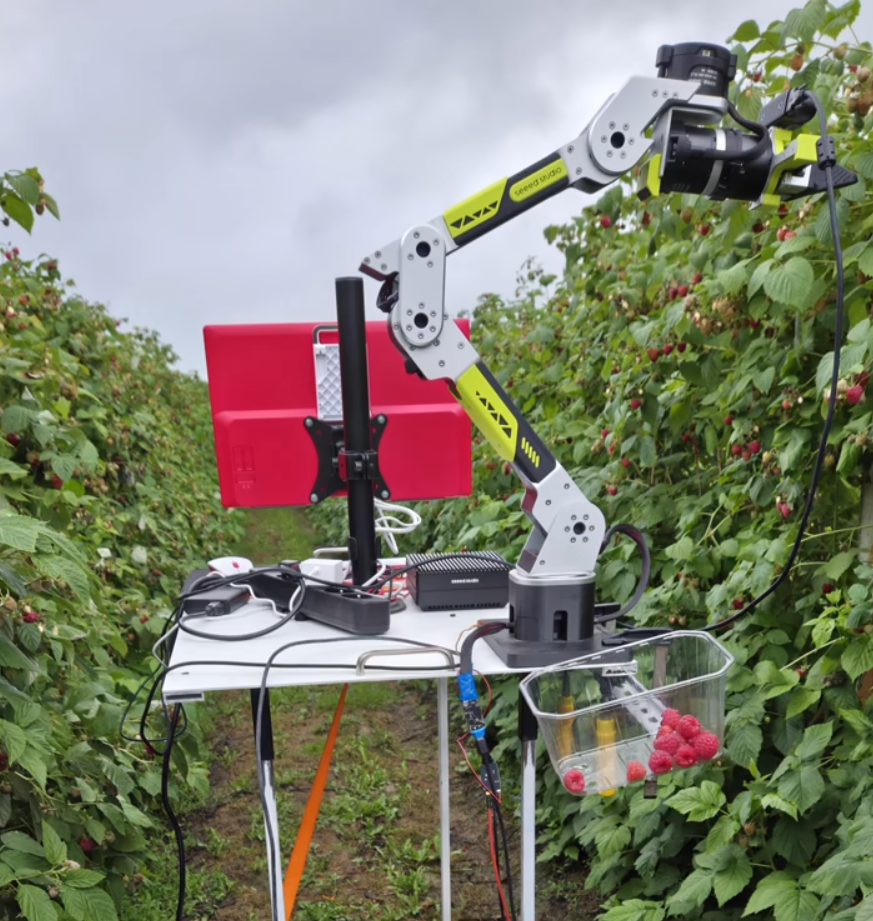
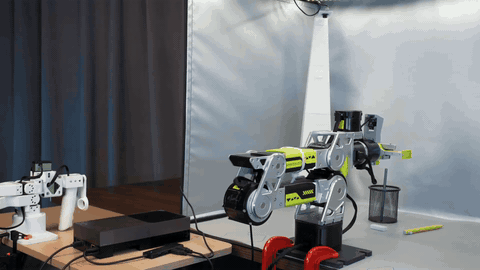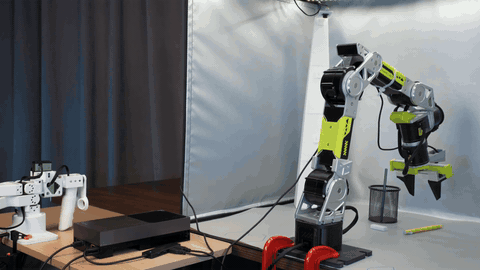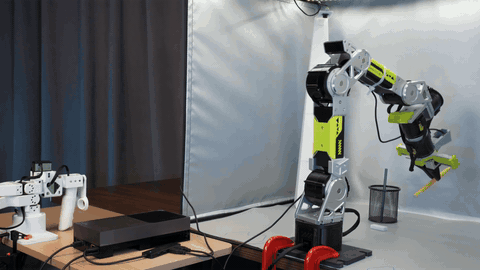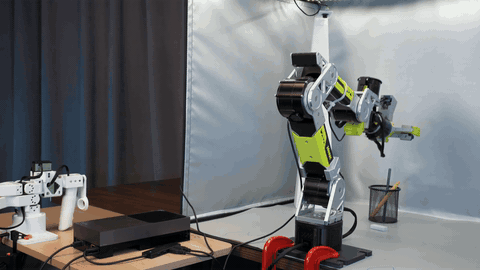
 reBot-DevArm — полностью опенсорсный проект робота-манипулятора (модели B601-DM и B601-RS), нацеленный на снижение порога входа в изучение Embodied AI; все файлы железа, BOM и софт выложены открыто.
Это только софт или железо тоже придётся покупать?Это полный стек железо+софт: нужен физический манипулятор (купите комплект или собранный агрегат на Seeedstudio/Amazon/Aliexpress либо напечатайте на 3D-принтере/выточите детали сами по открытой BOM), плюс Python SDK, ROS-интеграция и инструменты симуляции из репозитория.
Это полный стек железо+софт: нужен физический манипулятор (купите комплект или собранный агрегат на Seeedstudio/Amazon/Aliexpress либо напечатайте на 3D-принтере/выточите детали сами по открытой BOM), плюс Python SDK, ROS-интеграция и инструменты симуляции из репозитория.С чего начать с манипулятором?Купите или соберите один из пяти вариантов комплекта (motor kit, structural kit, gripper kit, full kit или собранный манипулятор) на Seeedstudio, затем следуйте руководству Getting Started для своей модели по сборке, базовому управлению моторами и программной интеграции (Python SDK, ROS2, LeRobot и др.). Можно также попробовать онлайн-симуляцию MuJoCo в браузере, вообще без железа.
Купите или соберите один из пяти вариантов комплекта (motor kit, structural kit, gripper kit, full kit или собранный манипулятор) на Seeedstudio, затем следуйте руководству Getting Started для своей модели по сборке, базовому управлению моторами и программной интеграции (Python SDK, ROS2, LeRobot и др.). Можно также попробовать онлайн-симуляцию MuJoCo в браузере, вообще без железа.Какое железо реально нужно докупить для питания?Нужен сам комплект манипулятора плюс отдельный блок питания (по умолчанию в комплект не входит): 12V 10A для версии DM/Leader или рекомендуемый Meanwell 48V 12.5A (или 48V 25A для полной производительности) для модели RS.
Нужен сам комплект манипулятора плюс отдельный блок питания (по умолчанию в комплект не входит): 12V 10A для версии DM/Leader или рекомендуемый Meanwell 48V 12.5A (или 48V 25A для полной производительности) для модели RS.Всё ли из дорожной карты уже готово?Большинство ключевых функций (базовое управление моторами, ROS2, Pinocchio, LeRobot, захват с камерой глубины, голосовое управление) отмечены как готовые, но пункты вроде симуляции Isaac Sim для модели DM ещё в работе, а обещанные бесплатные курсы и постоянные обновления алгоритмов пока не вышли.
Большинство ключевых функций (базовое управление моторами, ROS2, Pinocchio, LeRobot, захват с камерой глубины, голосовое управление) отмечены как готовые, но пункты вроде симуляции Isaac Sim для модели DM ещё в работе, а обещанные бесплатные курсы и постоянные обновления алгоритмов пока не вышли.На кого это рассчитано?На разработчиков, робототехников и учащихся, которые хотят изучать или внедрять Embodied AI на реальном полностью открытом настольном манипуляторе, а не на закрытой коммерческой платформе.
На разработчиков, робототехников и учащихся, которые хотят изучать или внедрять Embodied AI на реальном полностью открытом настольном манипуляторе, а не на закрытой коммерческой платформе.Он работает на каких-то конкретных ОС или робототехнических фреймворках?Программный стек нацелен на робототехнические среды на базе Linux через ROS1/ROS2, Isaac Sim, Pinocchio и LeRobot от Hugging Face, с Python SDK для управления моторами; онлайн-симулятор работает в Chrome или Edge в любом браузере.
Программный стек нацелен на робототехнические среды на базе Linux через ROS1/ROS2, Isaac Sim, Pinocchio и LeRobot от Hugging Face, с Python SDK для управления моторами; онлайн-симулятор работает в Chrome или Edge в любом браузере.В чём разница между версиями манипулятора DM и RS?Внешне они одинаковы, но используют разные марки моторов (Damiao против Robstride); у модели DM грузоподъёмность 1.5 кг и вылет 767 мм, а у модели RS более сильные 2.5 кг, вылет 754 мм и поддержка embodied-агента, выполняющего команды захвата на естественном языке.
Внешне они одинаковы, но используют разные марки моторов (Damiao против Robstride); у модели DM грузоподъёмность 1.5 кг и вылет 767 мм, а у модели RS более сильные 2.5 кг, вылет 754 мм и поддержка embodied-агента, выполняющего команды захвата на естественном языке.Манипулятор понимает голос или команды на естественном языке?Да, он интегрирует четырёхмикрофонную решётку reSpeaker Flex для управления голосом, а B601-RS имеет Embodied Agent Architecture, принимающую команды на естественном языке вроде 'pick up the red block' и автоматически планирующую захват.
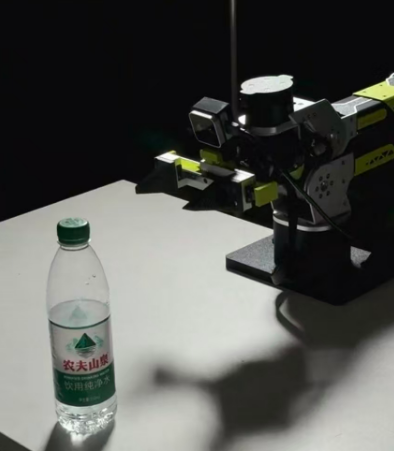
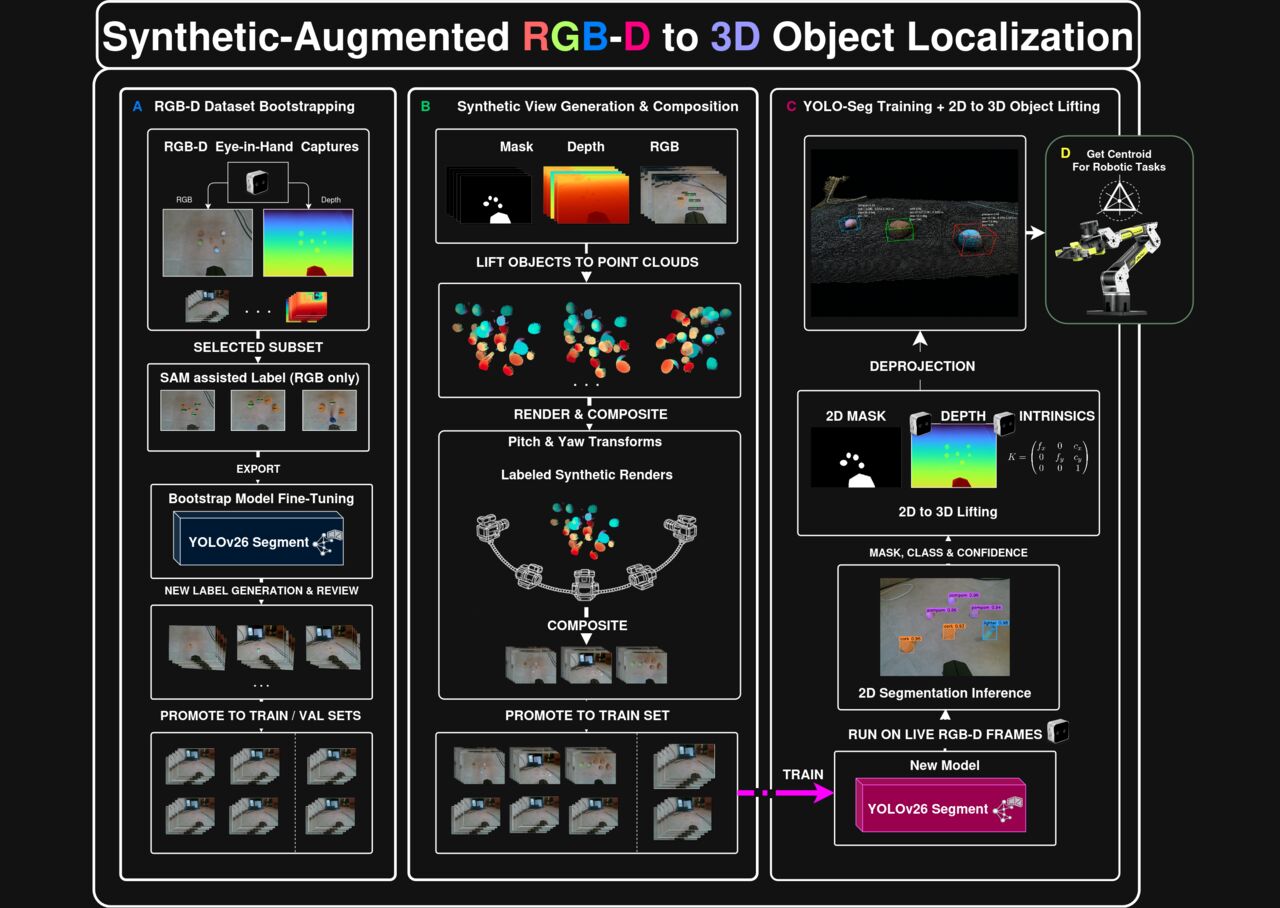
Да, он интегрирует четырёхмикрофонную решётку reSpeaker Flex для управления голосом, а B601-RS имеет Embodied Agent Architecture, принимающую команды на естественном языке вроде 'pick up the red block' и автоматически планирующую захват.Поддерживается ли визуальный захват?Да, есть демо визуального захвата, сочетающее детекцию объектов YOLO с камерами глубины (D435i, D405, Gemini) для pick-and-place на основе восприятия.
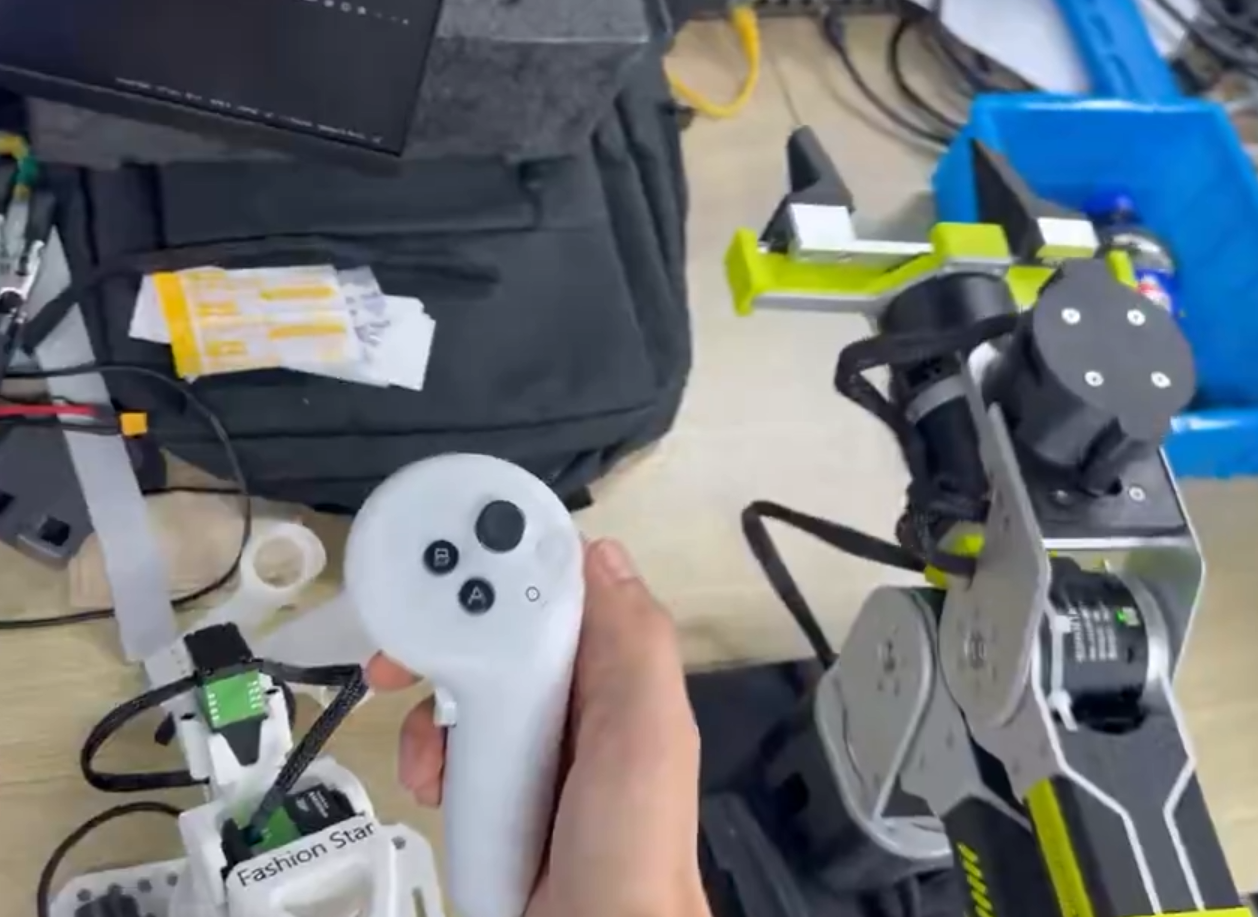
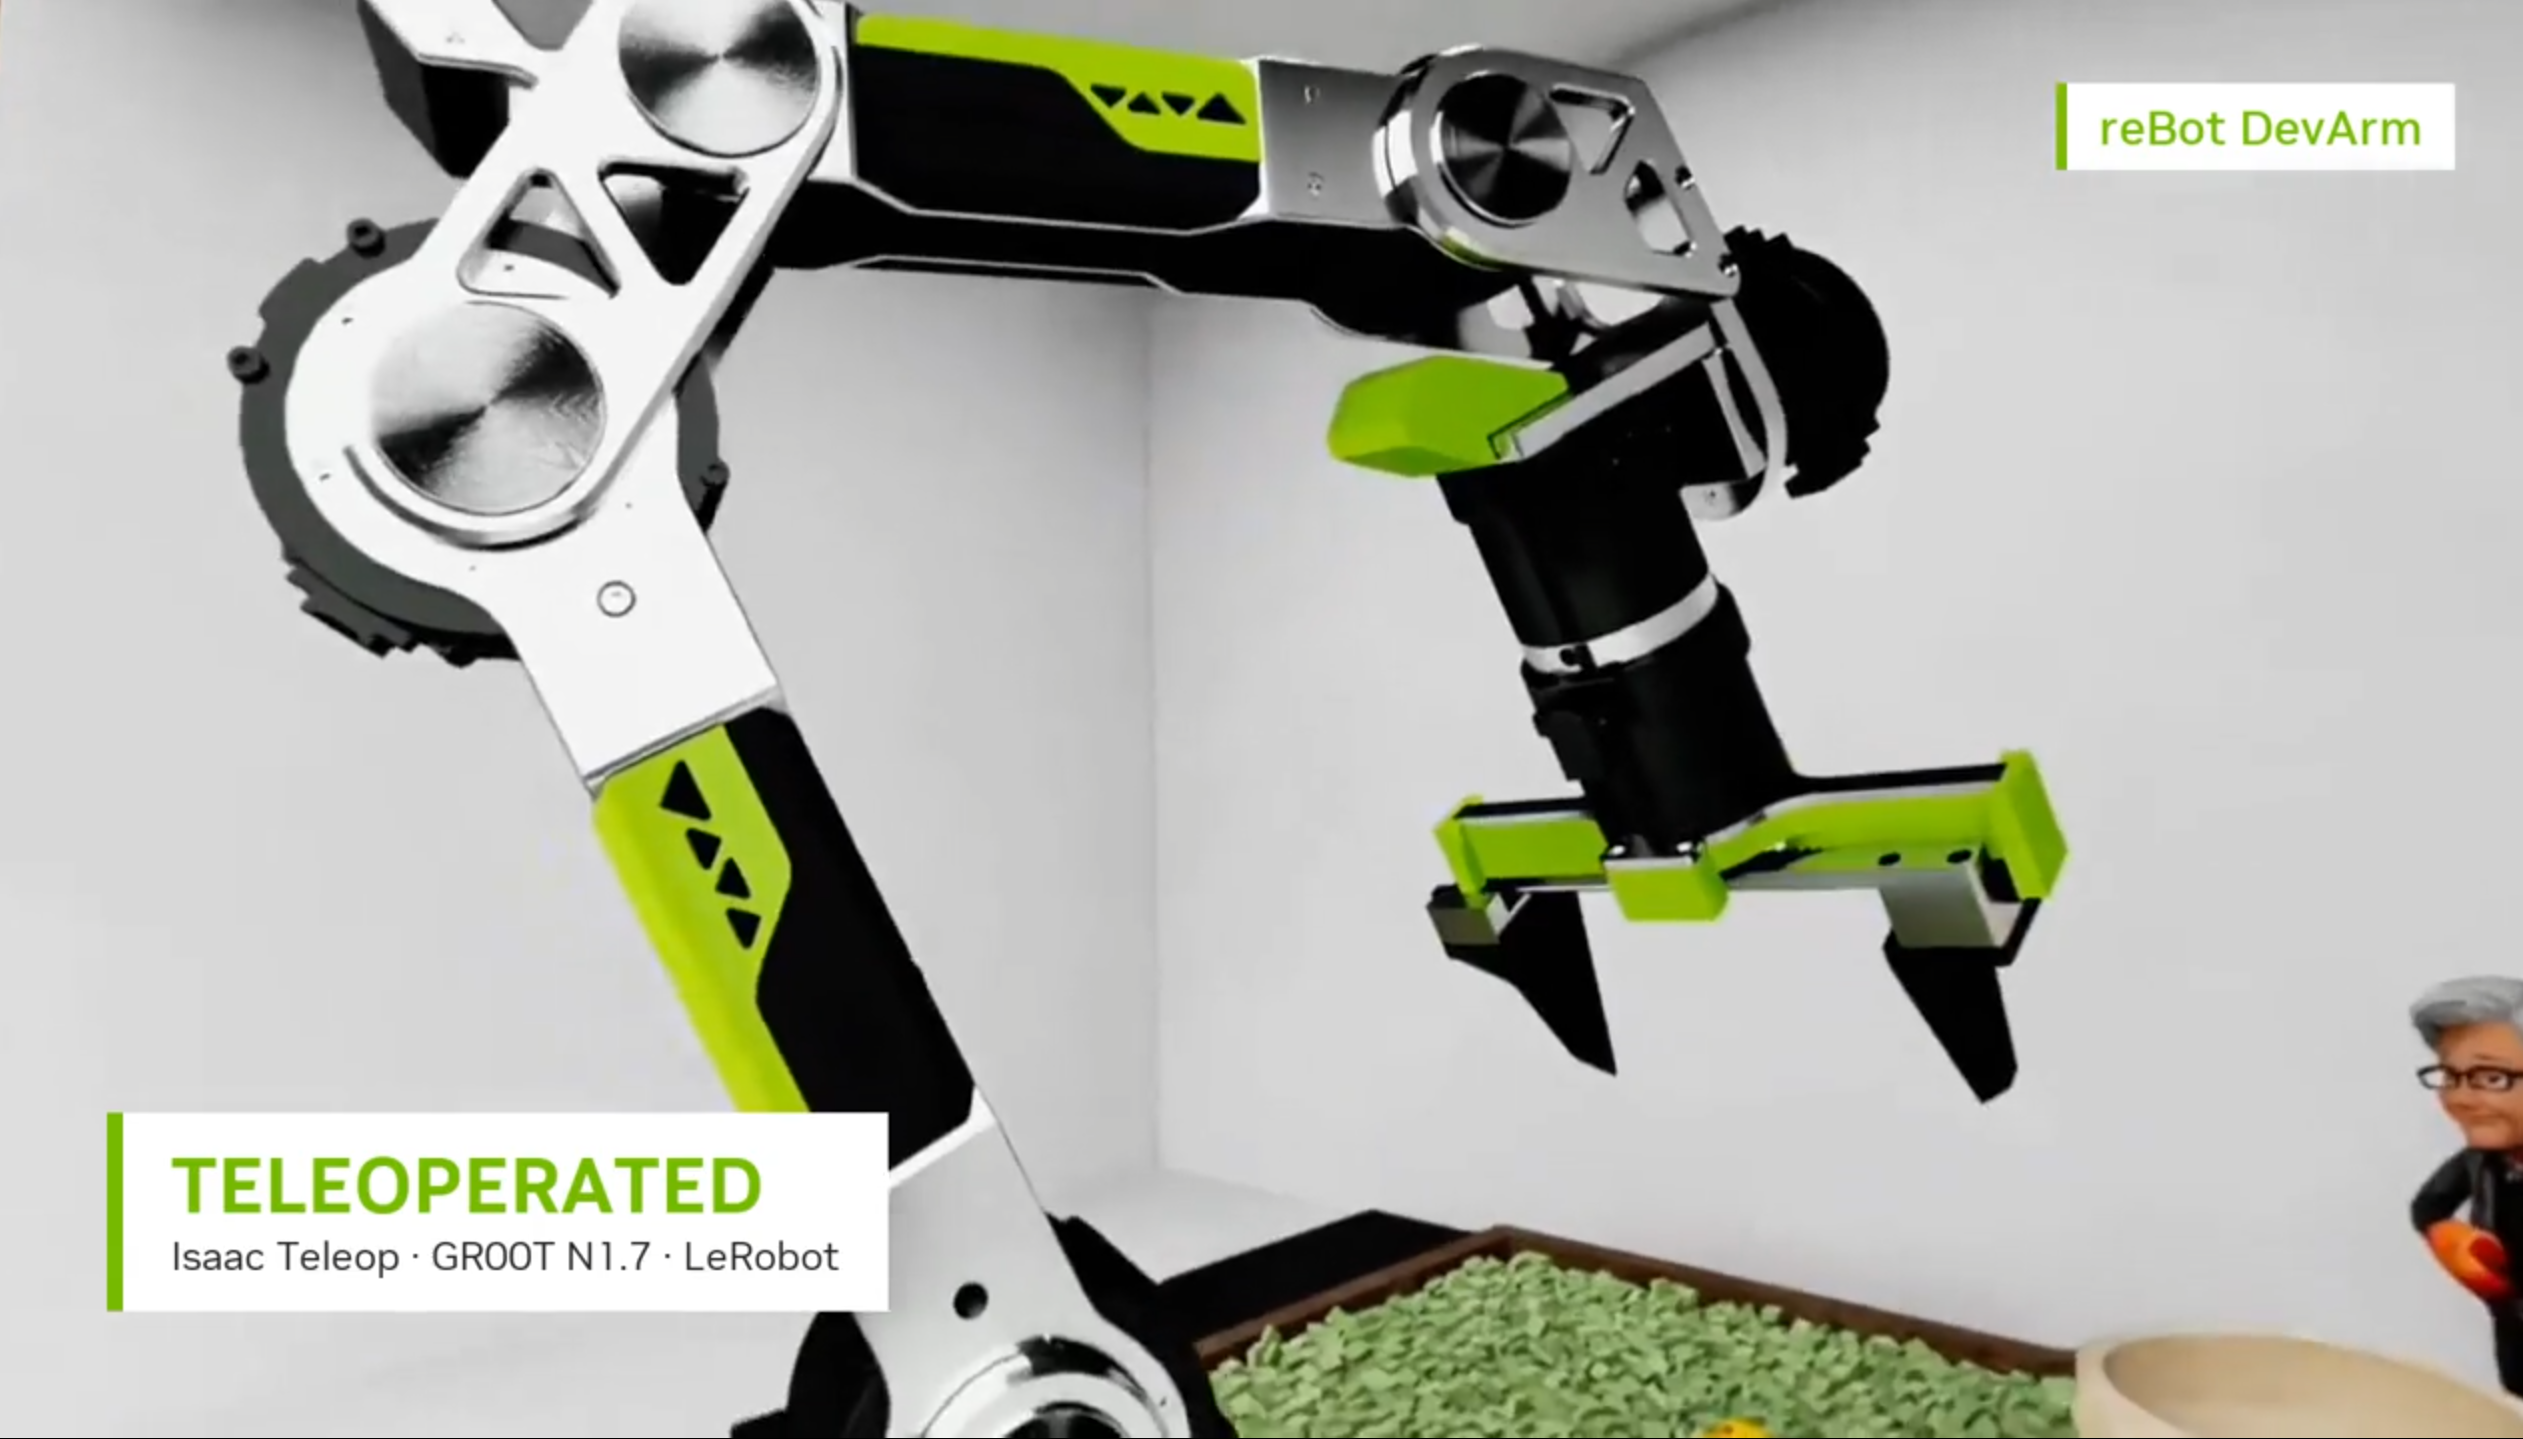
Да, есть демо визуального захвата, сочетающее детекцию объектов YOLO с камерами глубины (D435i, D405, Gemini) для pick-and-place на основе восприятия.Можно ли управлять связкой лидер/фолловер для телеоперации?Да, манипулятор совместим с Leader Arm (Star Arm 102-LD) для телеоперации и поддерживает телеоперацию IK/FK с геймпадом благодаря вкладам сообщества в ROS2.
Да, манипулятор совместим с Leader Arm (Star Arm 102-LD) для телеоперации и поддерживает телеоперацию IK/FK с геймпадом благодаря вкладам сообщества в ROS2.What are similar projects?FluxVLA, intrinsic-core, LightNav-0, carla, Embodied-AI-Guide, jumper, ZDTaichu5.0-9B, RoboHarness
FluxVLA, intrinsic-core, LightNav-0, carla, Embodied-AI-Guide, jumper, ZDTaichu5.0-9B, RoboHarnessWhich topics is it in?ros, yolo, 3d-printing, embodied-ai, voice, object-detection, robotics, simulation, iot, hardware, gaming, huggingface
ros, yolo, 3d-printing, embodied-ai, voice, object-detection, robotics, simulation, iot, hardware, gaming, huggingface