Topics / #slam
Slam projects on GitHub
Simultaneous localization and mapping for robots and spatial sensing.
As of , the most-starred Slam projects on GitHub are PythonRobotics (30.7K stars), oomwoo (12.1K stars) and ORB_SLAM2 (10.3K stars). GitHub.Locker tracks 5 Slam repositories with 54.8K stars combined. The fastest-growing on October 18 was oomwoo, with +67 stars in a day.
Hot right now
Most stars gained in a day · Oct 18
 +67
oomwoo
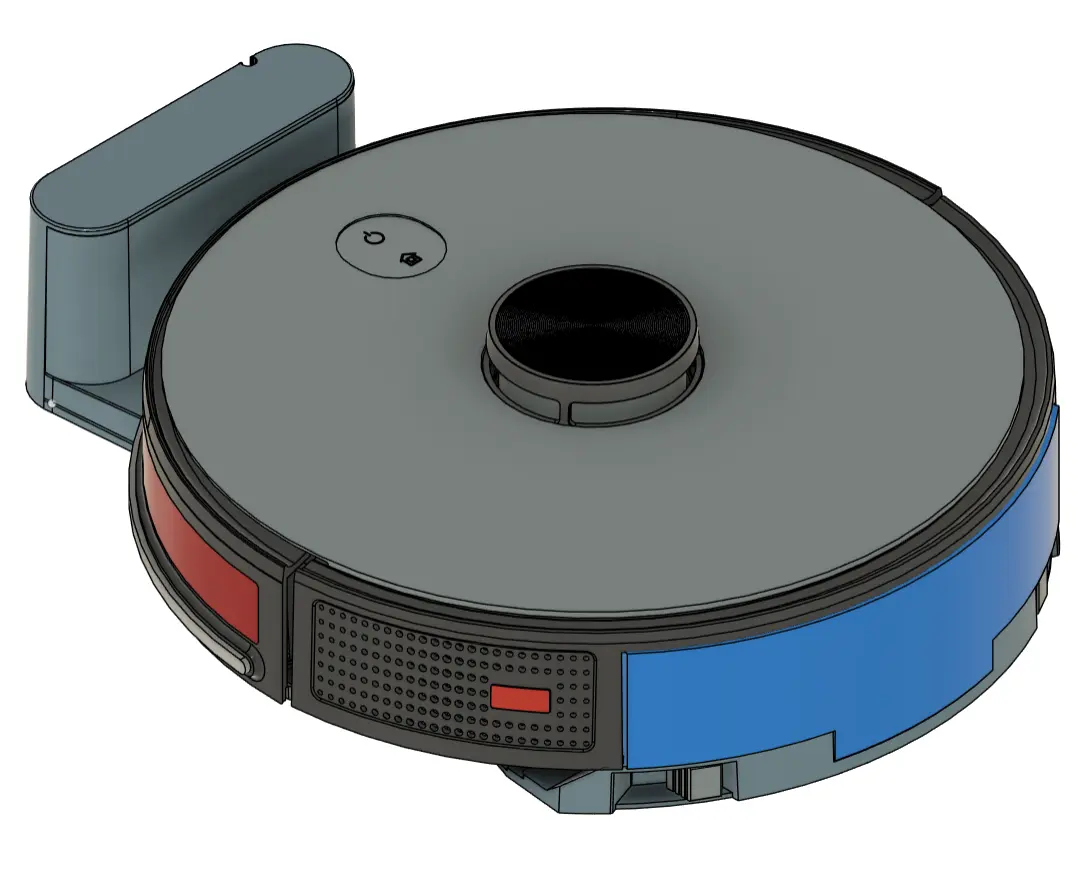
makerspet/oomwoo · ★ 12.1KOOMWOO is an open-source home vacuum robot you build yourself, using a Raspberry Pi, 3D-printed parts, Home Assistant, Arduino and ROS2, navigating with an affordable 2D LiDAR.
 +20
PythonRobotics
AtsushiSakai/PythonRobotics · ★ 30.7KPythonRobotics is a Python code collection and textbook of classic robotics algorithms, covering localization, mapping, SLAM, path planning, path tracking, arm navigation, aerial navigation, and bipedal control.
 +2
ABot-Recon
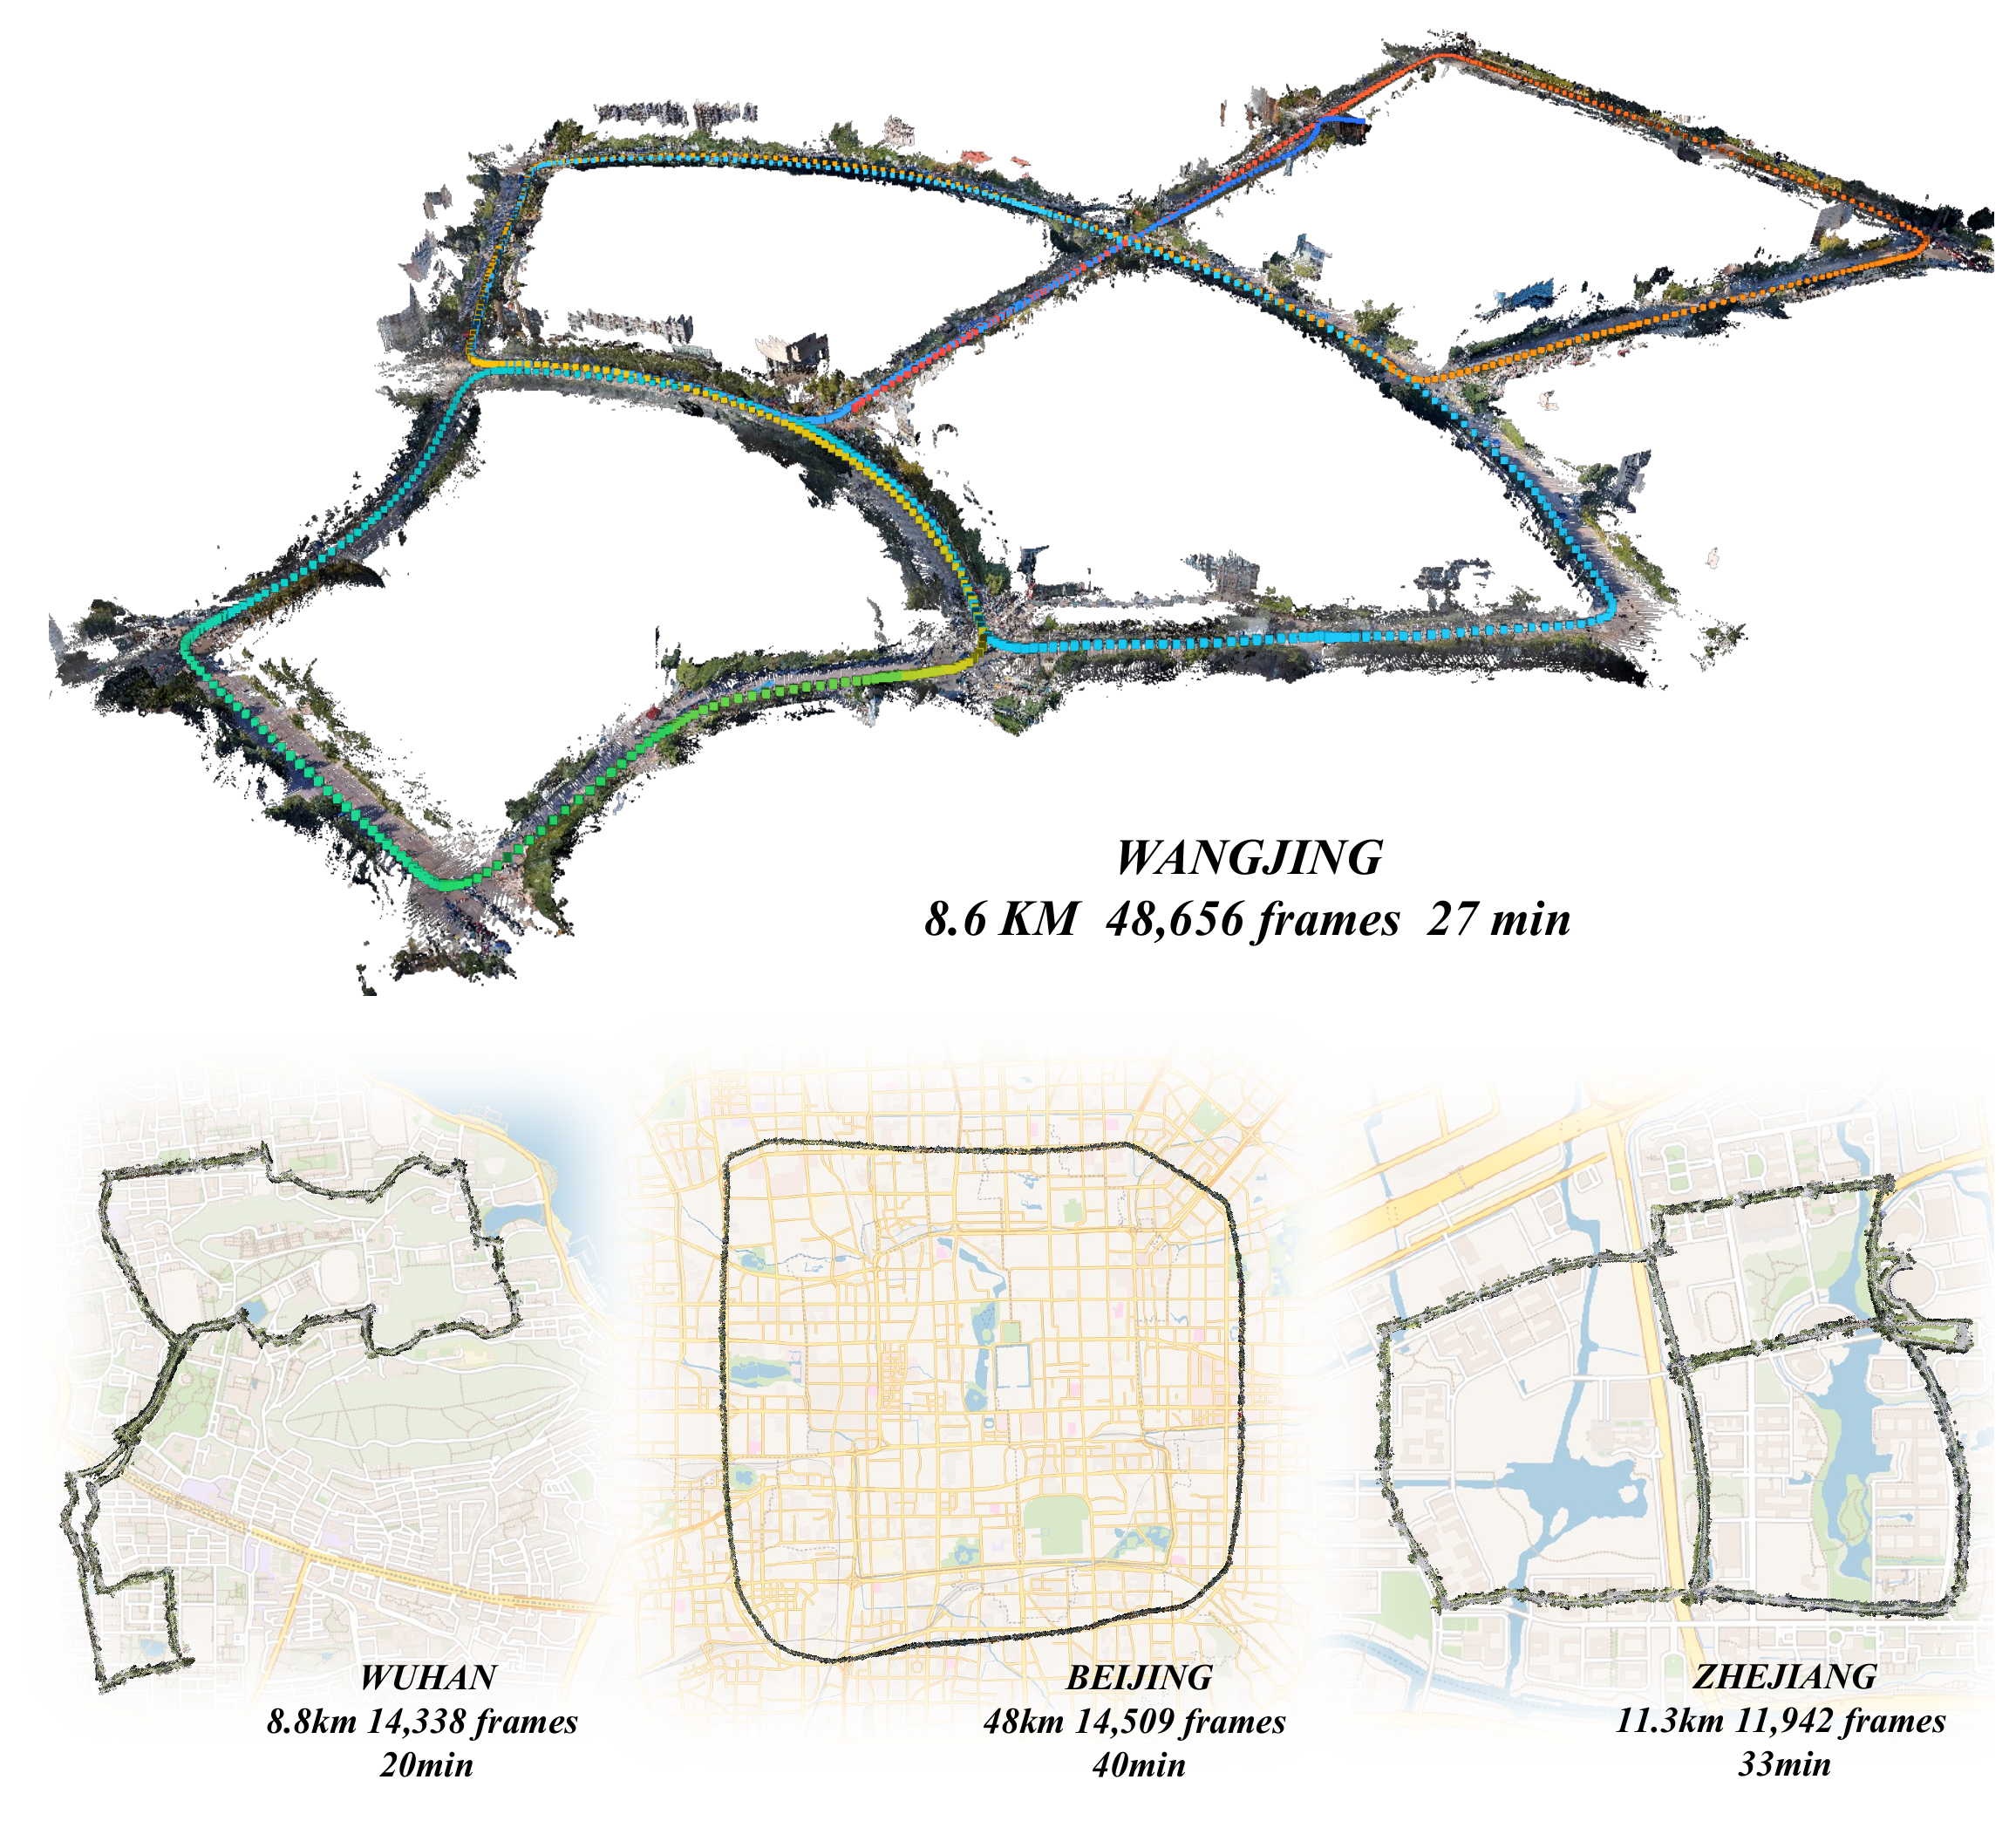
amap-cvlab/ABot-Recon · ★ 1.4KABot-Recon is a streaming 3D reconstruction system: feed it a video stream and it recovers the camera trajectory plus a 3D point cloud, using only a fixed 12-frame local context instead of persistent long-range memory.
 +1
ORB_SLAM2
raulmur/ORB_SLAM2 · ★ 10.3KORB-SLAM2 is a real-time SLAM library for monocular, stereo and RGB-D cameras: it tracks the camera trajectory and builds a sparse 3D reconstruction, with loop detection and relocalization.
The all-time top
5 projects · by stars
- 30.7K#1 · AtsushiSakai/PythonRobotics
PythonRobotics
PythonRobotics is a Python code collection and textbook of classic robotics algorithms, covering localization, mapping, SLAM, path planning, path tracking, arm navigation, aerial navigation, and bipedal control.
- 12.1K#2 · makerspet/oomwoo
oomwoo
OOMWOO is an open-source home vacuum robot you build yourself, using a Raspberry Pi, 3D-printed parts, Home Assistant, Arduino and ROS2, navigating with an affordable 2D LiDAR.
- 10.3K#3 · raulmur/ORB_SLAM2
ORB_SLAM2
ORB-SLAM2 is a real-time SLAM library for monocular, stereo and RGB-D cameras: it tracks the camera trajectory and builds a sparse 3D reconstruction, with loop detection and relocalization.
- 4
ABot-Recon
1.4Kamap-cvlab/ABot-Recon · PythonABot-Recon is a streaming 3D reconstruction system: feed it a video stream and it recovers the camera trajectory plus a 3D point cloud, using only a fixed 12-frame local context instead of persistent long-range memory.
- 5
wuji-ego-mint
258wuji-technology/wuji-ego-mint · PythonMINT is a unified deep learning model that takes ordinary egocentric RGB video and directly predicts world-space camera motion and two-hand (MANO) motion, replacing the usual calibration + depth + SLAM + hand-reconstruction pipeline with a single pass.
Related topics
Often tagged together