Turn a System One decision model into an agent loop. System One Harness observes an environment, compiles its finite action space into typed questions, gates each decision by confidence, executes the chosen action, and records the complete trace.
One model call per step. No generated actions. A probability on every transition.
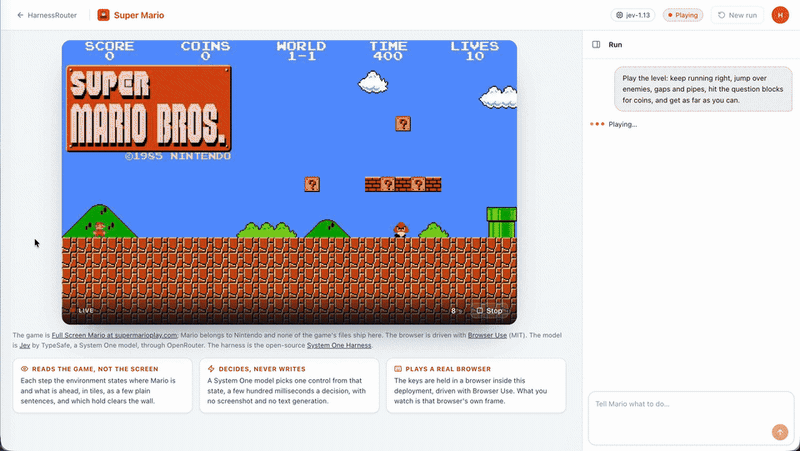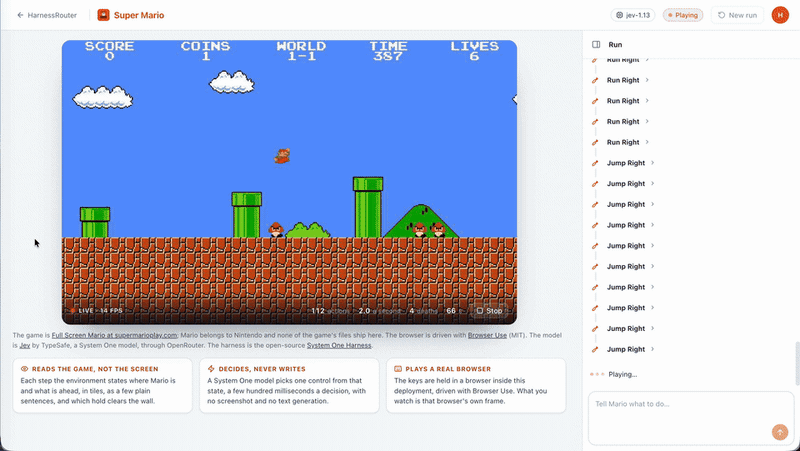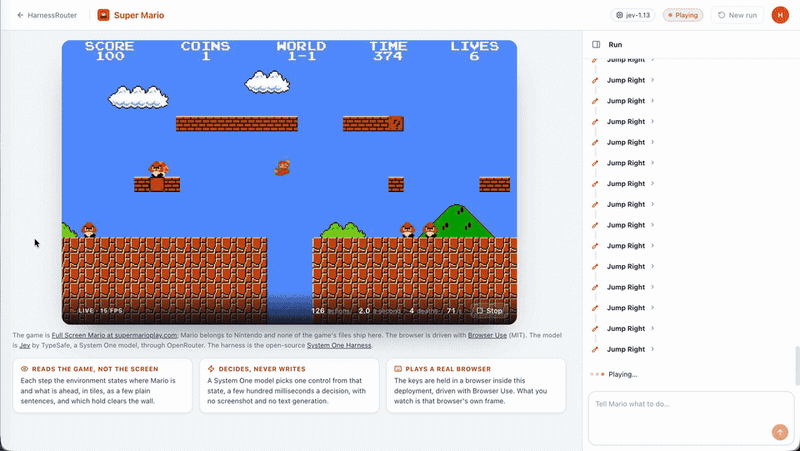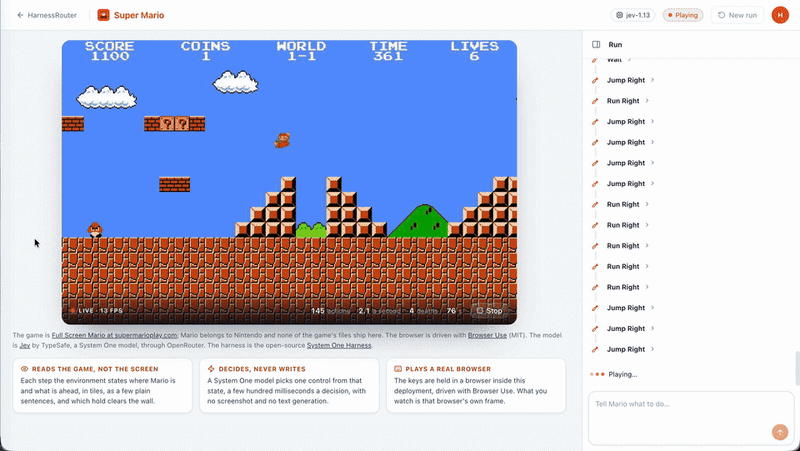
Jev playing a live browser game through System One Harness — one typed decision per step, with no generated control text.
The first supported model is Jev by TypeSafe, available through OpenRouter or TypeSafe directly.
git clone https://github.com/HarnessRouter/SystemOneHarness.git
cd SystemOneHarness
pip install -e .

export OPENROUTER_API_KEY=sk-or-...   # or TYPESAFE_API_KEY=...
s1 run --env order:ship_fastest_gift
This runs the built-in order fulfilment environment against the live model:
goal: Order B-220 is a gift: note it, then ship it by the fastest carrier.
model: ~typesafe/jev-latest
    0  add_note(note='gift')              p=0.96  241 ms
    1  pick_item(item='scarf')            p=1.00  269 ms
    2  pack()                             p=0.99  166 ms
    3  choose_carrier(carrier='express')  p=0.98  151 ms
    4  ship()                             p=0.93  152 ms

status=completed reason=environment_terminal steps=5 wall=0.98s cost=$0.000208
Each step shows the selected action, its weakest required probability, and the model round trip. The final line records how the run ended, how long it took, and what it cost.
What it provides
Finite actions
The model chooses only from actions and parameter values declared by the environment.
Confidence gates
Read, write, and destructive actions can require different probability thresholds.
Explicit outcomes
Every run ends as completed, incomplete, failed, or cancelled with a structured reason.
Complete traces
State, questions, distributions, verdicts, results, latency, and usage are recorded step by step.
Pluggable environments
Drive Python processes, MCP servers, or web pages with the same controller.
UHP compatibility
Serve the loop through the Unified Harness Protocol for streaming, continuation, cancellation, and discovery.
Real-time environments
Games, live feeds, and other moving environments can return "realtime": true. The controller then treats a refused or repeated decision as a clock tick, keeps the model's history short, and lets the last action remain active until it changes.
Choose the smallest boundary that fits your system.
Environment
Use it when
Start with
Action space + process
You own a local program or service loop.
s1 run --actions actions.yaml --env-cmd "python3 env.py" --goal "..."
MCP server
Your tools already expose enumerable inputs over MCP.
s1 run --mcp "python -m your_server" --goal "..."
Browser
The task is expressed through DOM controls in Chrome.
s1 run --browser --headless --start-url https://example.com --goal "..."
Python
You want an in-process integration.
Subclass Environment and implement observe() and execute().
Declare an action space
An action space is YAML or the same structure in Python. Every parameter must be enumerable.
instructions: >-
  Move the order to shipped, or cancel it when the goal says so.

actions:
  choose_carrier:
    description: Select a carrier for the packed order.
    risk: write
    params:
      carrier:
        from: available_carriers
  ship:
    description: Hand the packed order to the selected carrier.
    risk: destructive

gate:
  read: 0.5
  write: 0.6
  destructive: 0.8
  finish: 0.5
Parameters can use fixed choices, observation candidates, a boolean flag, or ordered levels. Free text is rejected because a System One model does not generate text.
The harness lists an MCP server's tools, compiles supported schemas into actions, and explains every unsupported tool instead of silently dropping it.
pip install -e ".[mcp]"
s1 tools --mcp "python -m systemone_harness.envs.order_mcp"
s1 run --mcp "python -m systemone_harness.envs.order_mcp --scenario ship_fastest_gift" \
  --goal "Order B-220 is a gift. Ship it by the fastest carrier."
An observe tool provides state. An optional reset tool starts a run. Every other compatible tool becomes an action. MCP annotations determine whether the action is read, write, or destructive.
Drive a browser
The browser environment uses Browser Use to turn visible DOM controls into a finite action space. Text comes from named values supplied by the caller. The model chooses values by name and never writes them.
pip install -e ".[browser]"
s1 run --browser --headless --start-url https://example.com/book \
  --text name=Customer --text [email protected] \
  --goal "Book a table at 19:30 with a window seat."
input                  → goal
function_call          → selected action
function_call_output   → environment result
reasoning              → distribution and gate verdict
previous_response_id   → continued environment and history
Streaming emits each item as it happens. Cancellation lets the current model step finish and records it. The included report passes all 40 checks in the UHP core conformance class.
Five live runs per scenario on 2026-09-19 with typesafe/jev-1.13-20260917 through OpenRouter:
Scenario
Goal met
Mean steps
Mean model latency
Mean wall time
Cost per run
Ship by cheapest carrier
5/5
6.0
241 ms
1.45 s
$0.000265
Ship fastest and add gift note
5/5
5.0
199 ms
0.99 s
$0.000214
Cancel a fraudulent order
5/5
1.0
197 ms
0.20 s
$0.000044
The benchmark proves the controller, compiler, gate, and model can complete these small deterministic tasks. It does not claim the same result for ambiguous state, arithmetic, dates, or long irrelevant context.
Everything that shapes the reflex's decisions except the model and the world is one versioned
YAML, the action-space file extended: version, instructions, gate, encoder, tunables
(numbers an environment's rendering reads), the optional declared actions, and an objective
(what the environment counts as success, failure, ordered metrics and place). Skills, directories
of SKILL.md, are compiled into the instructions once per load, since a reflex cannot open a file
mid-step. The trace carries the configuration's version.
s1 run --mcp ./bin/env --config config.yaml --skills ./skills --goal "..." --json trace.json
s1 run --mcp ./bin/env --config config.yaml --script "run_right,jump_right,jump_right"   # a probe
s1 bench --mcp ./bin/env --config config.yaml --runs 3 --json-dir traces/               # one at a time, then the report
s1 report --config config.yaml traces/run-*.json                                        # scoreboard and failure groups
A run that ends because the reflex could not decide (no_confident_action, or escalate chosen)
carries a handoff on its record: the state it refused on, the questions, its answers with their
probabilities, the weakest judgment and the threshold it failed. That is the branch for whoever
takes over, a reasoning harness or a person. docs/dual-loop.md describes the outer loop that
uses all of this to improve a configuration version by version.
Command line
s1 run    Run one goal against a built-in, process, MCP, or browser environment
s1 tools  Inspect how an MCP server compiles into supported actions
s1 serve  Expose a configured loop as a UHP server
s1 bench  Run the built-in live benchmark
Use s1 <command> --help for every option. Add --json trace.json to run, tools, or bench when you need machine-readable output.
Test
pip install -e . pytest
pytest -q tests
The suite covers action compilation, unsupported inputs, state truncation, confidence gates, every terminal reason, cancellation, continuation, MCP, browser actions, and the UHP server. Recorded model answers keep the default suite deterministic and keyless.
Project status
Version
0.3.1
Models
Jev through OpenRouter or TypeSafe directly
UHP
core, 40 of 40 checks
Environments
Python, stdio, MCP, browser, and real-time loops
Python
3.10 or newer
Next milestones are a systemone base in HarnessRouter, skills as loadable actions, the Chrome side panel as a plain UHP client, and the UHP extended conformance class.





 一个开源的 Python 框架,把 System One 决策模型变成一个智能体循环:它观察环境,把有限的动作空间编译成带类型的问题,用置信度把关每个决策,执行动作并记录完整的运行轨迹。